⏱️ BENCHMARK: 9.68s SOLVE
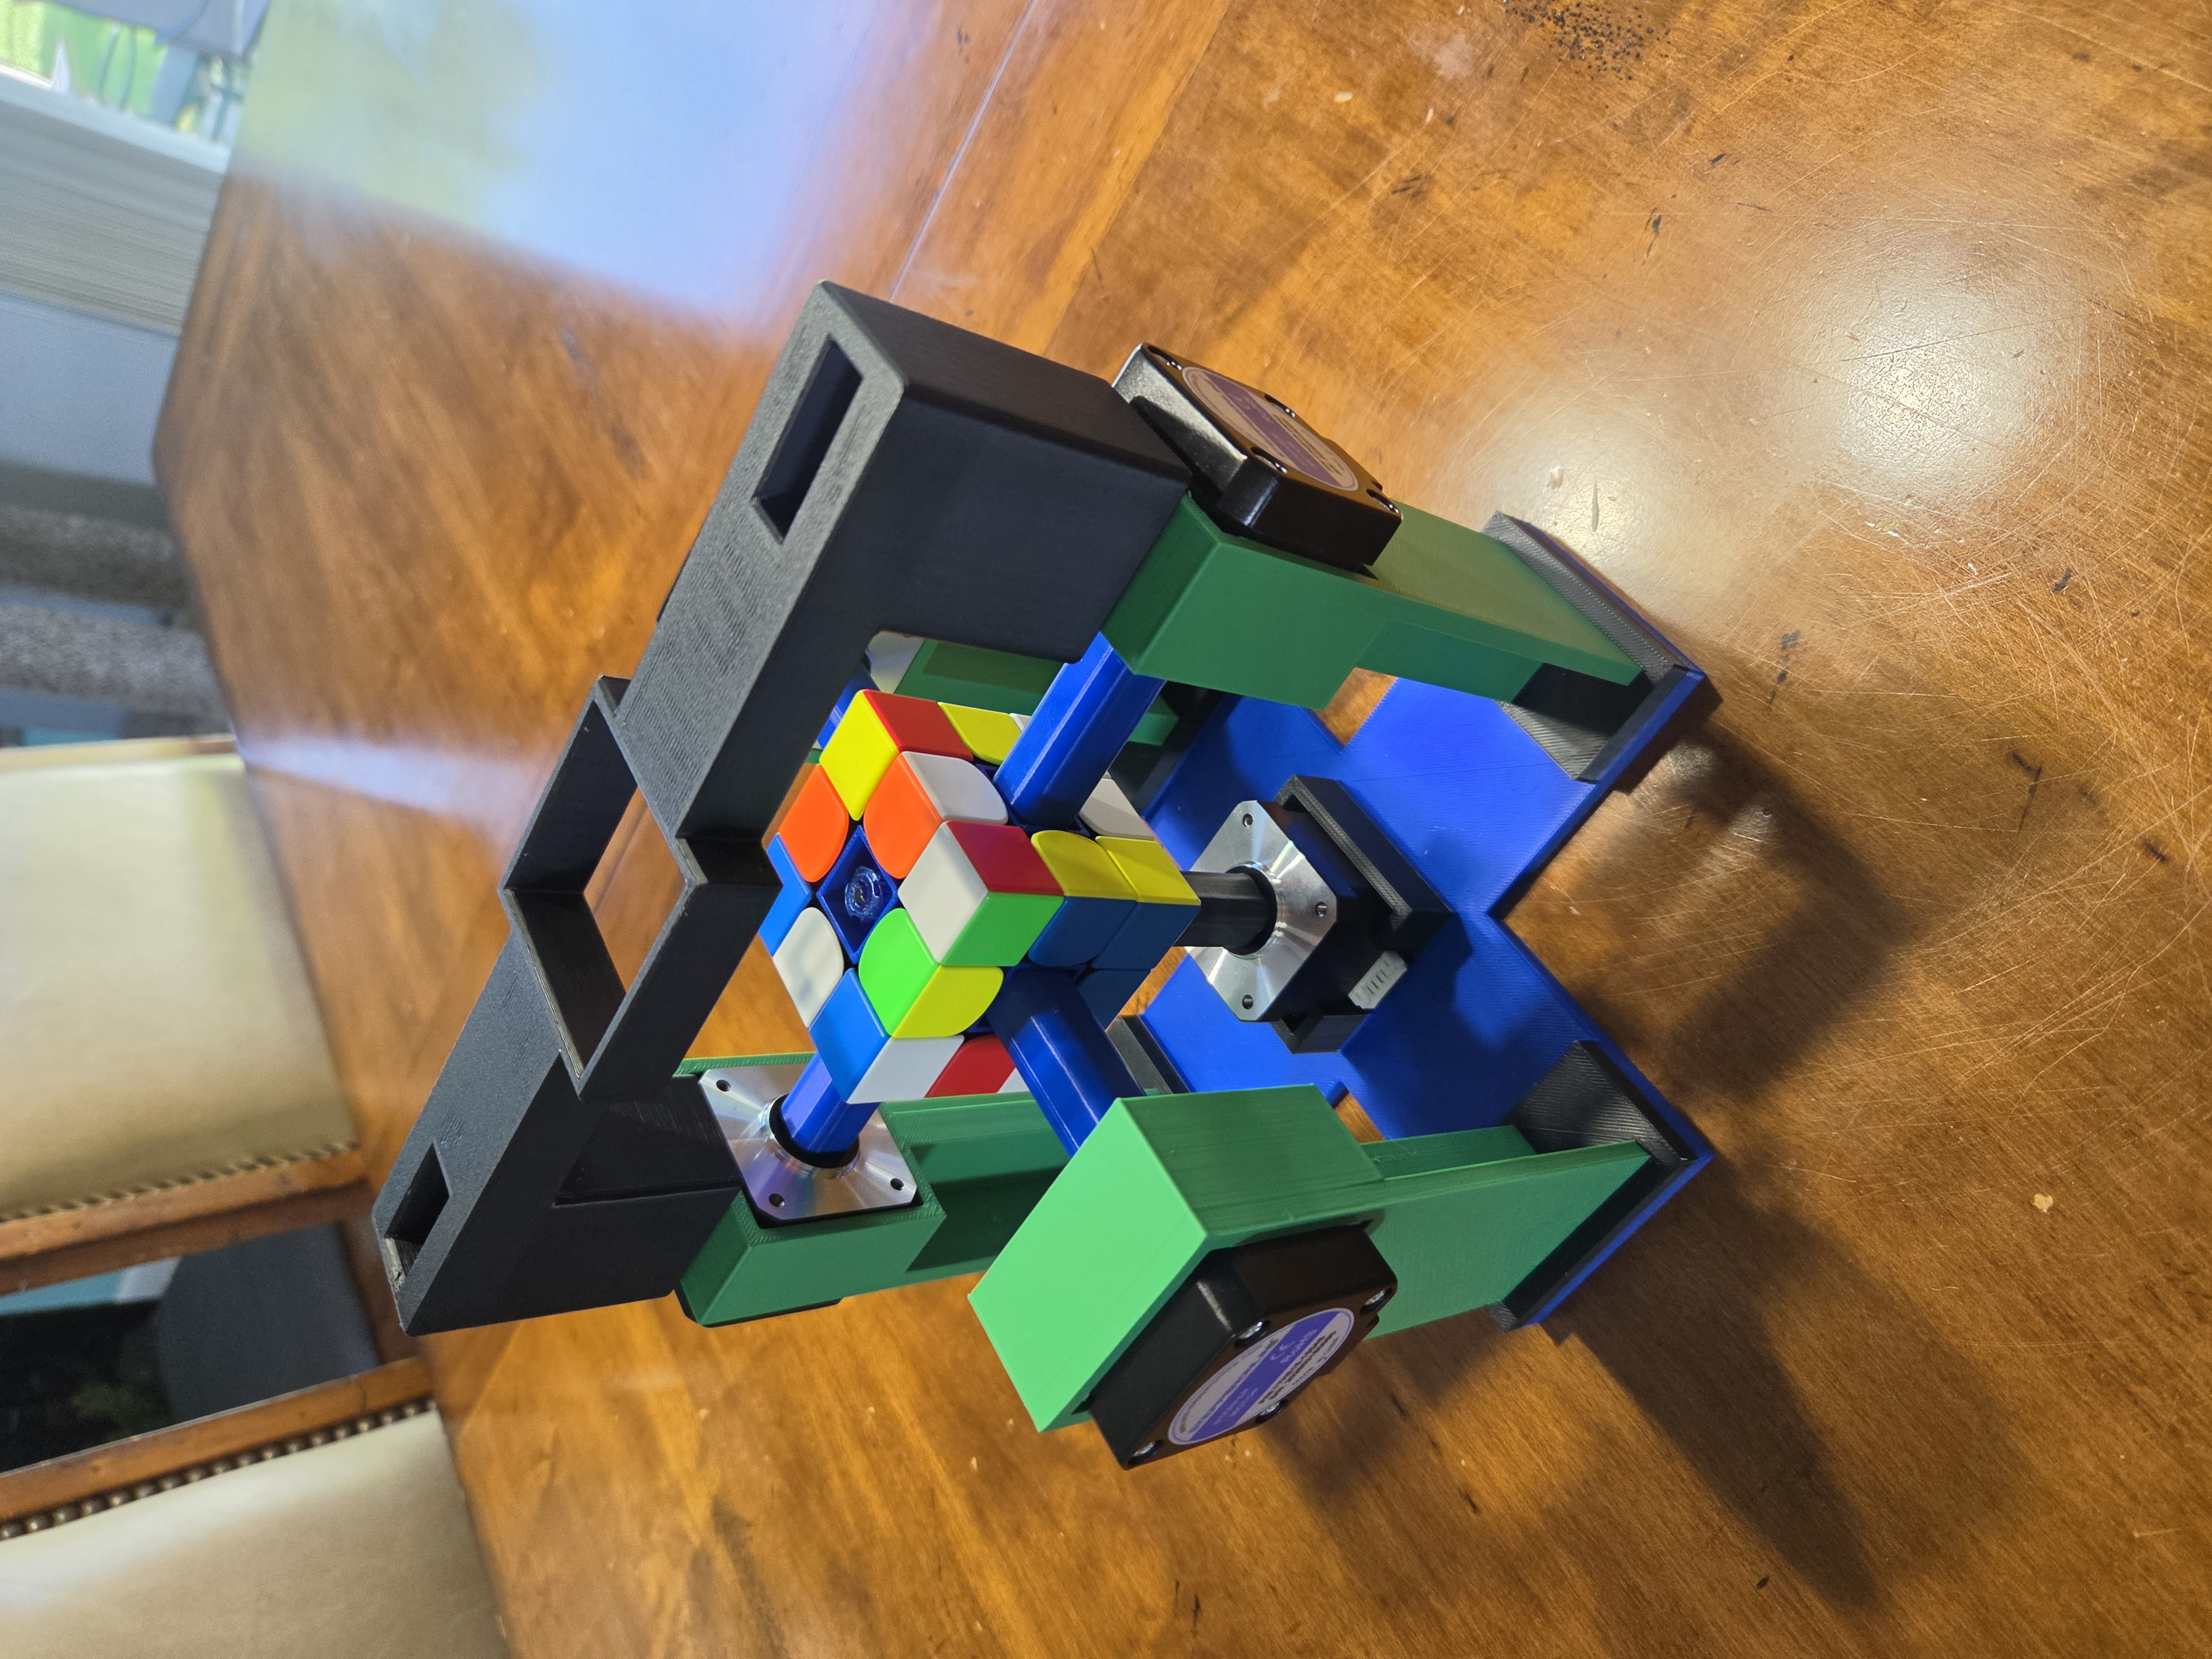
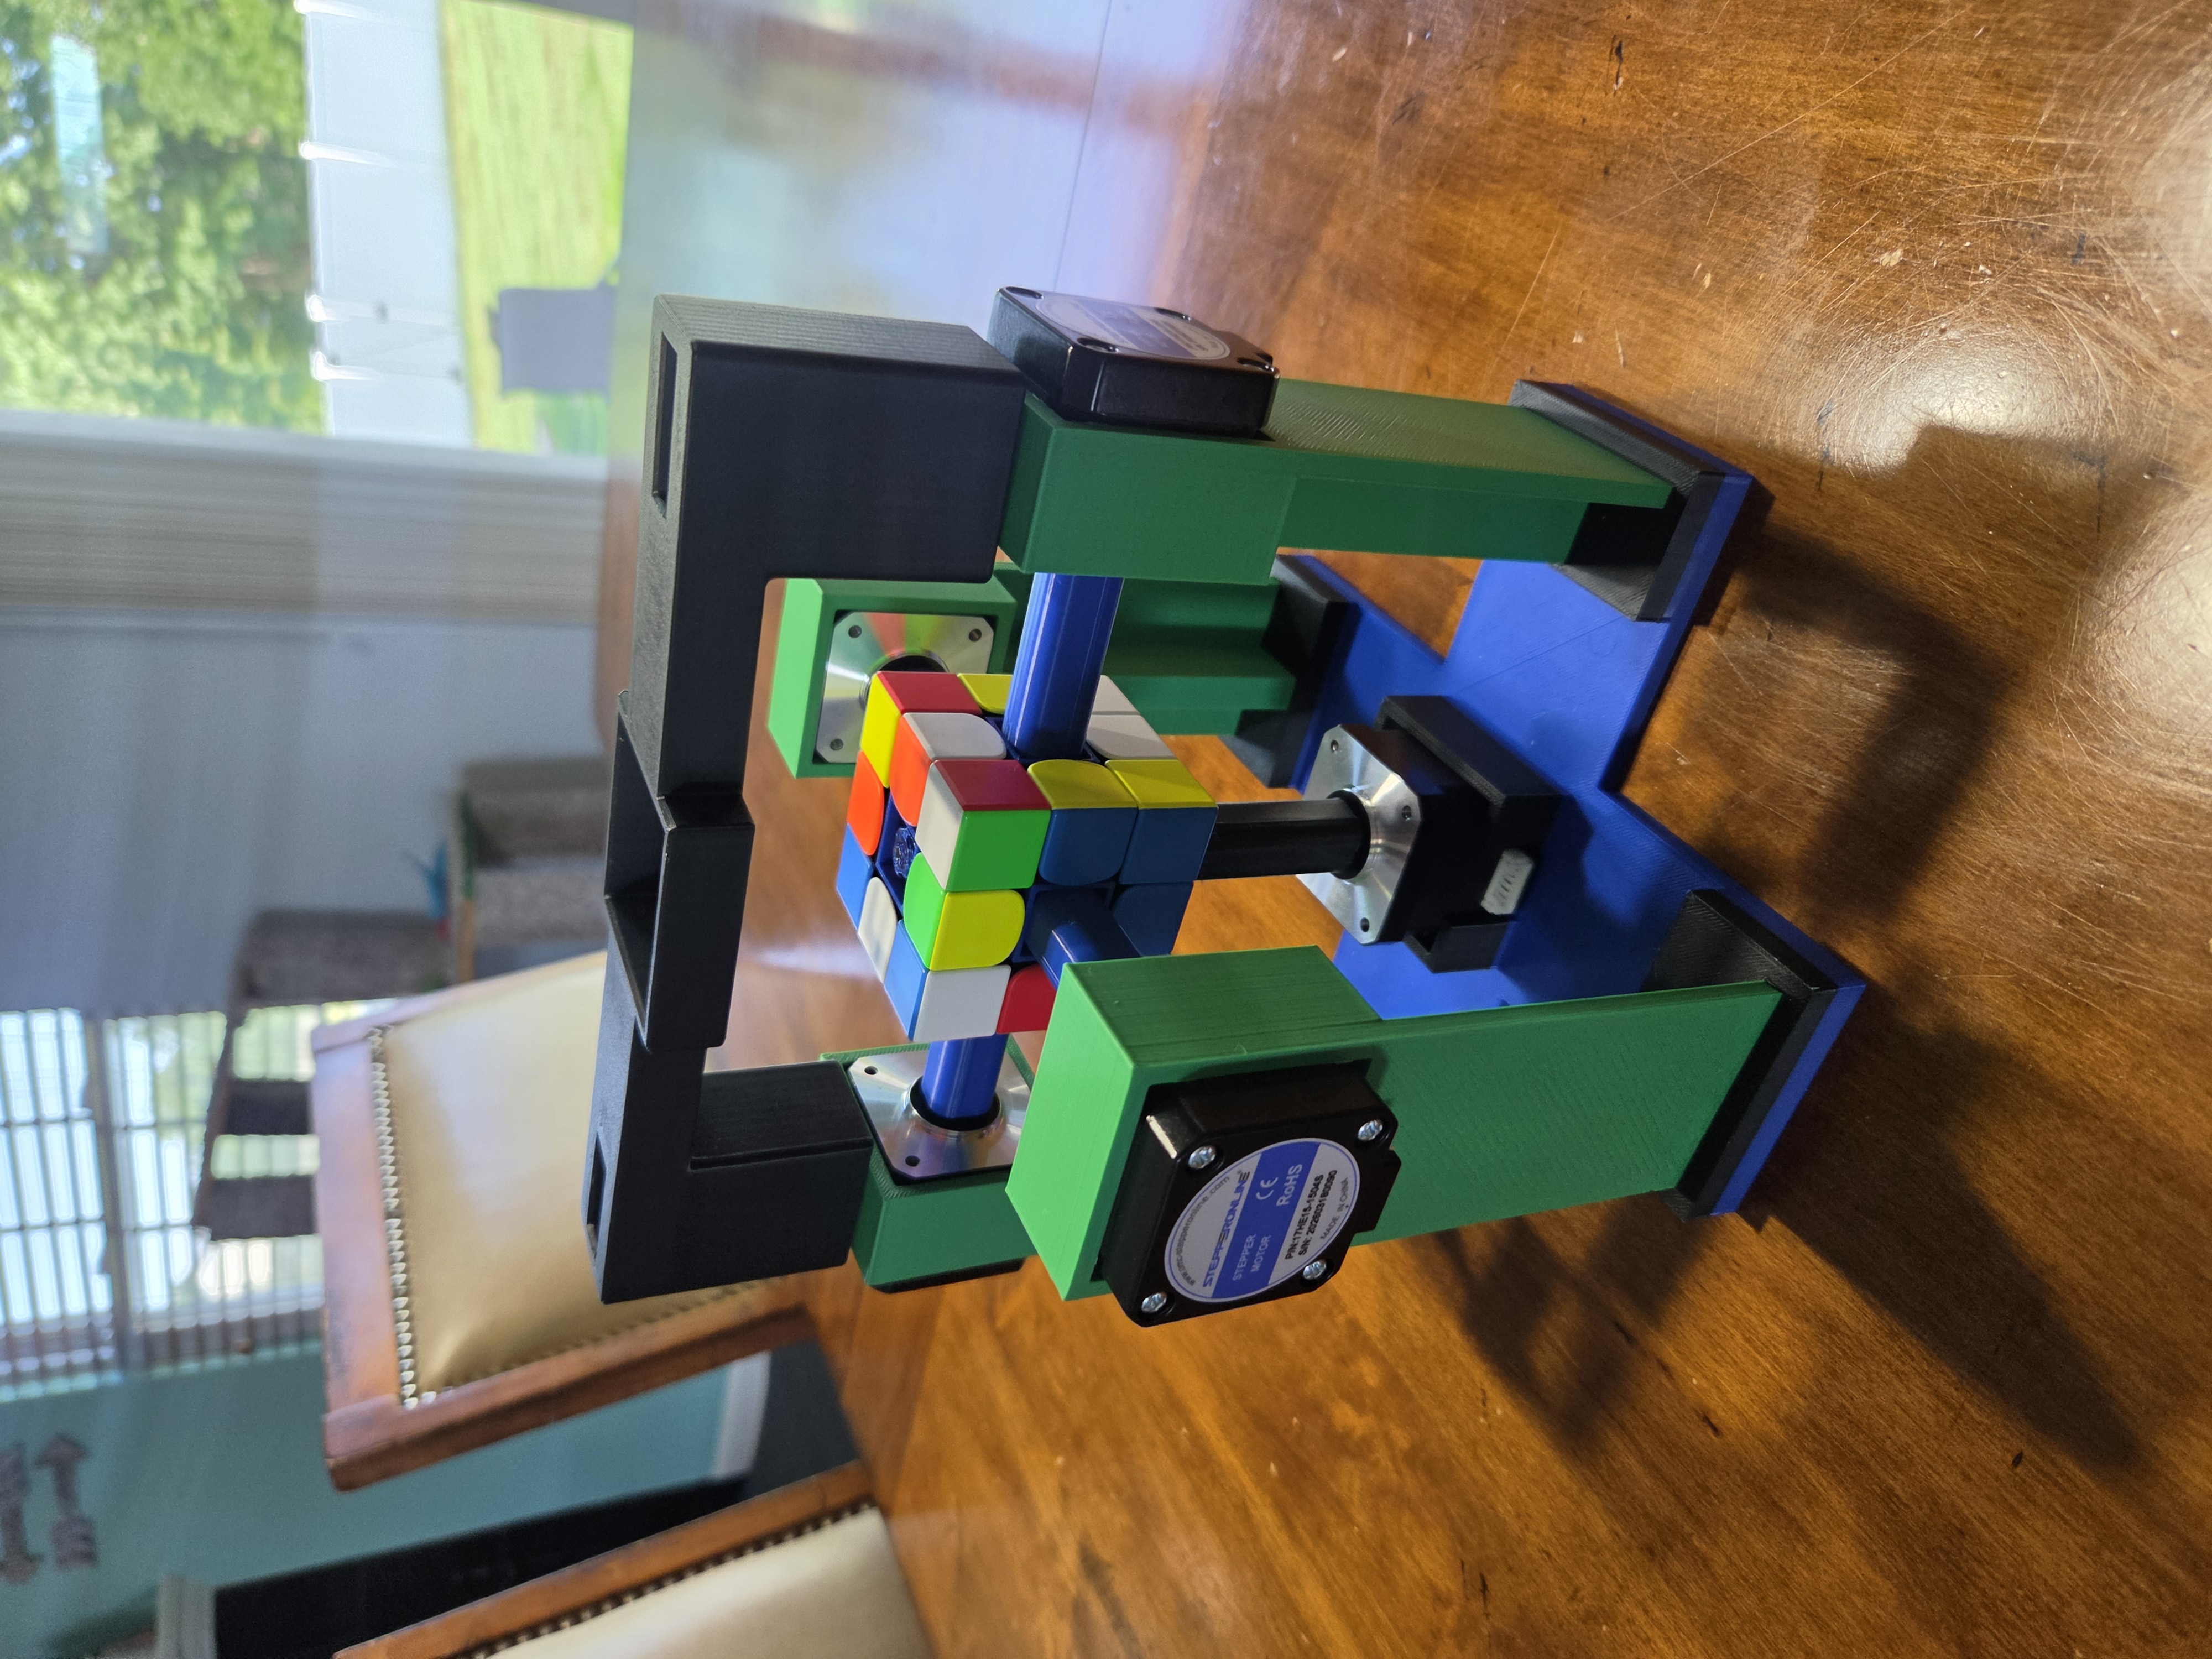
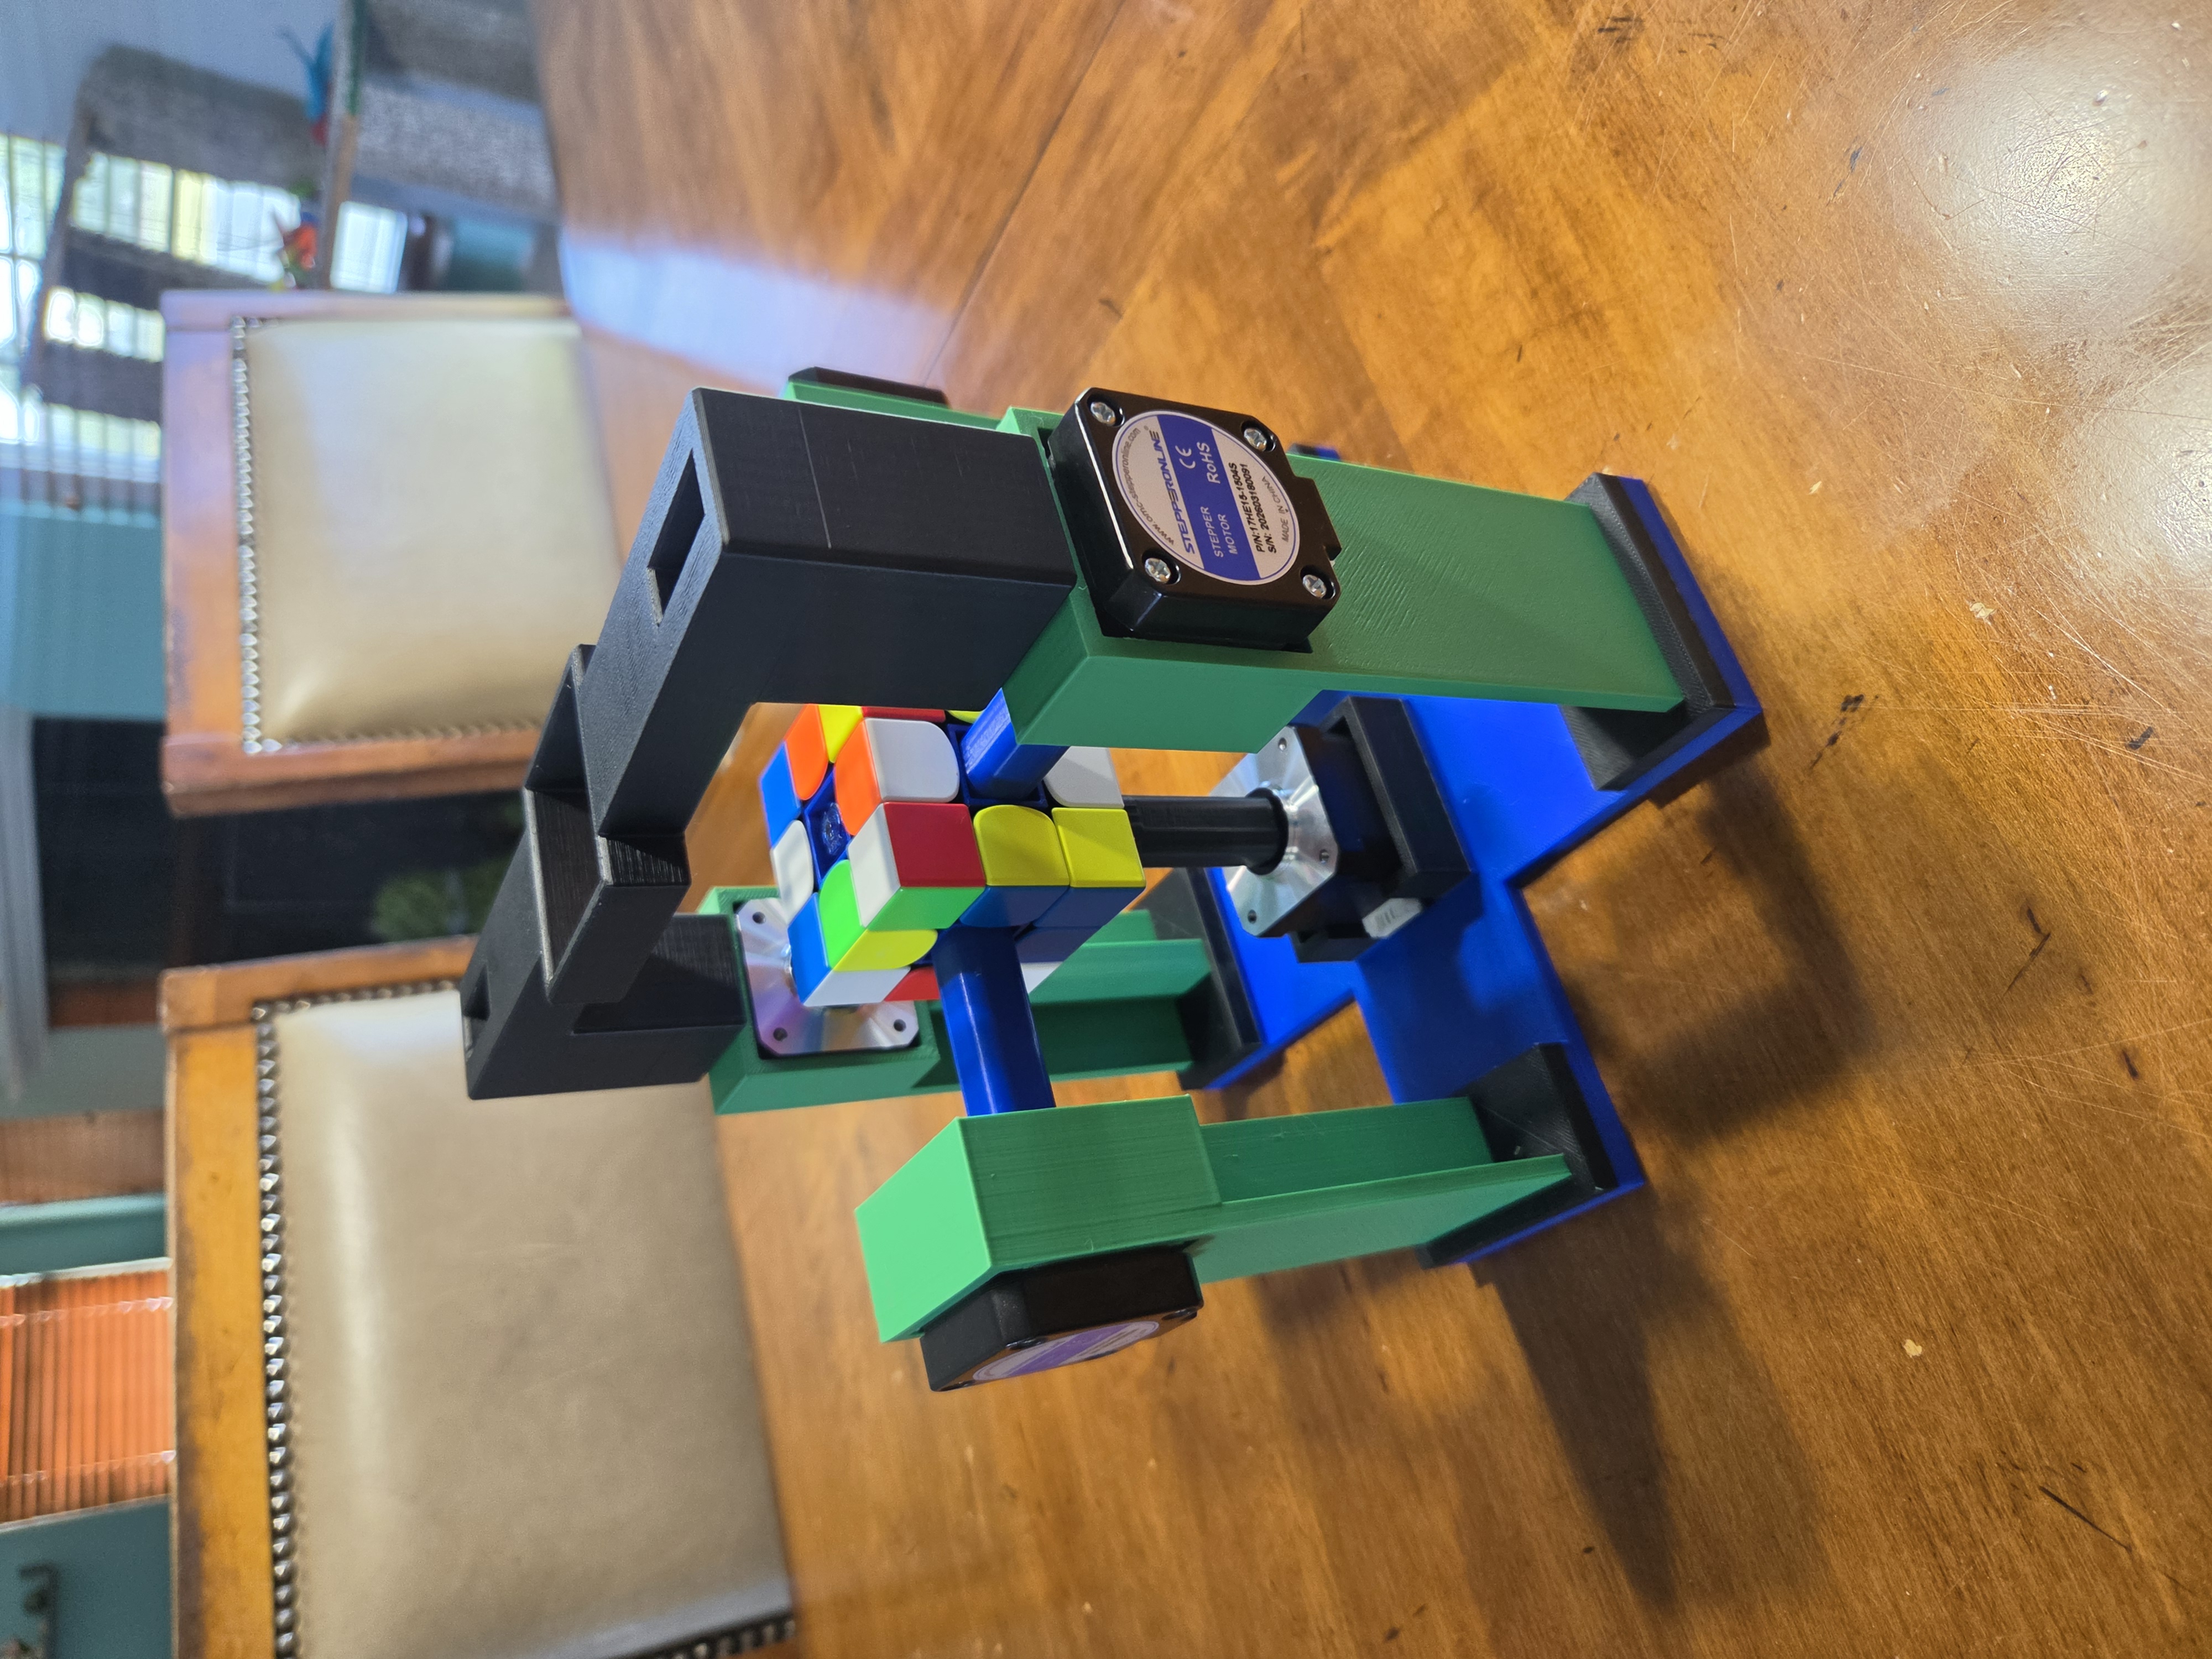
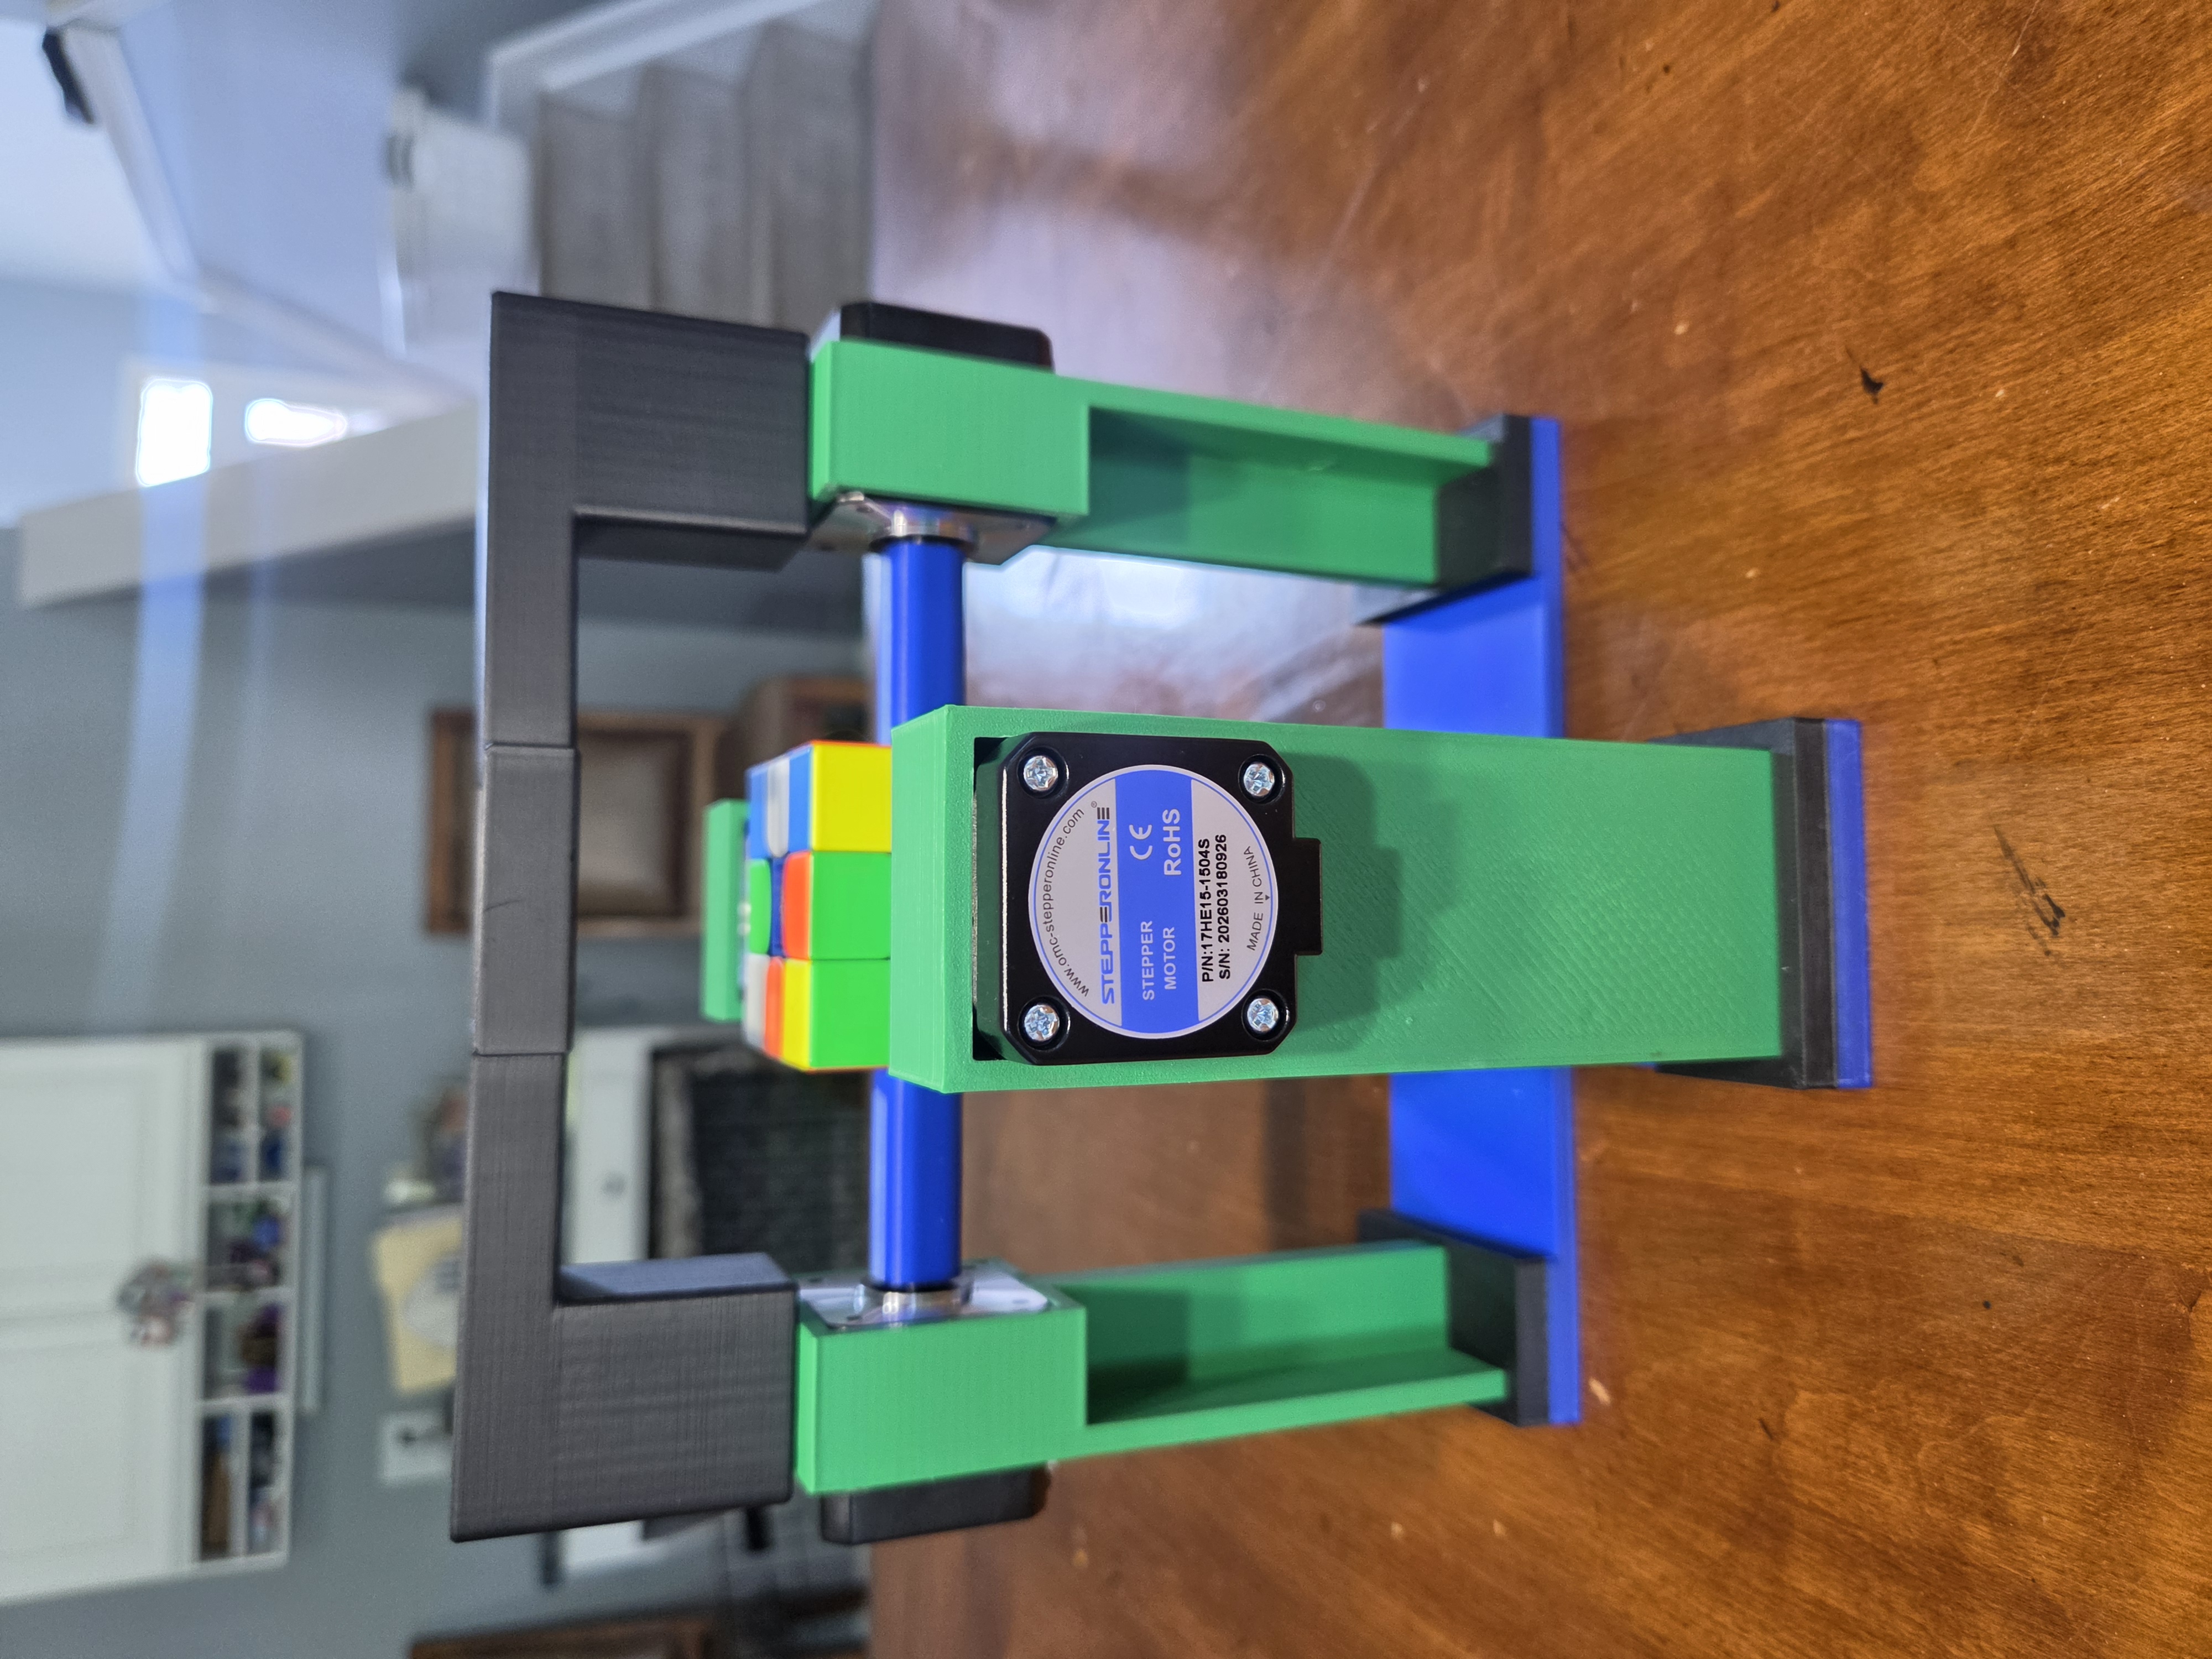
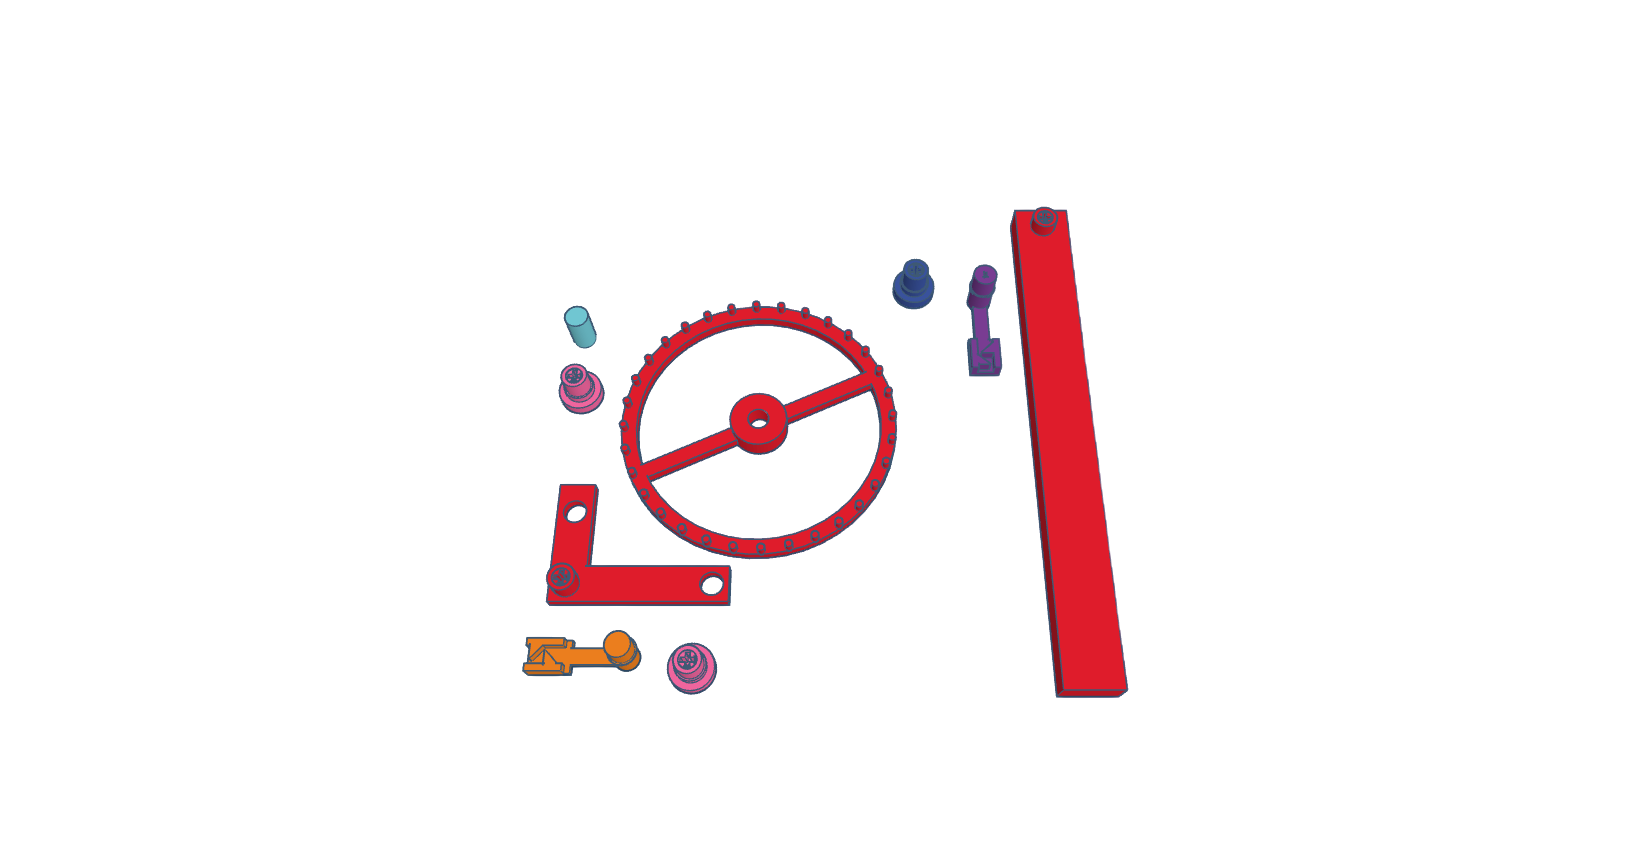
⚙️ Precision 3D Printed Subassemblies
(Ender 3 V3 KE)
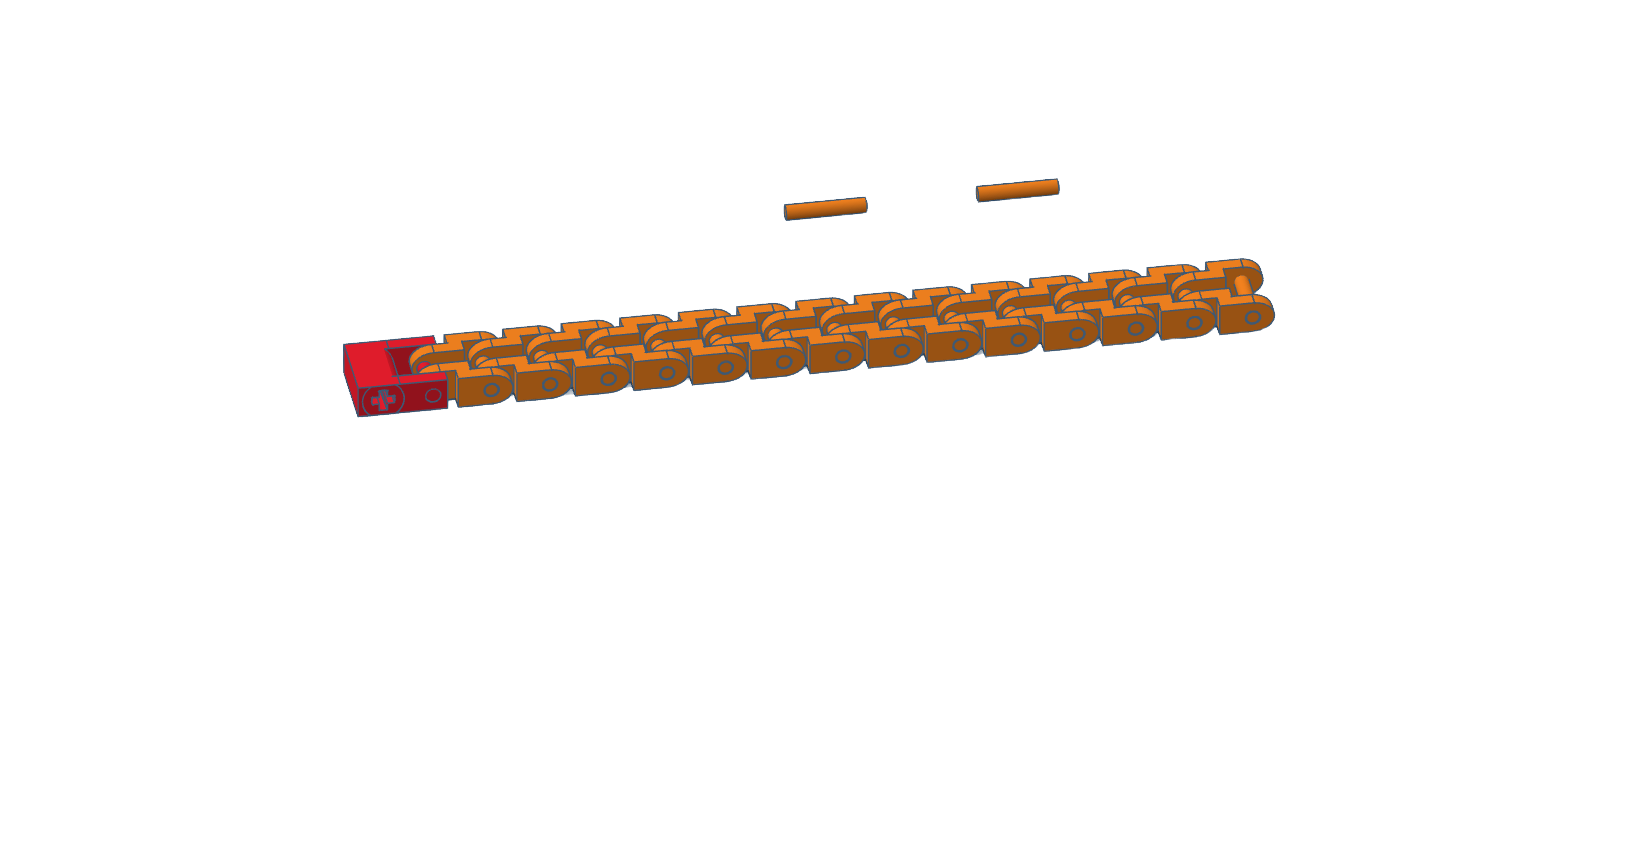
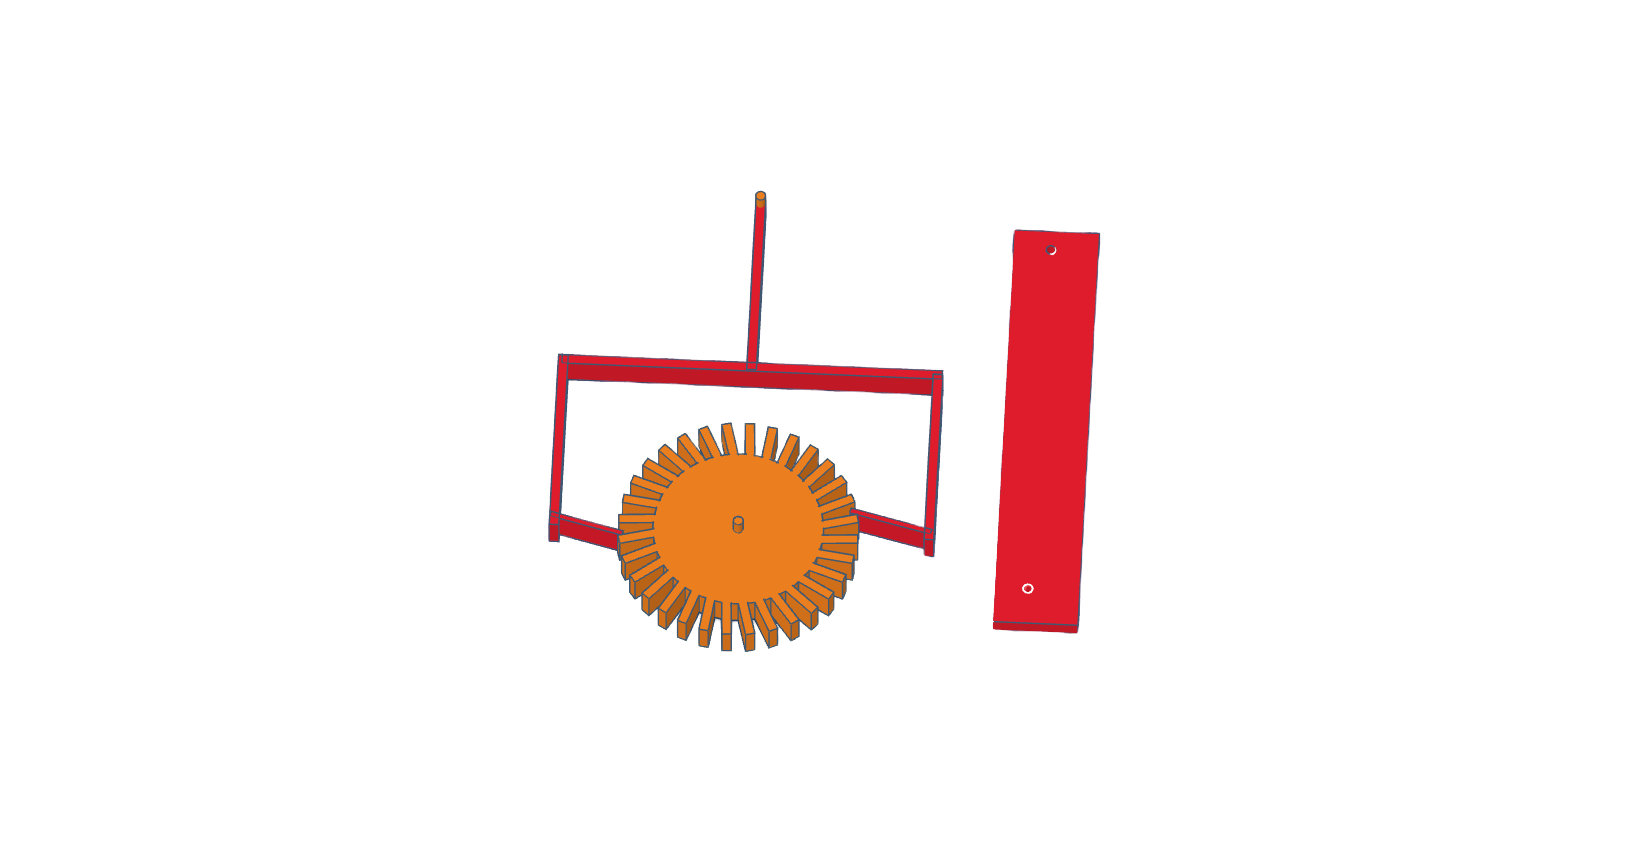
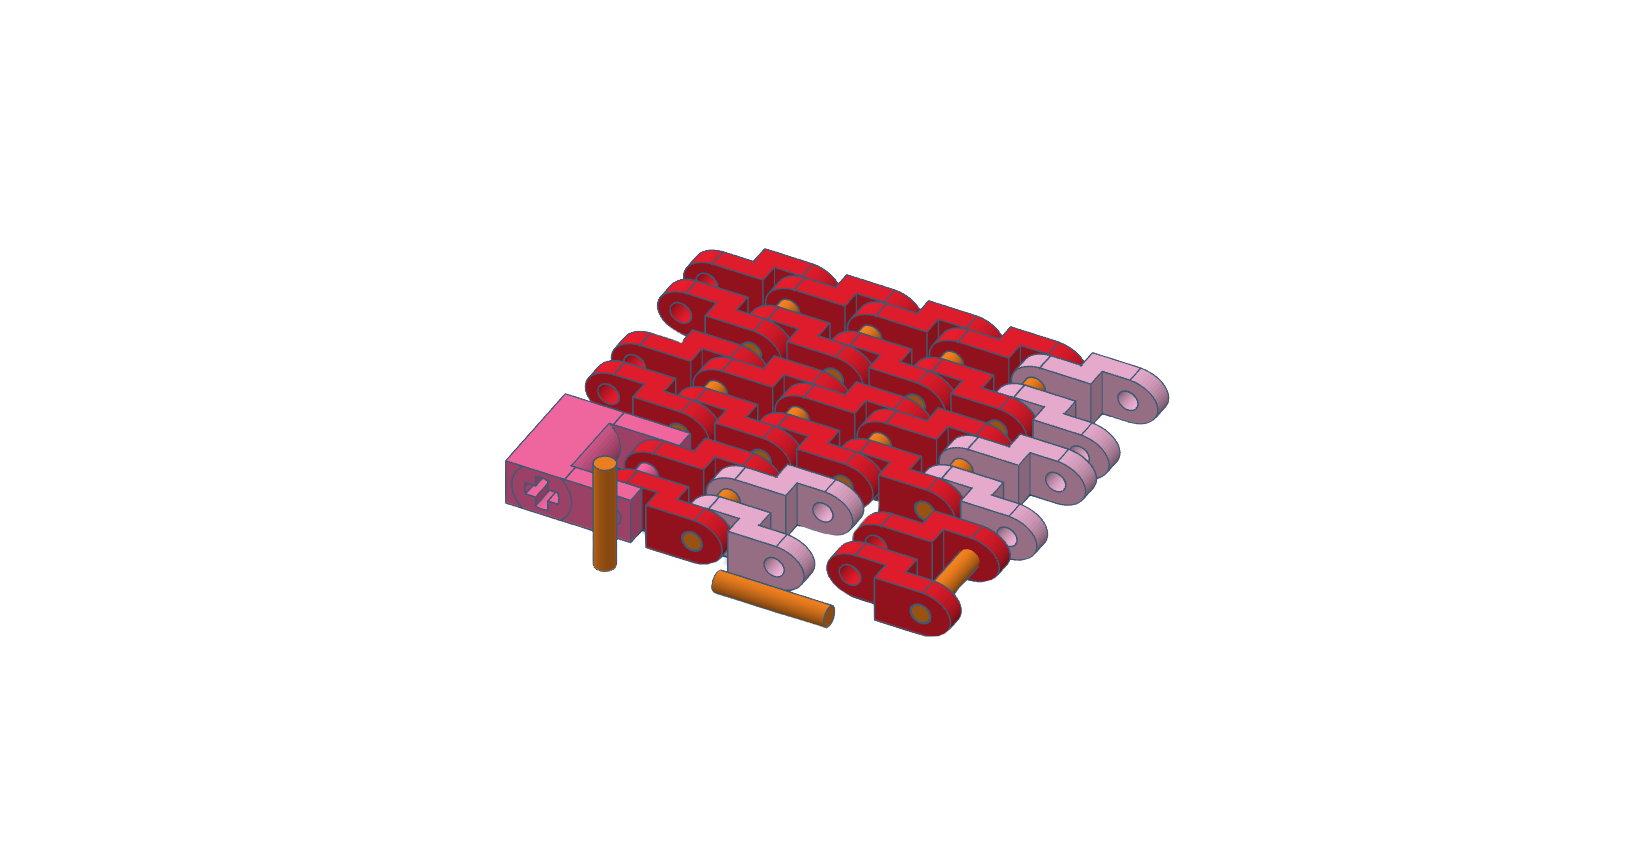
Click to inspect CAD fit & tolerances
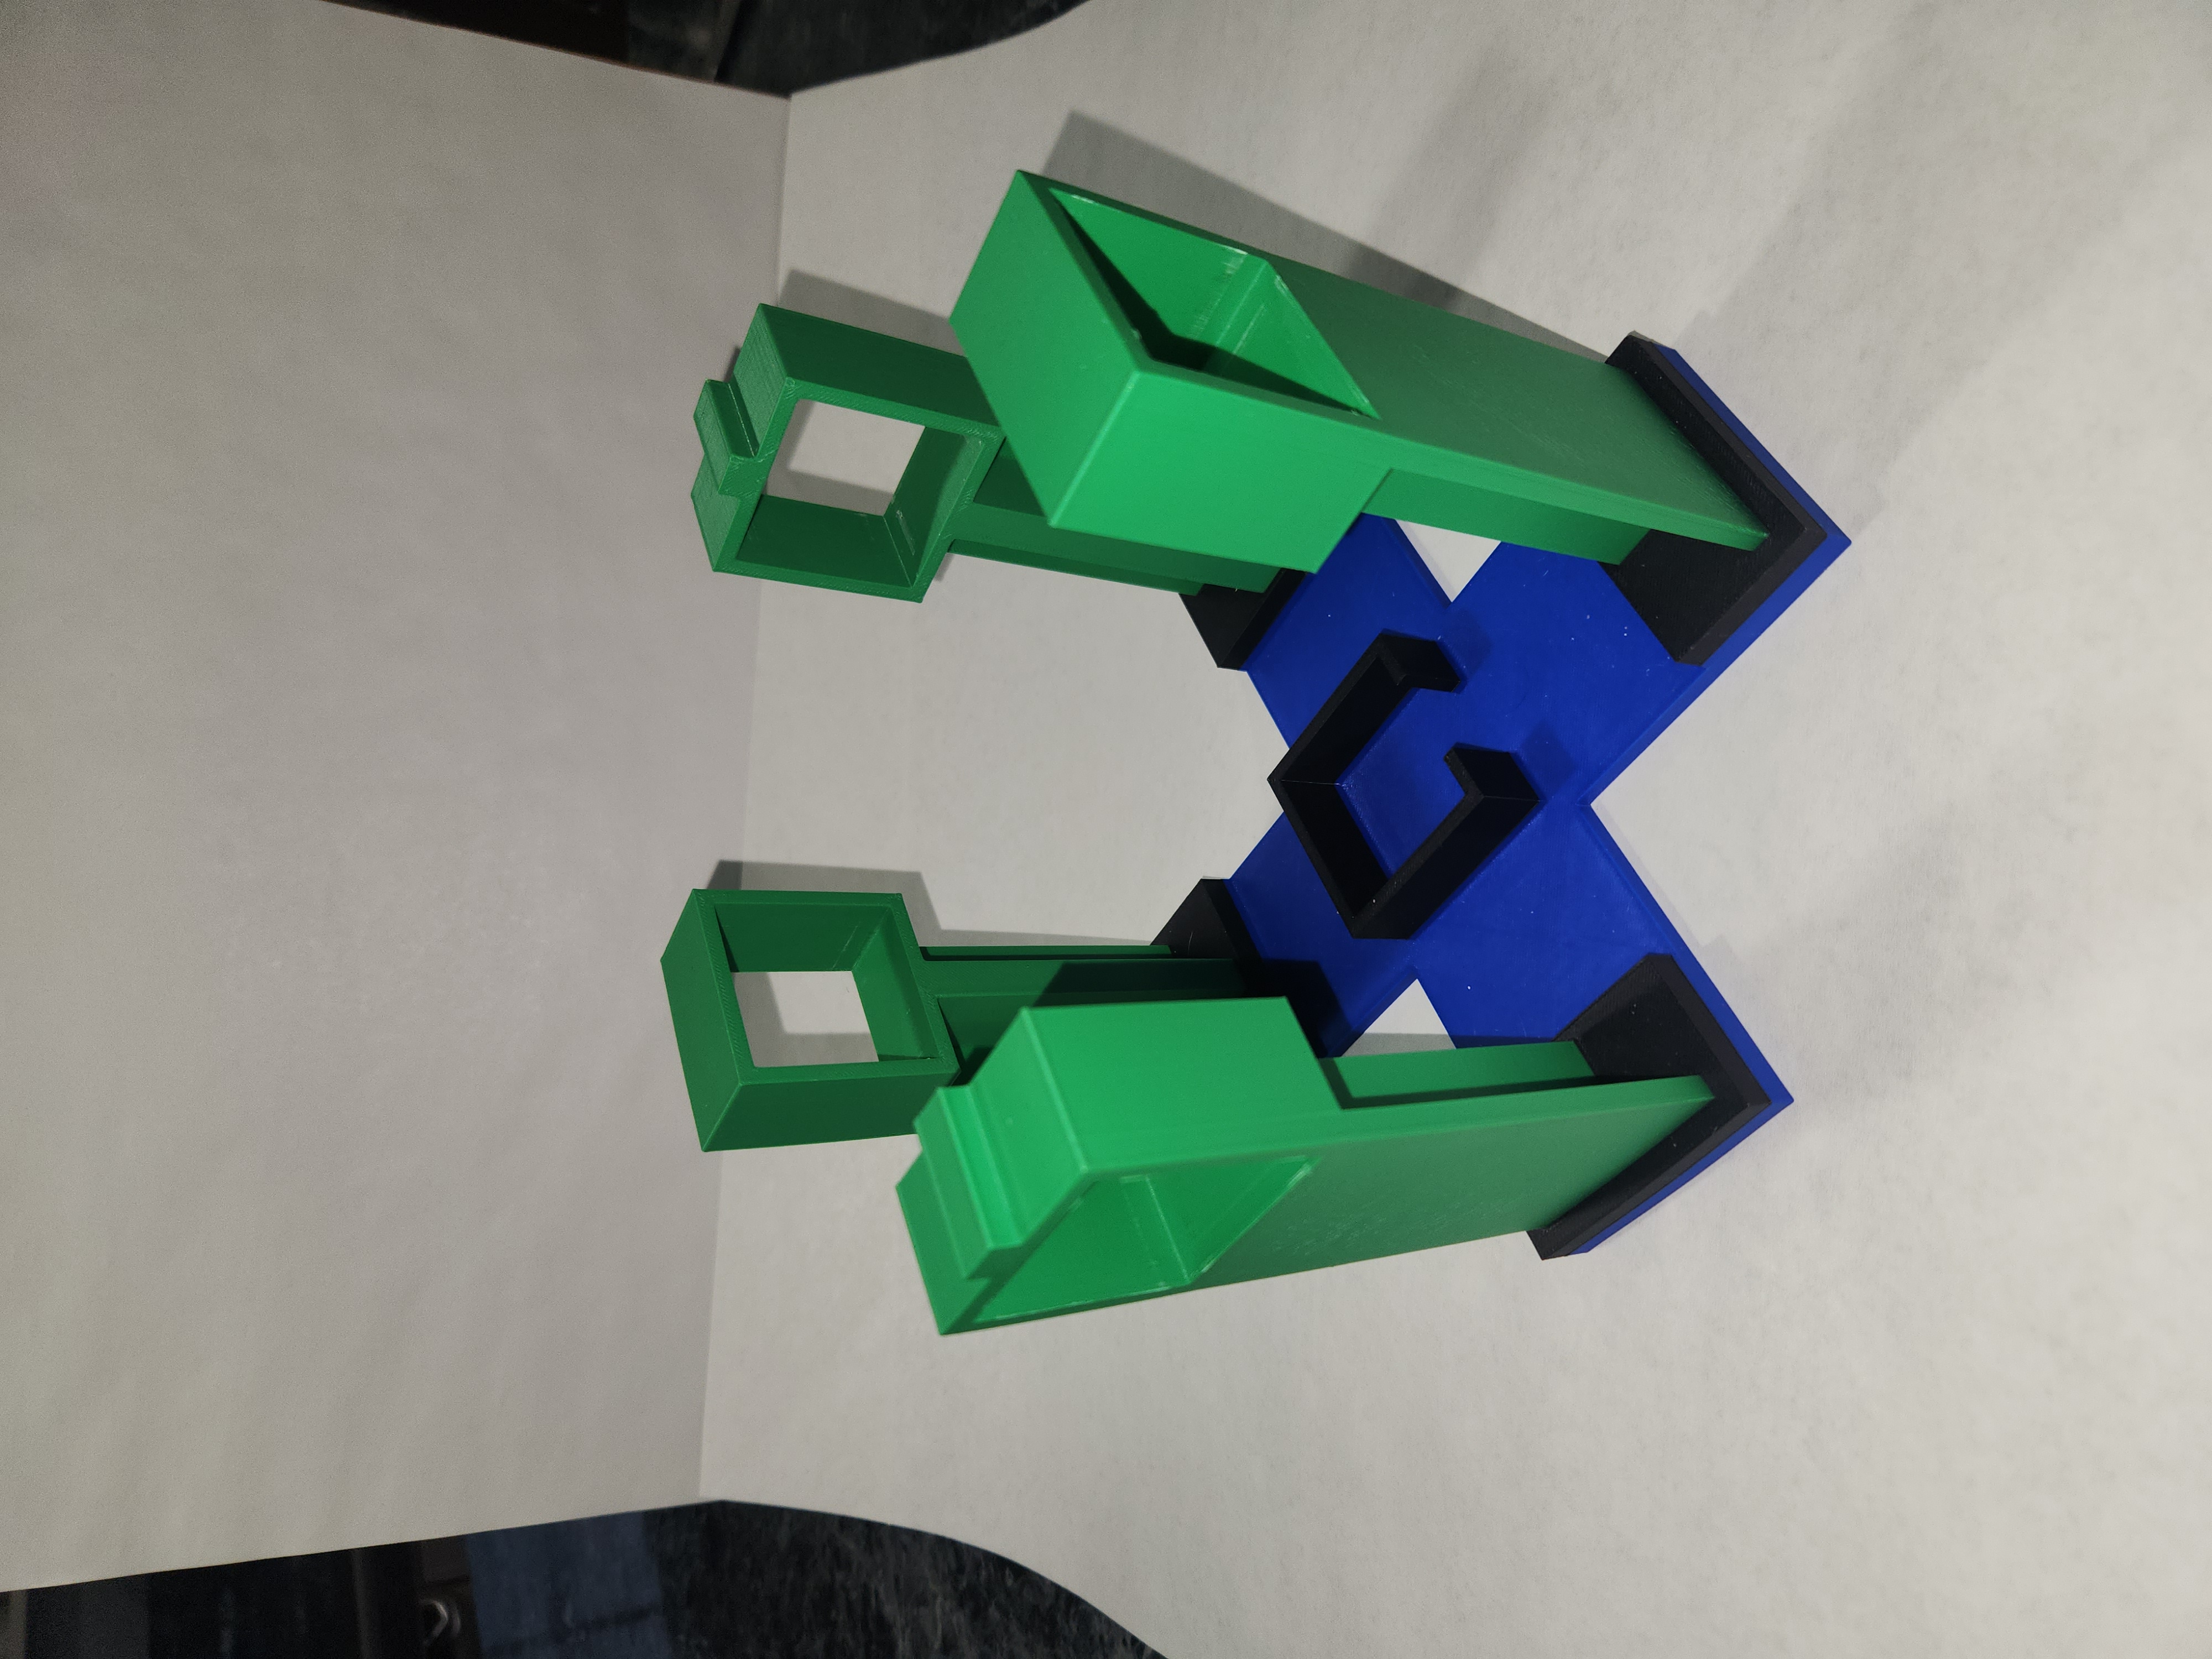
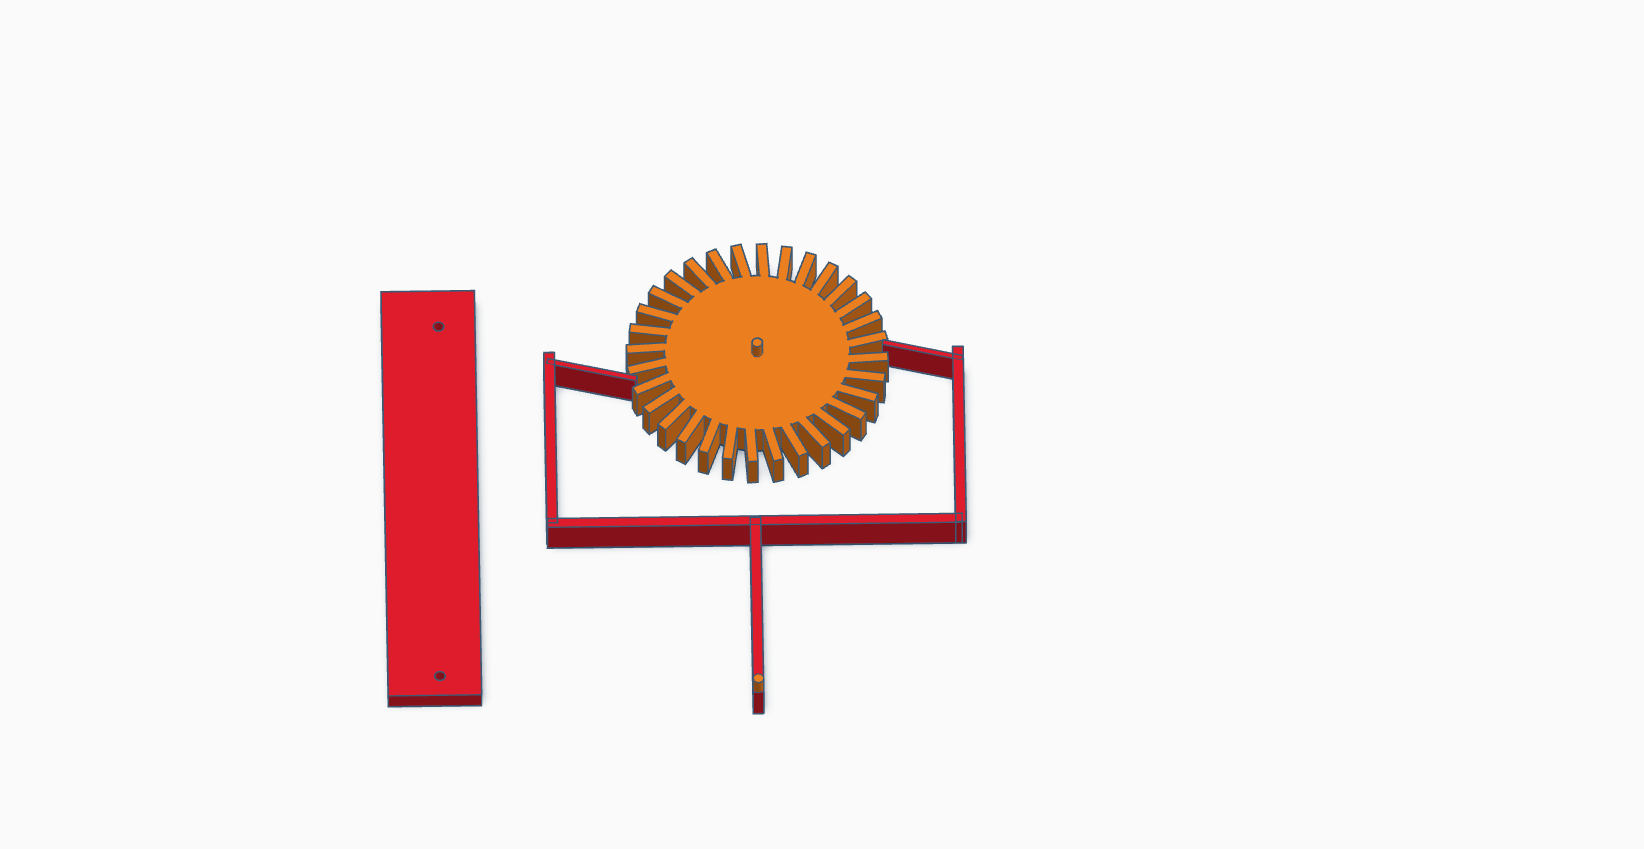
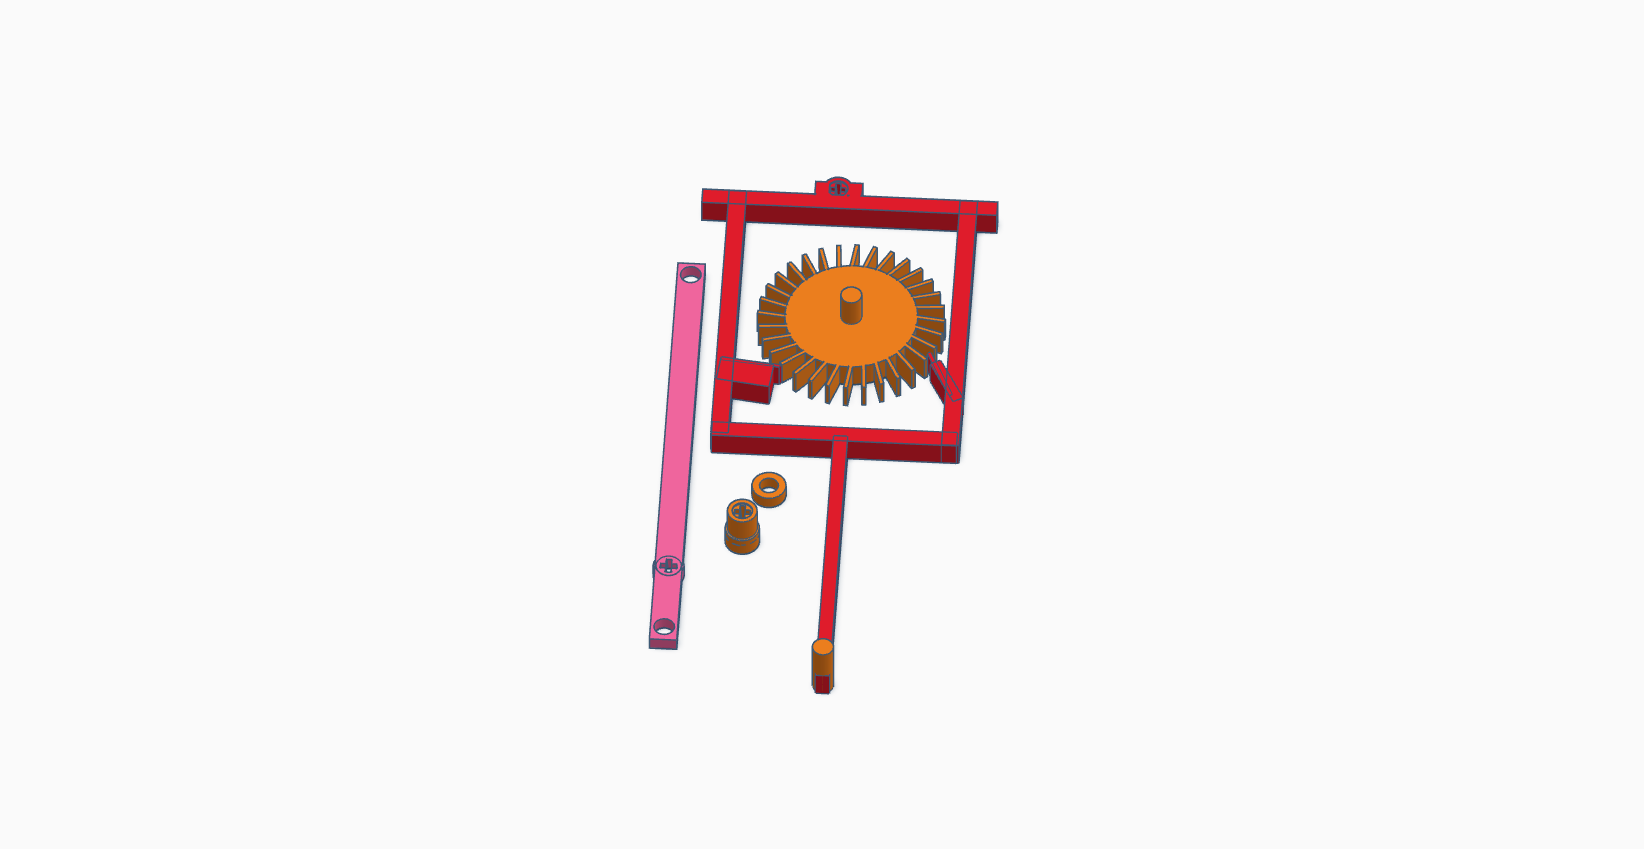
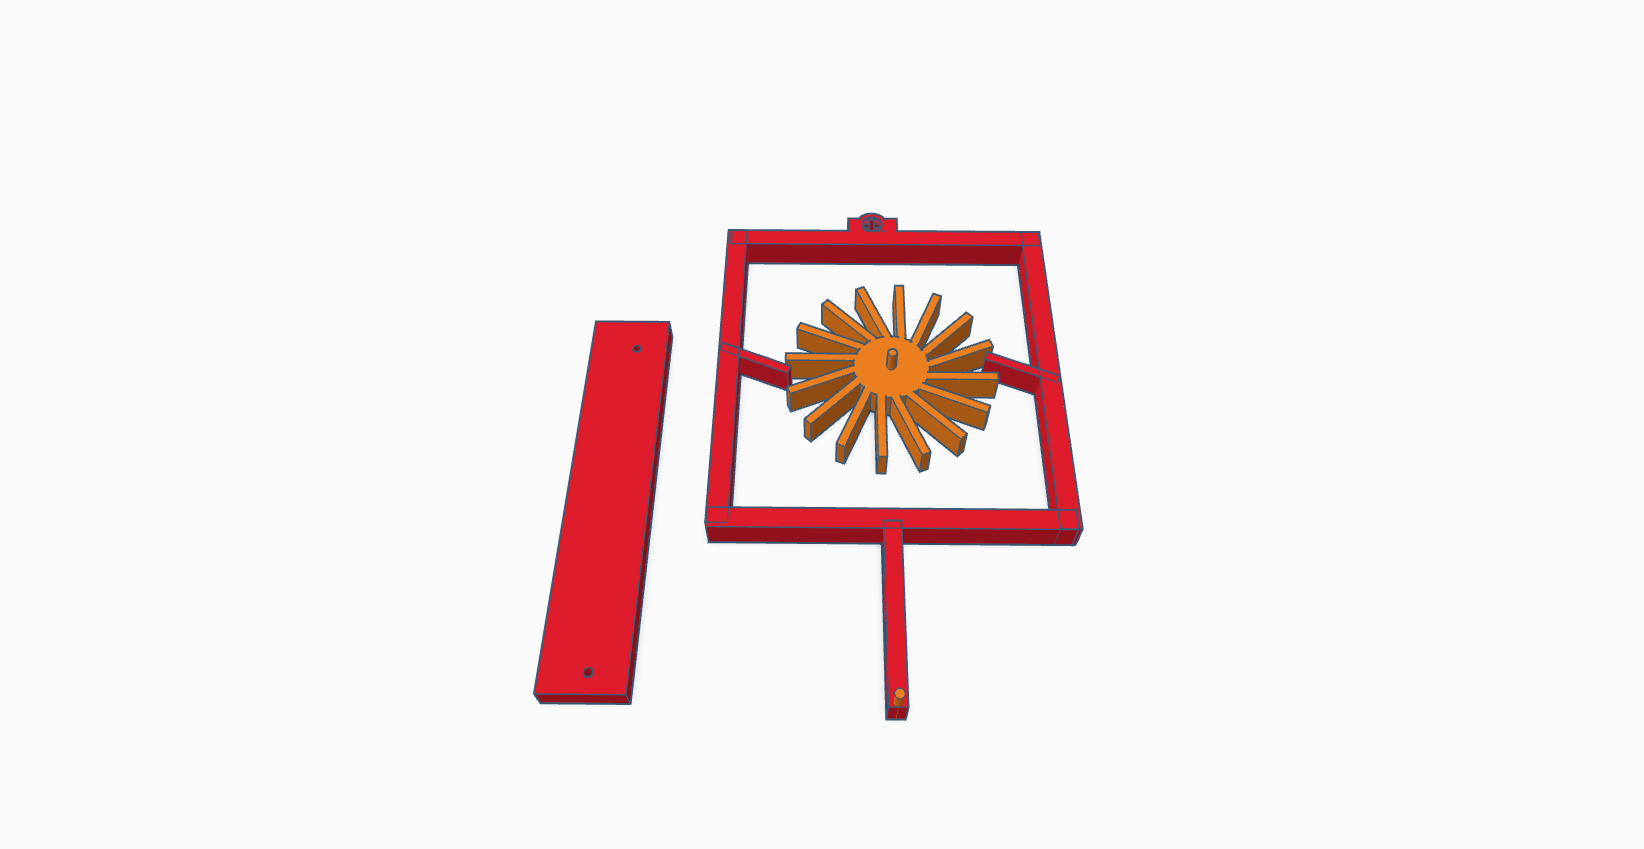
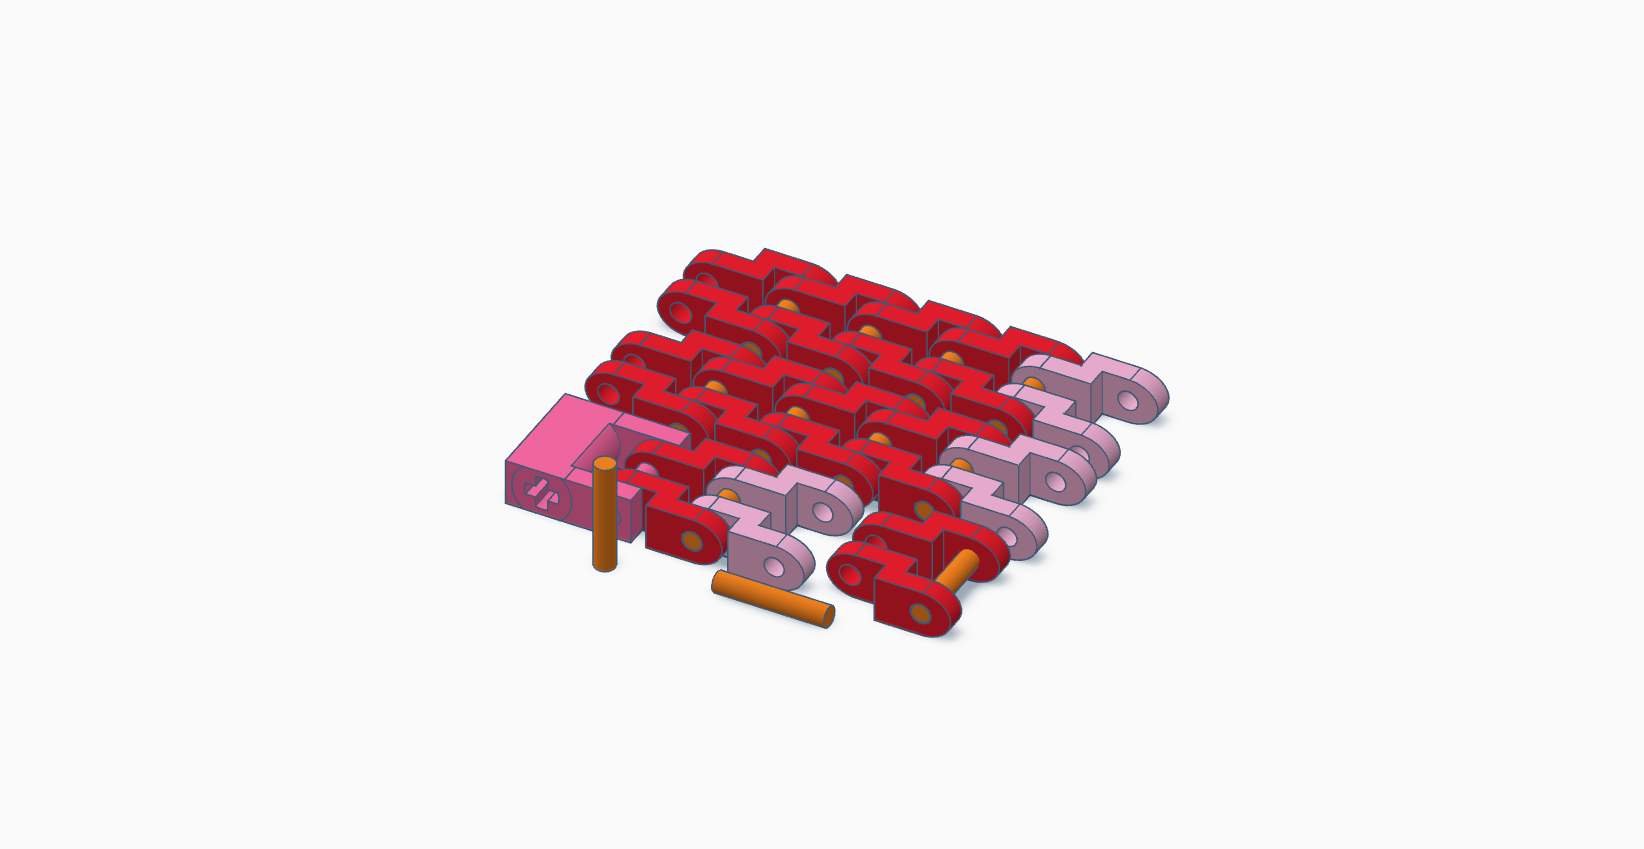
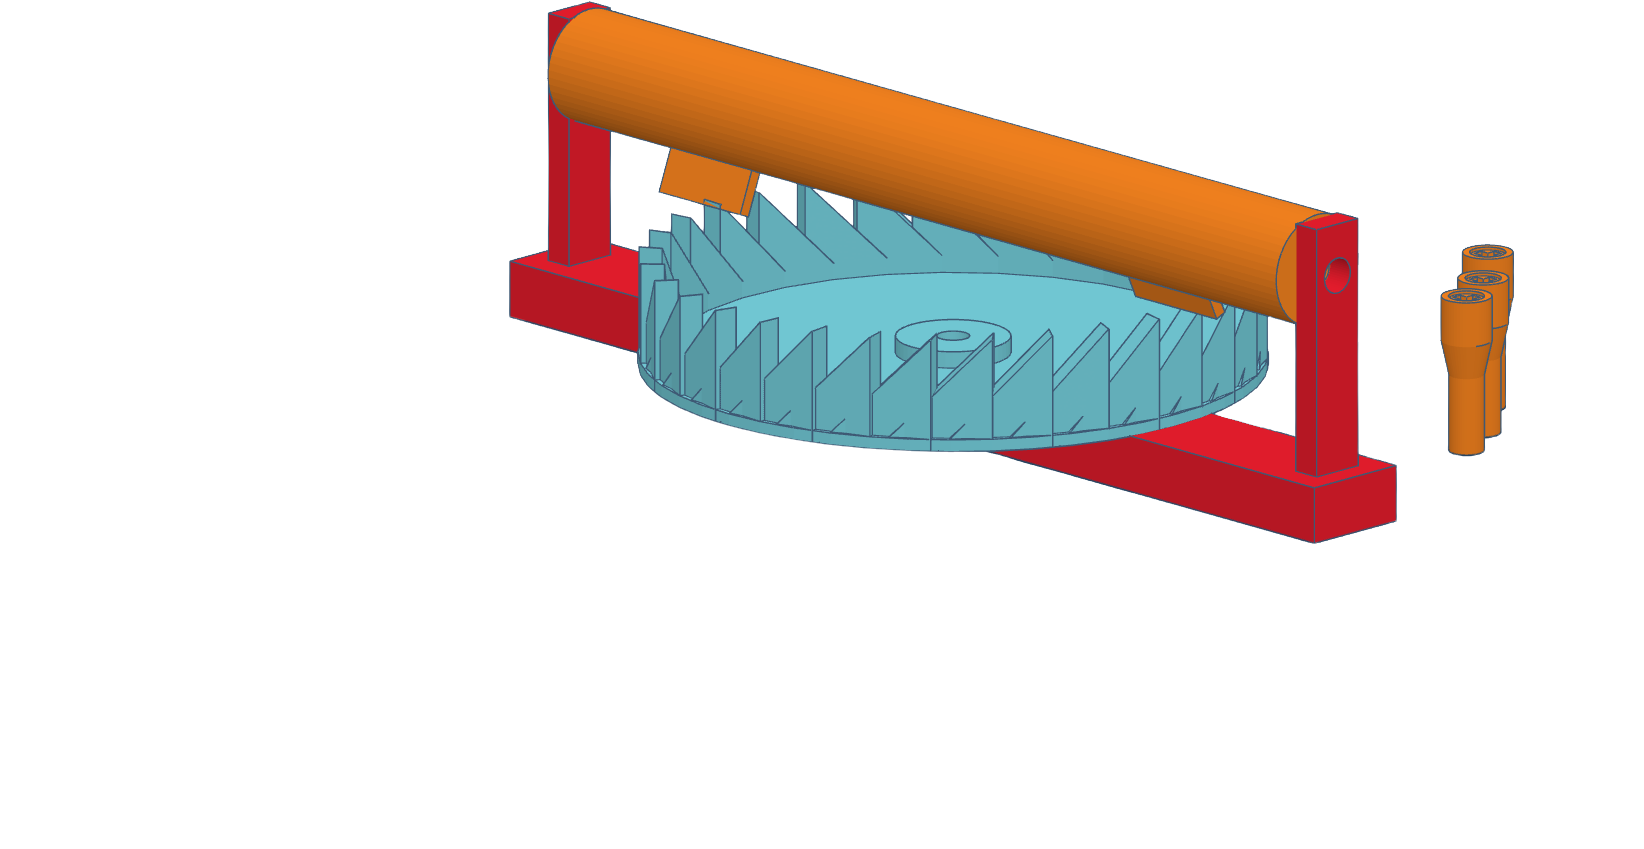
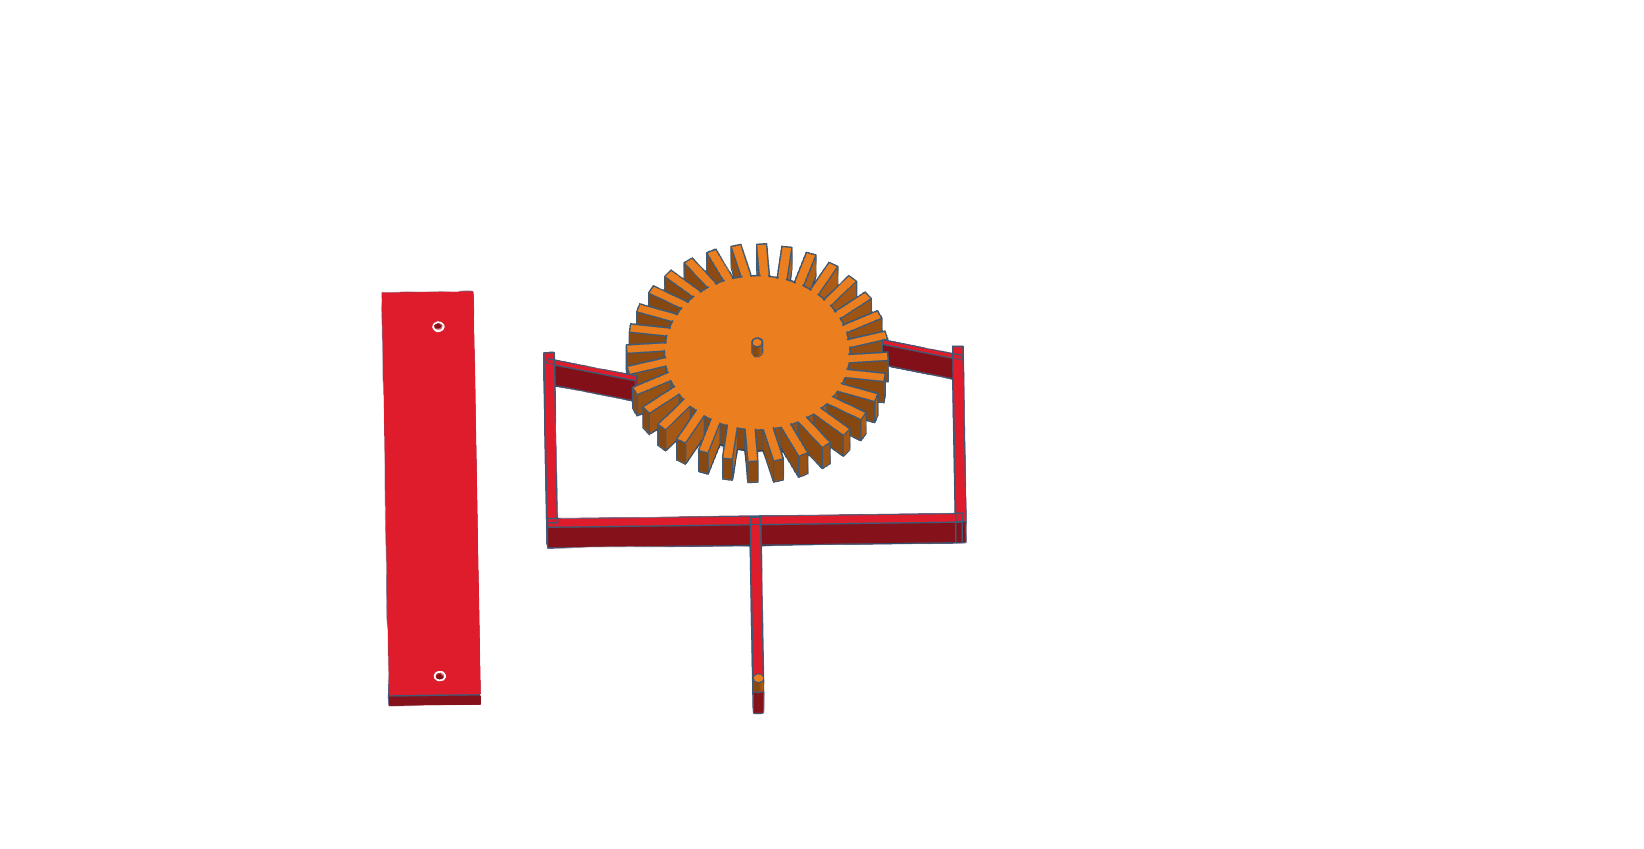
Modular Chassis & Riser Towers
Interlocking high-rigidity structural frame
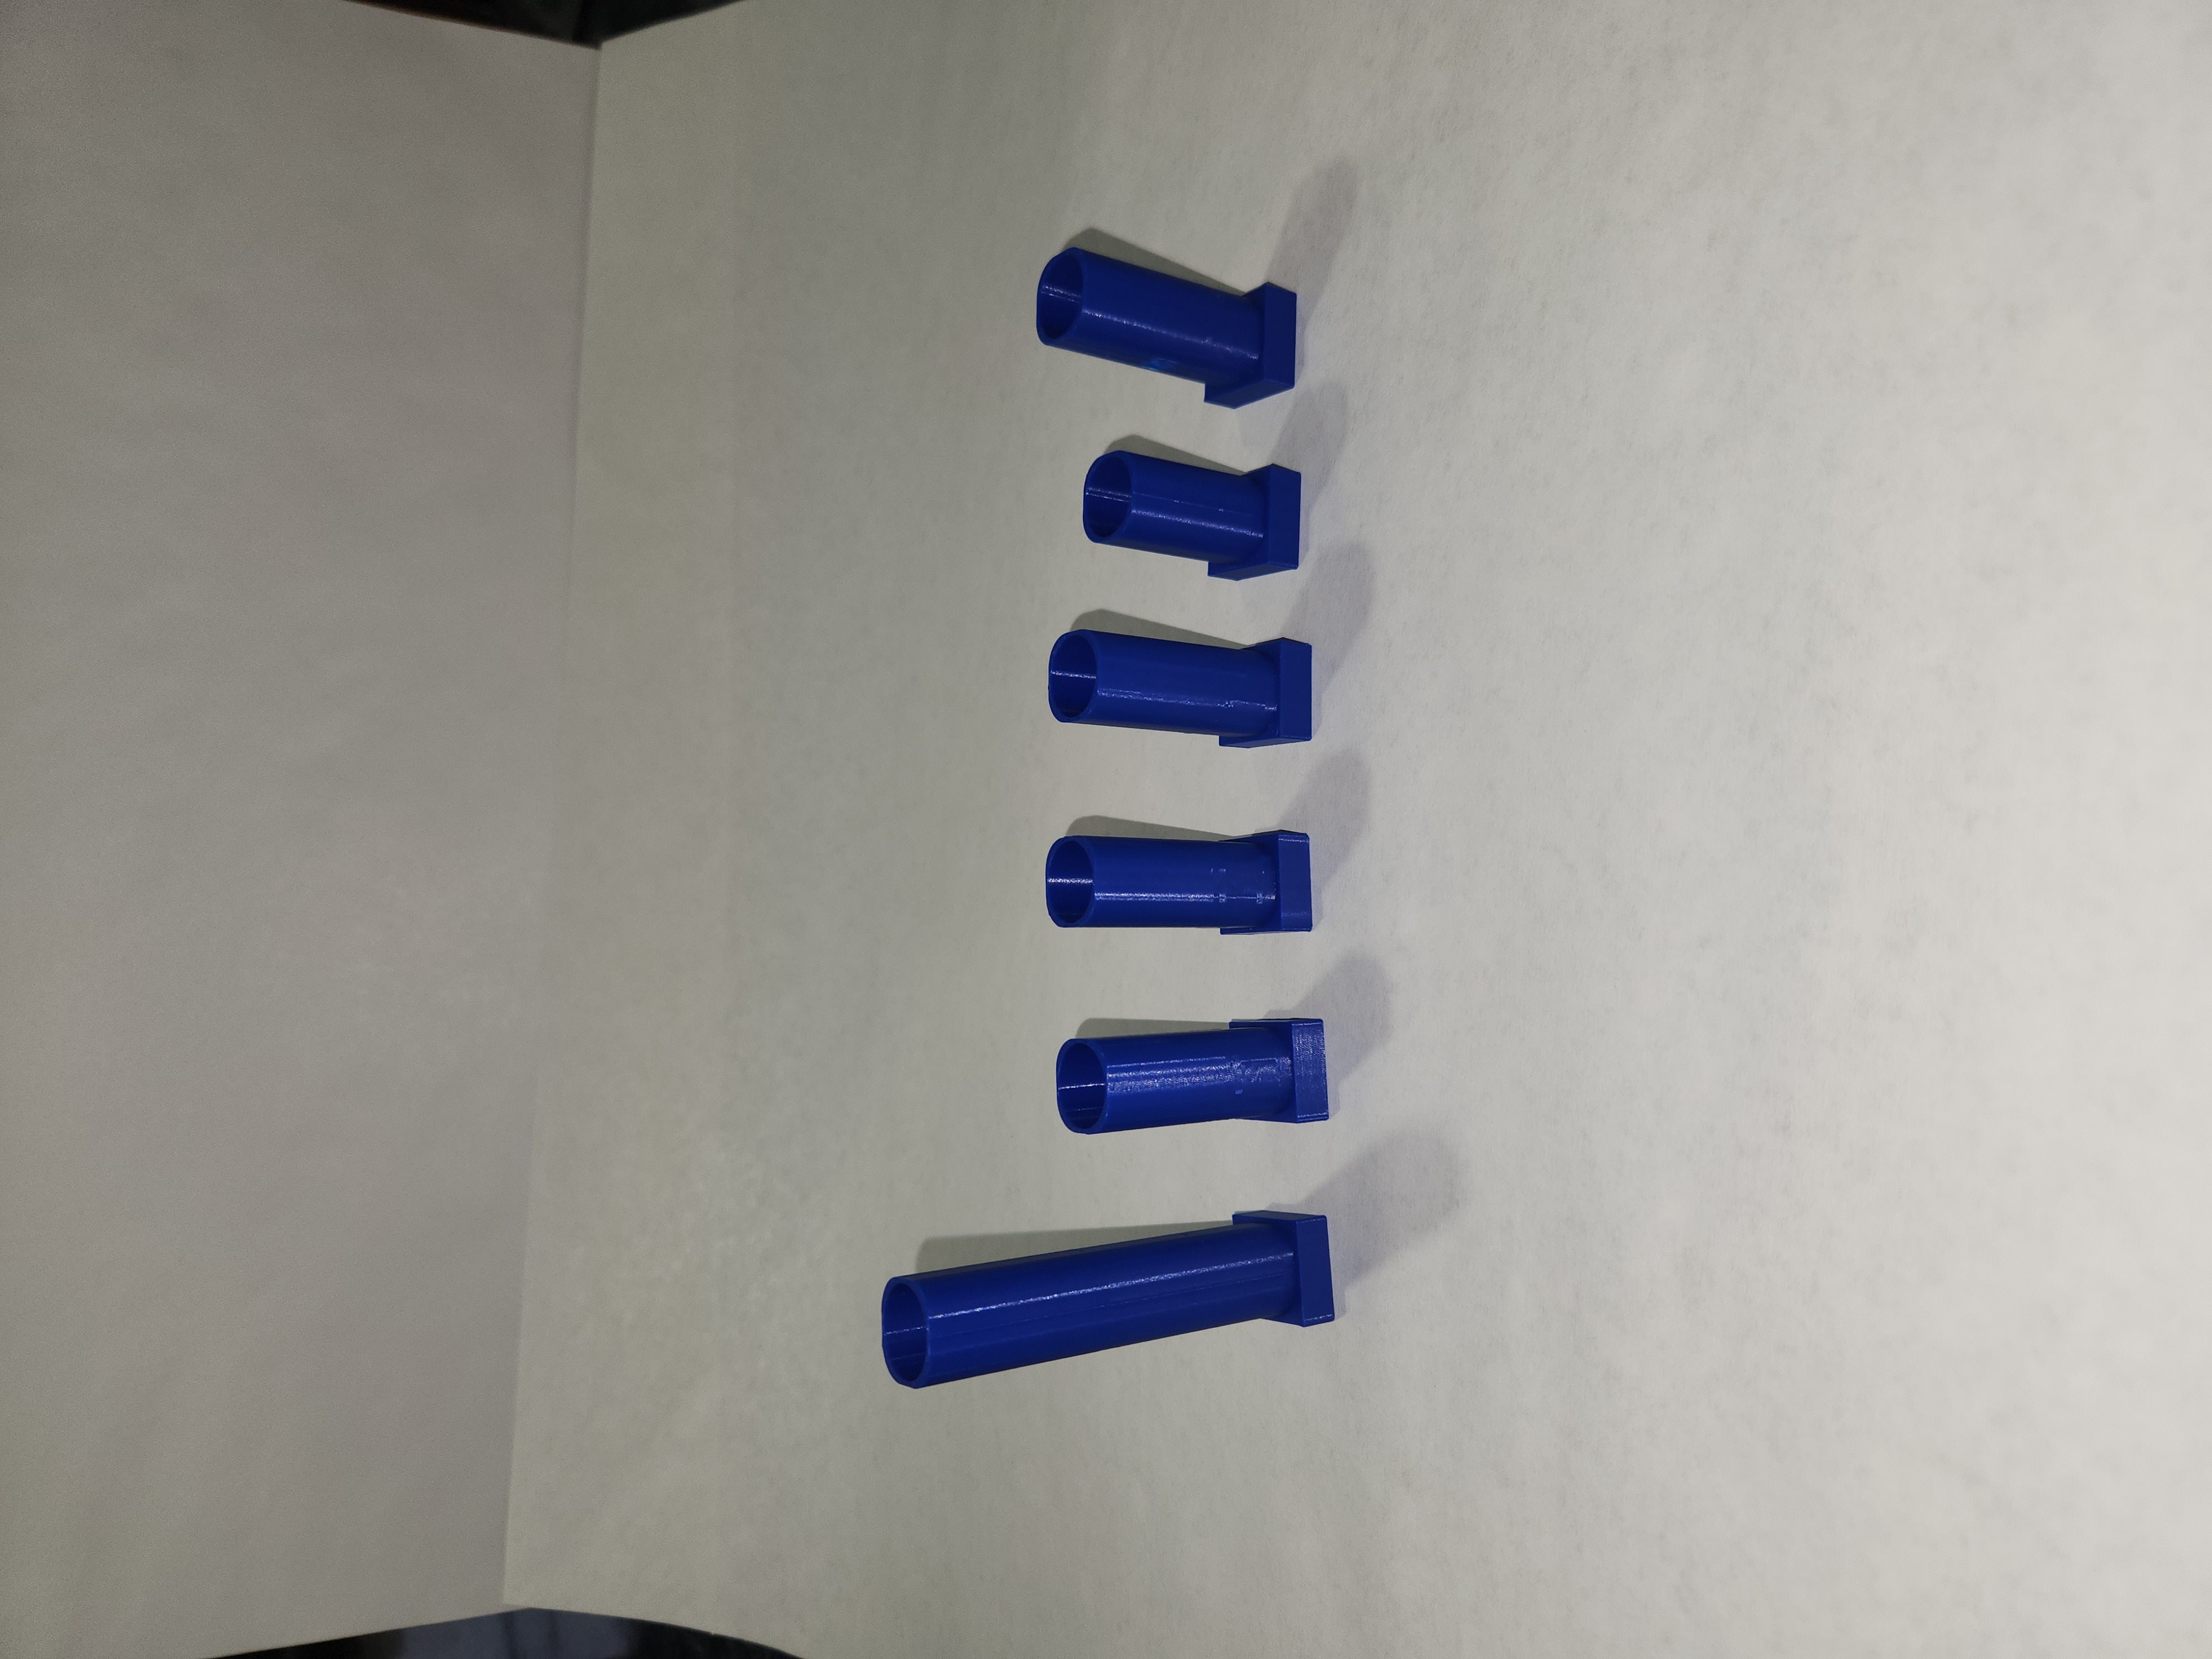
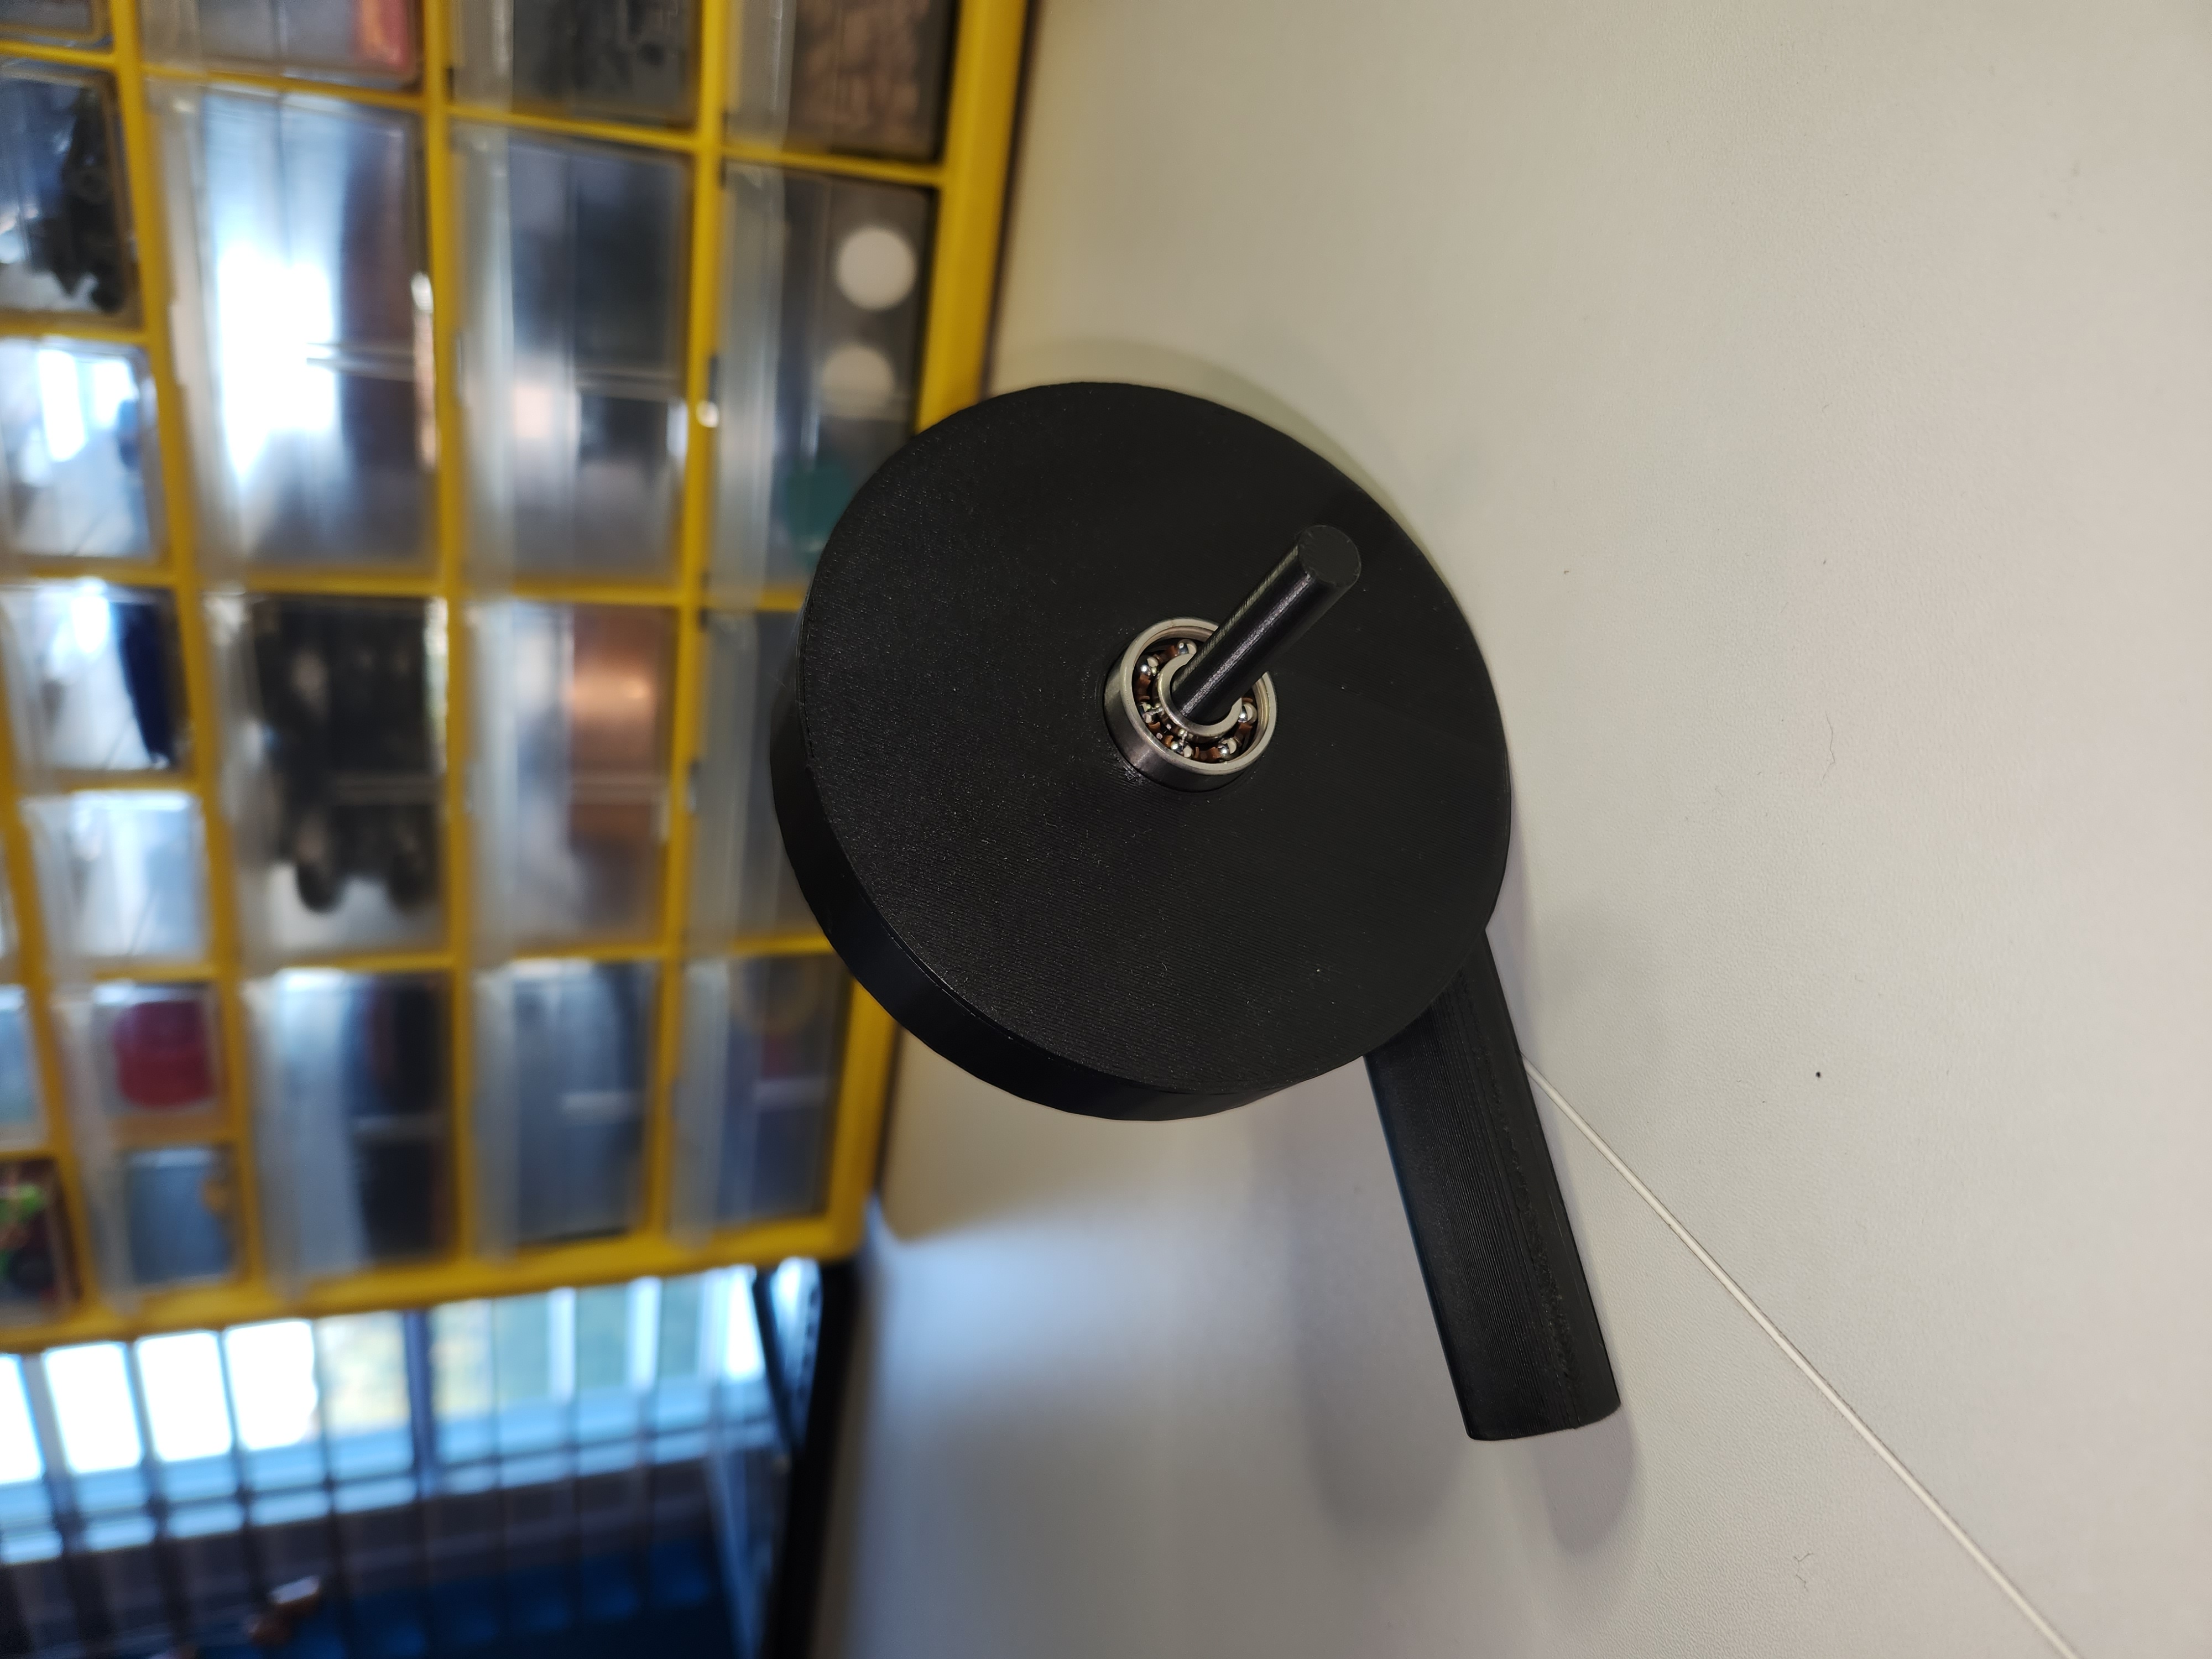
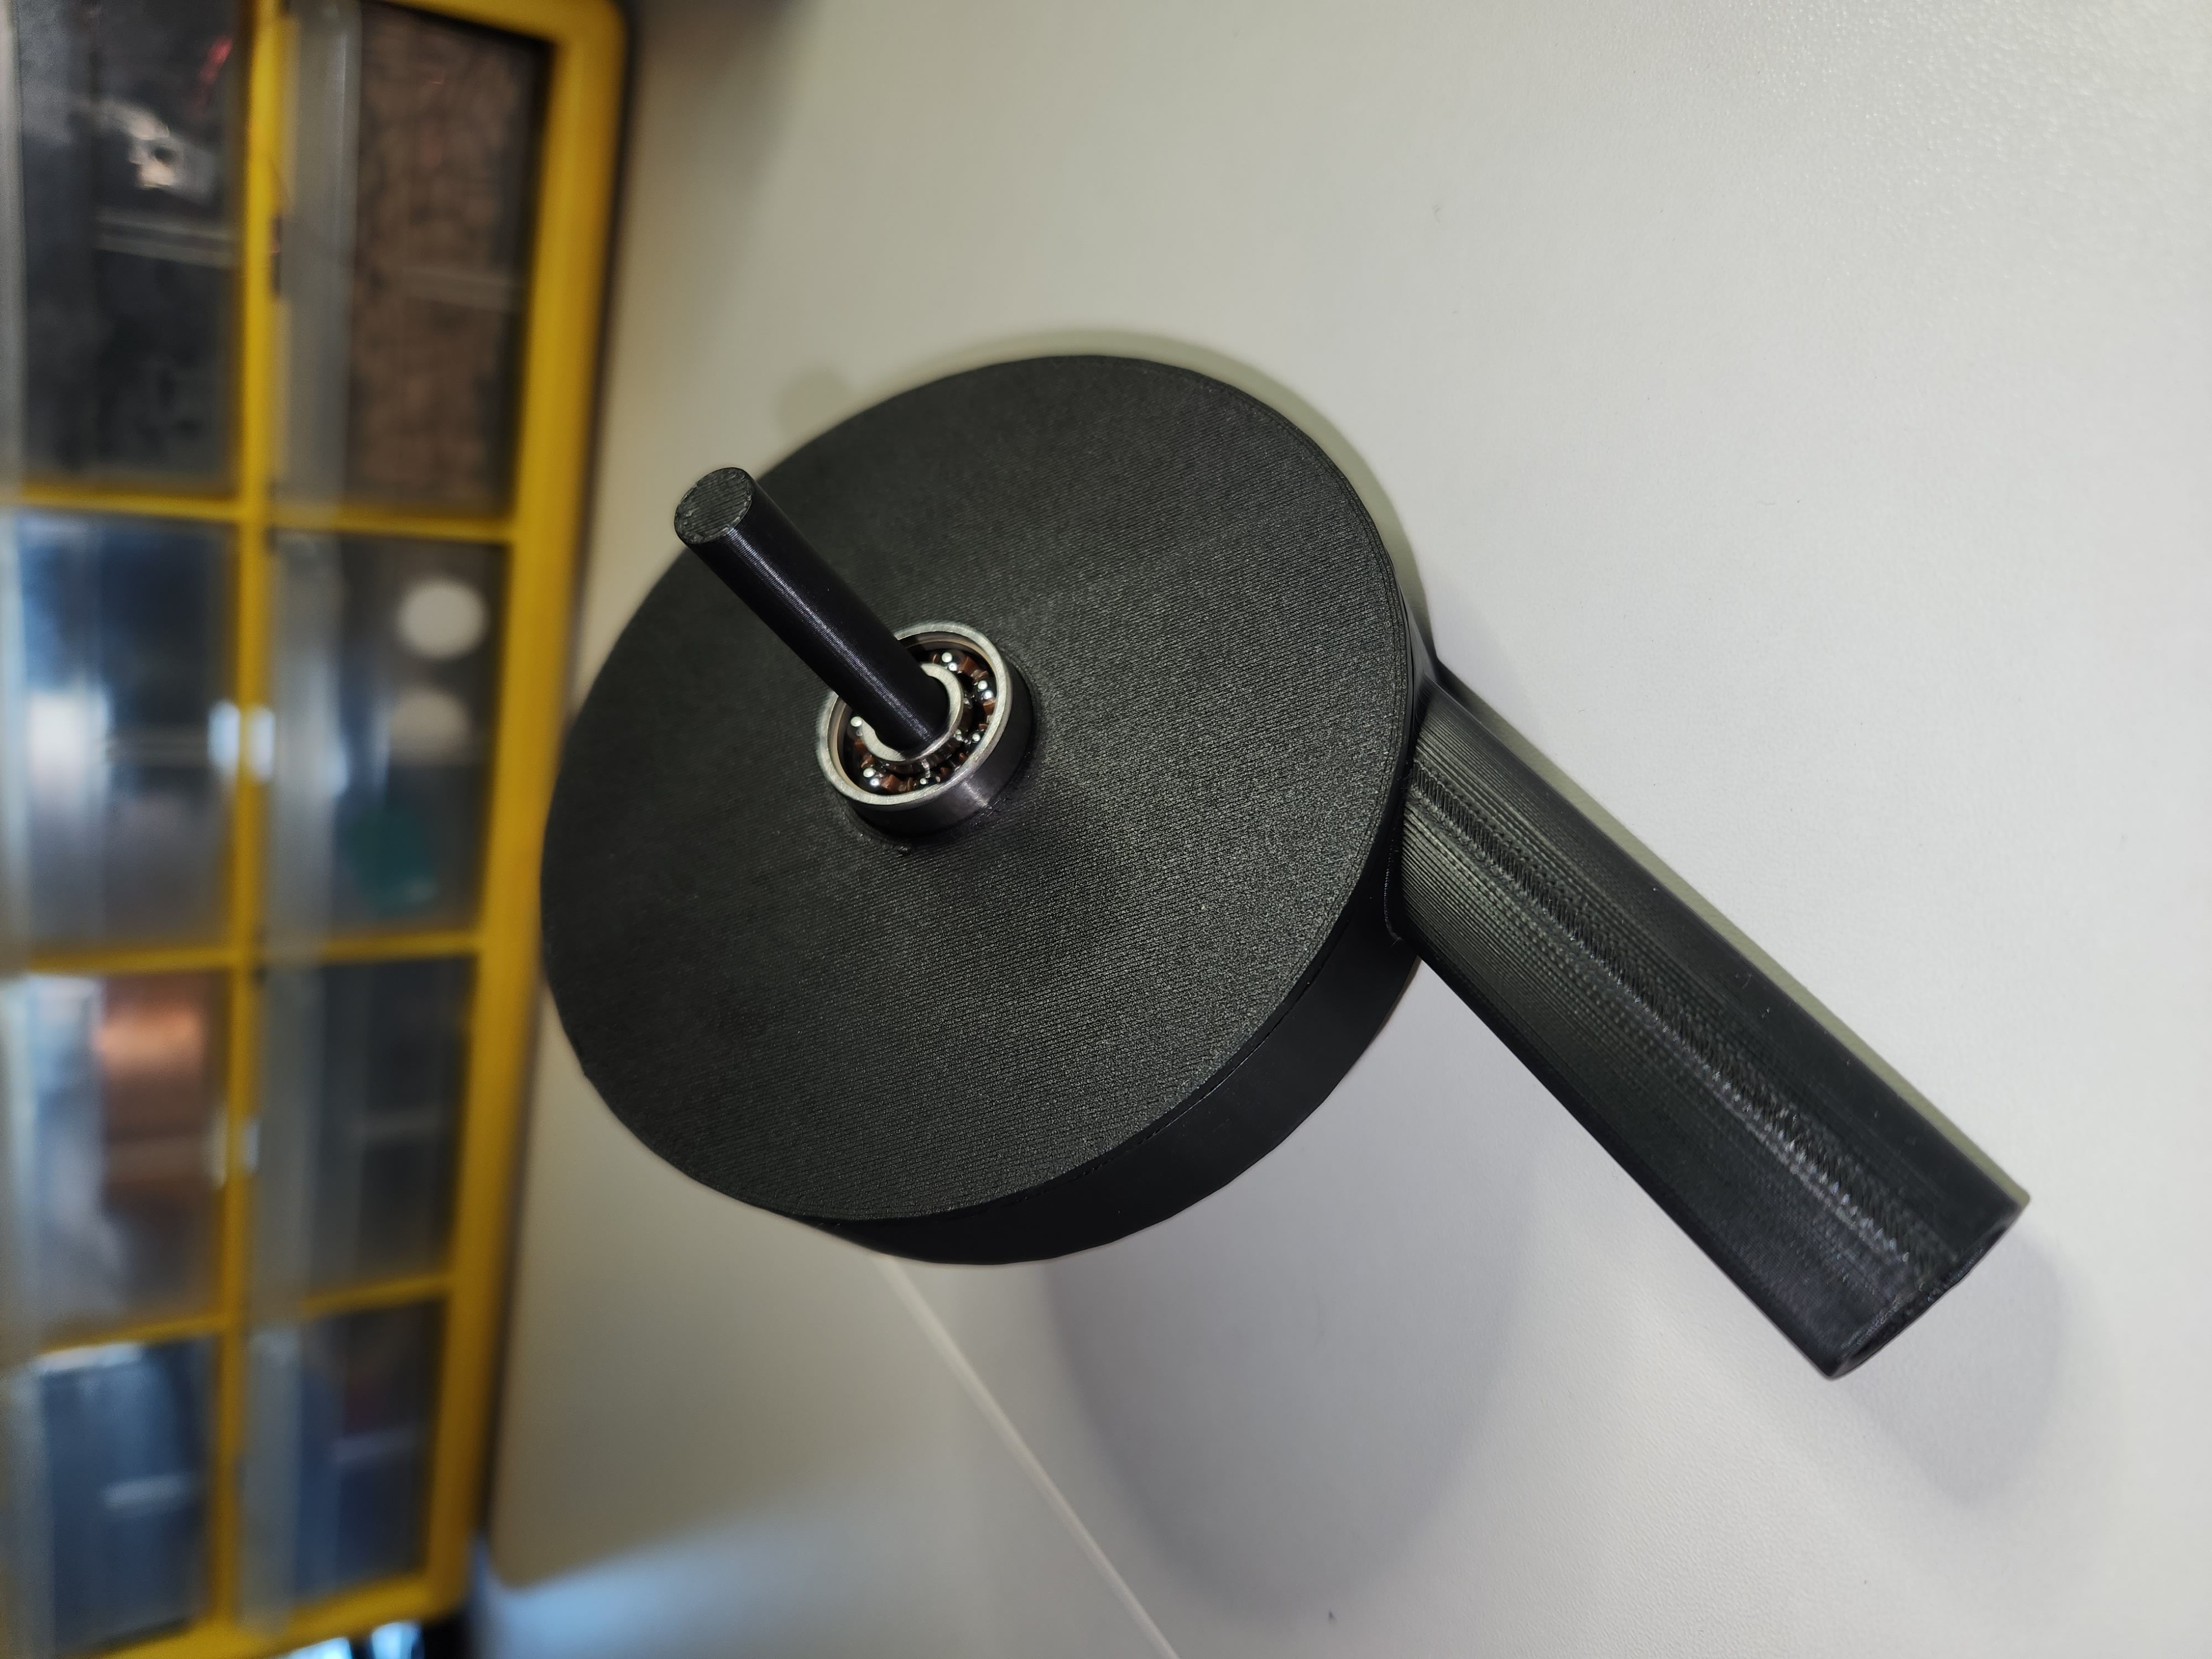
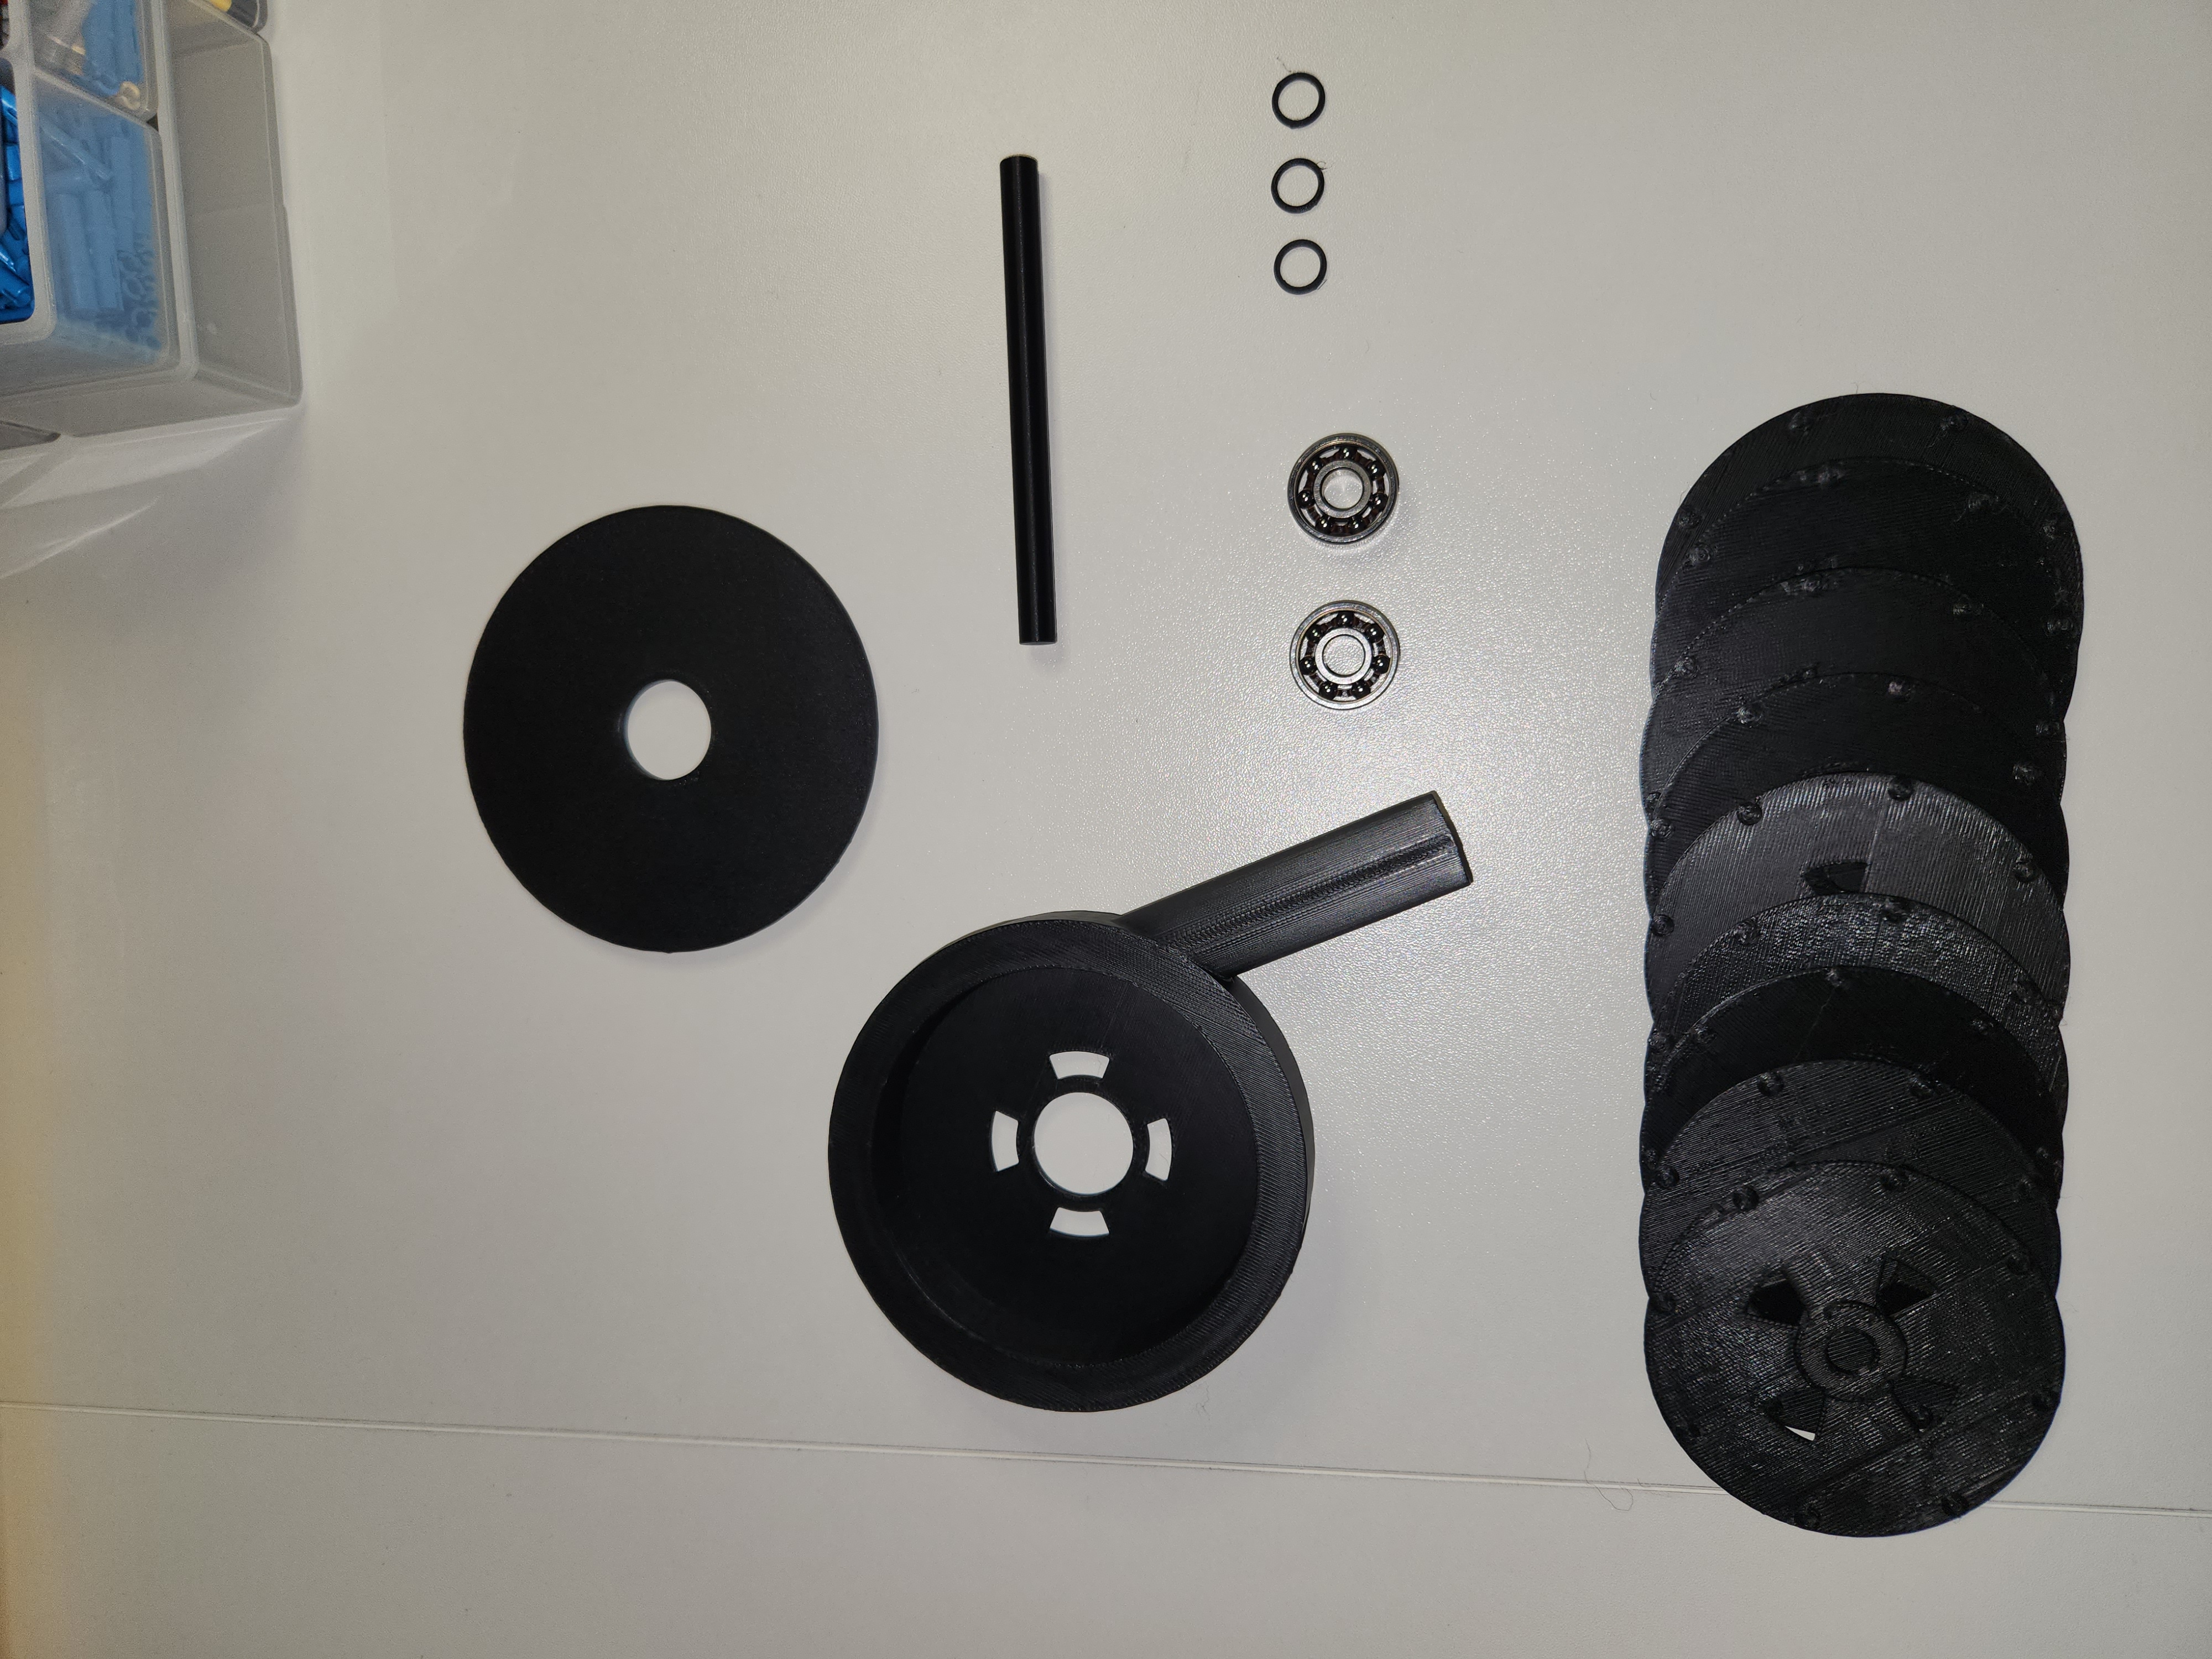
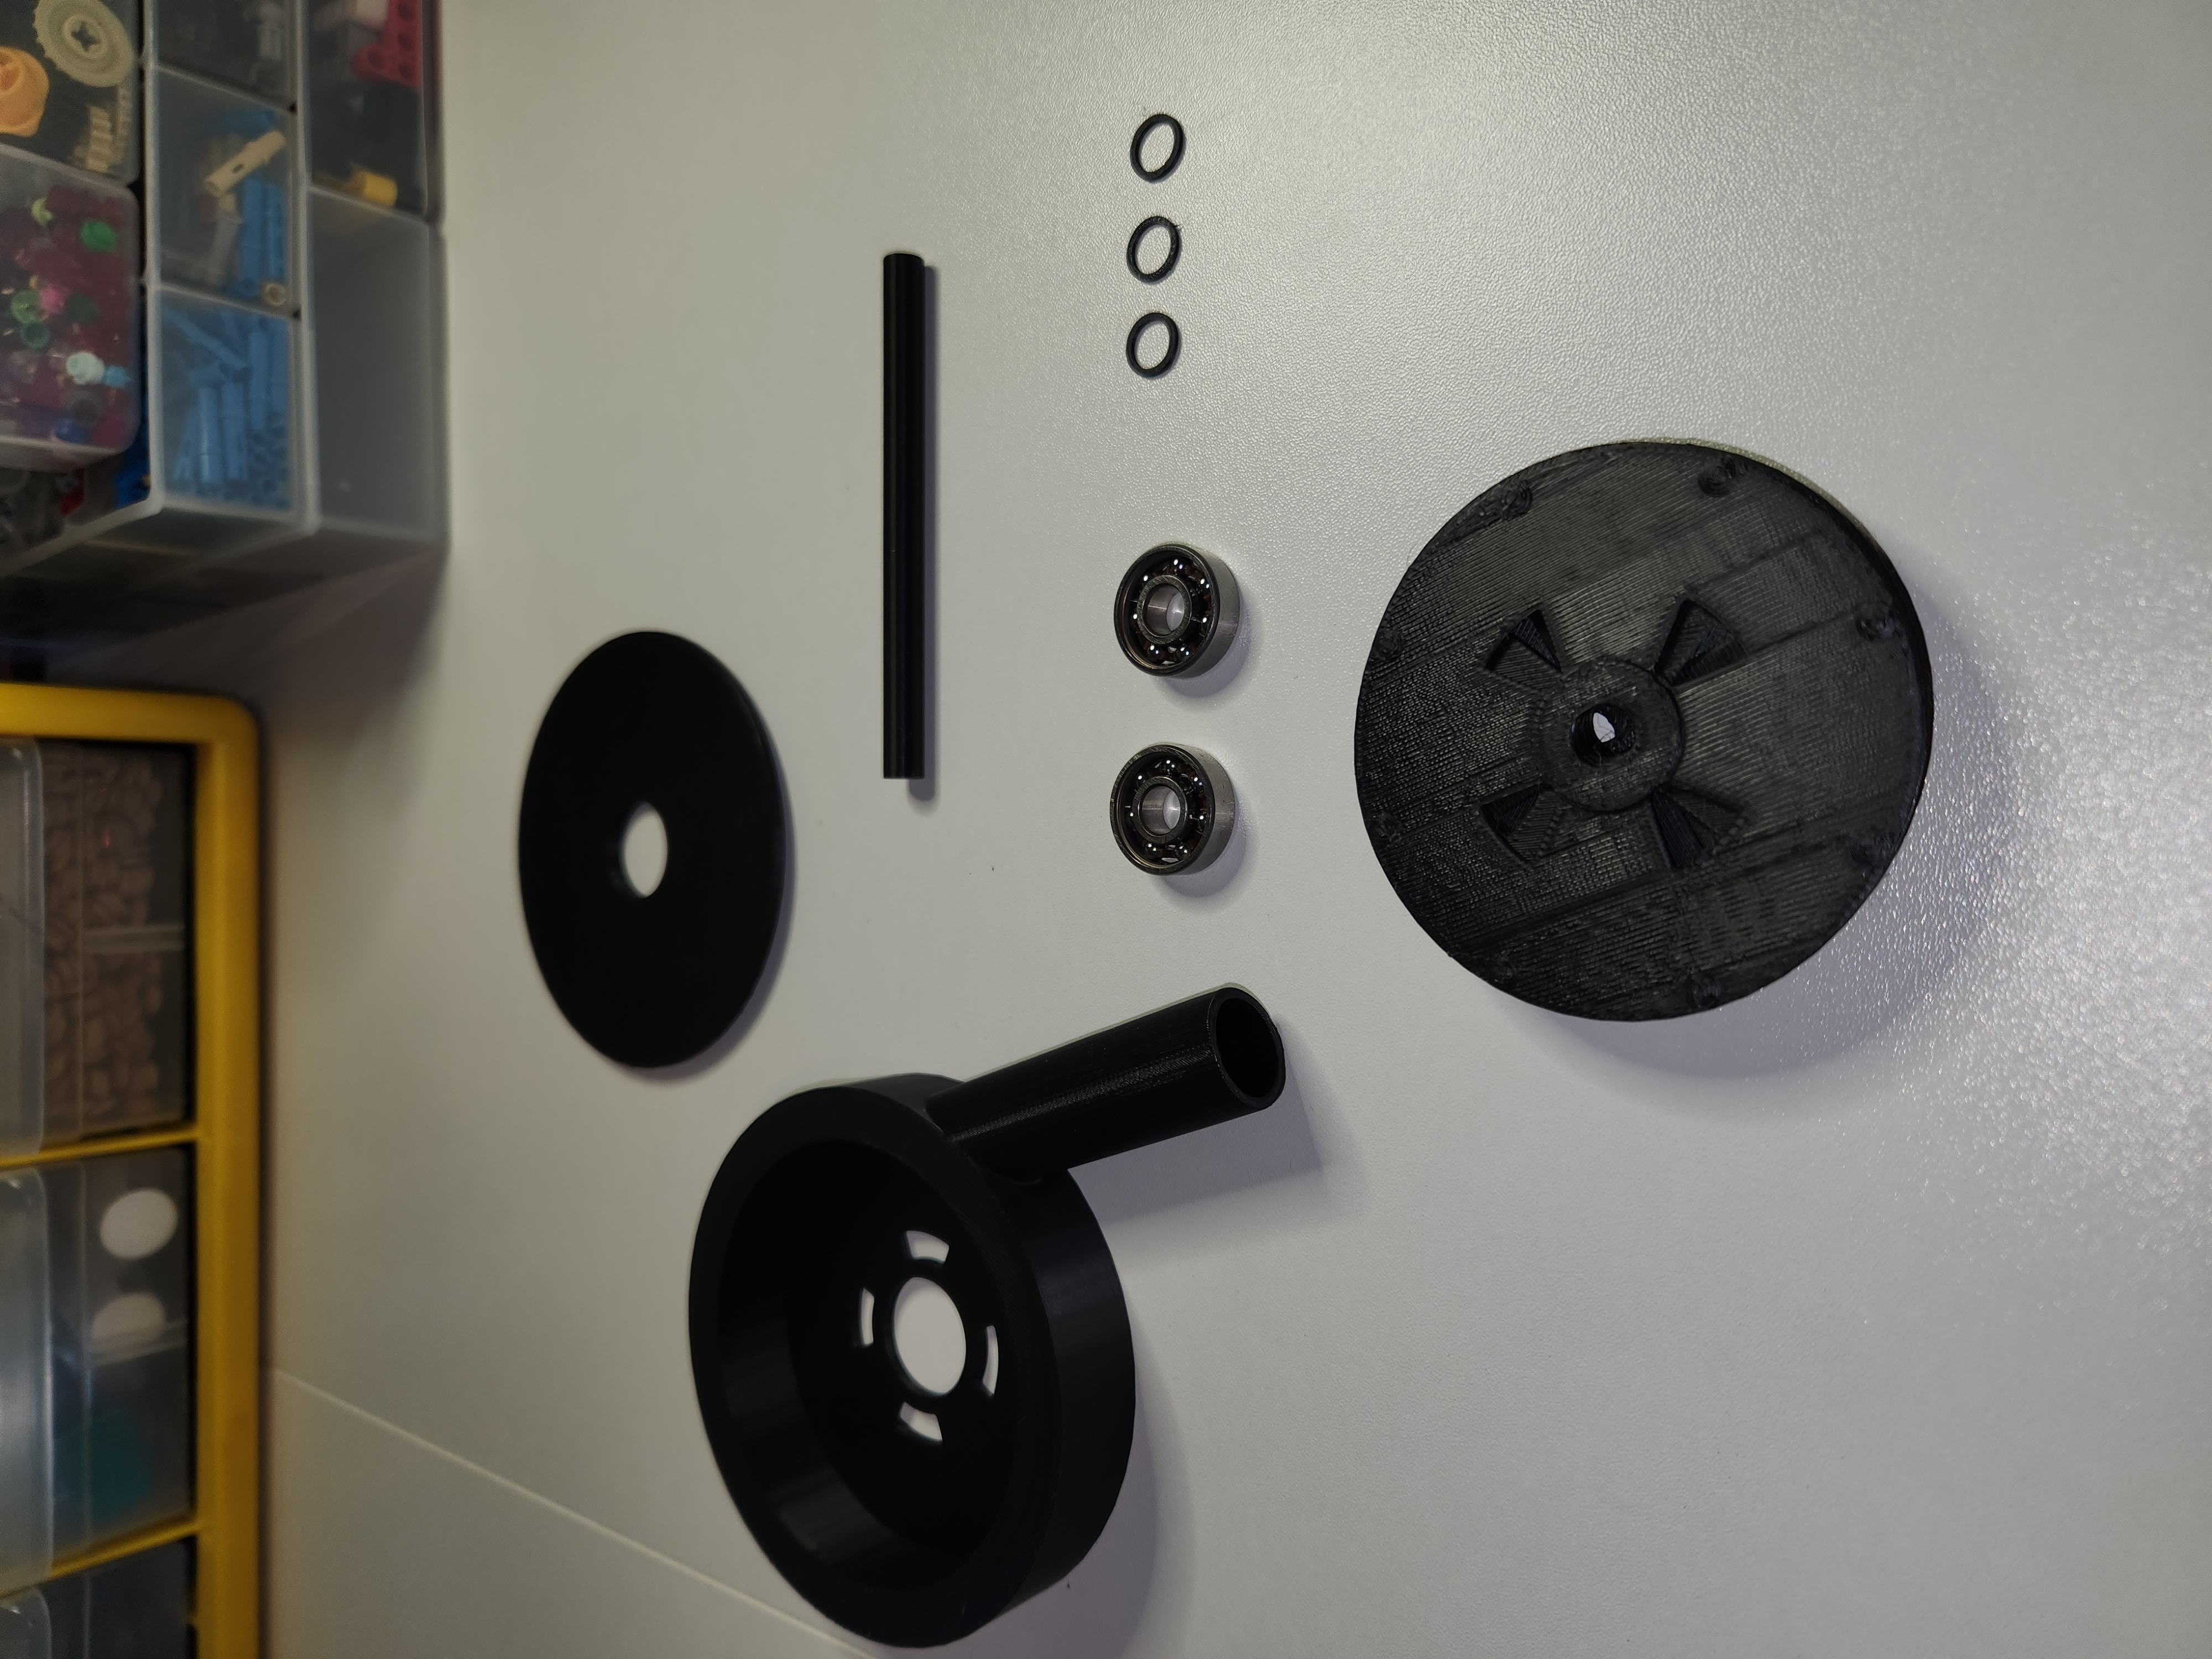
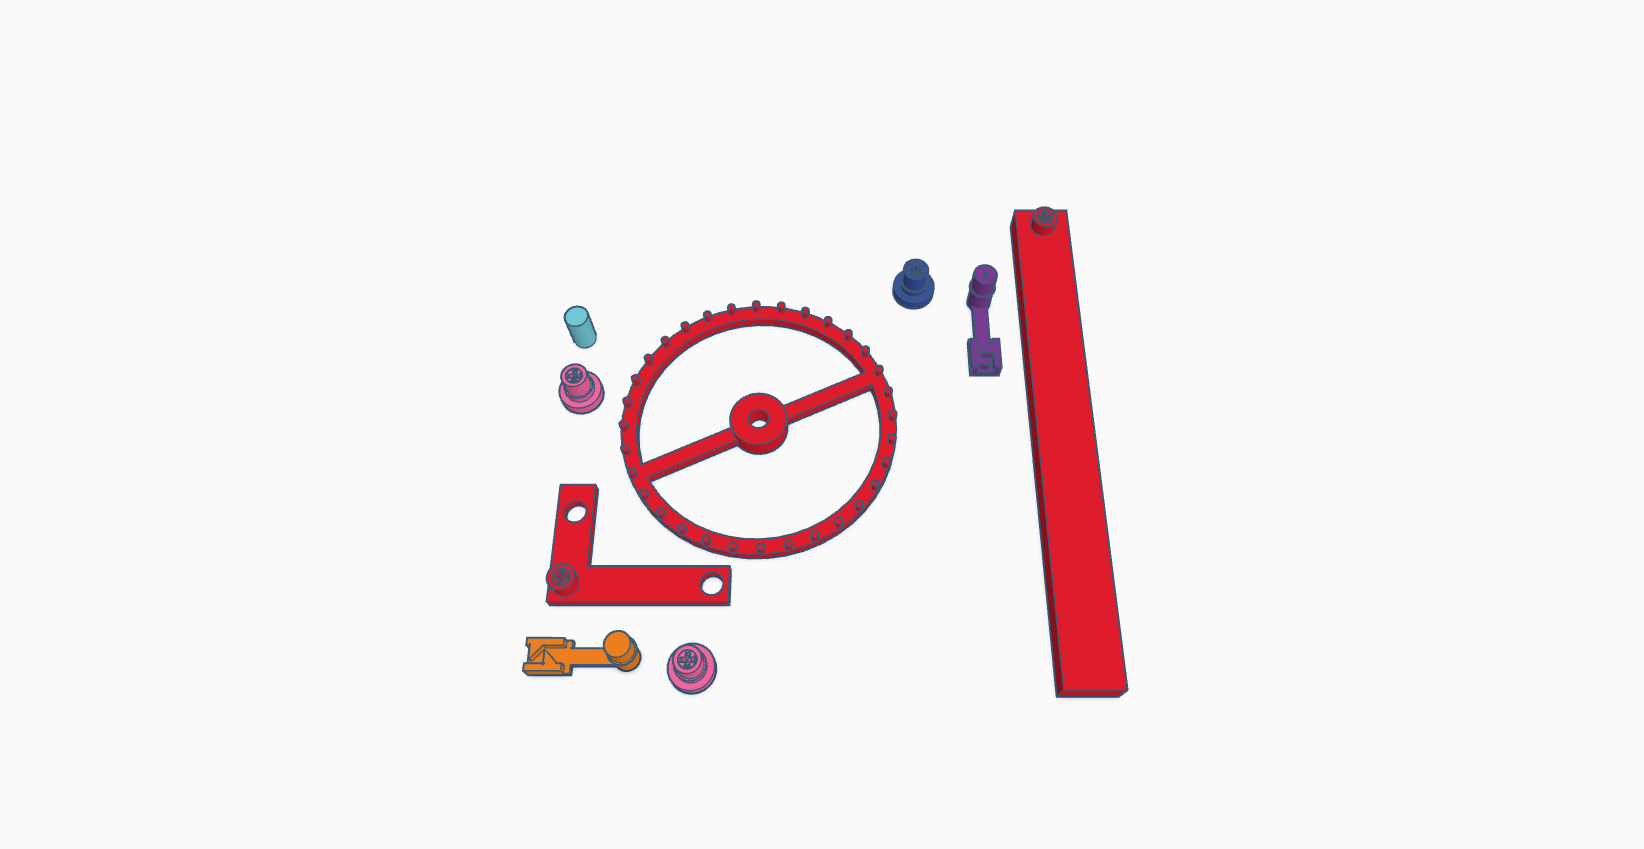
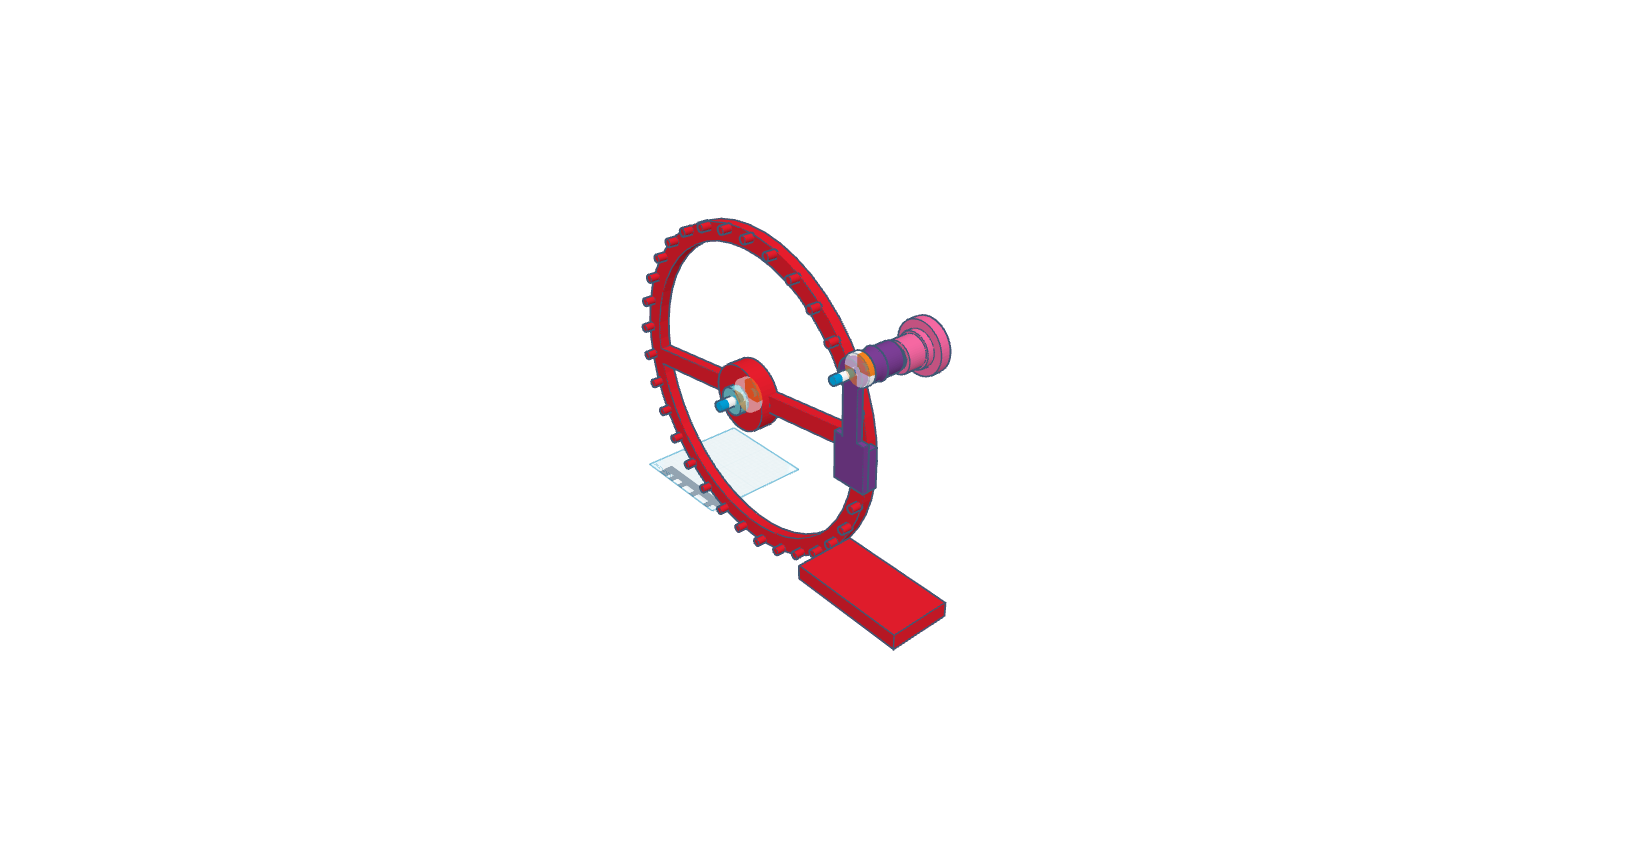
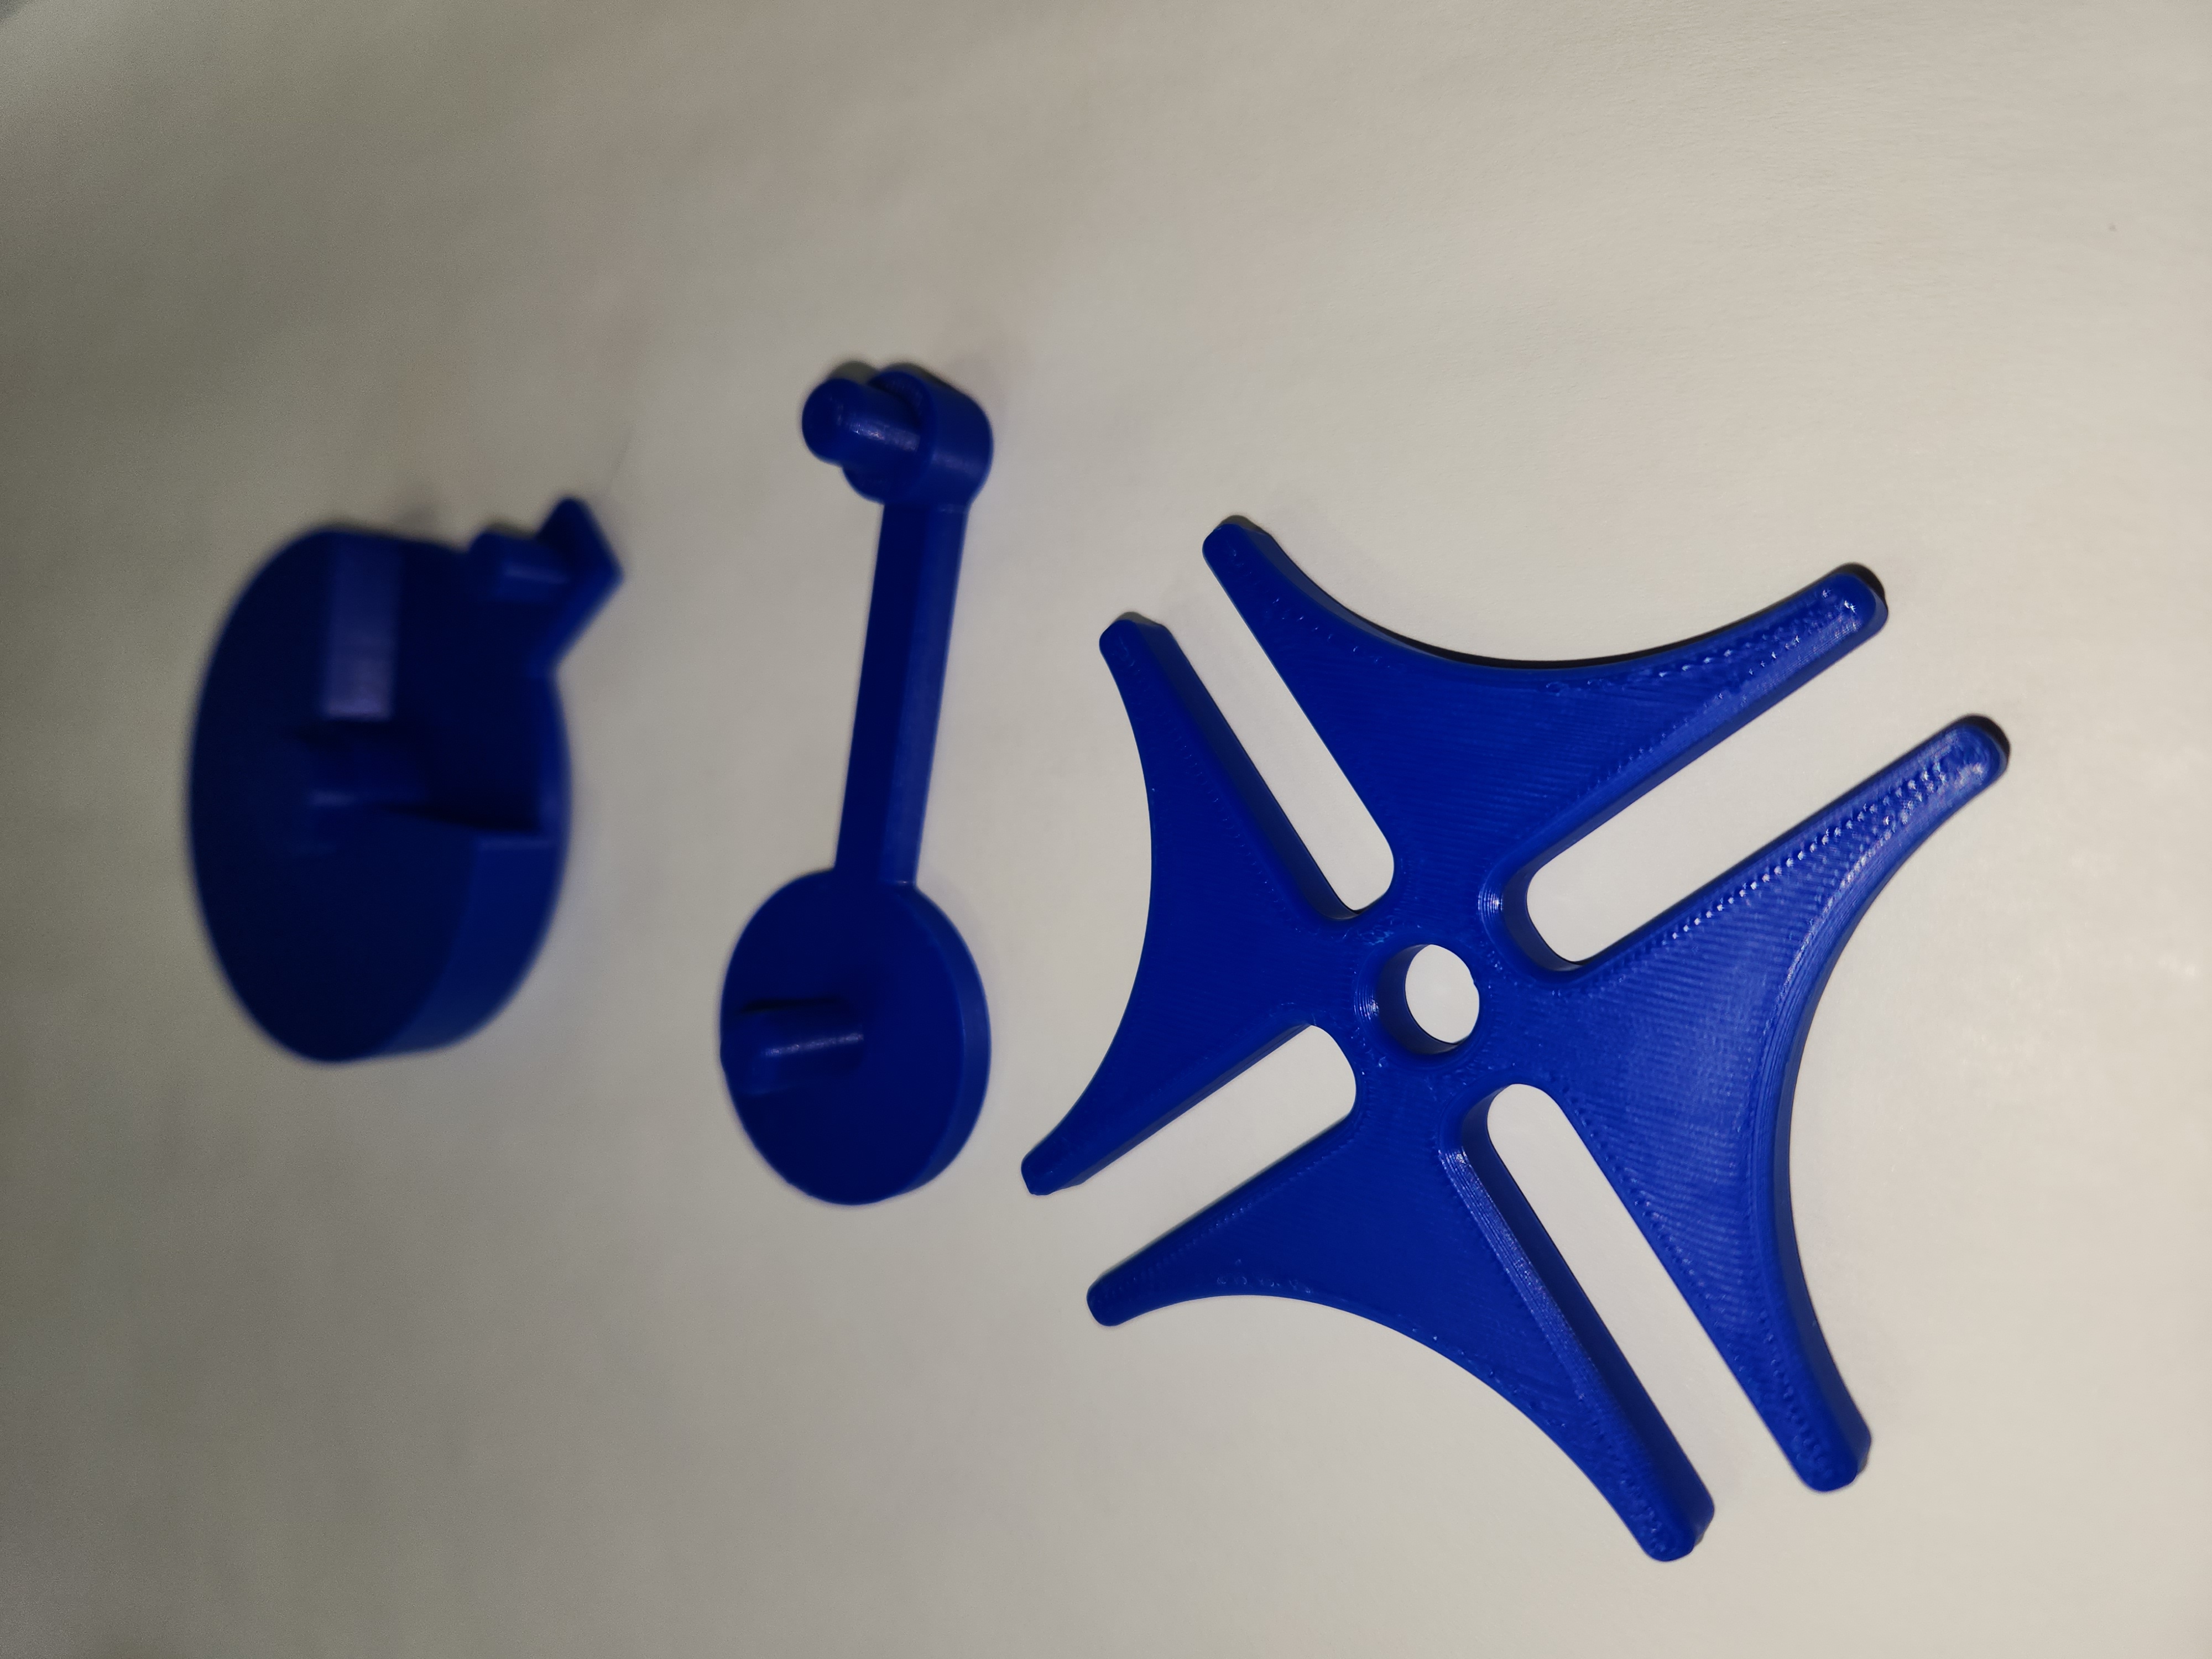
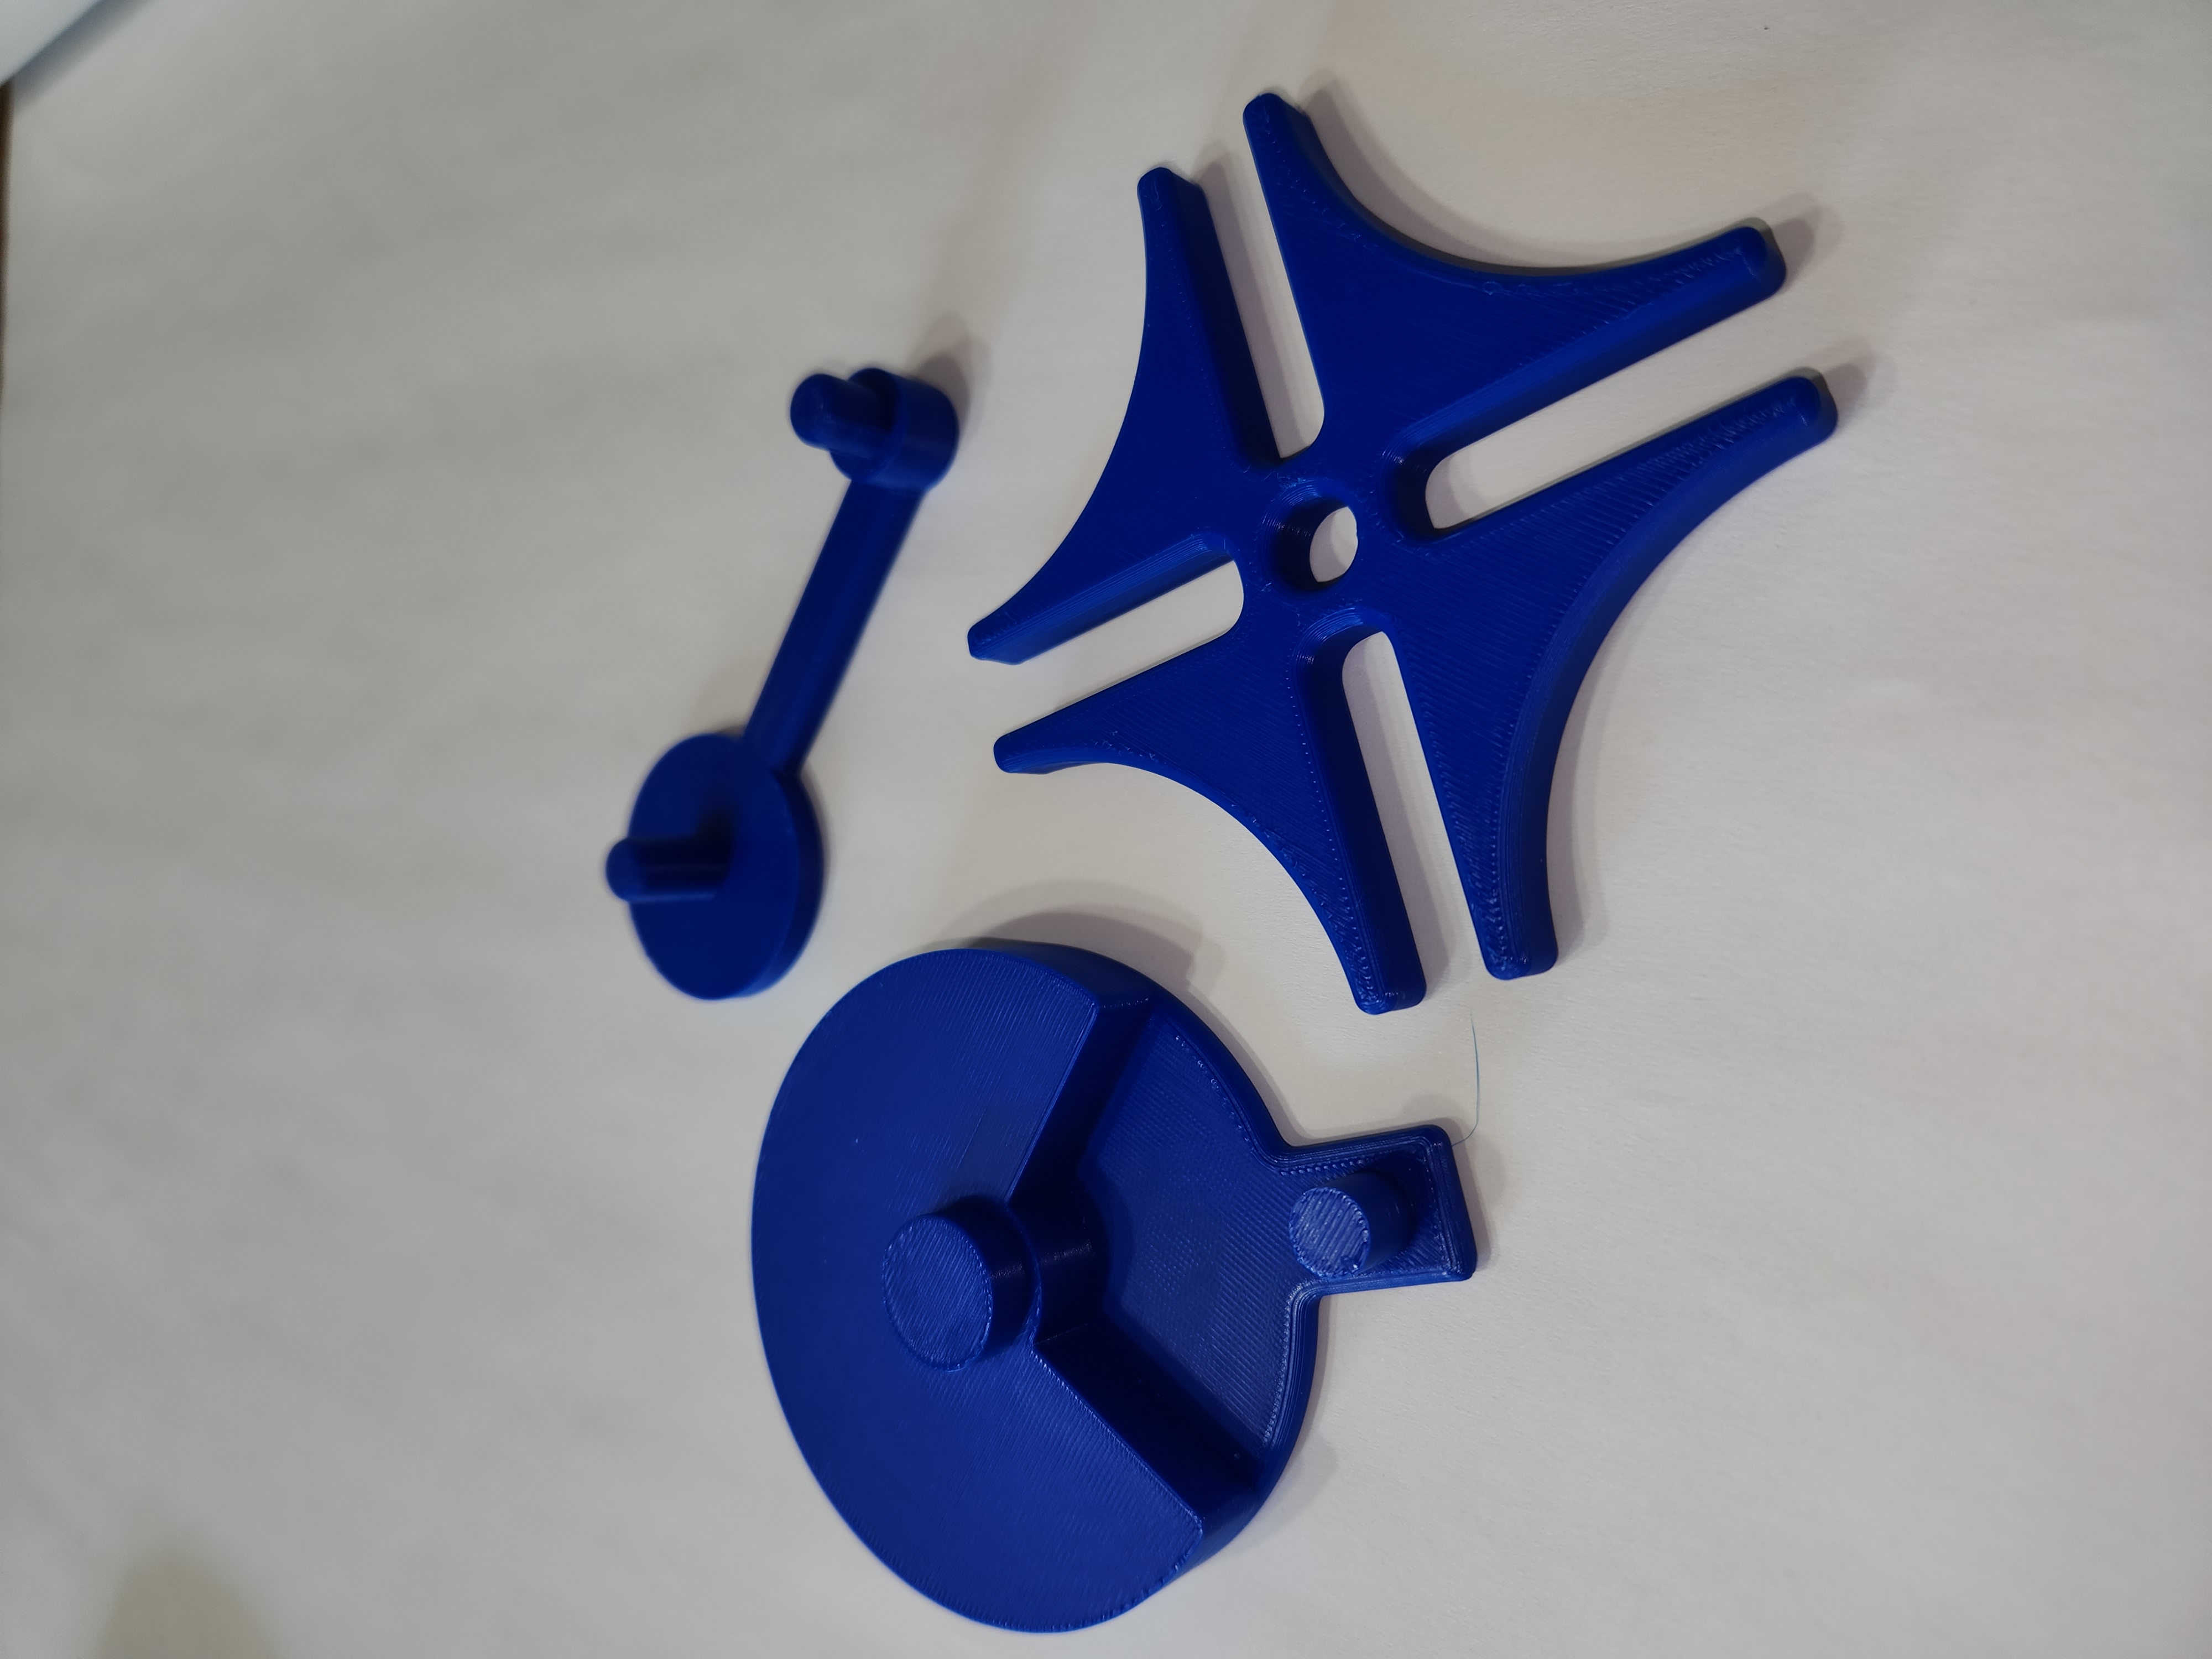
Custom D-Shaft Drive Spindles
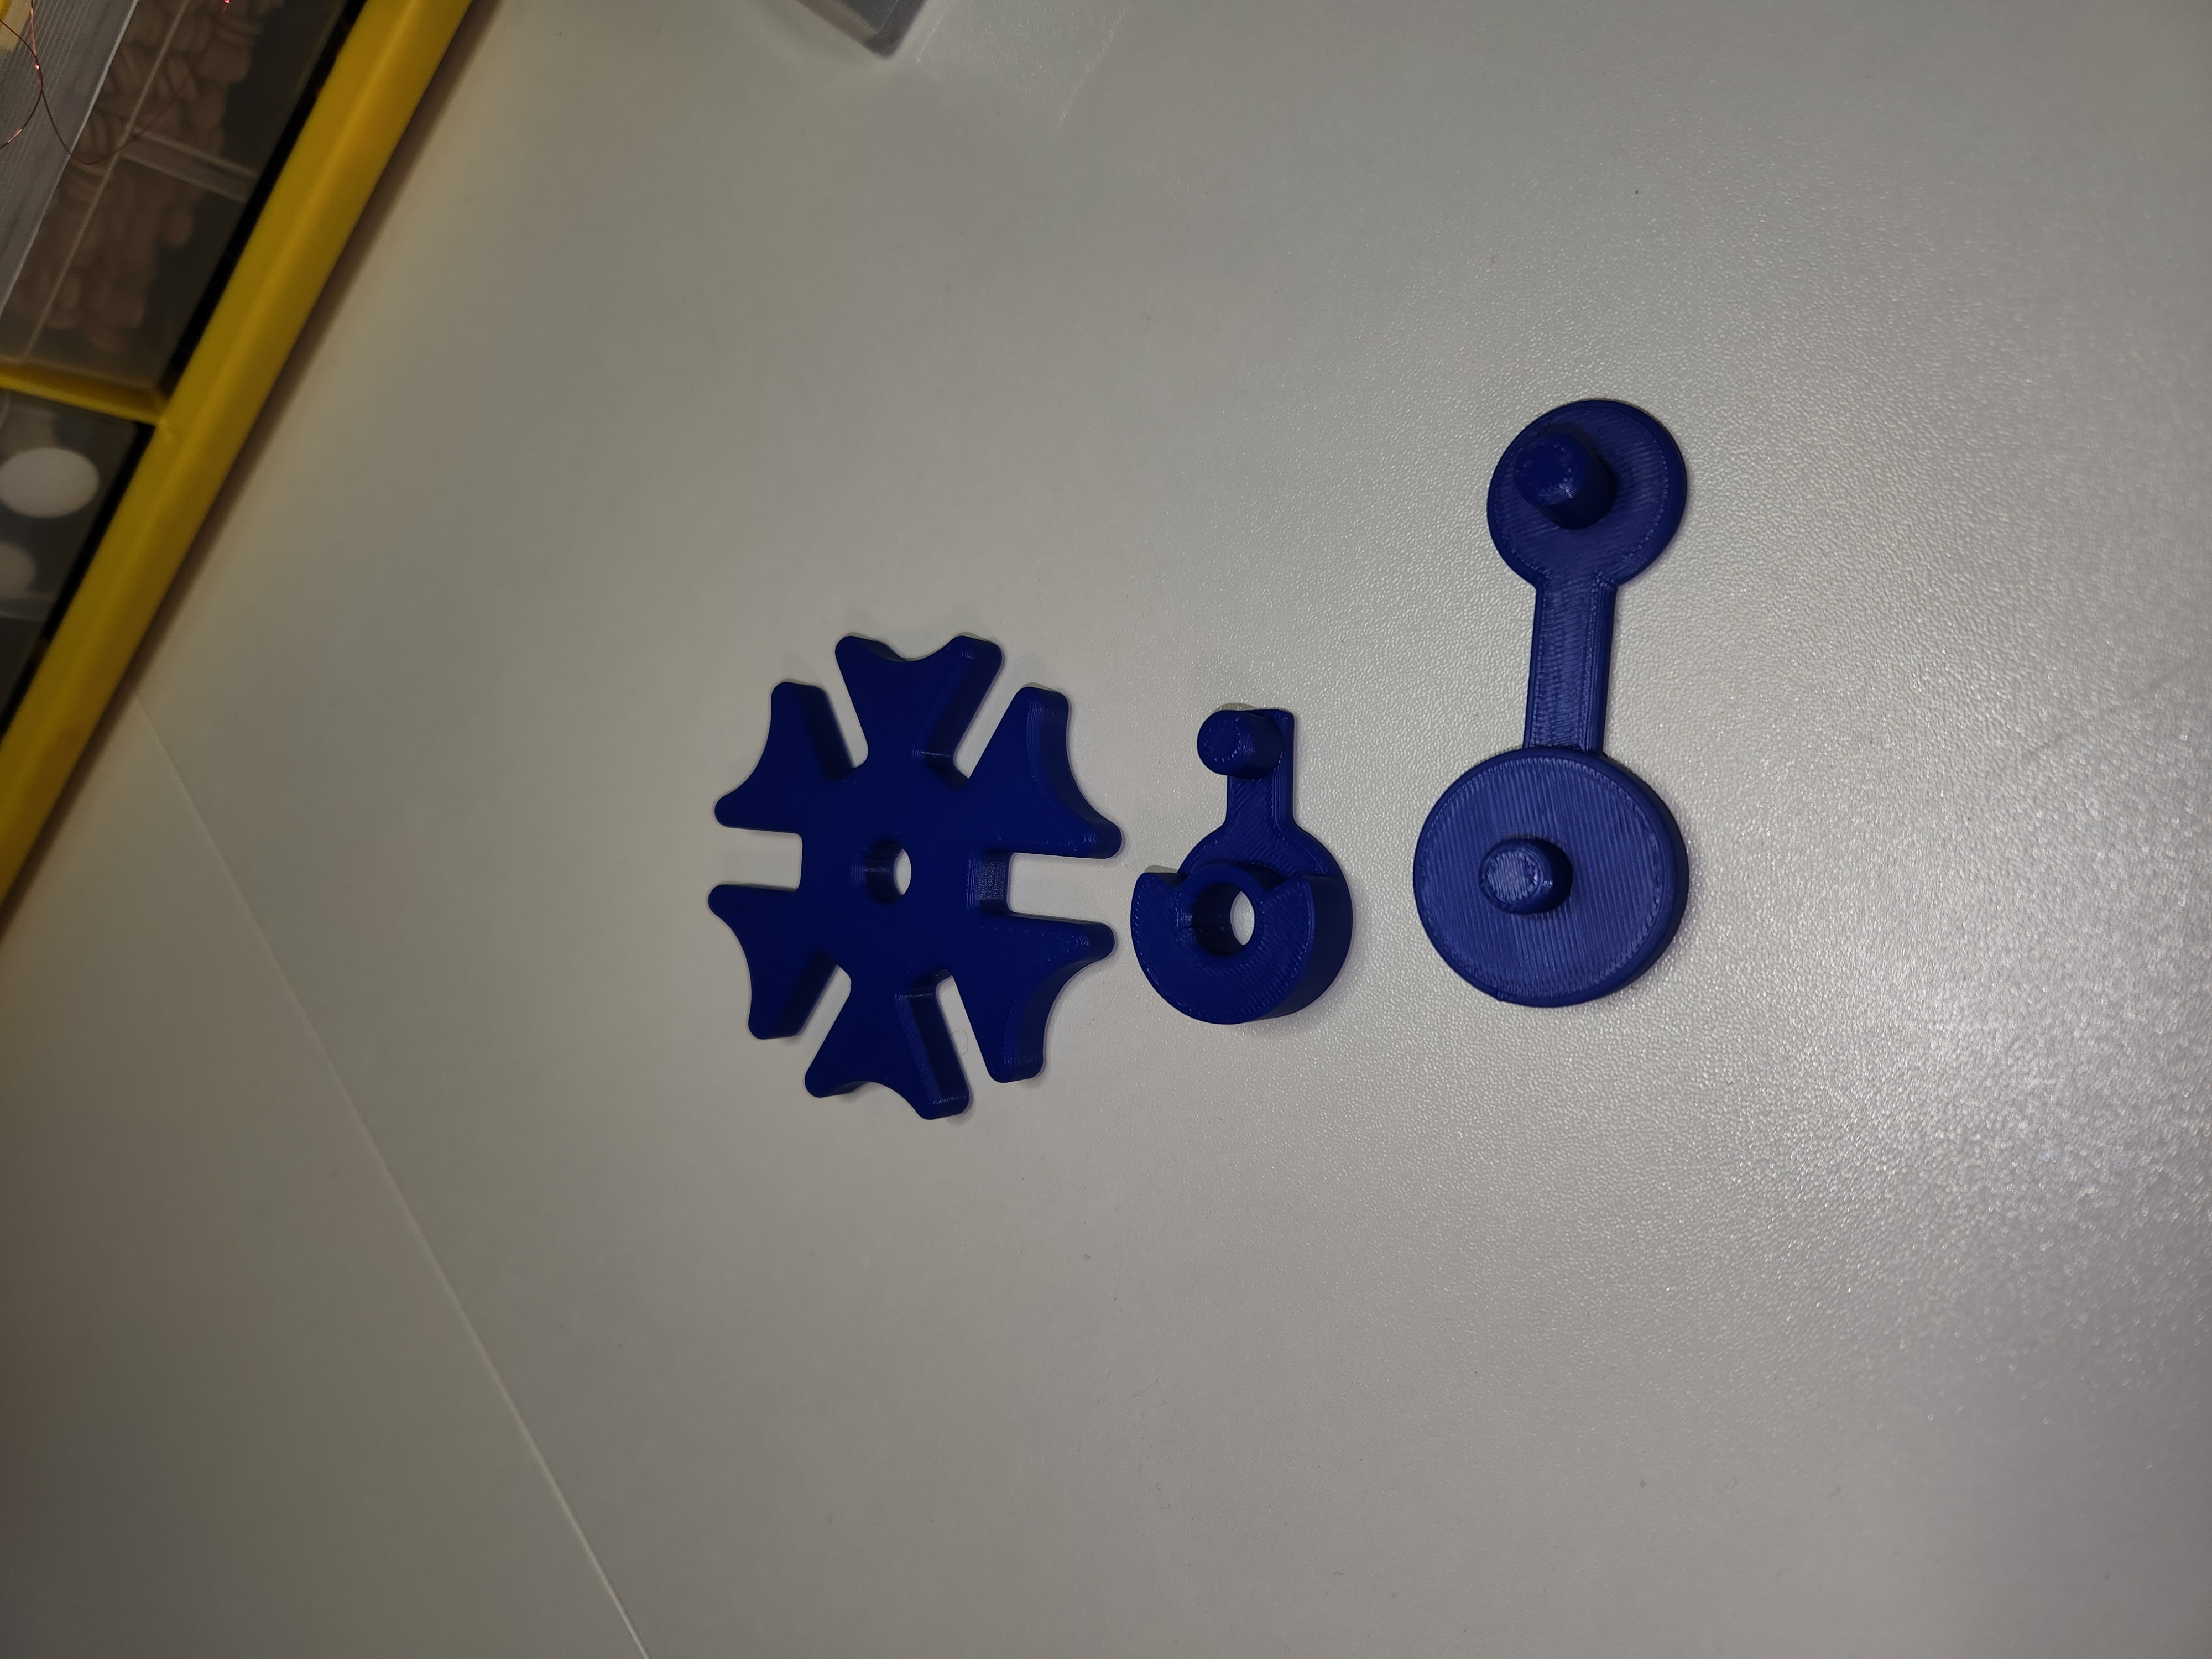
Set of 6 direct motor-to-cube face adapters
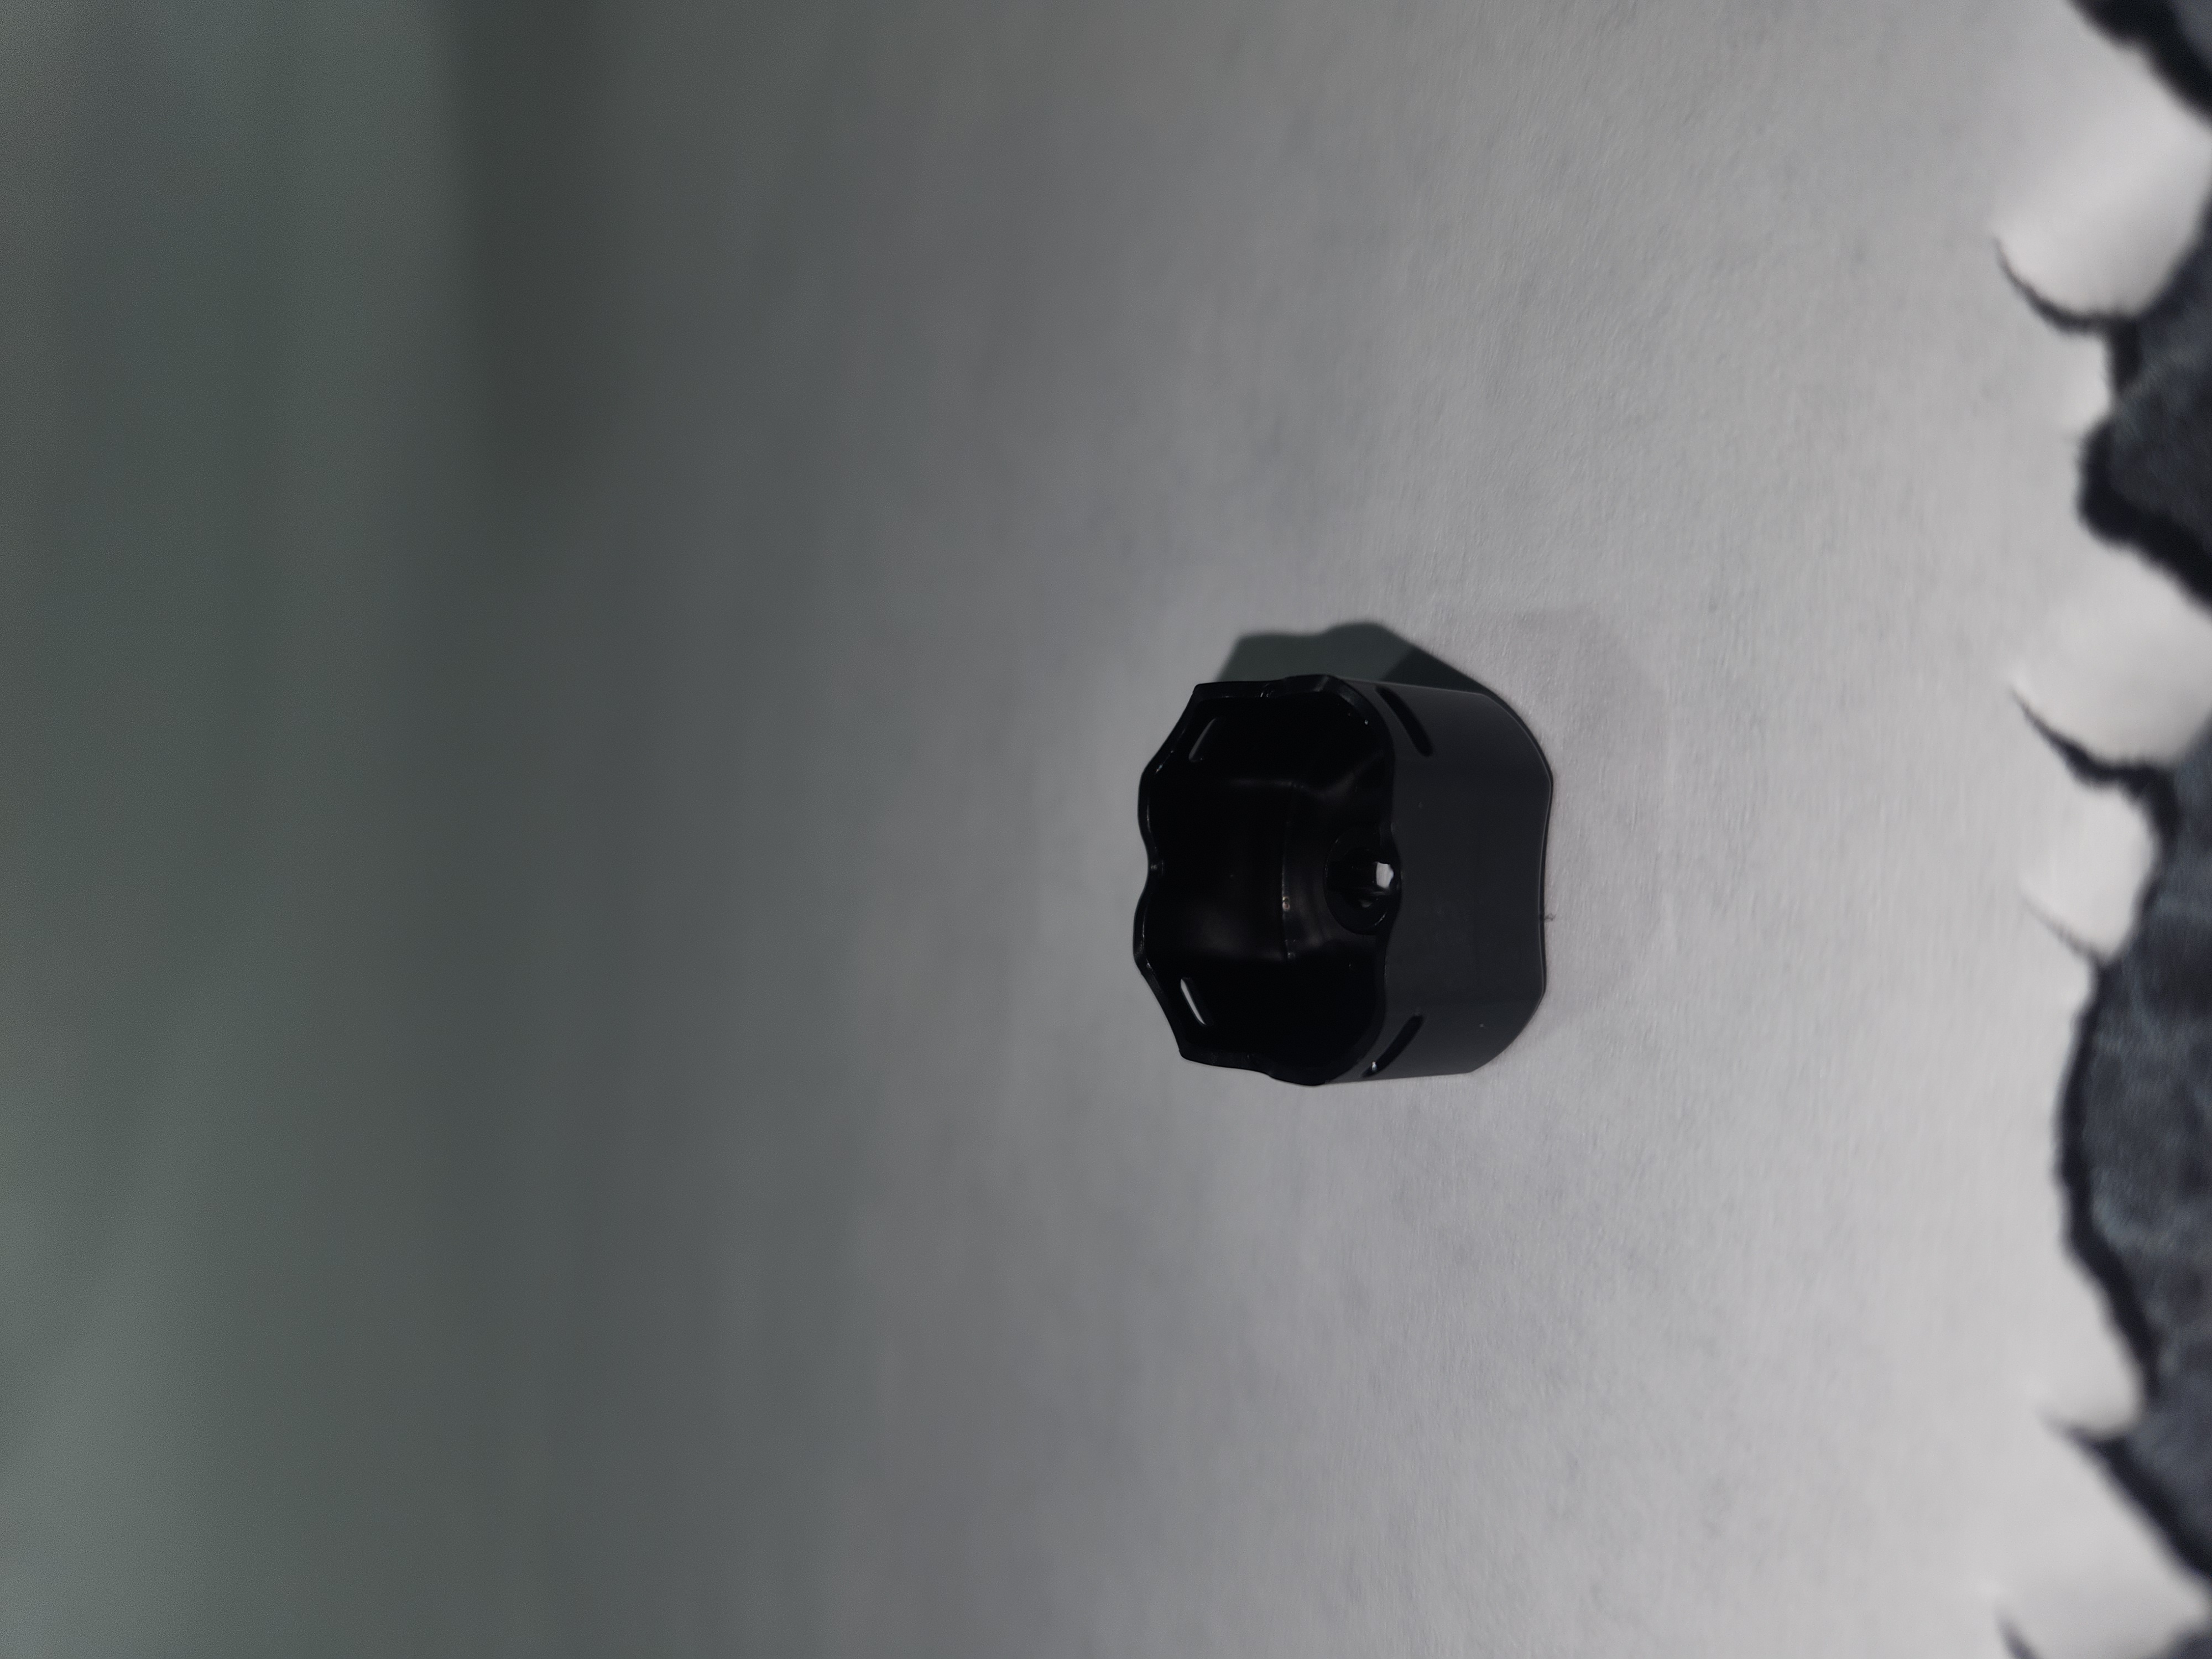
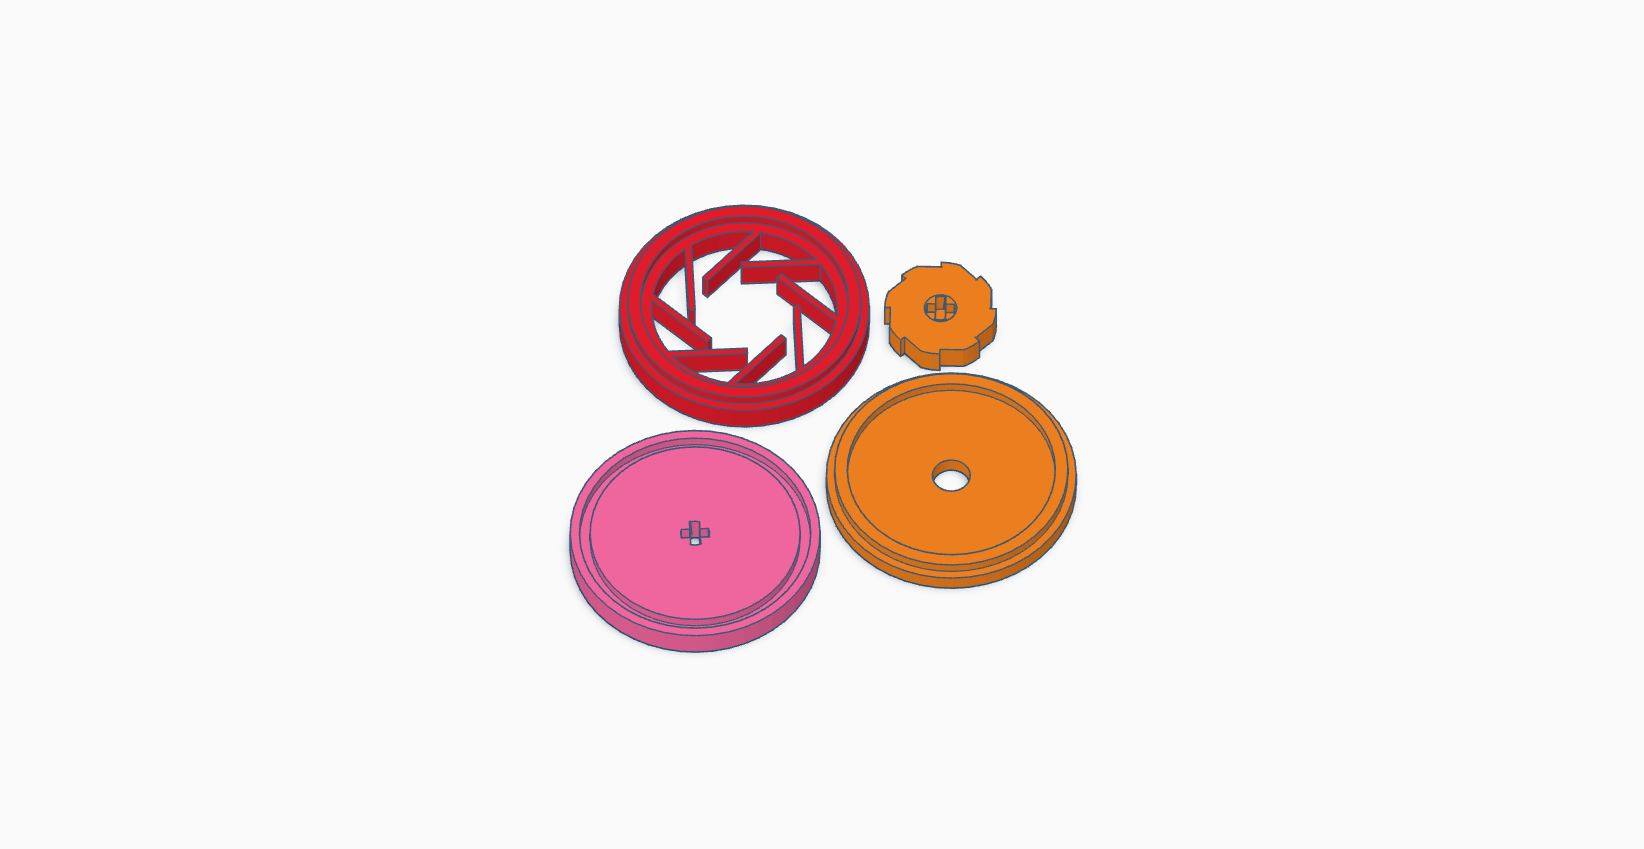
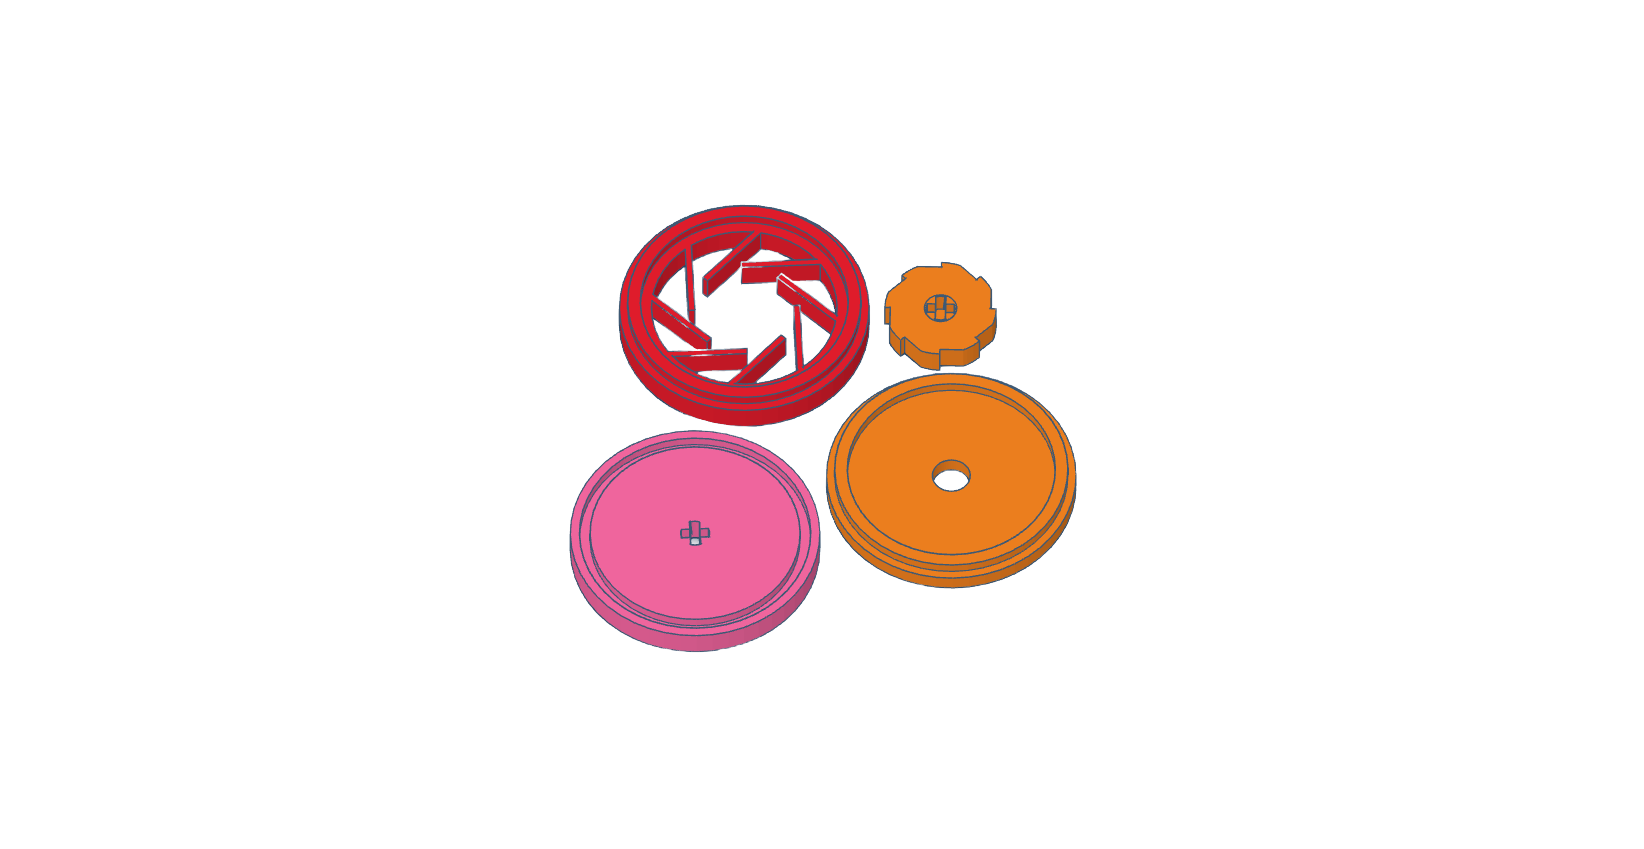
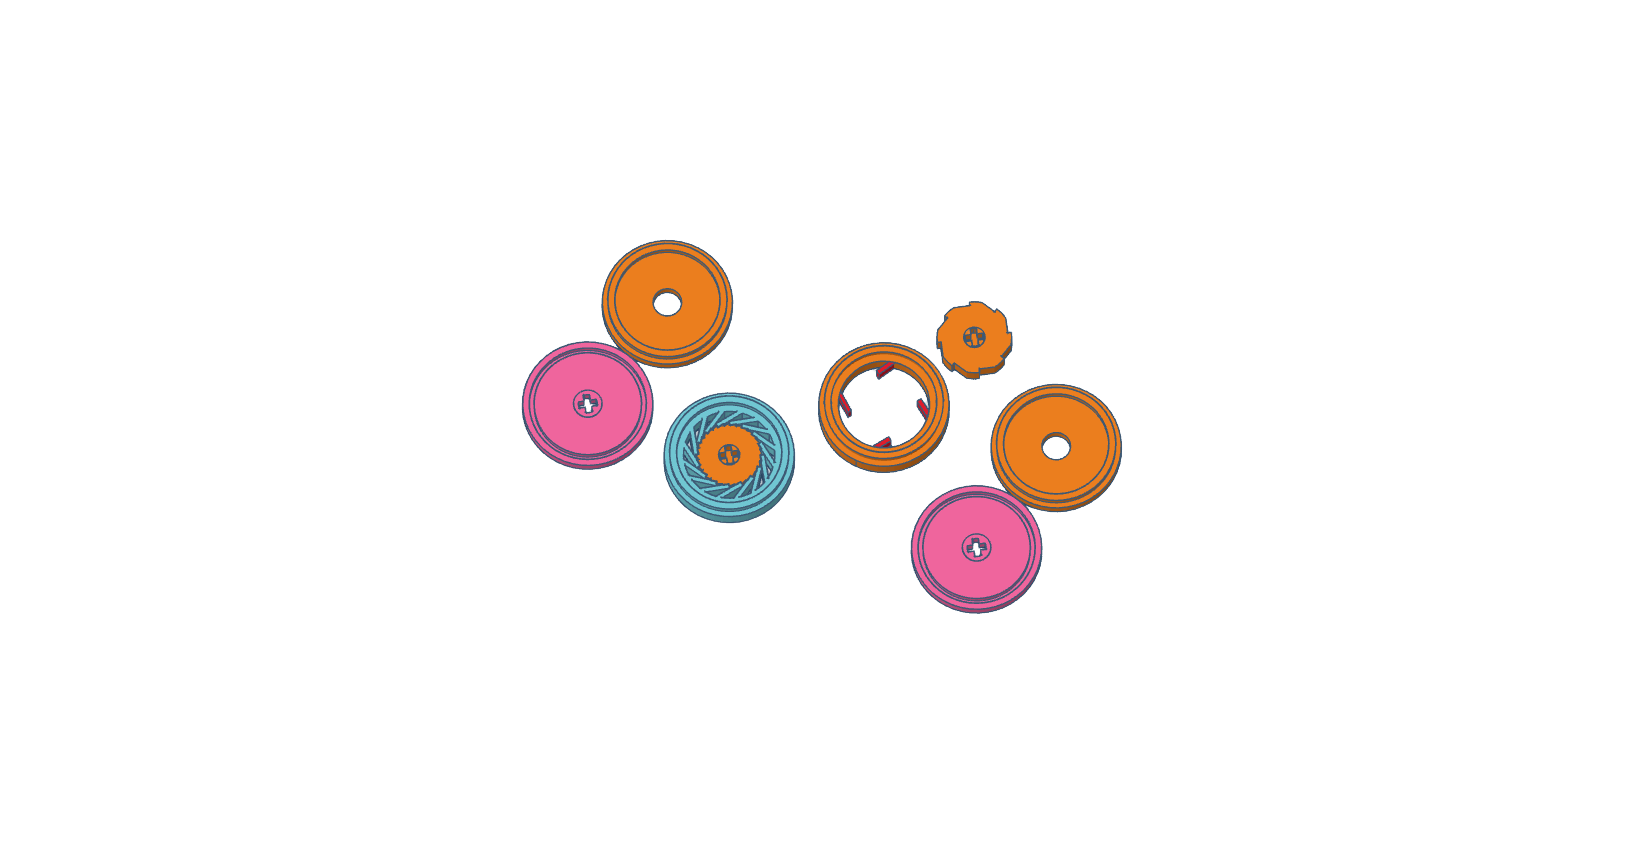
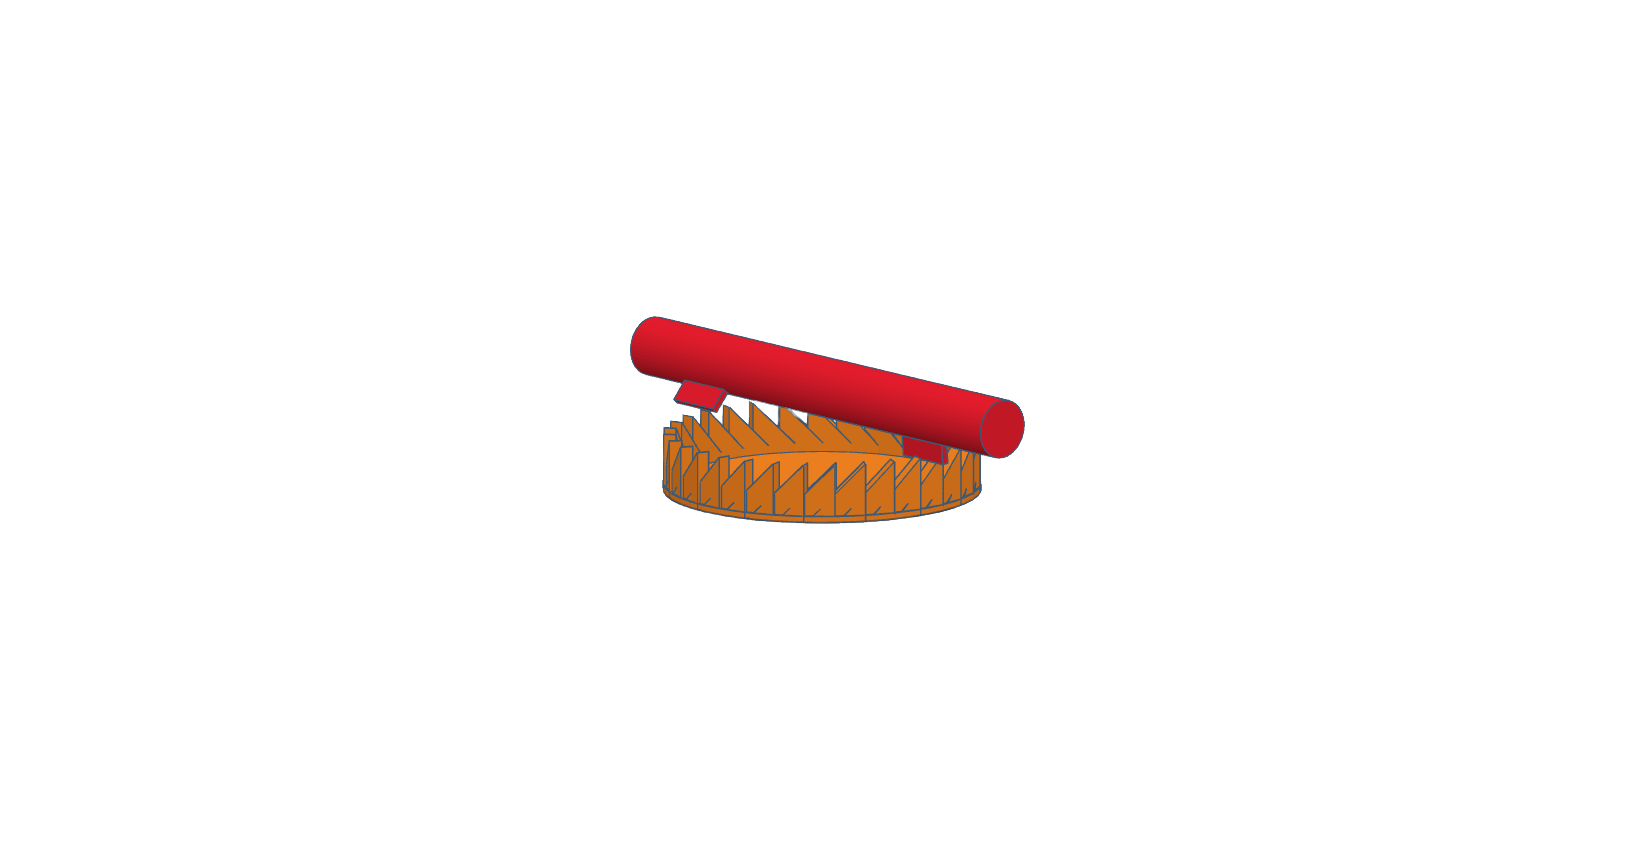
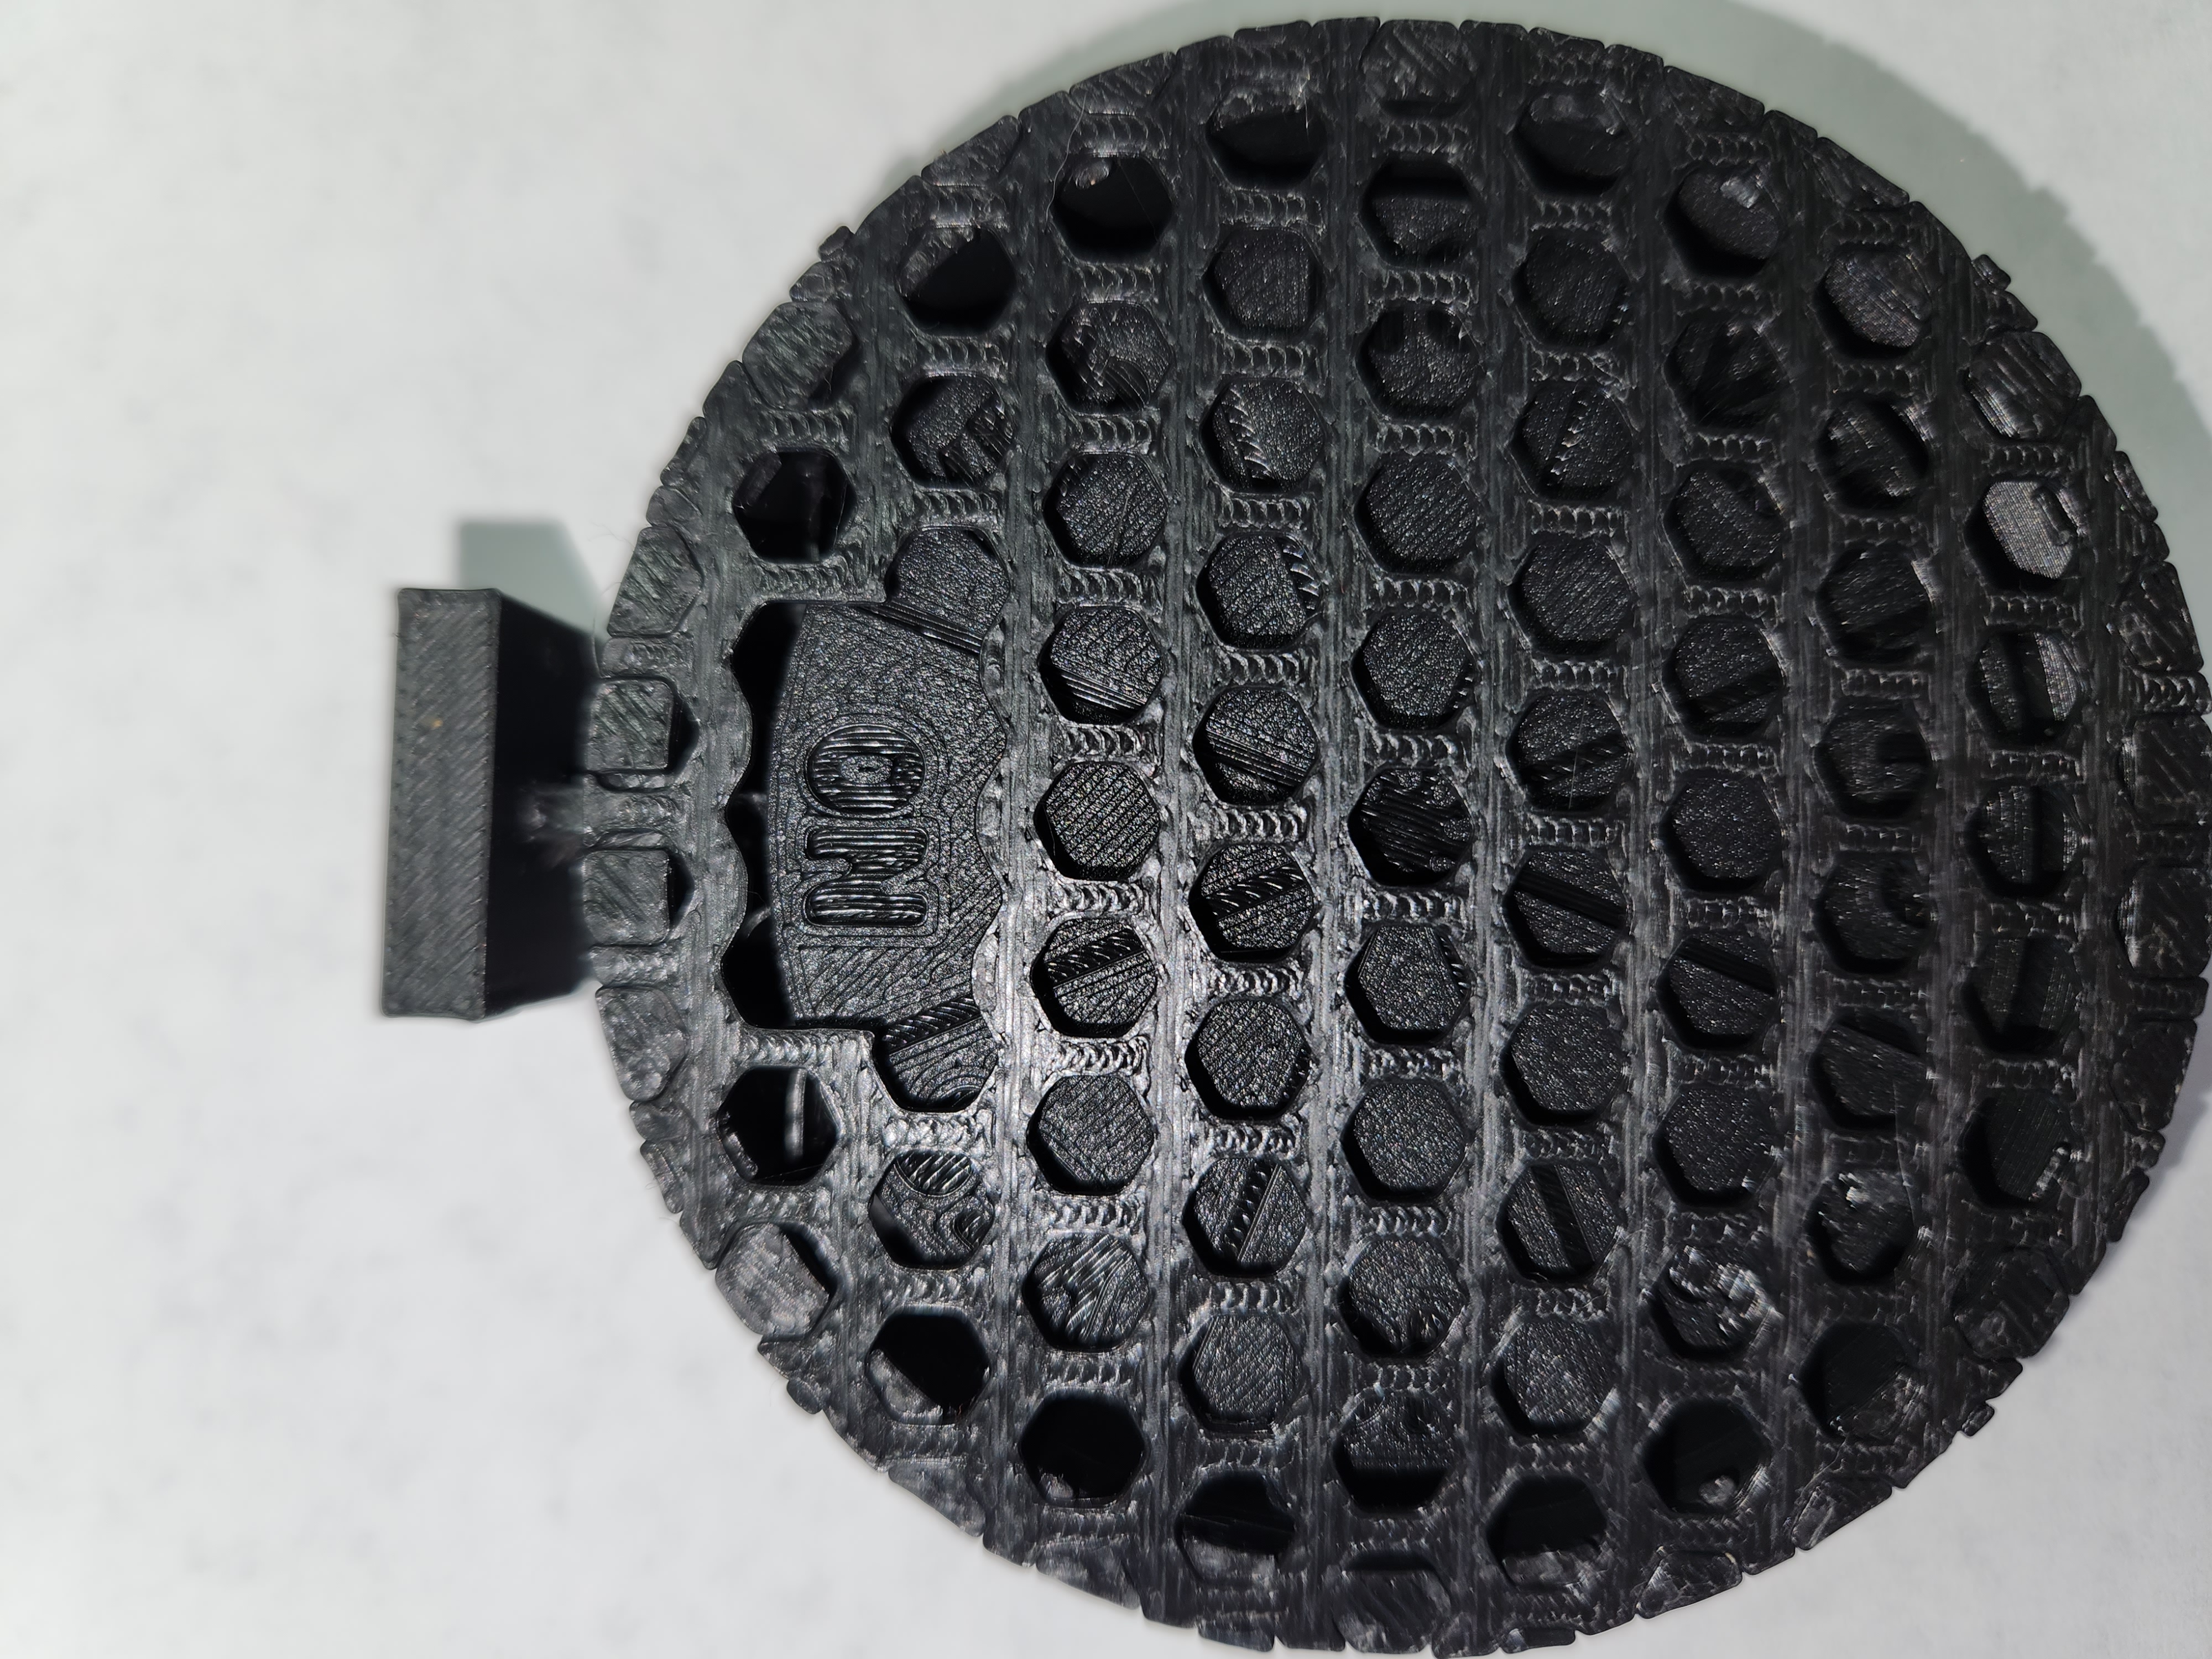
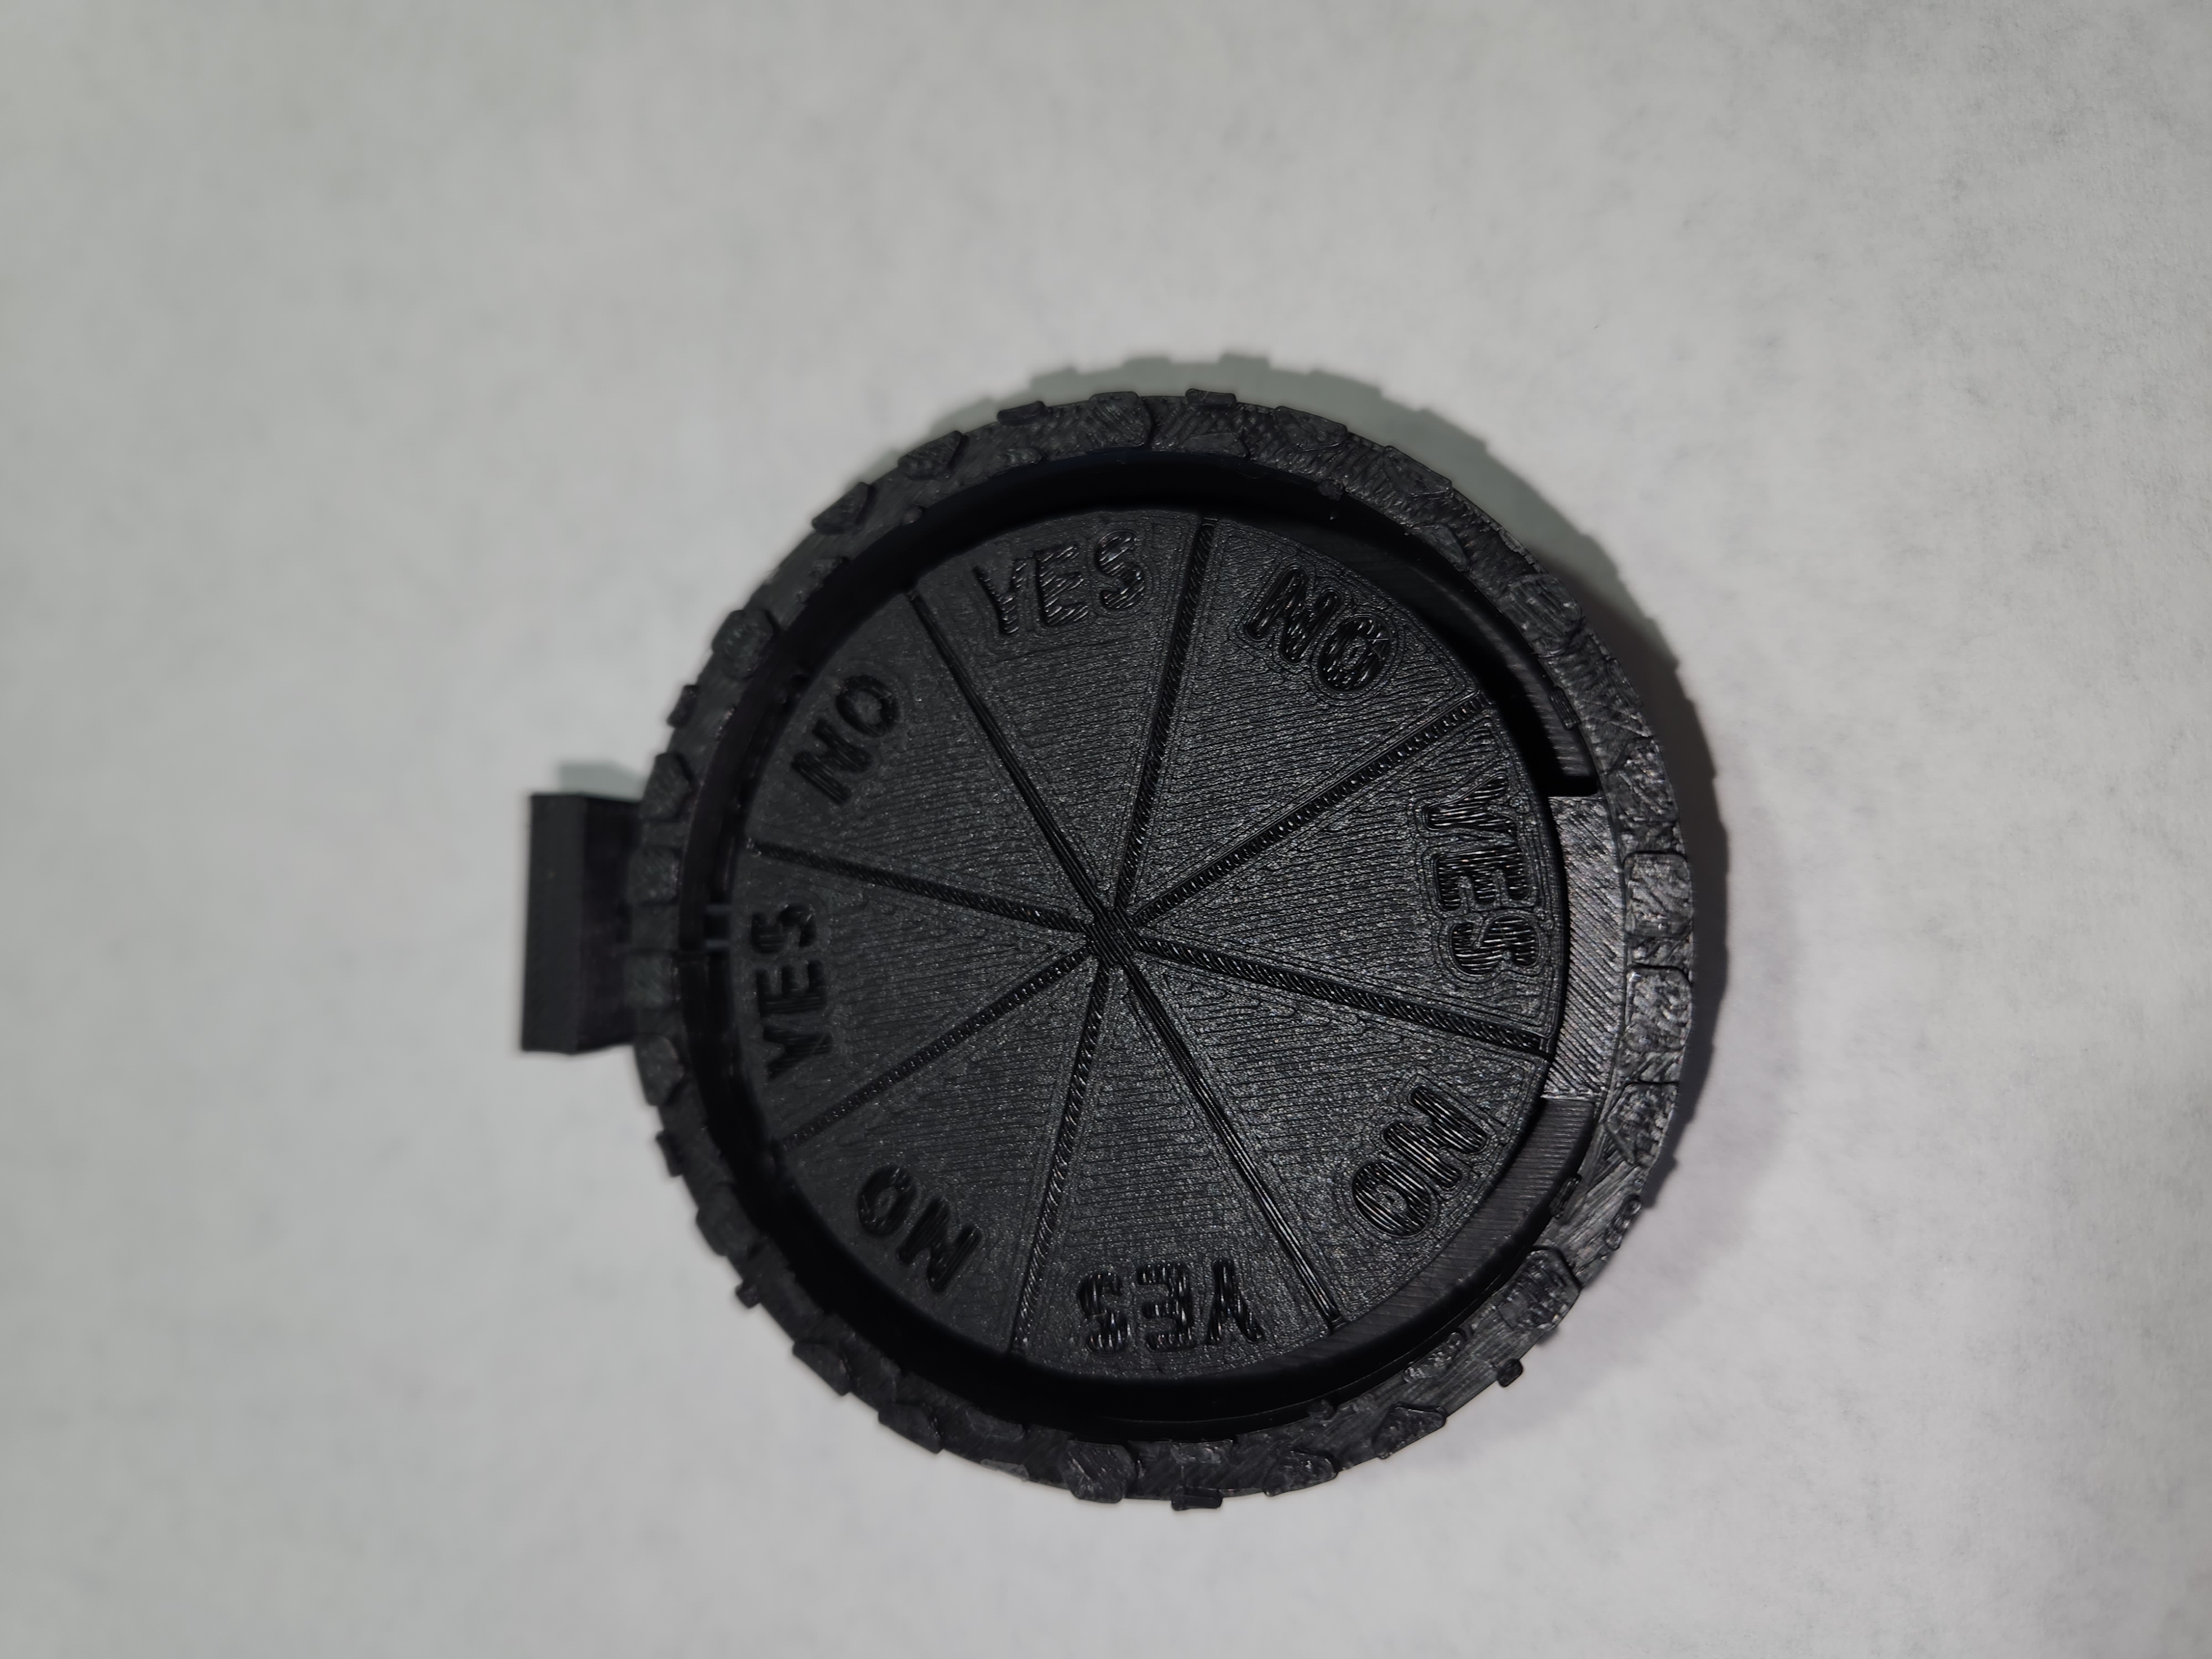
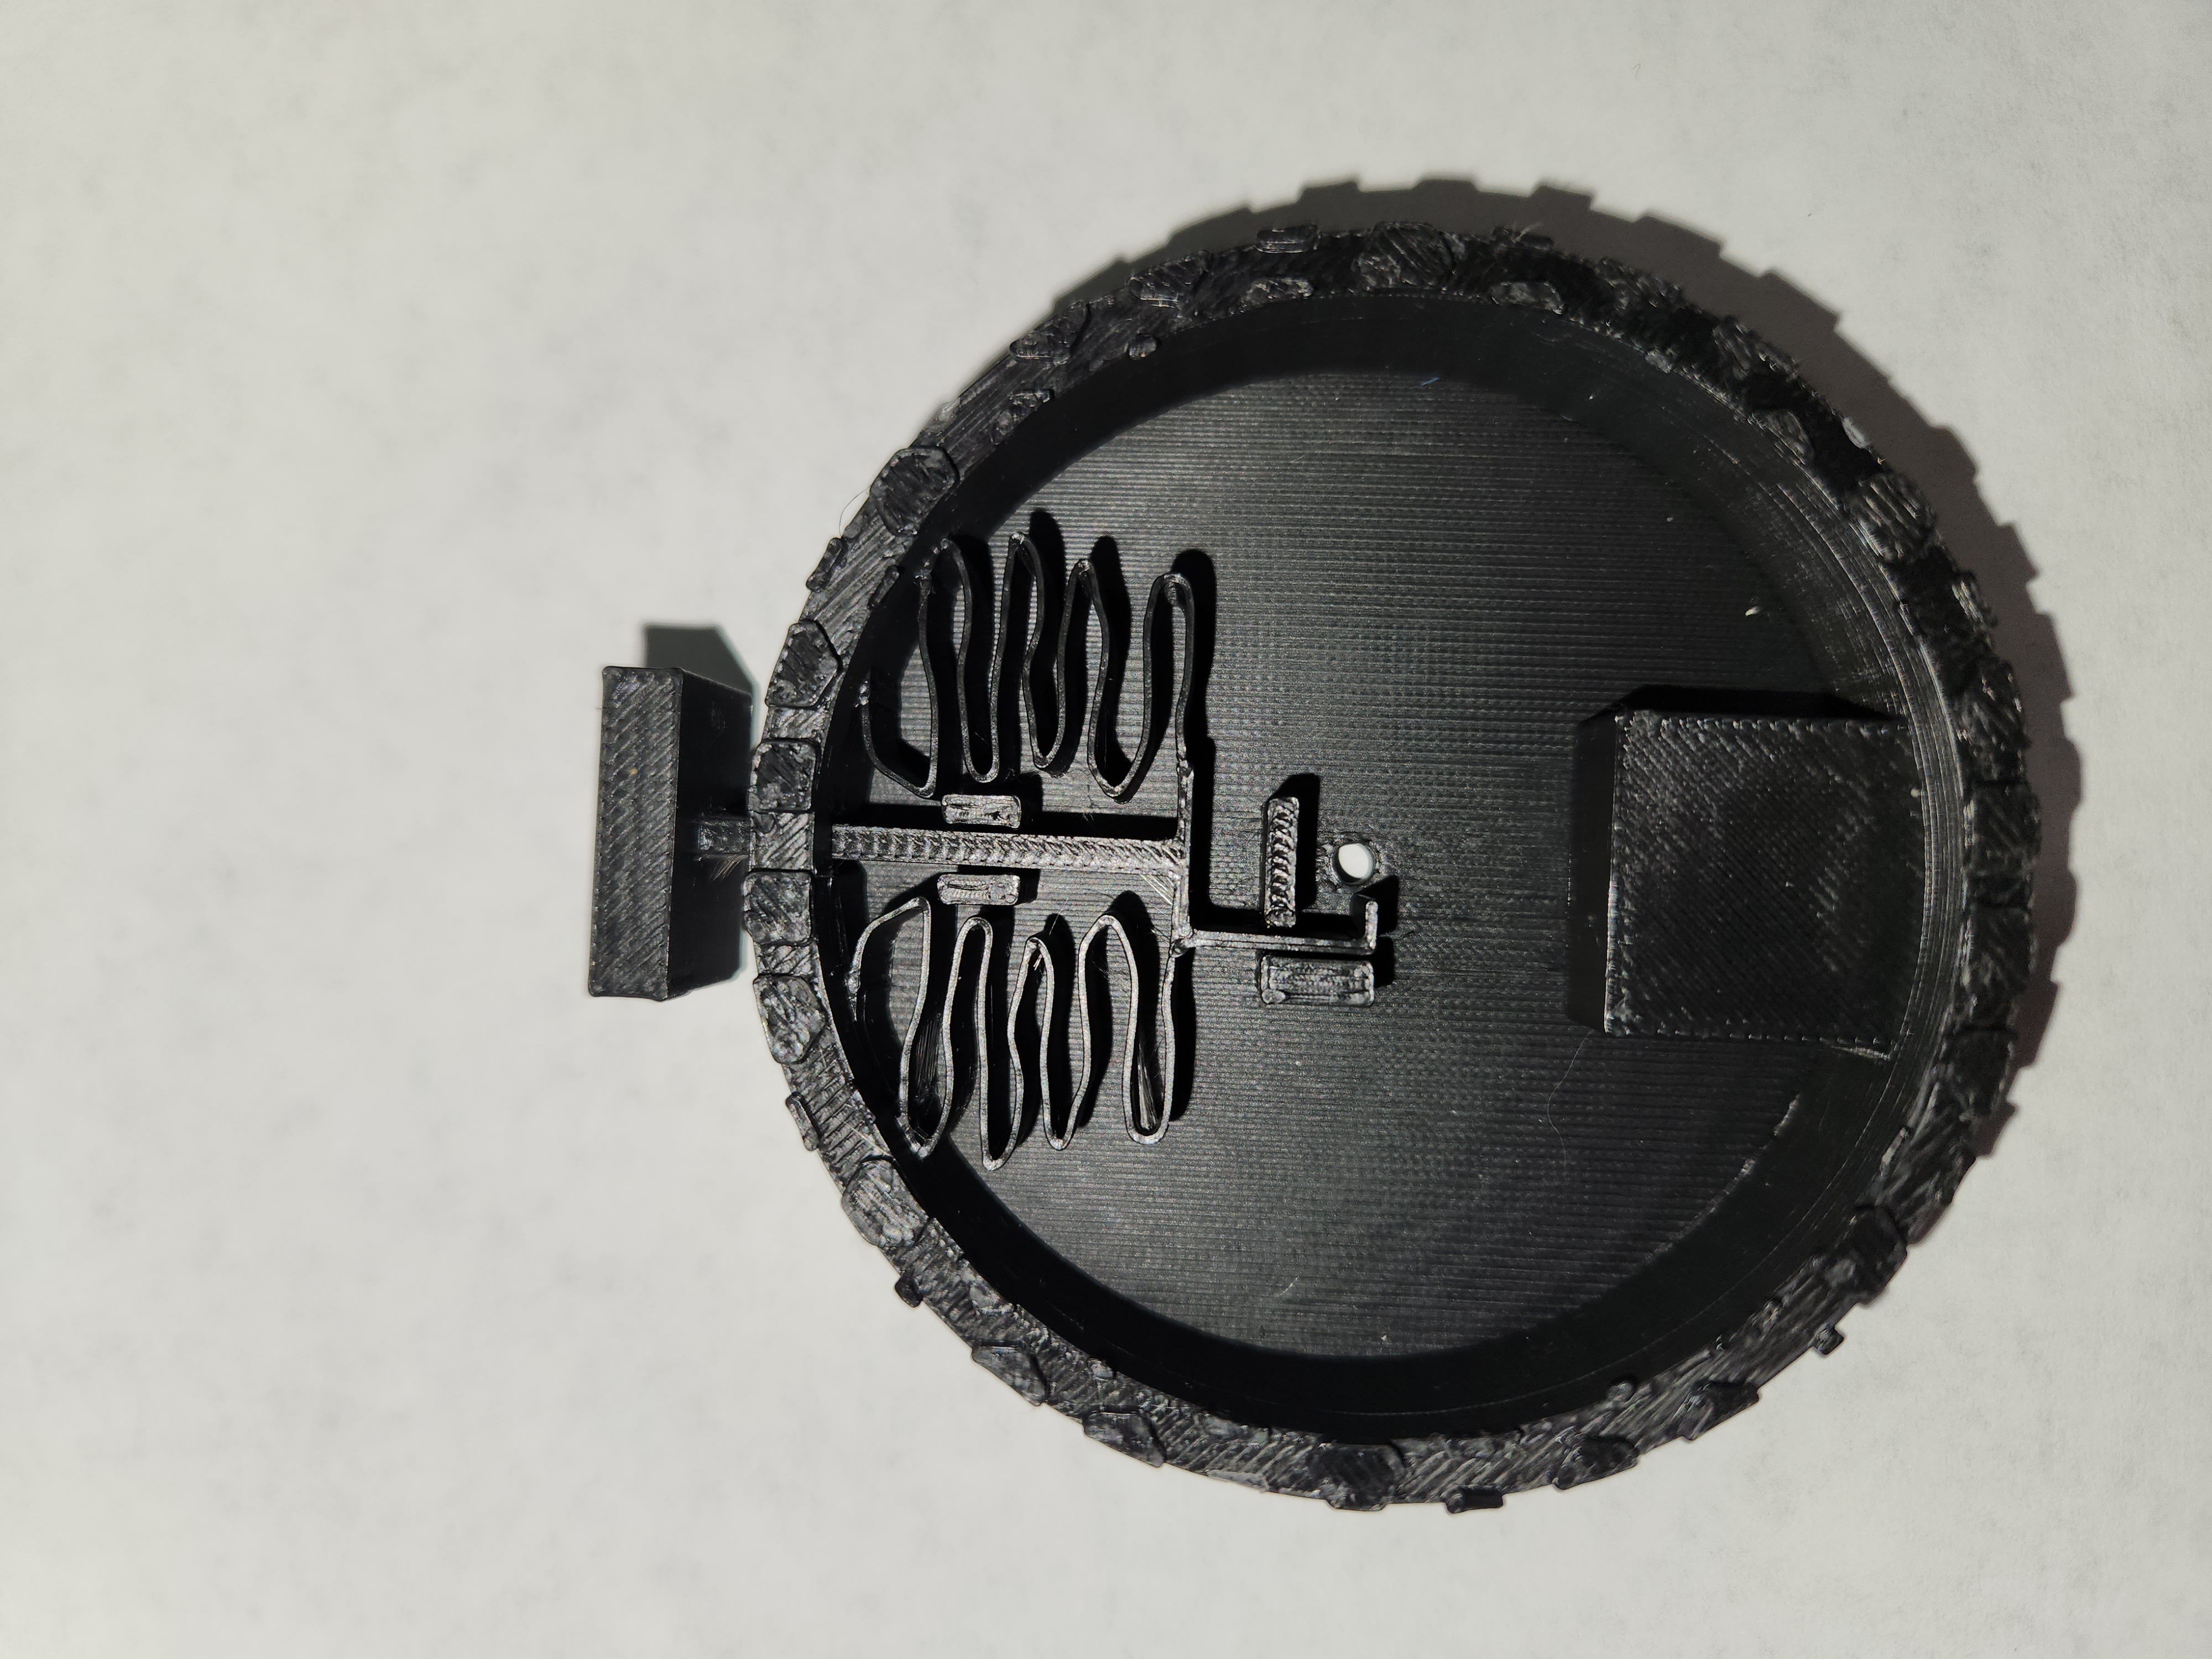
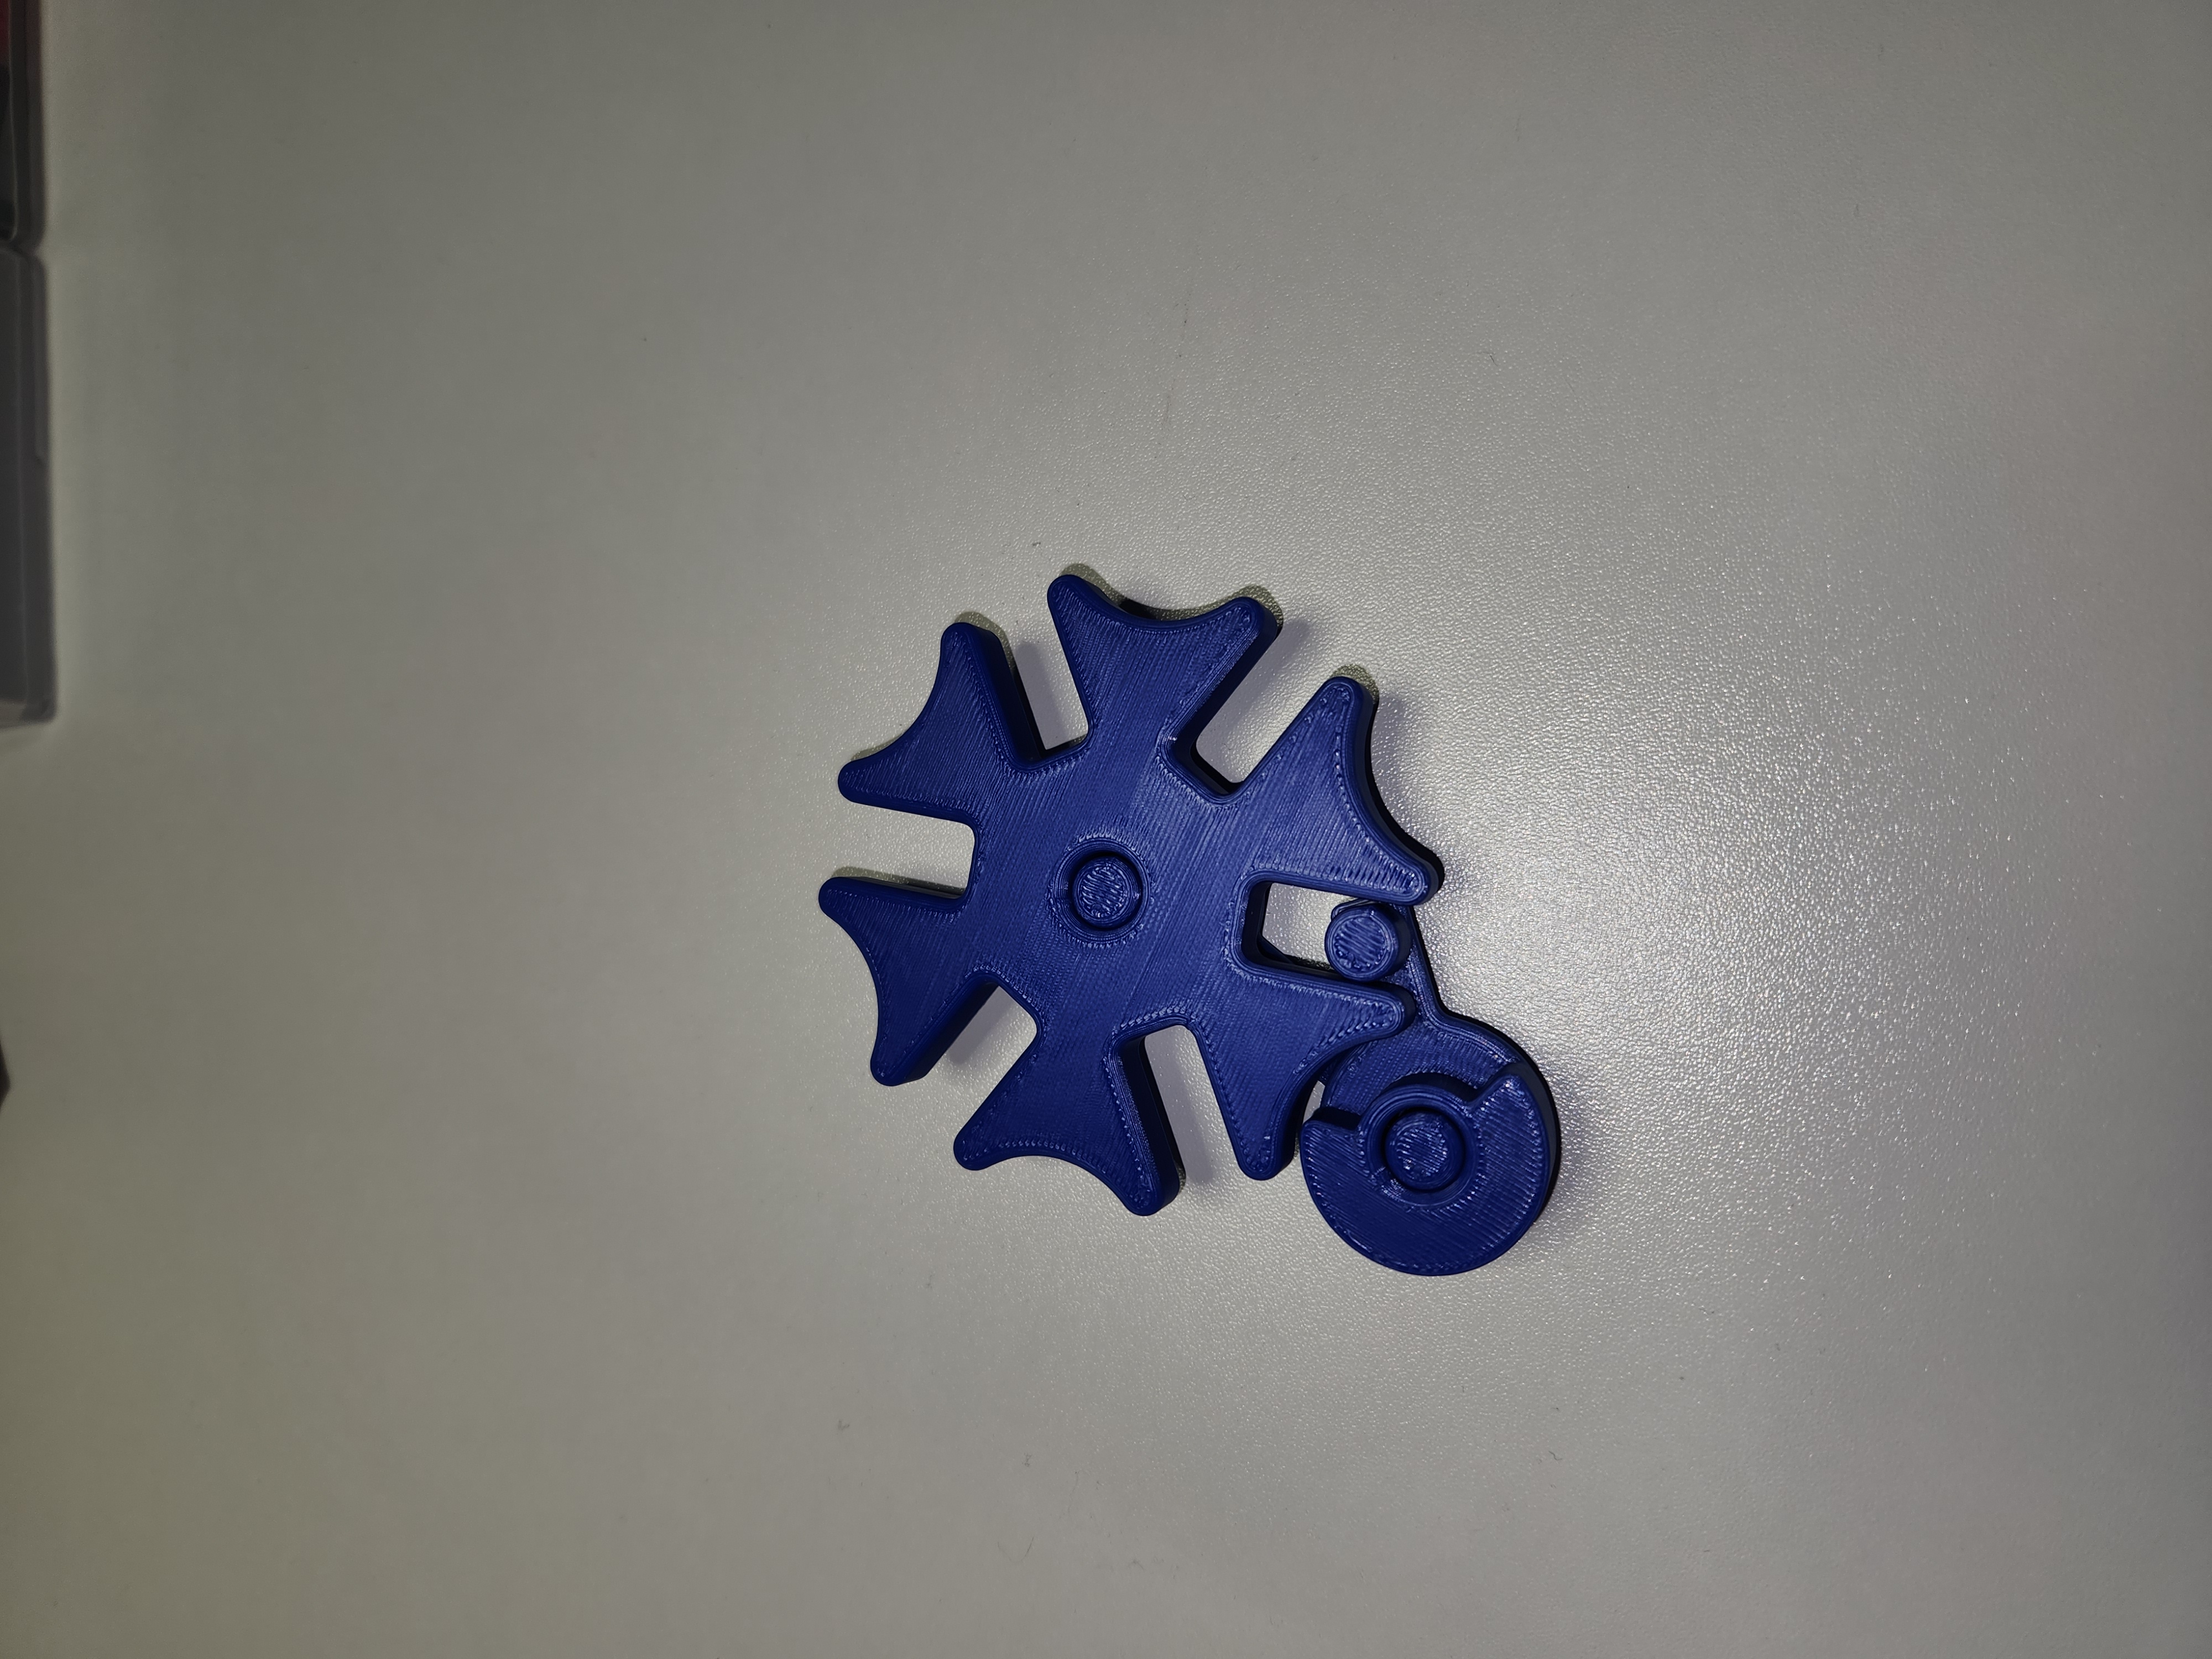
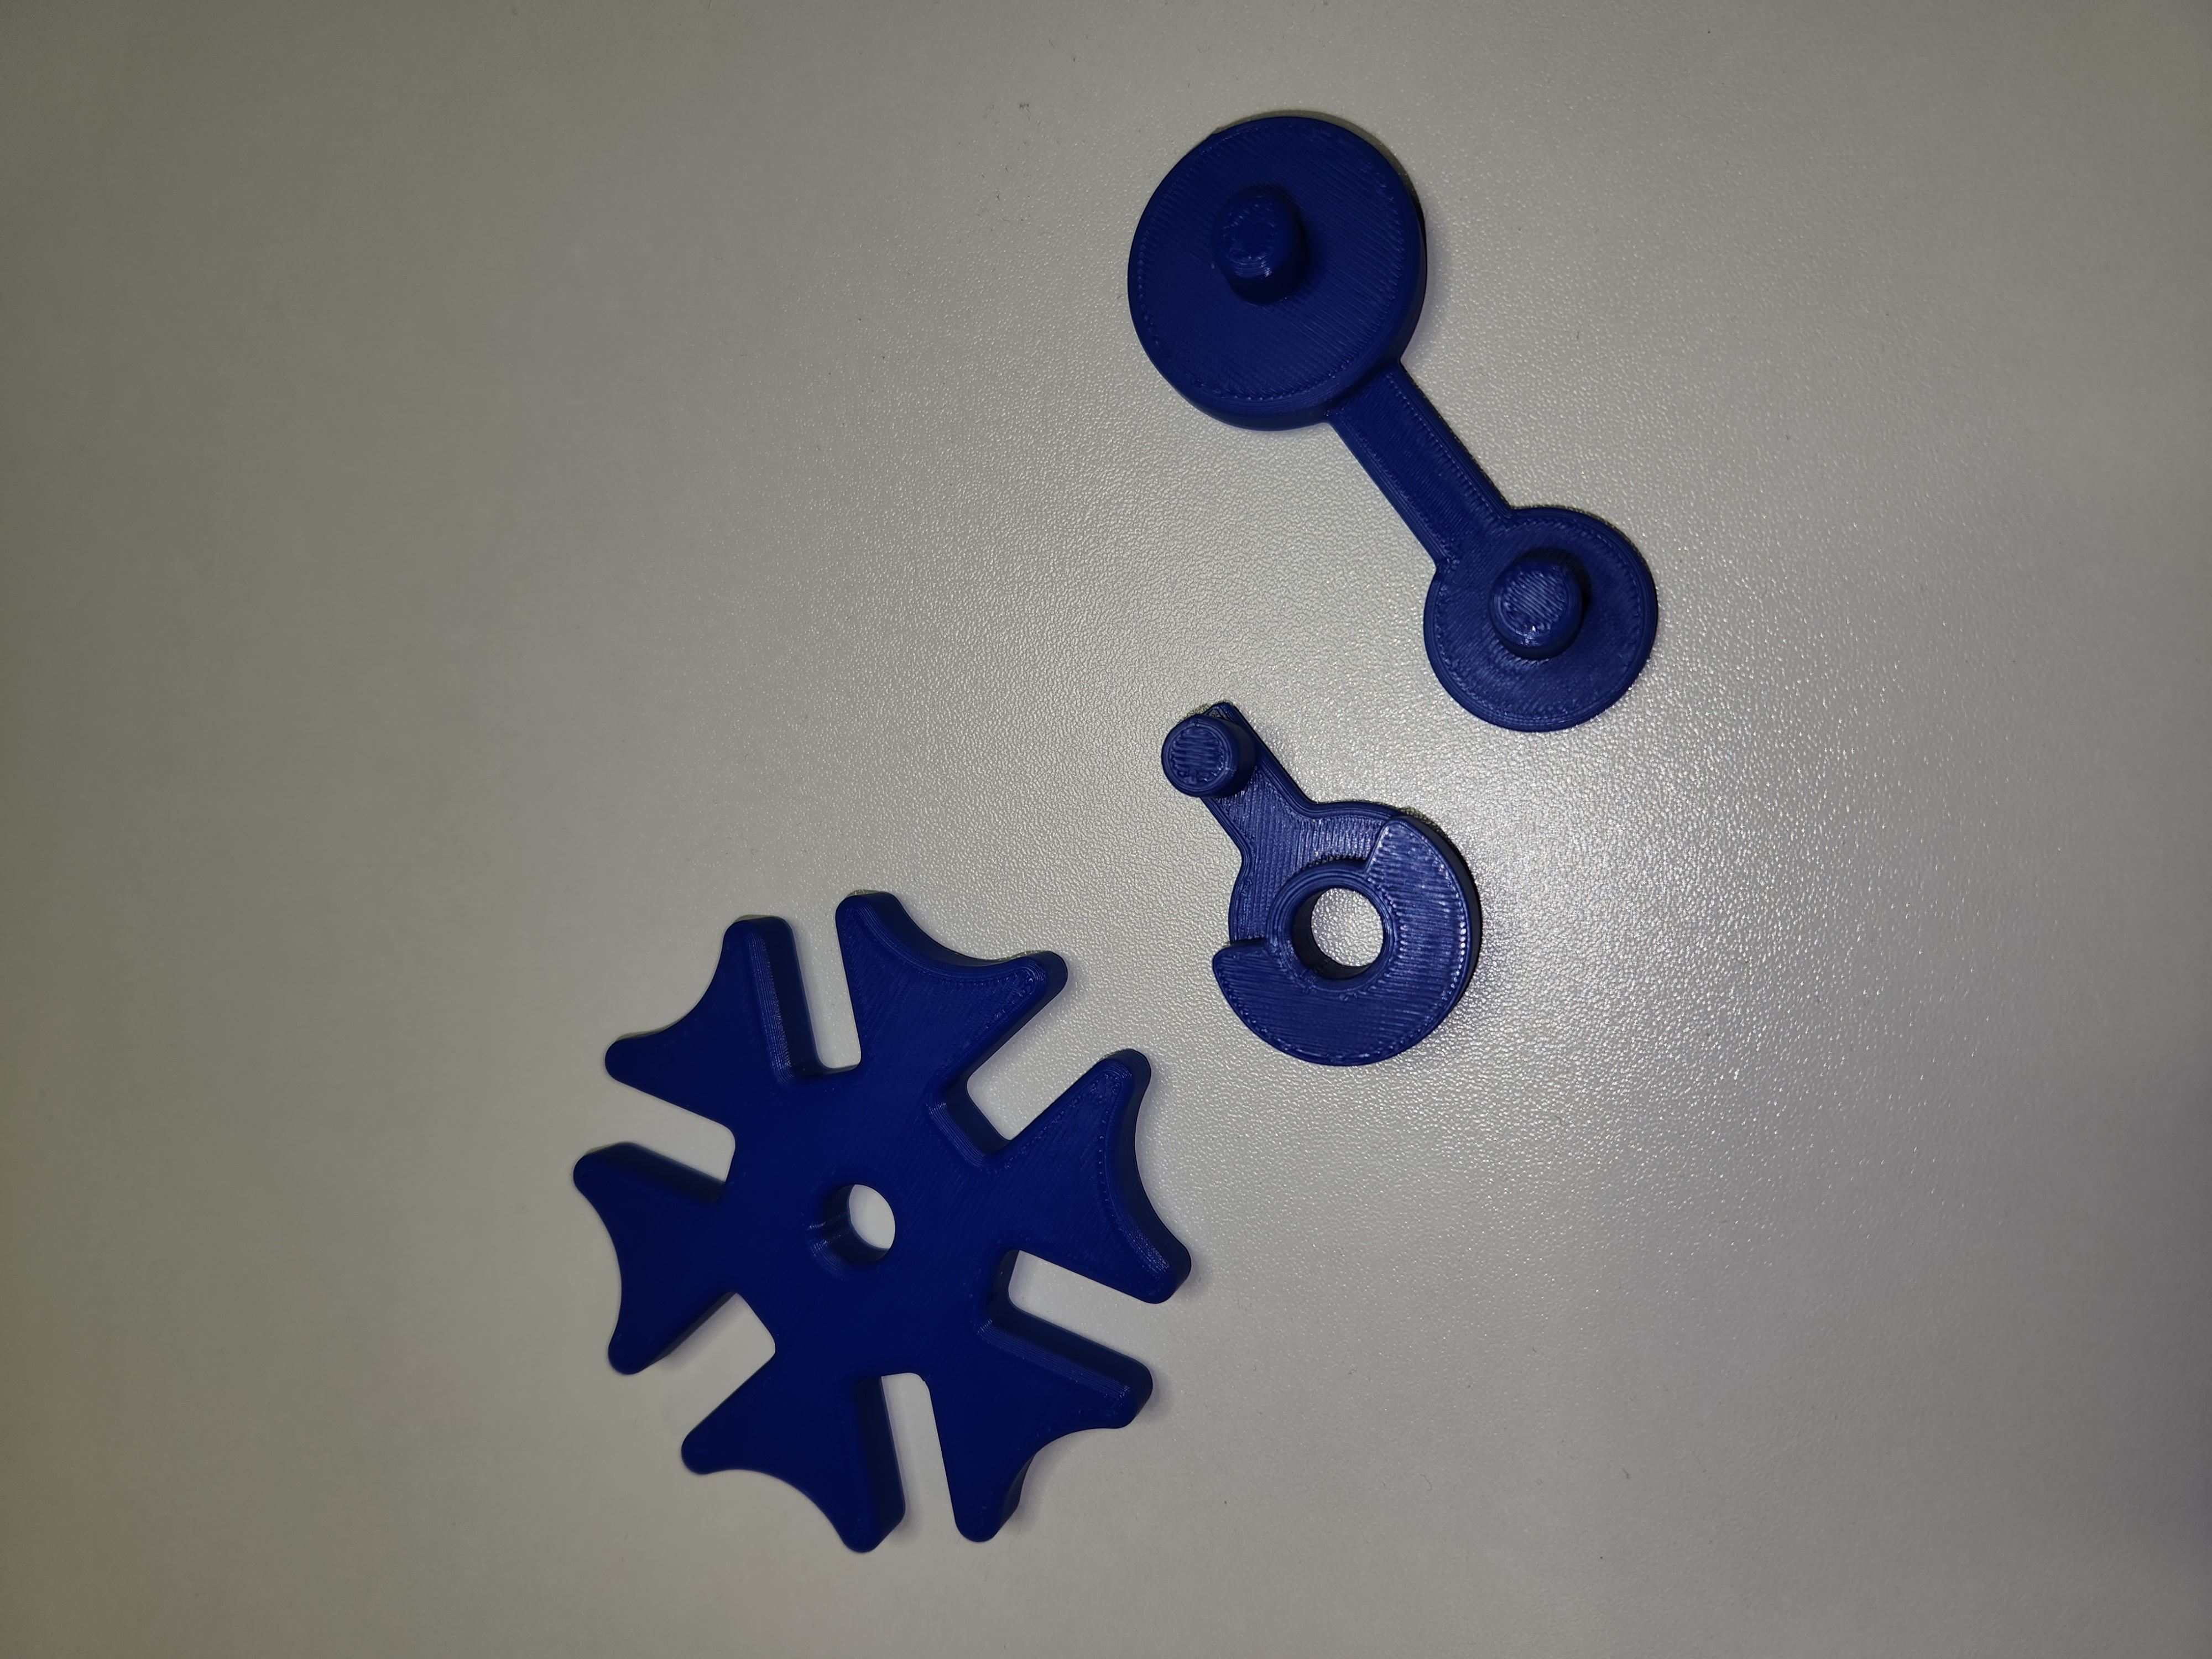
Center Cap Retention Interface
Maintains internal spherical core tension
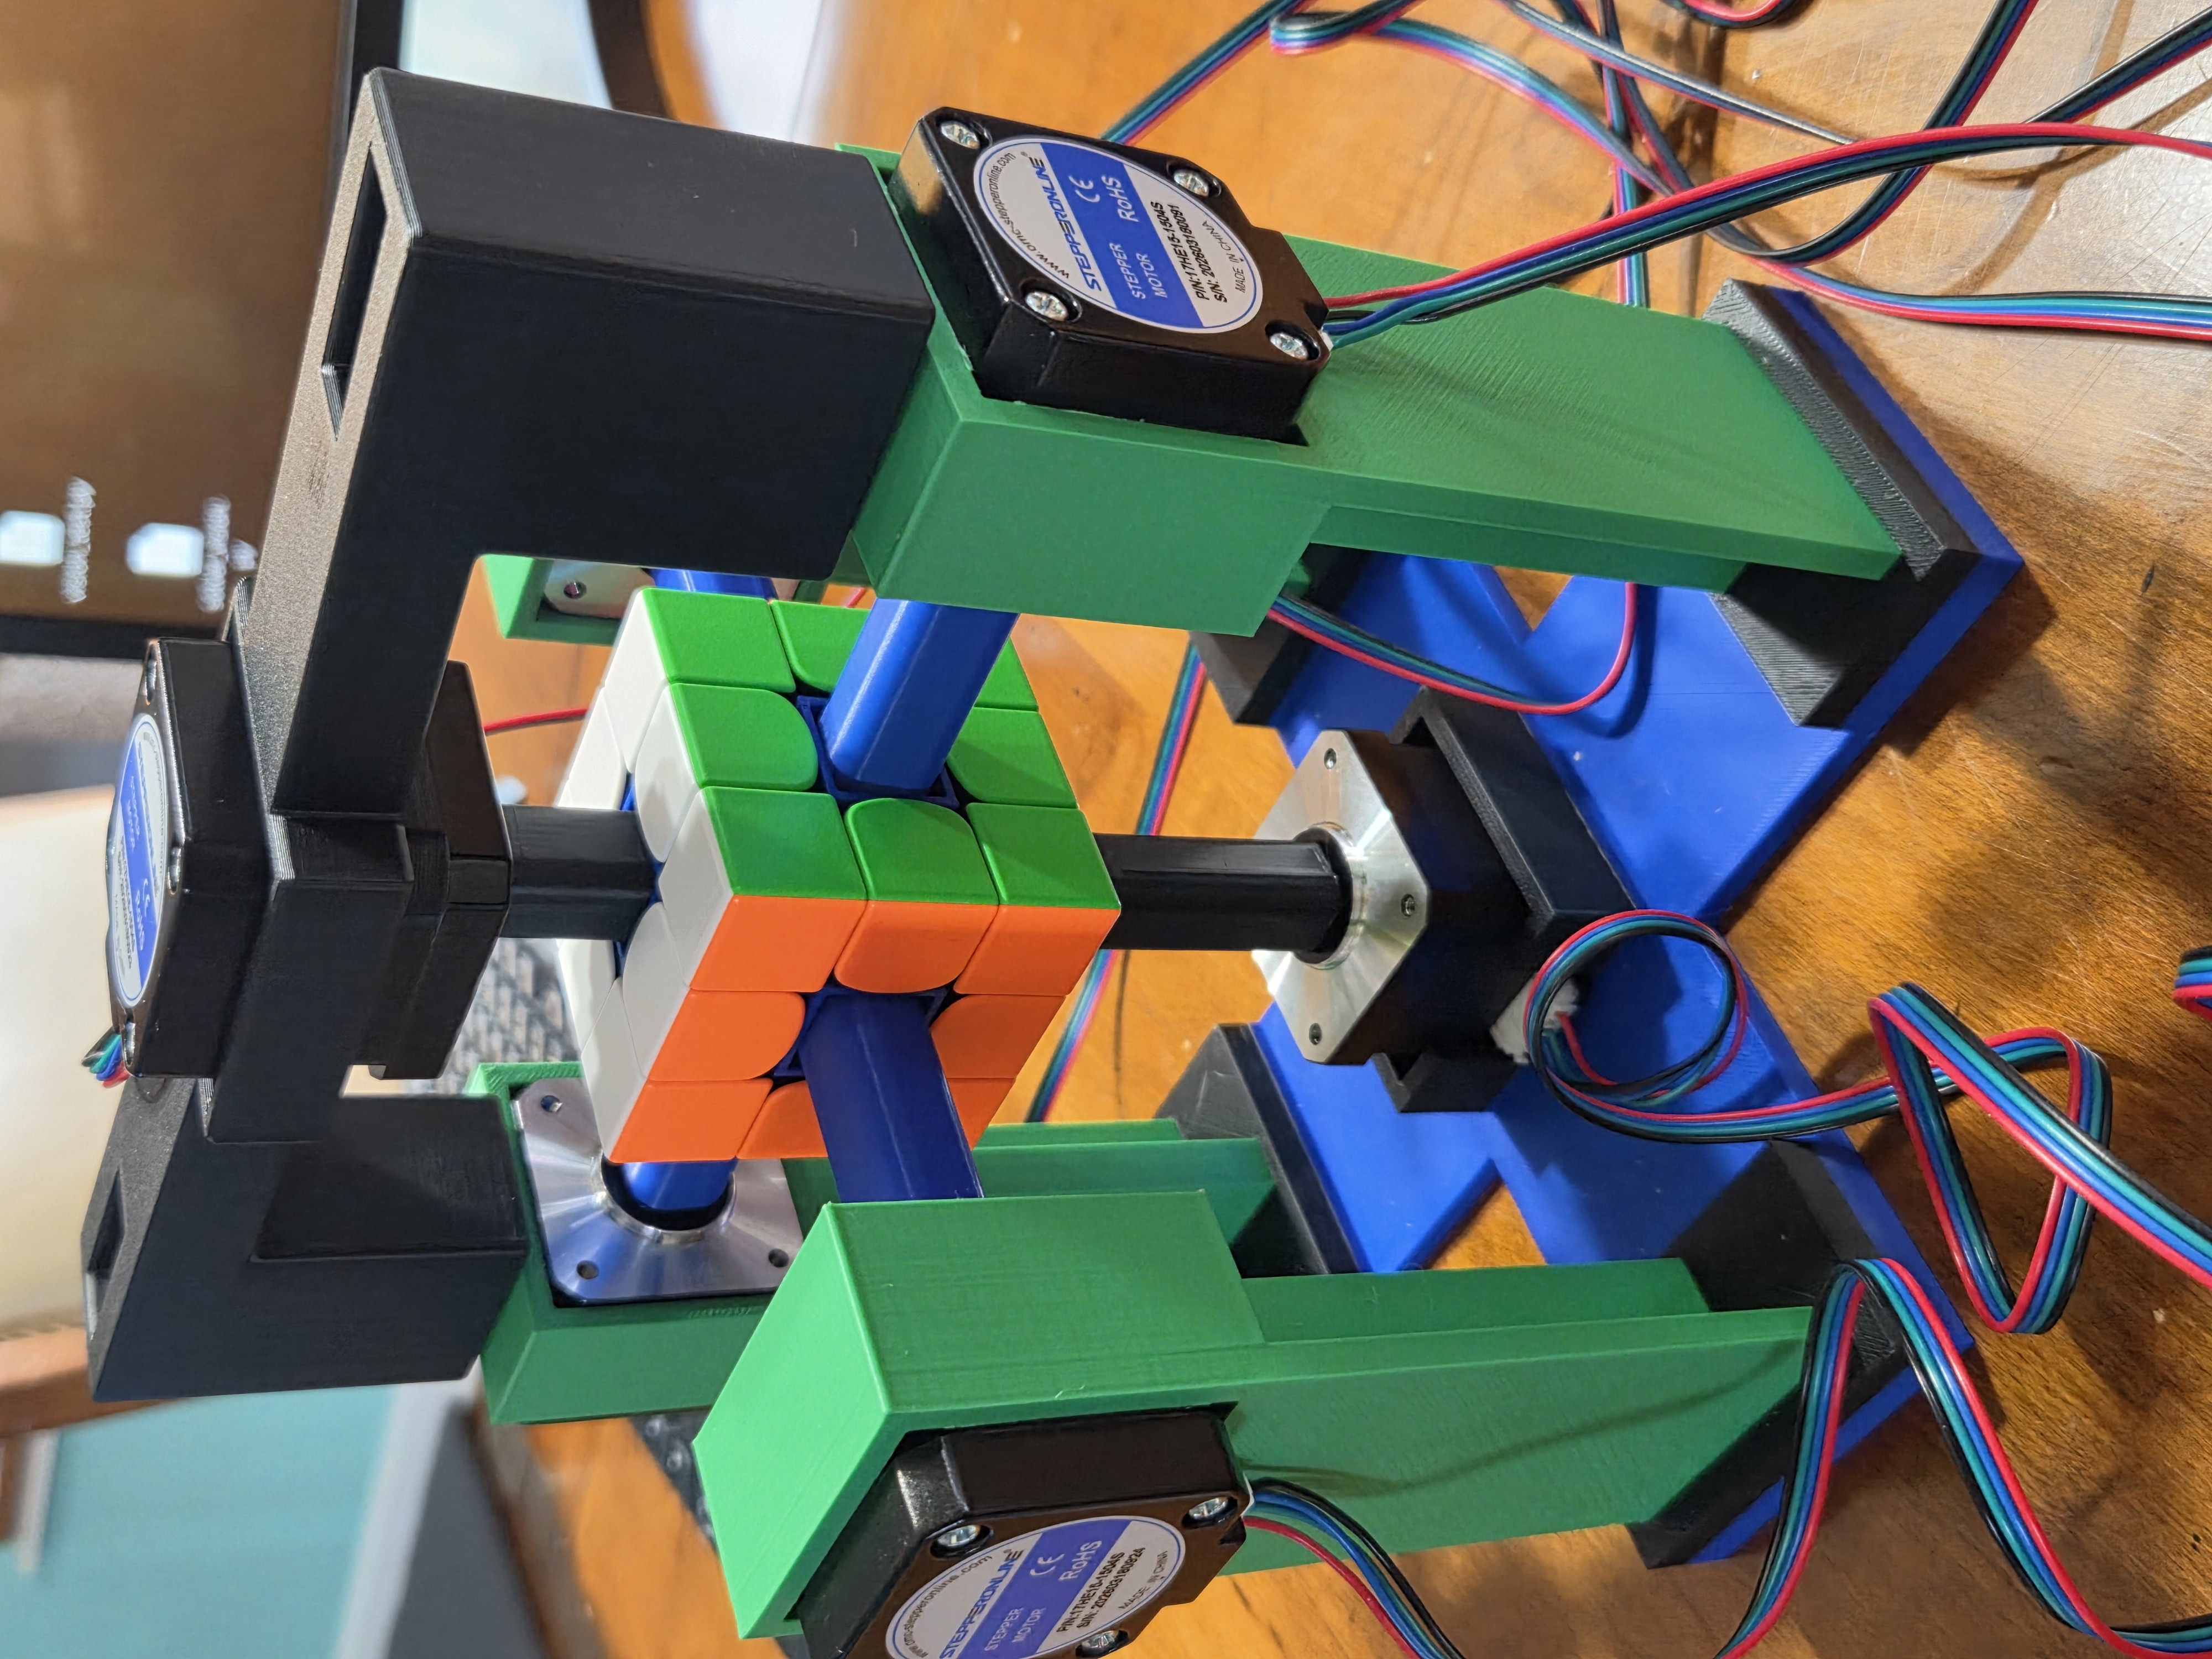
Orthogonal Axis Tolerancing
Zero-backlash face coupling alignment
⚡ 24V Mechatronics, Klipper MCU &
Two-Phase Solver
Click to view telemetry & wiring
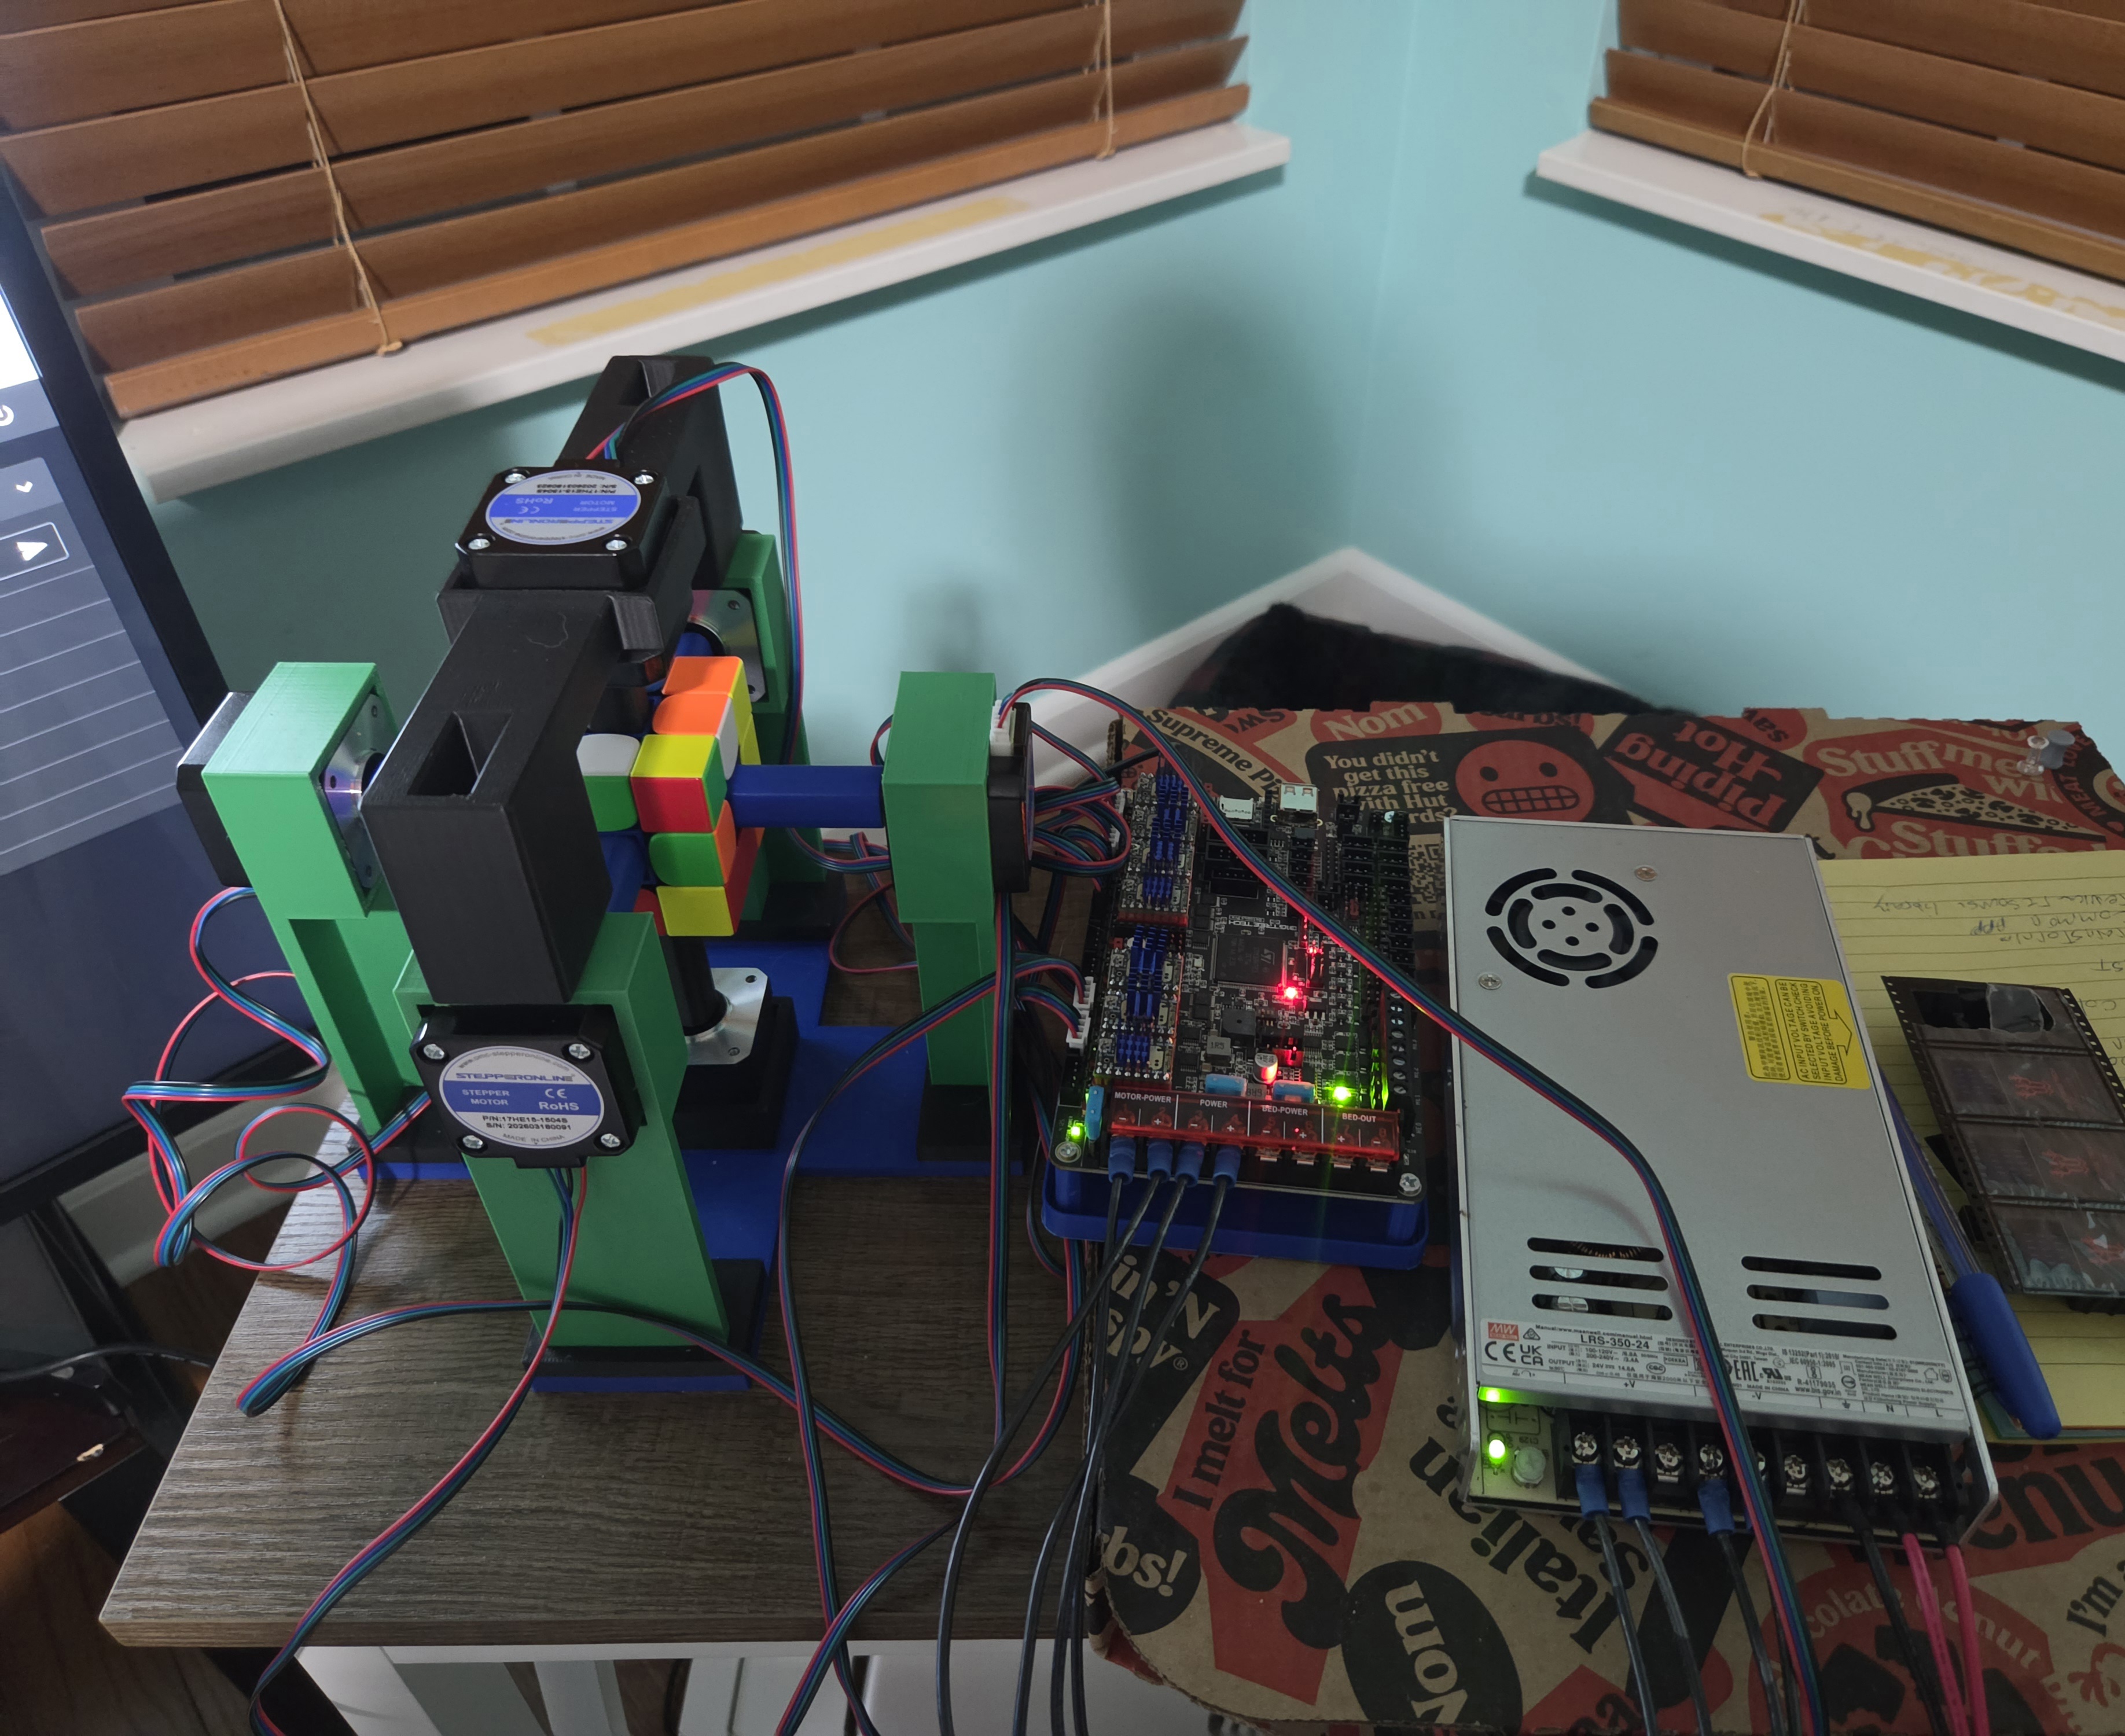
24V Power & TMC2209 Driver Bay
350W Mean Well PSU + silent microstepping
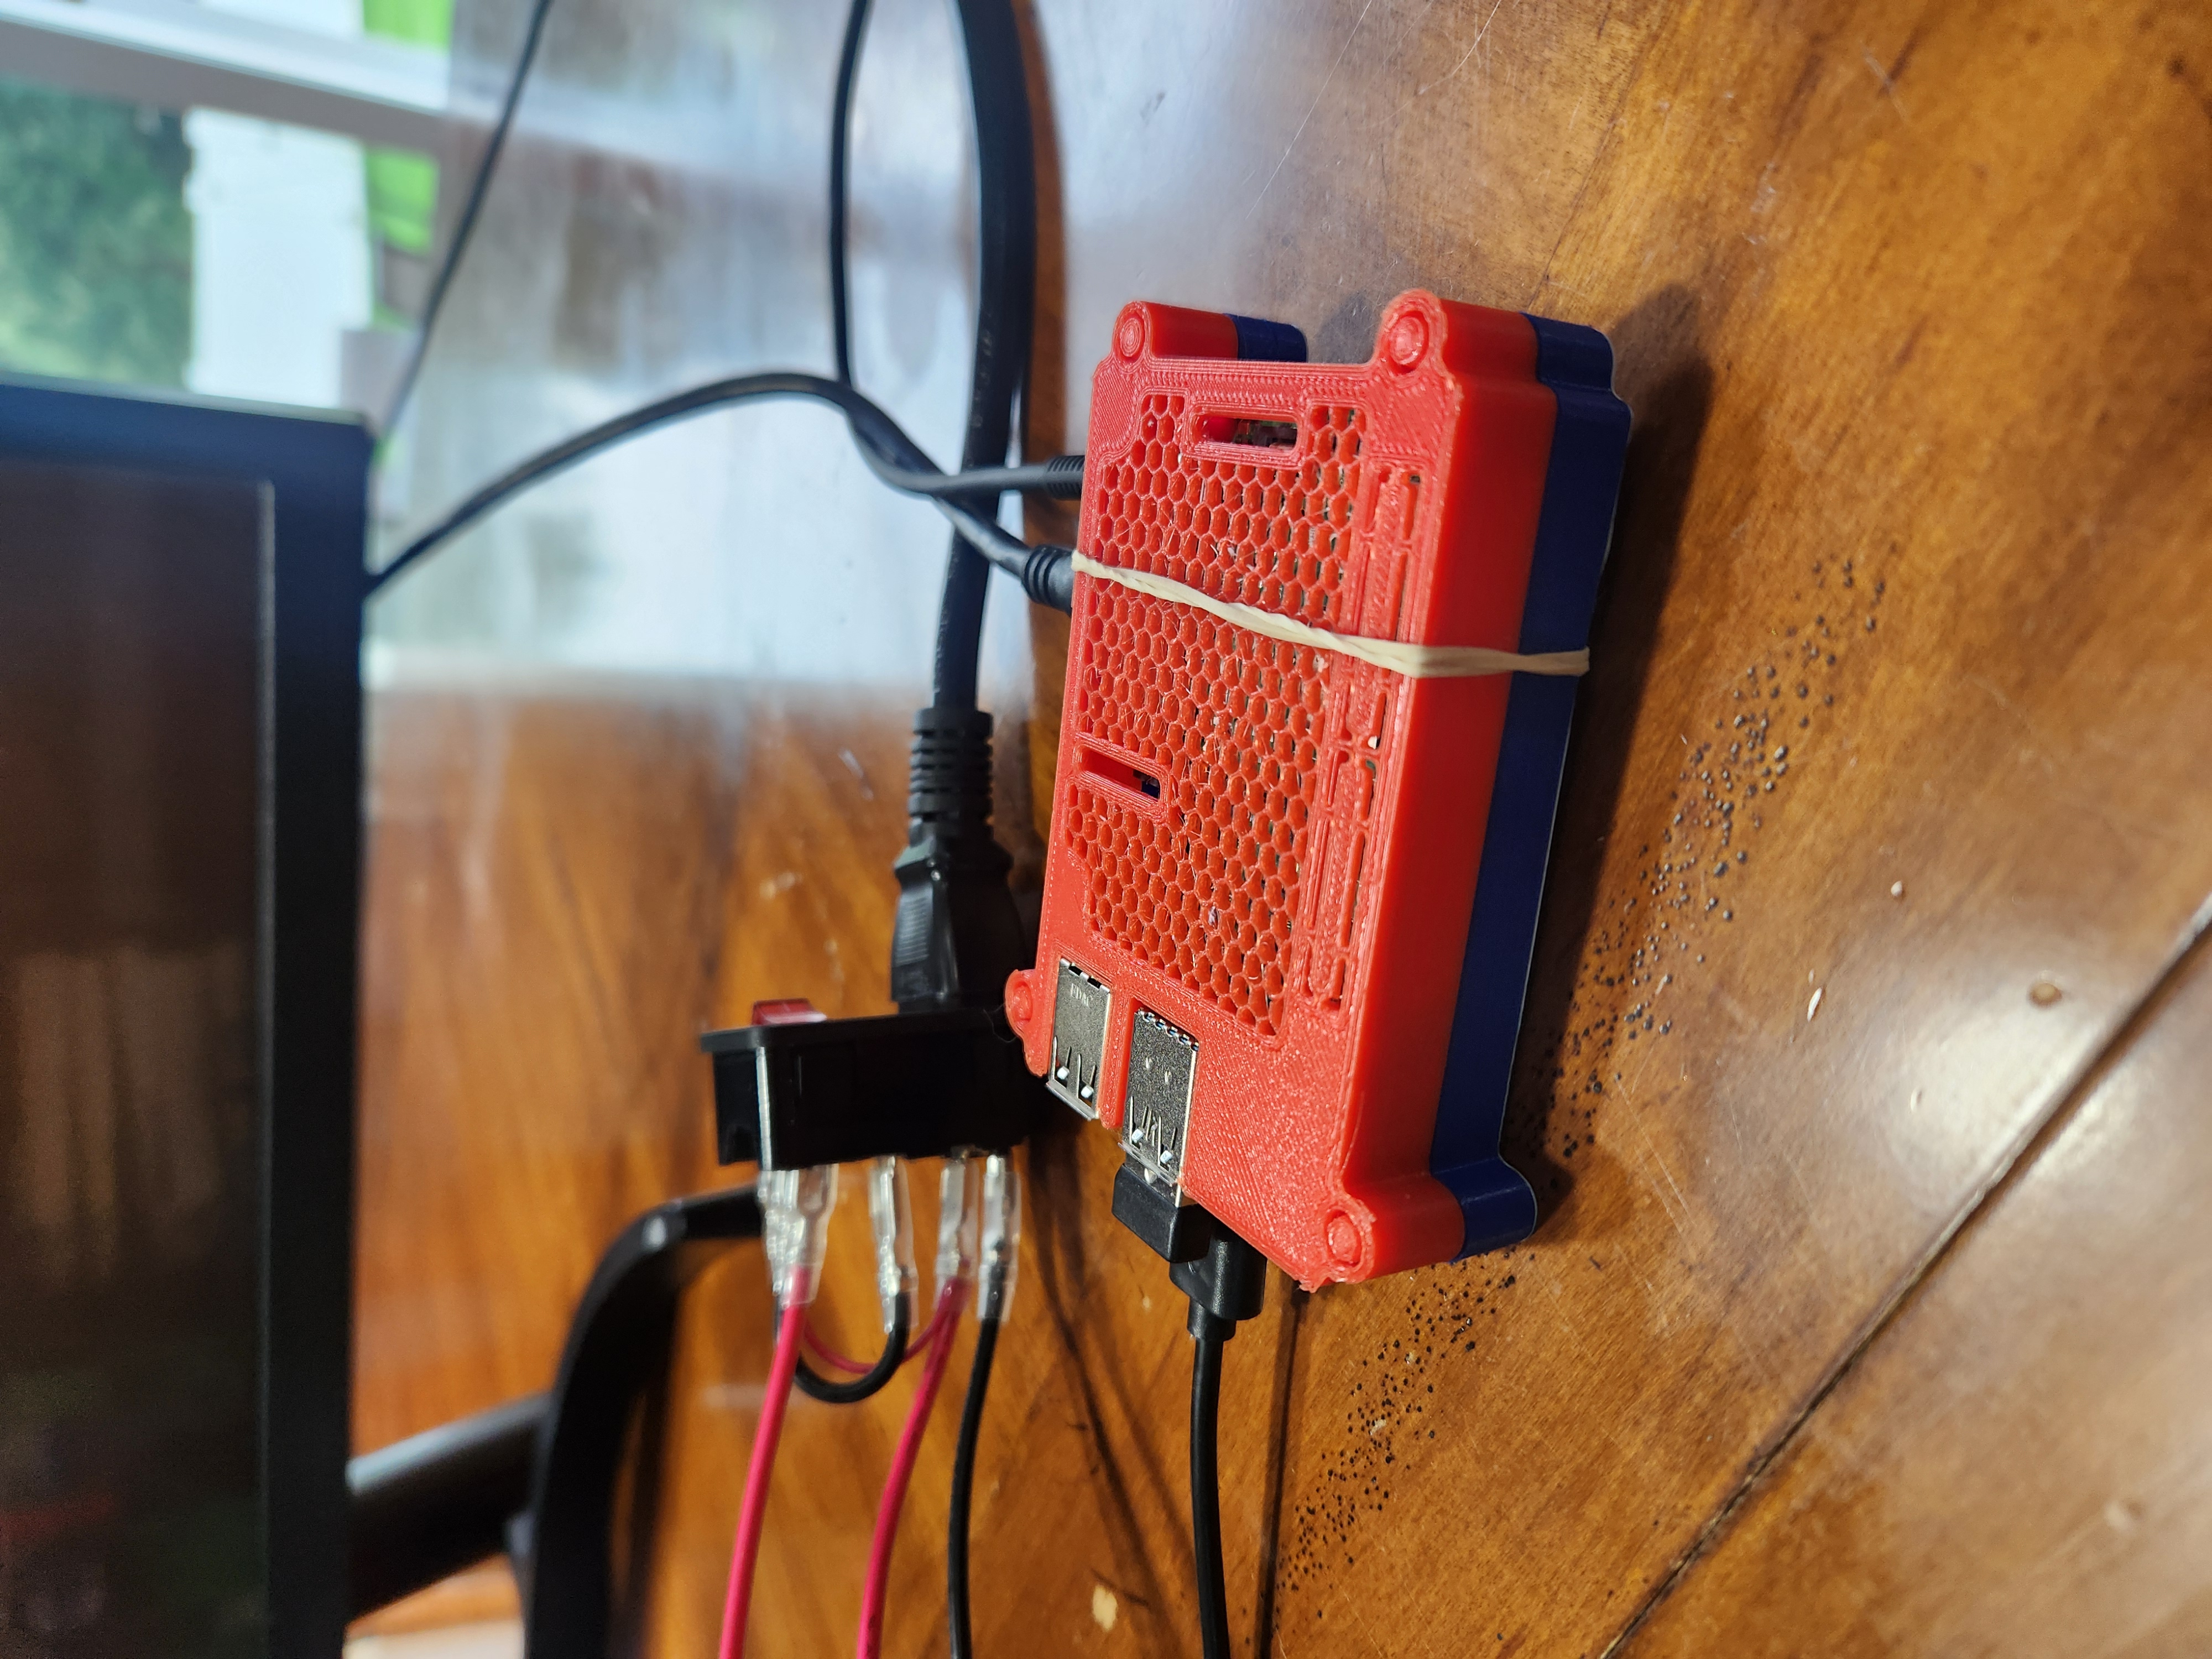
Raspberry Pi Enclosure
Custom cooling housing + Klipper host
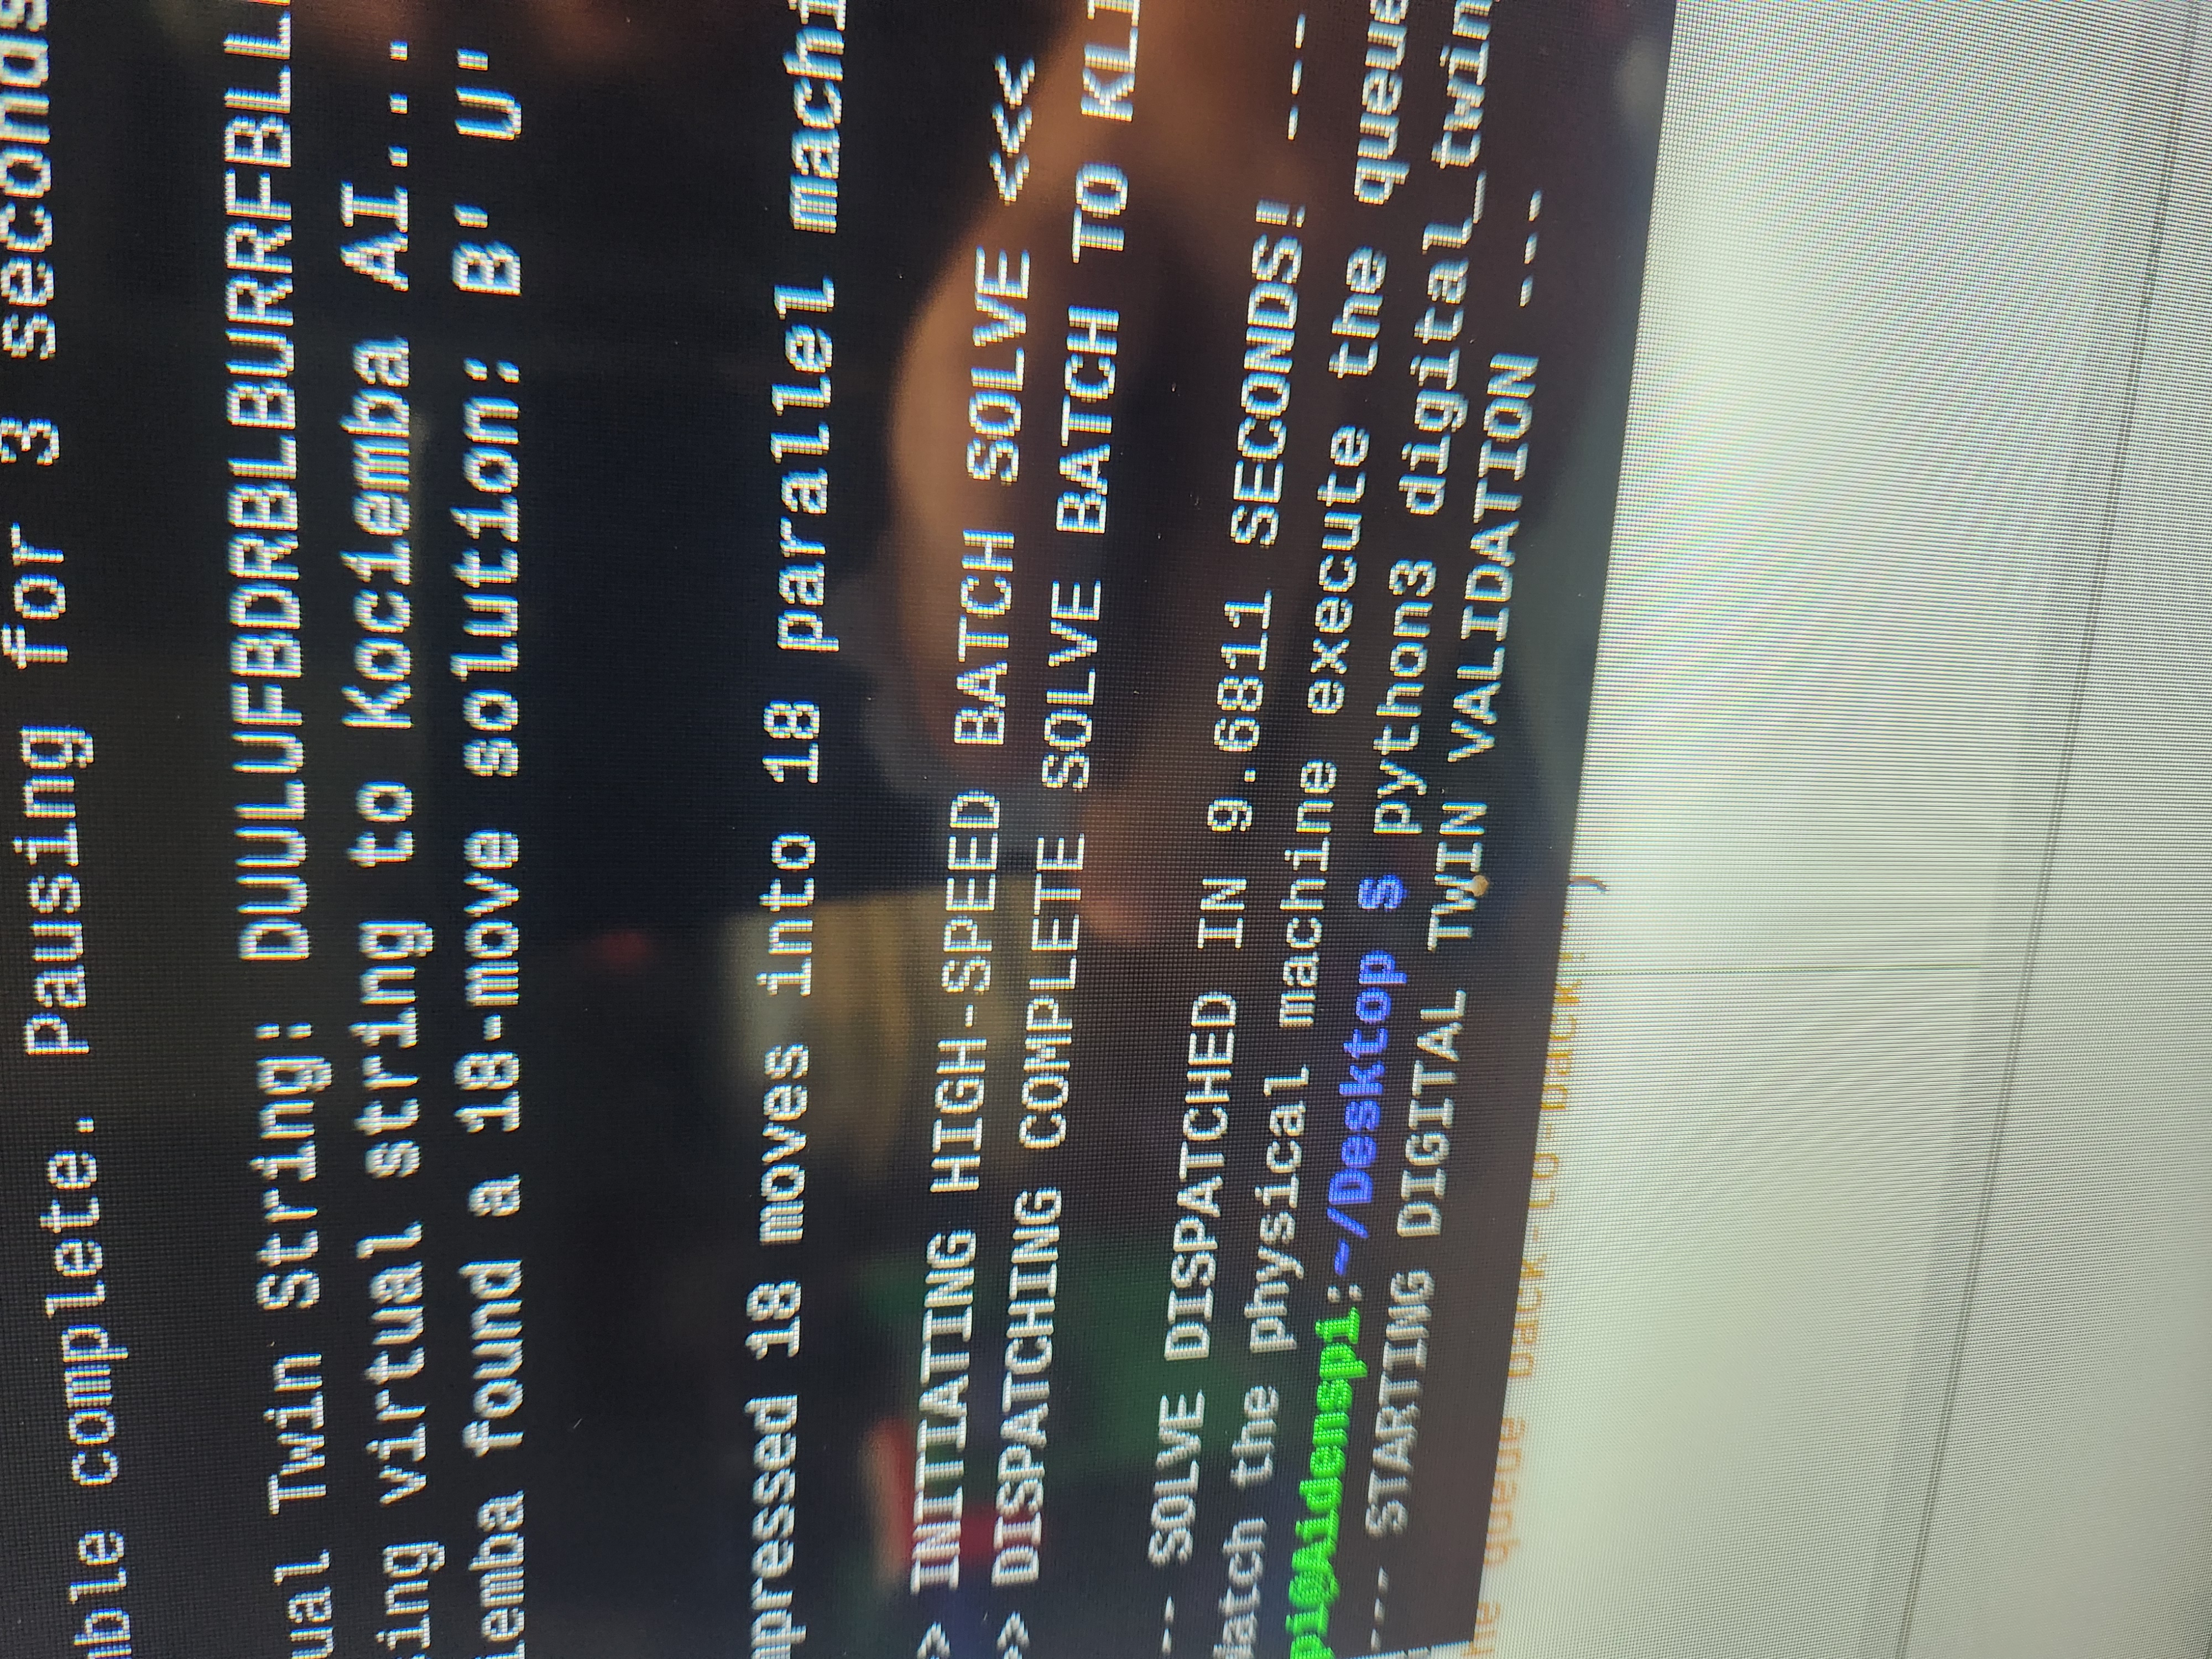
Kociemba Two-Phase Telemetry
Optimal solution + parallel move compression
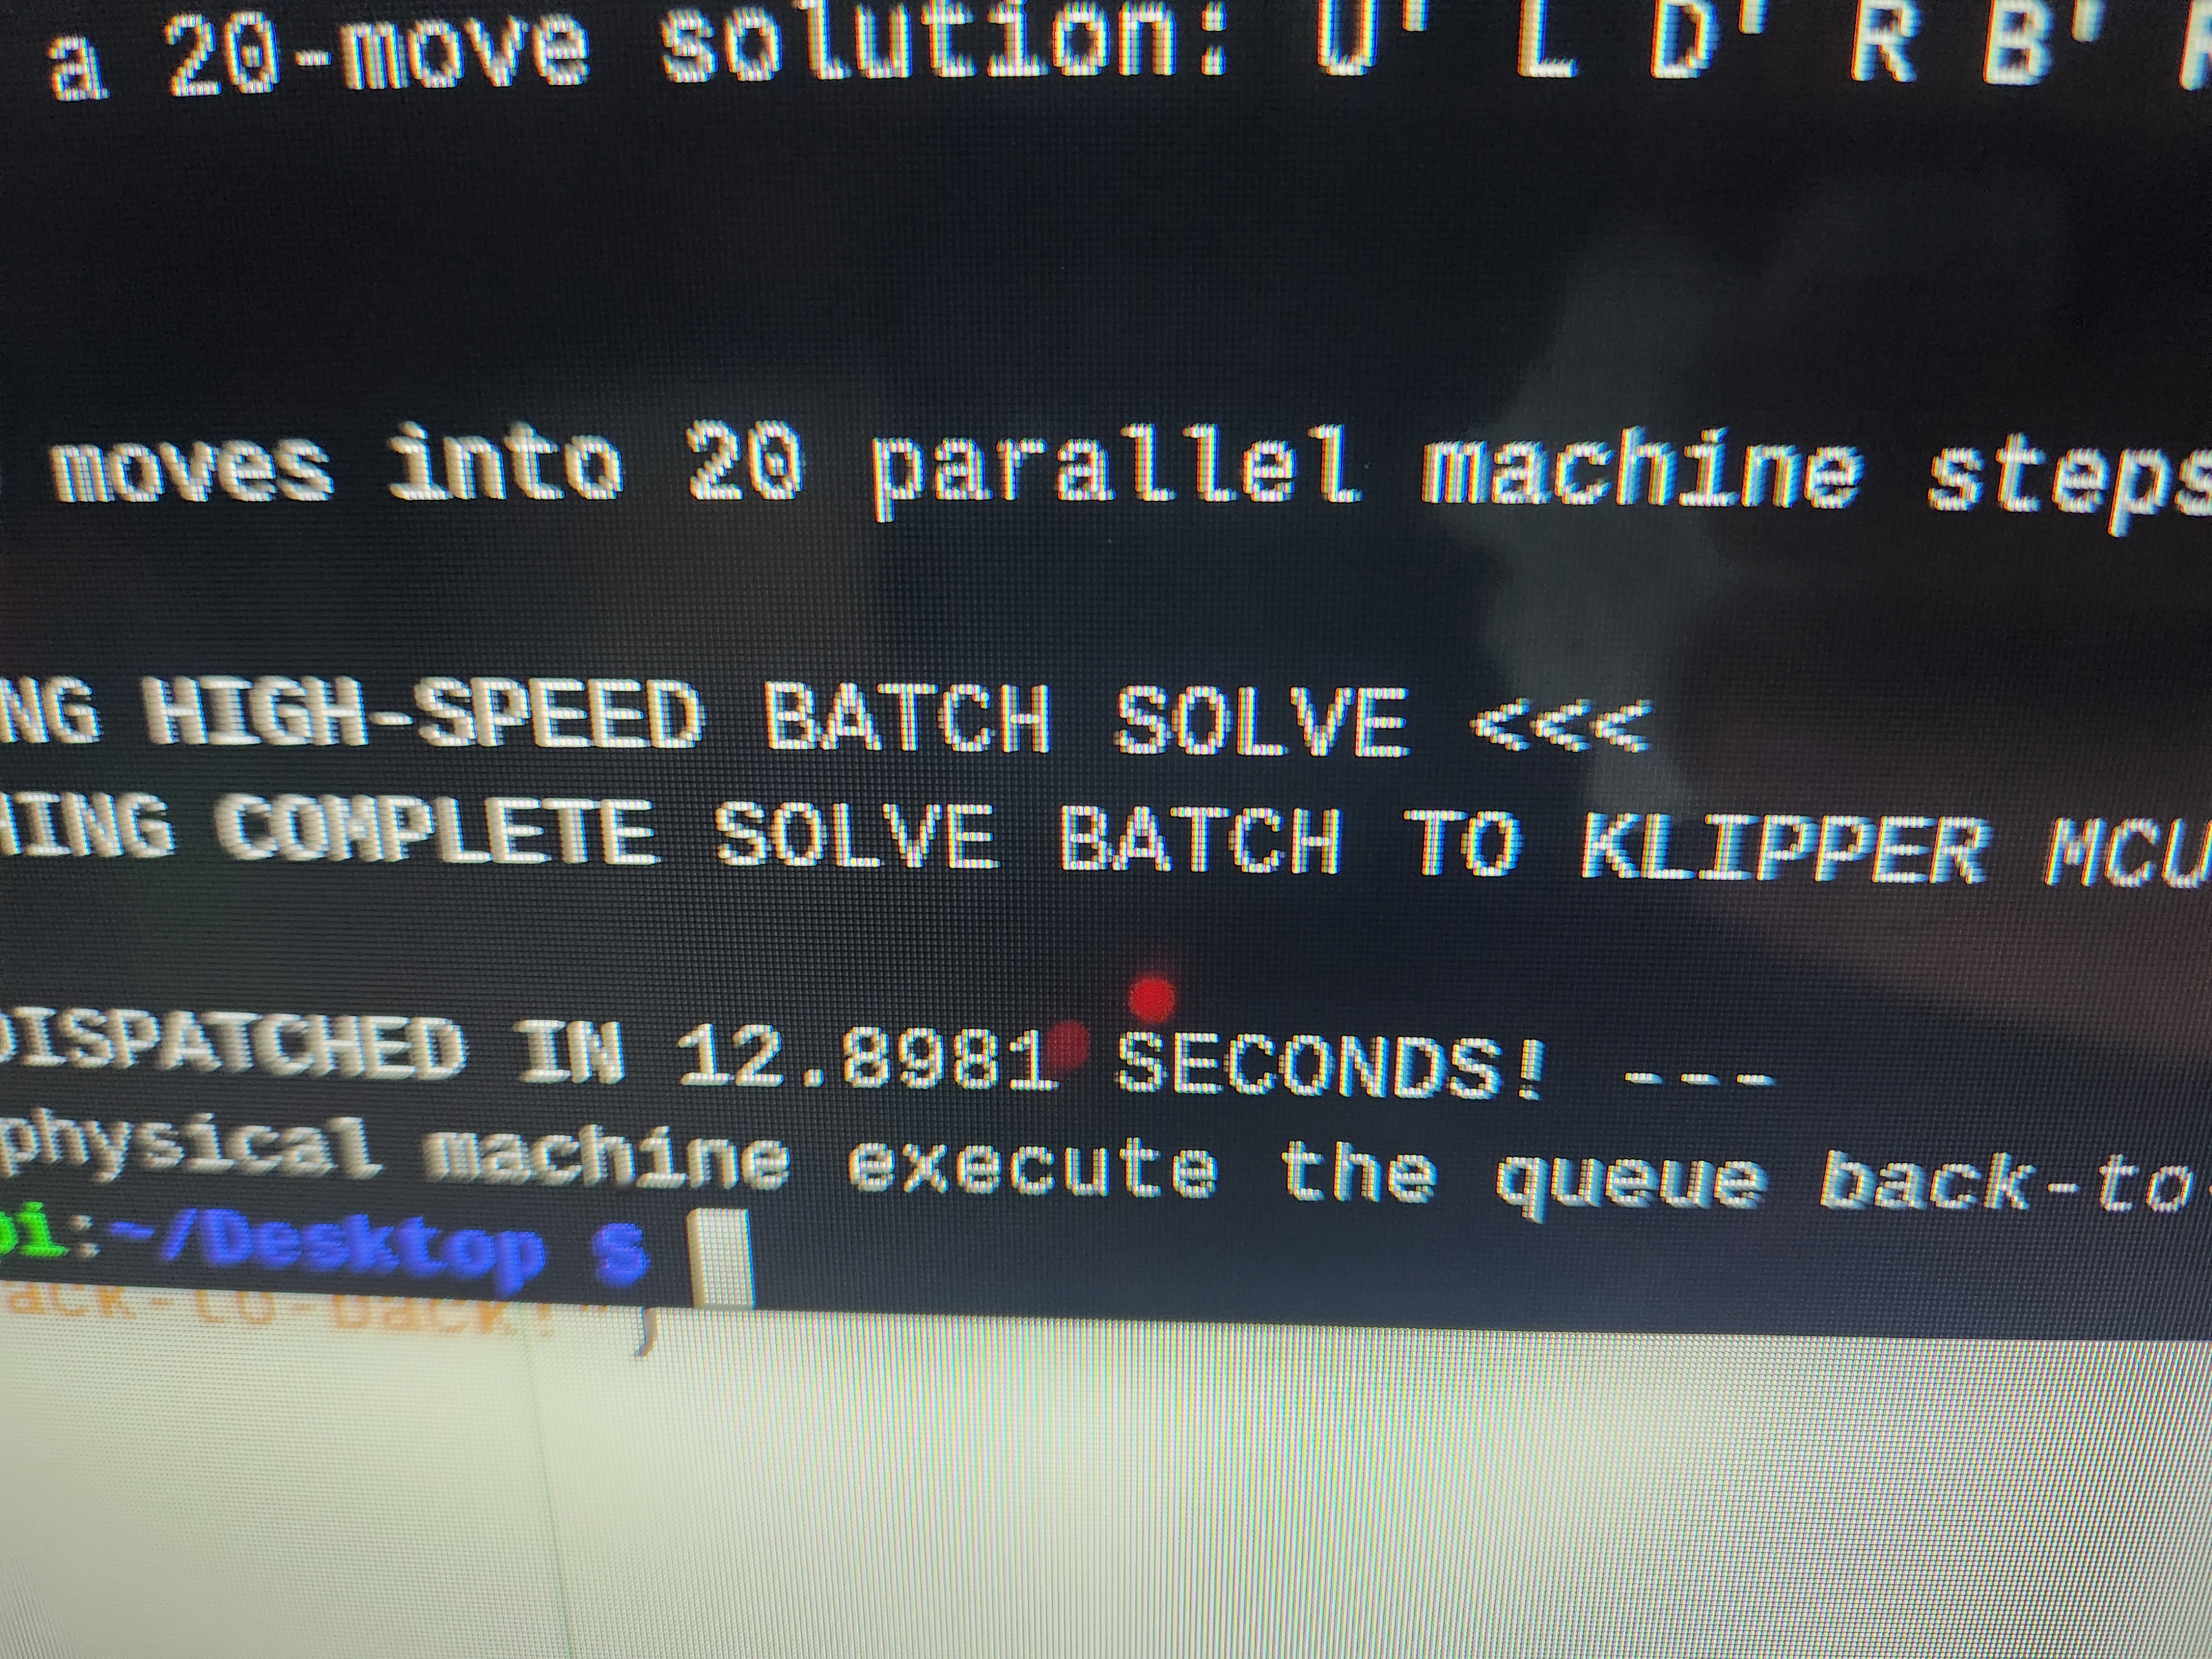
9.68s Benchmark Execution Log
High-speed MCU motion buffer & timing
📁 Project Media Gallery (12 Selected
Photos)
Click any image to inspect in full HD
Complete 6-Axis
SolverFull isometric overview
Overhead Gantry
AssemblyTop motor mount & wiring
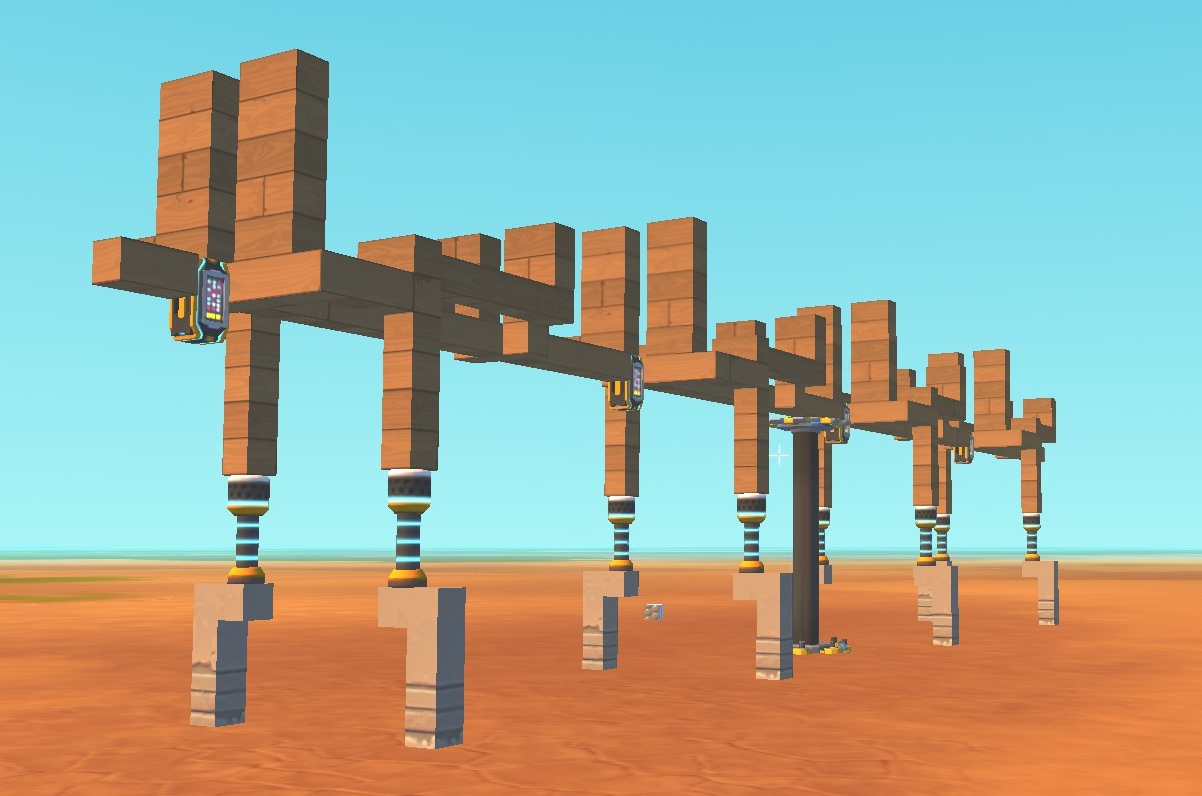
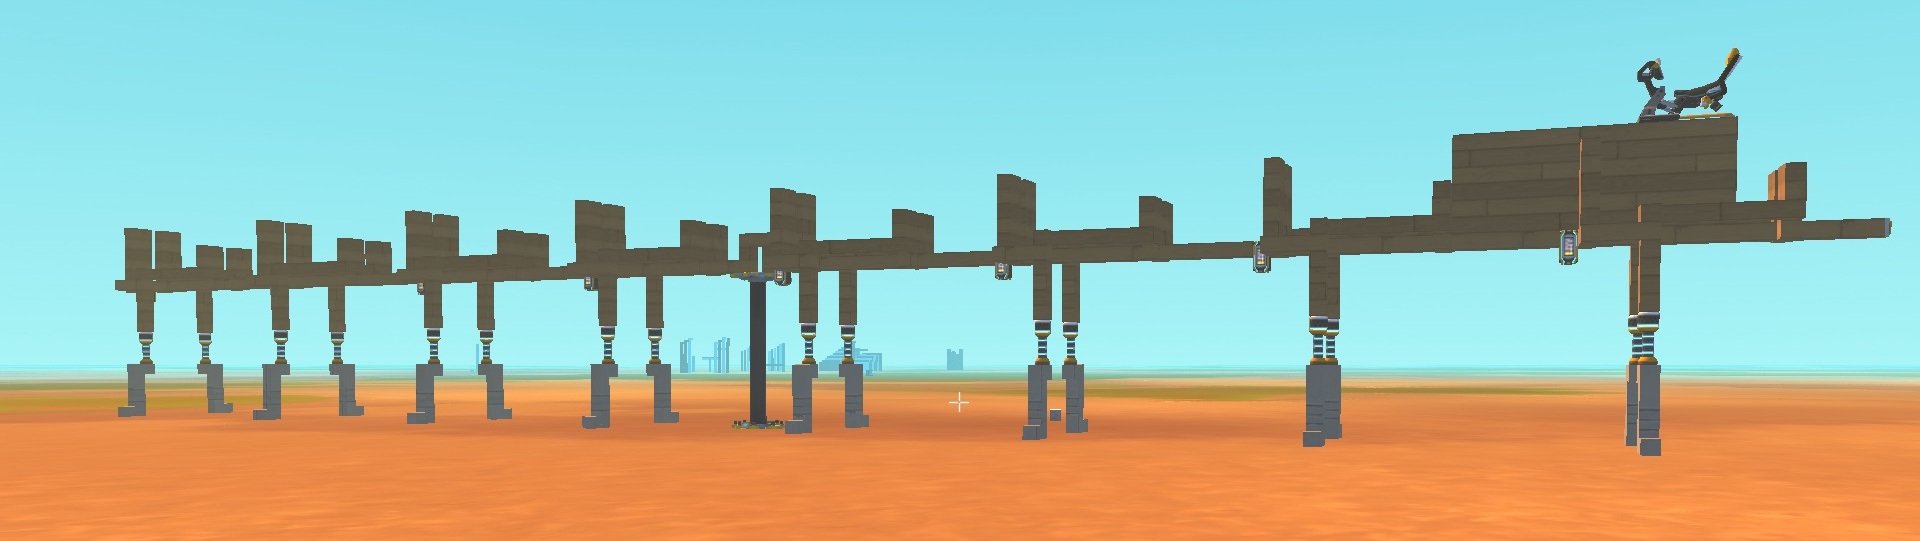
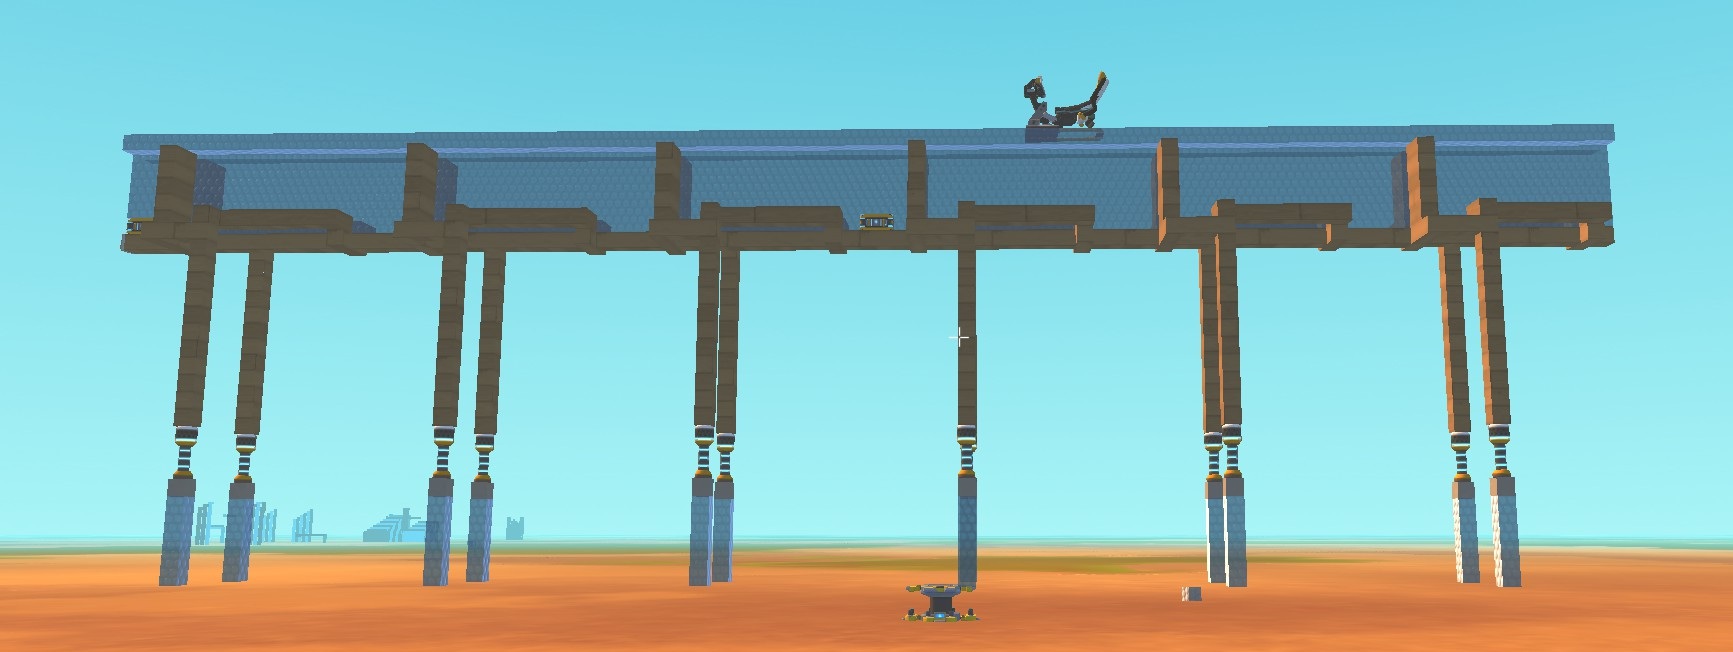
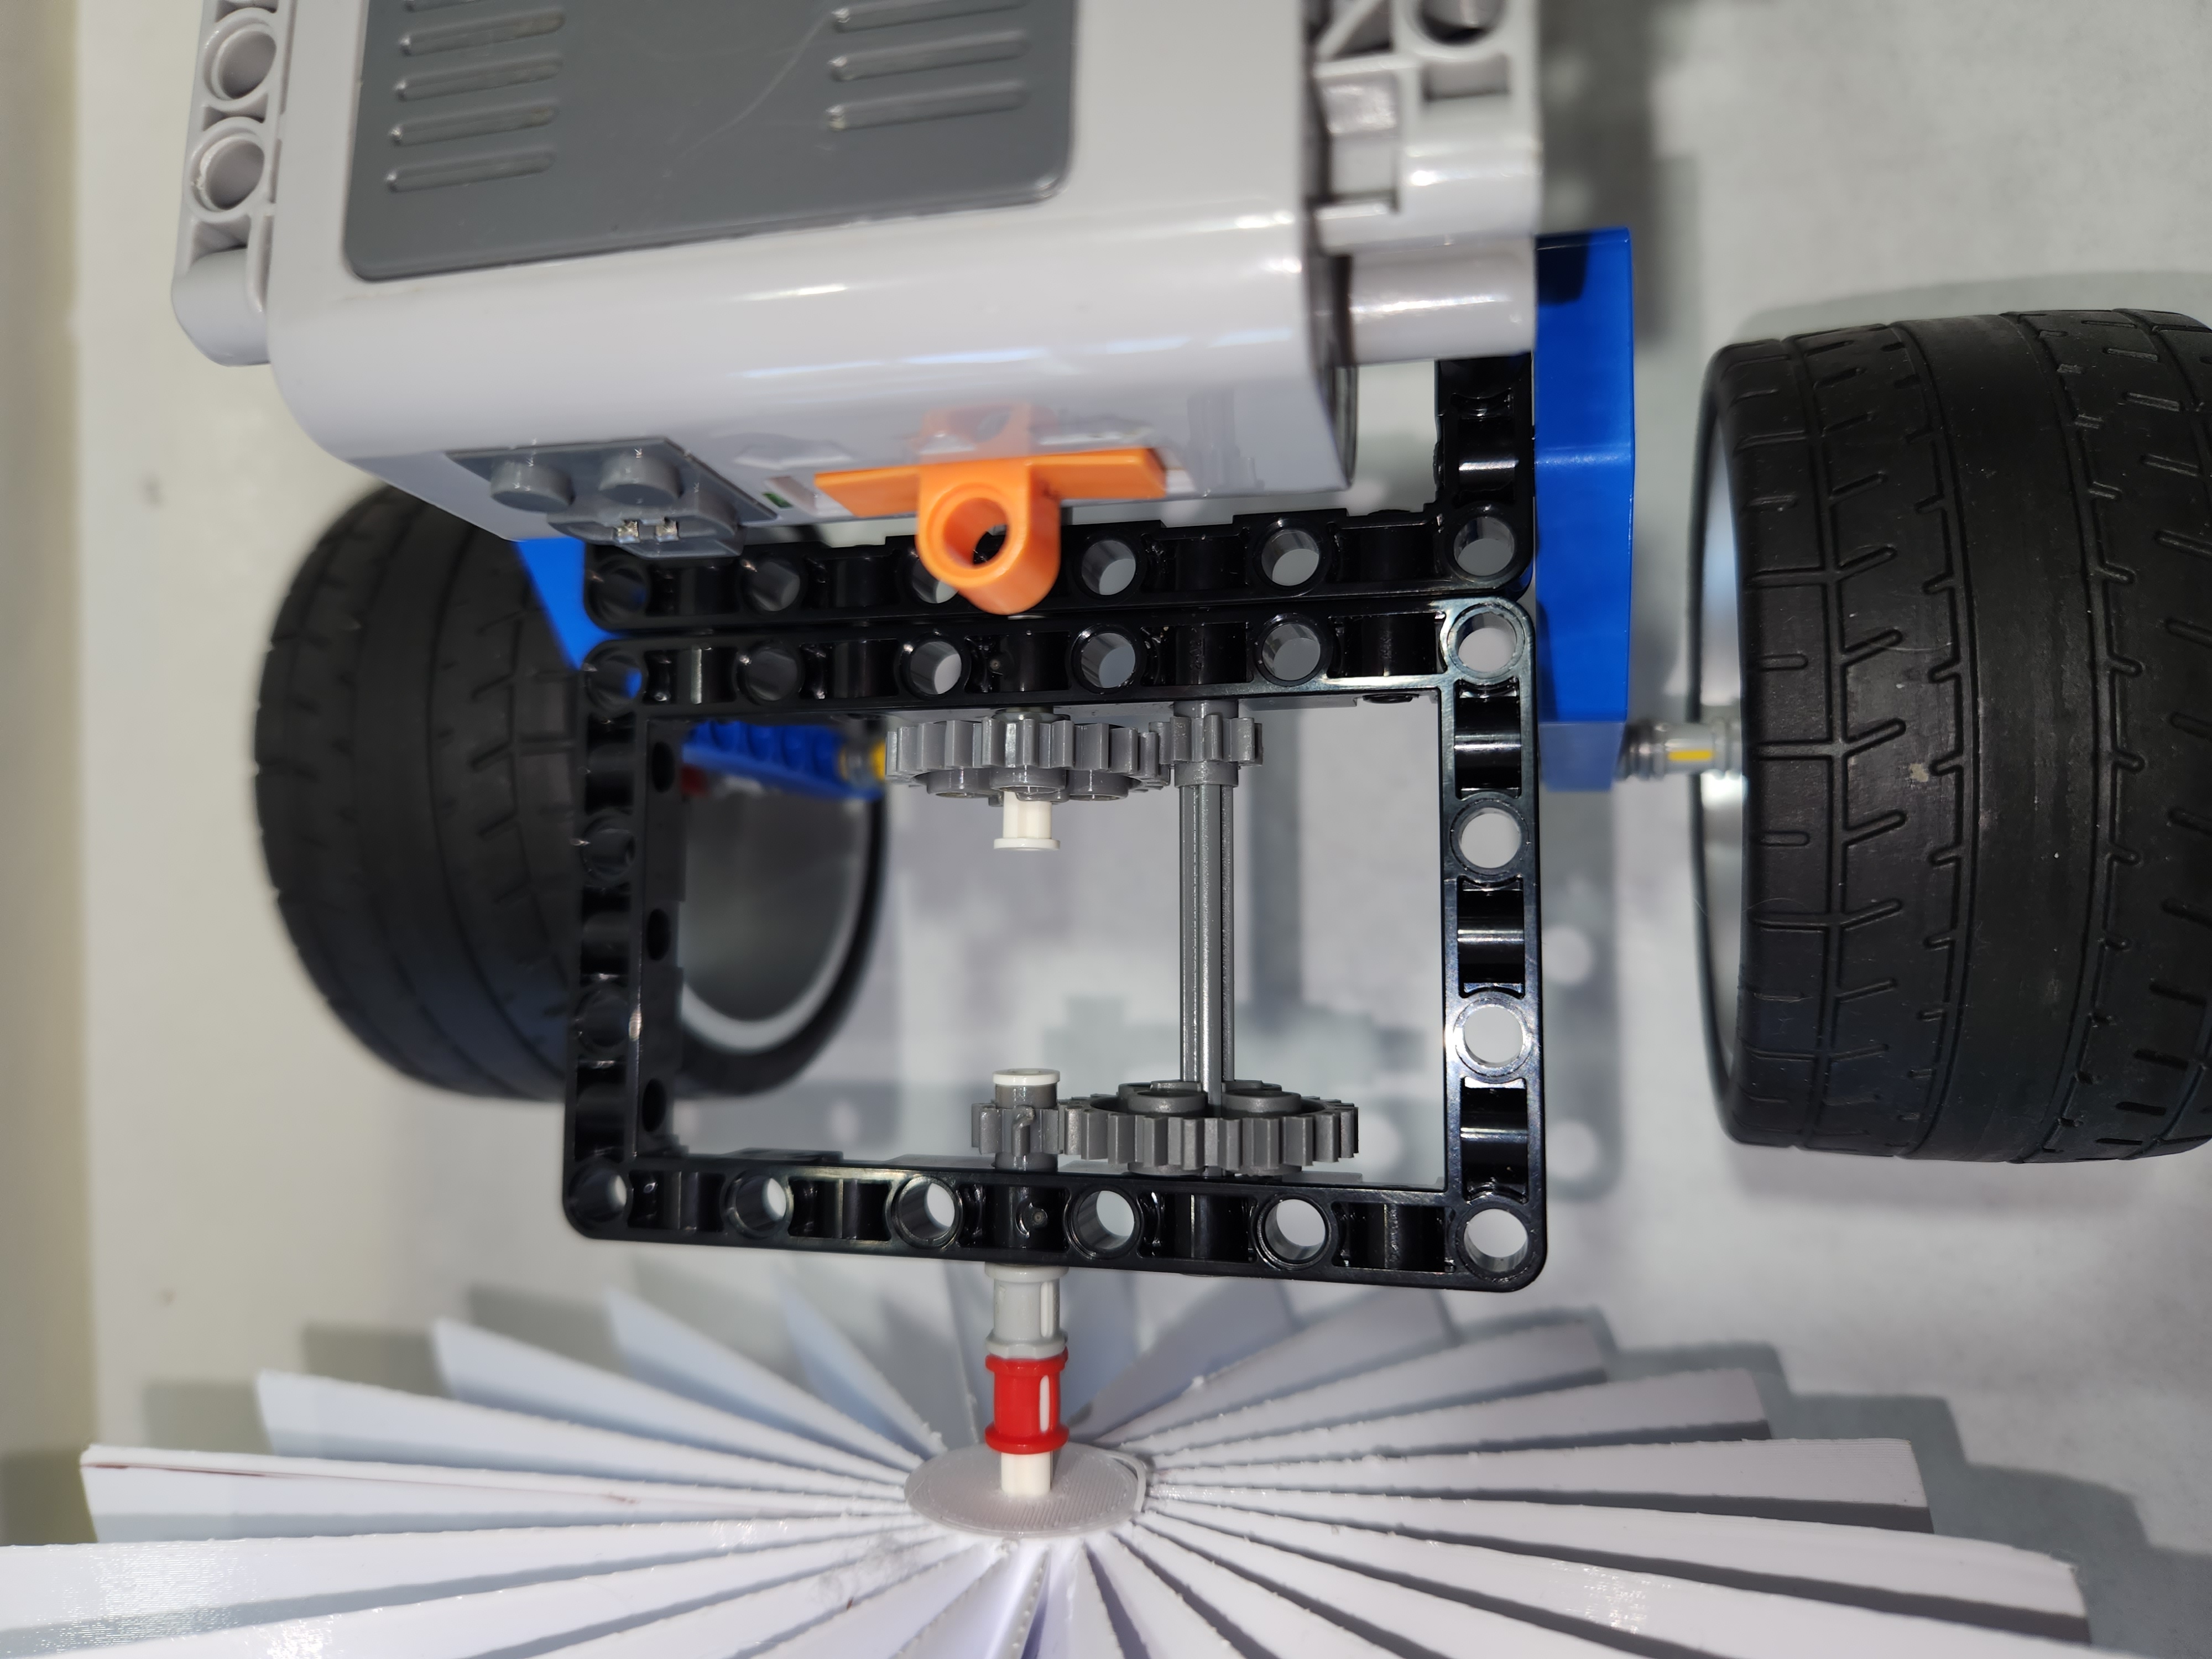
Front ElevationDirect face motor couplers
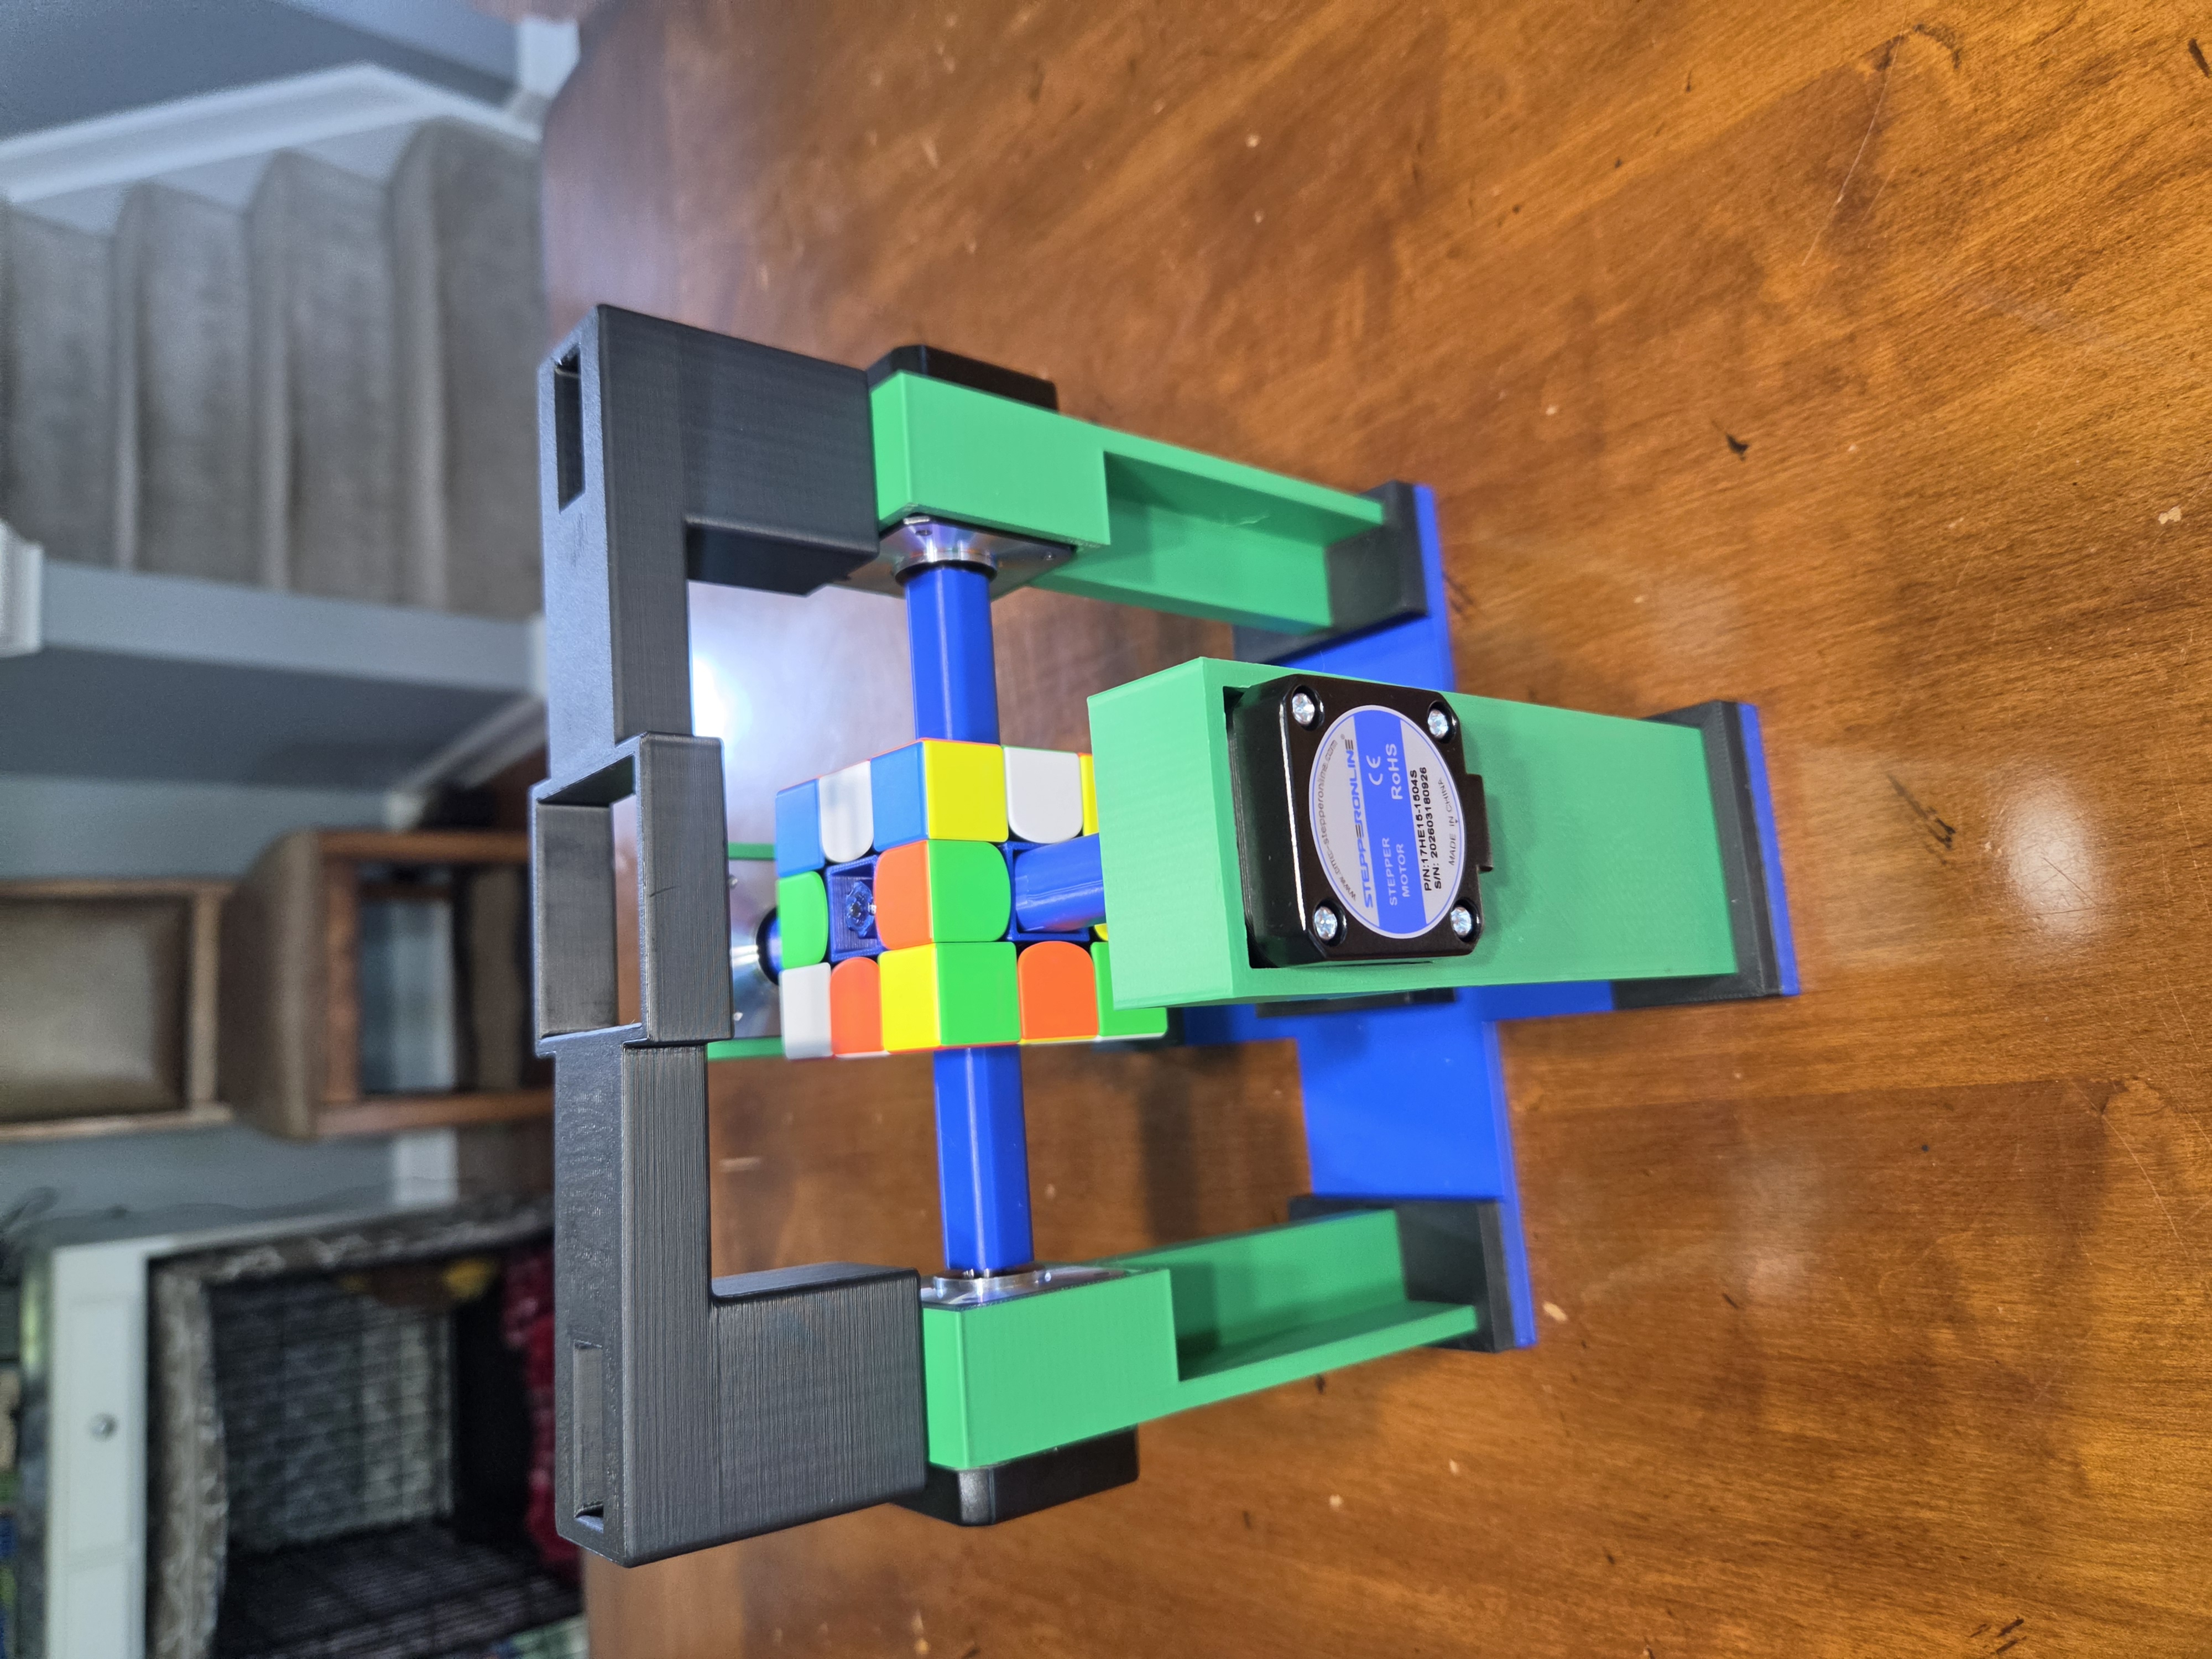
Lateral Rigidity
BracingAnti-flex structural struts
Orthogonal 3-Axis
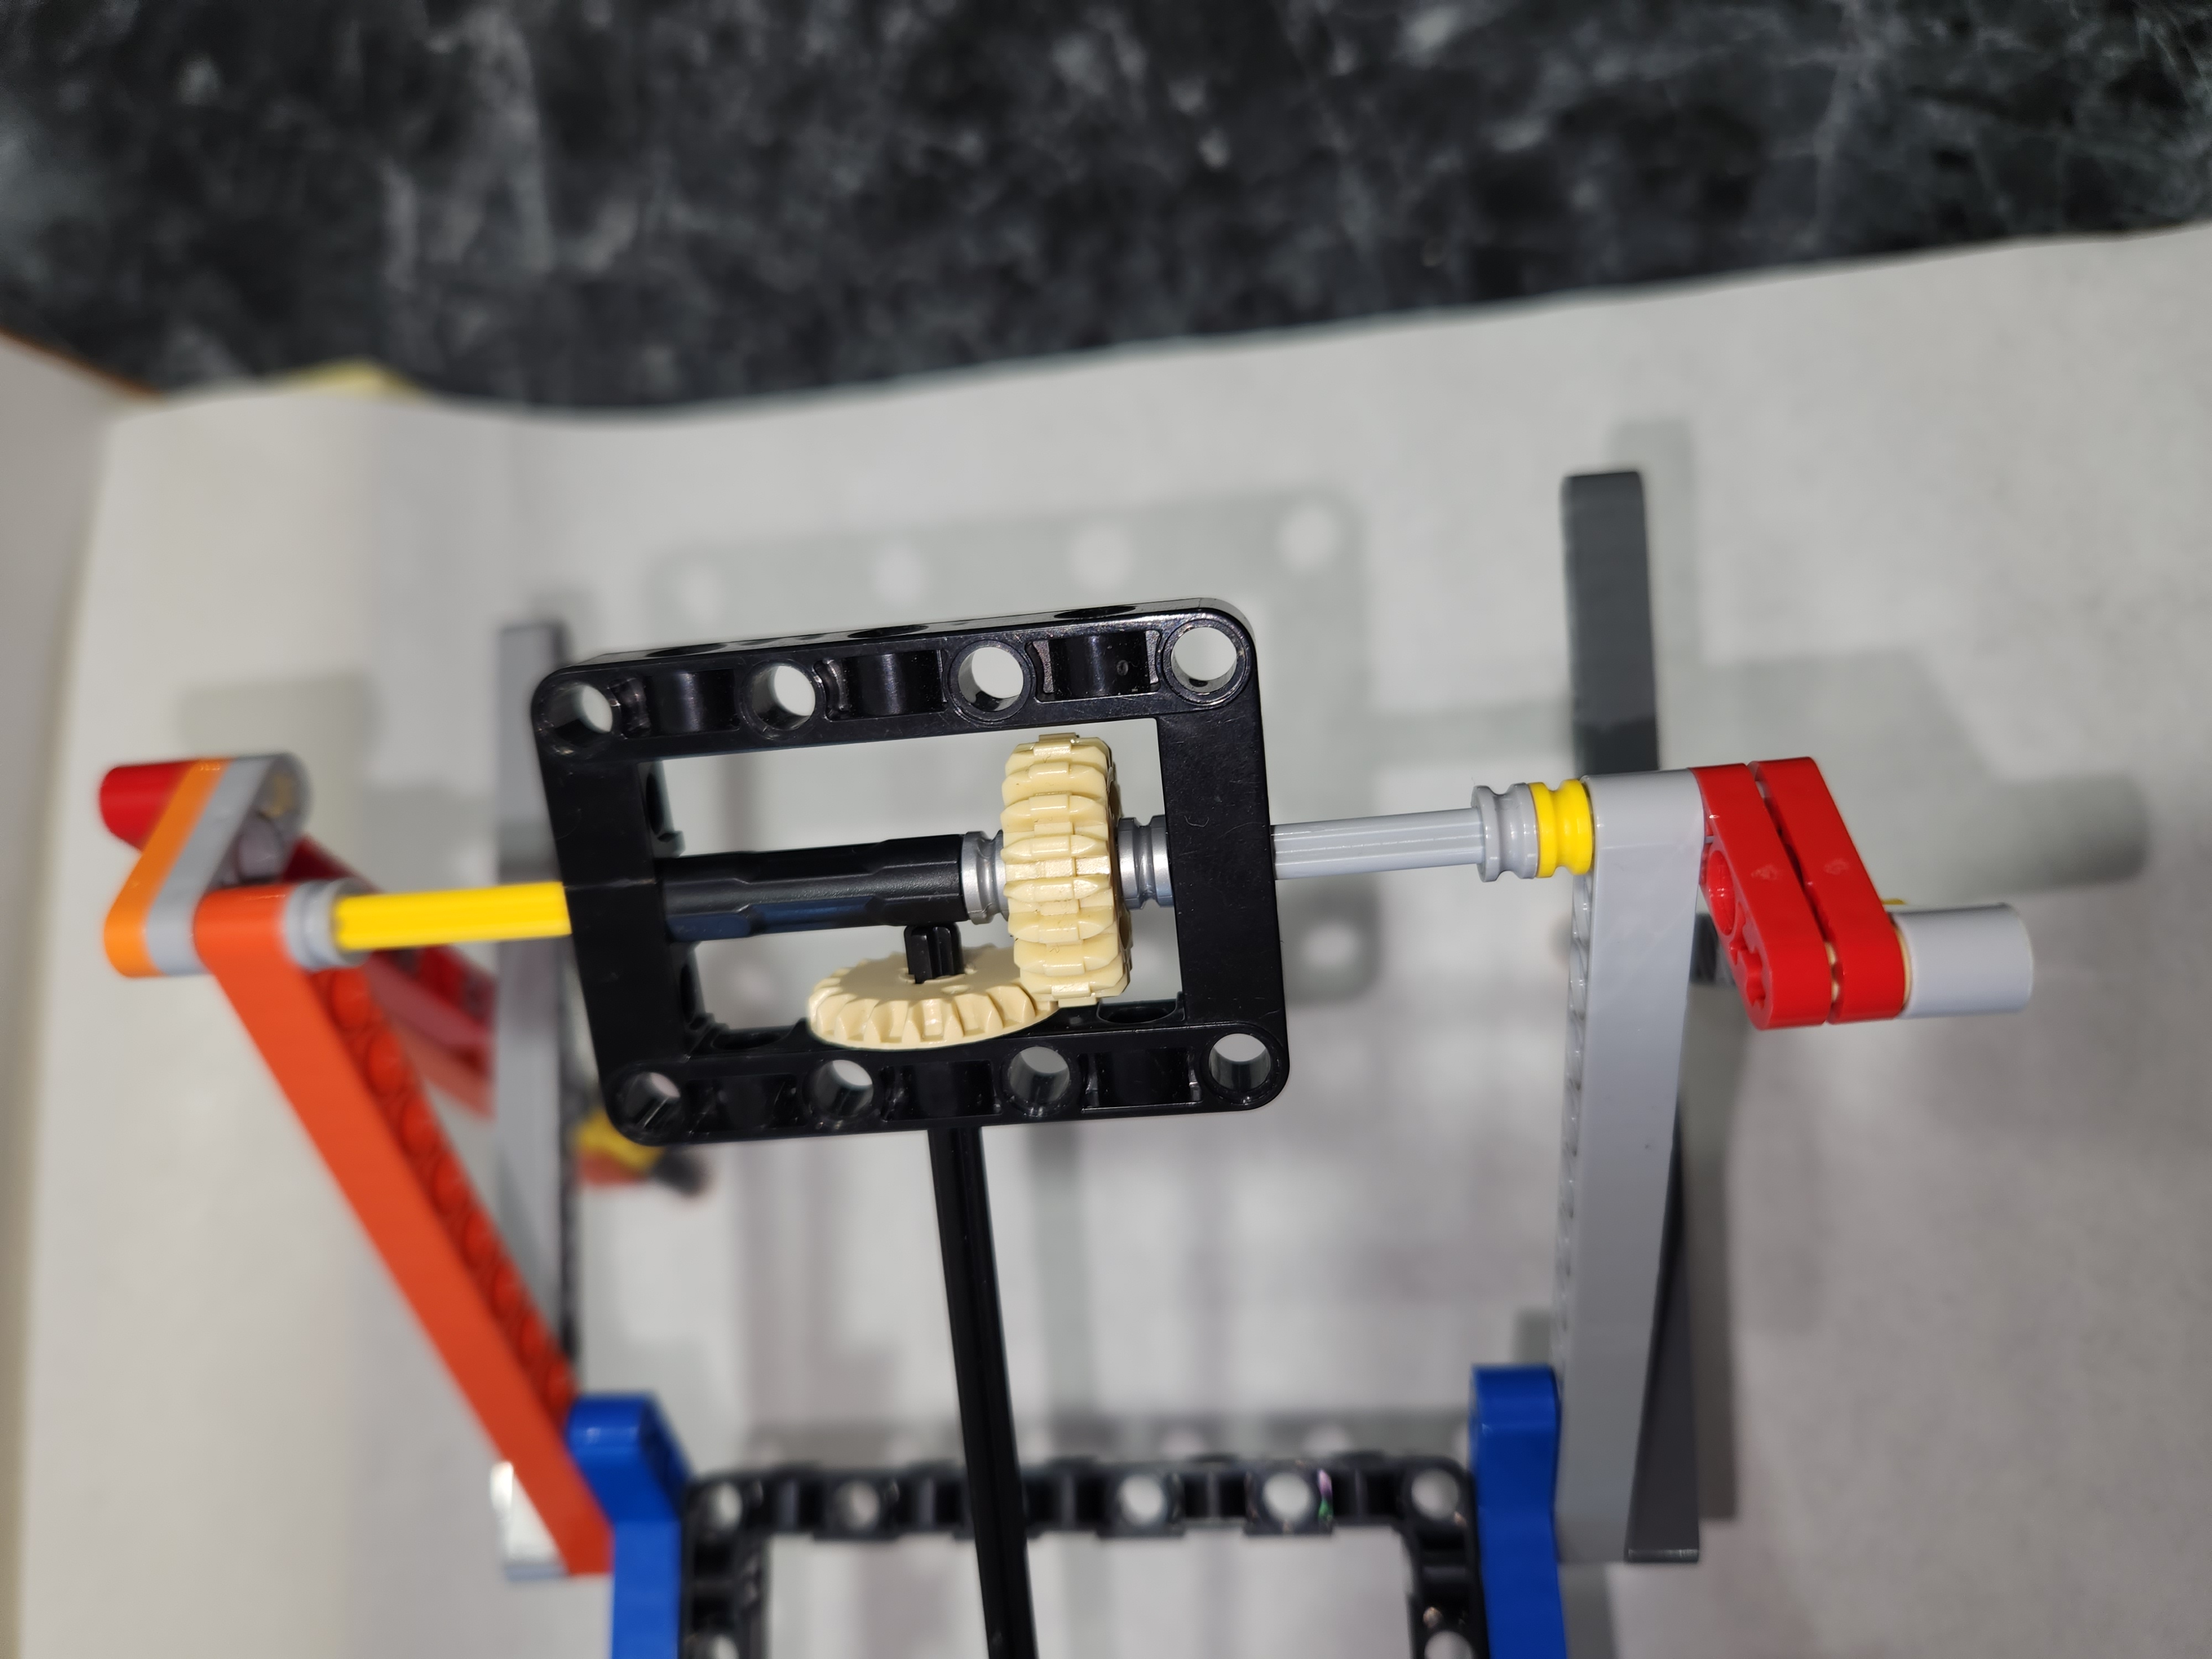
CoreKinematic center suspension
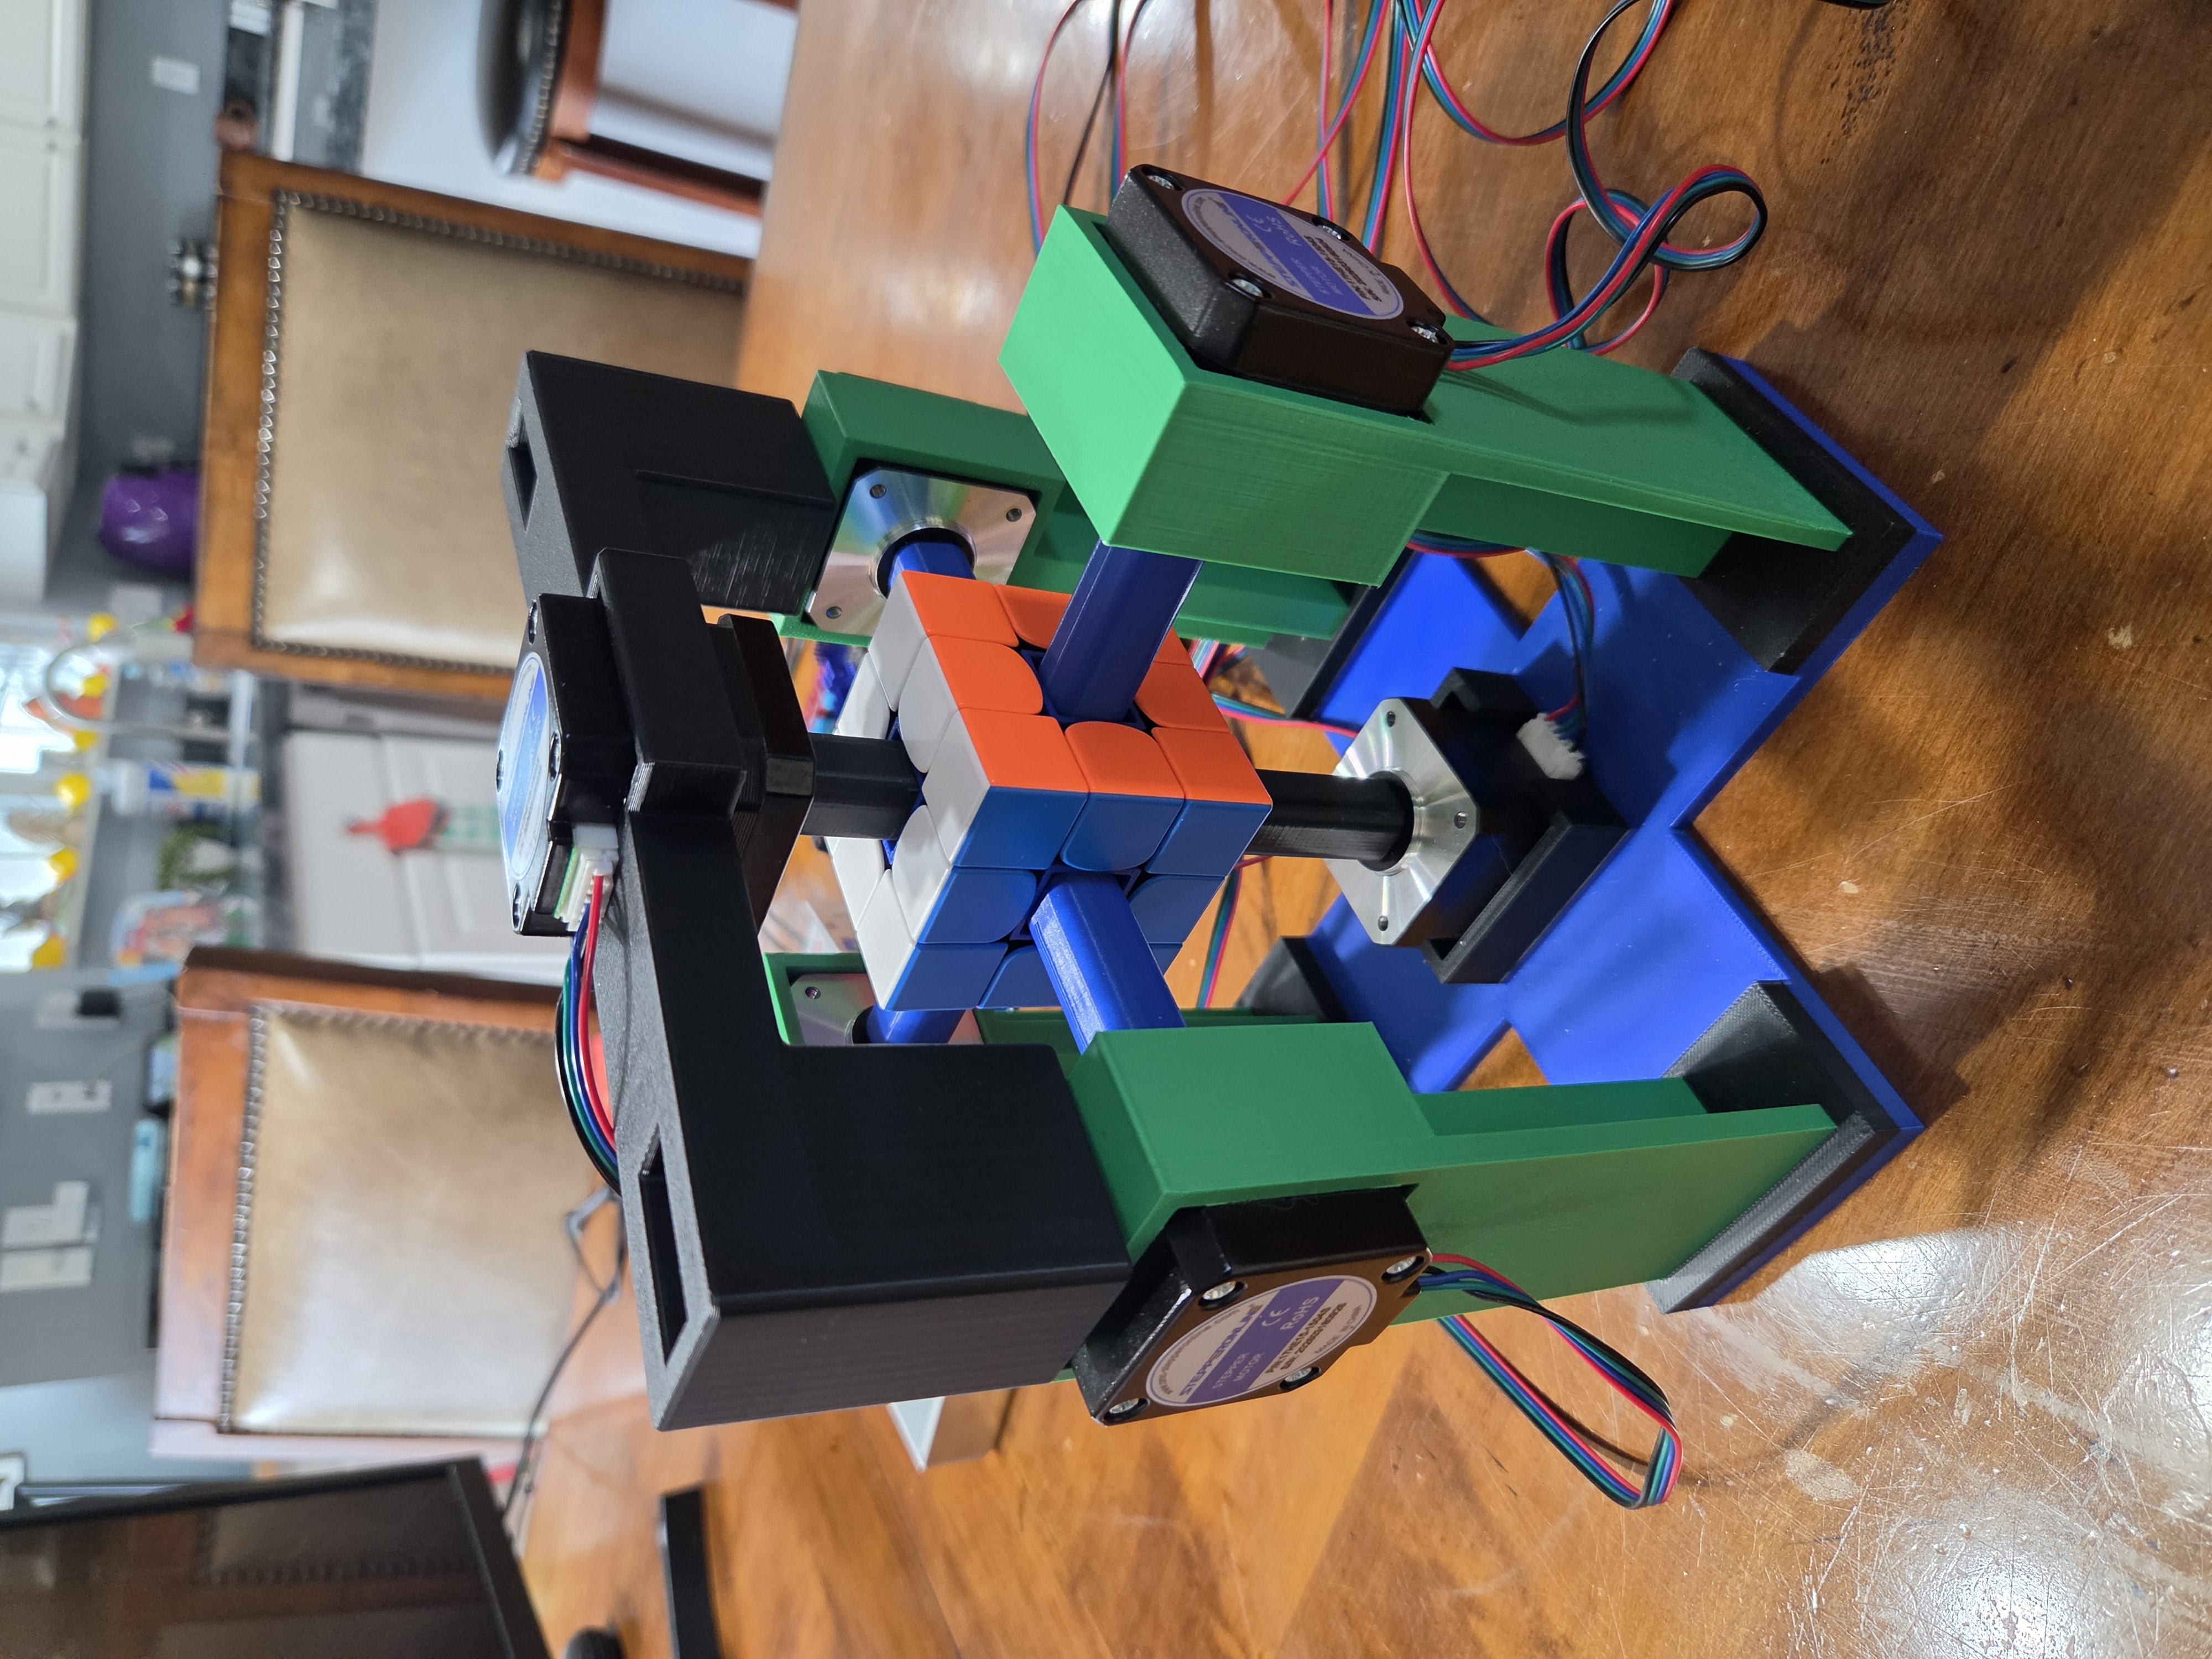
Base Mount &
RoutingBottom axis stepper mount
Coupler Seating
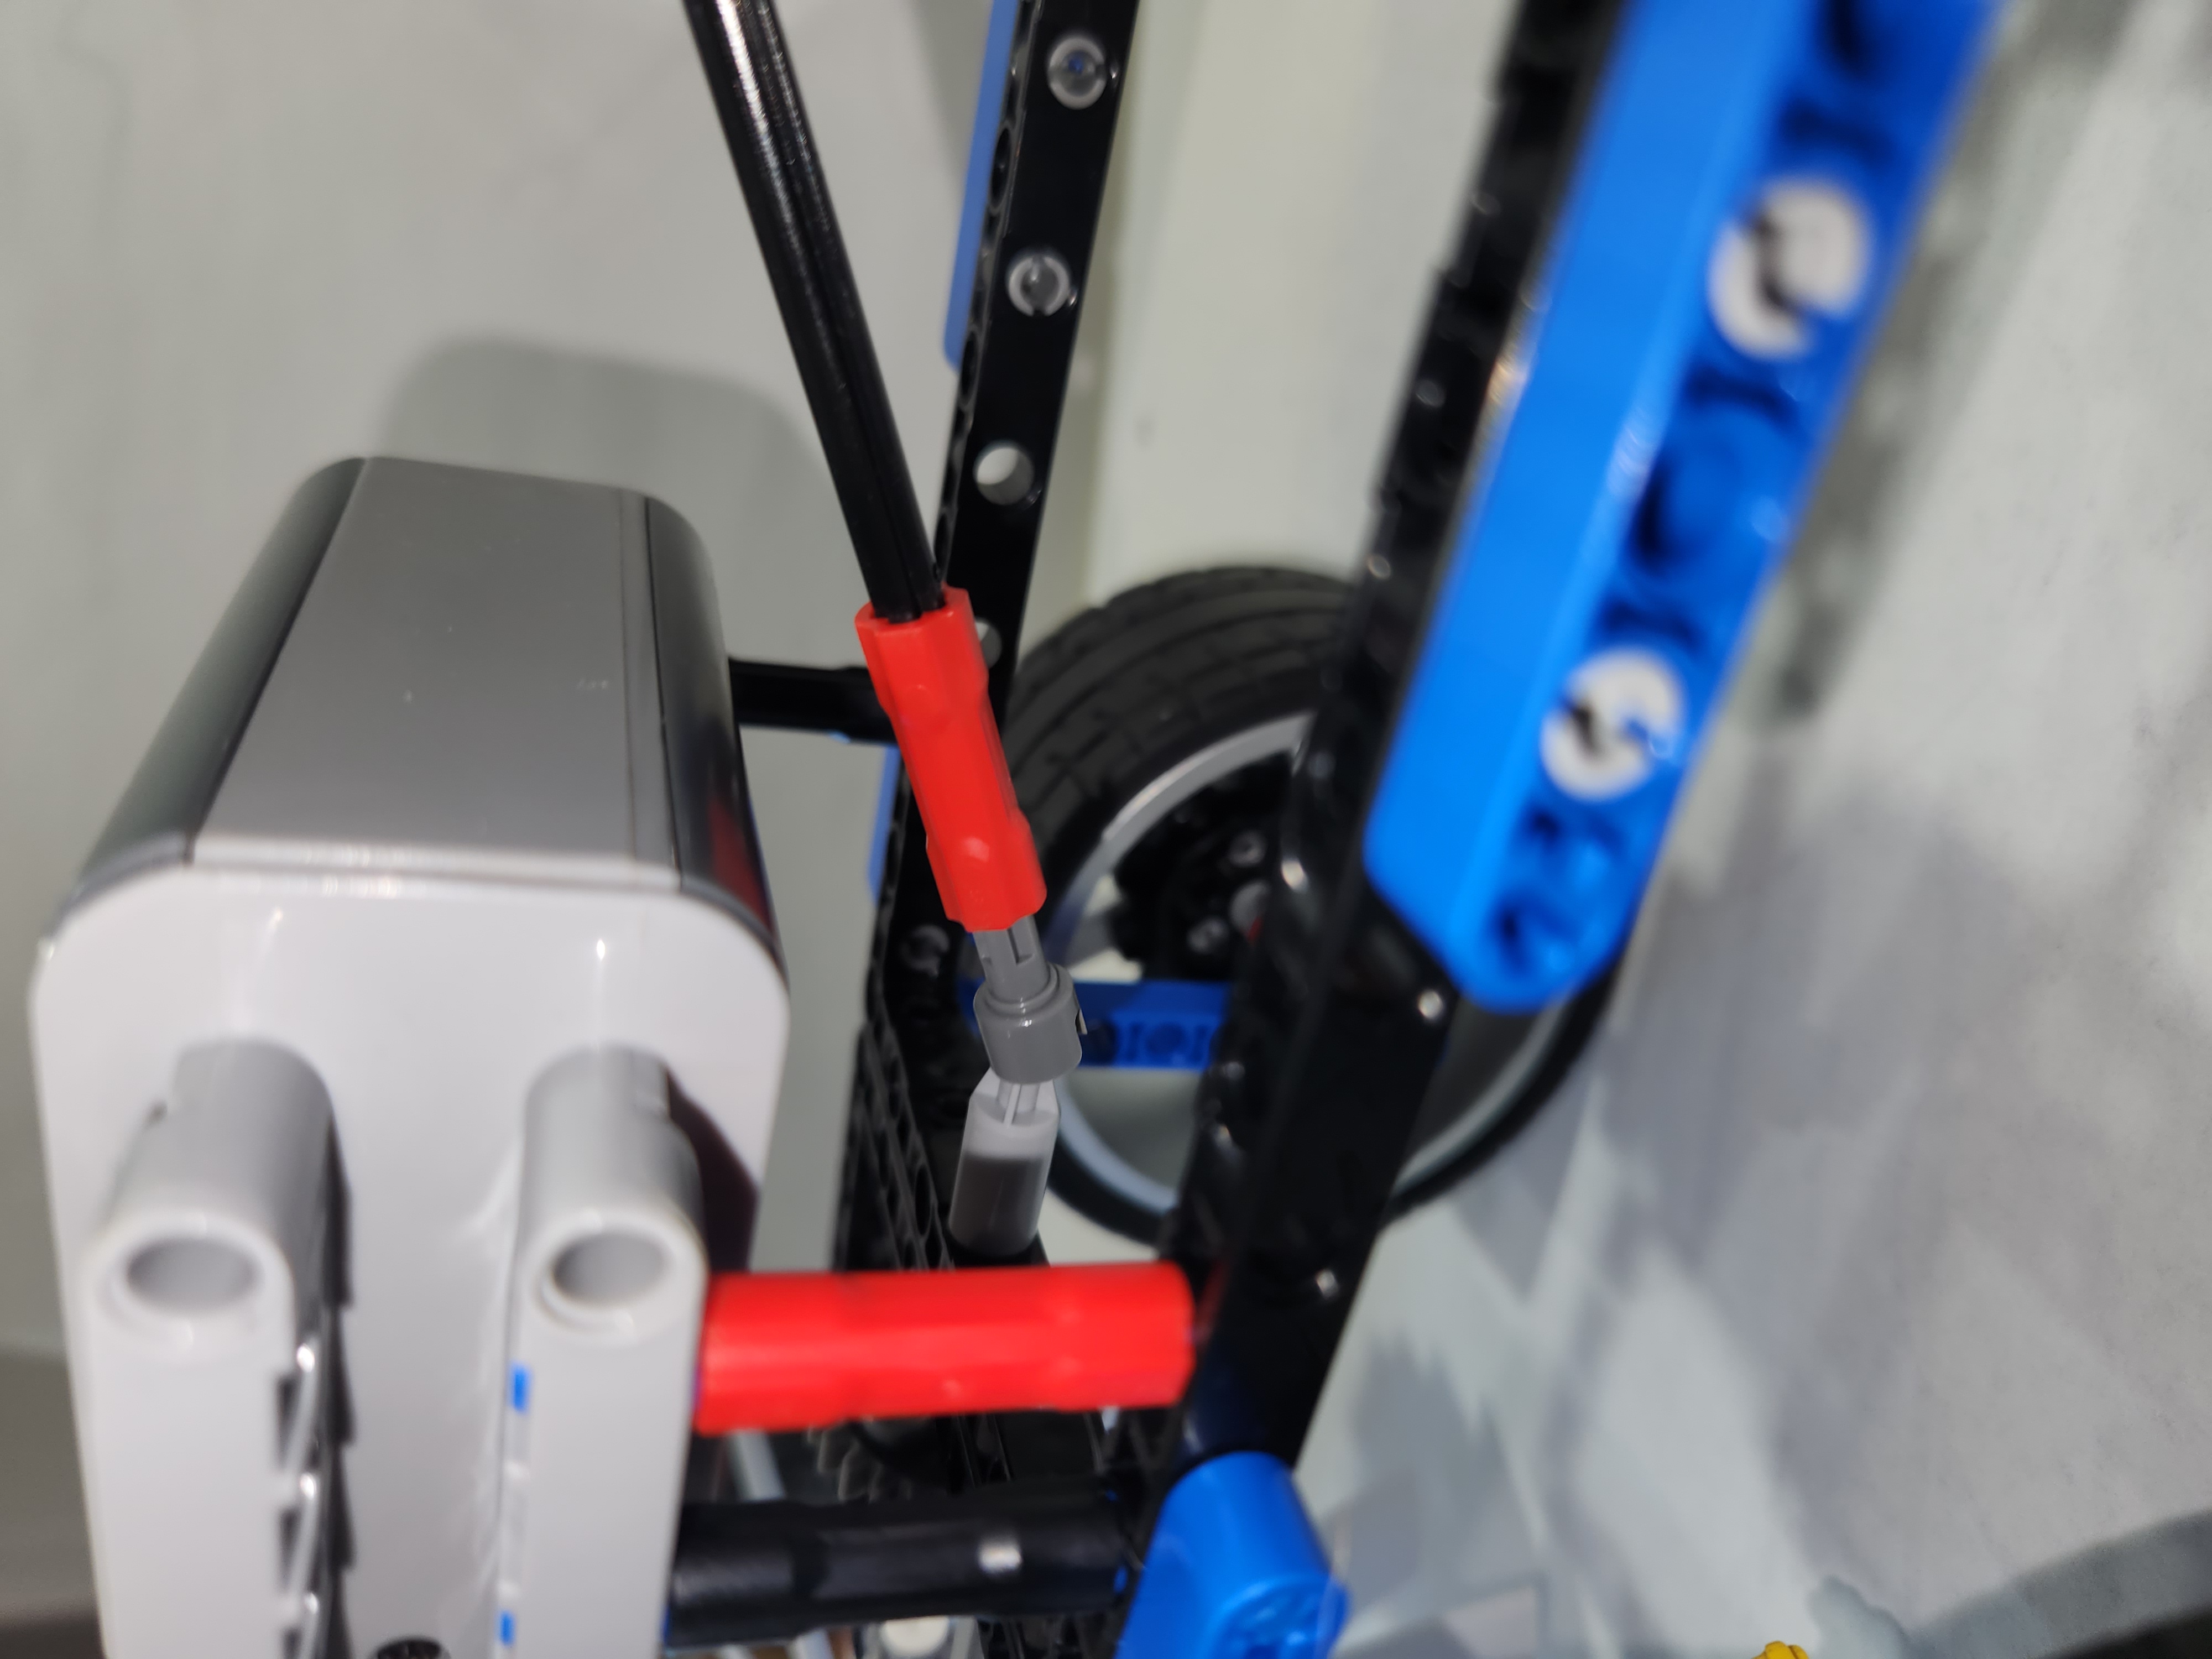
DetailZero-backlash spindle fit
24V Electronics
BayMean Well PSU + TMC2209
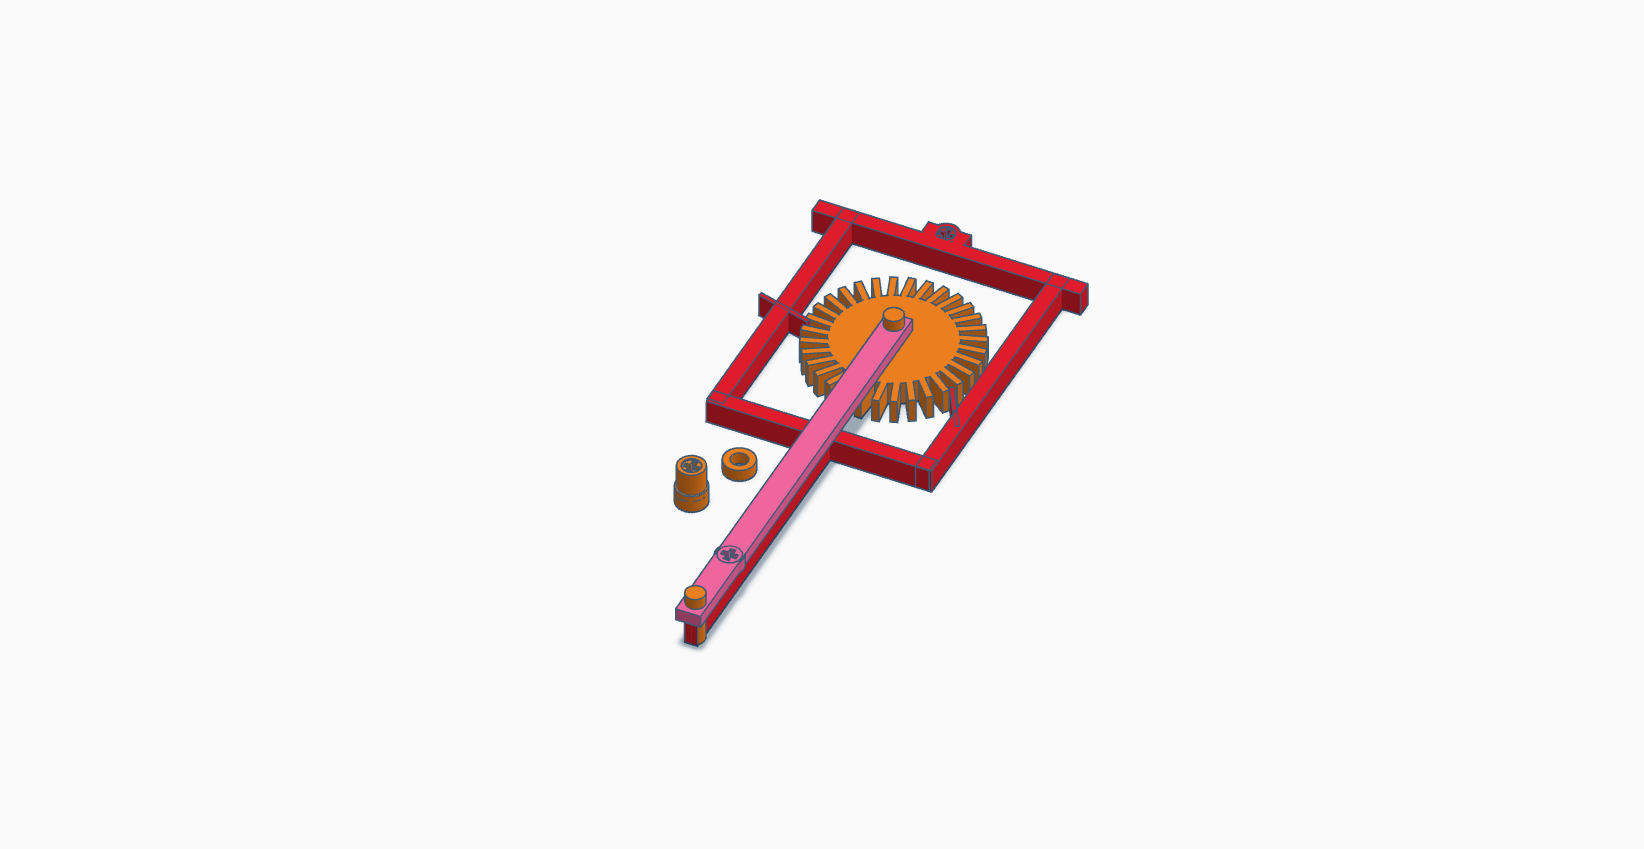
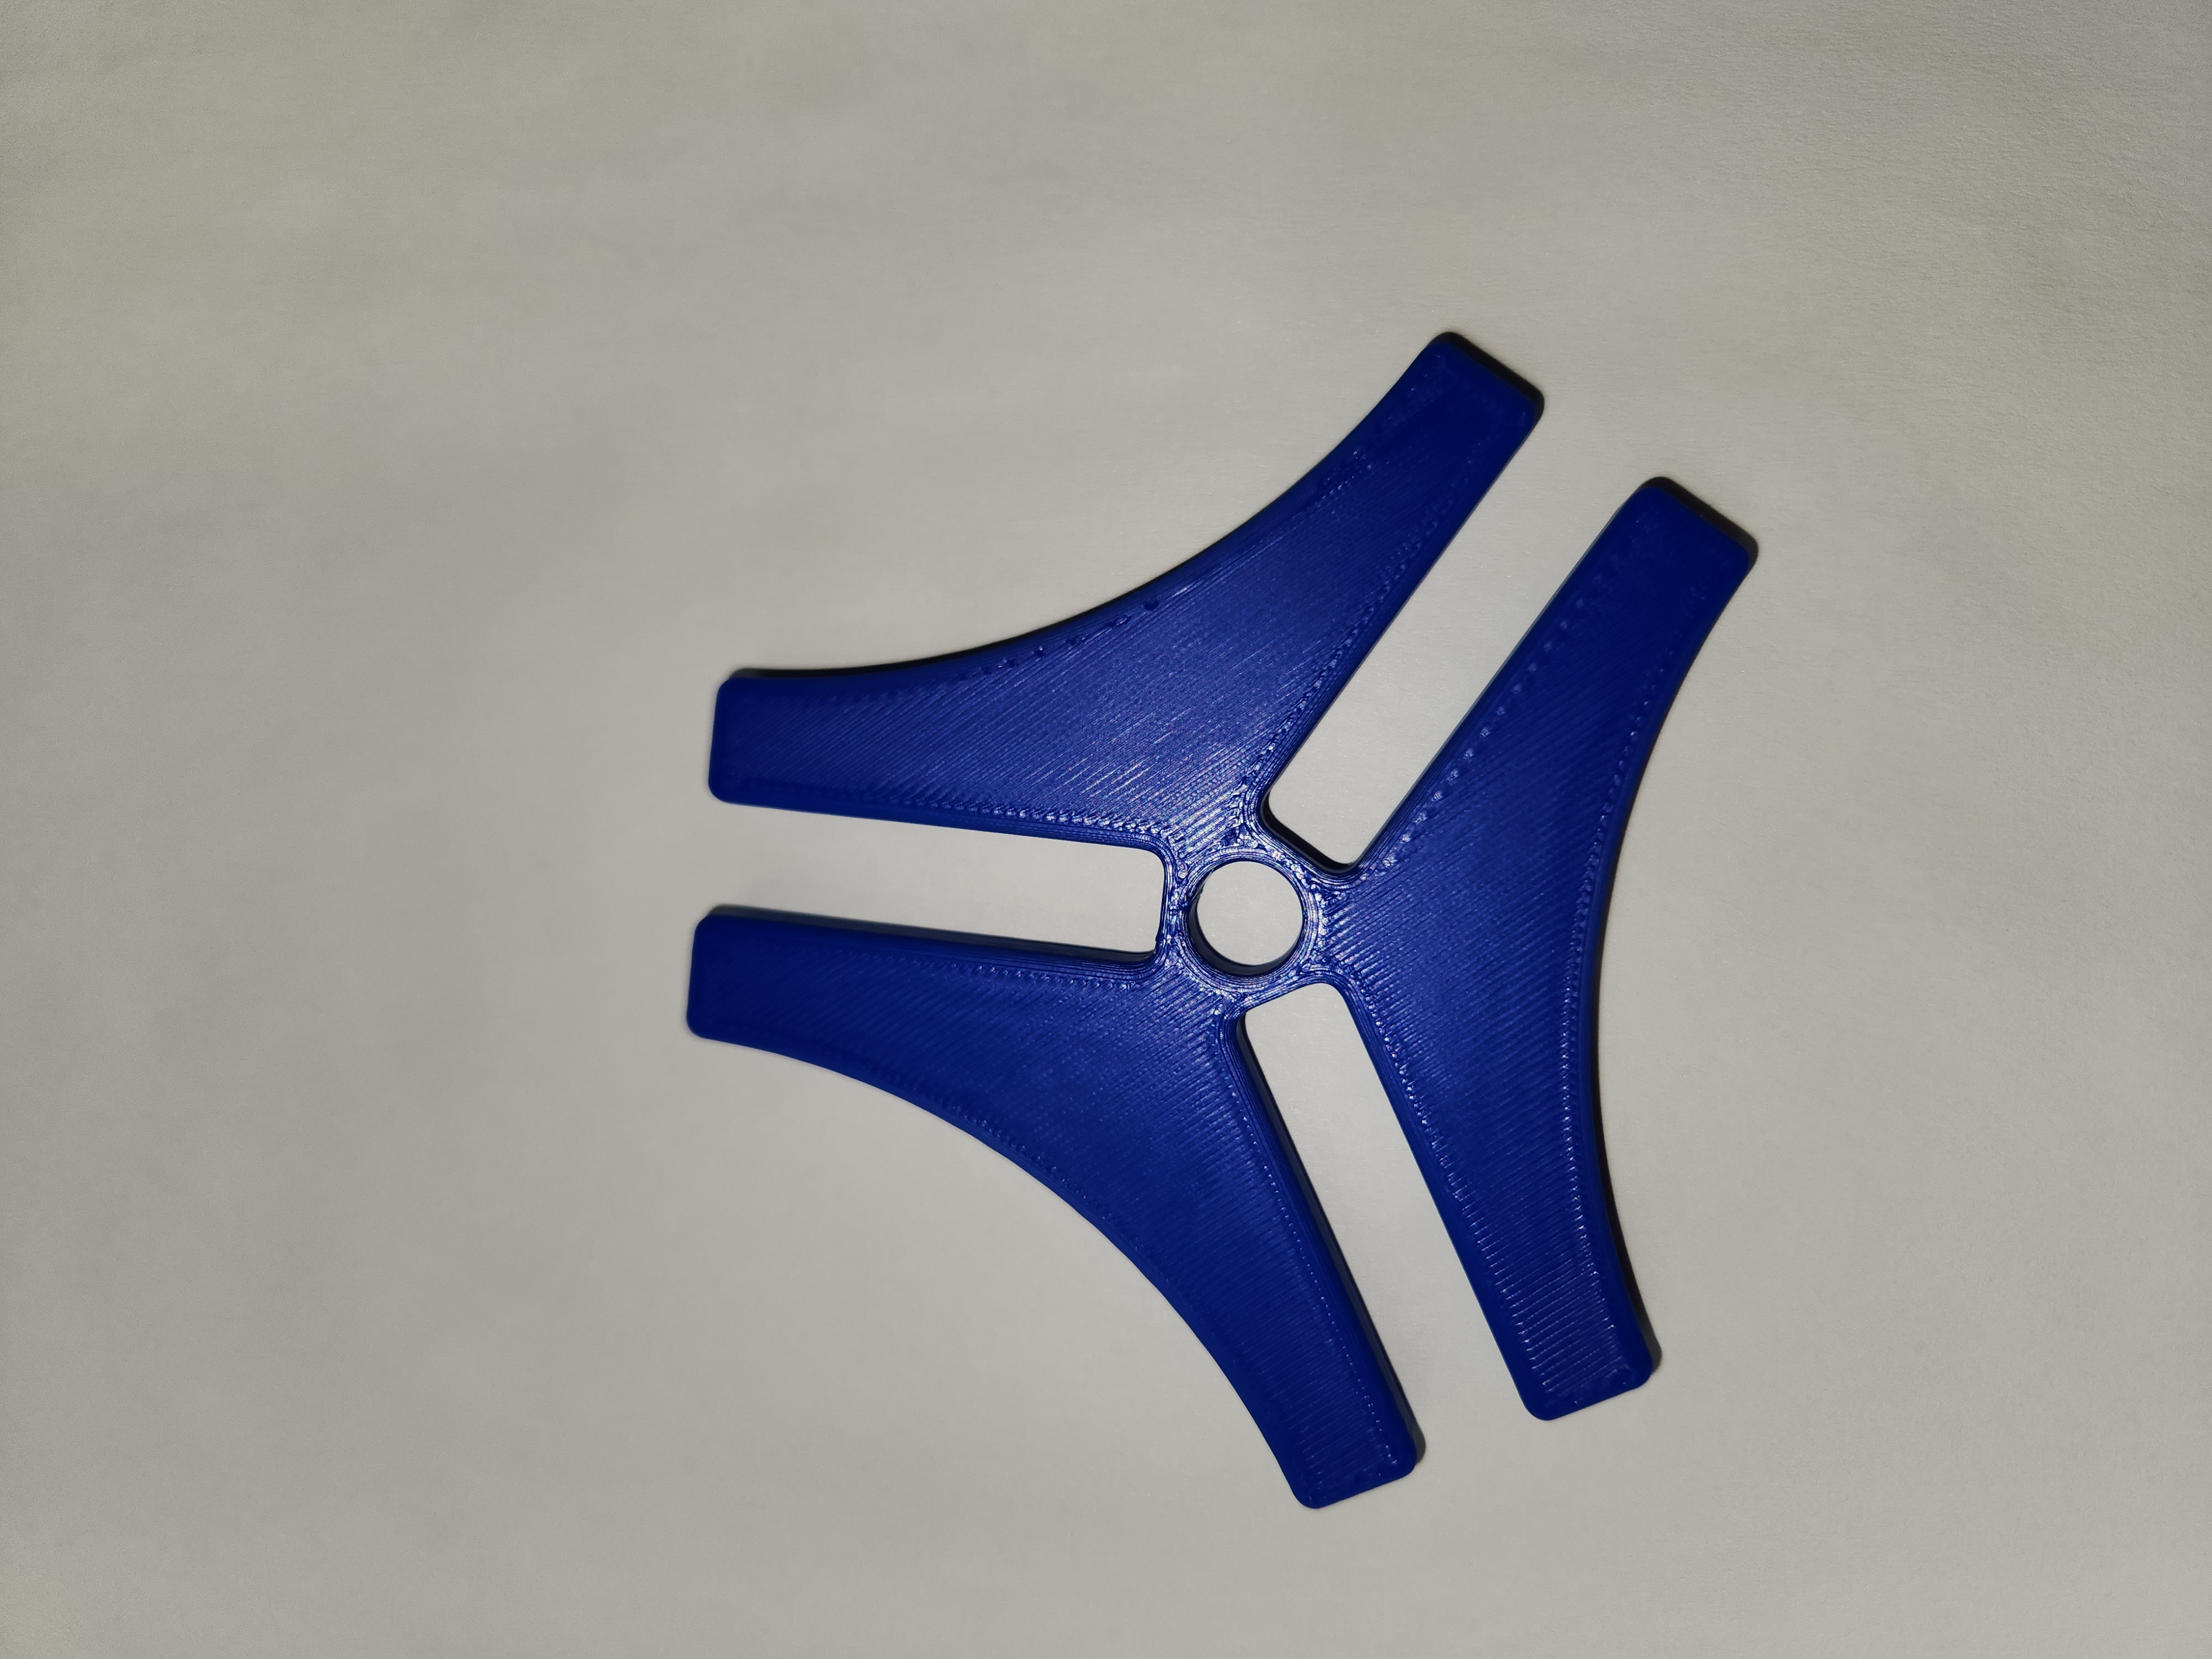
Frame Assembly
Bench3D-printed modular towers
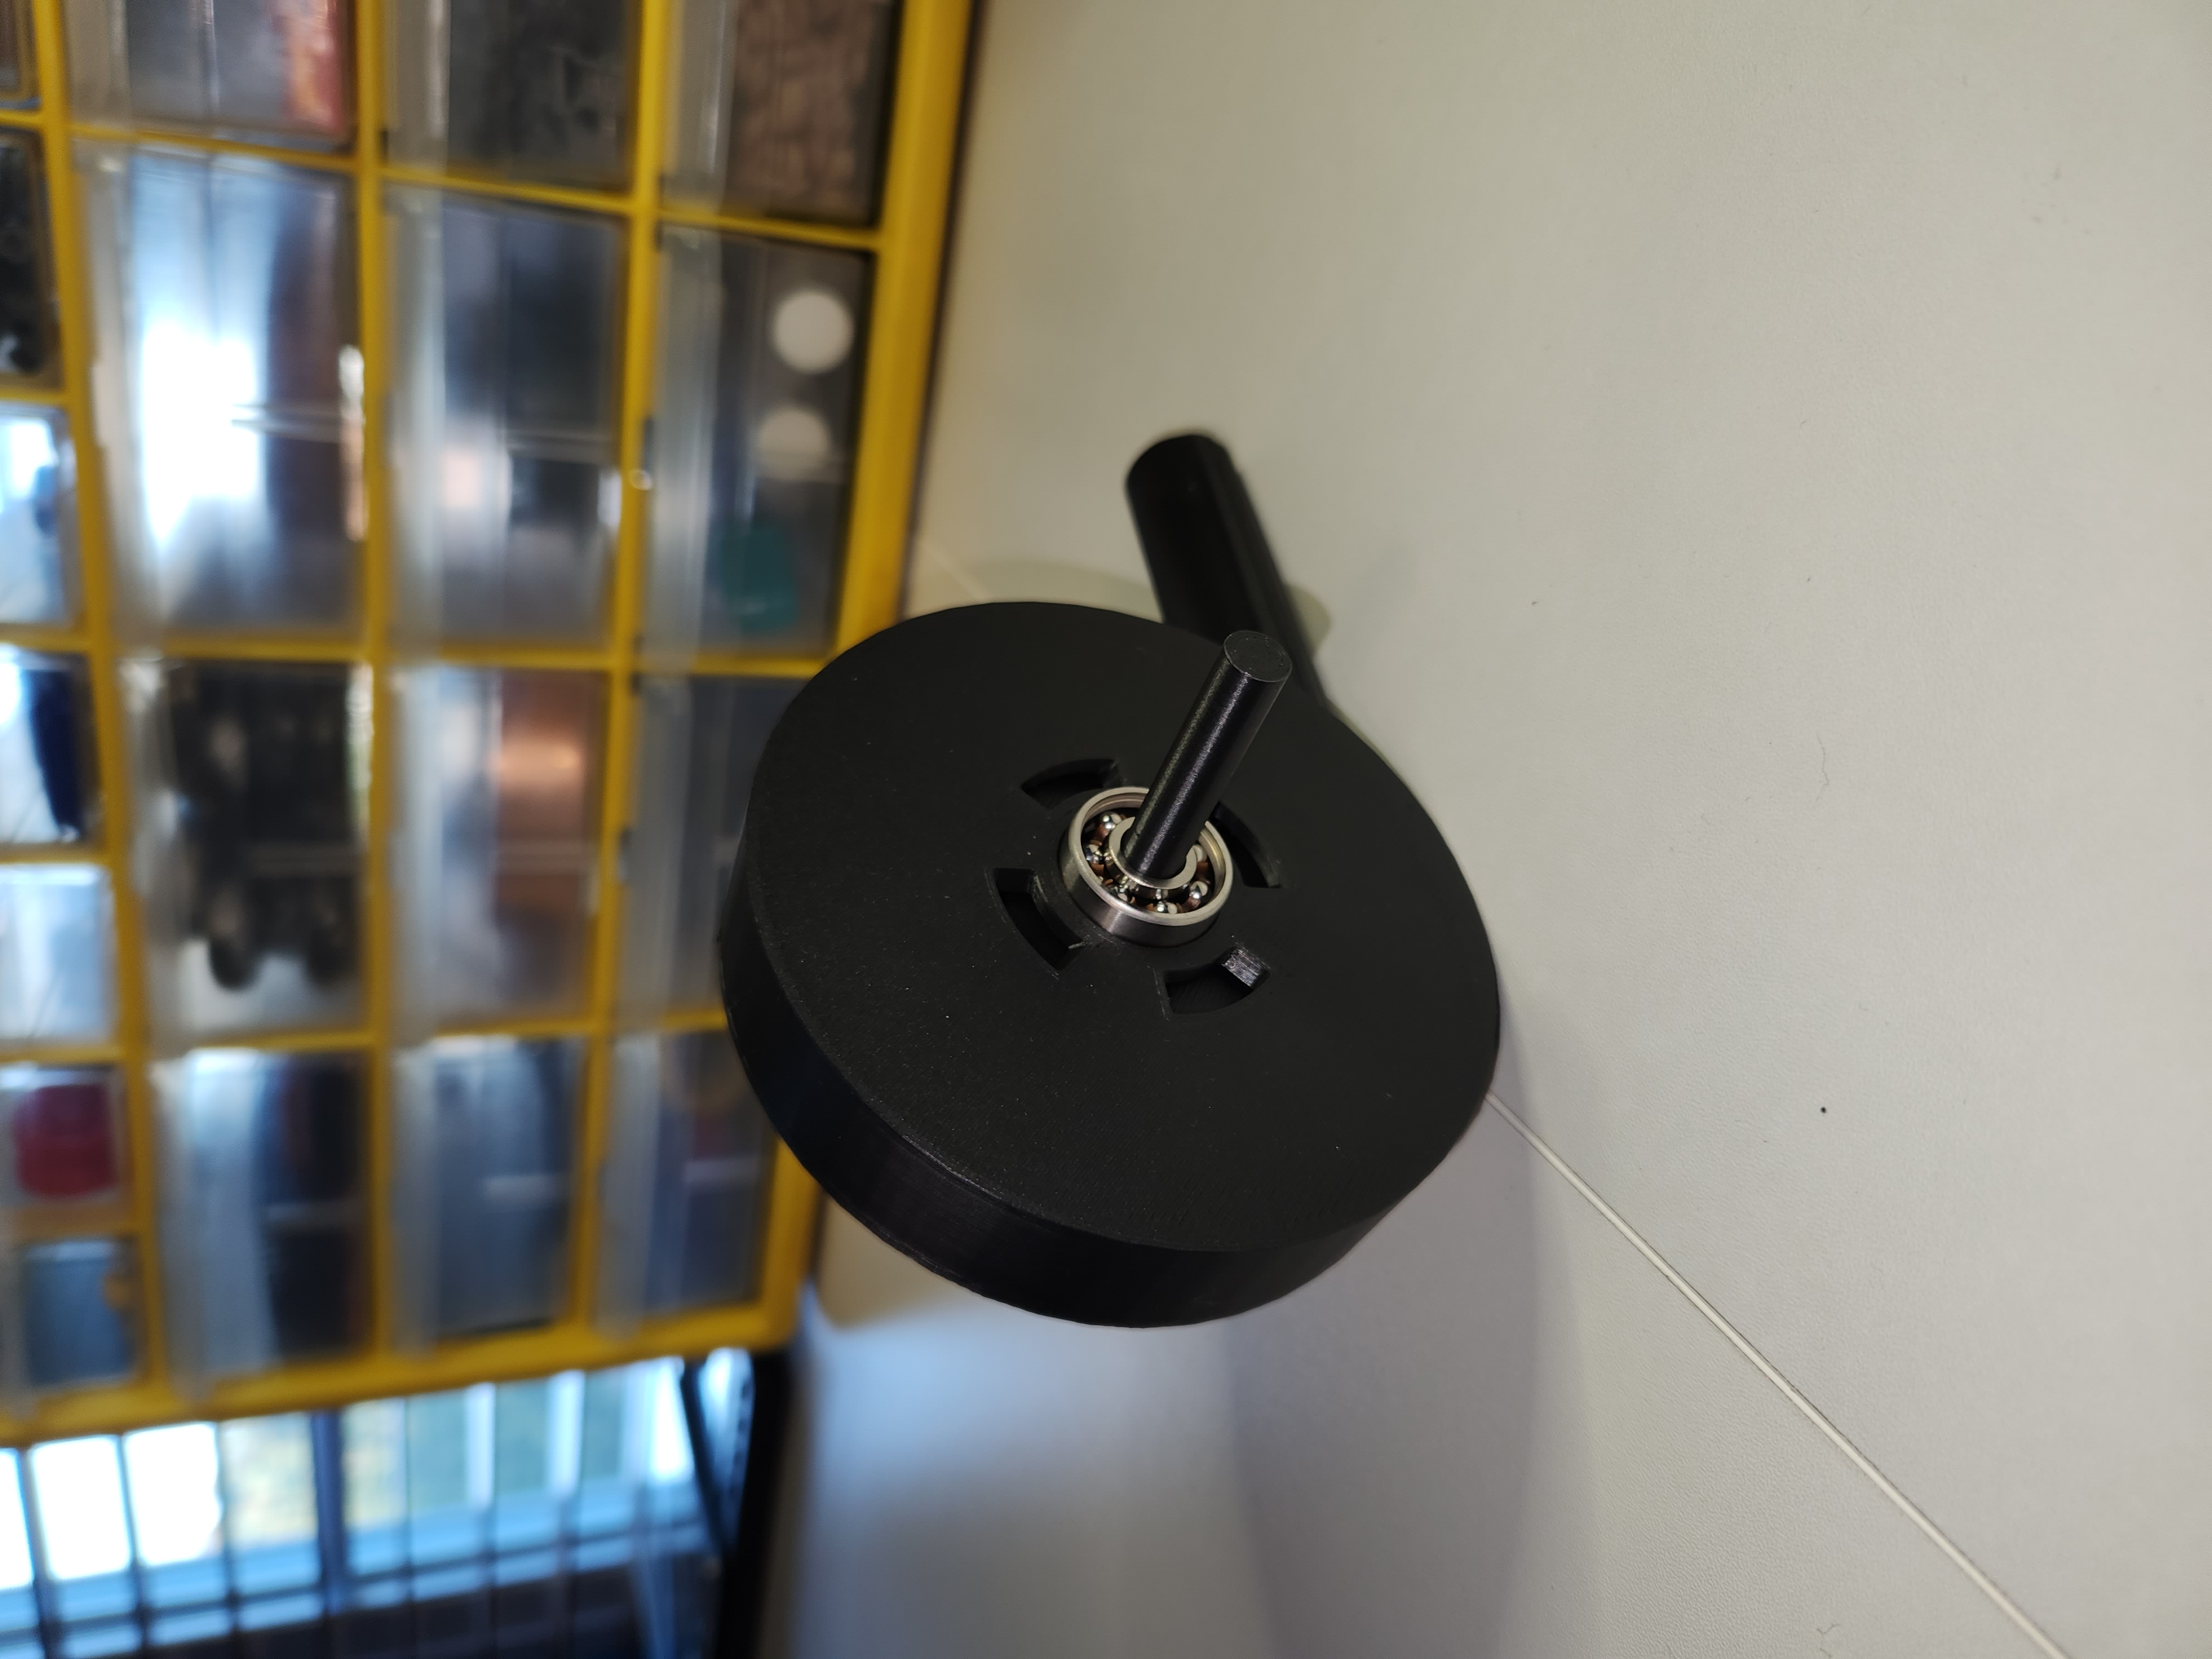
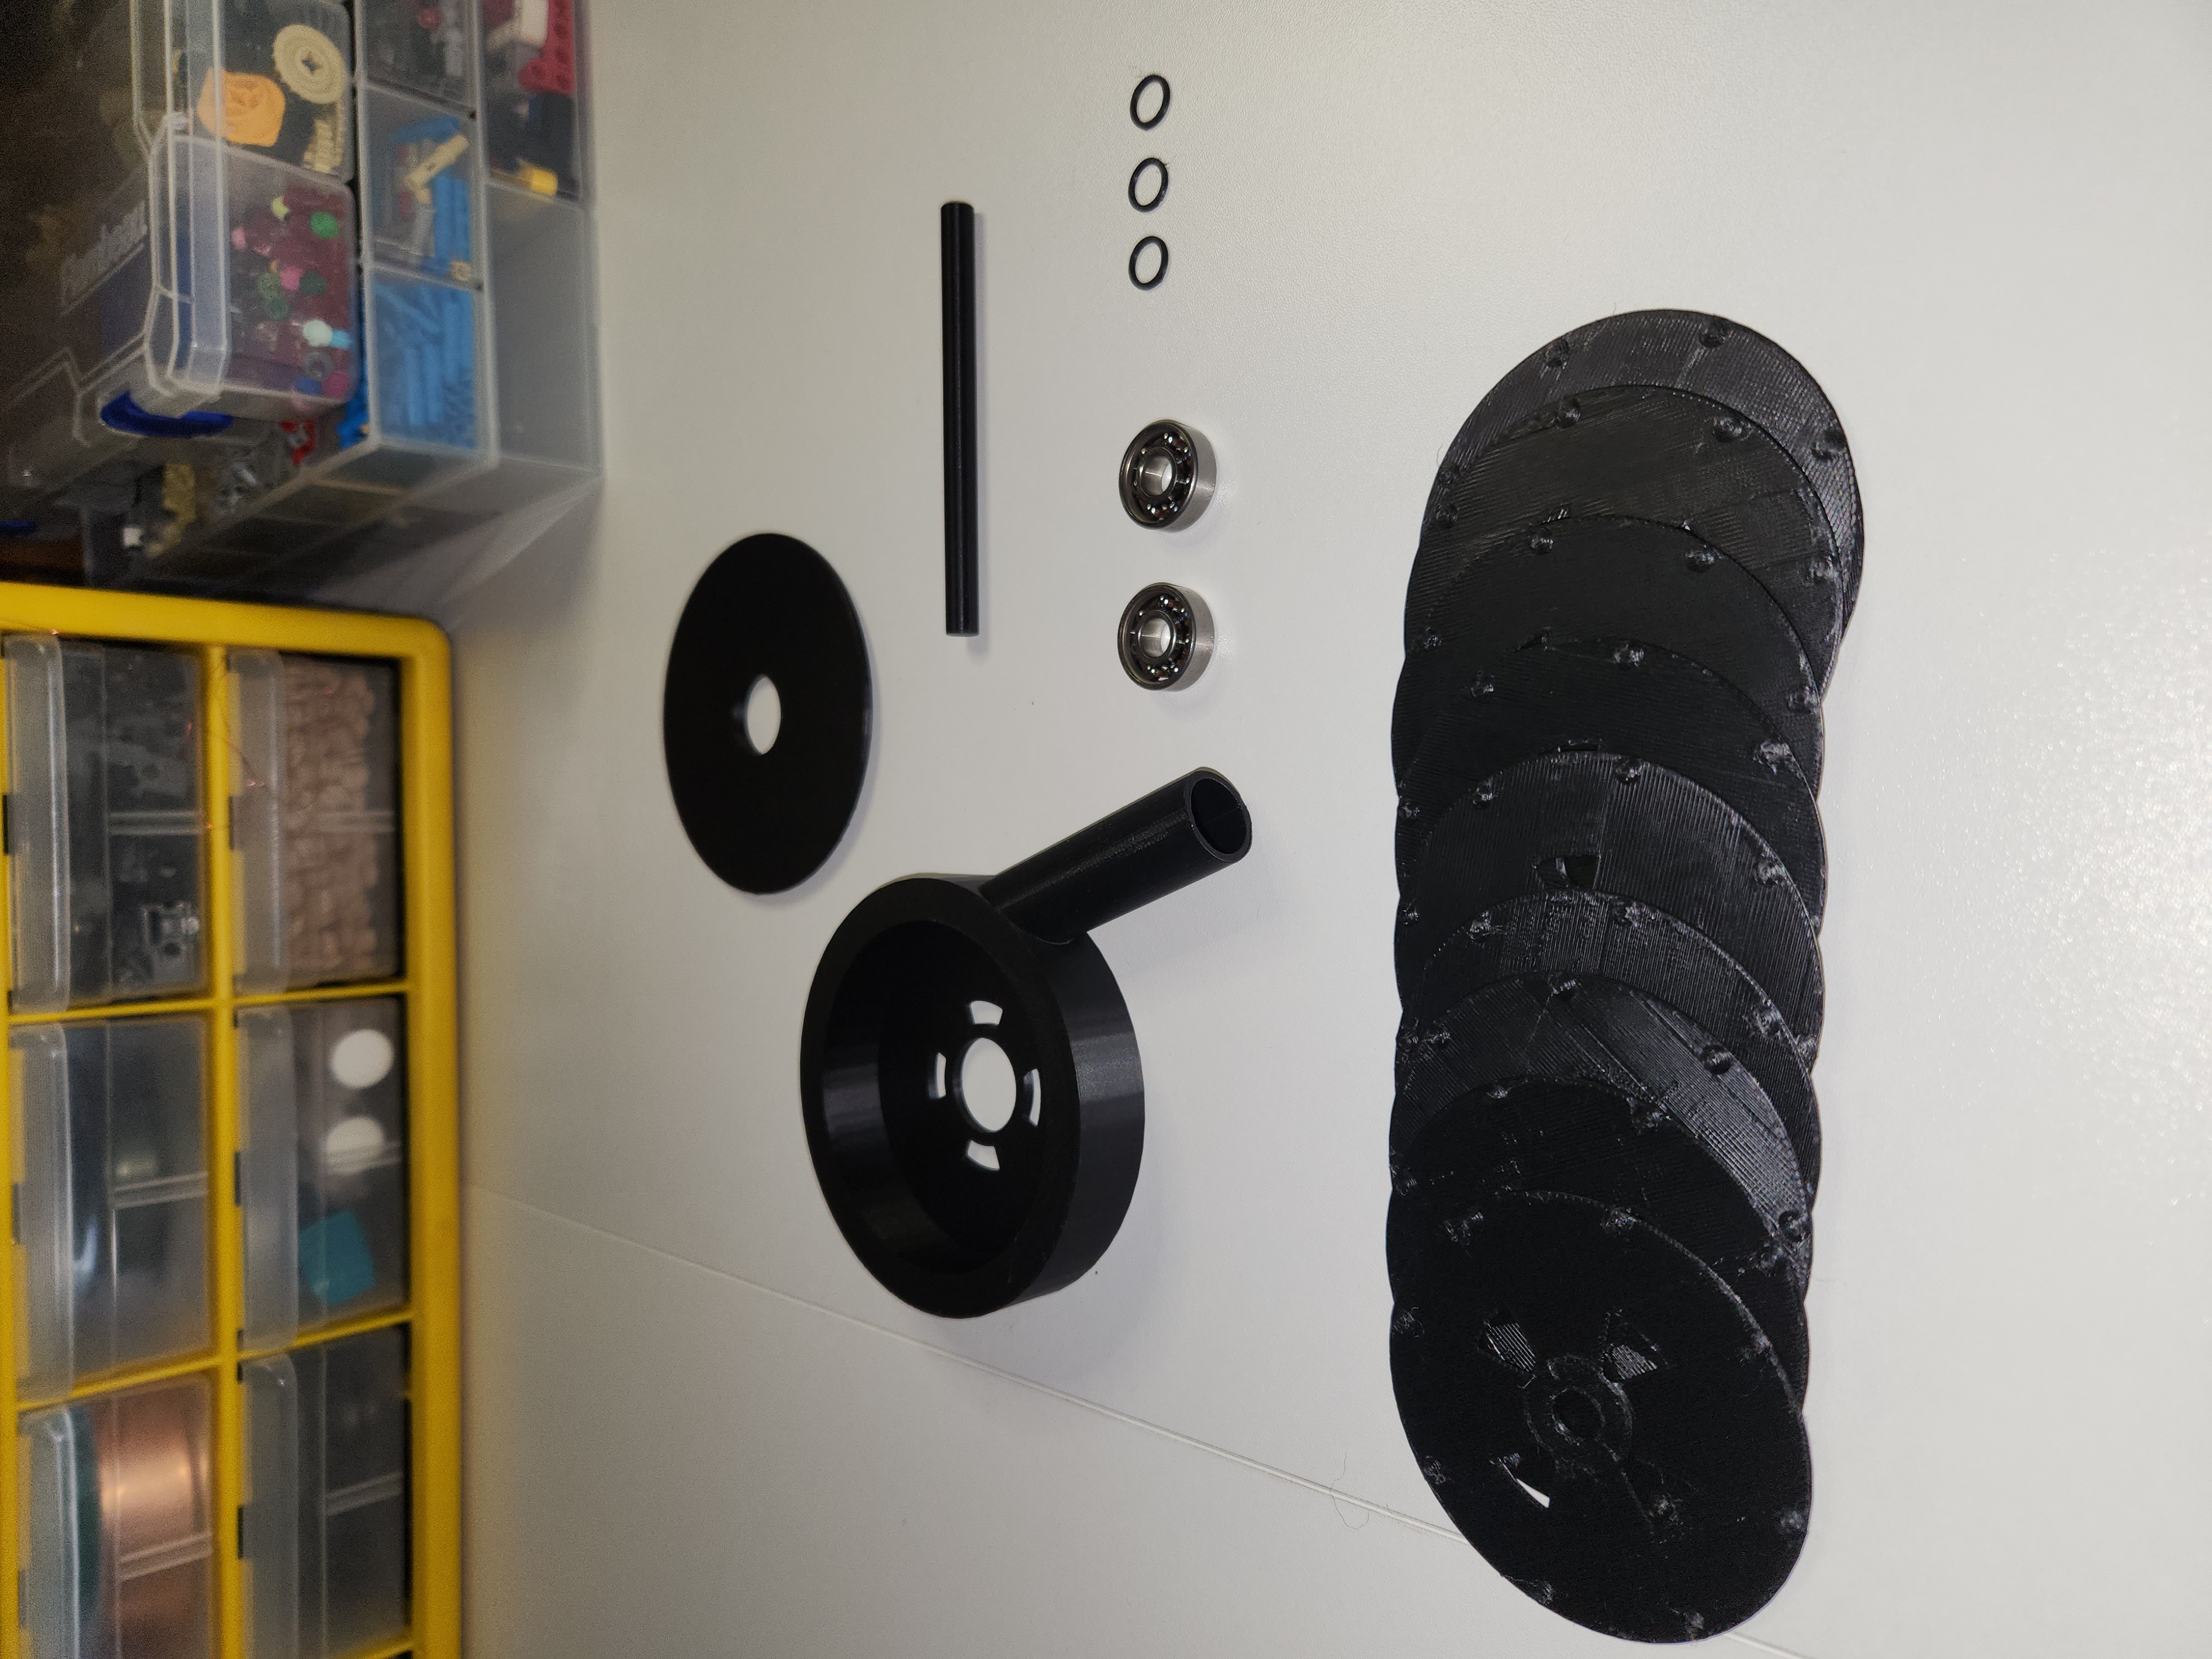
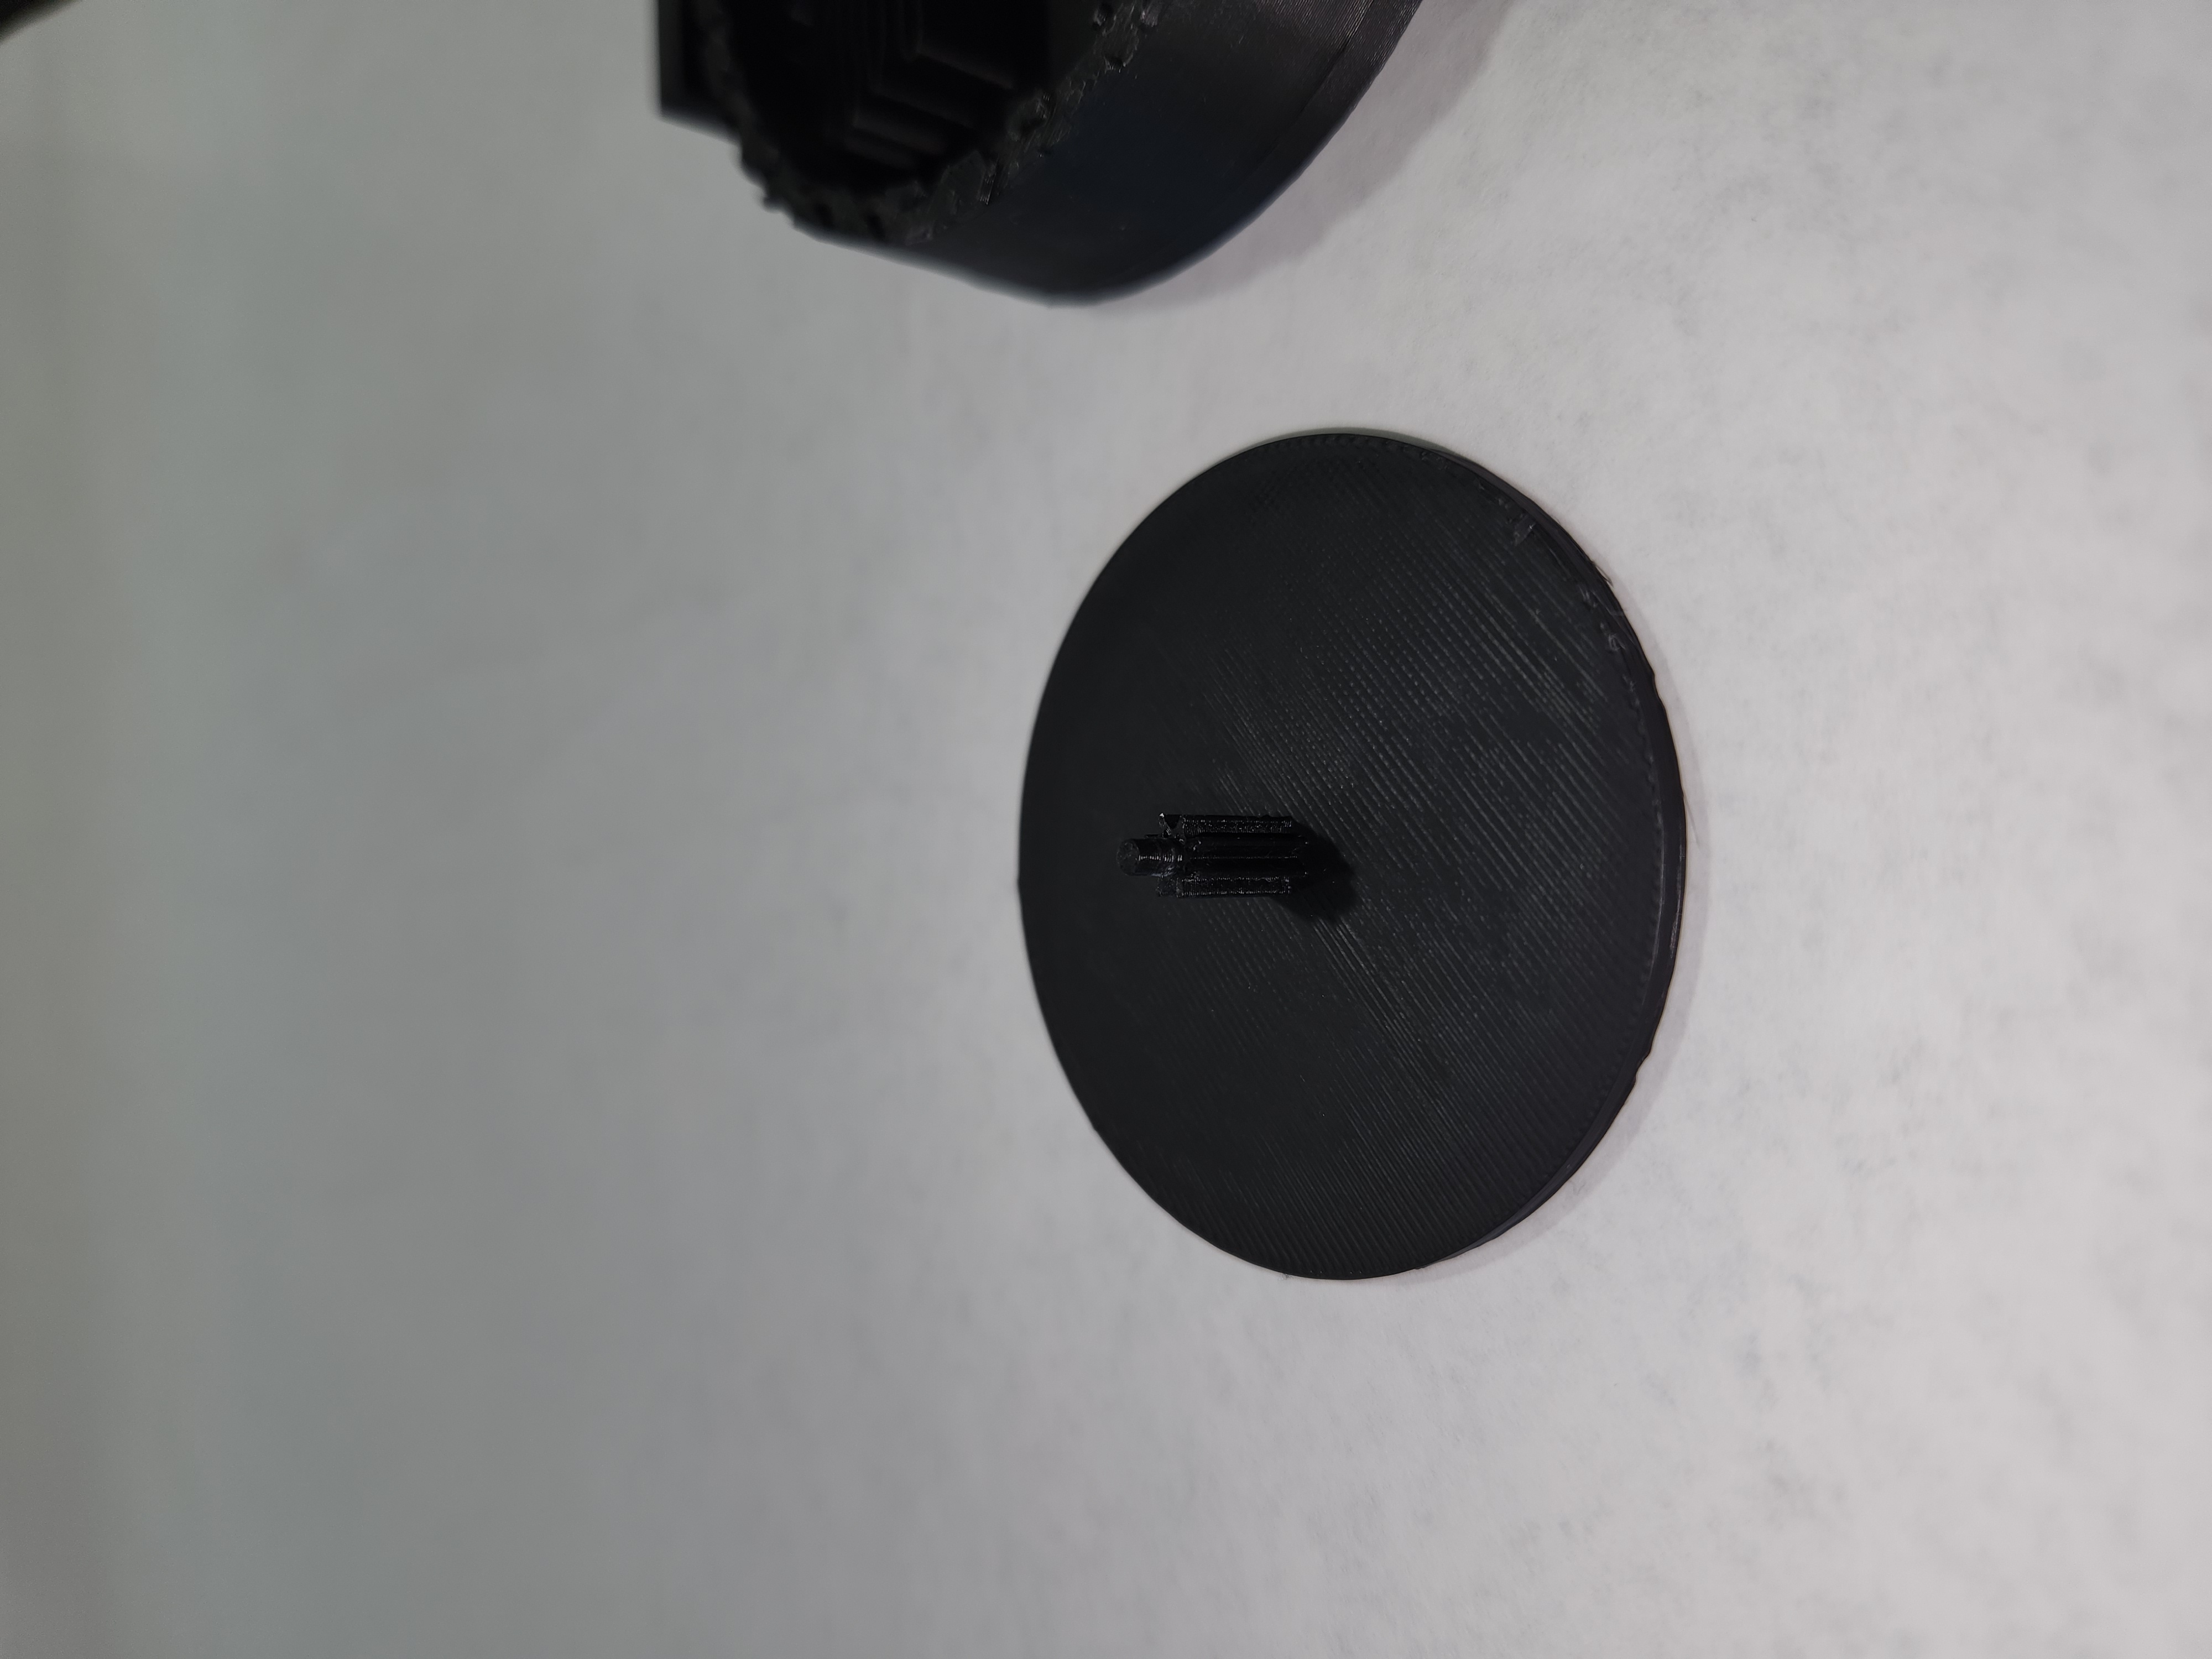
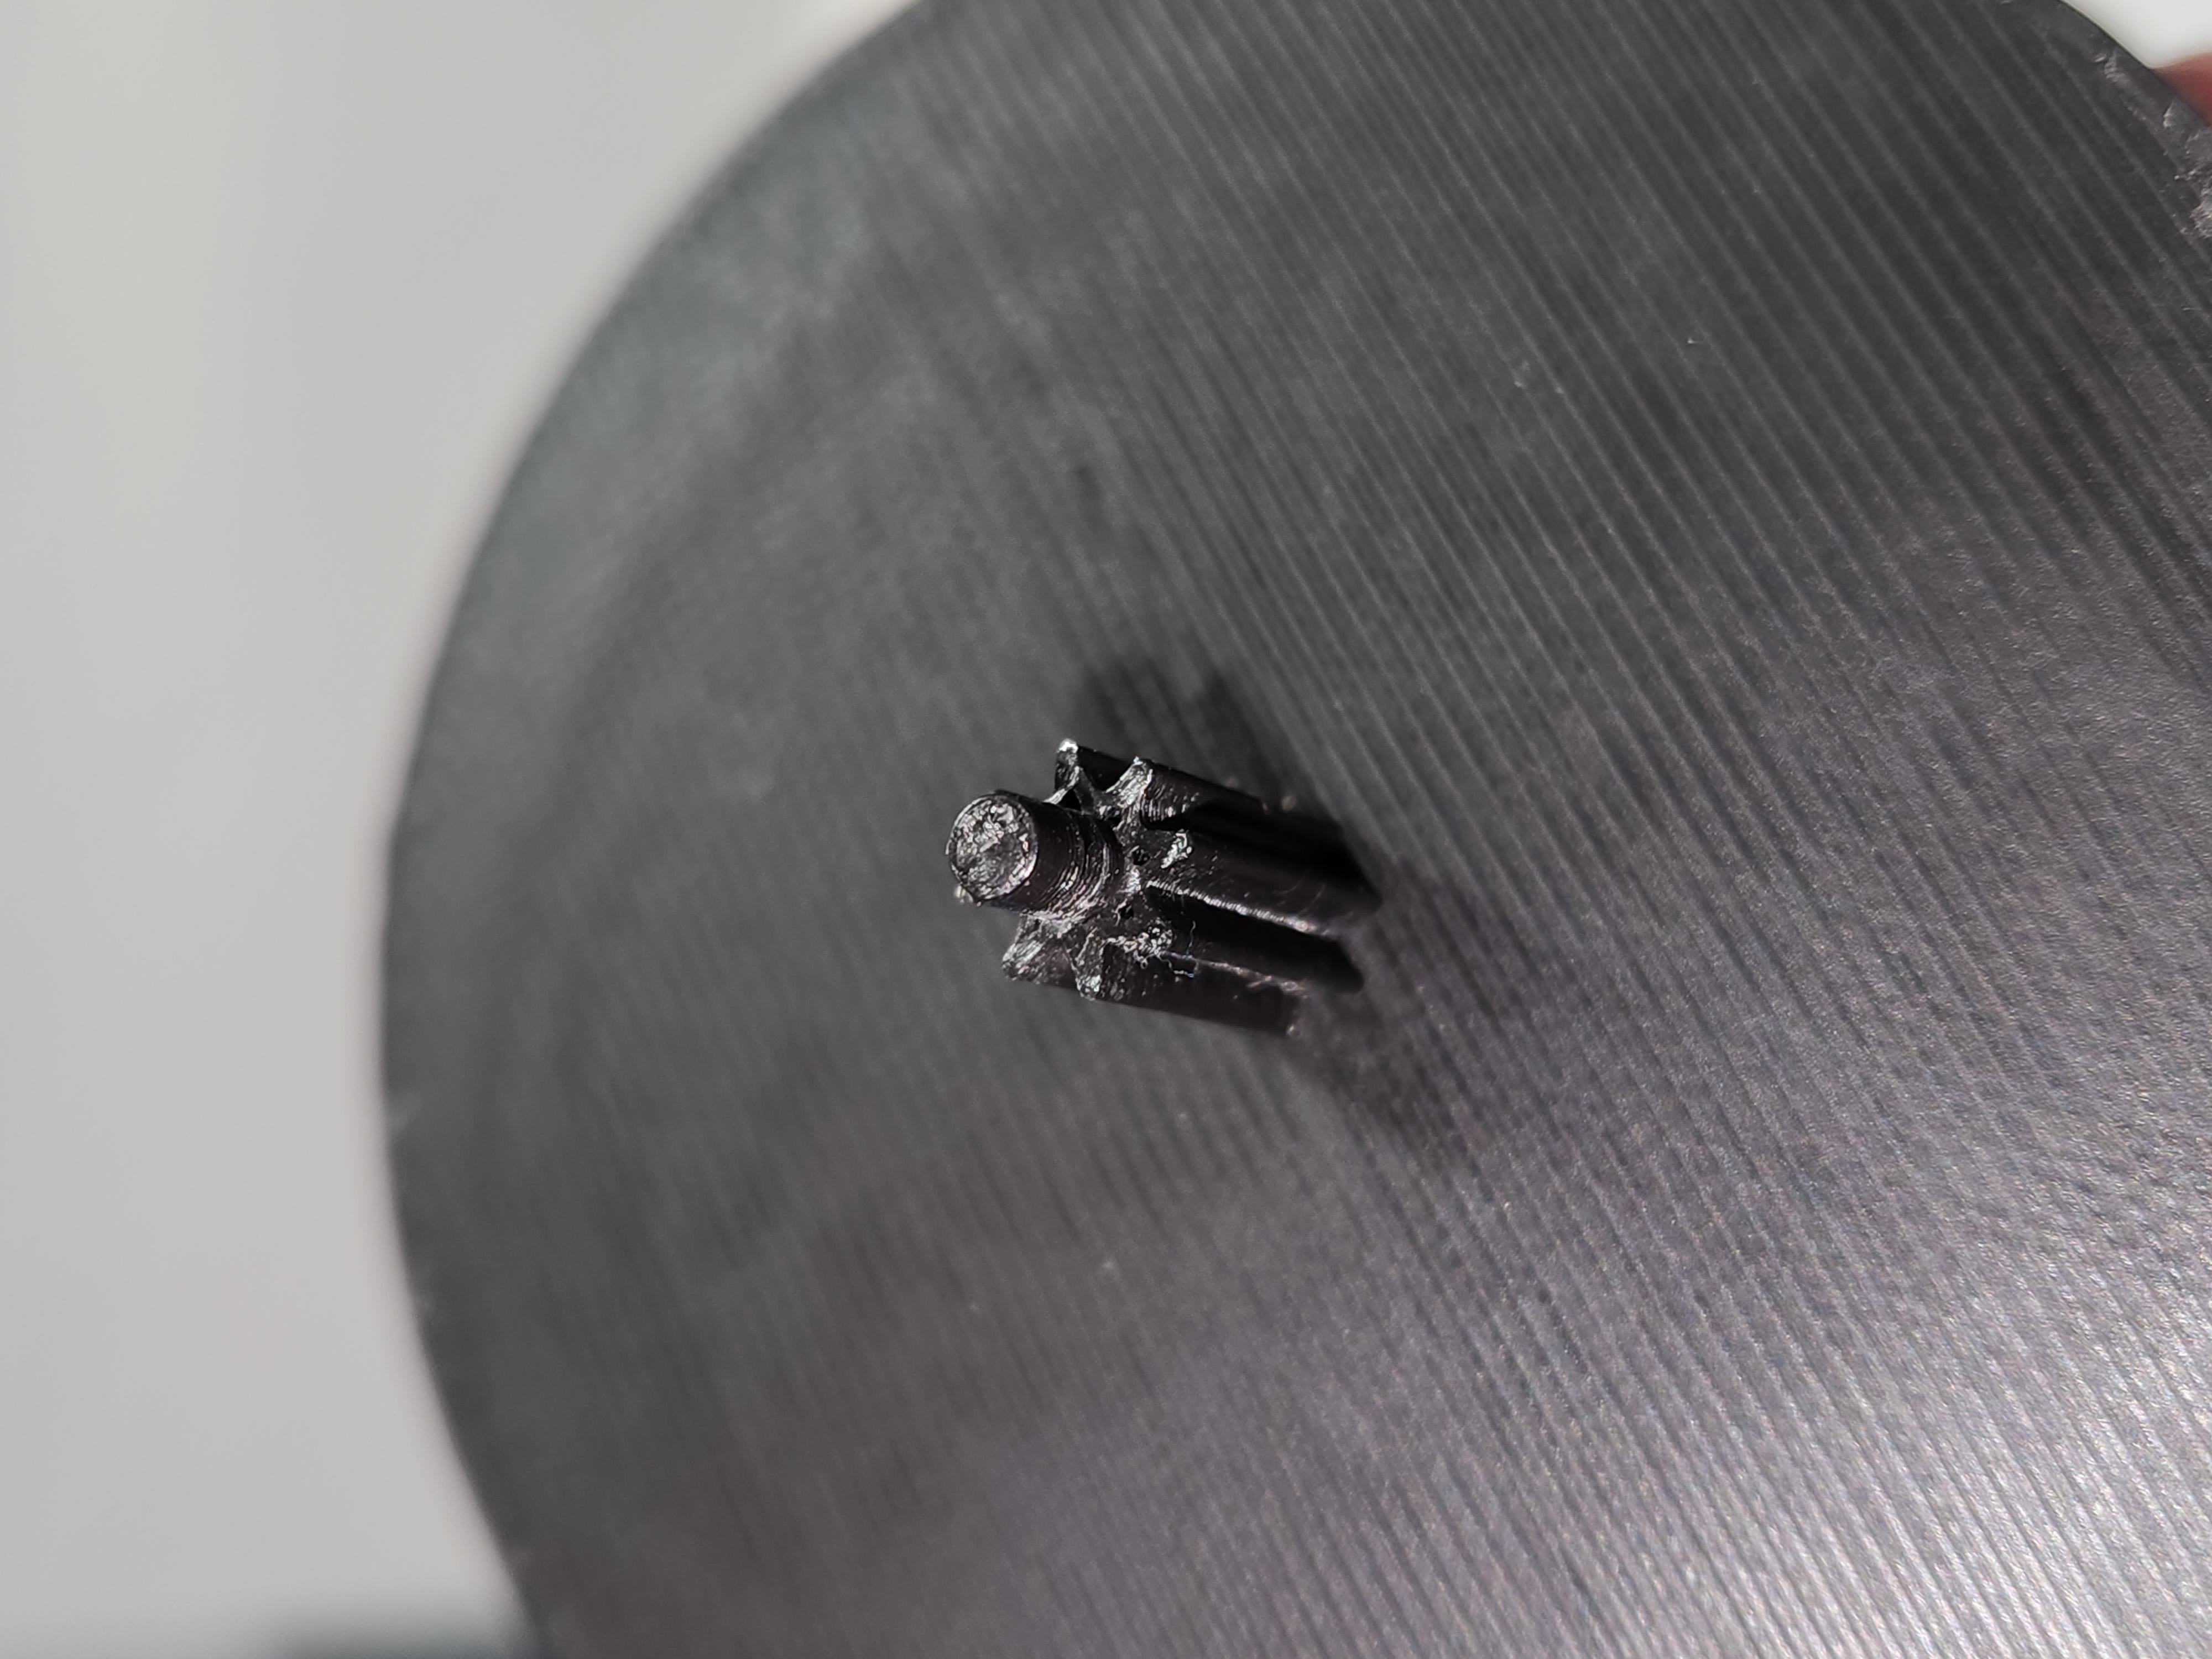
3D Printed
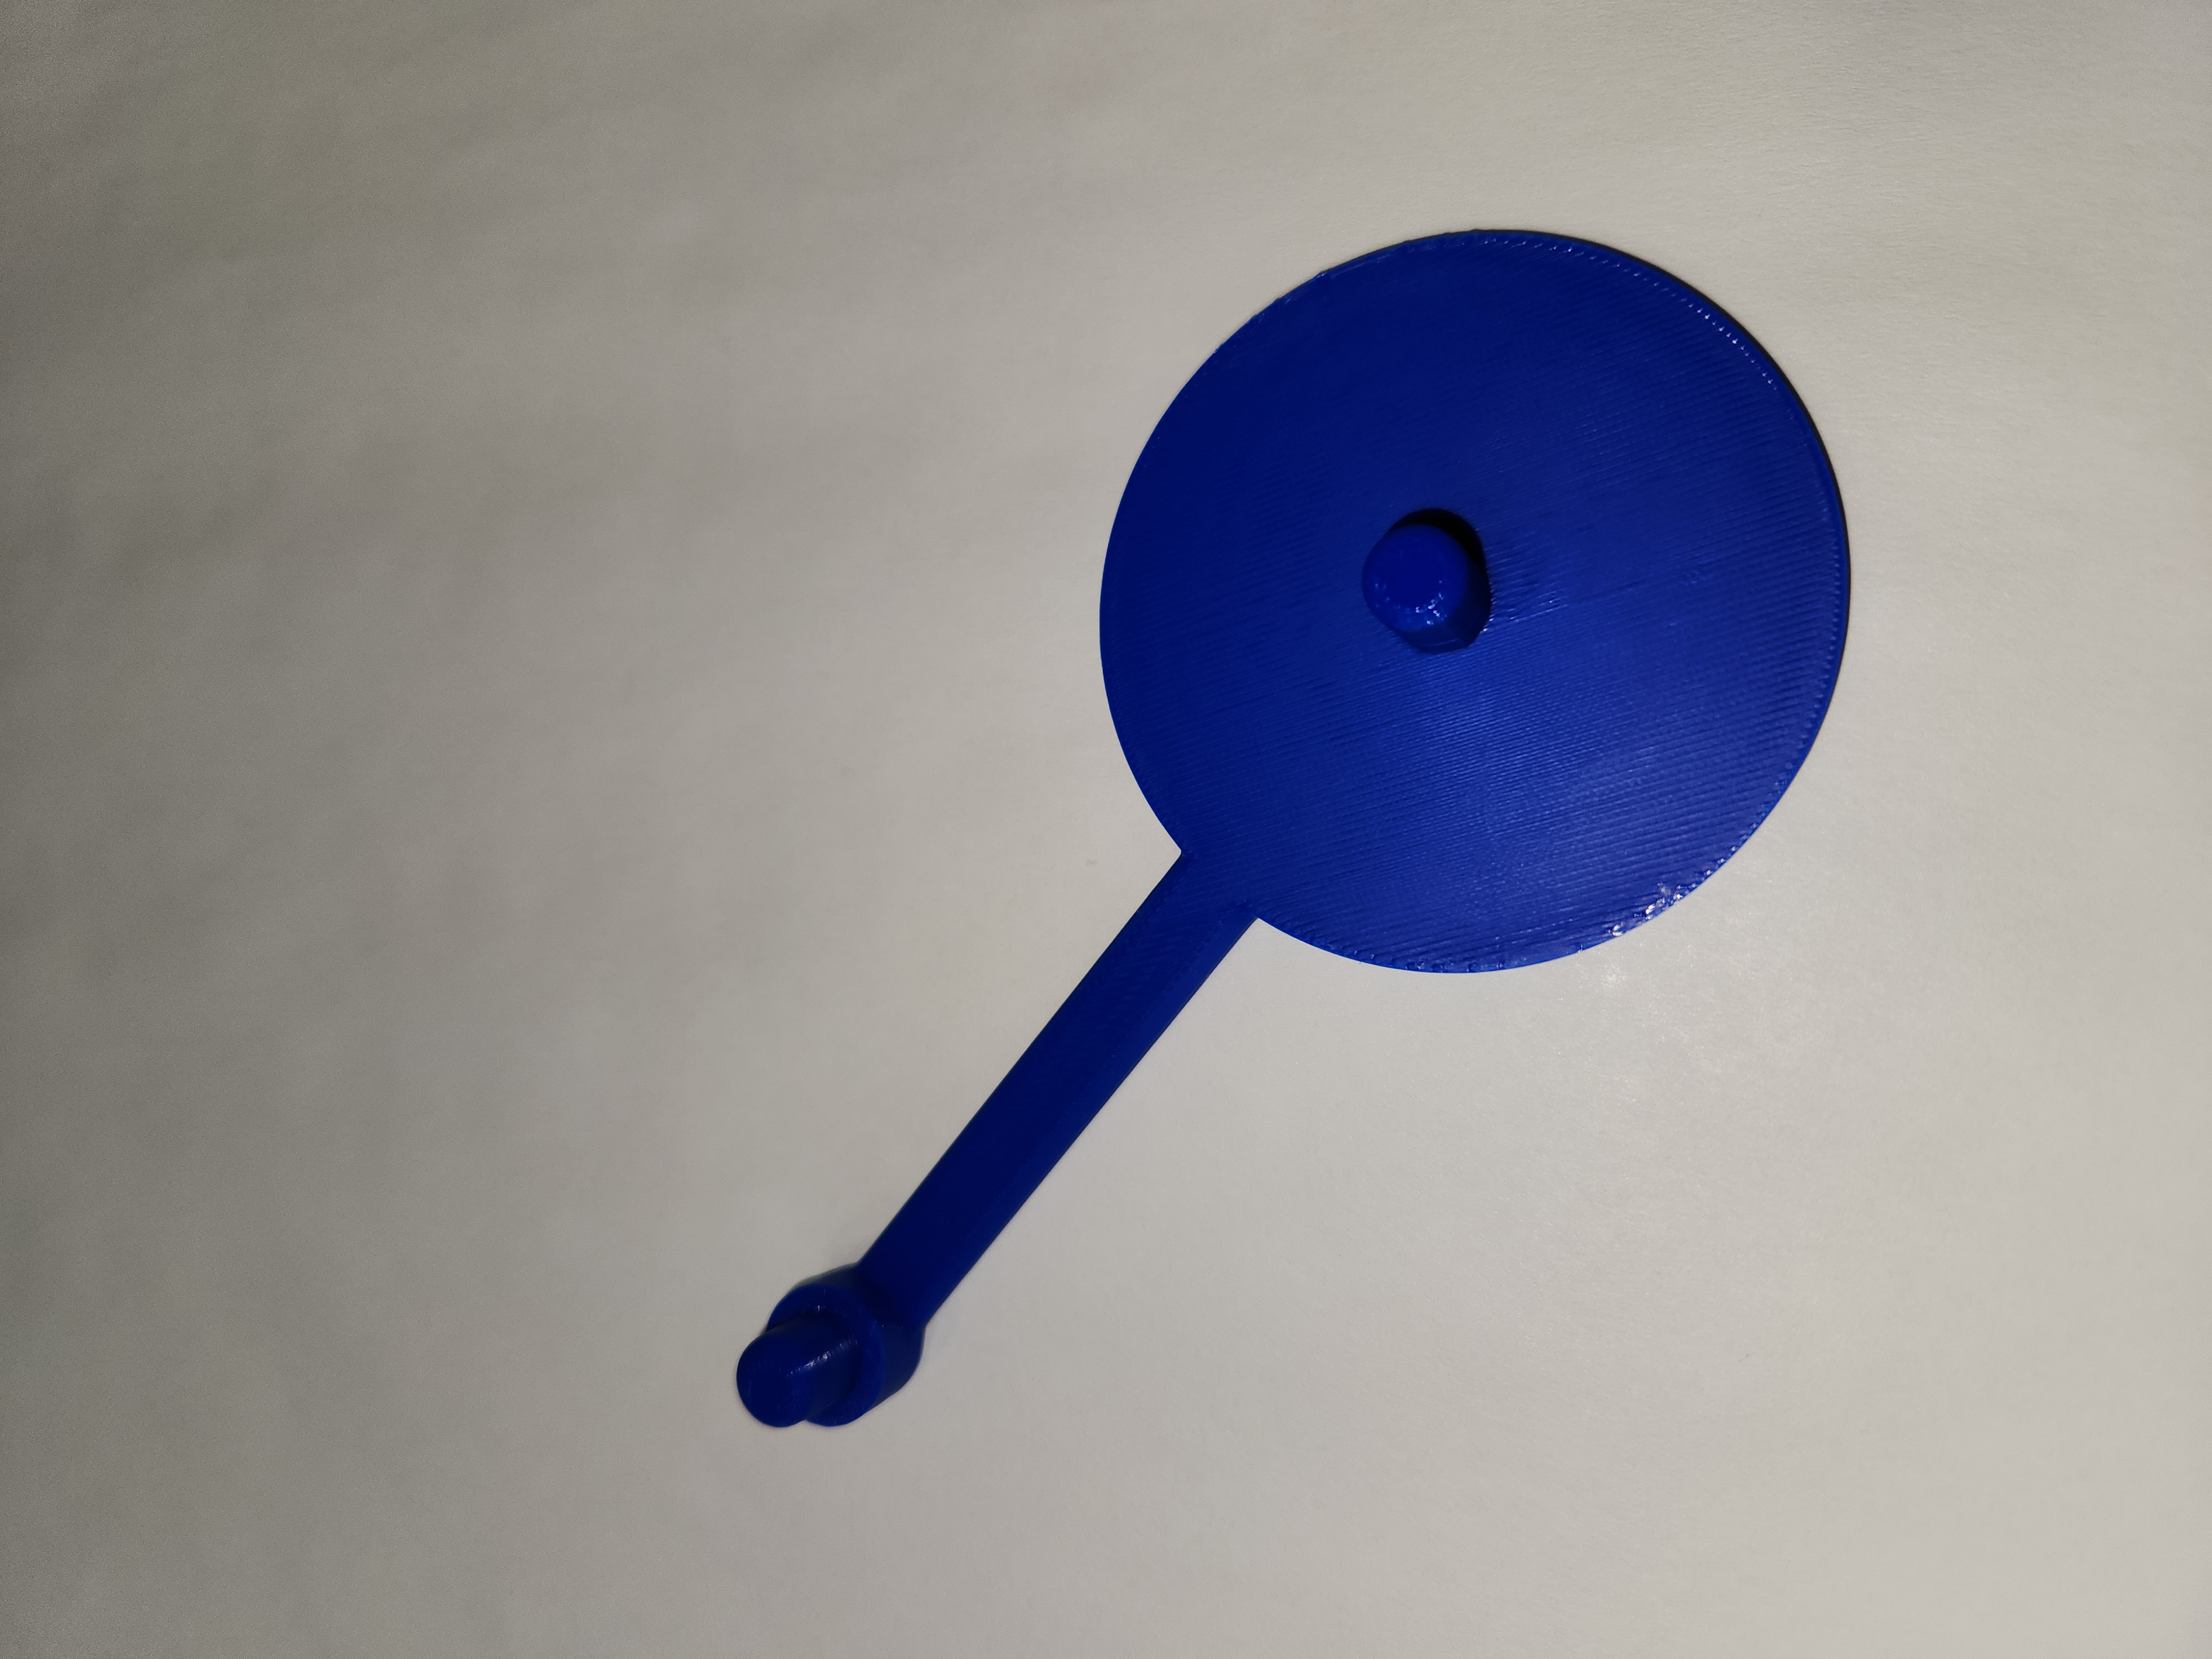
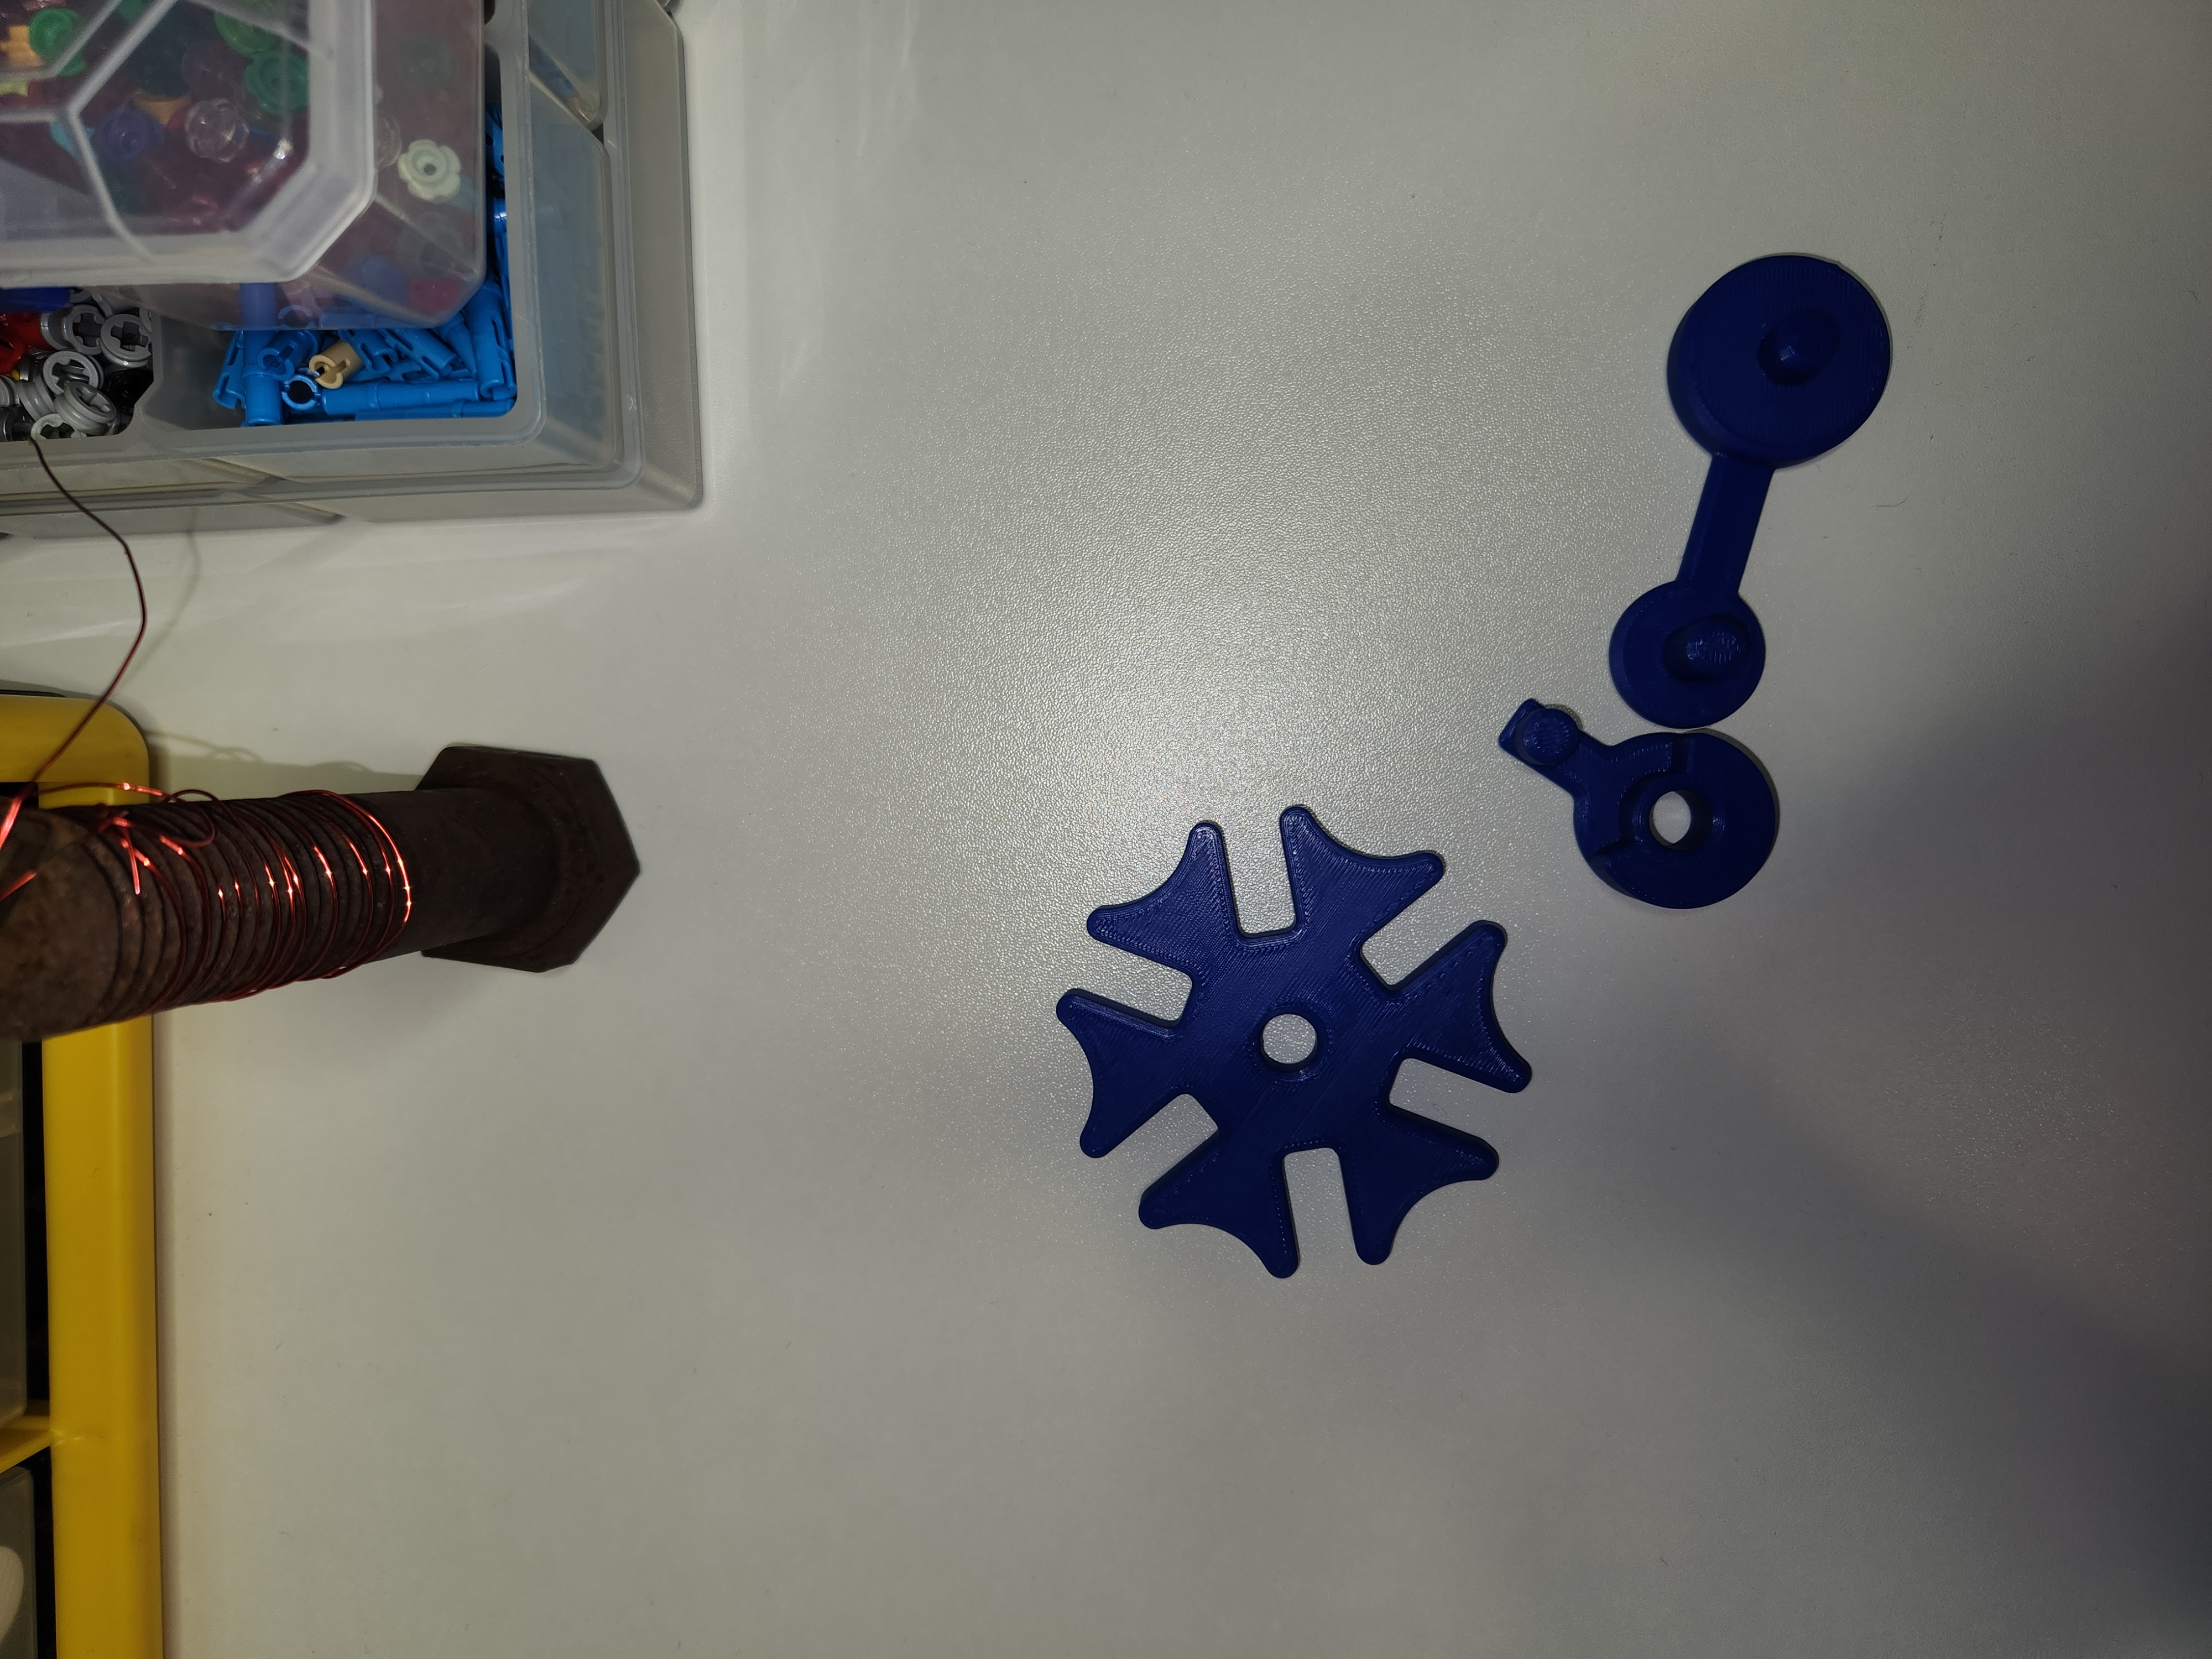
SpindlesSet of 6 face adapters
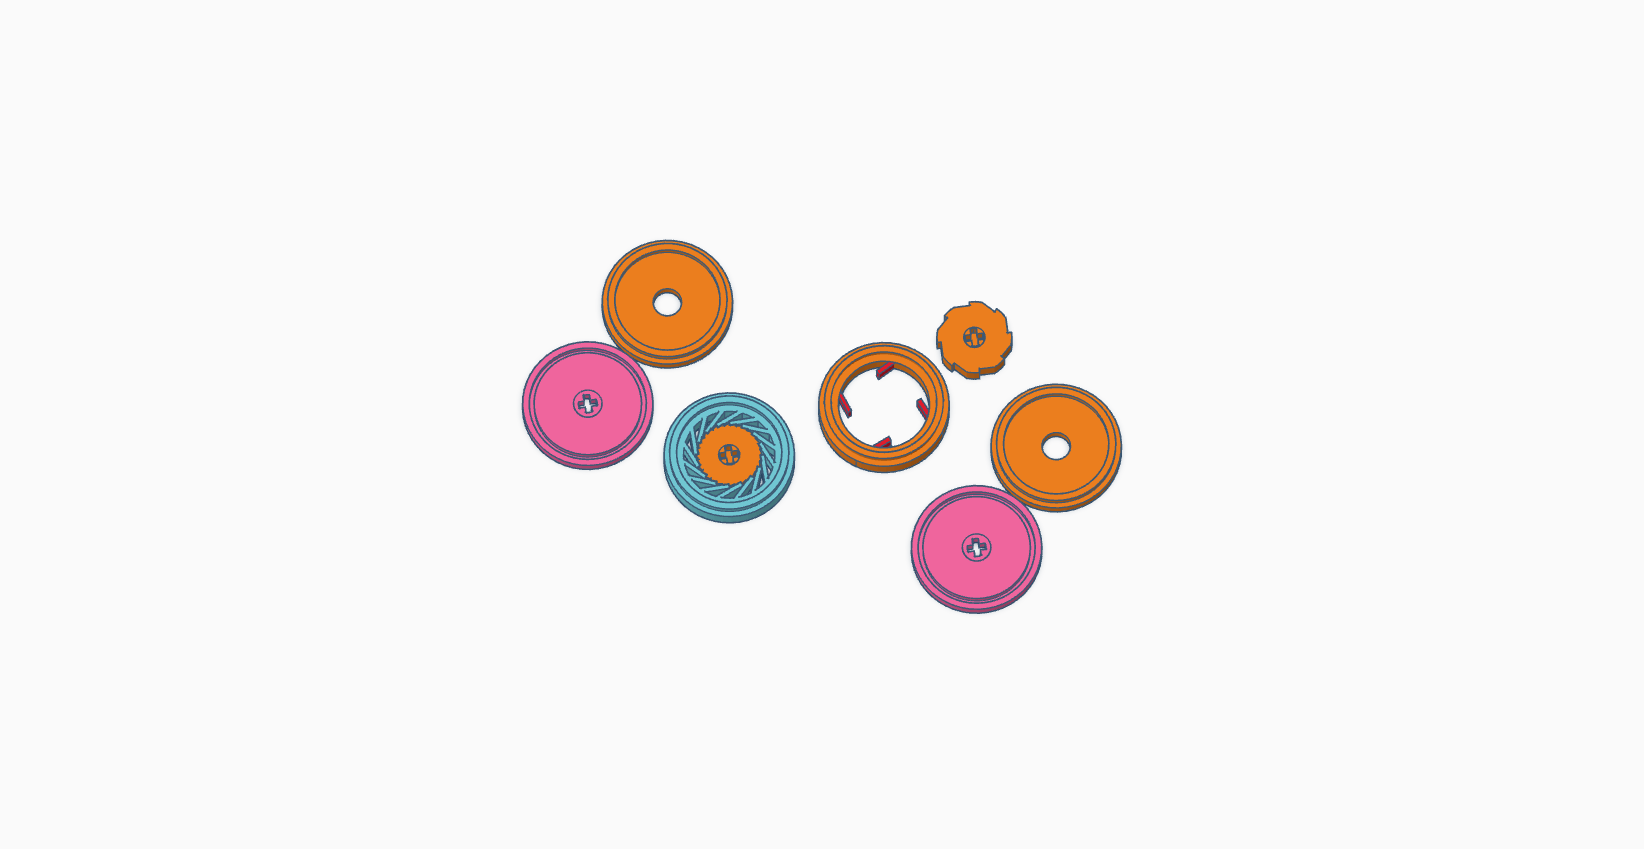
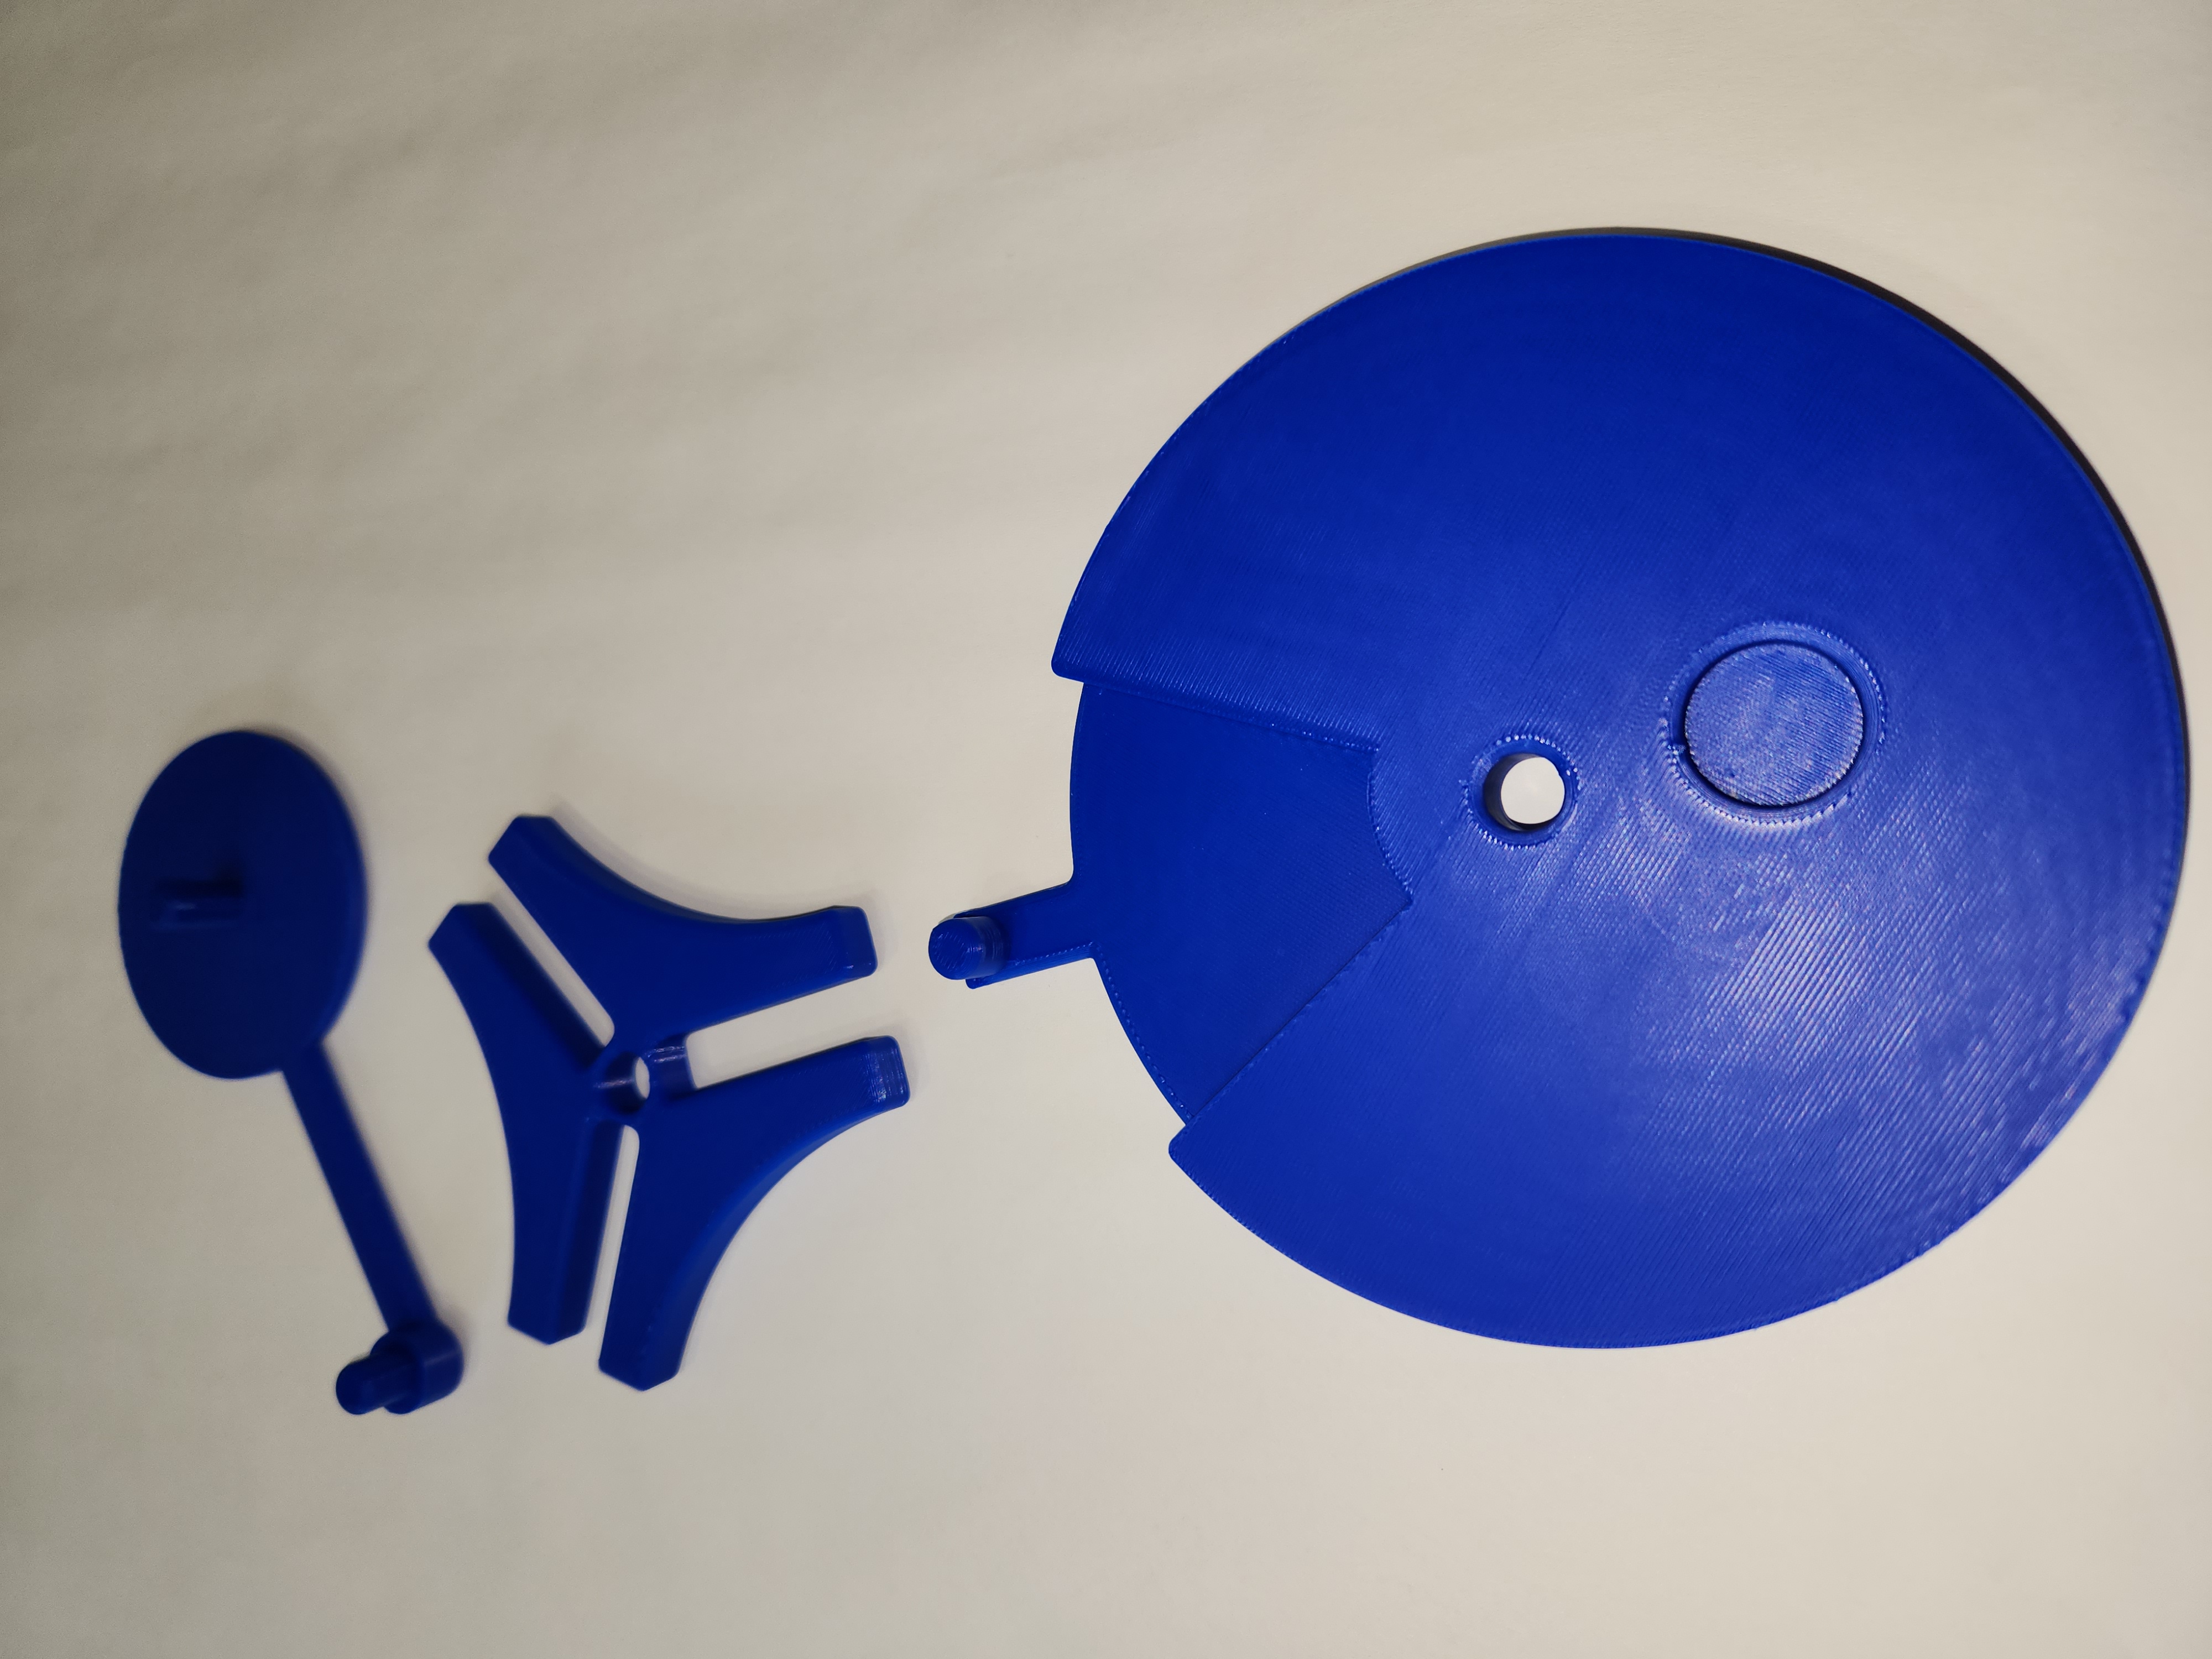
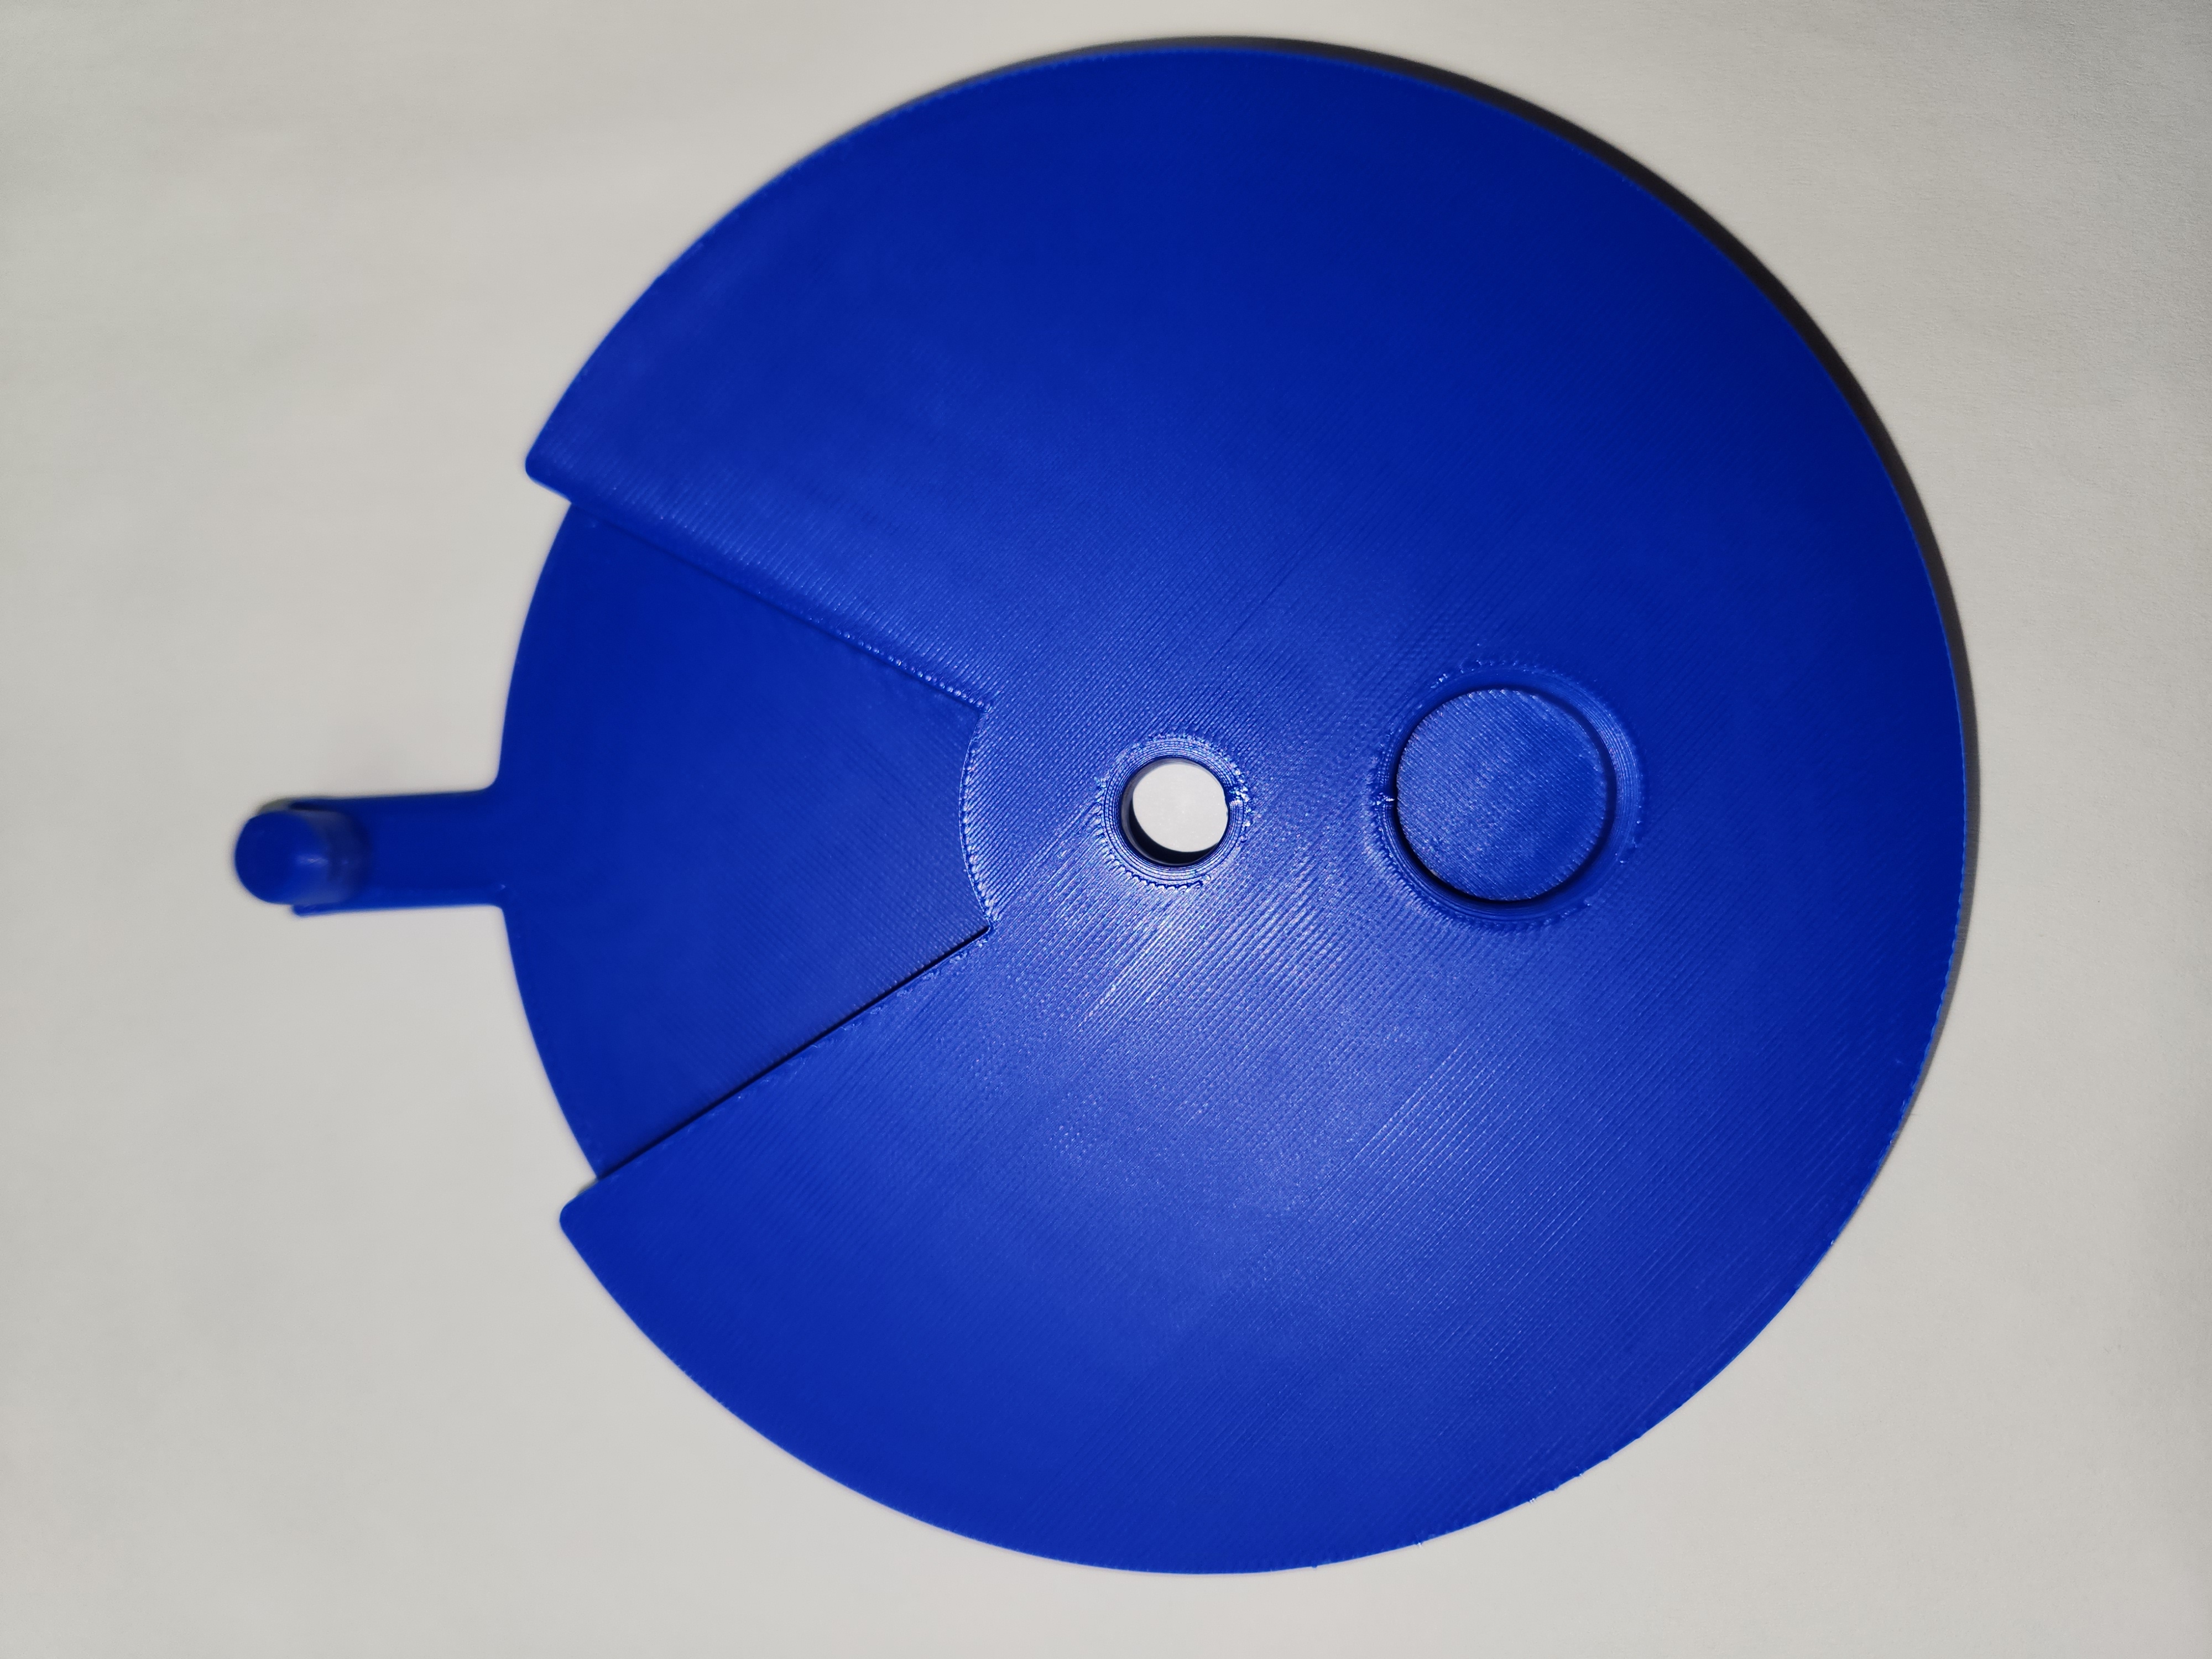
Center Cap
InterfaceCube core retention design
Raspberry Pi
EnclosureCustom active cooling case
Autonomous 6-Axis Robotic Rubik's Cube Solver
Engineered an autonomous high-speed robotics system capable of physically solving any scrambled 3x3 Rubik's cube in under 10 seconds. Designed and manufactured a custom 3D-printed modular chassis on the Creality Ender 3 V3 KE, developed direct-drive NEMA 17 spindle couplers, wired a 24V silent stepper driver bay, deployed Klipper MCU firmware on a dedicated Raspberry Pi, and executed a Two-Phase Kociemba algorithmic solver with parallel dual-axis step compression.
Benchmark Speed
9.68 sec
Kinematic Axes
6-Axis Indep.
Move Complexity
18-20 moves
Motion Planning
Parallel Axis
| Subsystem | Engineering Specification | Operational Parameters |
|---|---|---|
| Structural Chassis | Modular 3D-Printed Frame & Towers | Printed on Ender 3 V3 KE; 4 vertical stanchions absorbing reactionary torque |
| Actuation System | 6x NEMA 17 Stepper Motors | 1.8° step angle, 1.5A current, direct-drive coupling to each cube face |
| Motion Controller | 32-Bit MCU + Silent TMC2209 Drivers | Trinamic StealthChop microstepping, high acceleration velocity trapezoids |
| Host Compute | Raspberry Pi + Klipper | Custom 3D printed active-cooled case, high-speed USB-serial motion link |
| Solving Algorithm | Two-Phase Kociemba Algorithm | Optimal ~18–20 move solutions (God's Number tier) generated in milliseconds |
| Step Compression | Parallel Dual-Axis Scheduling | Simultaneous execution of non-conflicting face turns (U+D, L+R, F+B) |
| Power Supply | Mean Well LRS-350-24 (24V 14.6A) | 350W industrial power delivery for high concurrent stepper current draws |
⚙️ Mechanical & Kinematic Design
- Direct-Drive Spindle Adapters: Engineered custom D-shaft couplers with set-screw retention, directly interfacing with the Rubik's cube center piece cavities while maintaining internal spherical bearing preload.
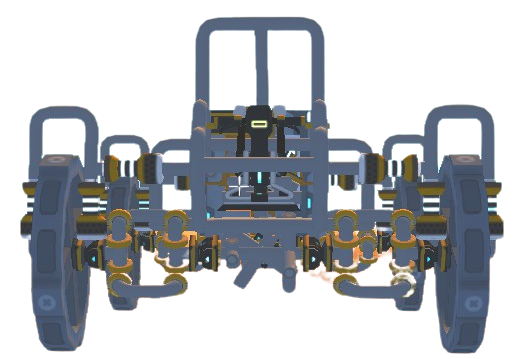
- Reactionary Torque Dampening: 4 interlocking vertical riser towers form a rigid orthogonal box with the gantry, preventing angular deflection during abrupt 500+ RPM/s² face stops.
⚡ Software, Firmware & Digital Twin
- Parallel Move Compression: Algorithmic motion planner analyzes God's Number move sequences and merges opposing face turns into concurrent dual-axis pulses, slashing physical solve time to 9.68 seconds.
- Digital Twin State Verification: Python simulation verifies cube legality and virtual kinematic states before issuing motion commands to the Klipper MCU, preventing jam states.

.png)
.png)
.png)
.png)
.png)