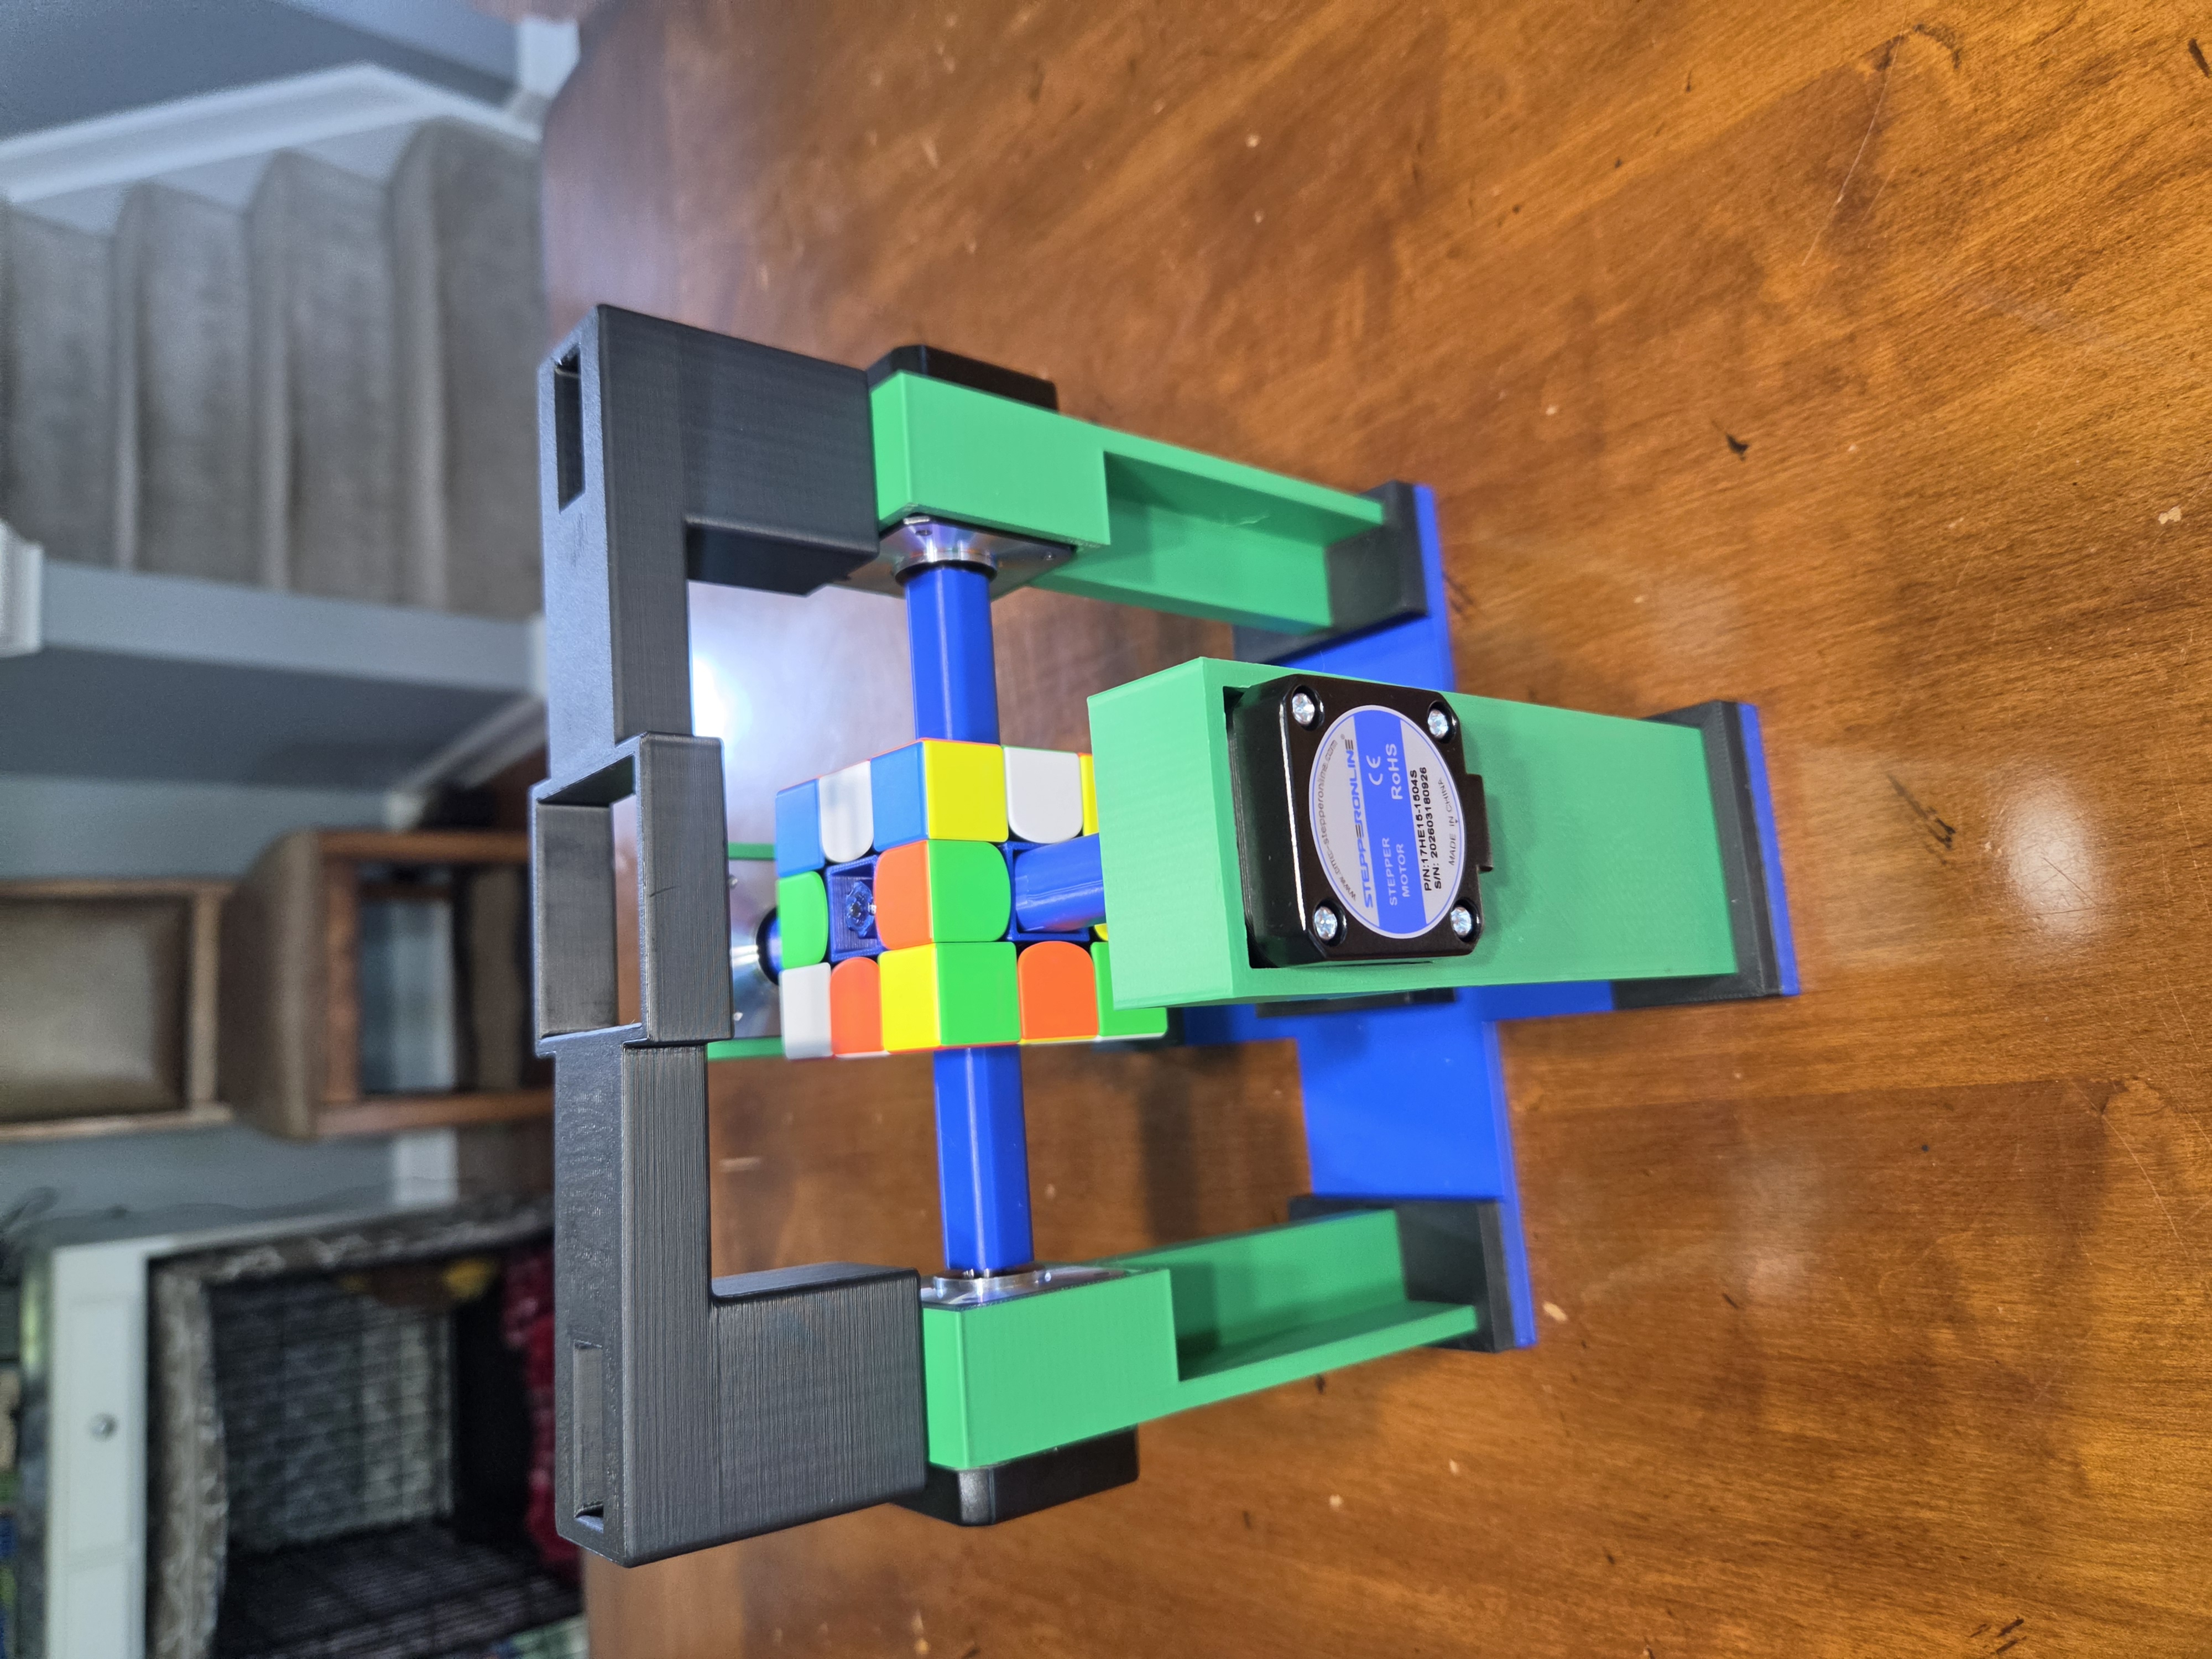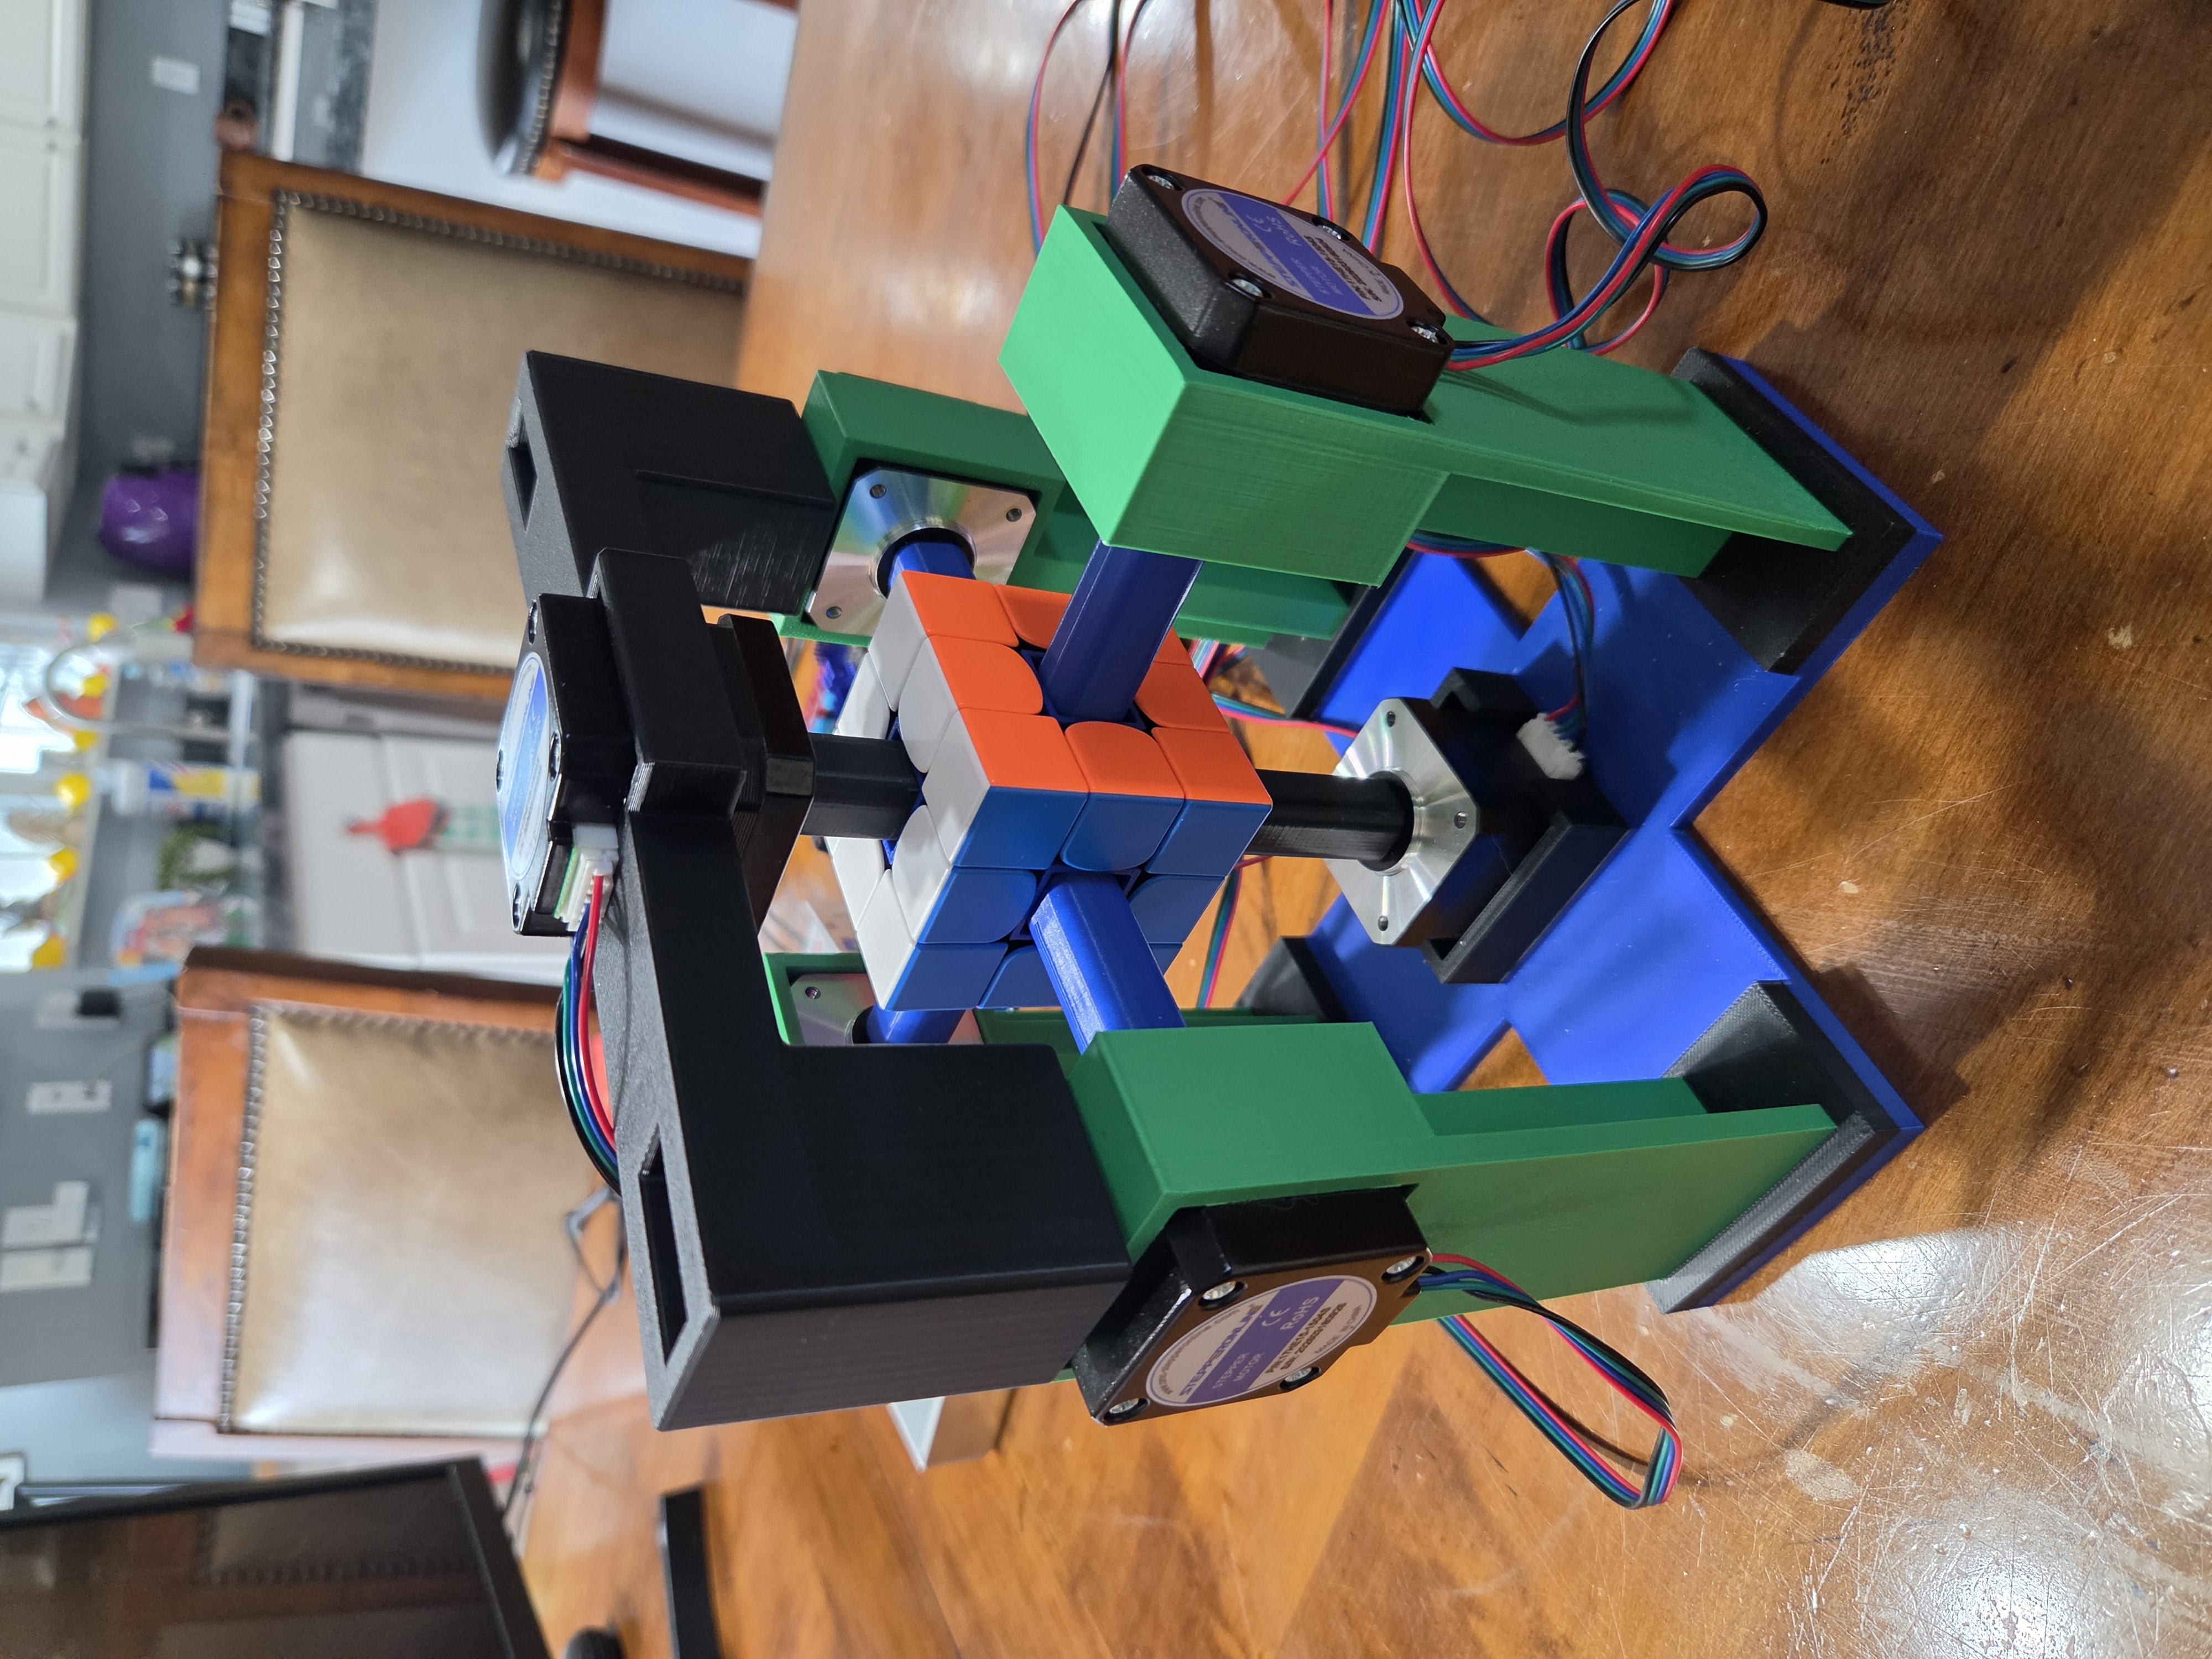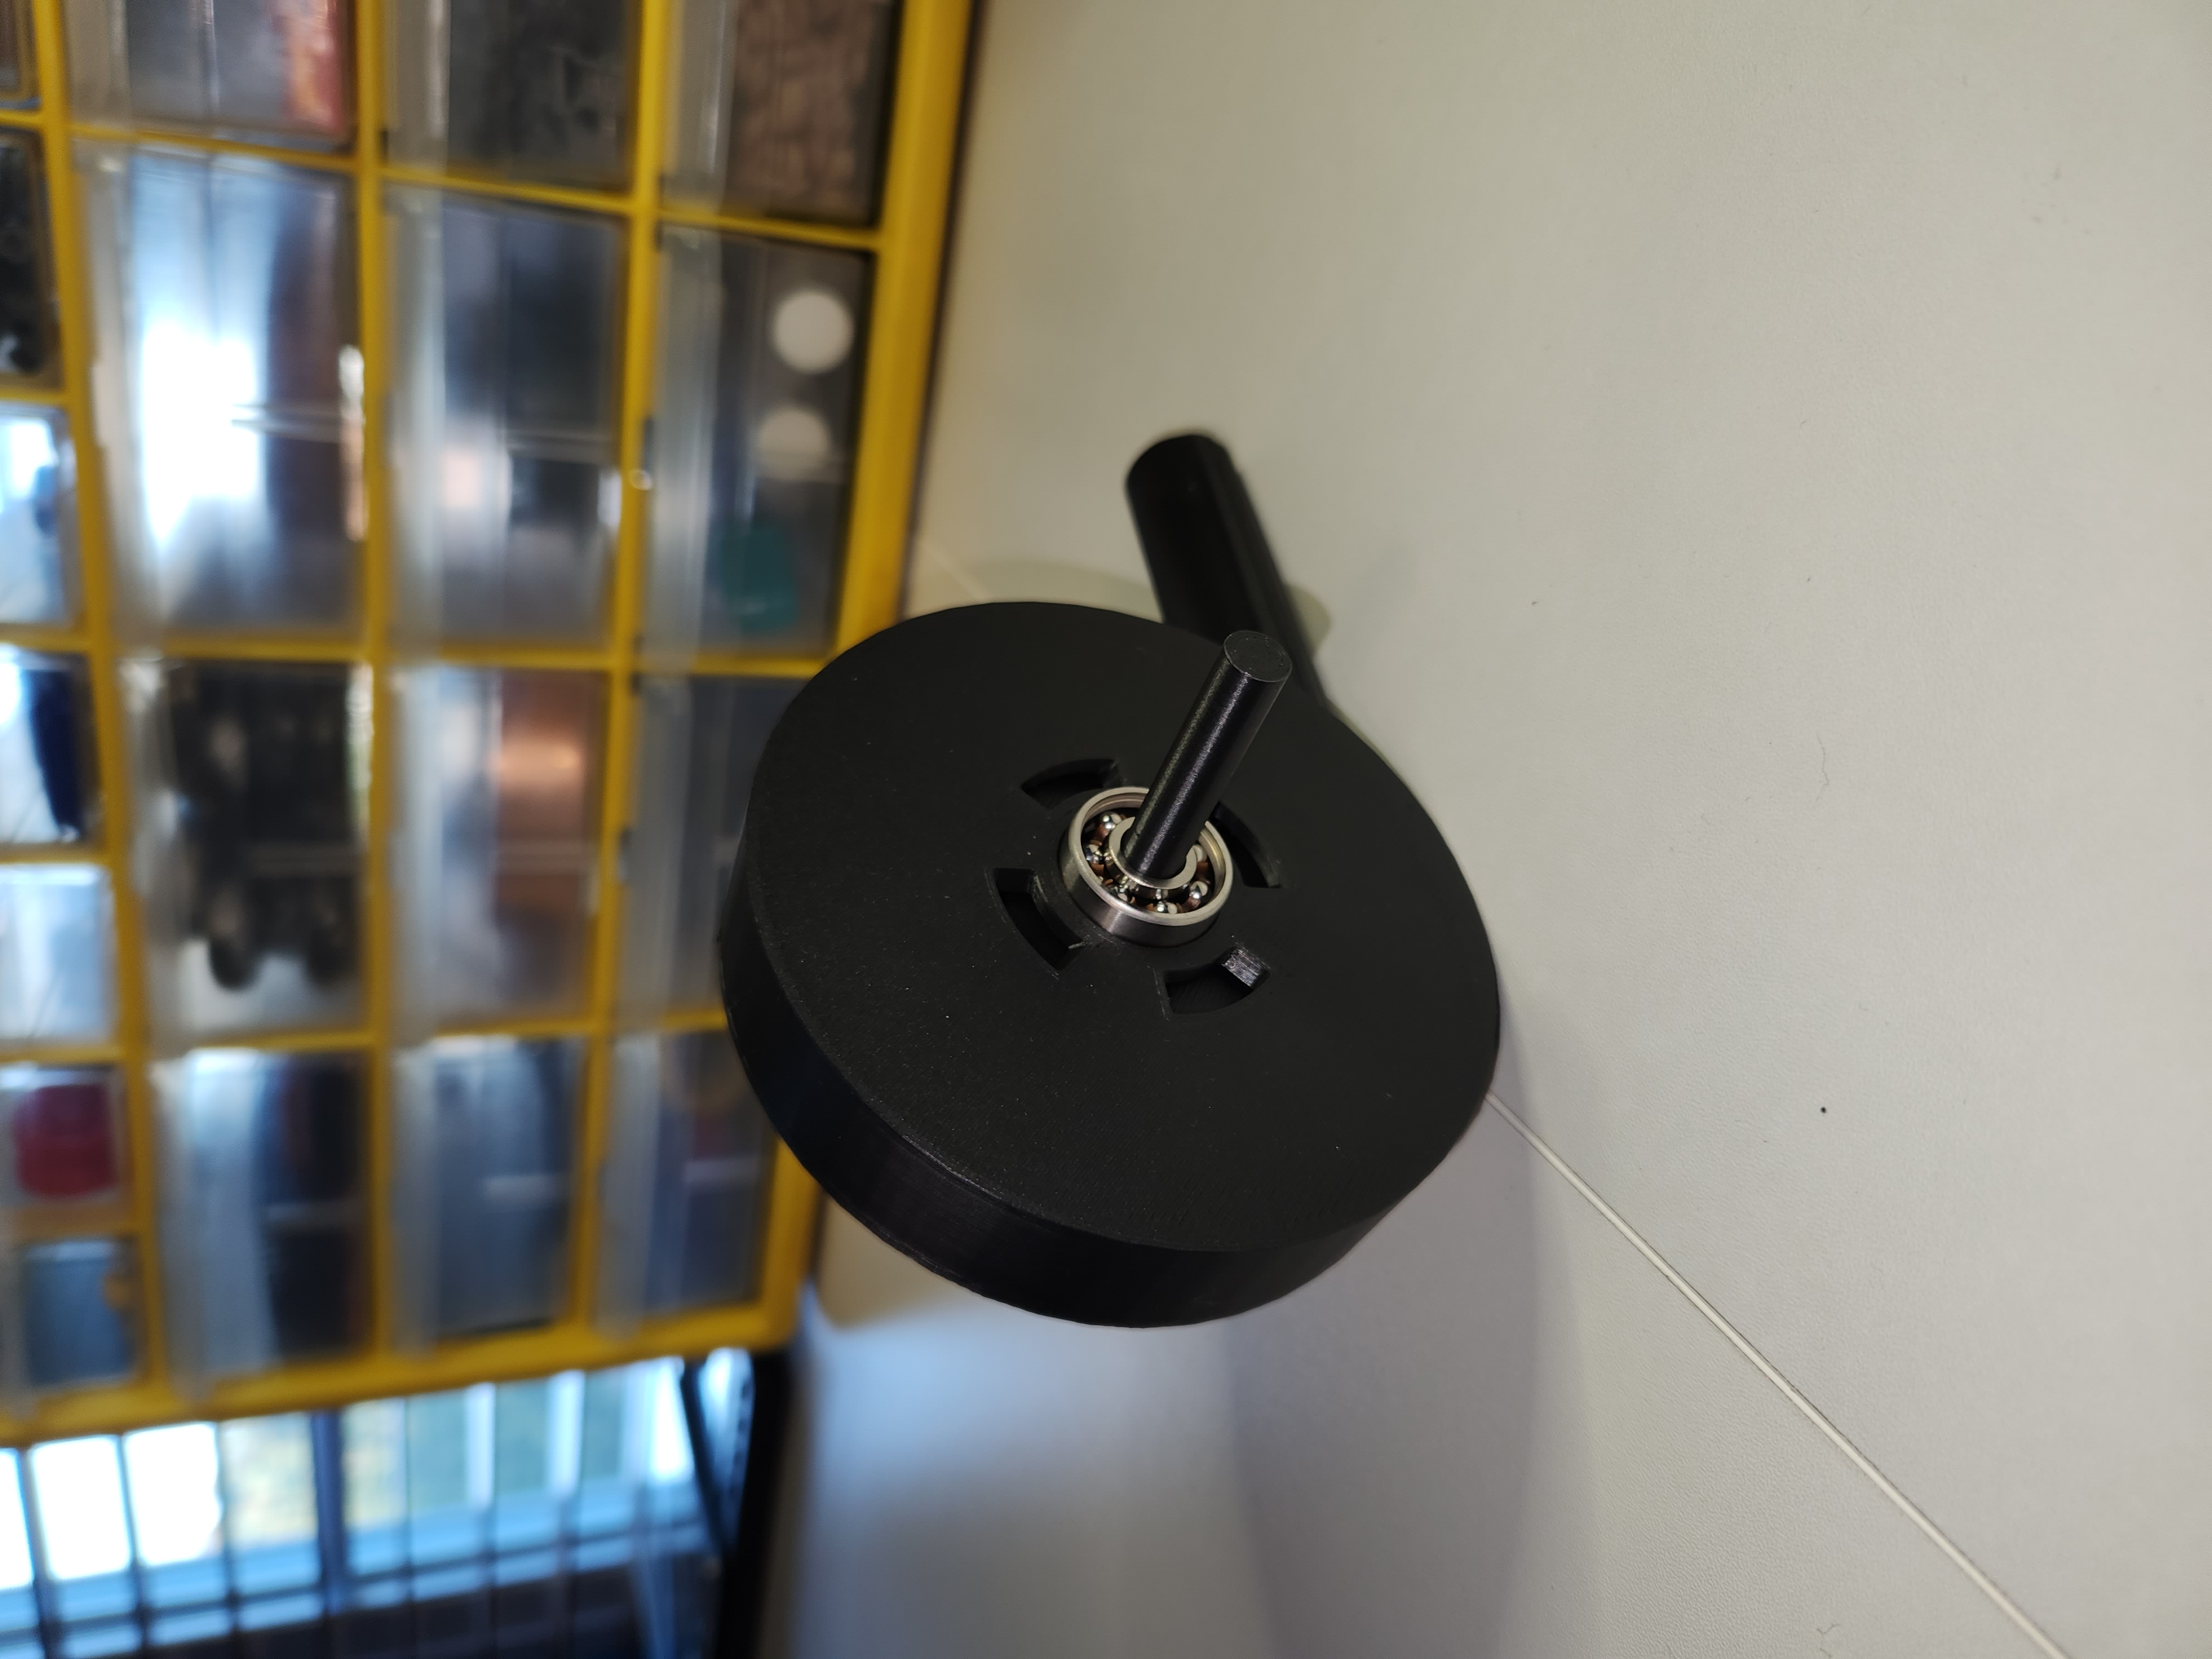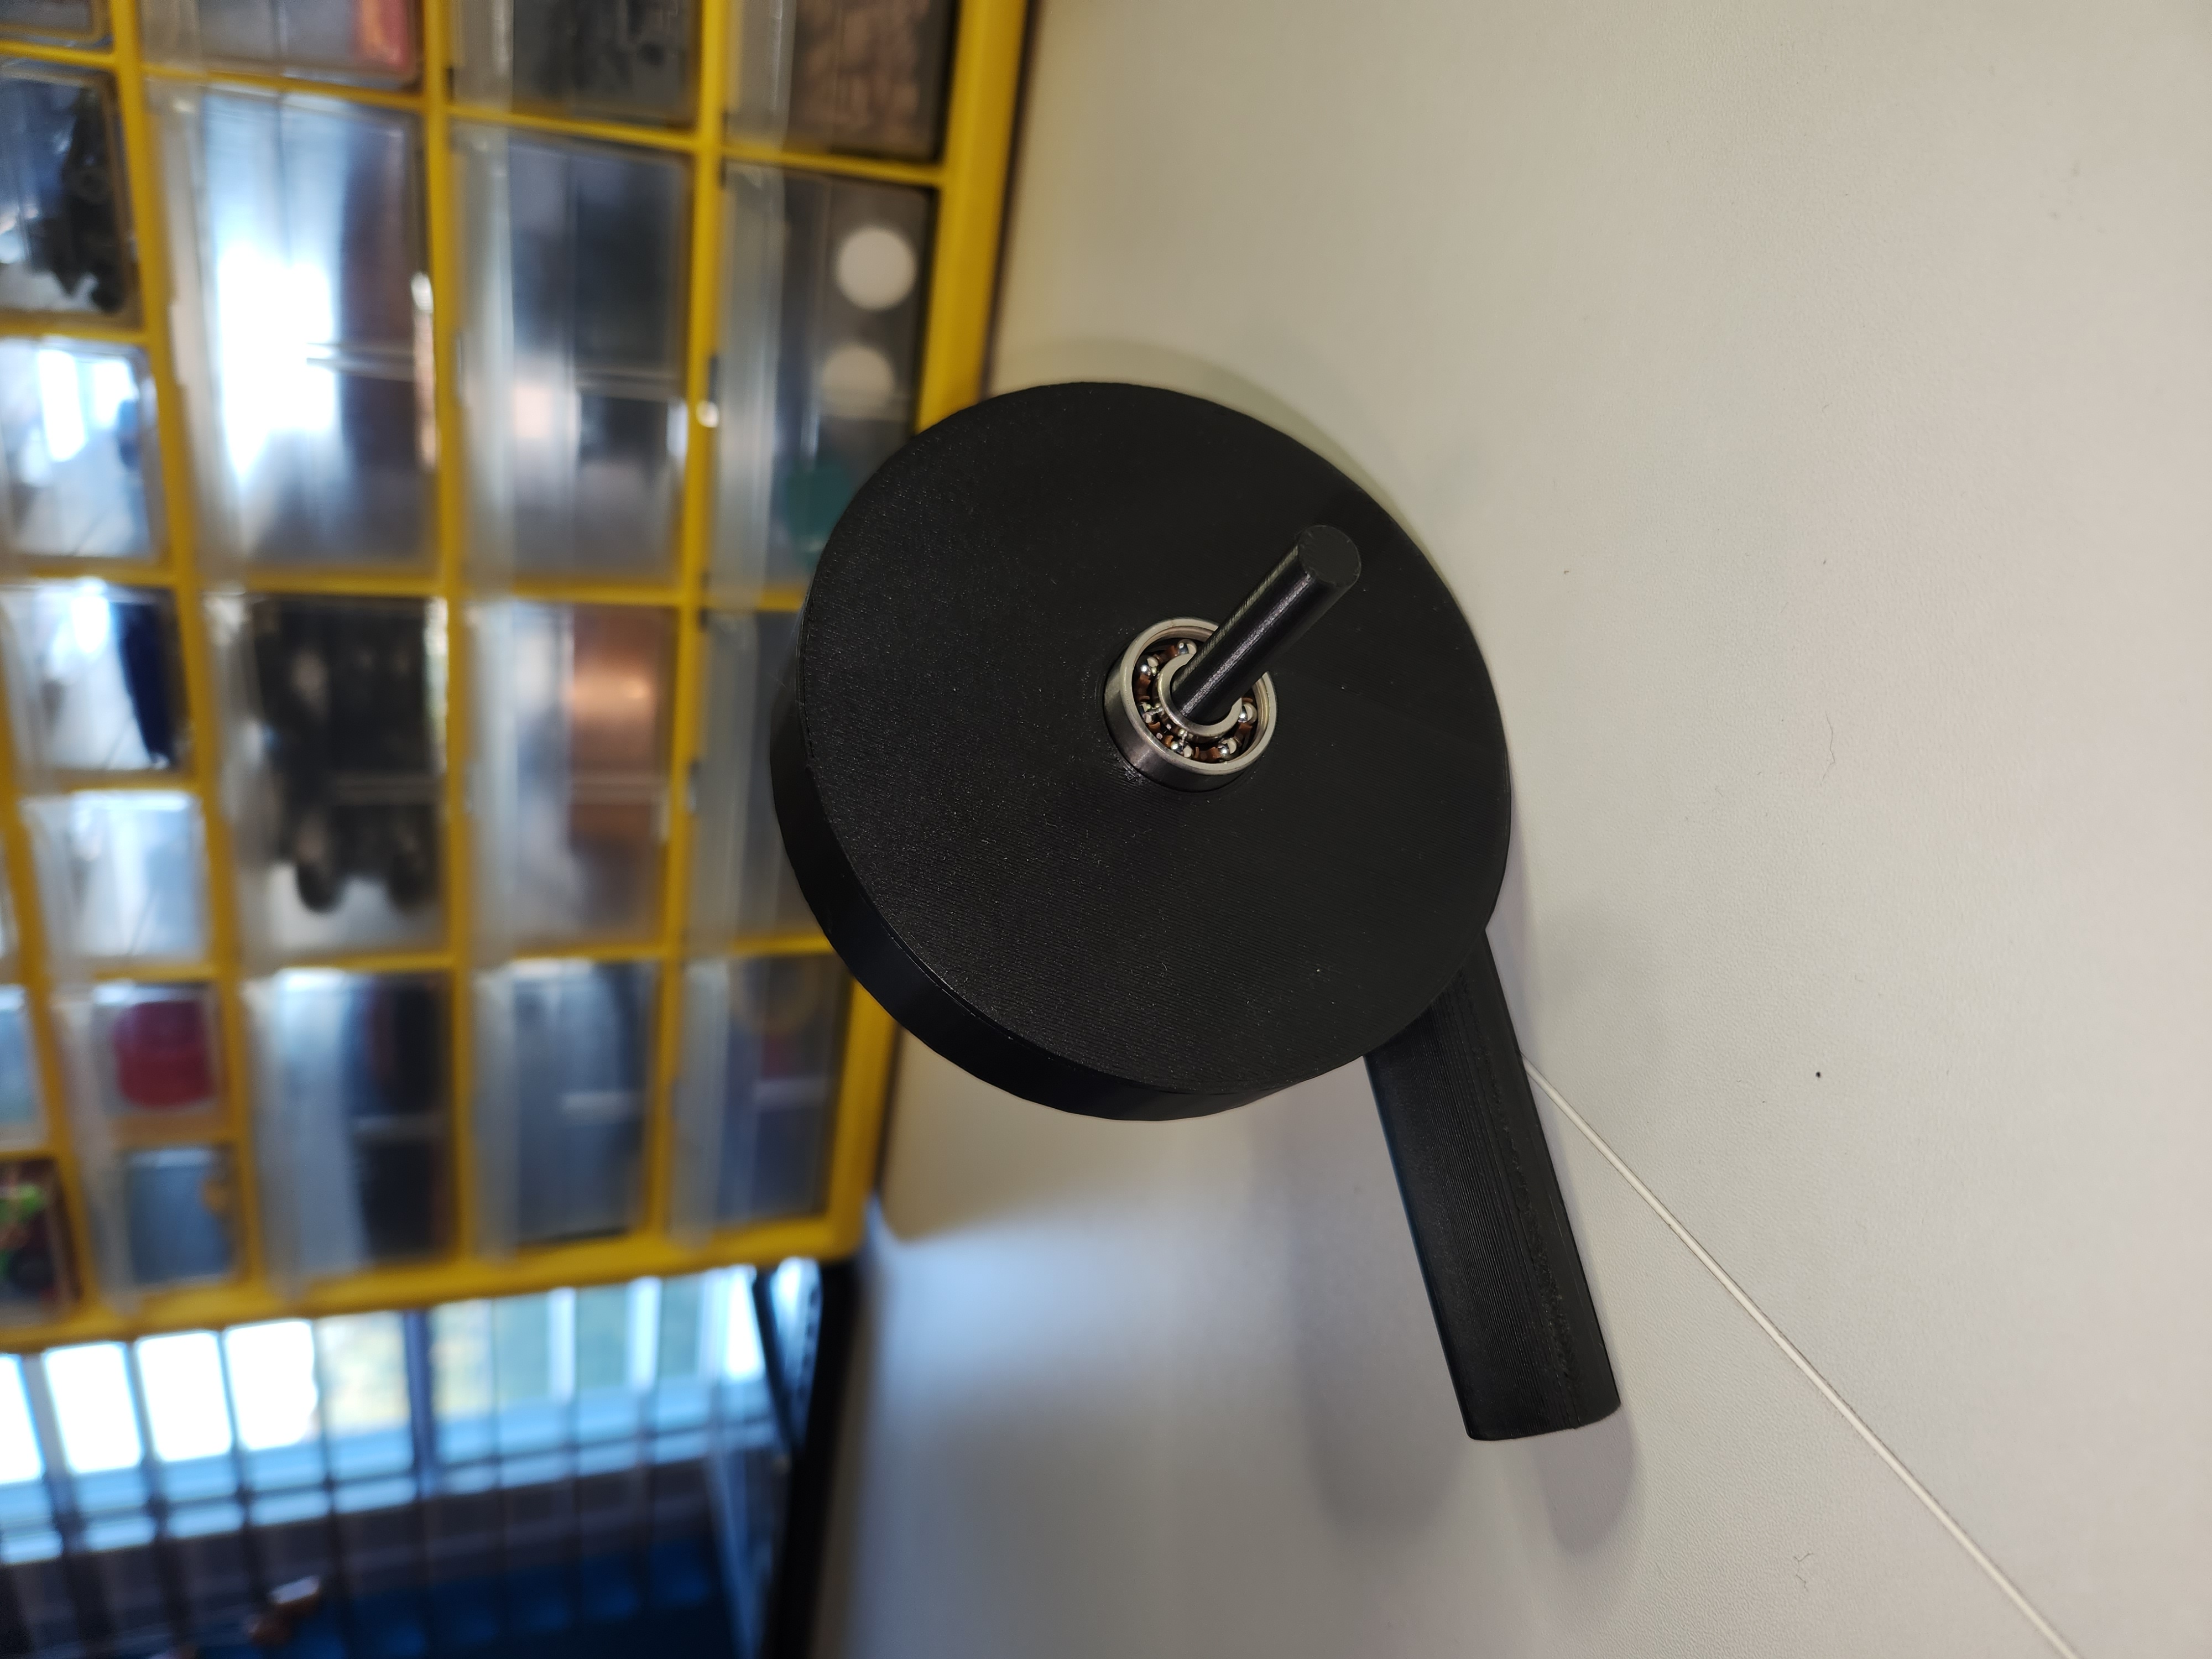
SYSTEM STATUS: ACTIVE PROTOTYPING & ENGINEERING

Mechanical Engineering
Built From The Ground Up

“I have been doing Mechanical Engineering my whole life.”

I’m a student who loves building, solving complex kinematic problems, and creating physical and virtual mechanisms that make life easier. My passion for machines started with hands-on physical assemblies and has evolved across real-time physics engines, digital twin simulations, CAD design in Fusion 360, and precision additive manufacturing.

70+ Piston Engines
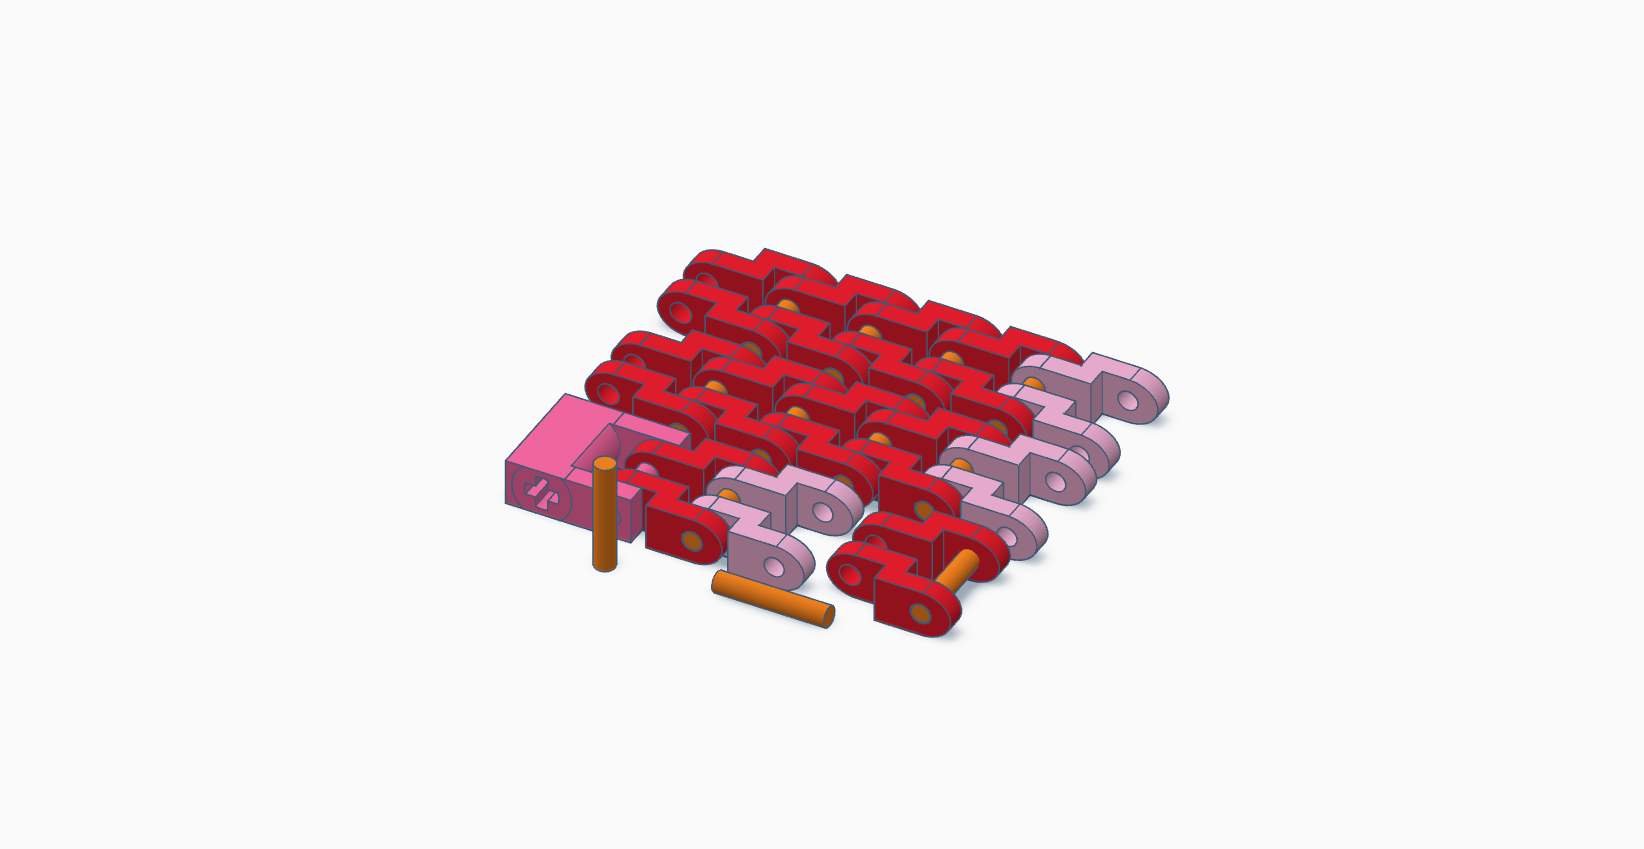
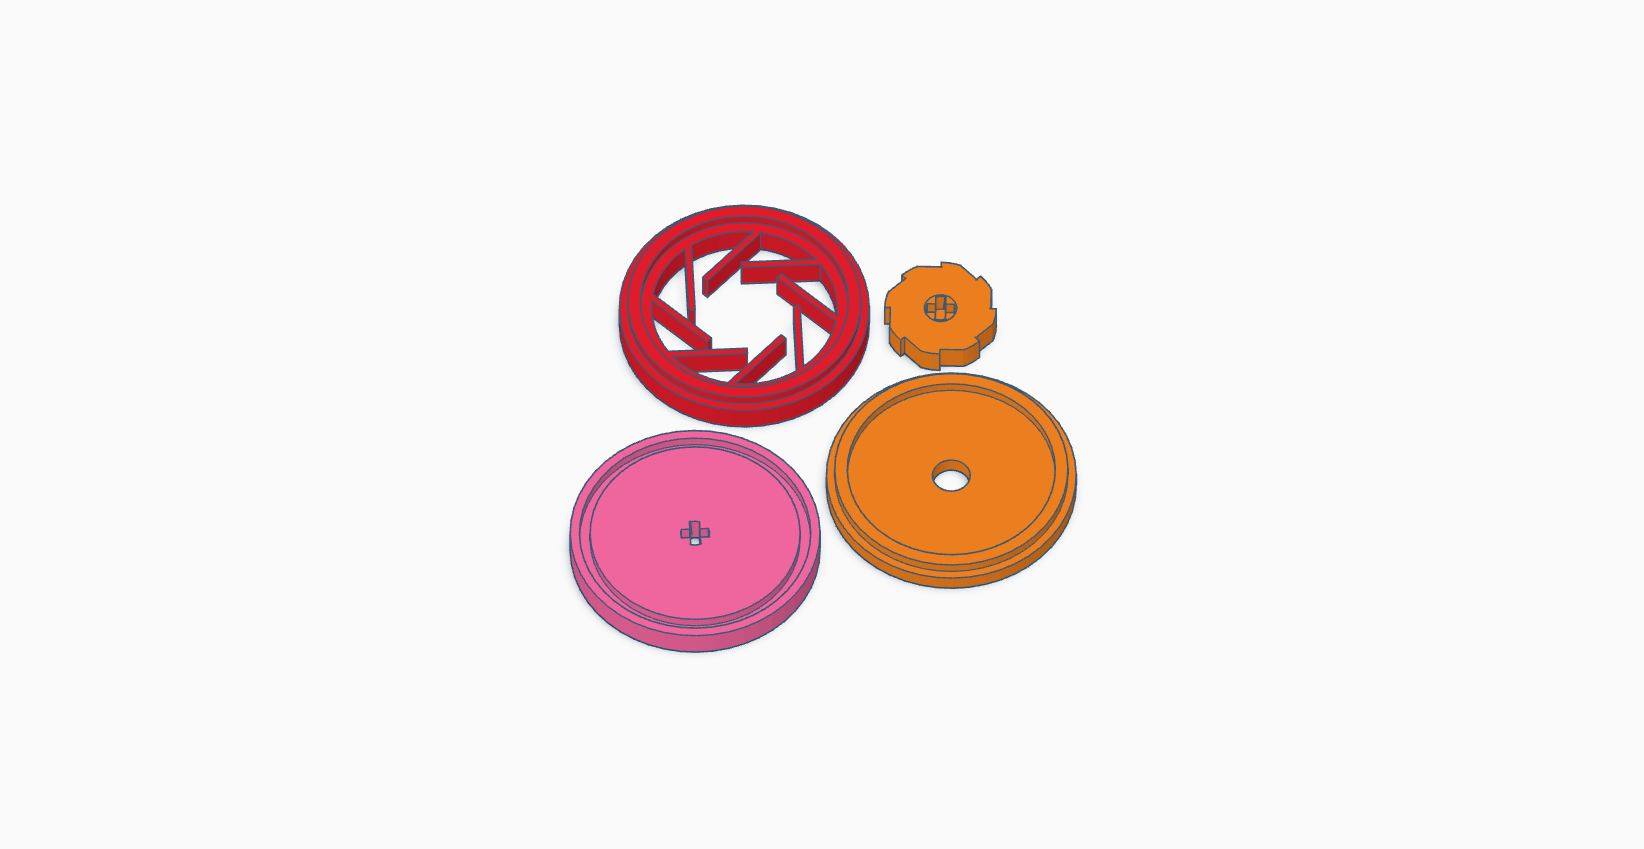
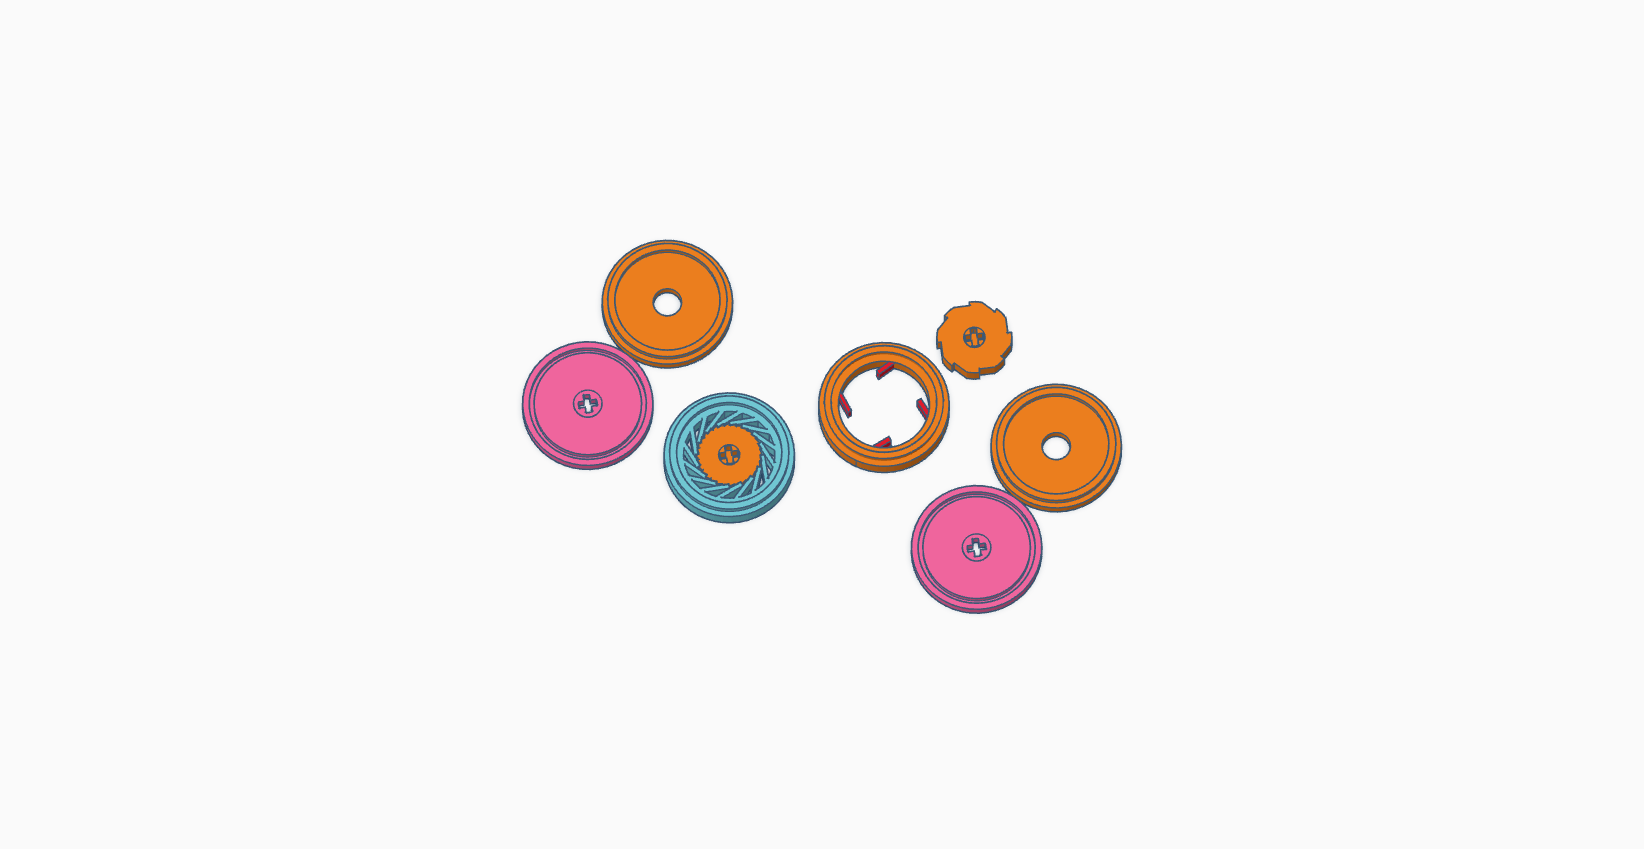
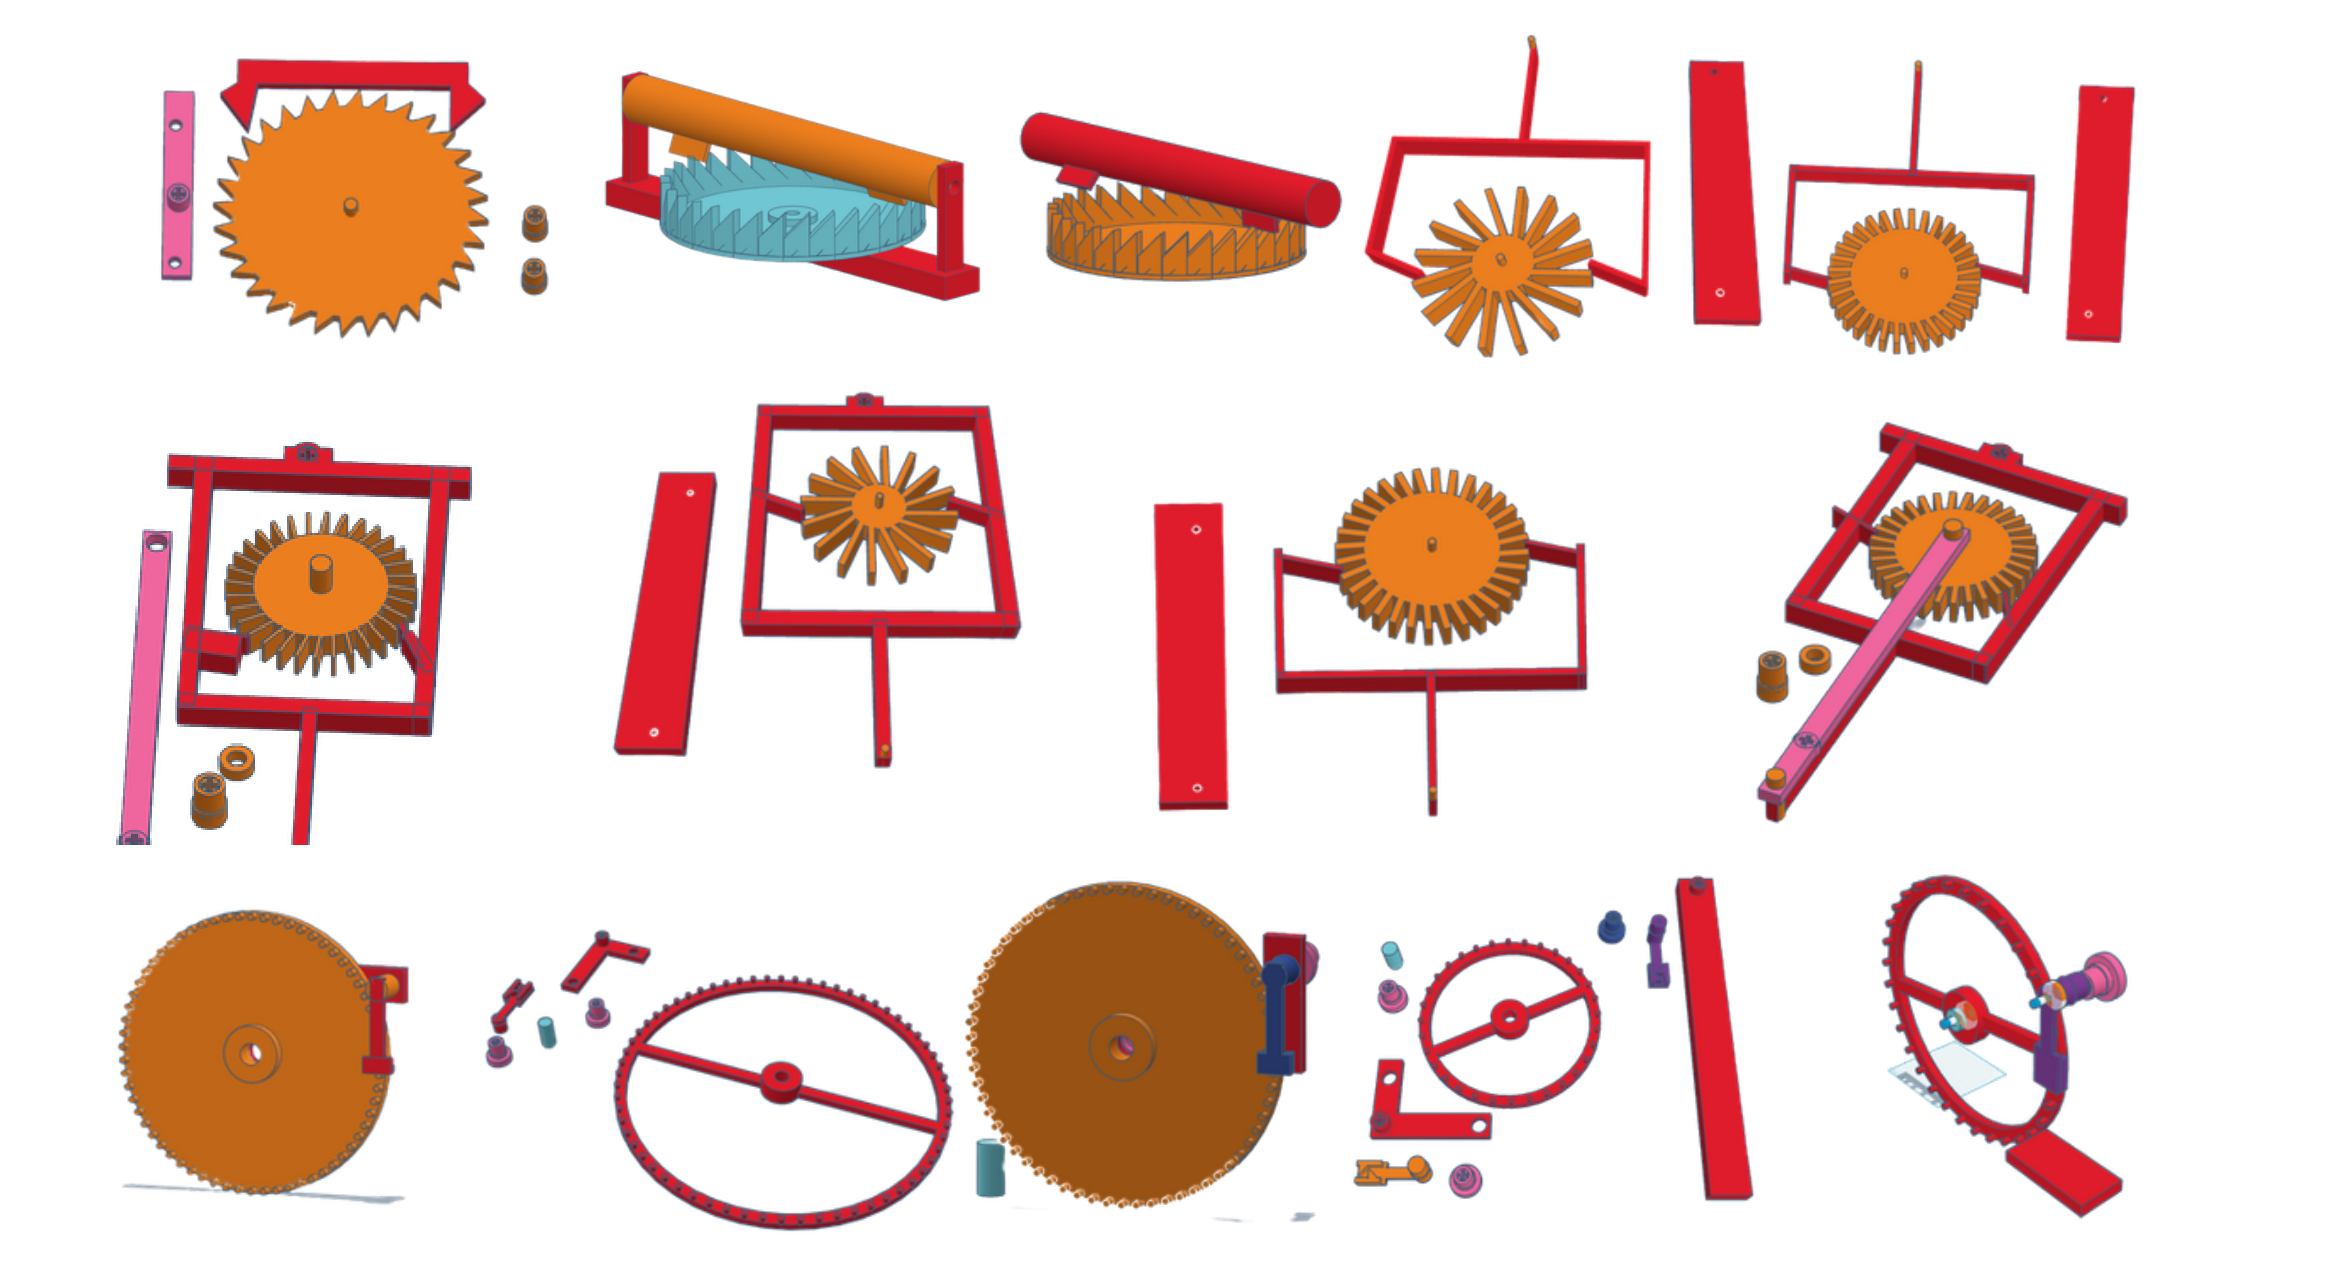
14+ Escapement CADs
6-Axis Mechatronics
15 Engineered Systems
Aiden Hockinberry - Mechanical Engineering
Aiden Hockinberry
Mechanical Engineer & Systems Builder

Functional Machines, Kinematics & Digital Twins

15 functional machines, robotic systems, fluid turbomachinery, and digital twin simulations—engineered, prototyped, and validated from first principles.

Robotics & Mechatronics
Biomimetic Linkages Boolean Logic Gates Gait Timing Optimization Arduino-Style Sequencing
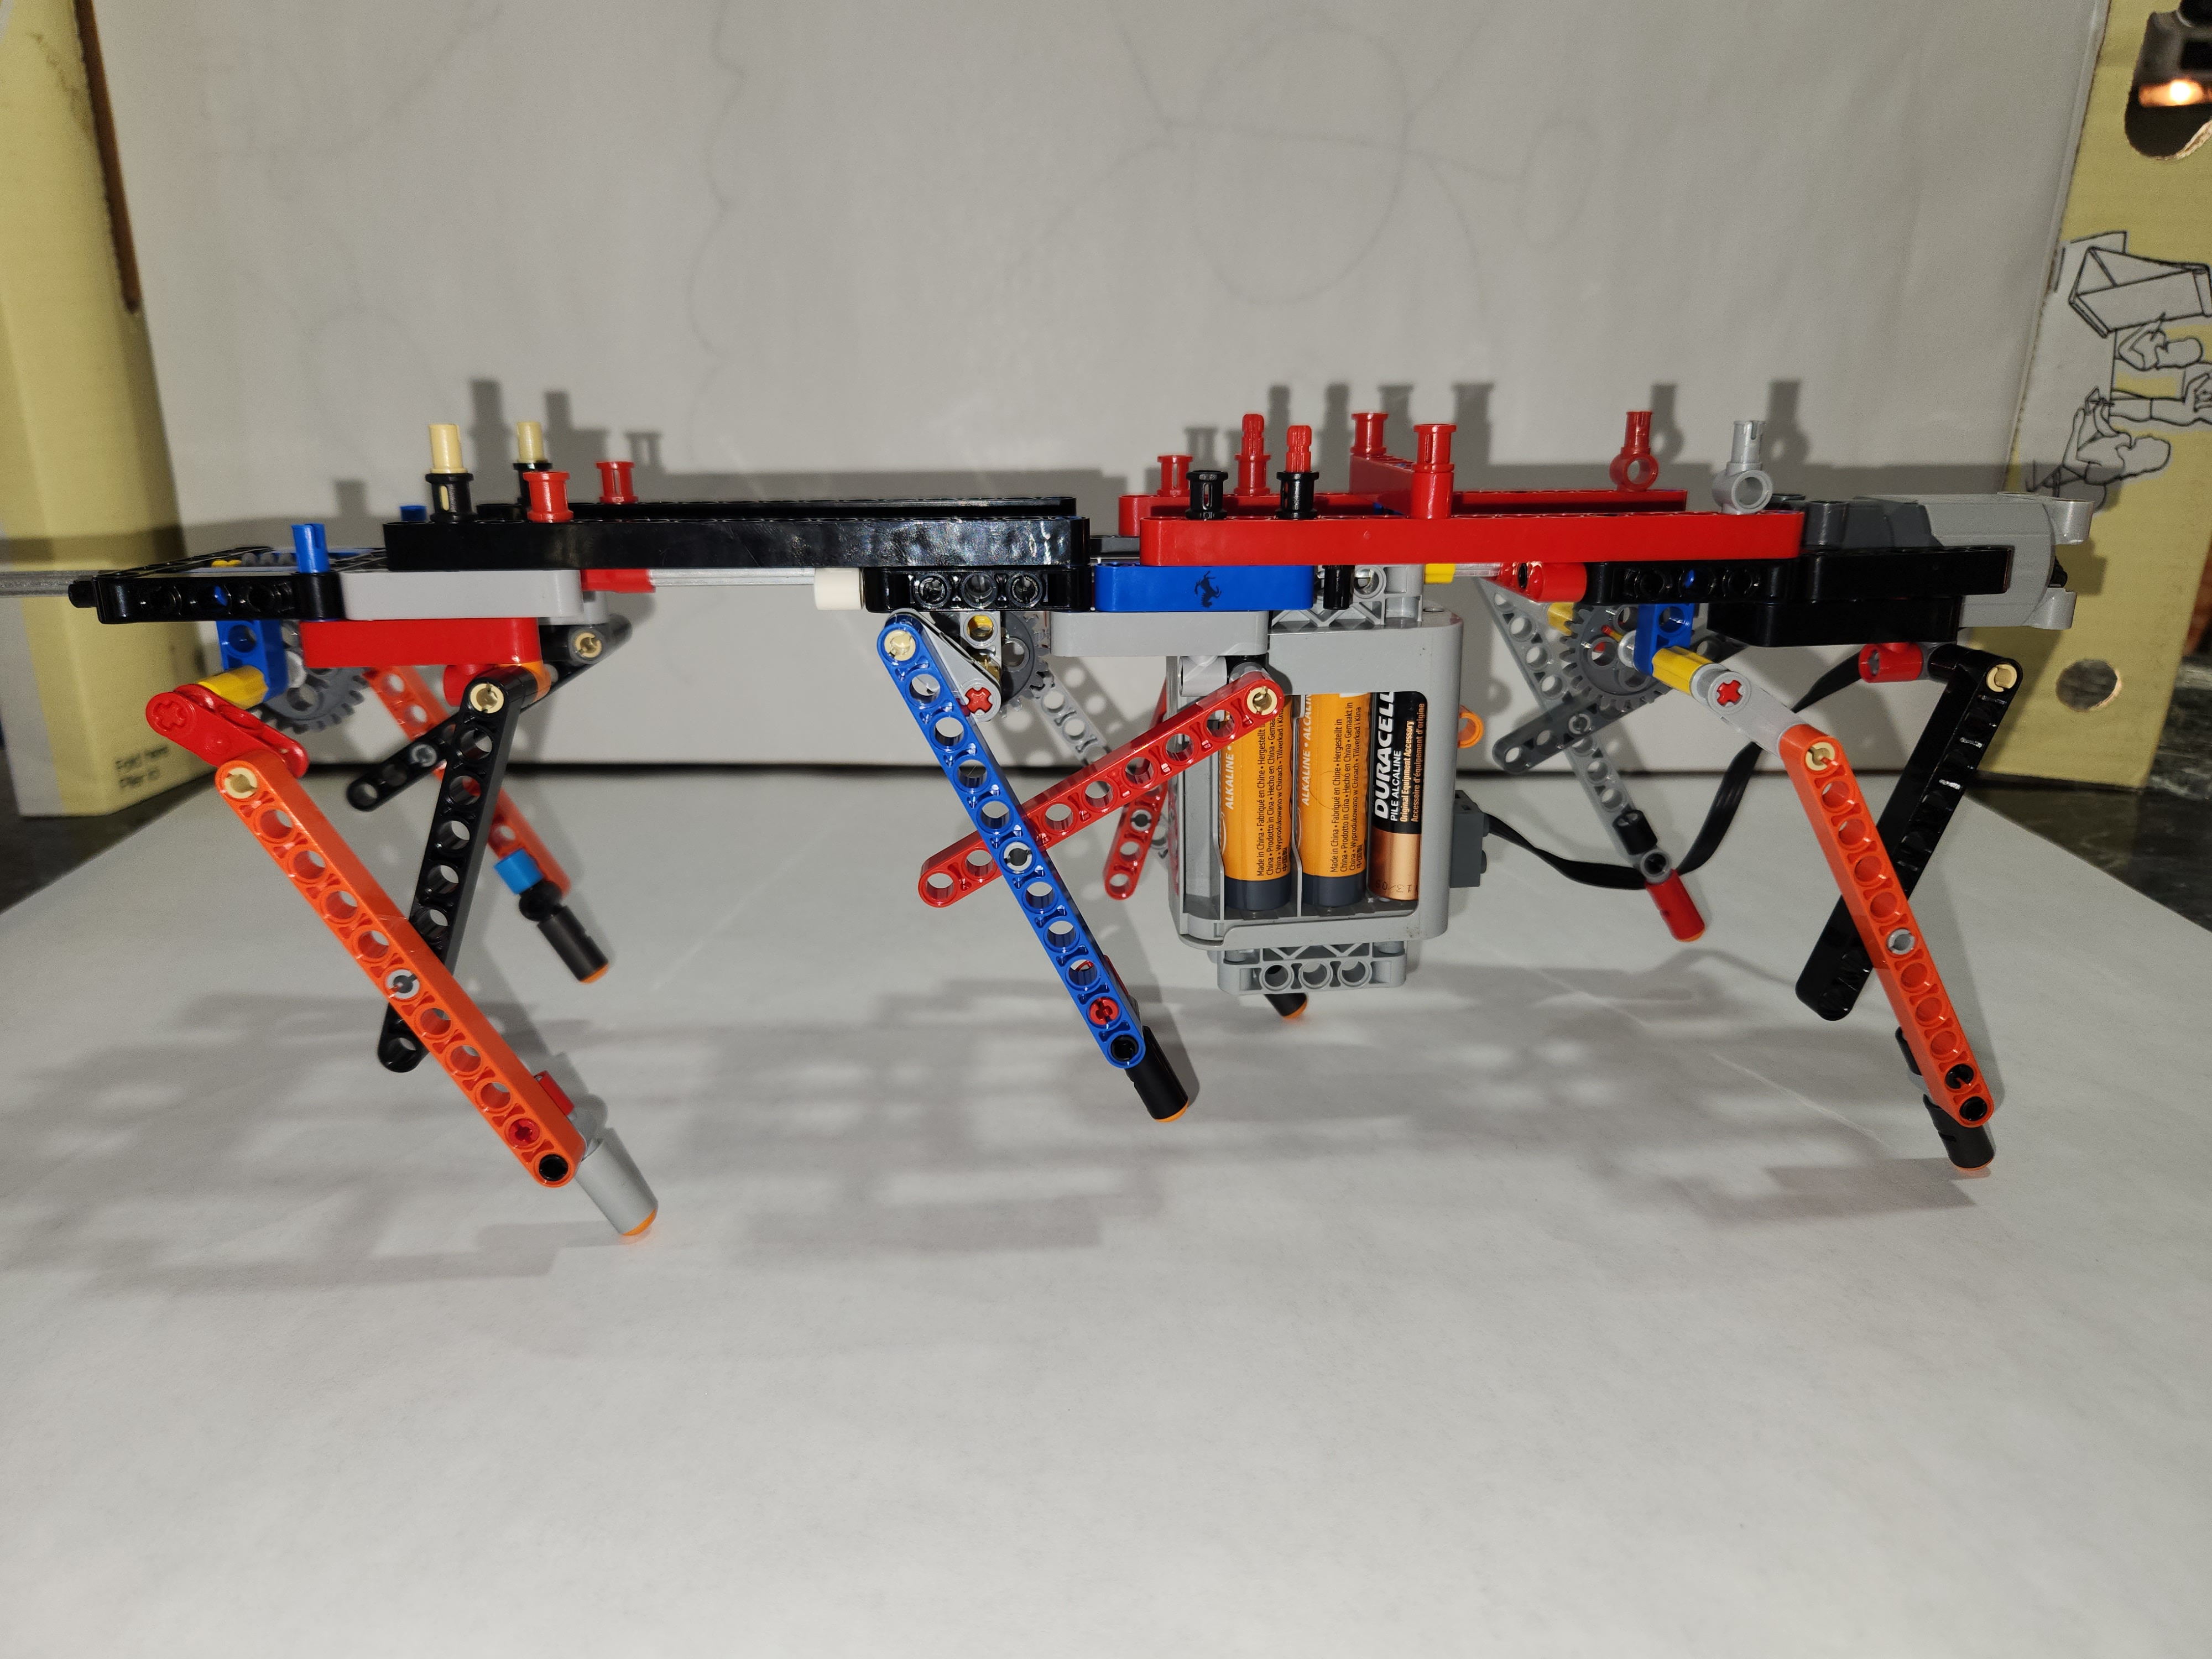
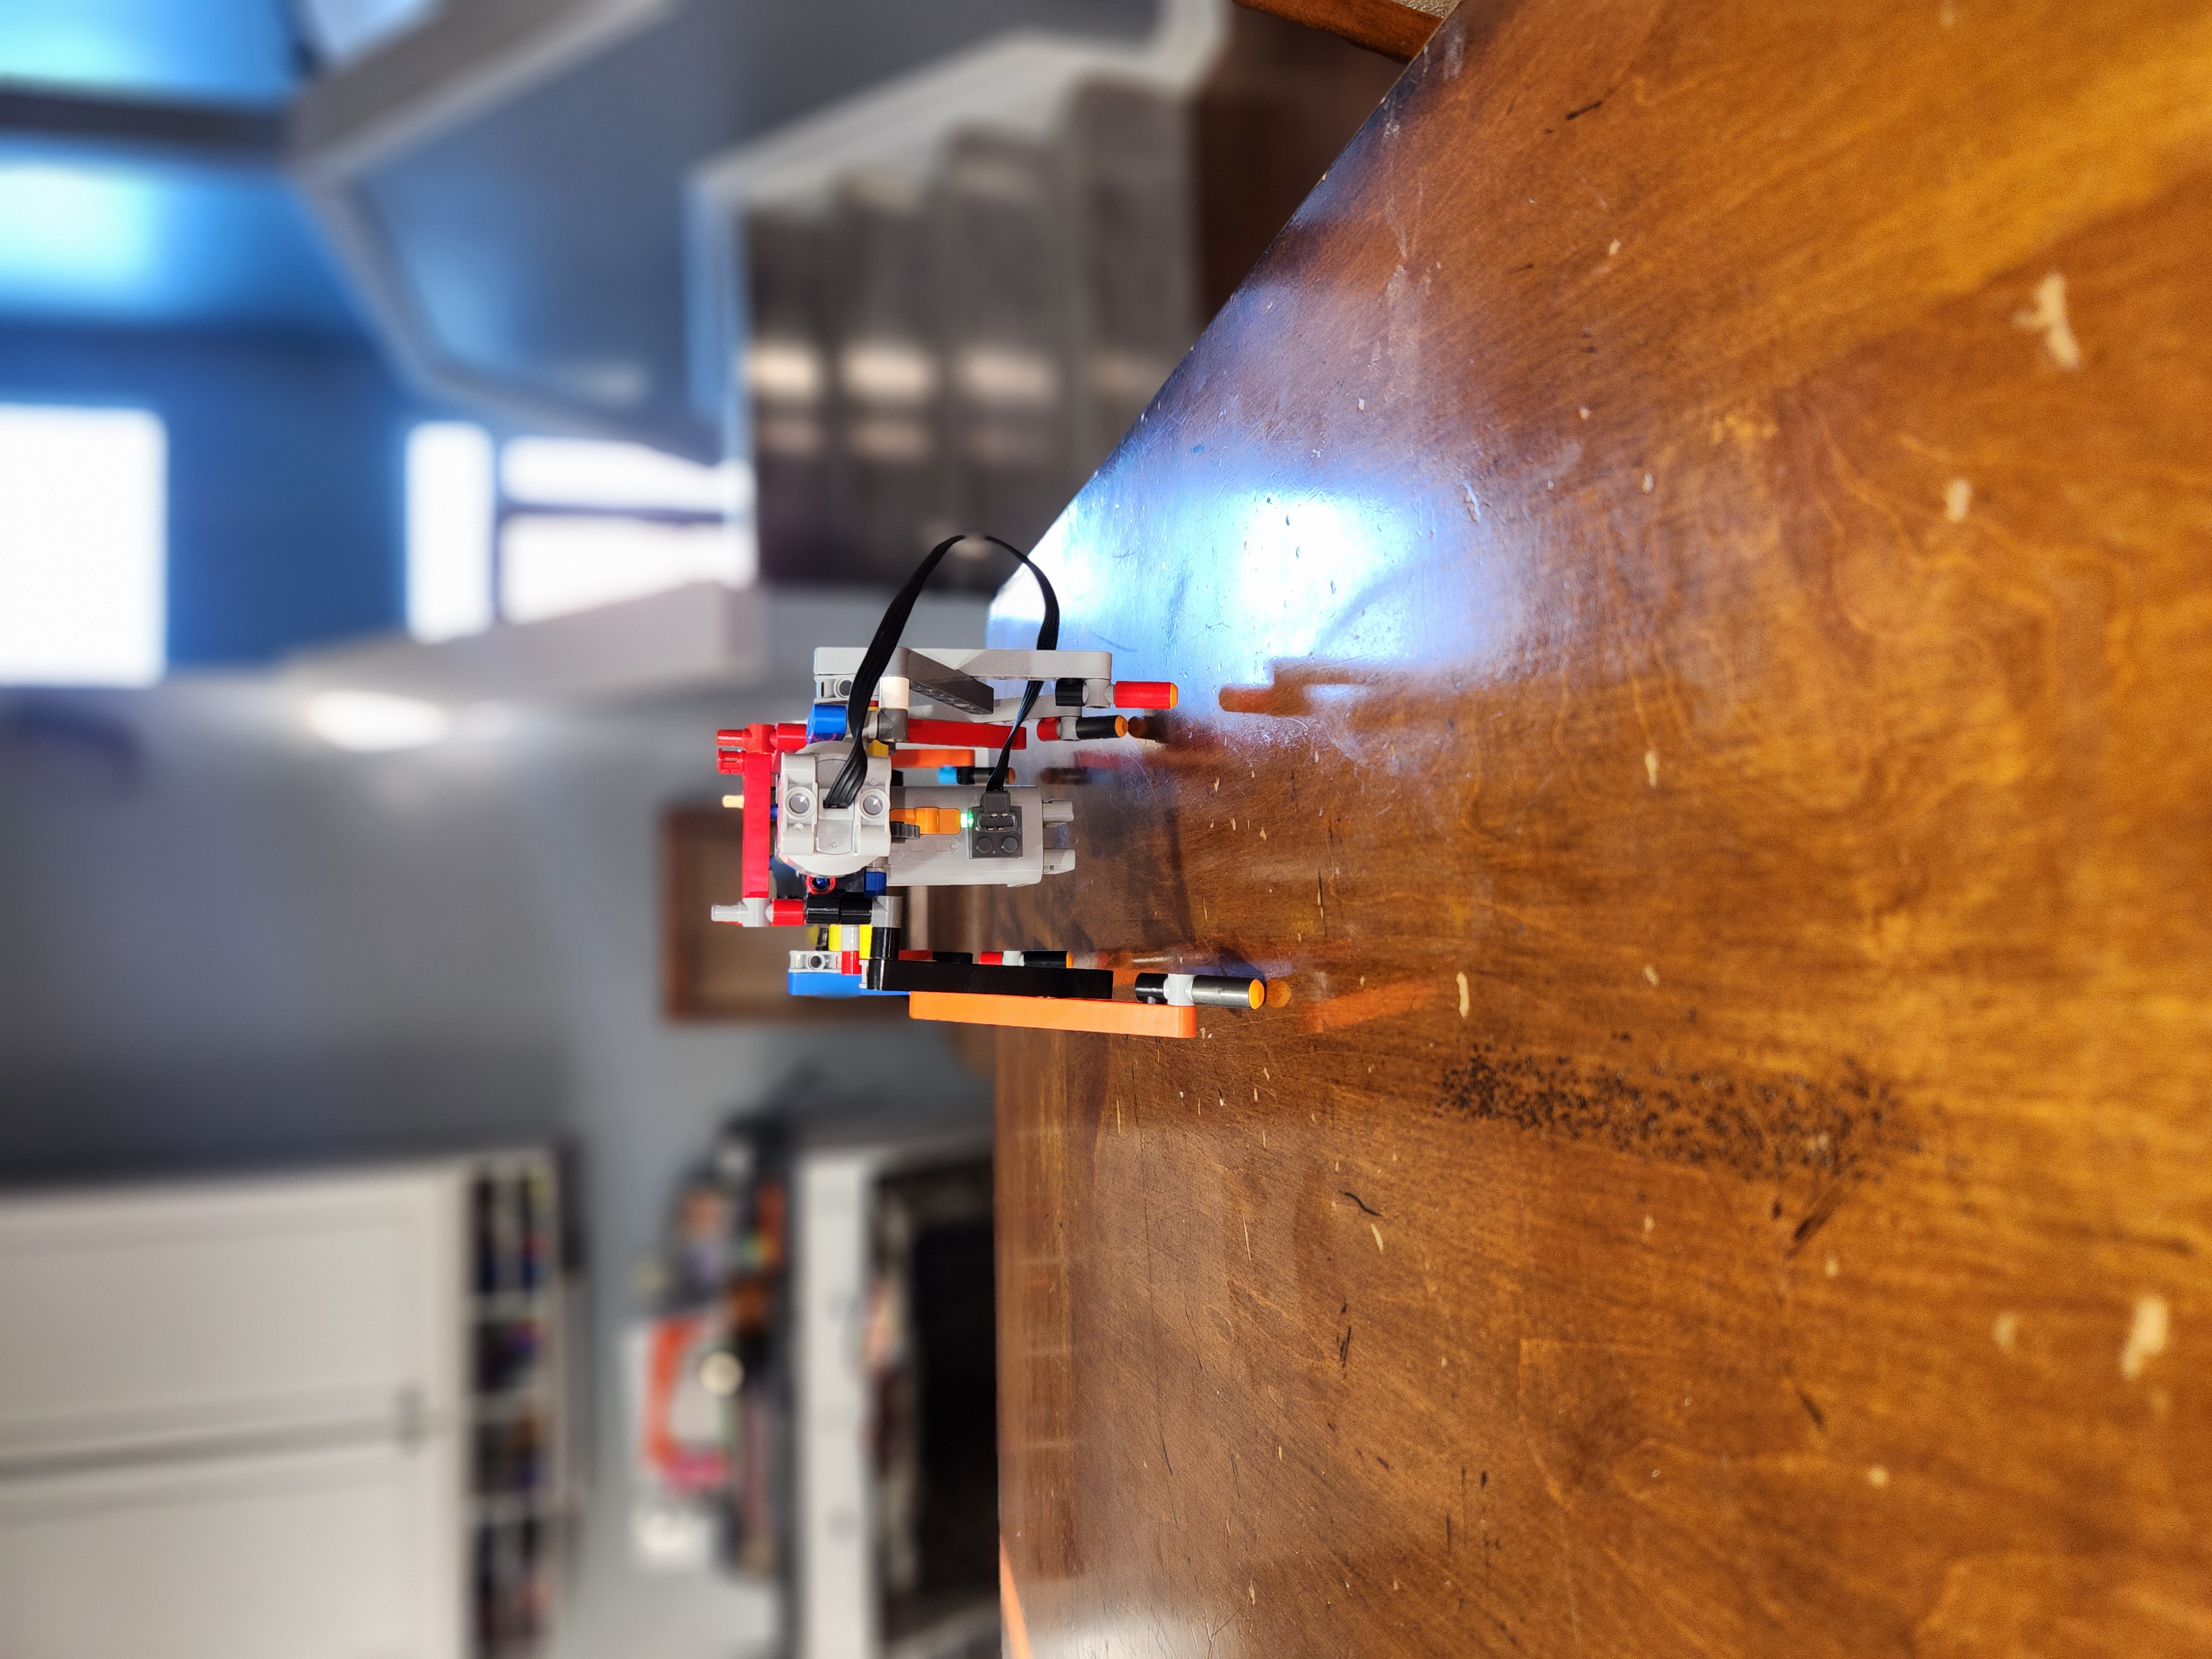
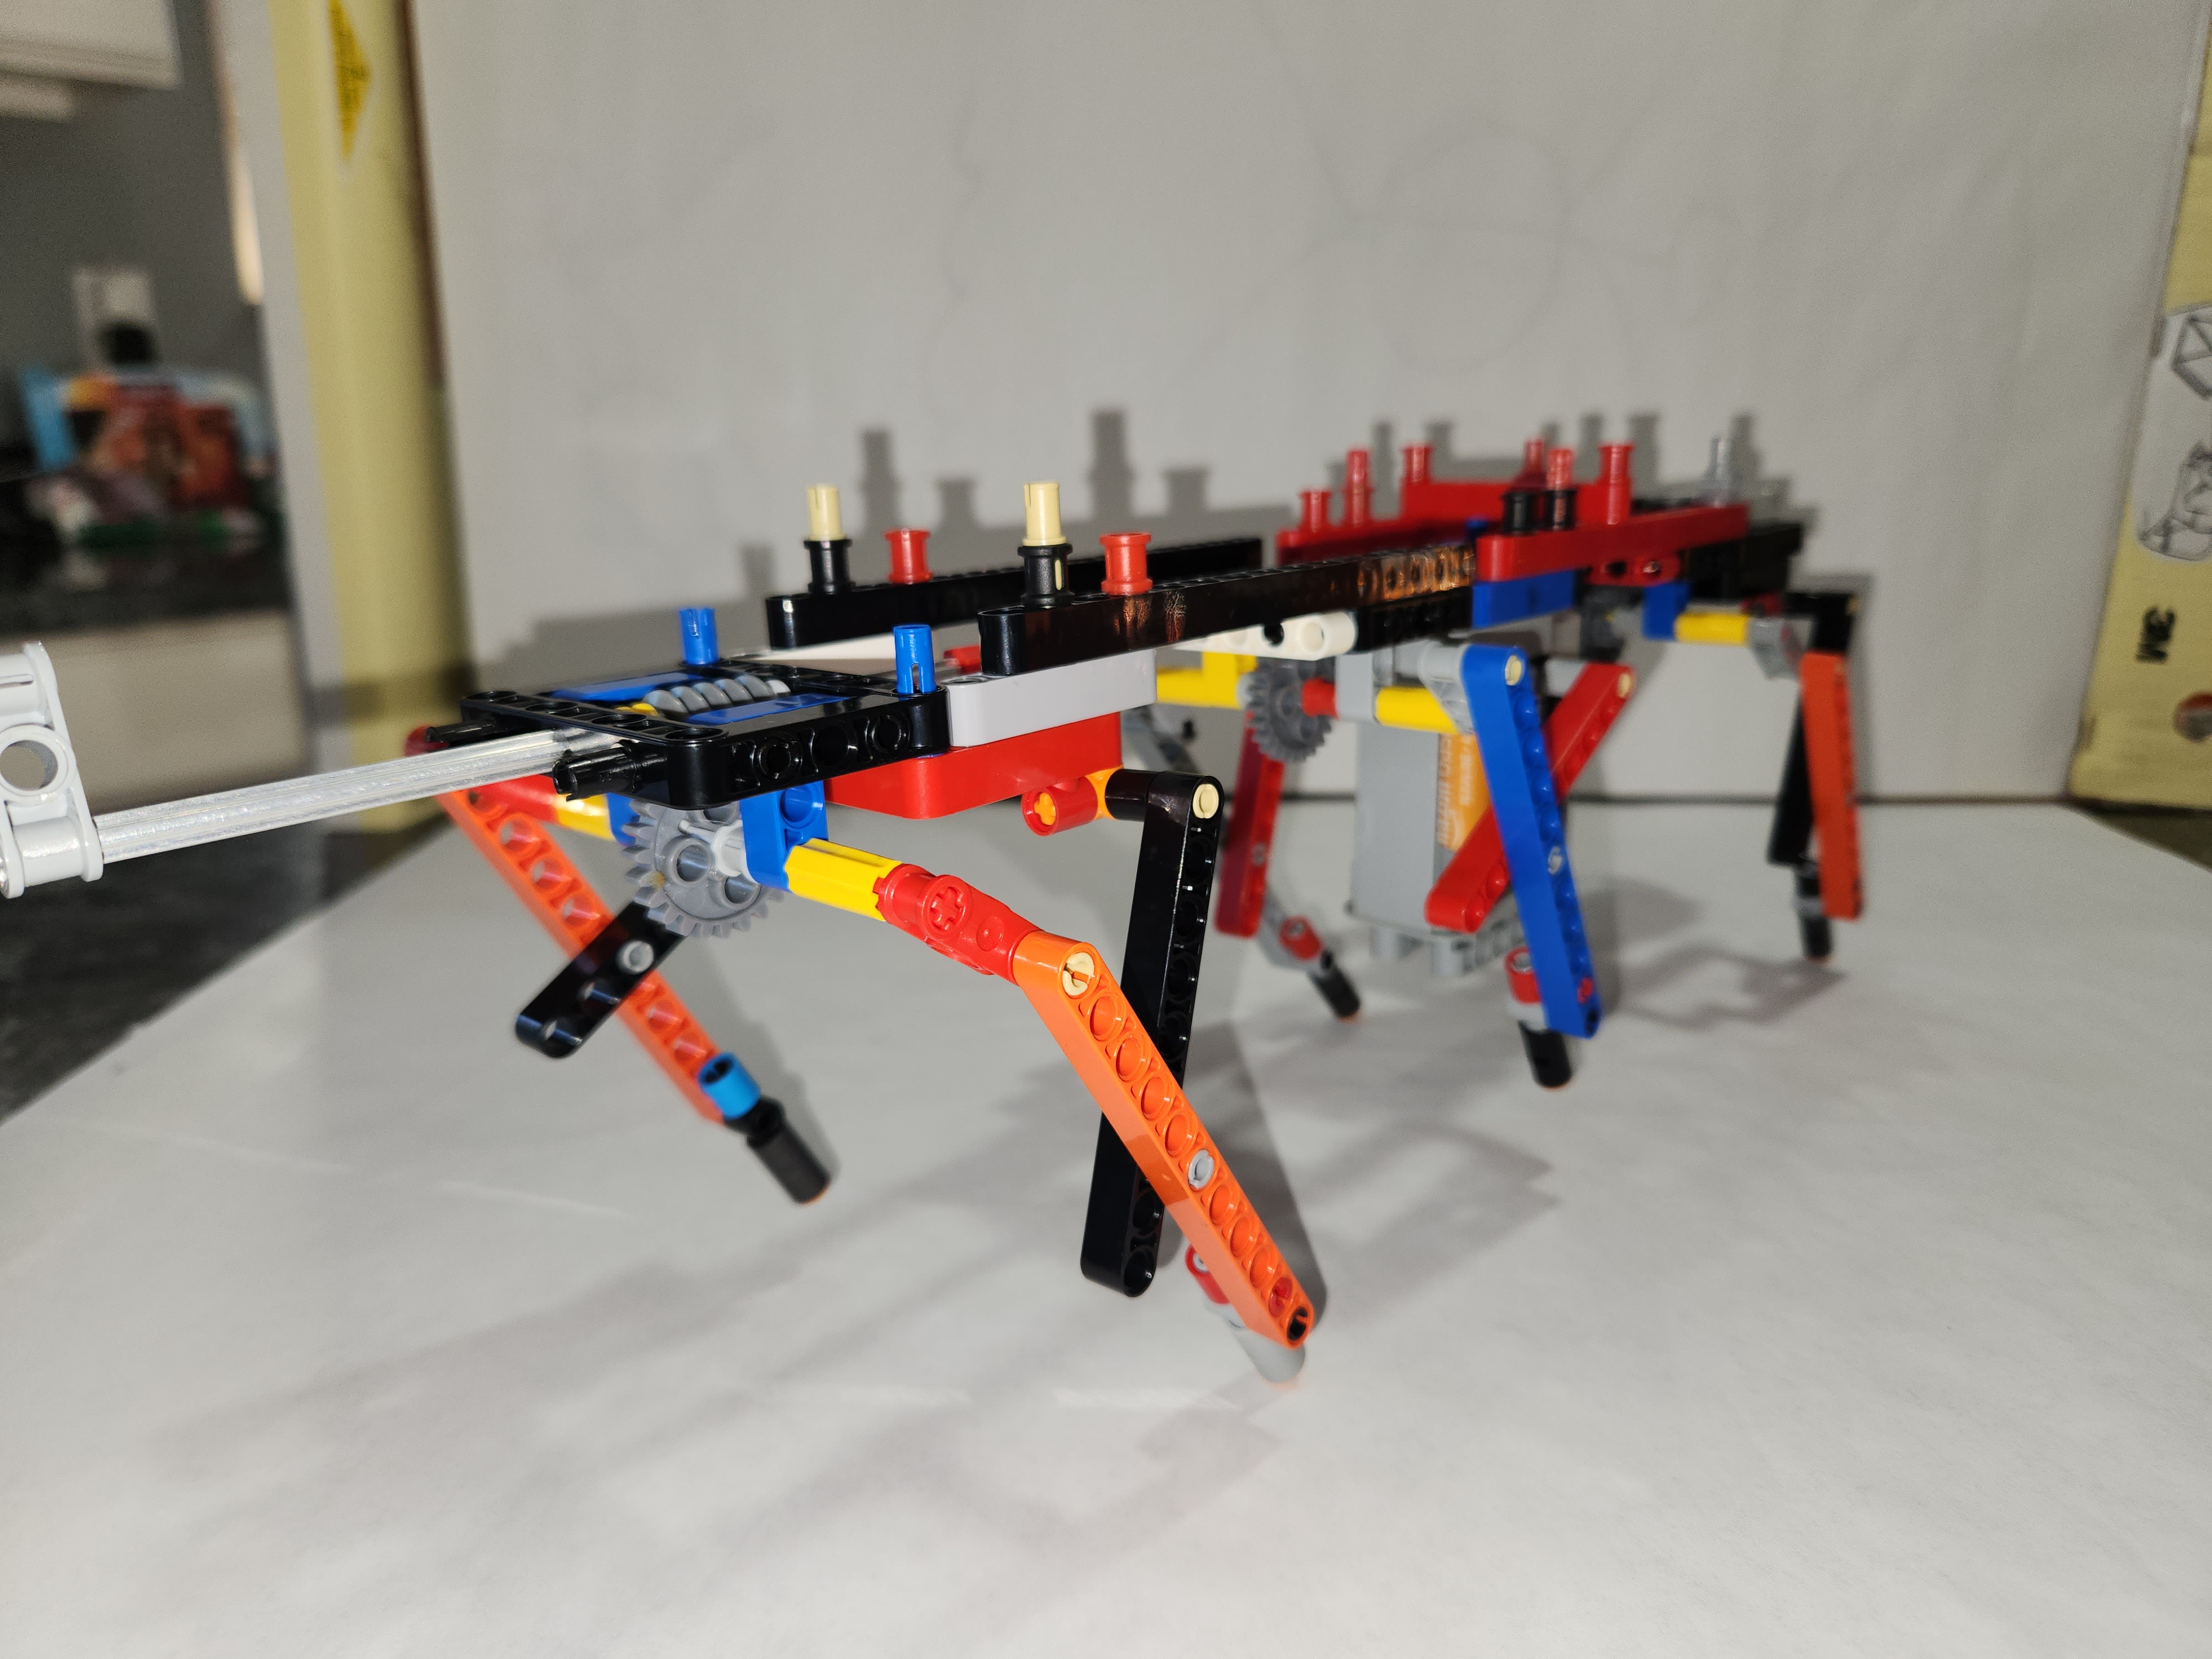
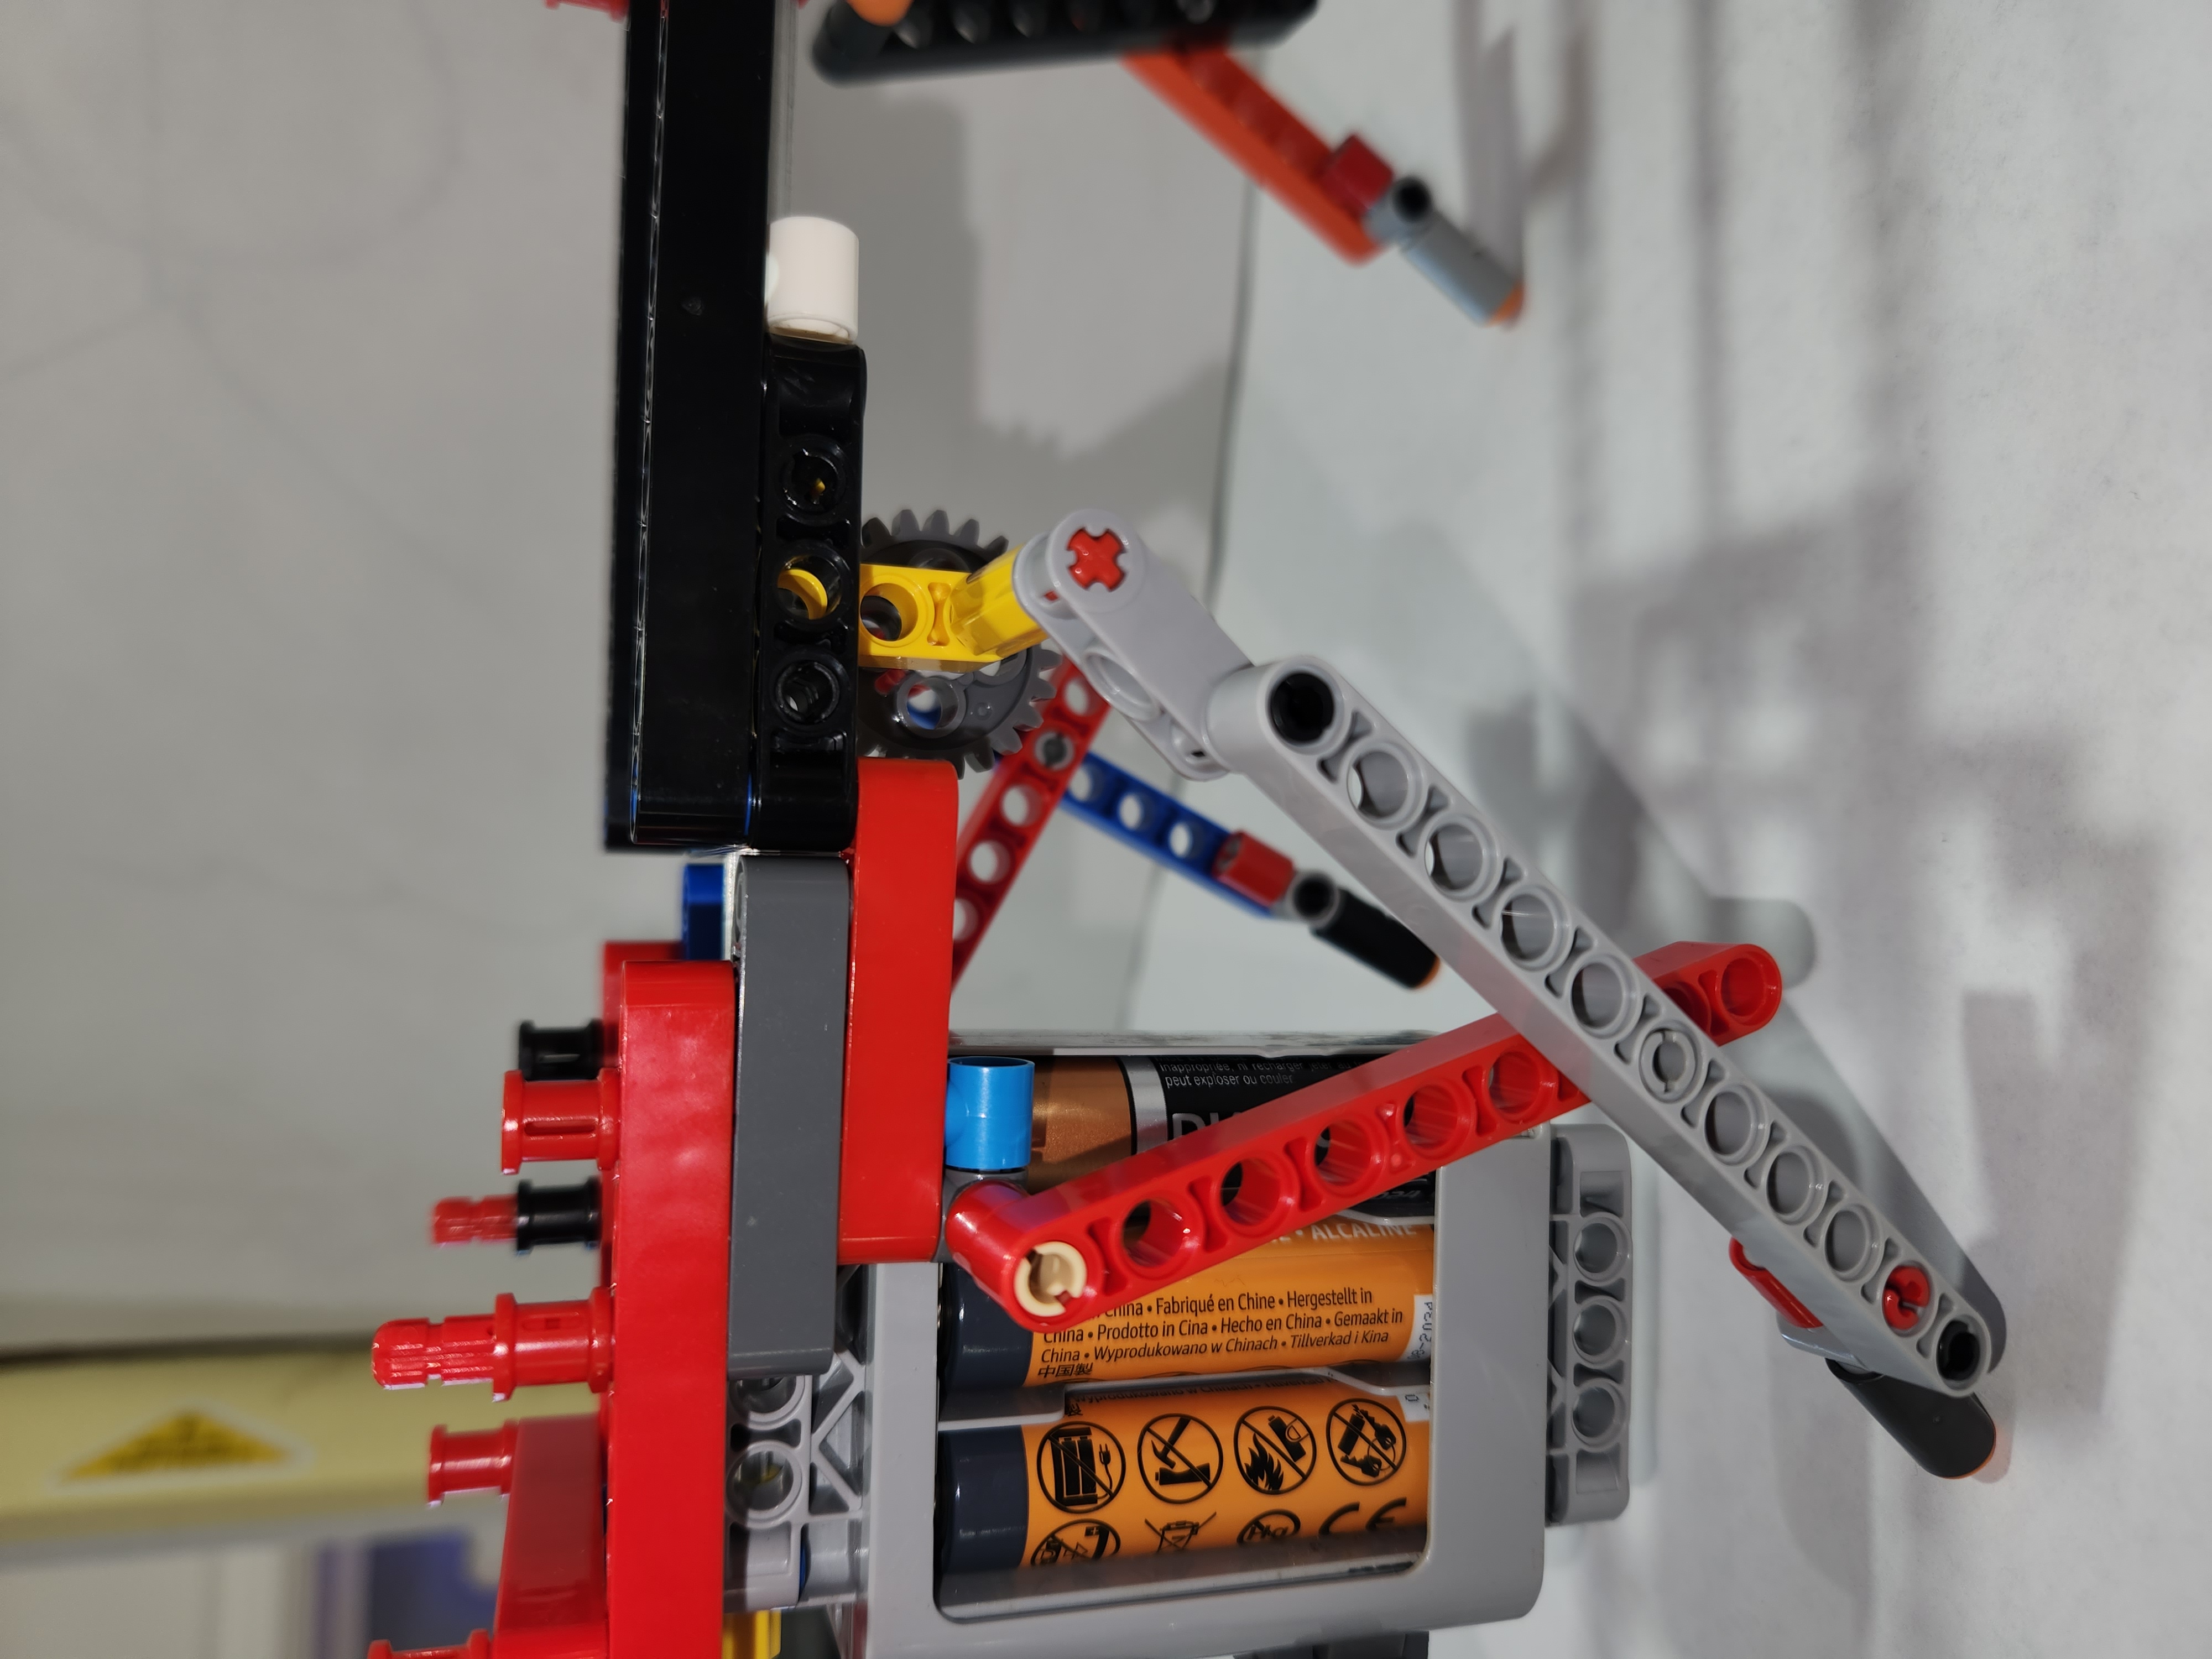
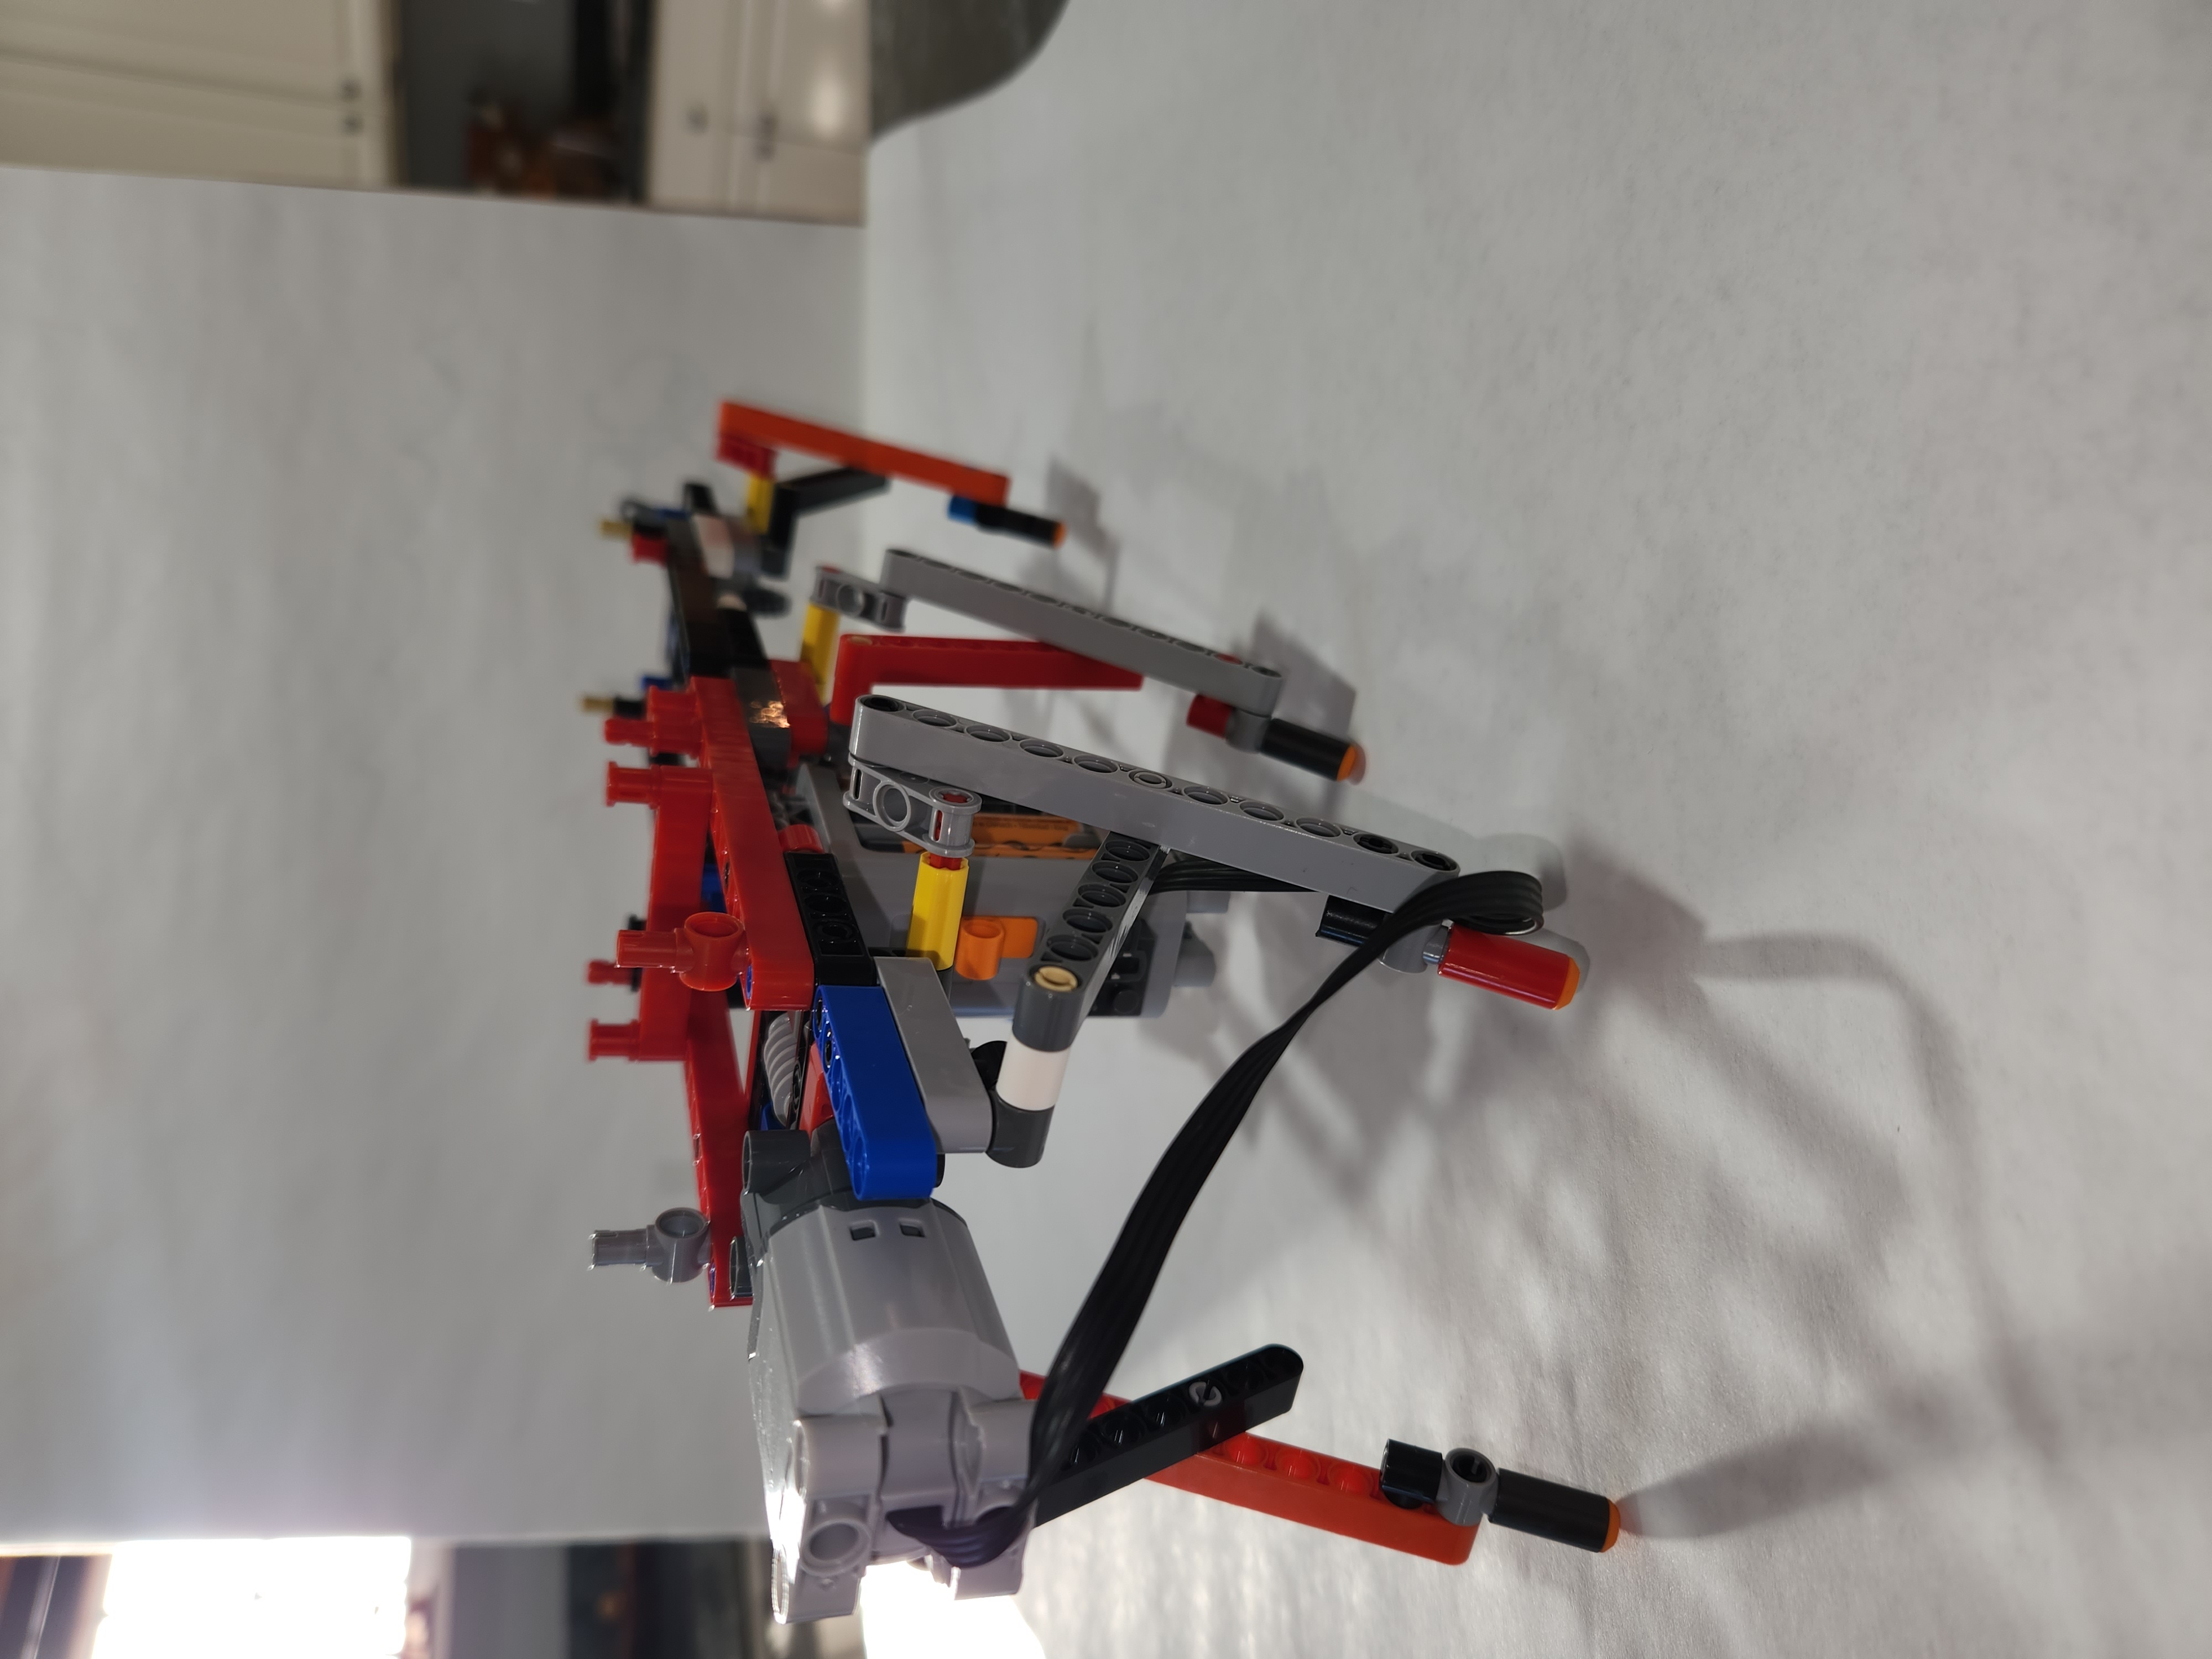
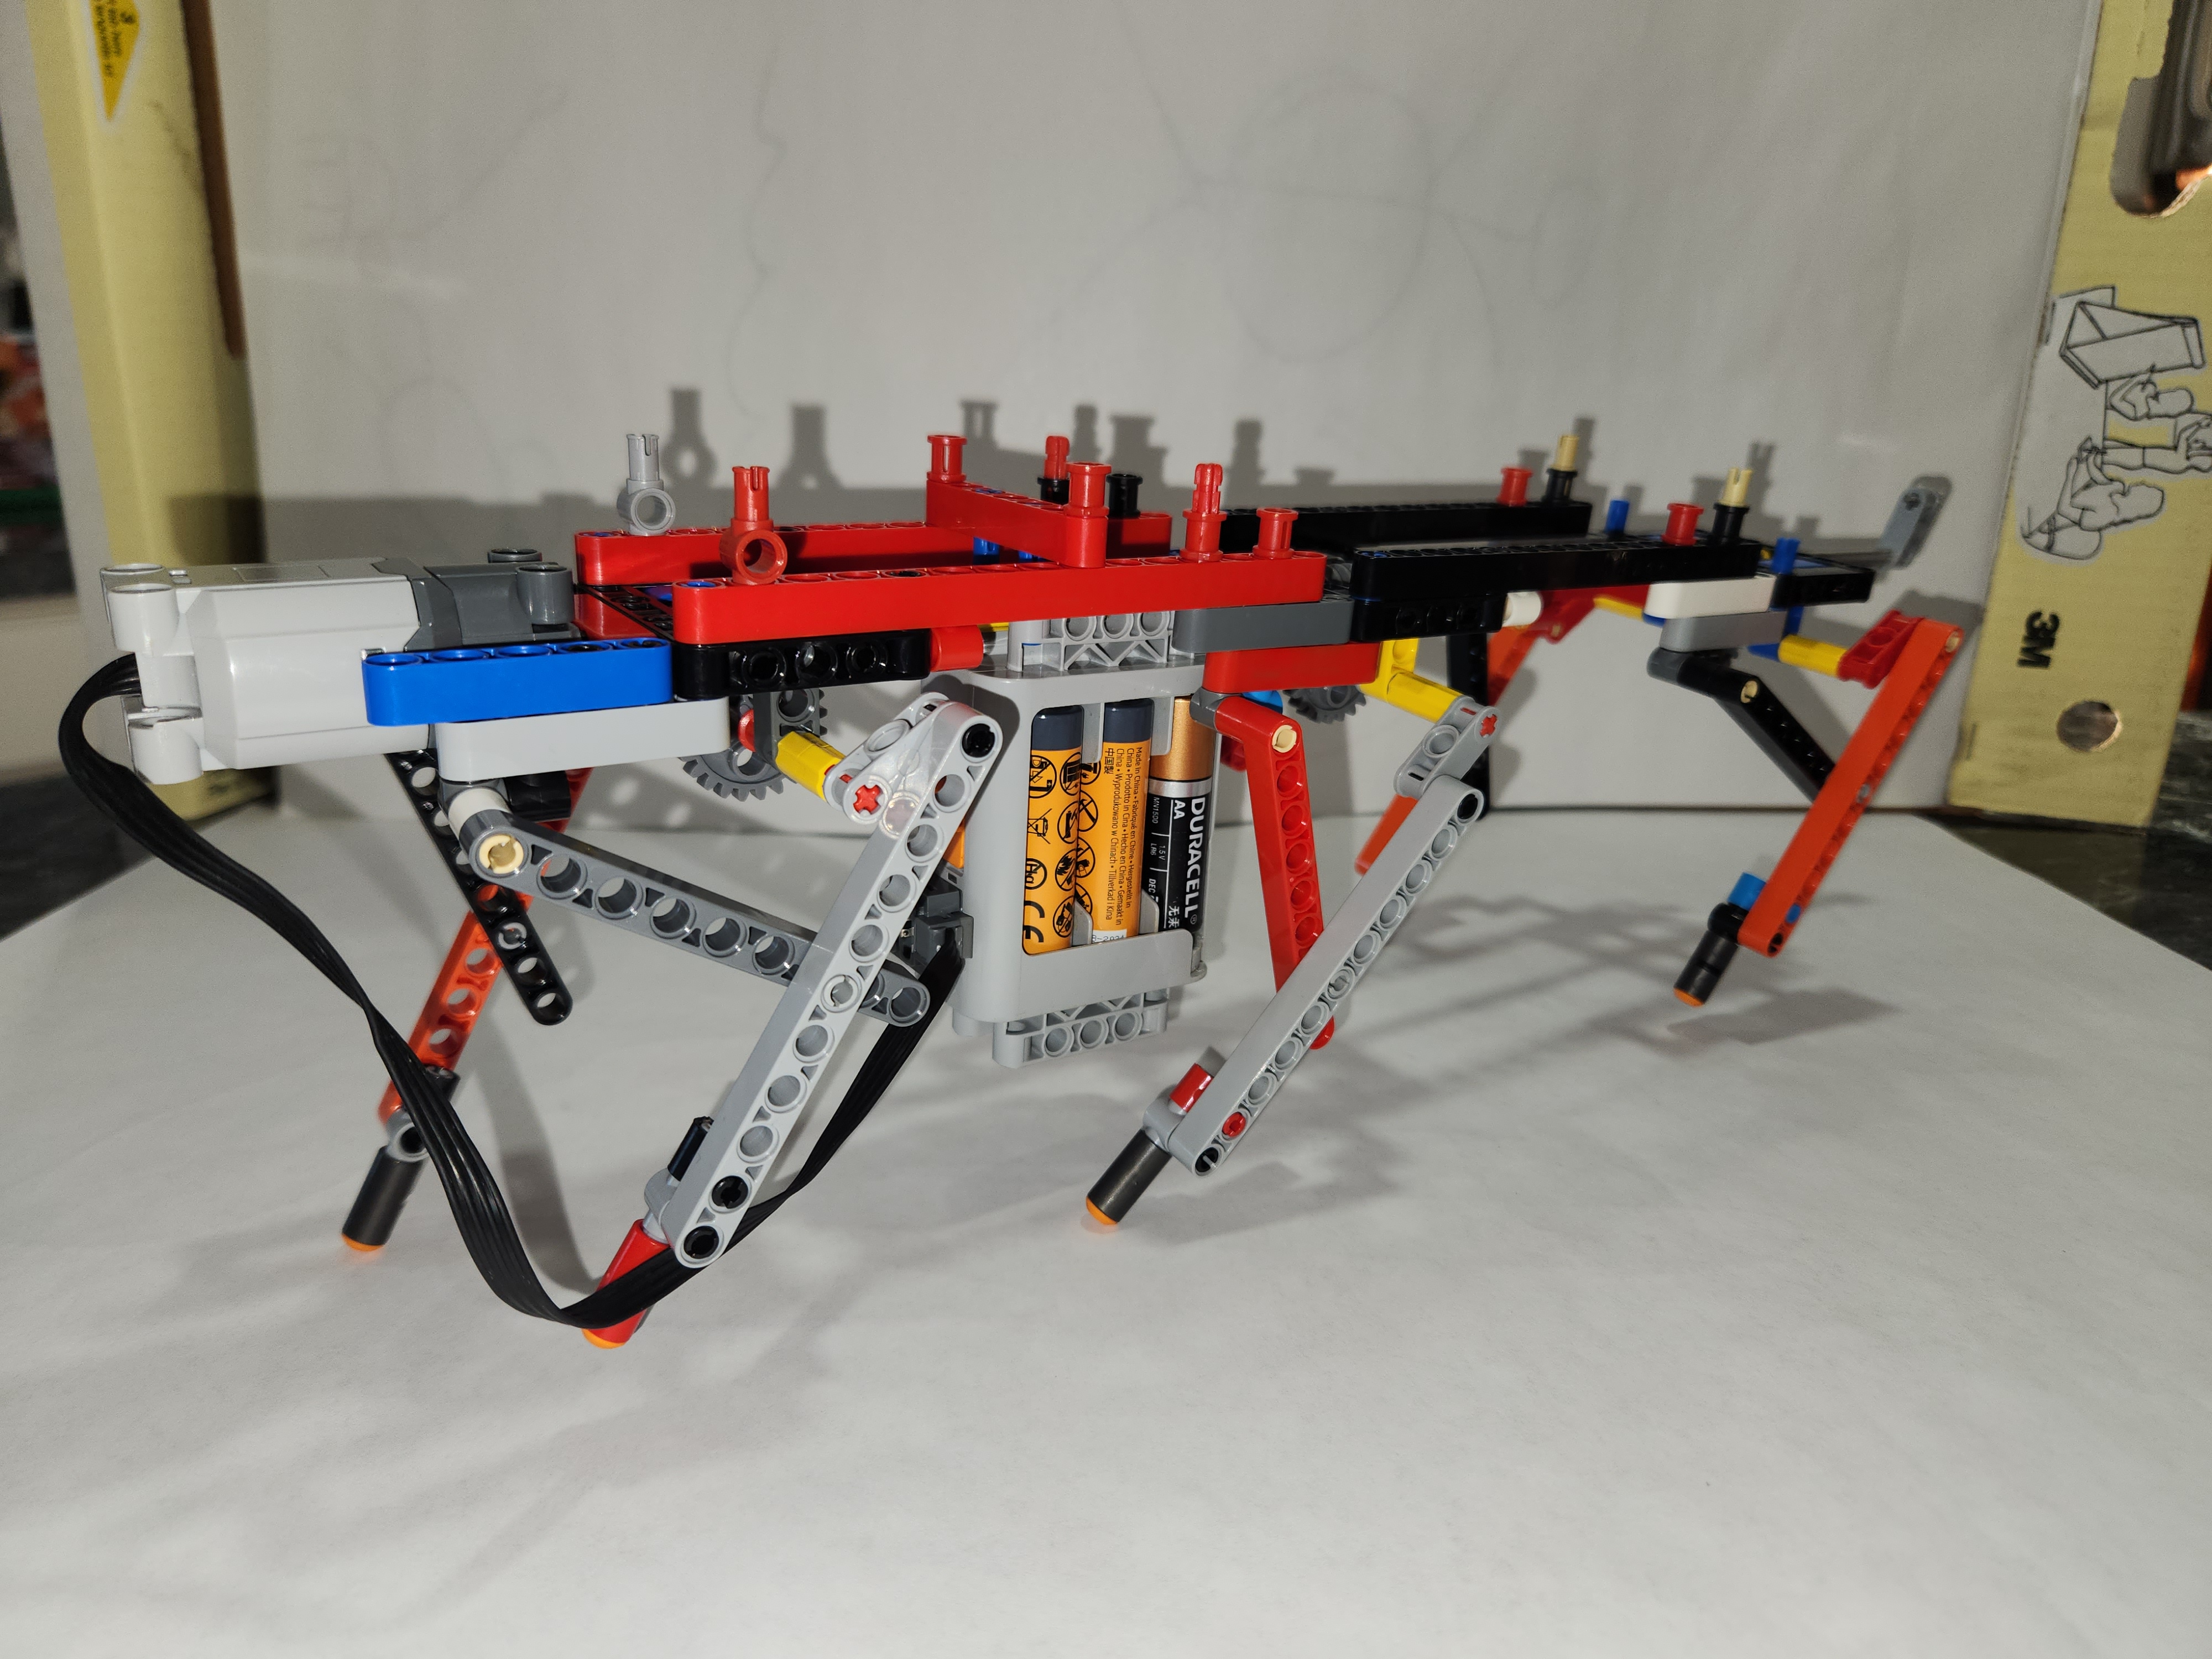
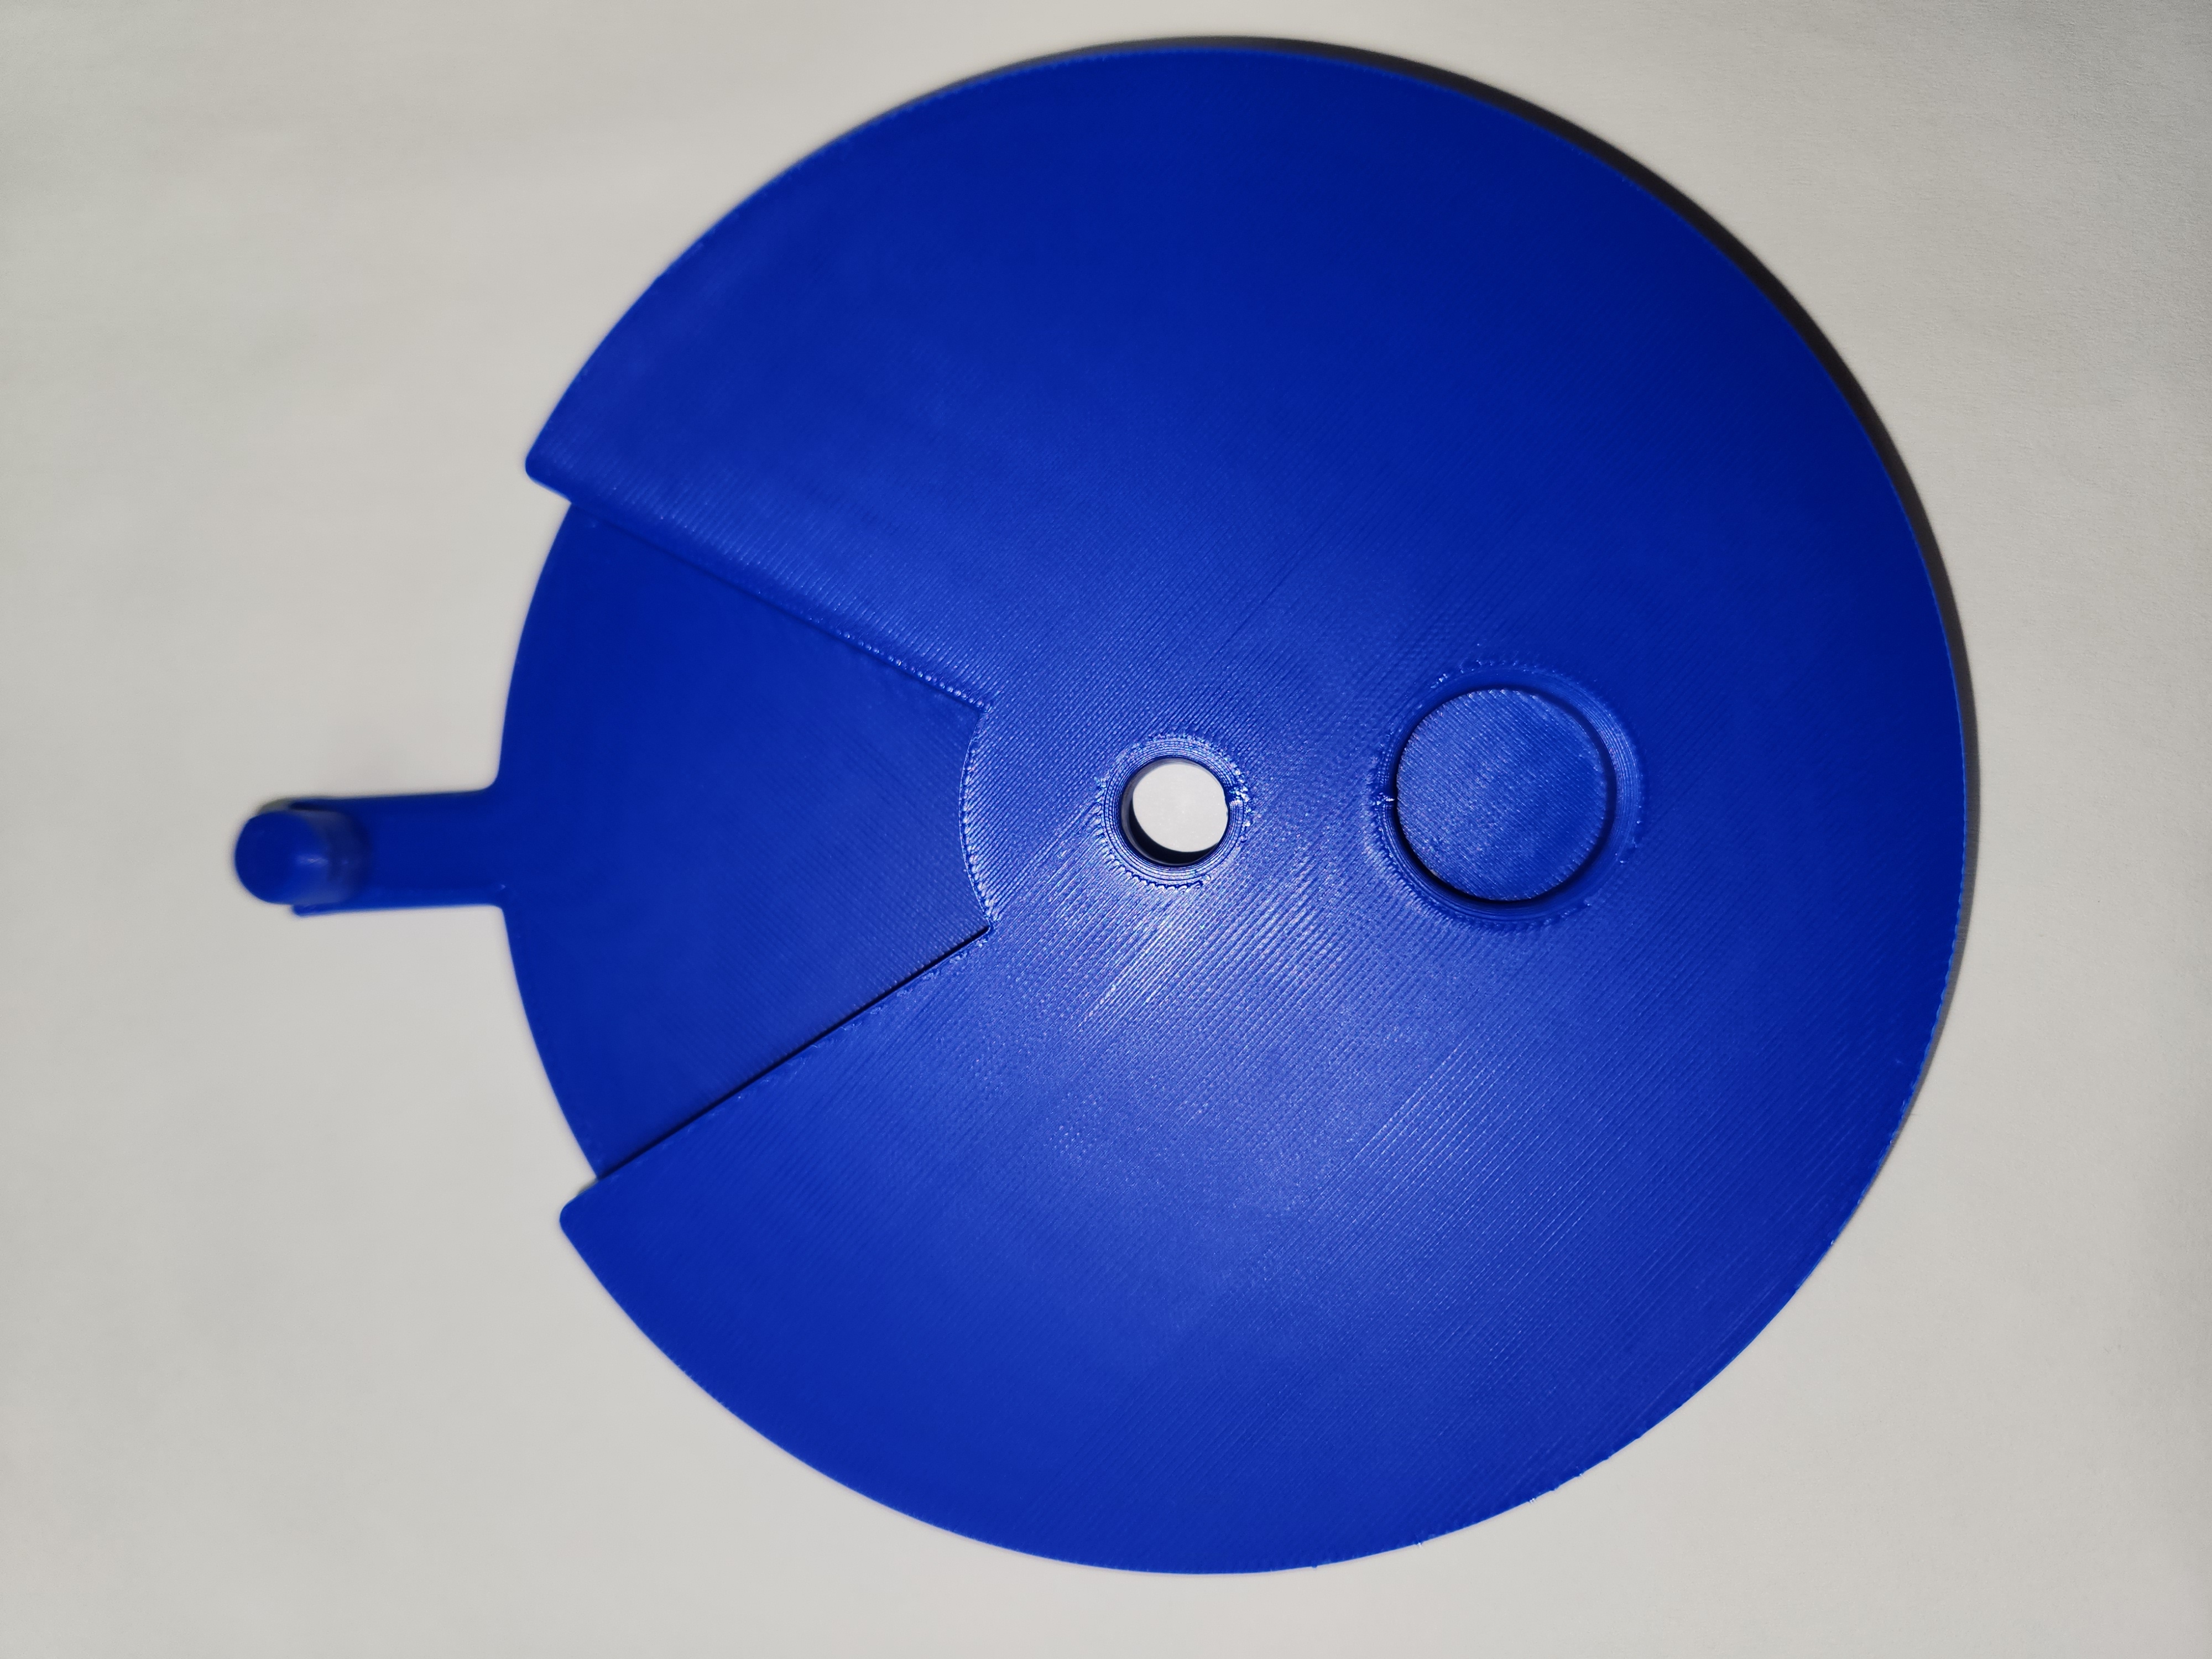
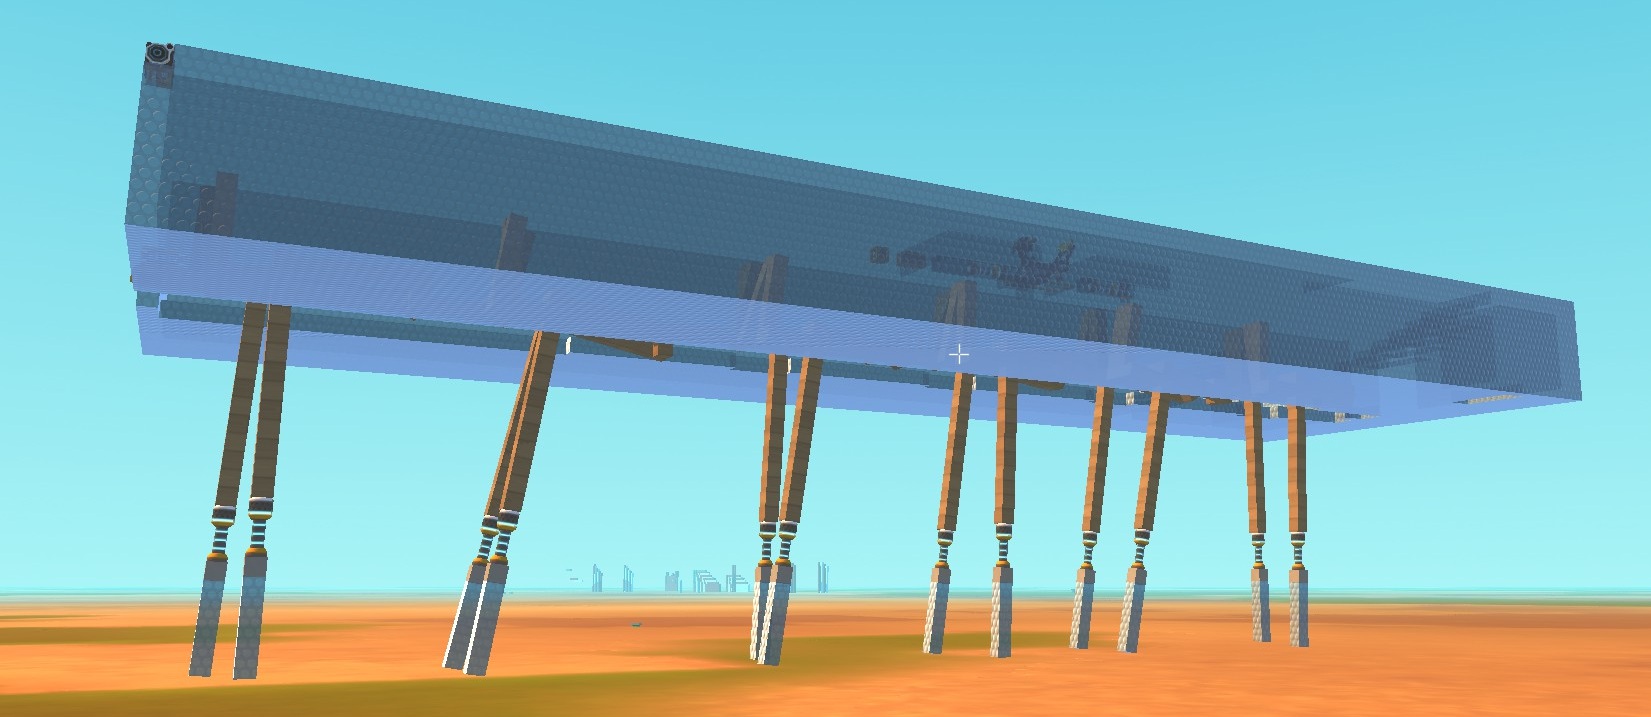
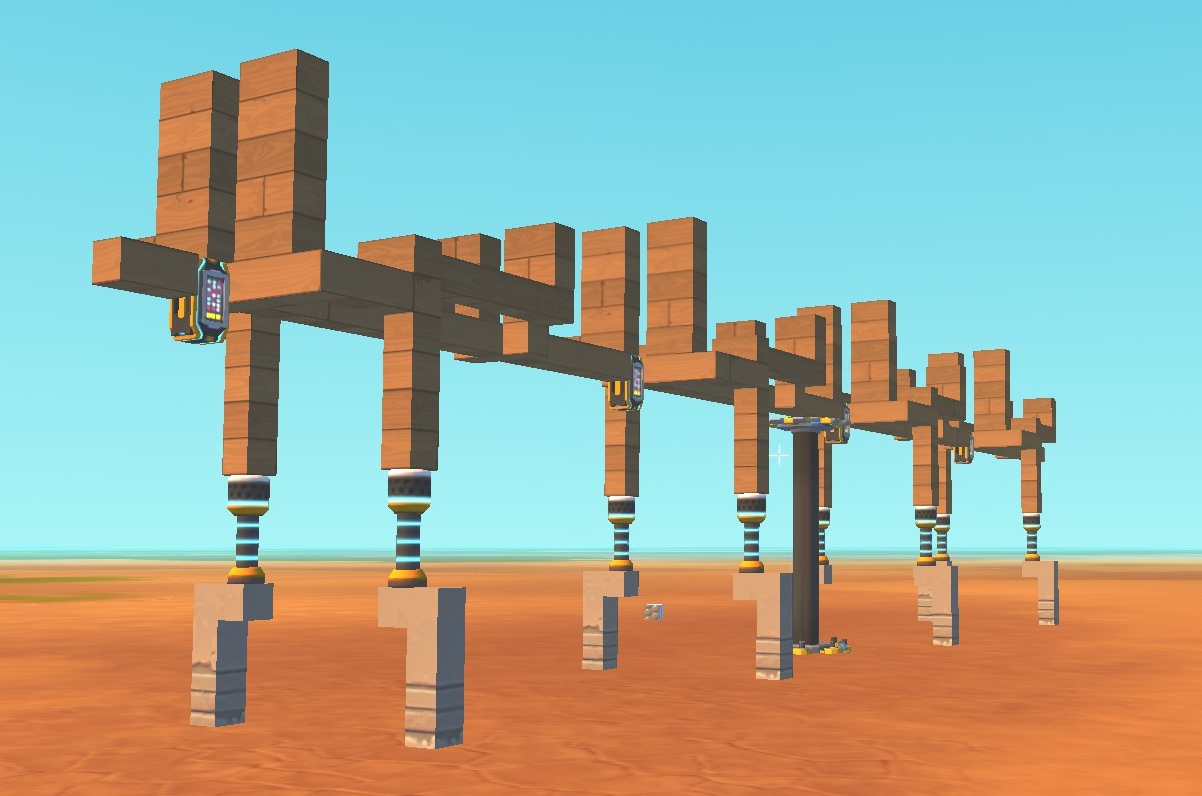
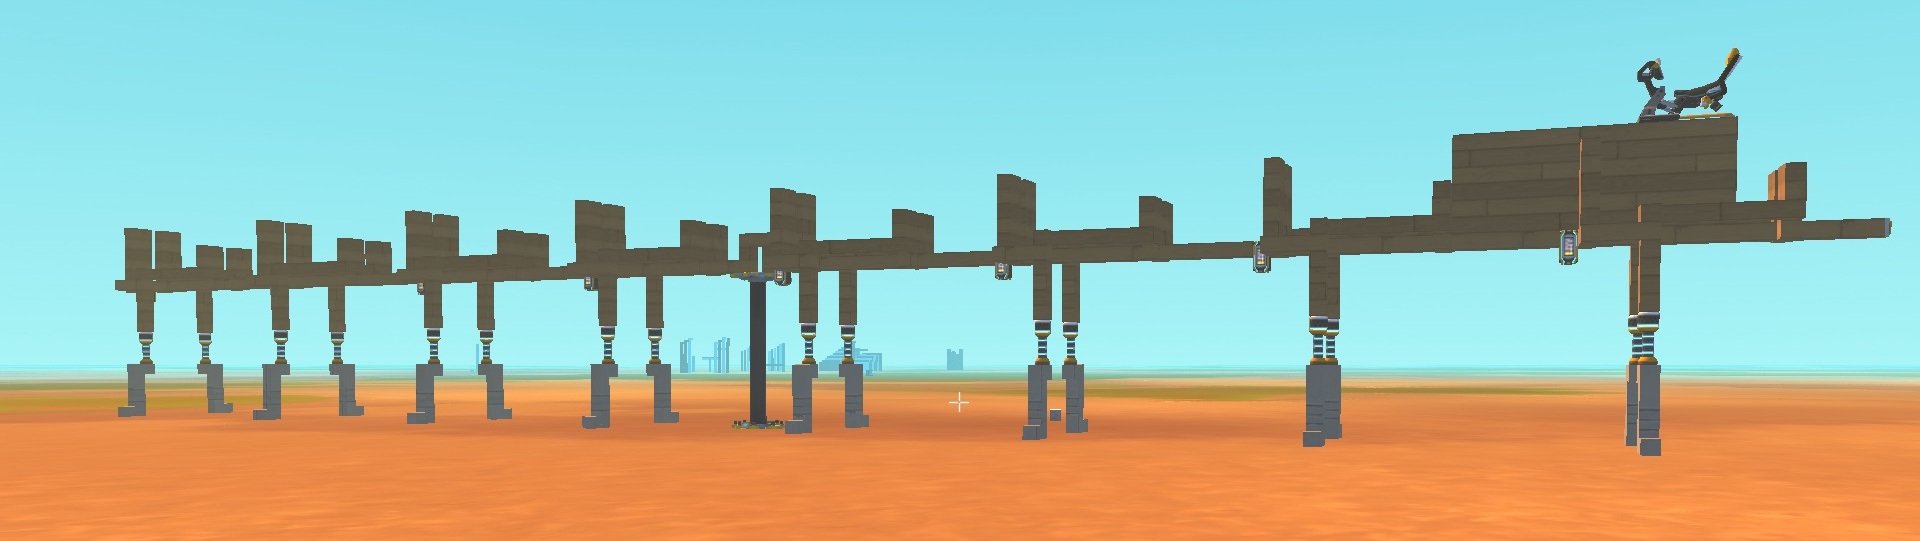
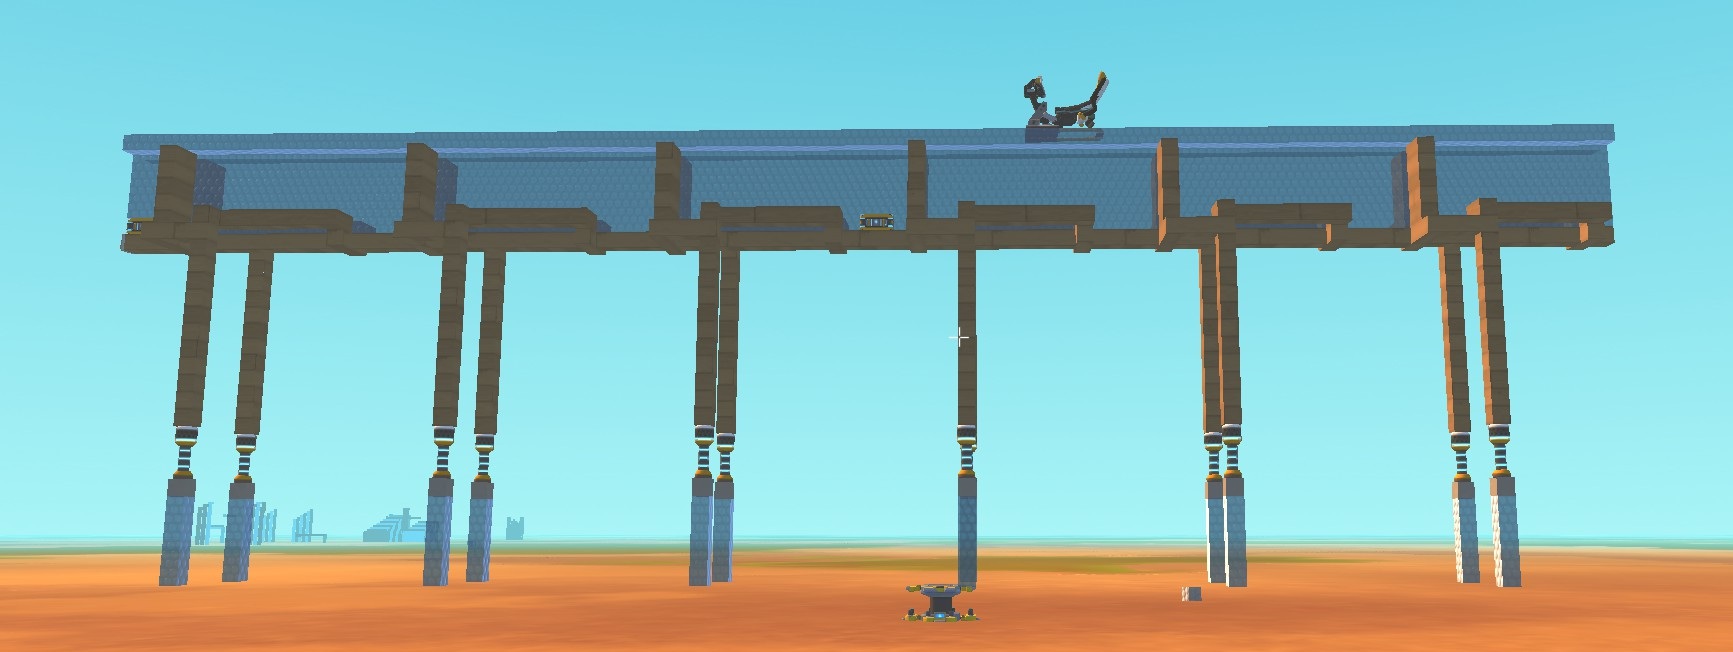
Final Biomimetic Walking Robot
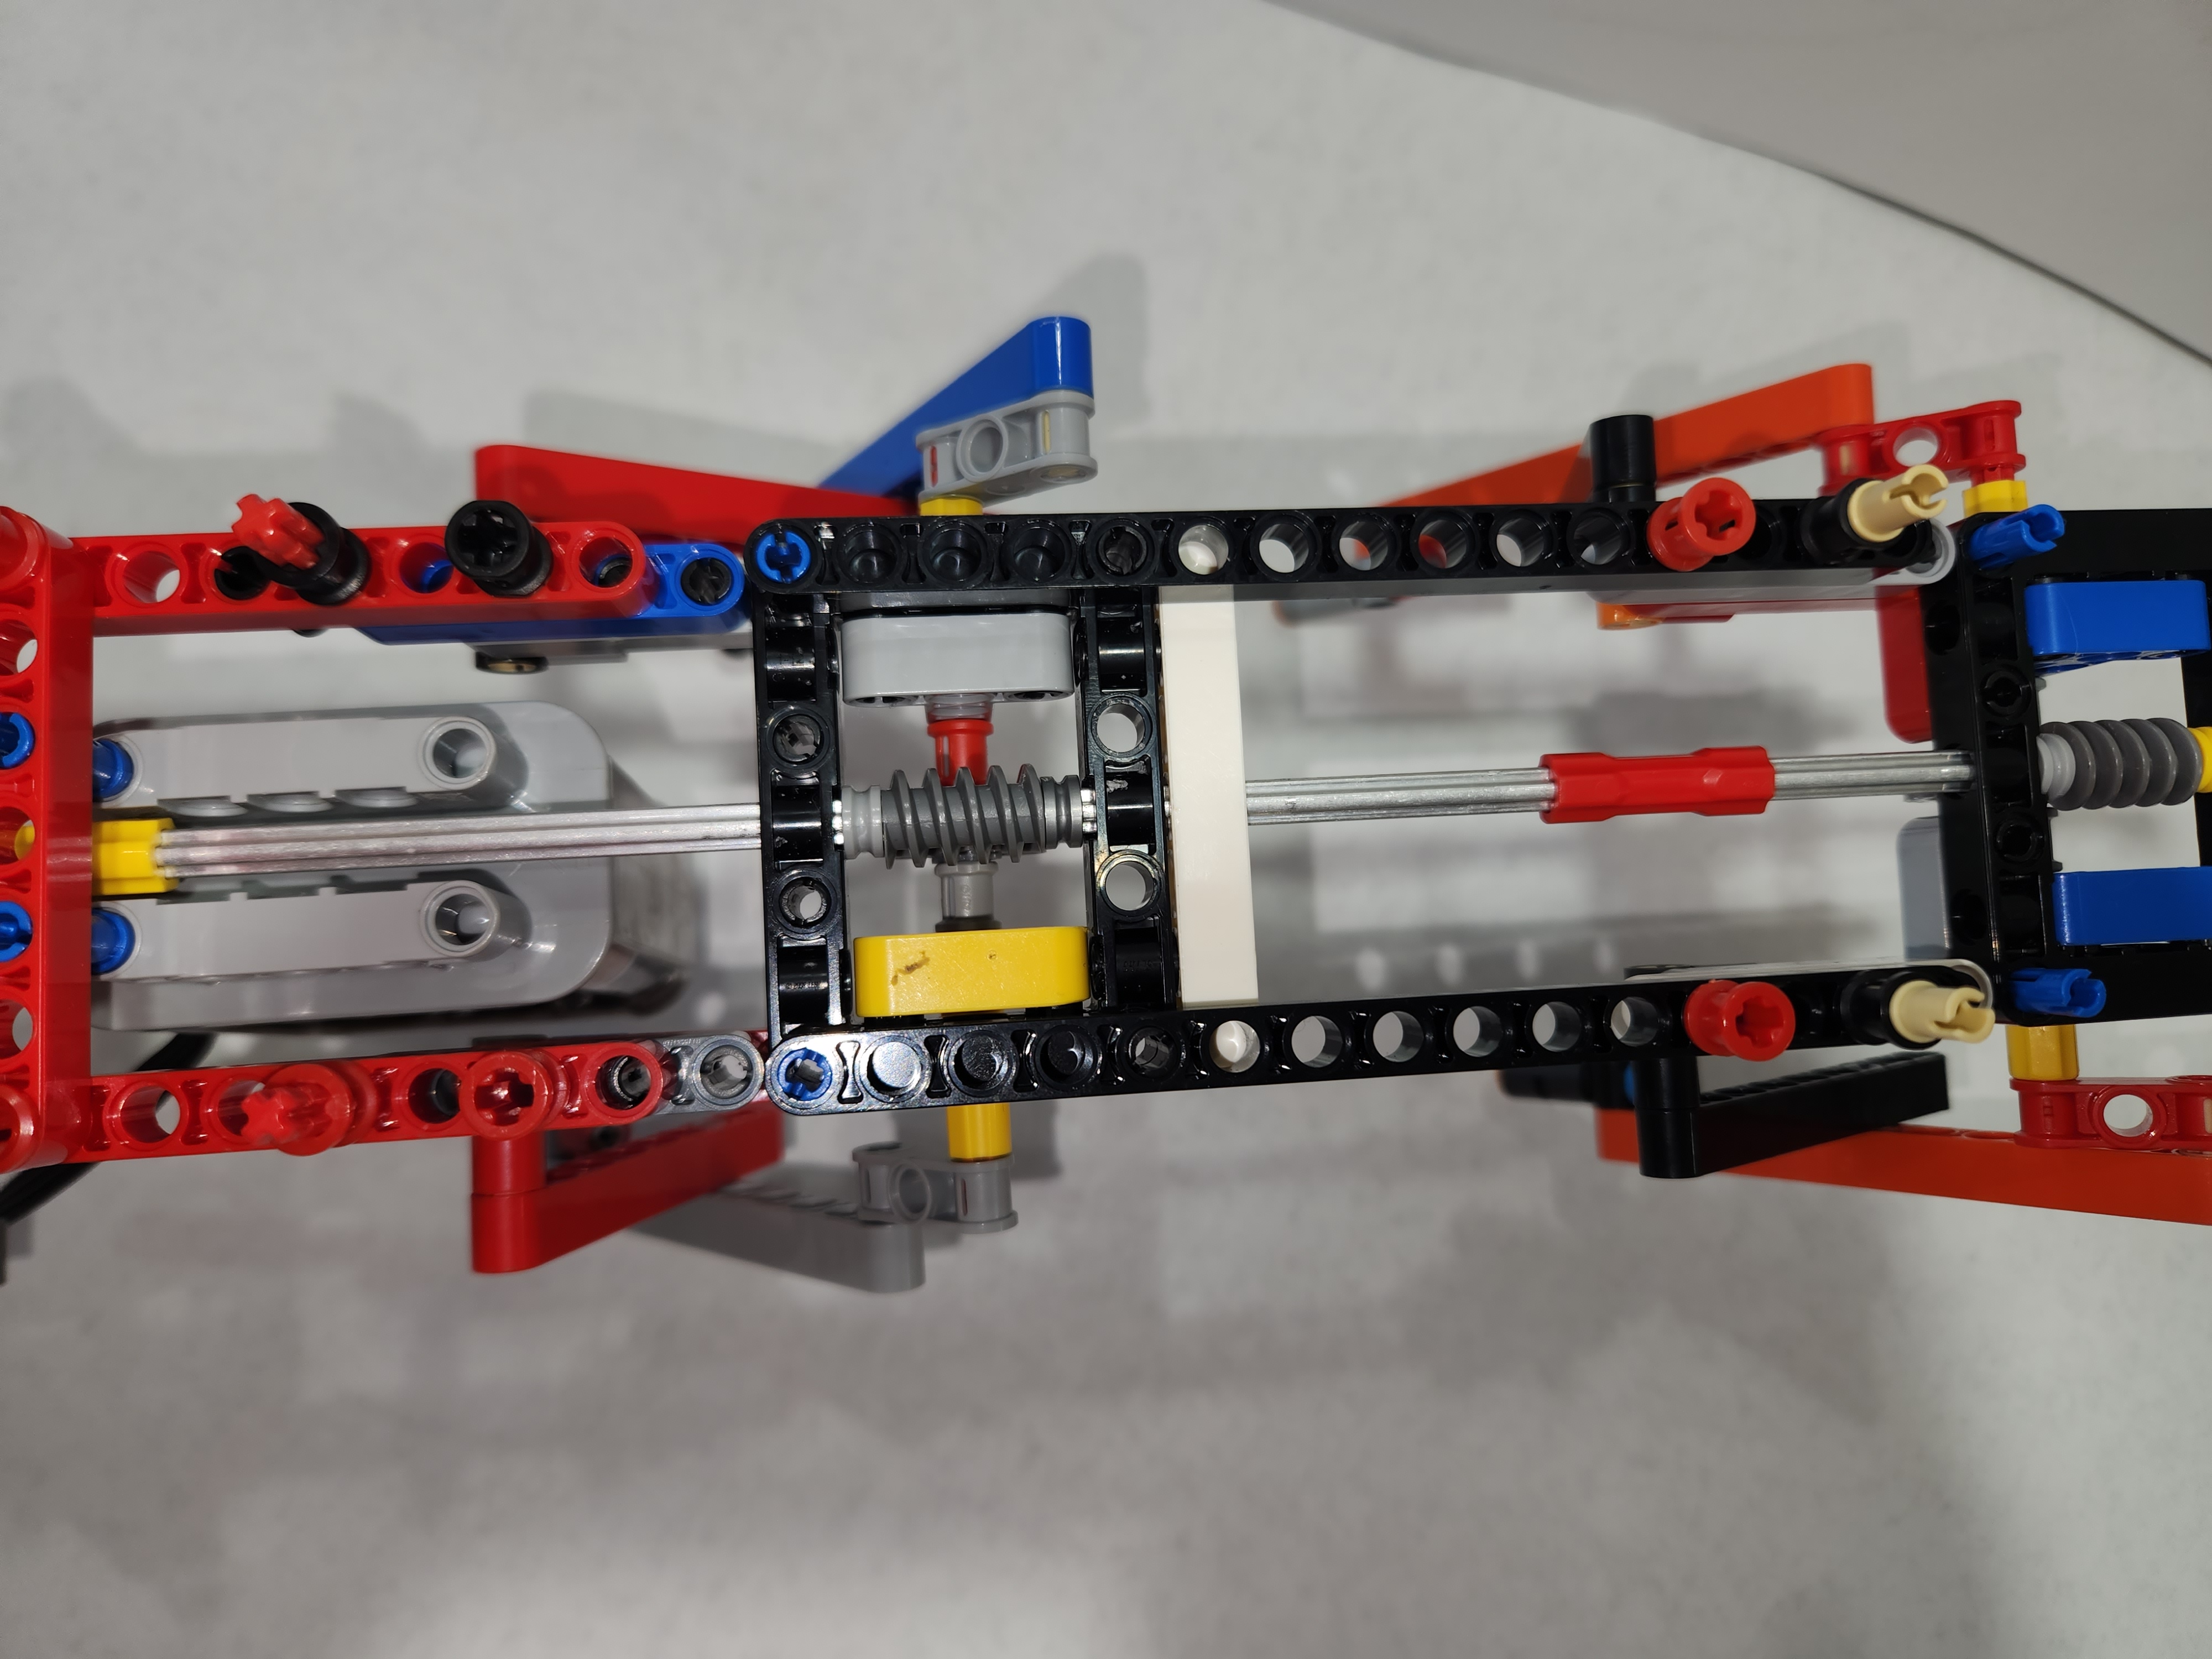
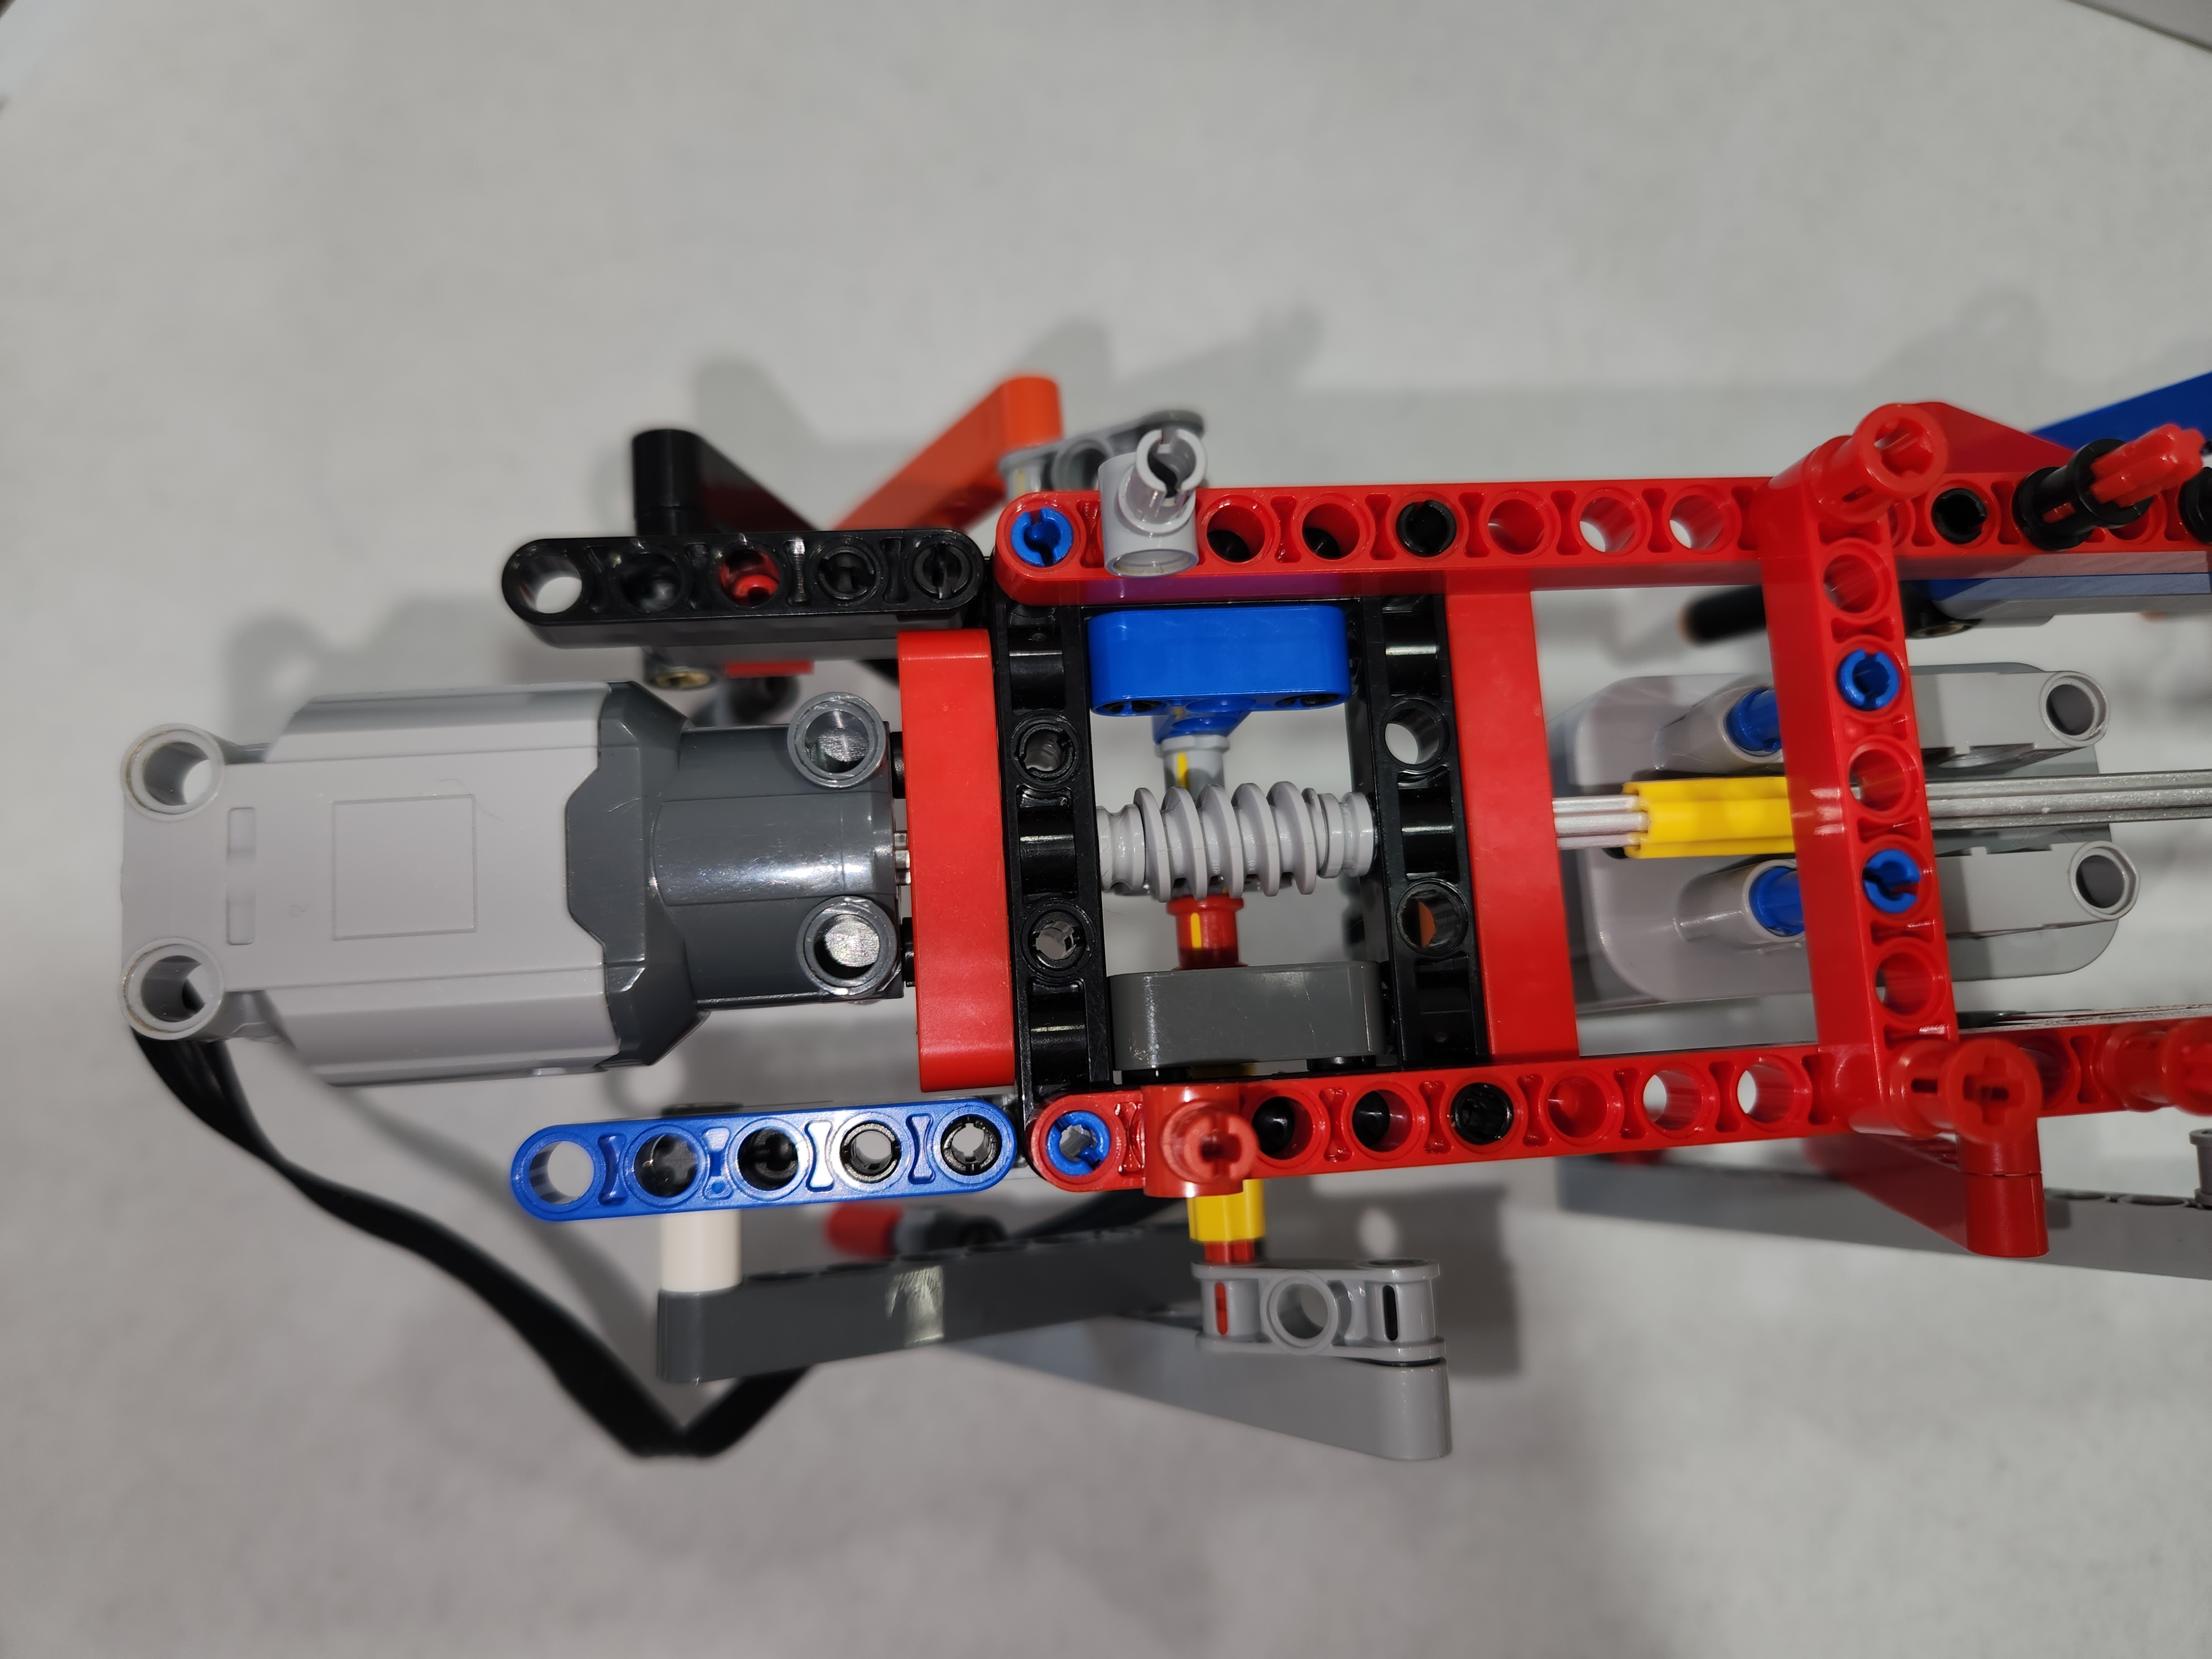
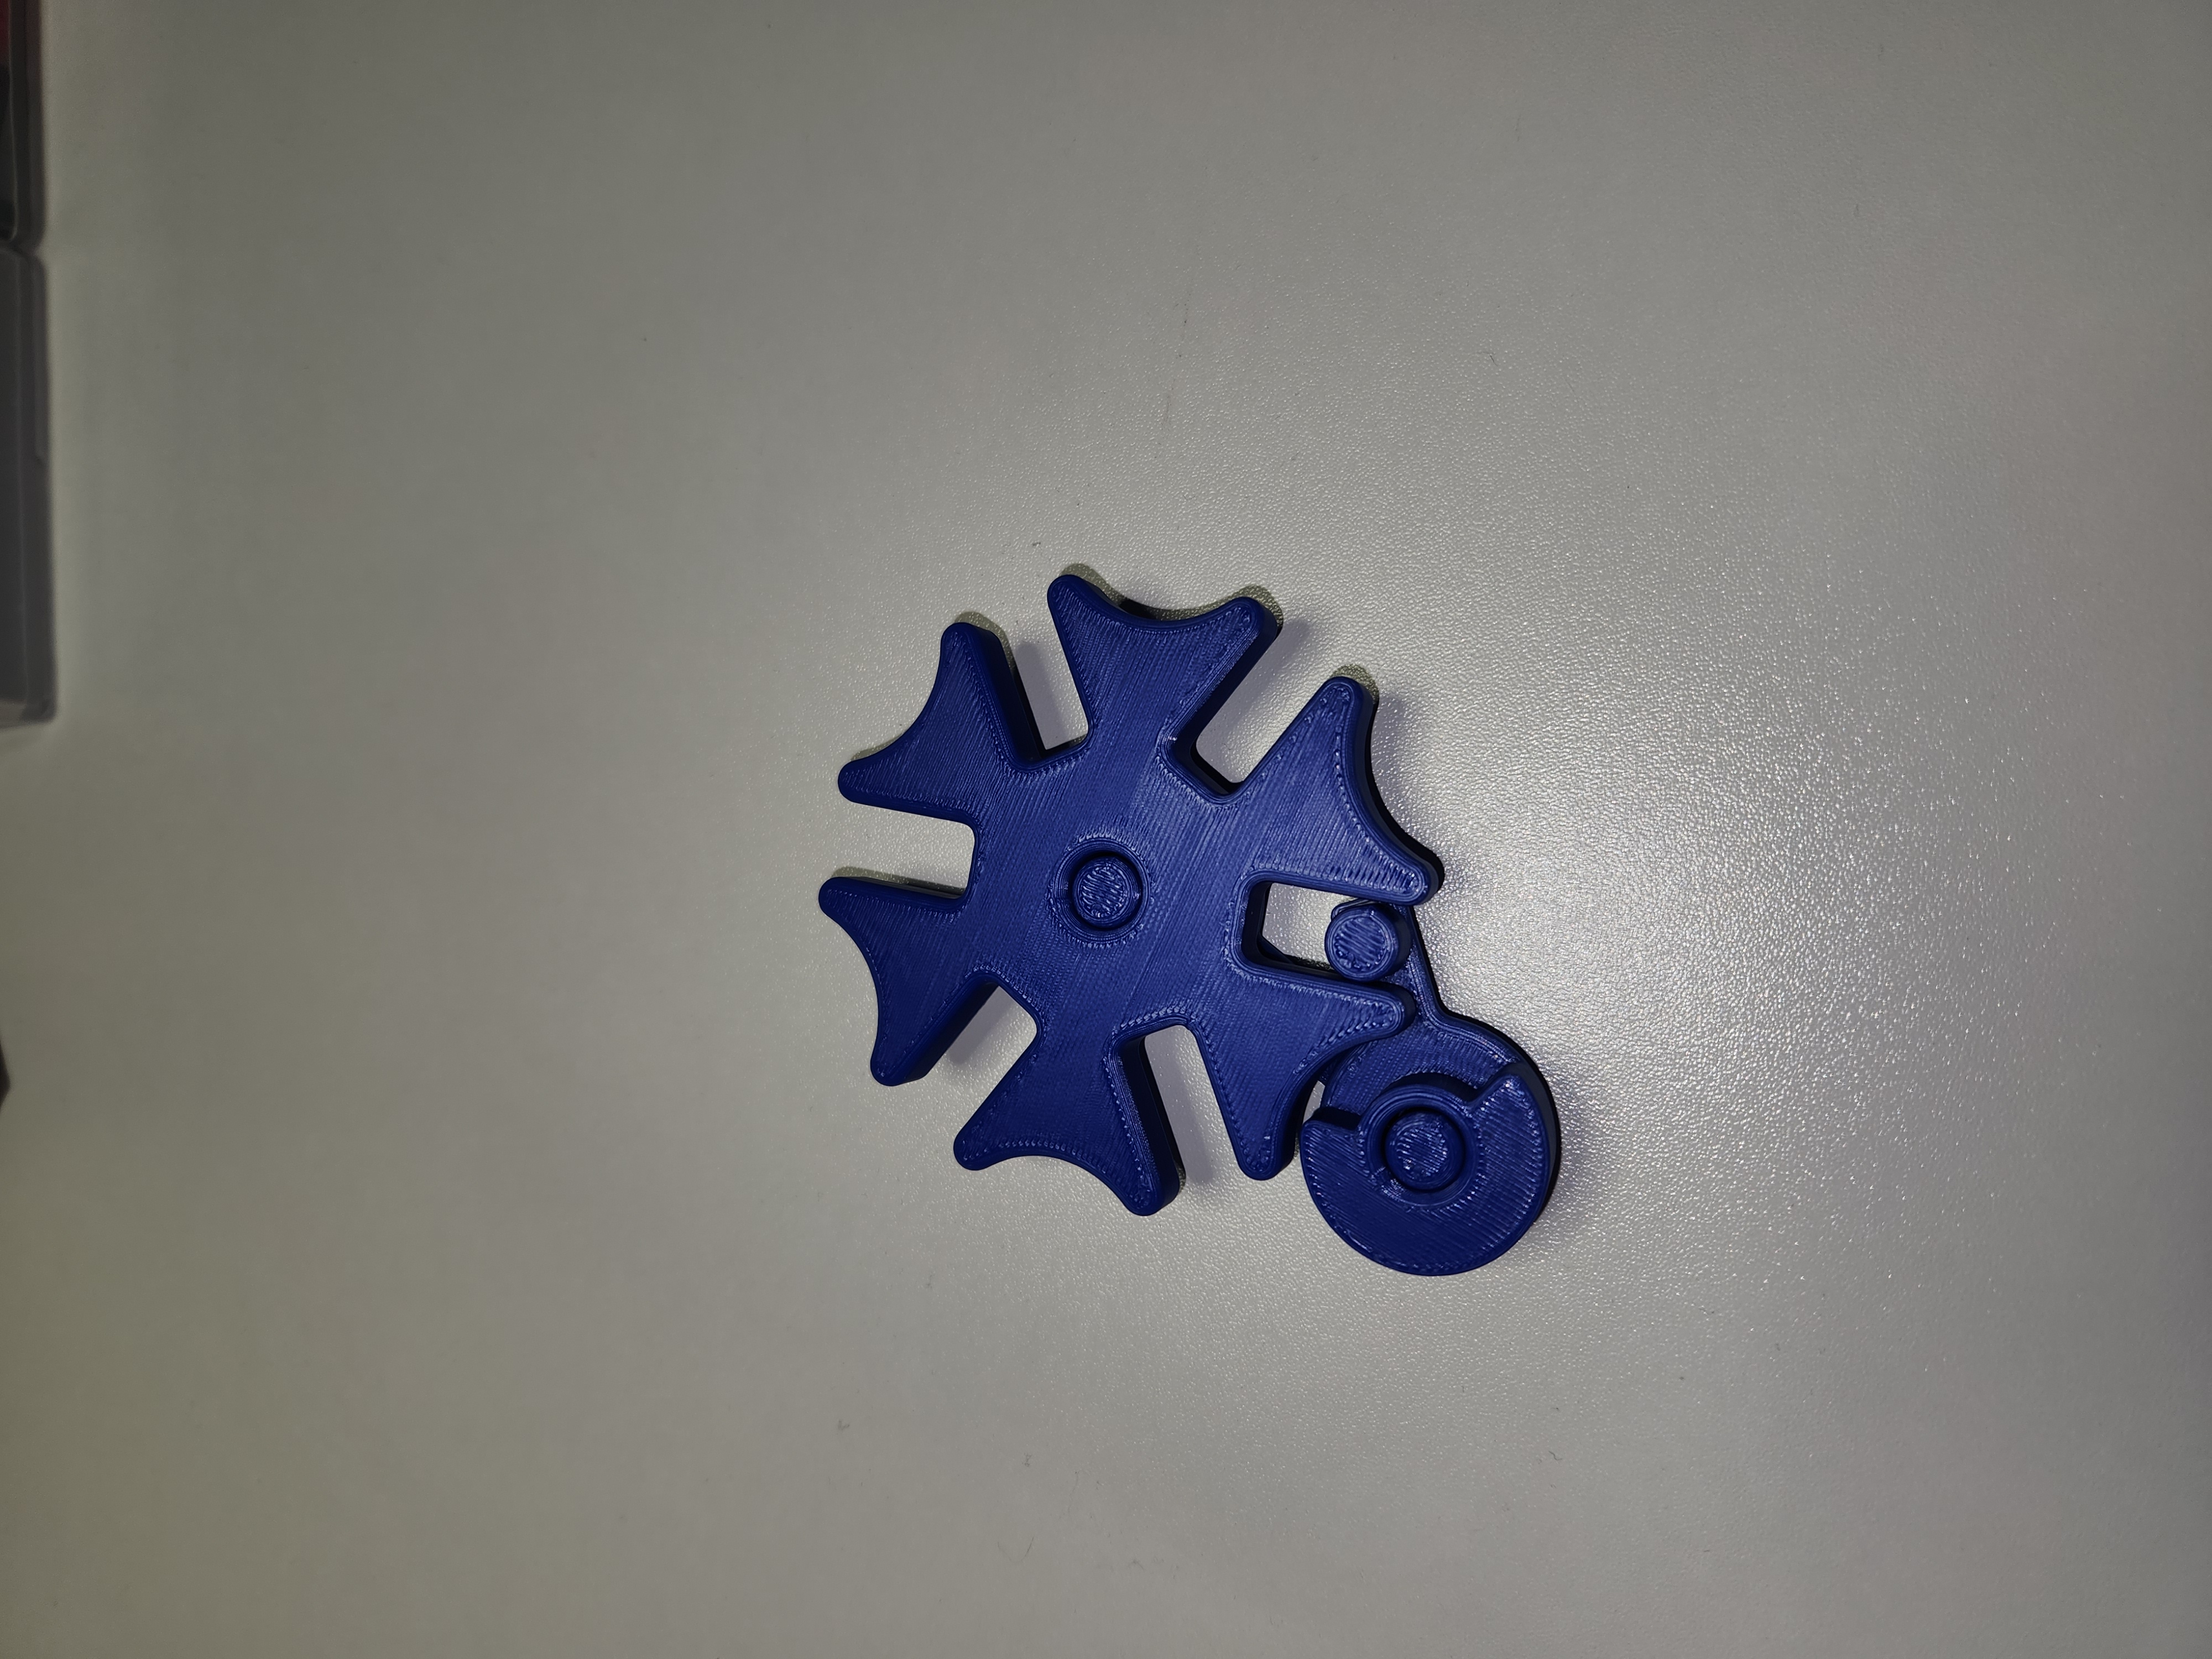
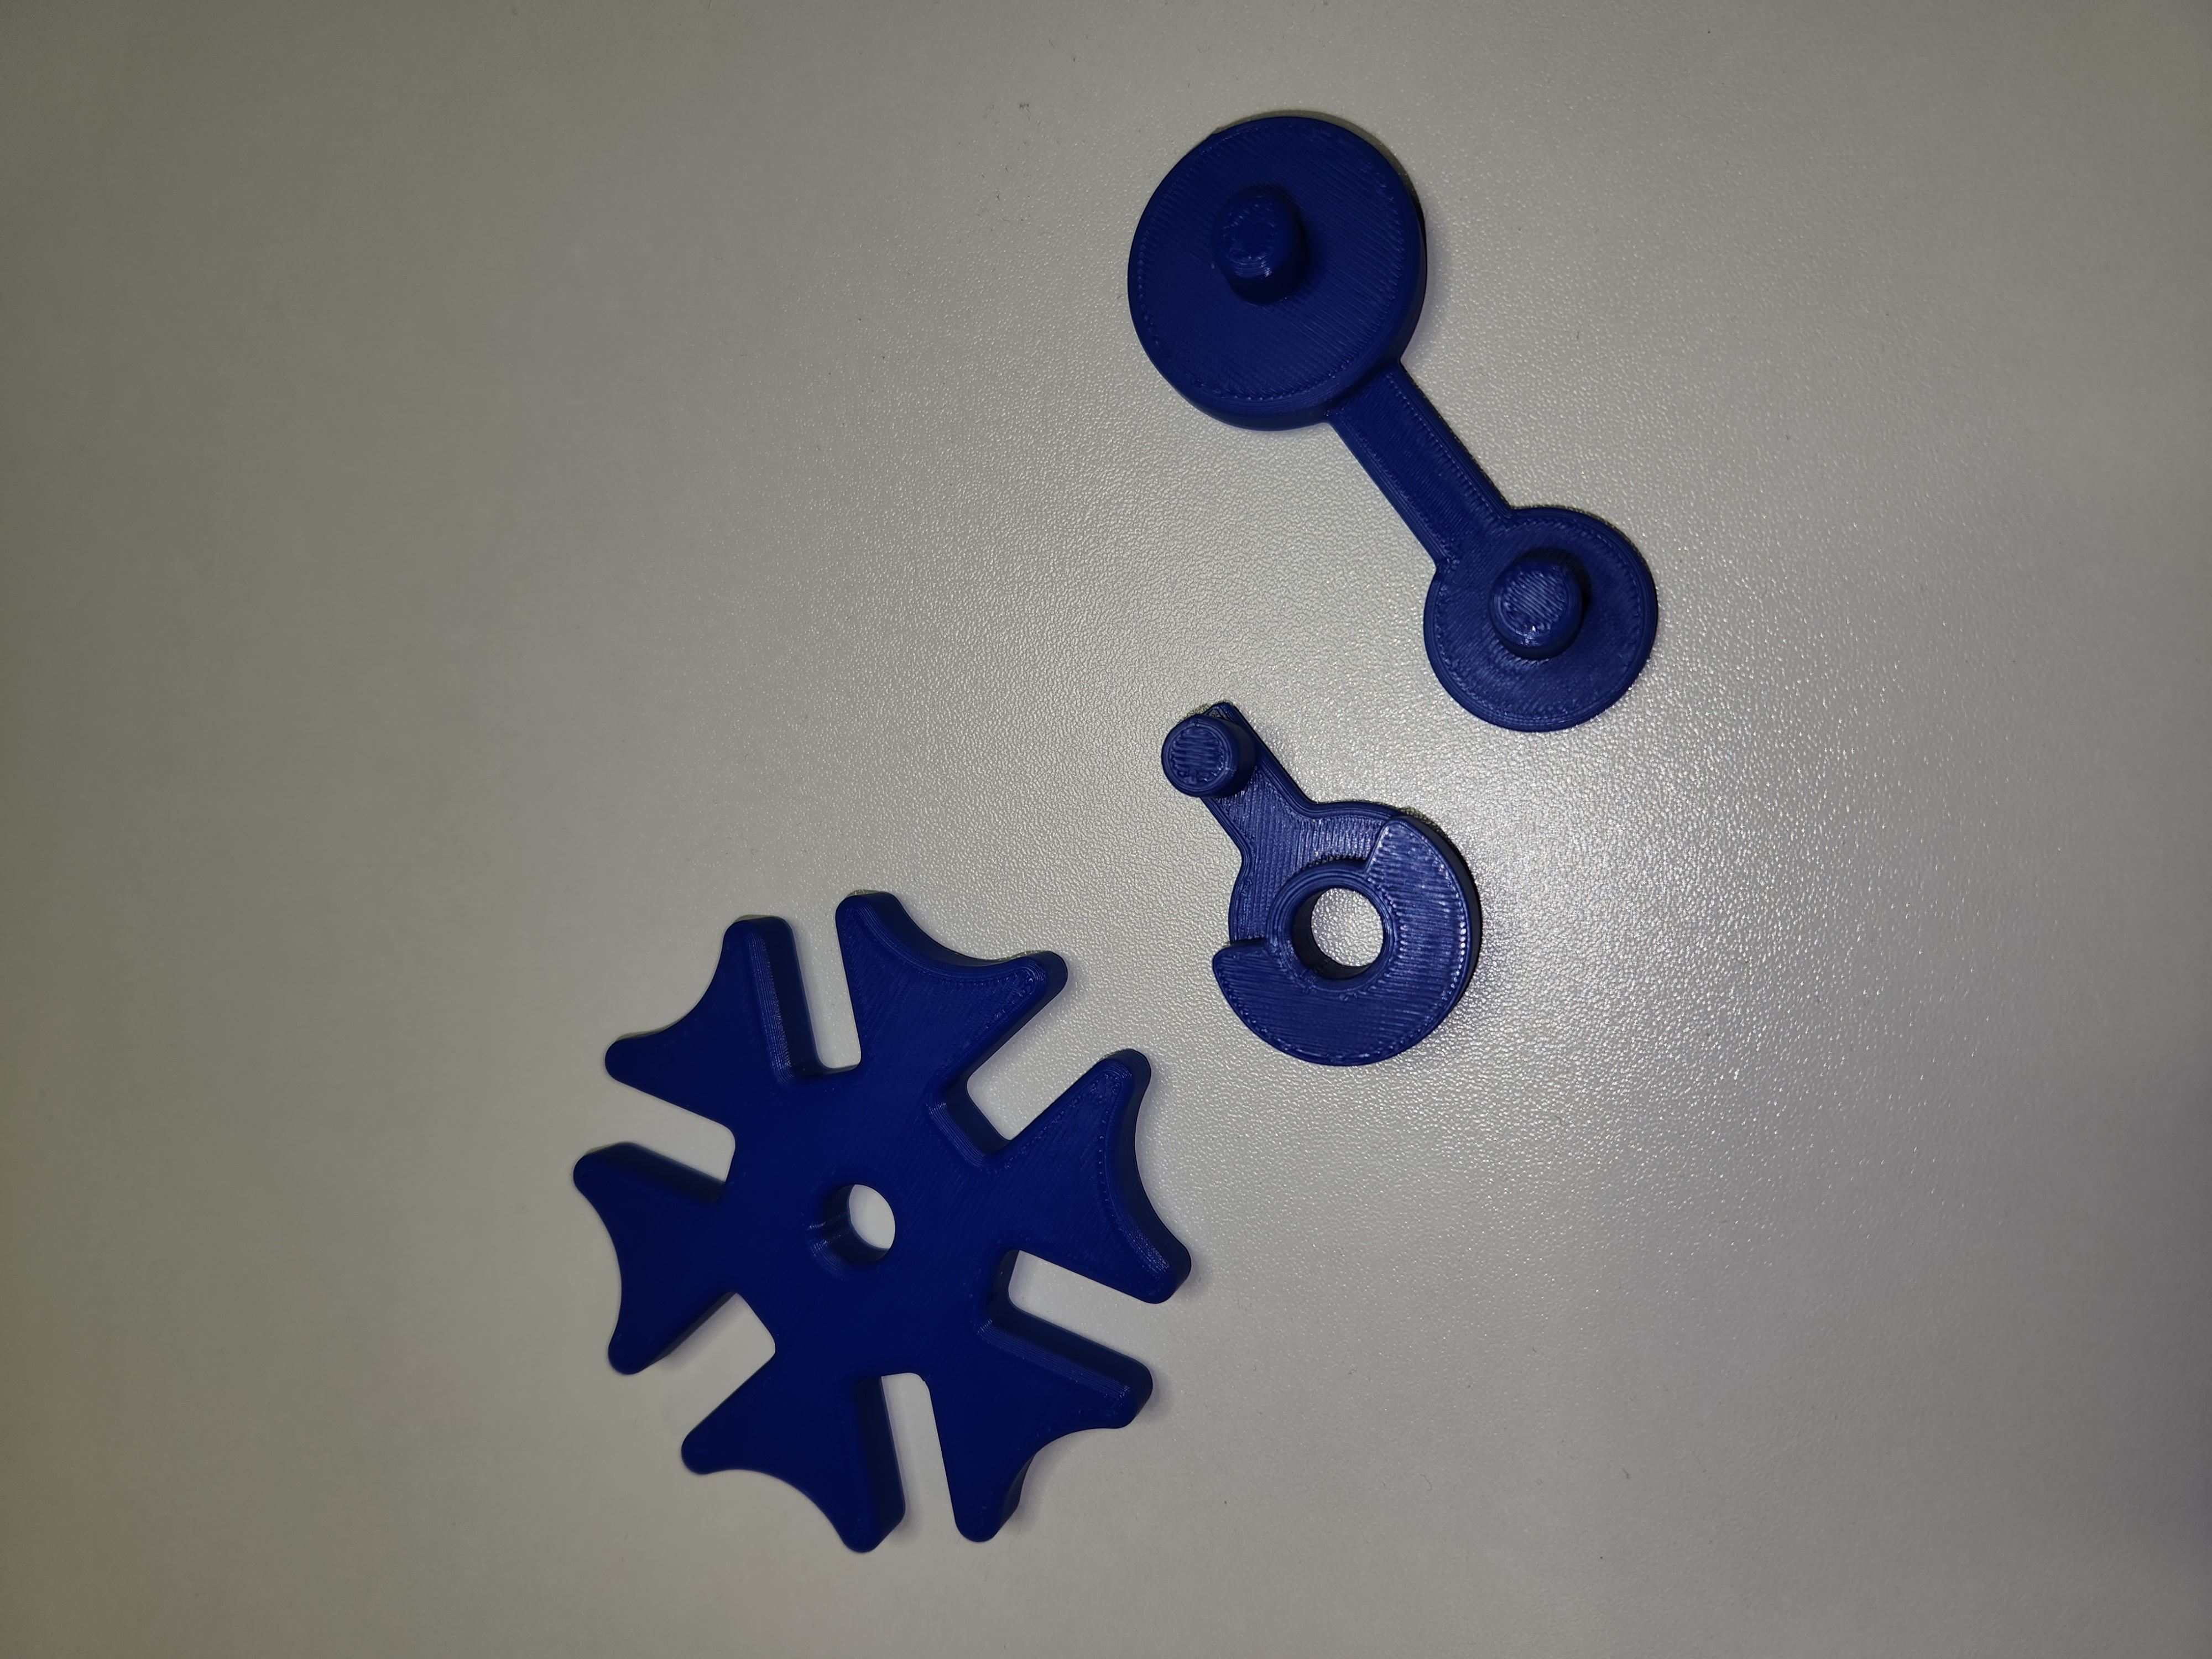
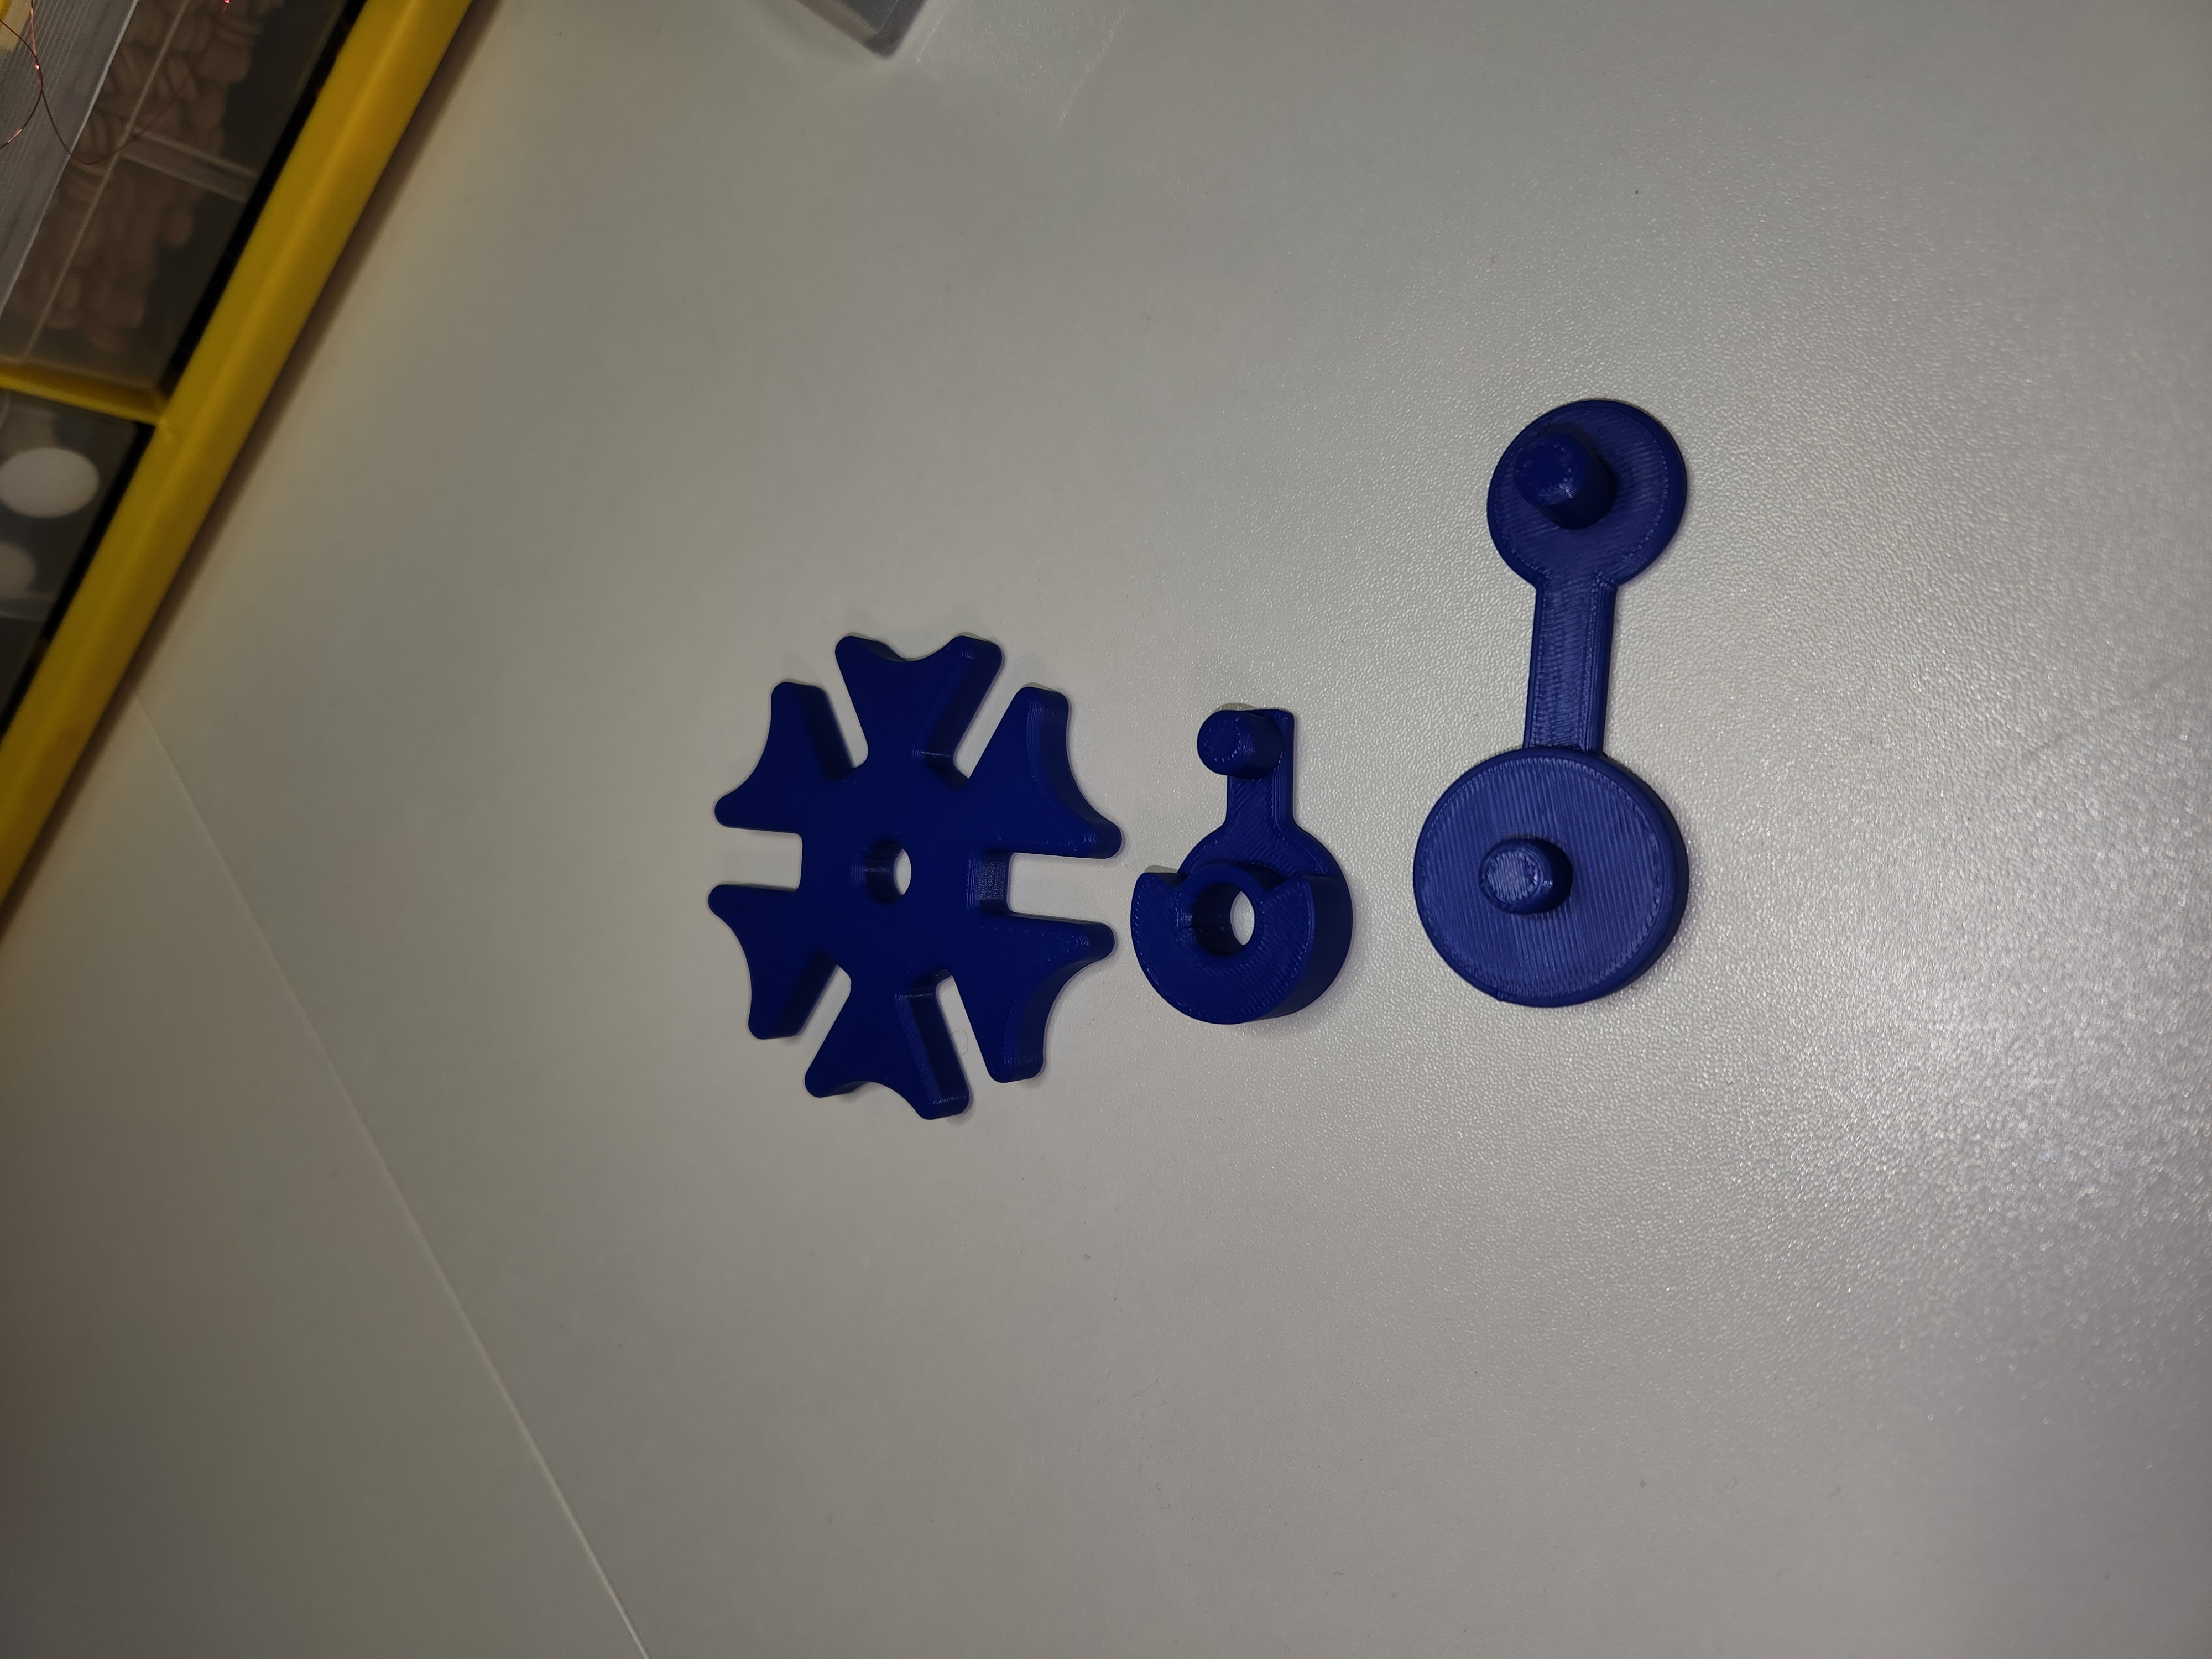
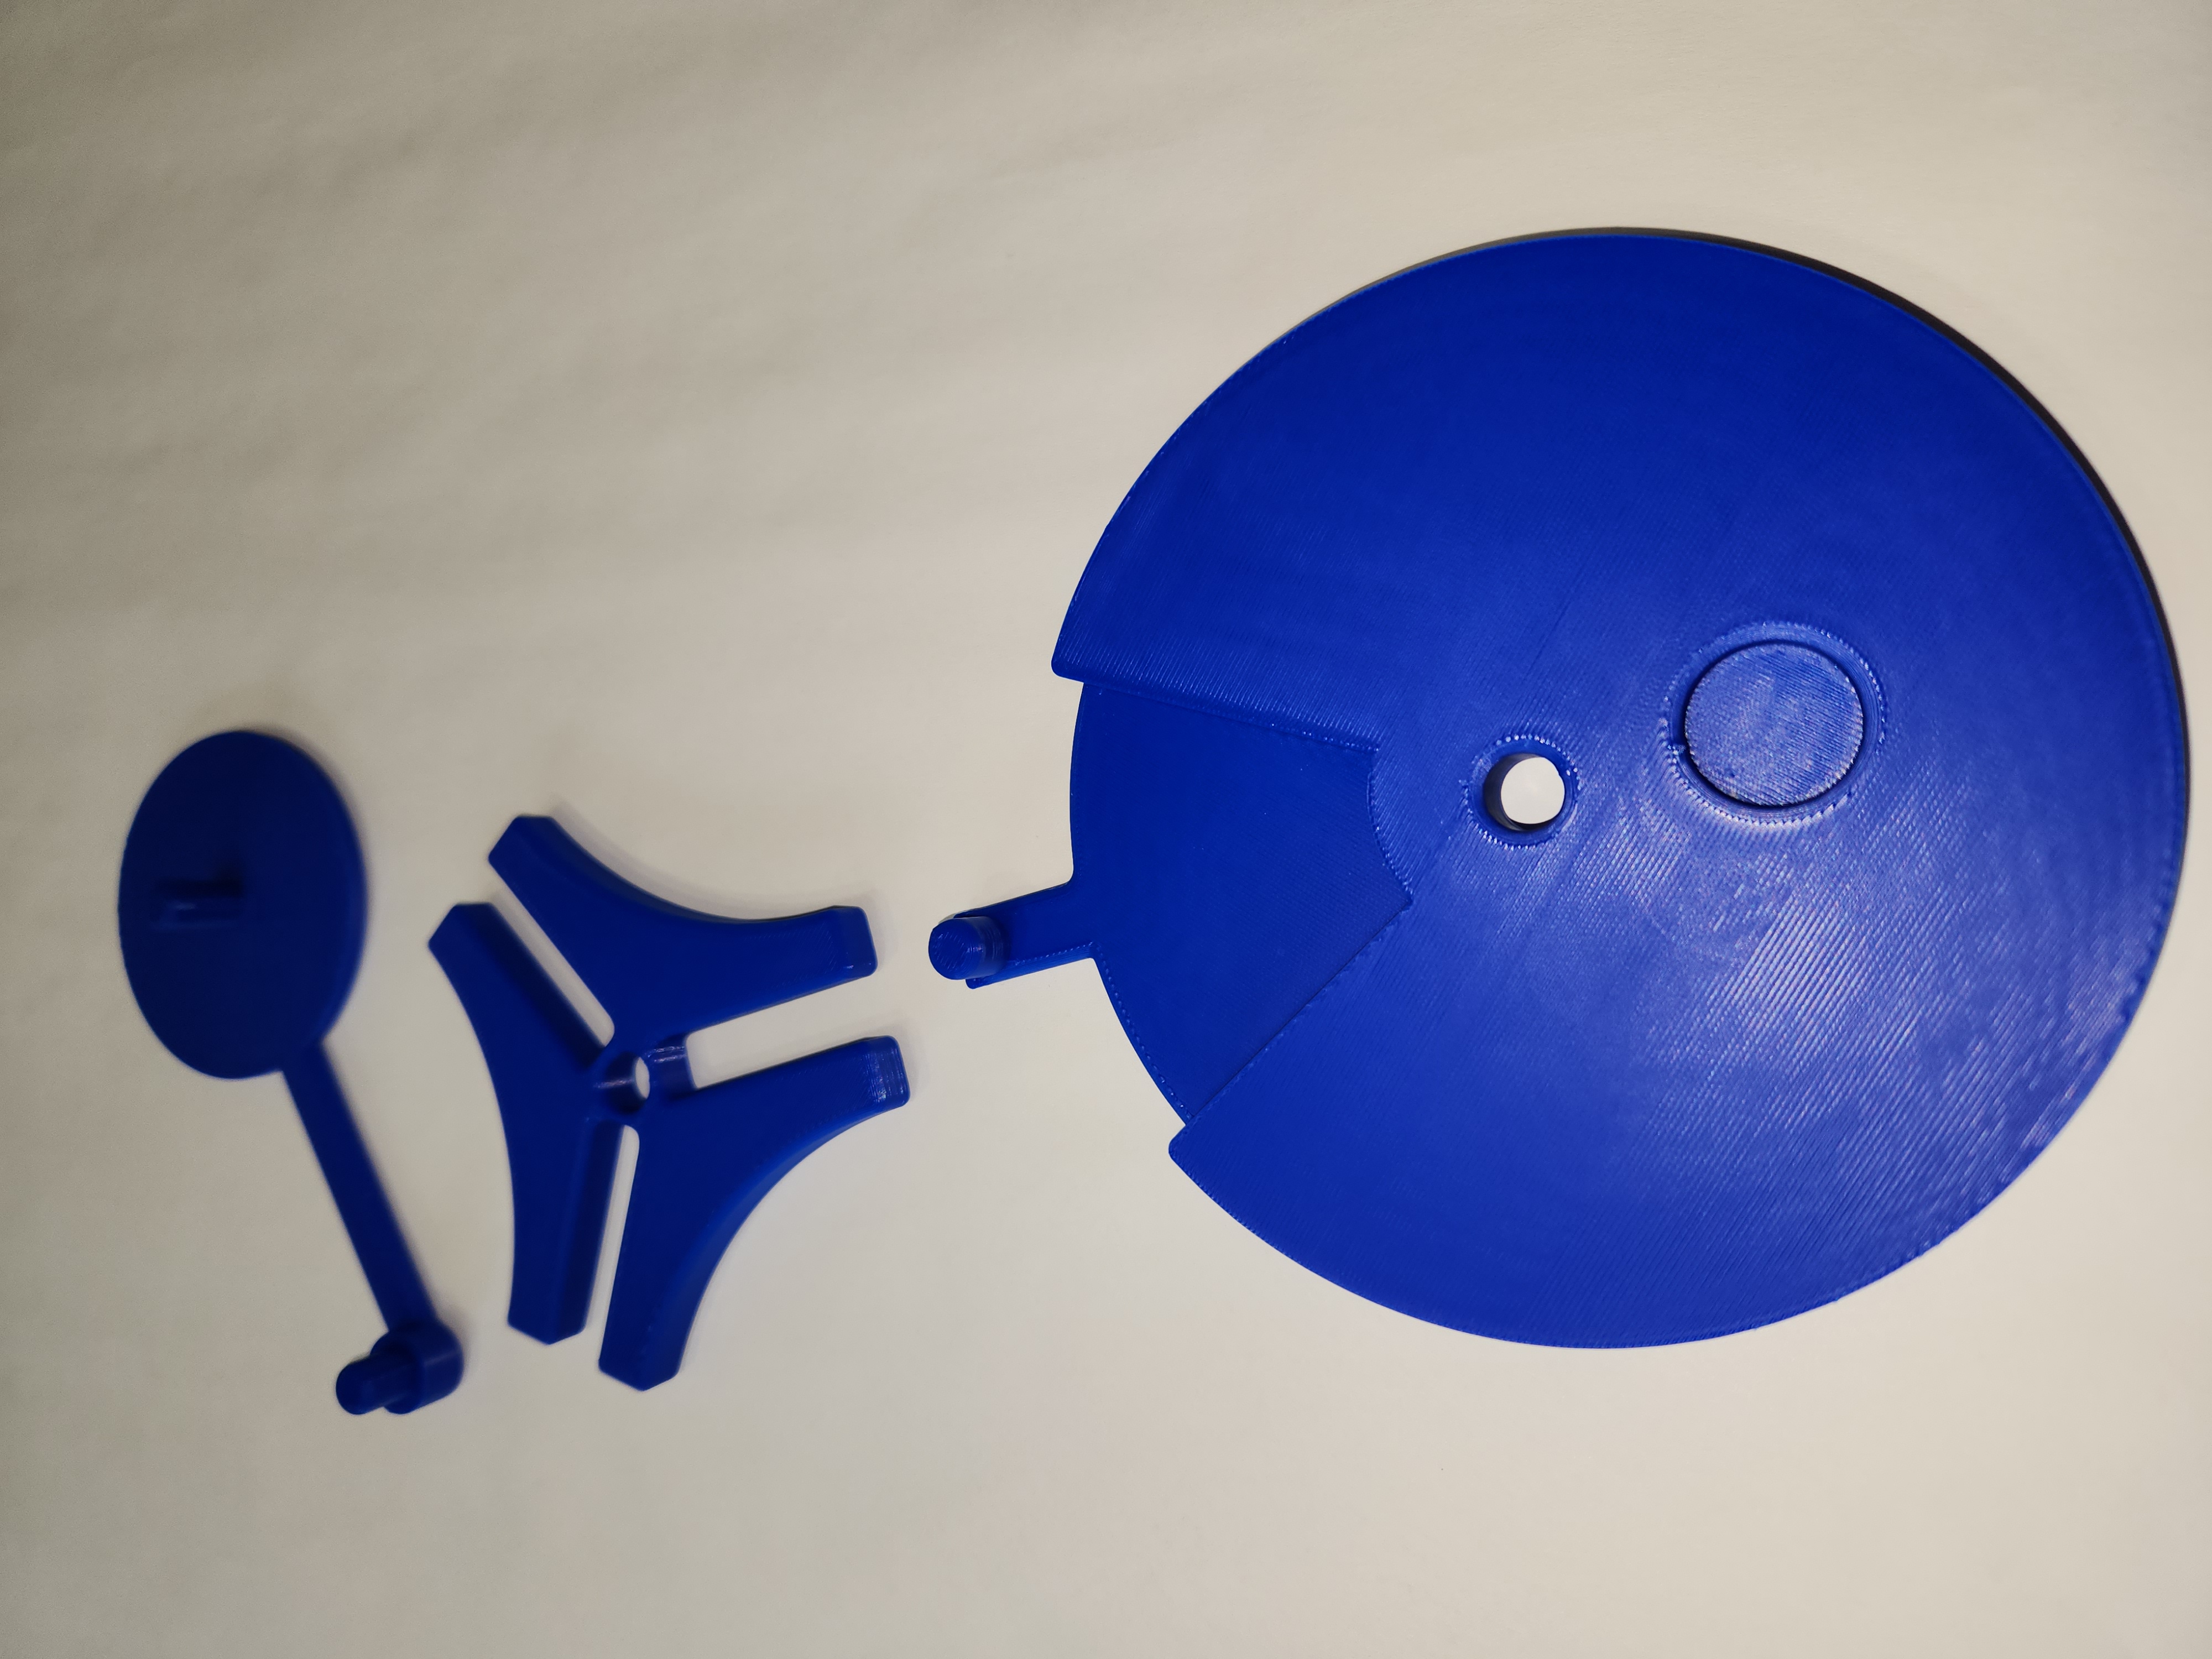
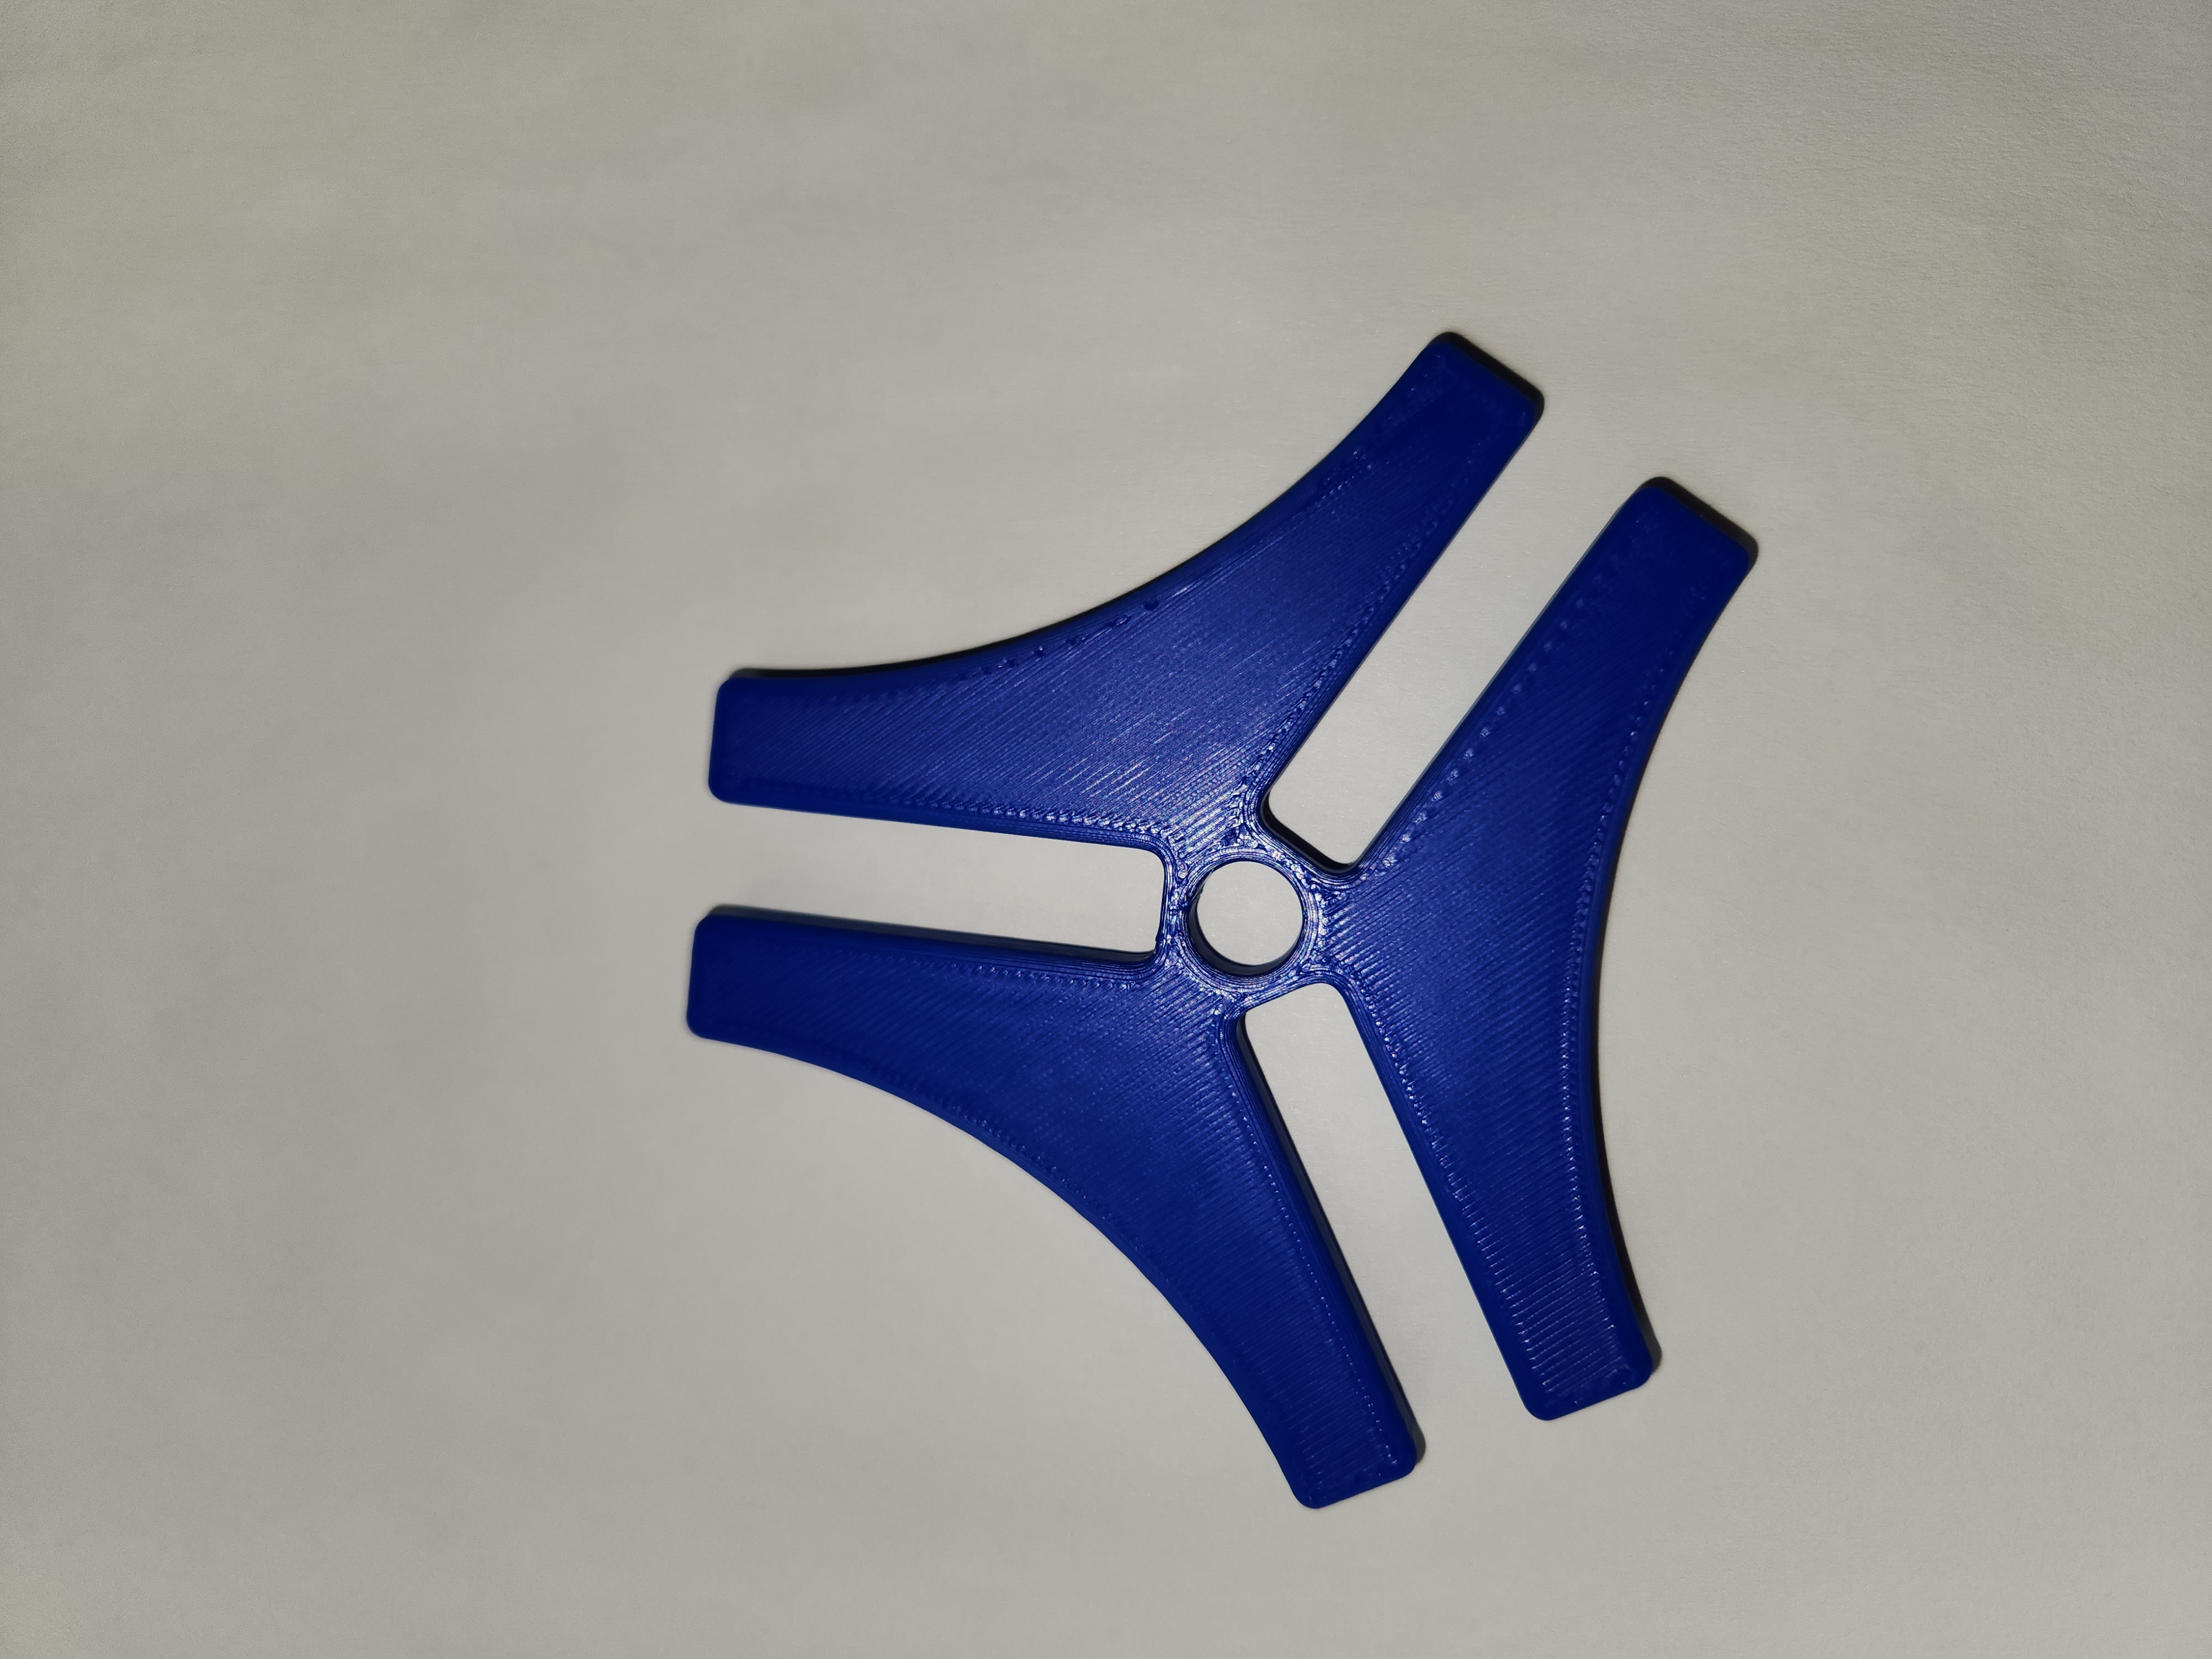
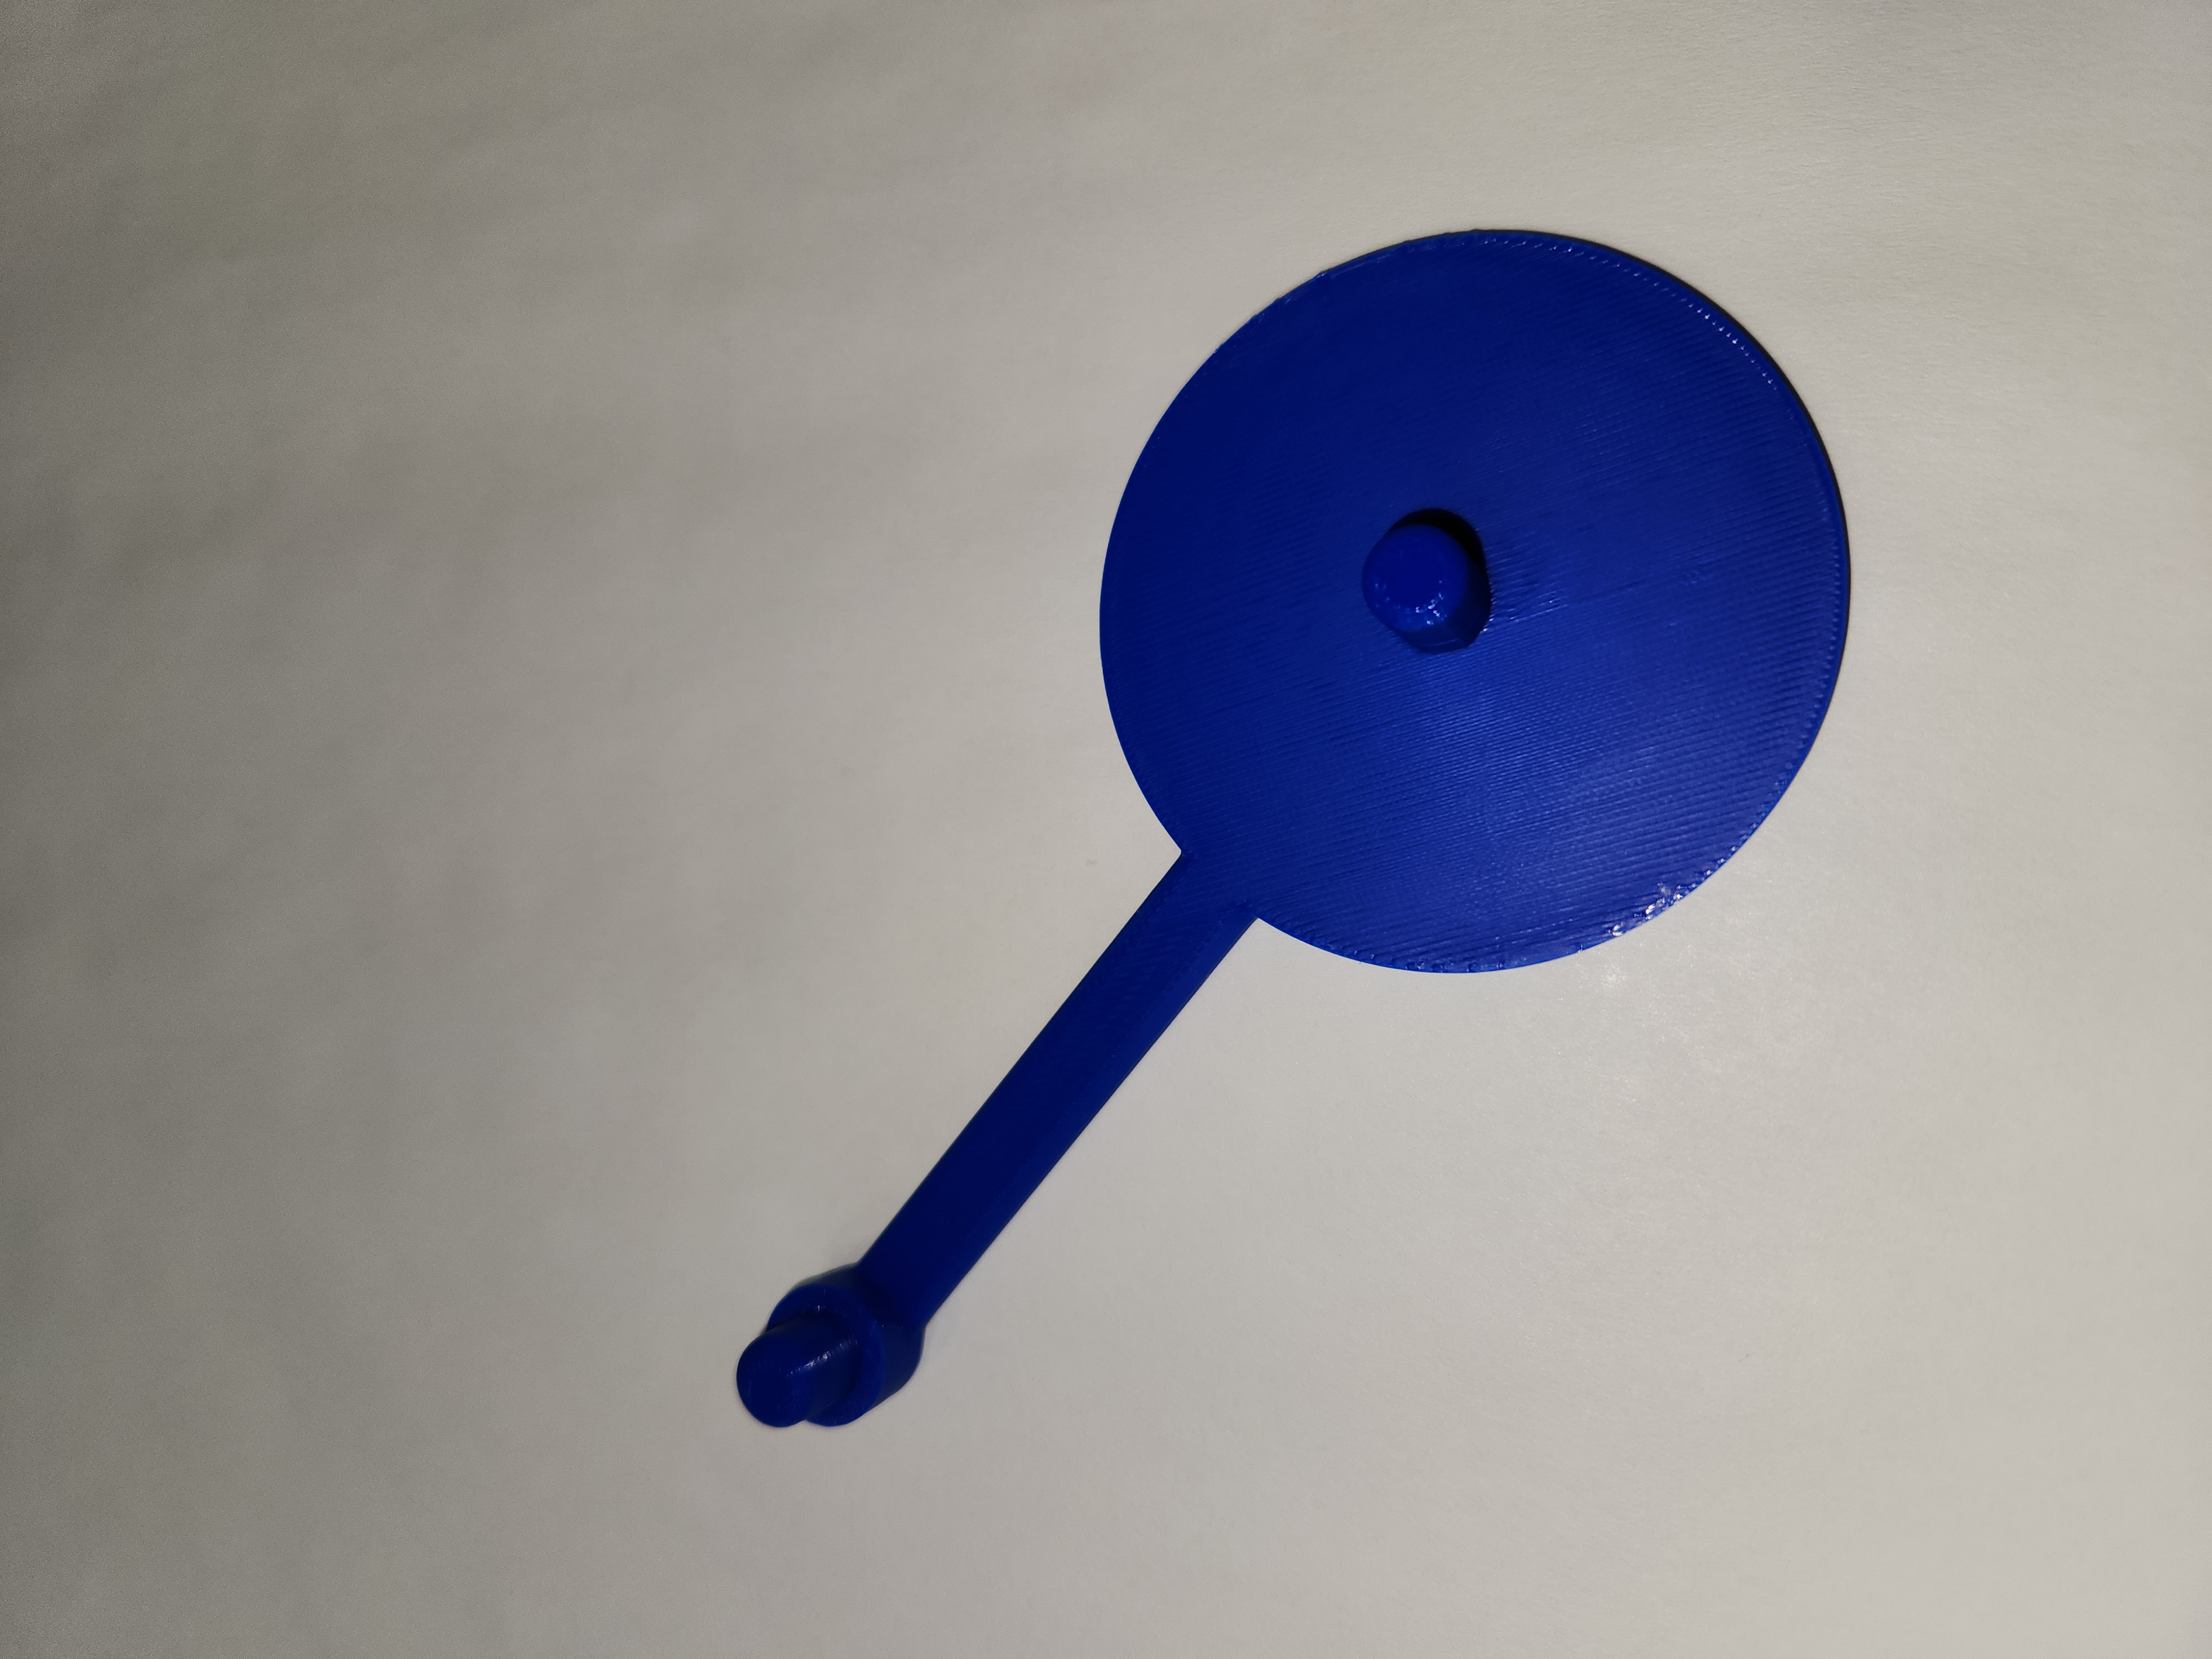
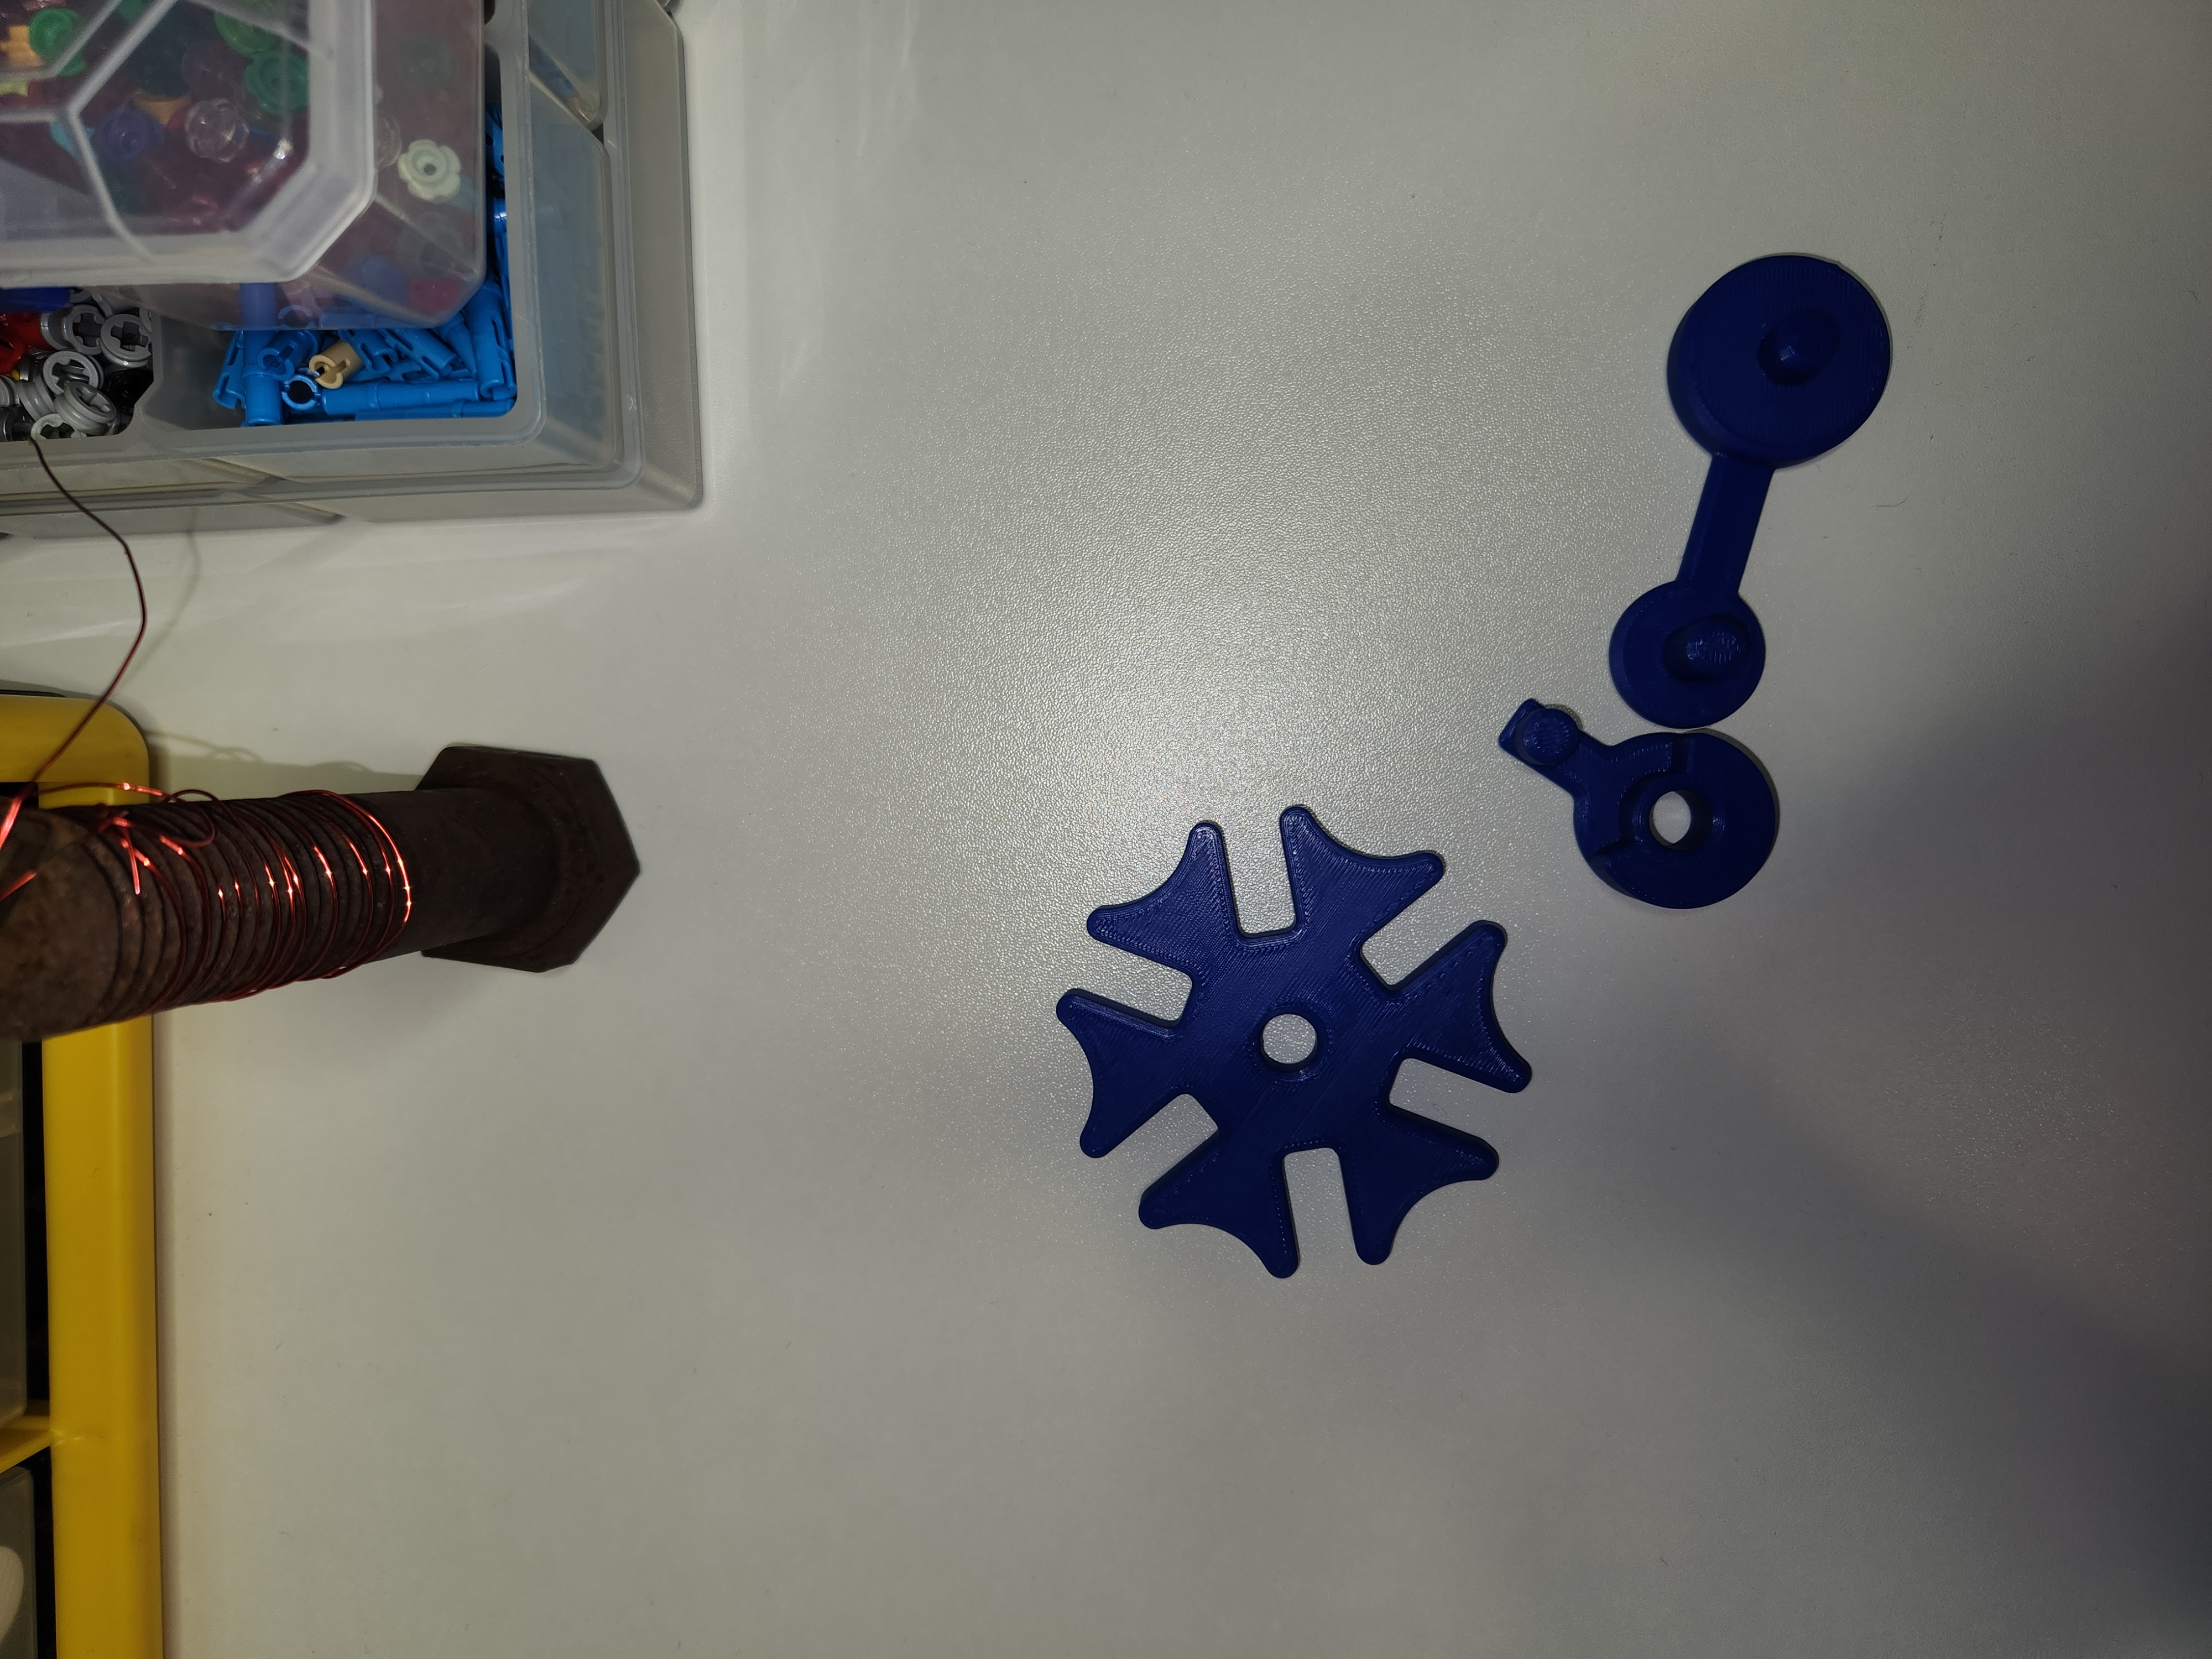
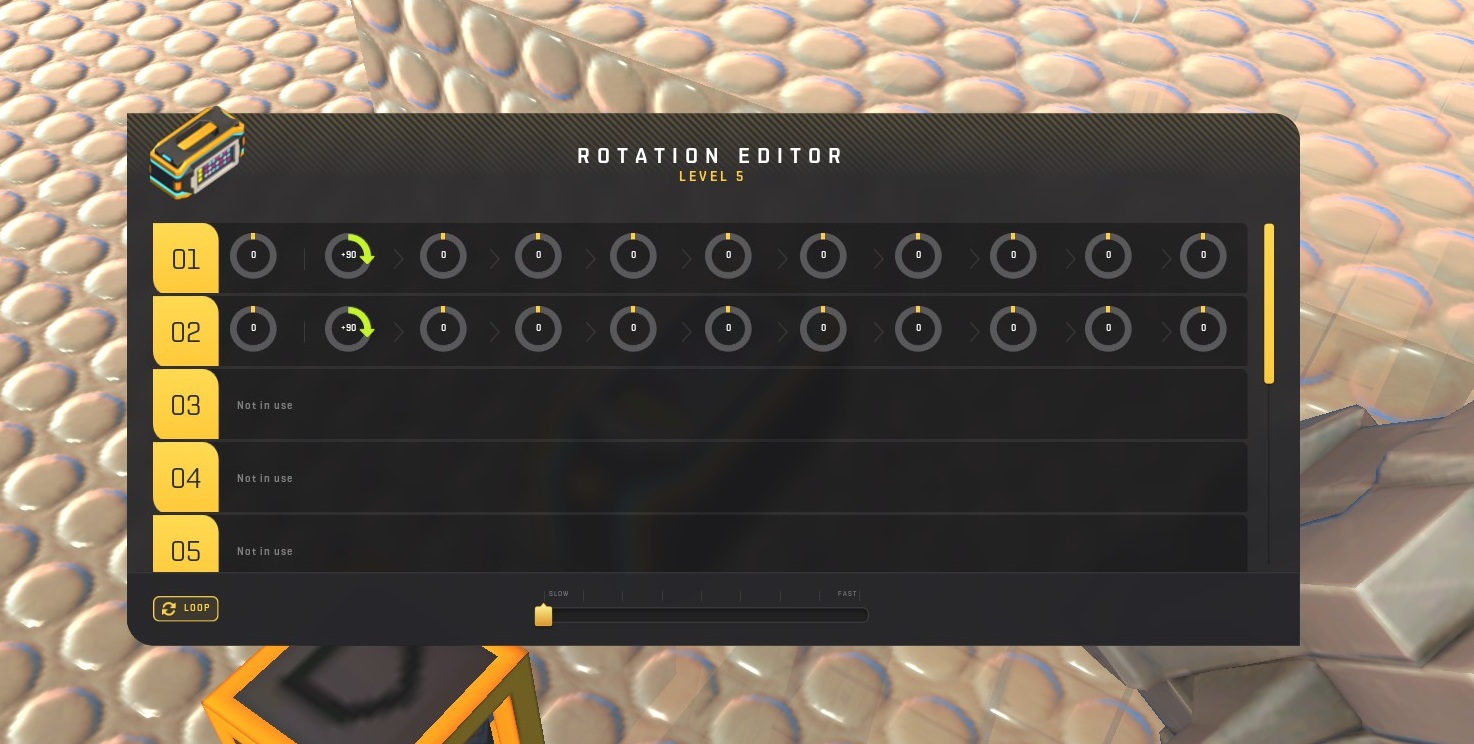
Rotation Sequencer
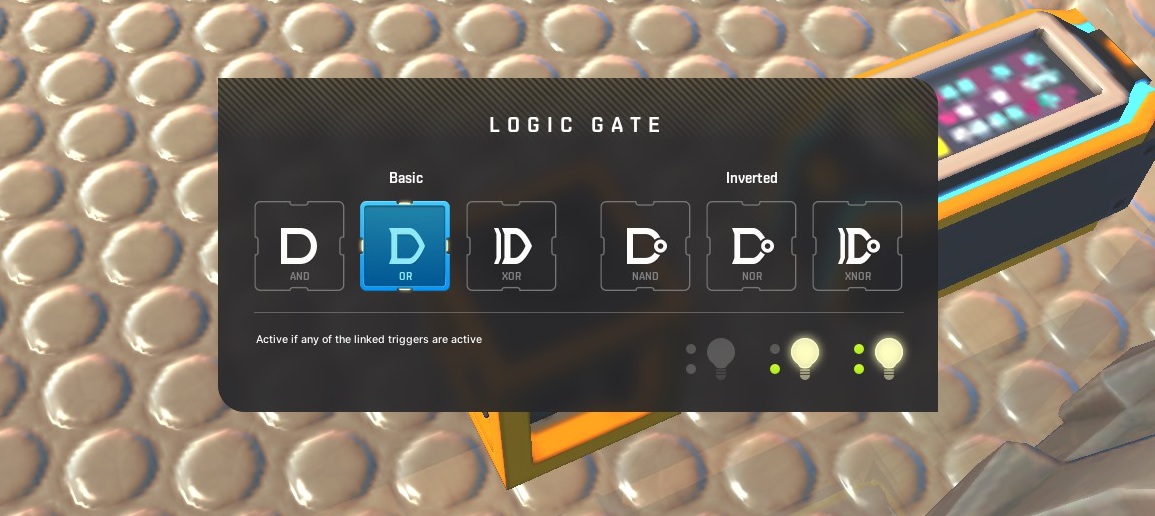
Logic Gates

Biomimetic Robotics & Logic-Driven Kinematics

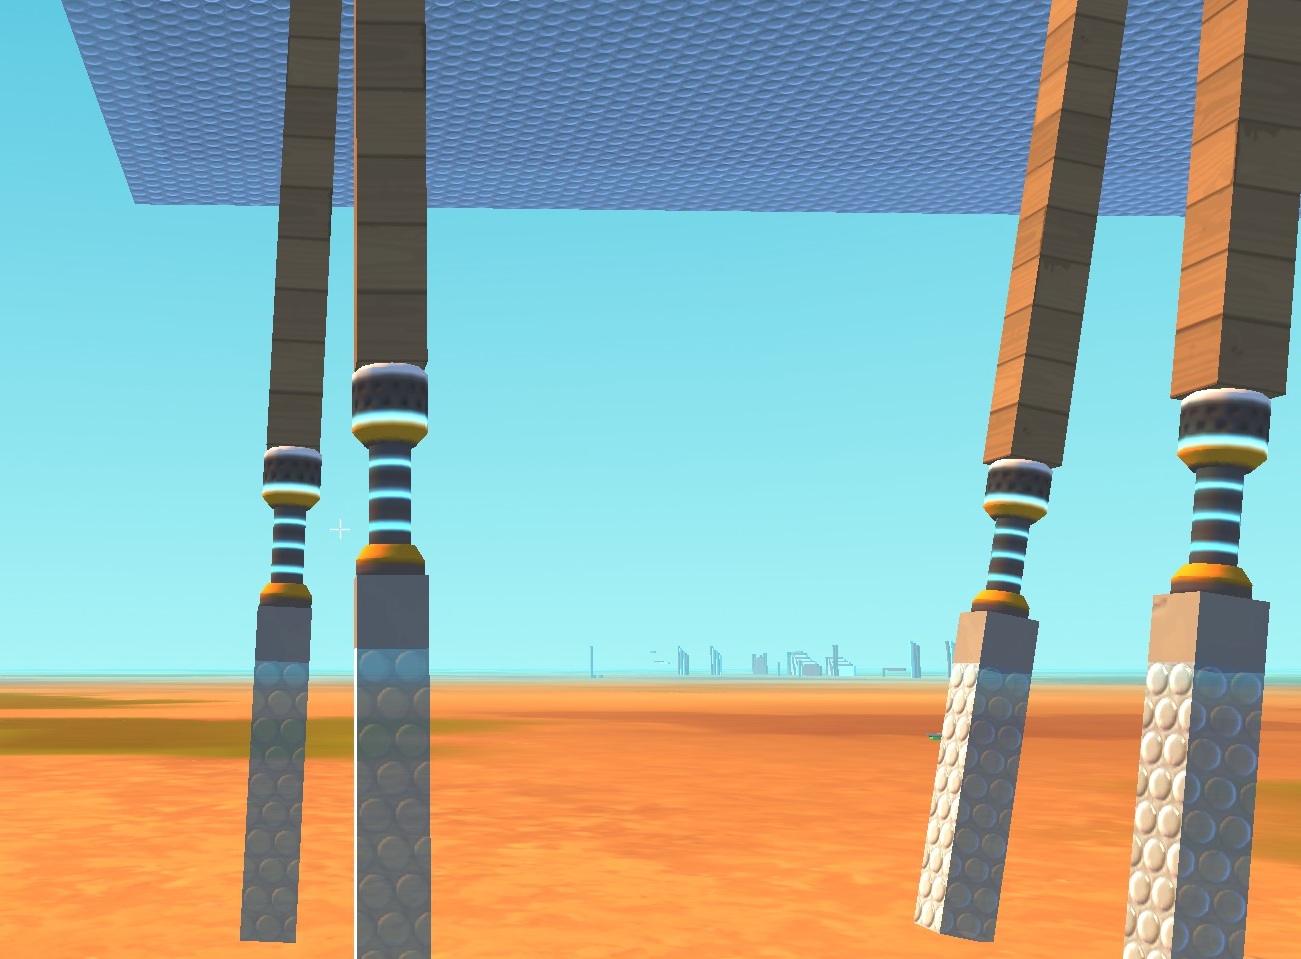
Designed a multi-legged walking mechanism integrating sequential rotation matrices and an on-board digital logic array to coordinate joint phase shifts. This mechatronic system synchronizes mechanical linkages to translate rotary motion into a stable linear gait while optimizing runtime timing to prevent joint binding.

⚙️ Digital Logic Architecture
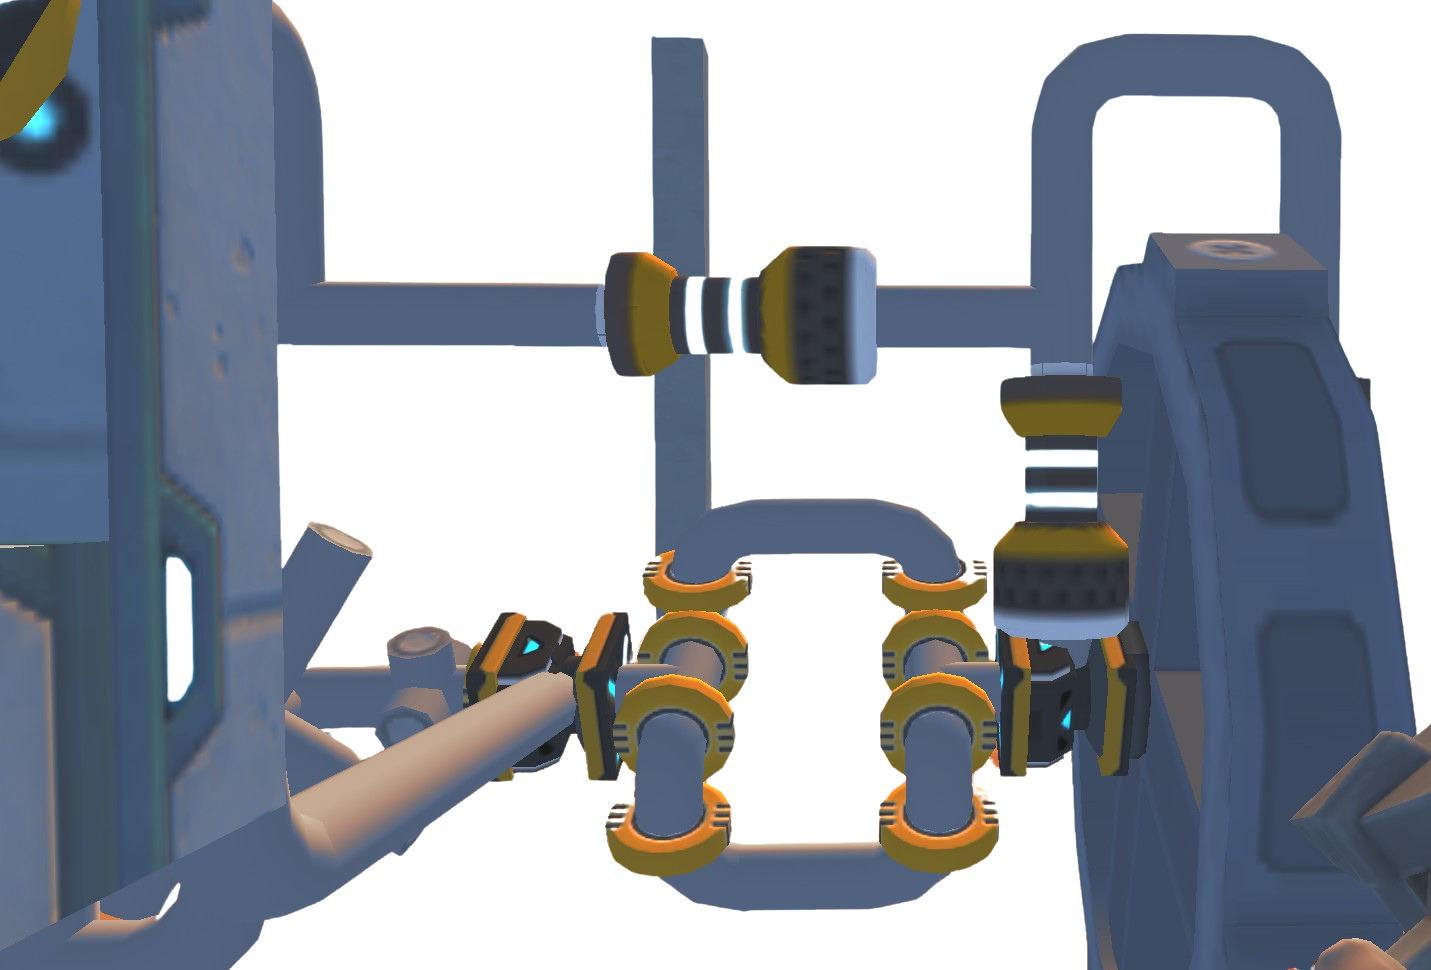
  • Boolean Gate Matrix: Configured standard logic gates (AND, OR, XOR, NAND) to handle state machines and control feedback loops.
  • Phase Shifting: Prevents opposing leg pairs from entering identical stride phases simultaneously.
🔧 Sequential Multi-Axis Actuation
  • Functions exactly like a real-world programmable microcontroller (e.g. Arduino) to time specific rotational angles of hip and knee joints during walking cycles.
Fluid Dynamics & Kinematics
🌪️ Headwind Propulsion Multi-Blade Turbine 90° Bevel Gearbox Spur Reduction Stage Universal Joint Linkage
🌪️ LIVE TEST: HEADWIND TRAVERSAL (15s)
Wind-Powered Kinematic Transport Prototype
▶
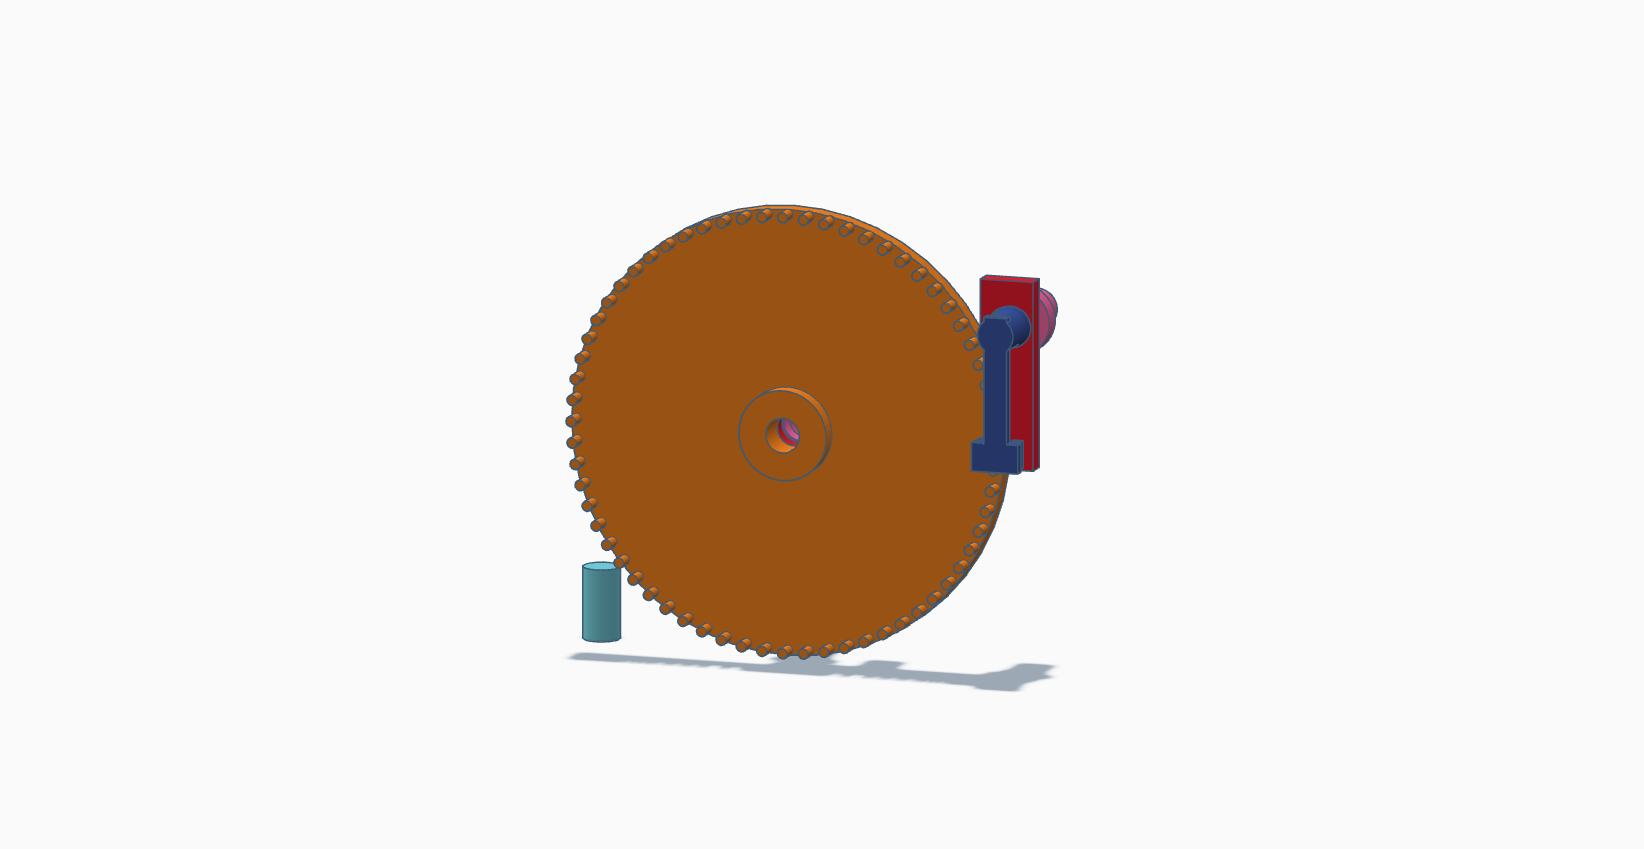
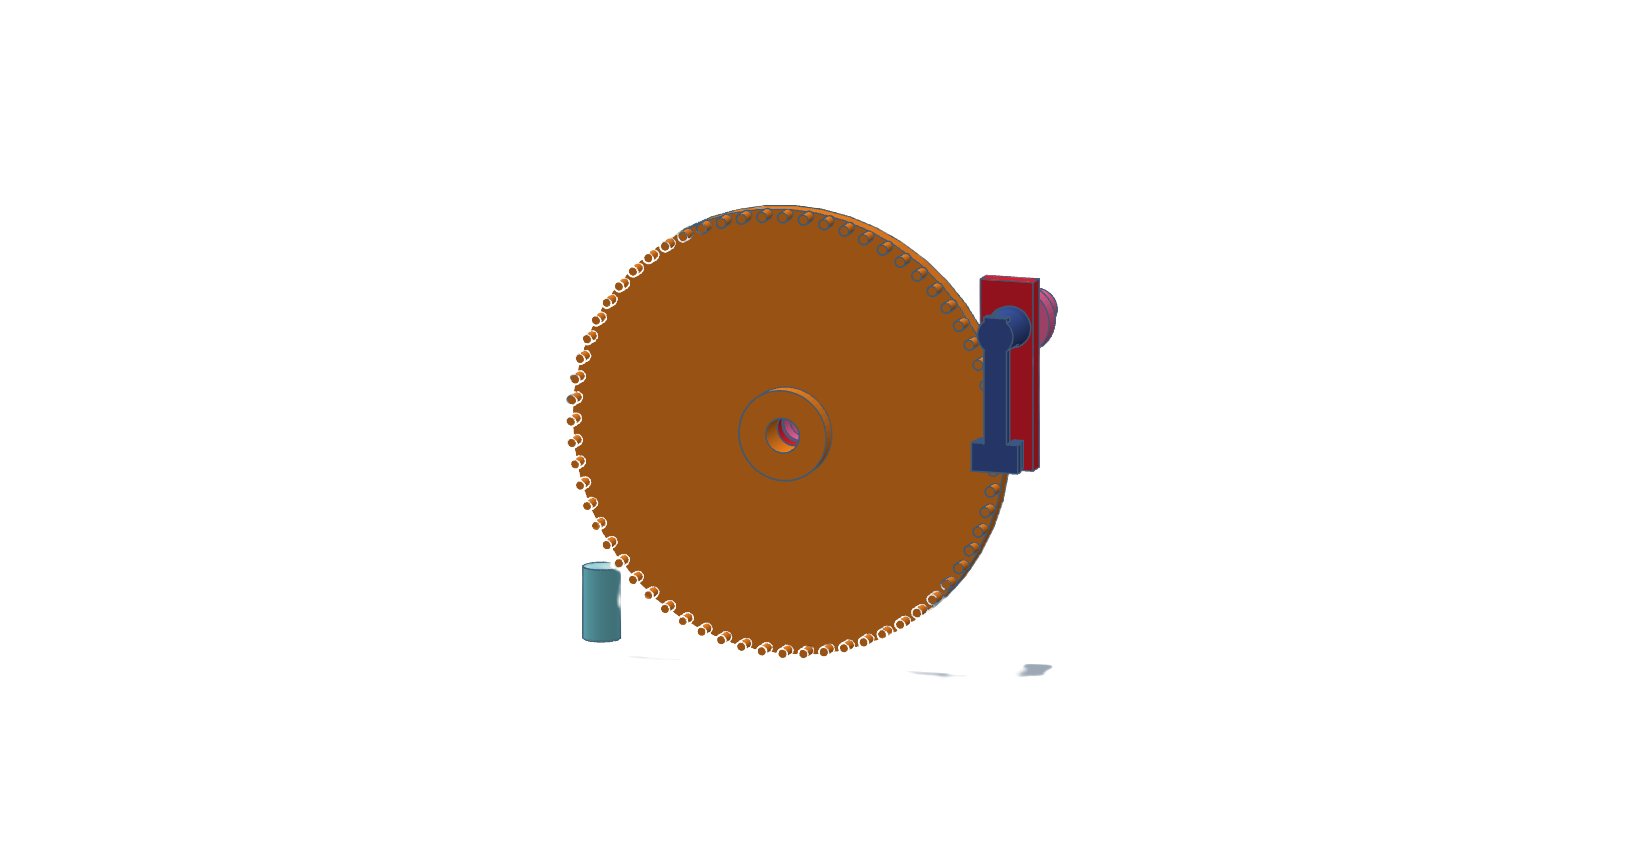
Lower Drivetrain Gear Mesh
Bevel Gear Transmission
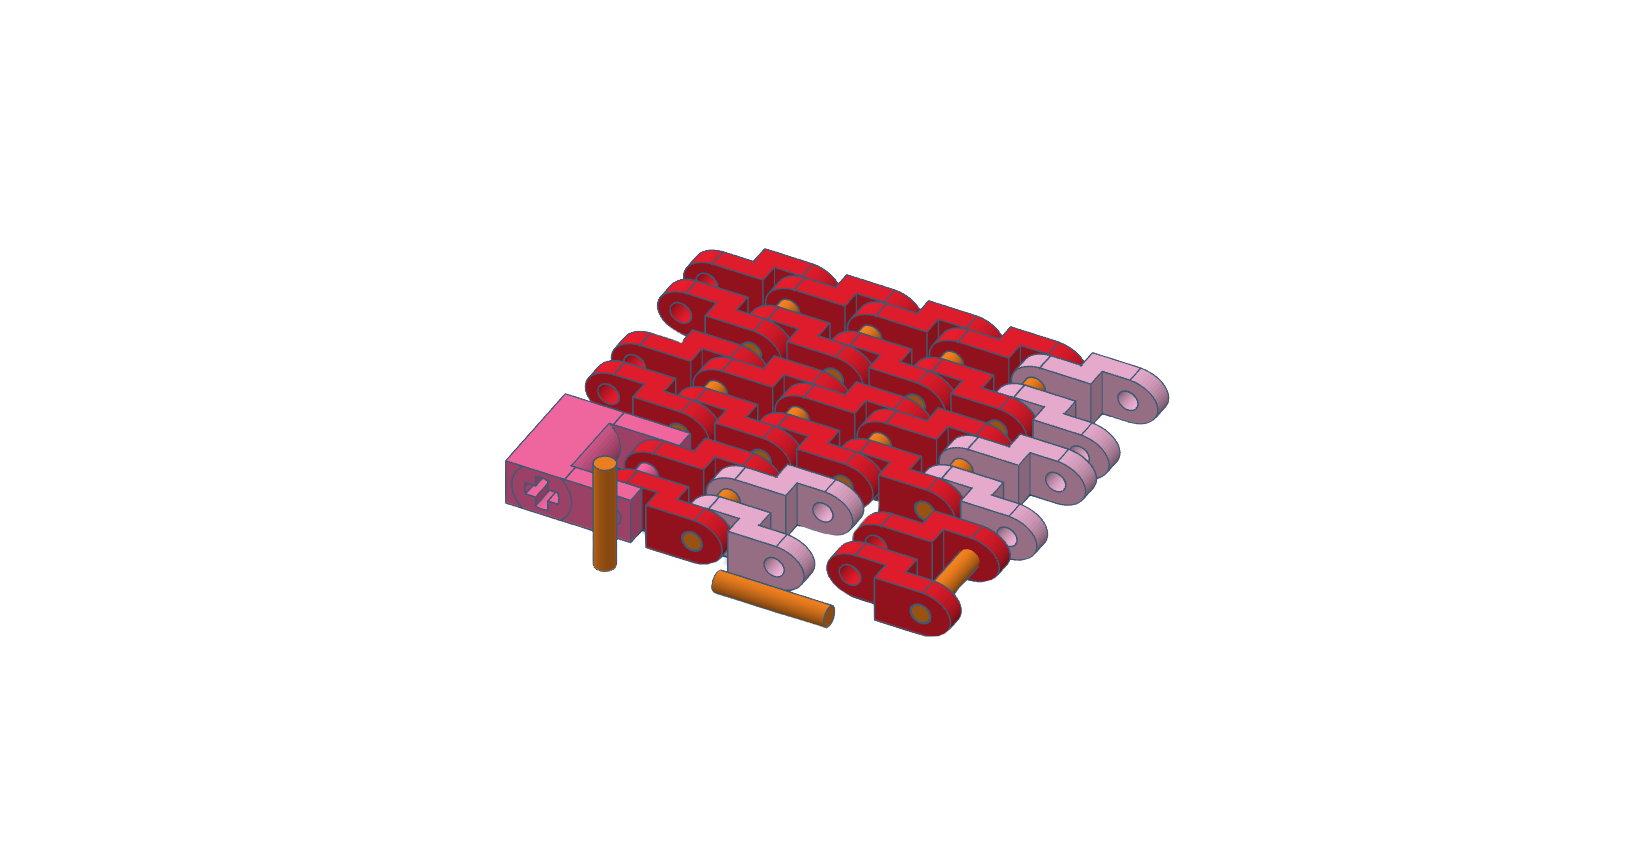
Universal Joint Linkage
Lower Drivetrain Assembly
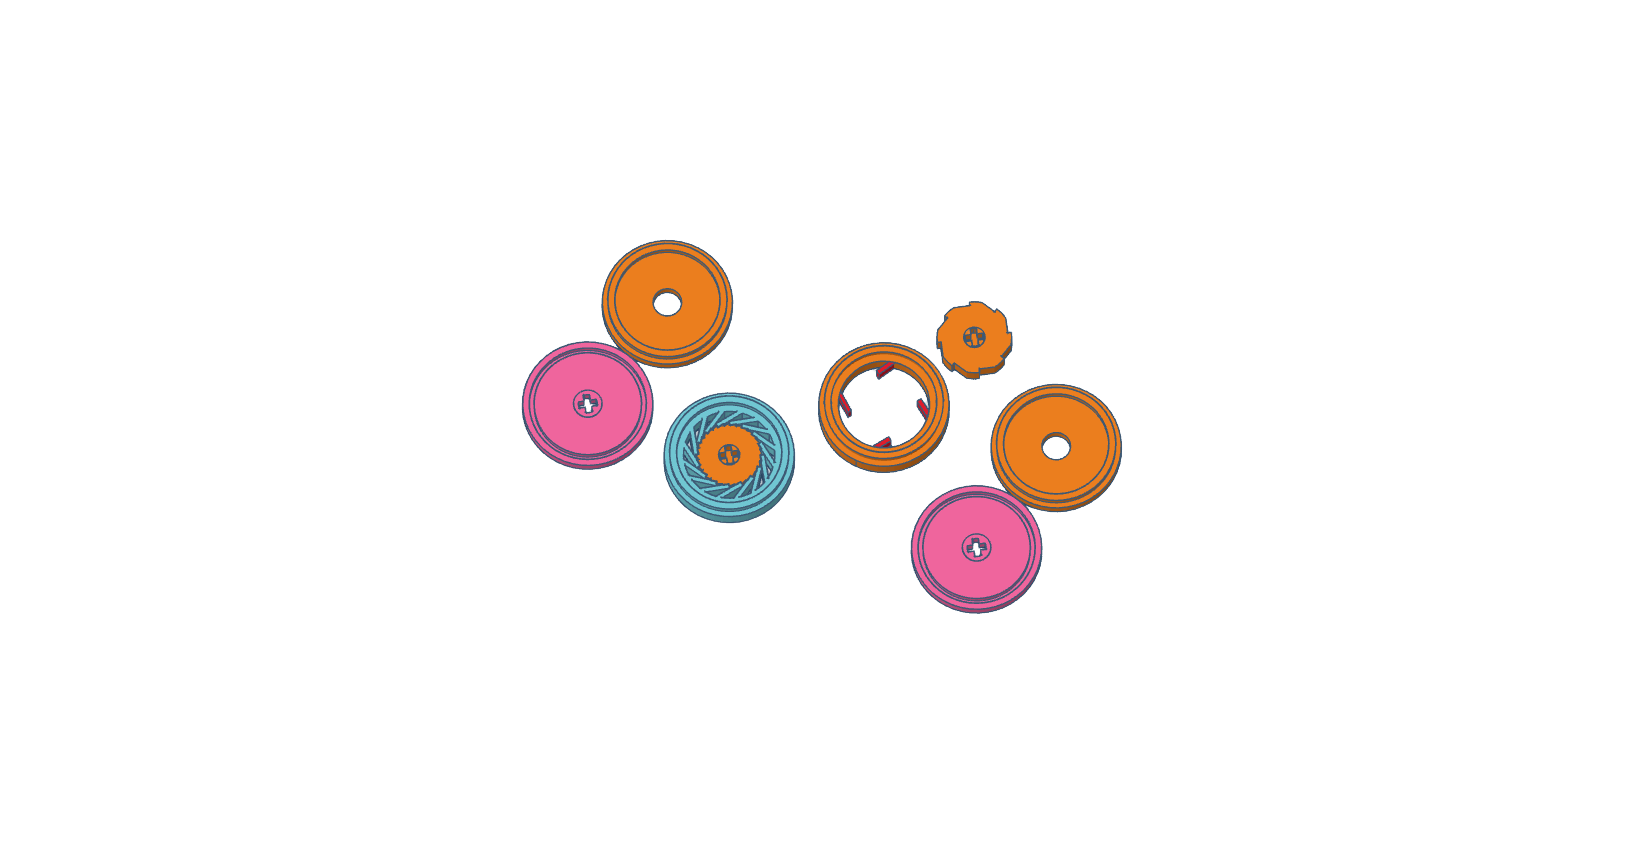
Bevel Gear Box
Universal Joint
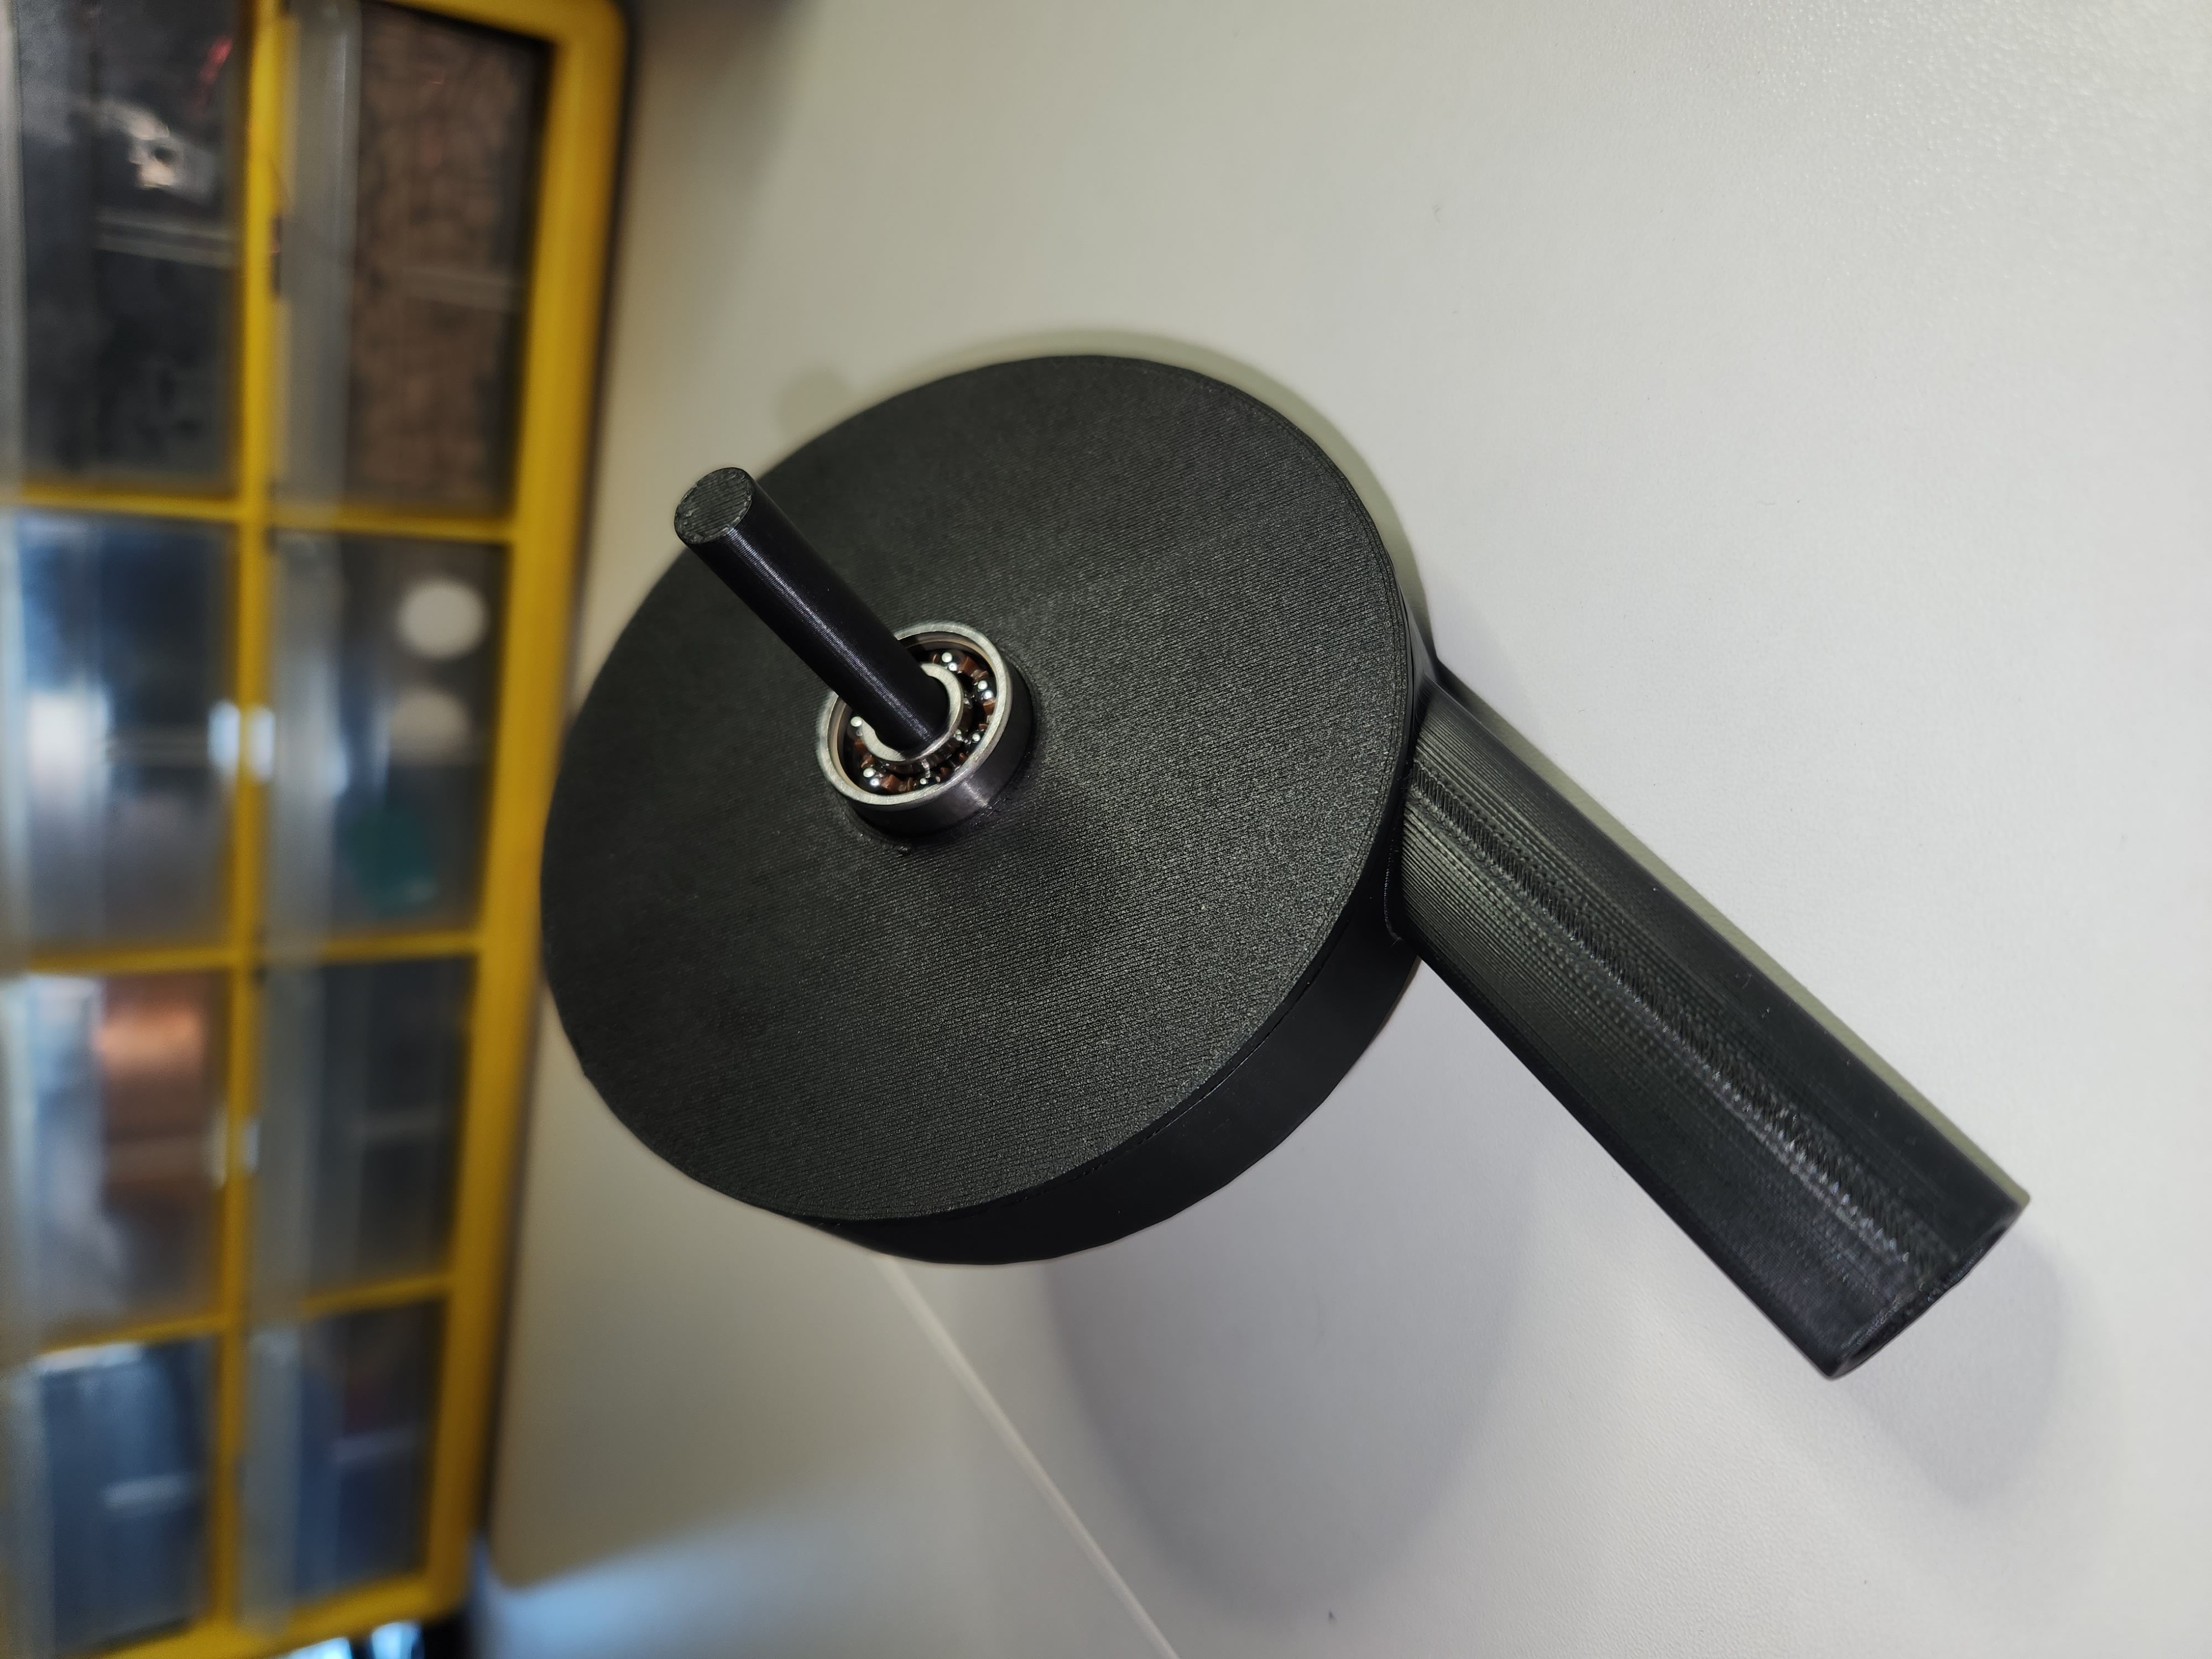
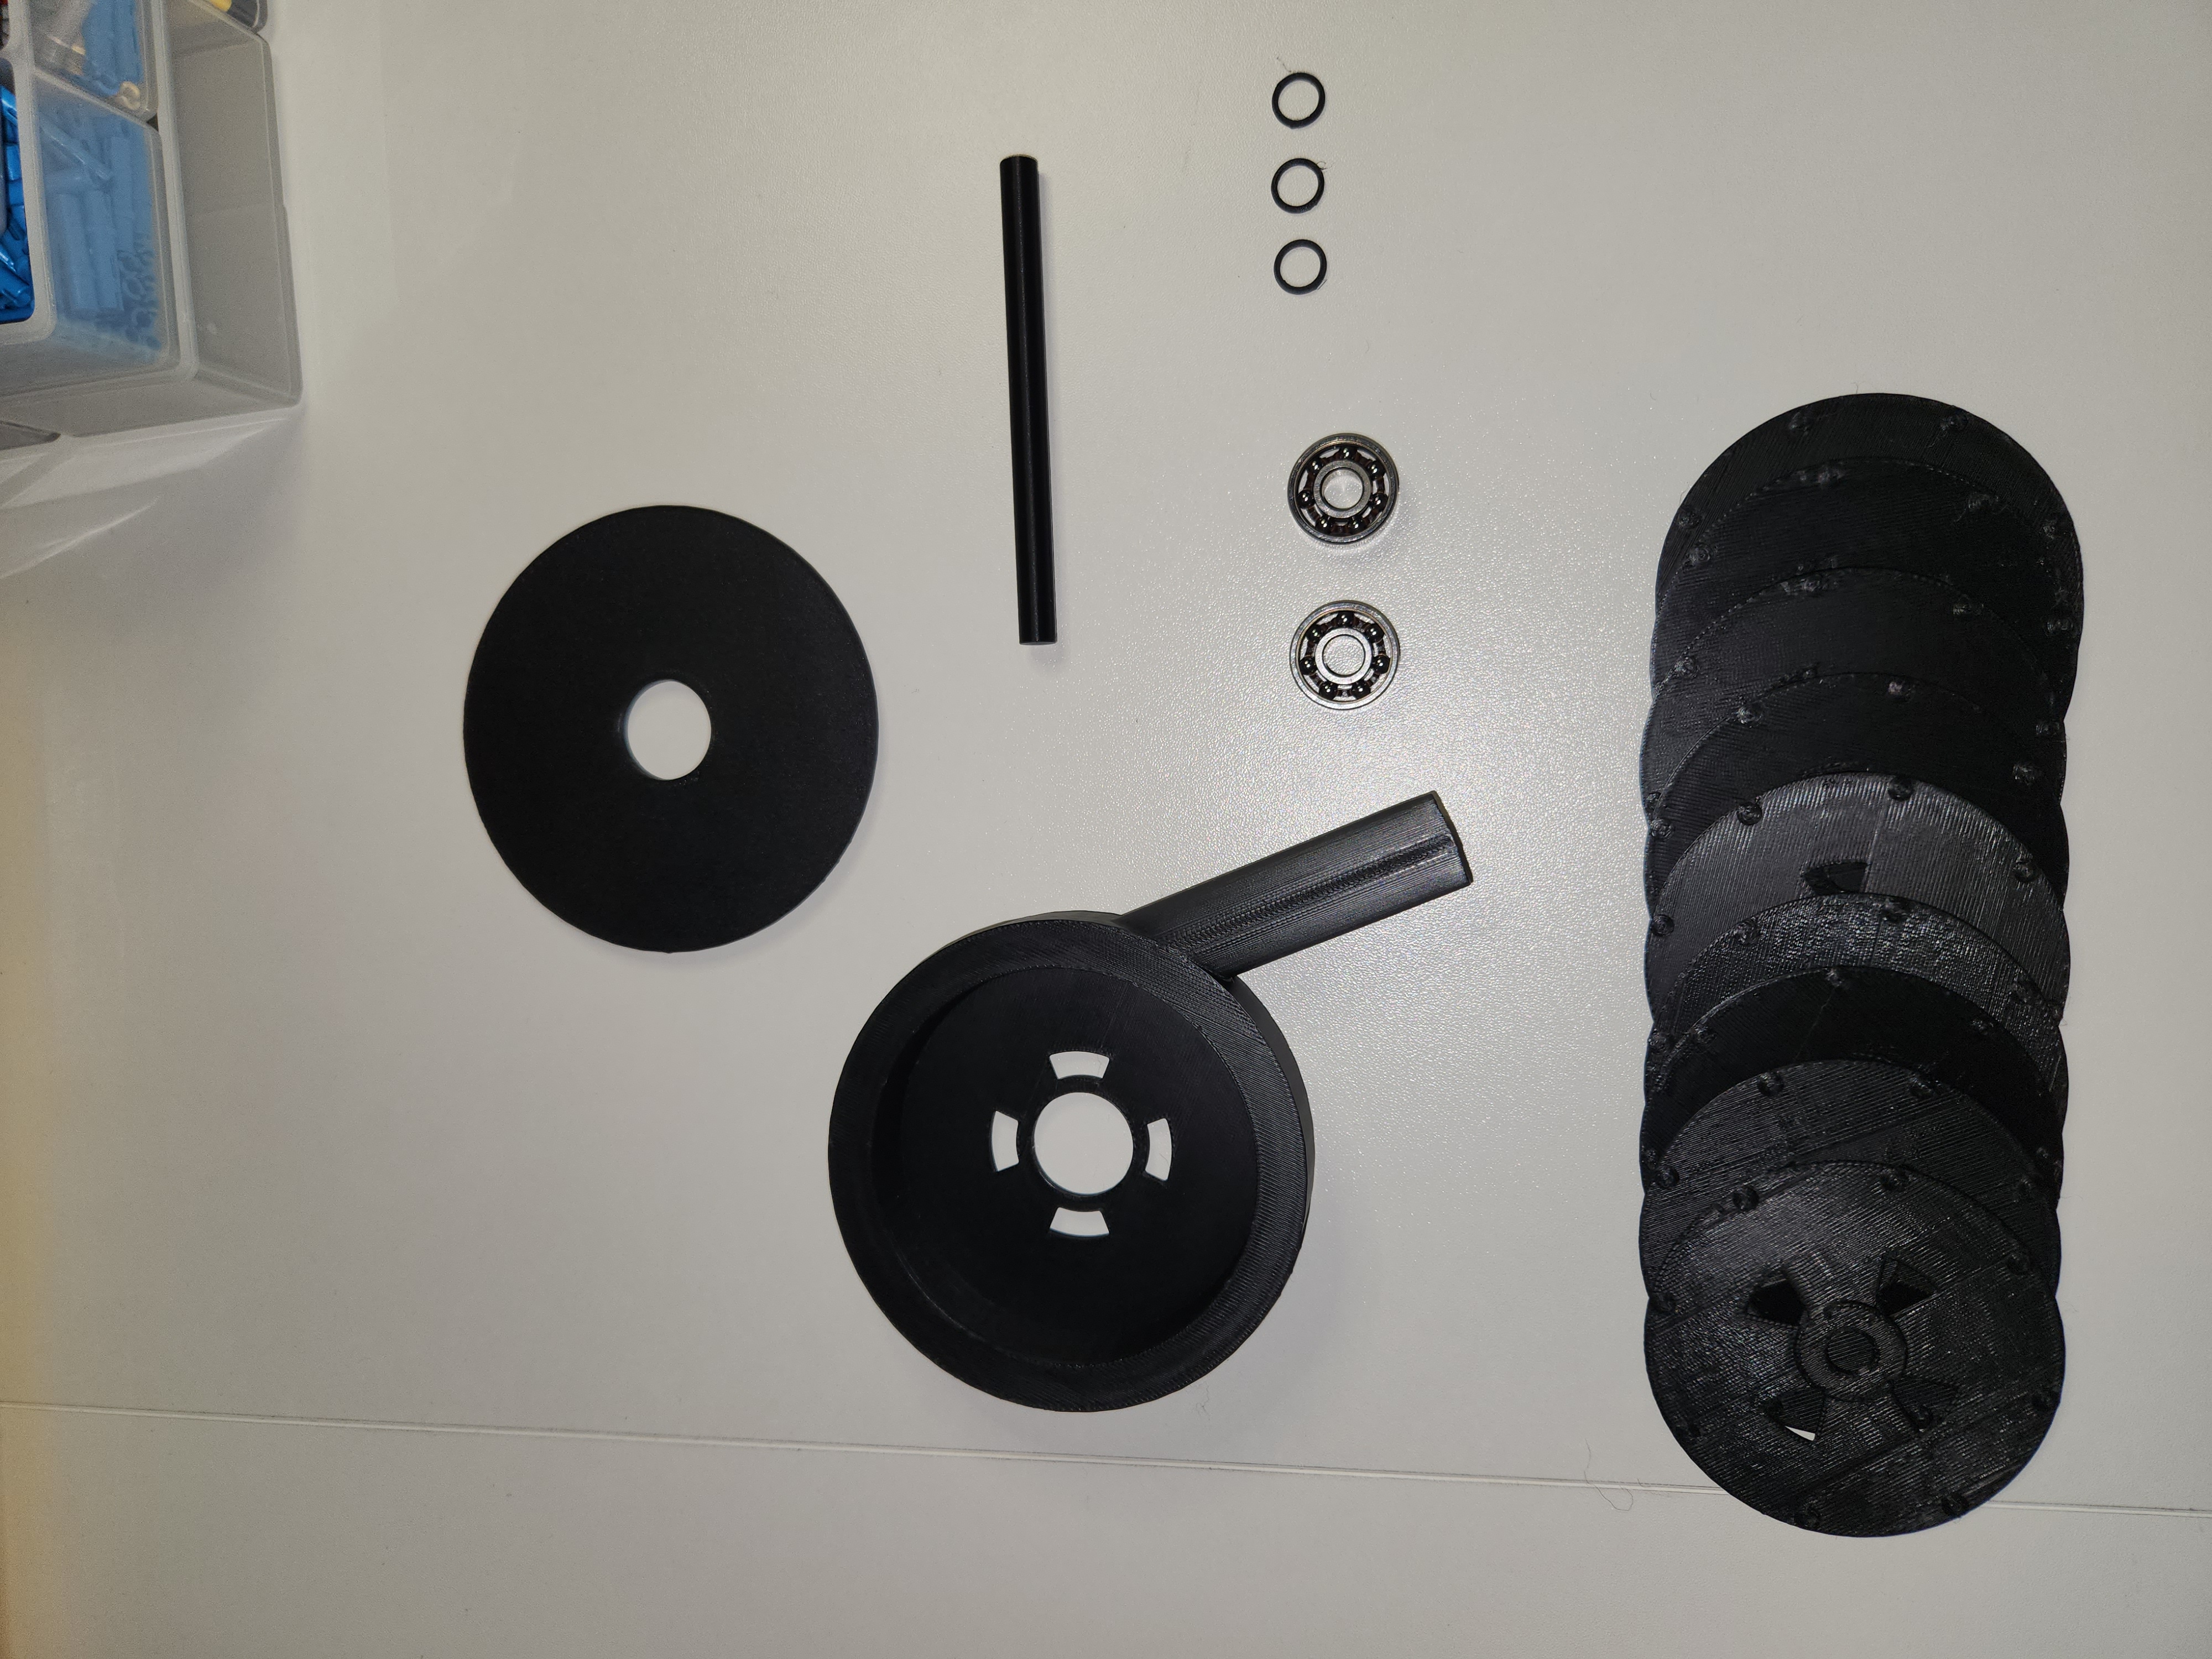
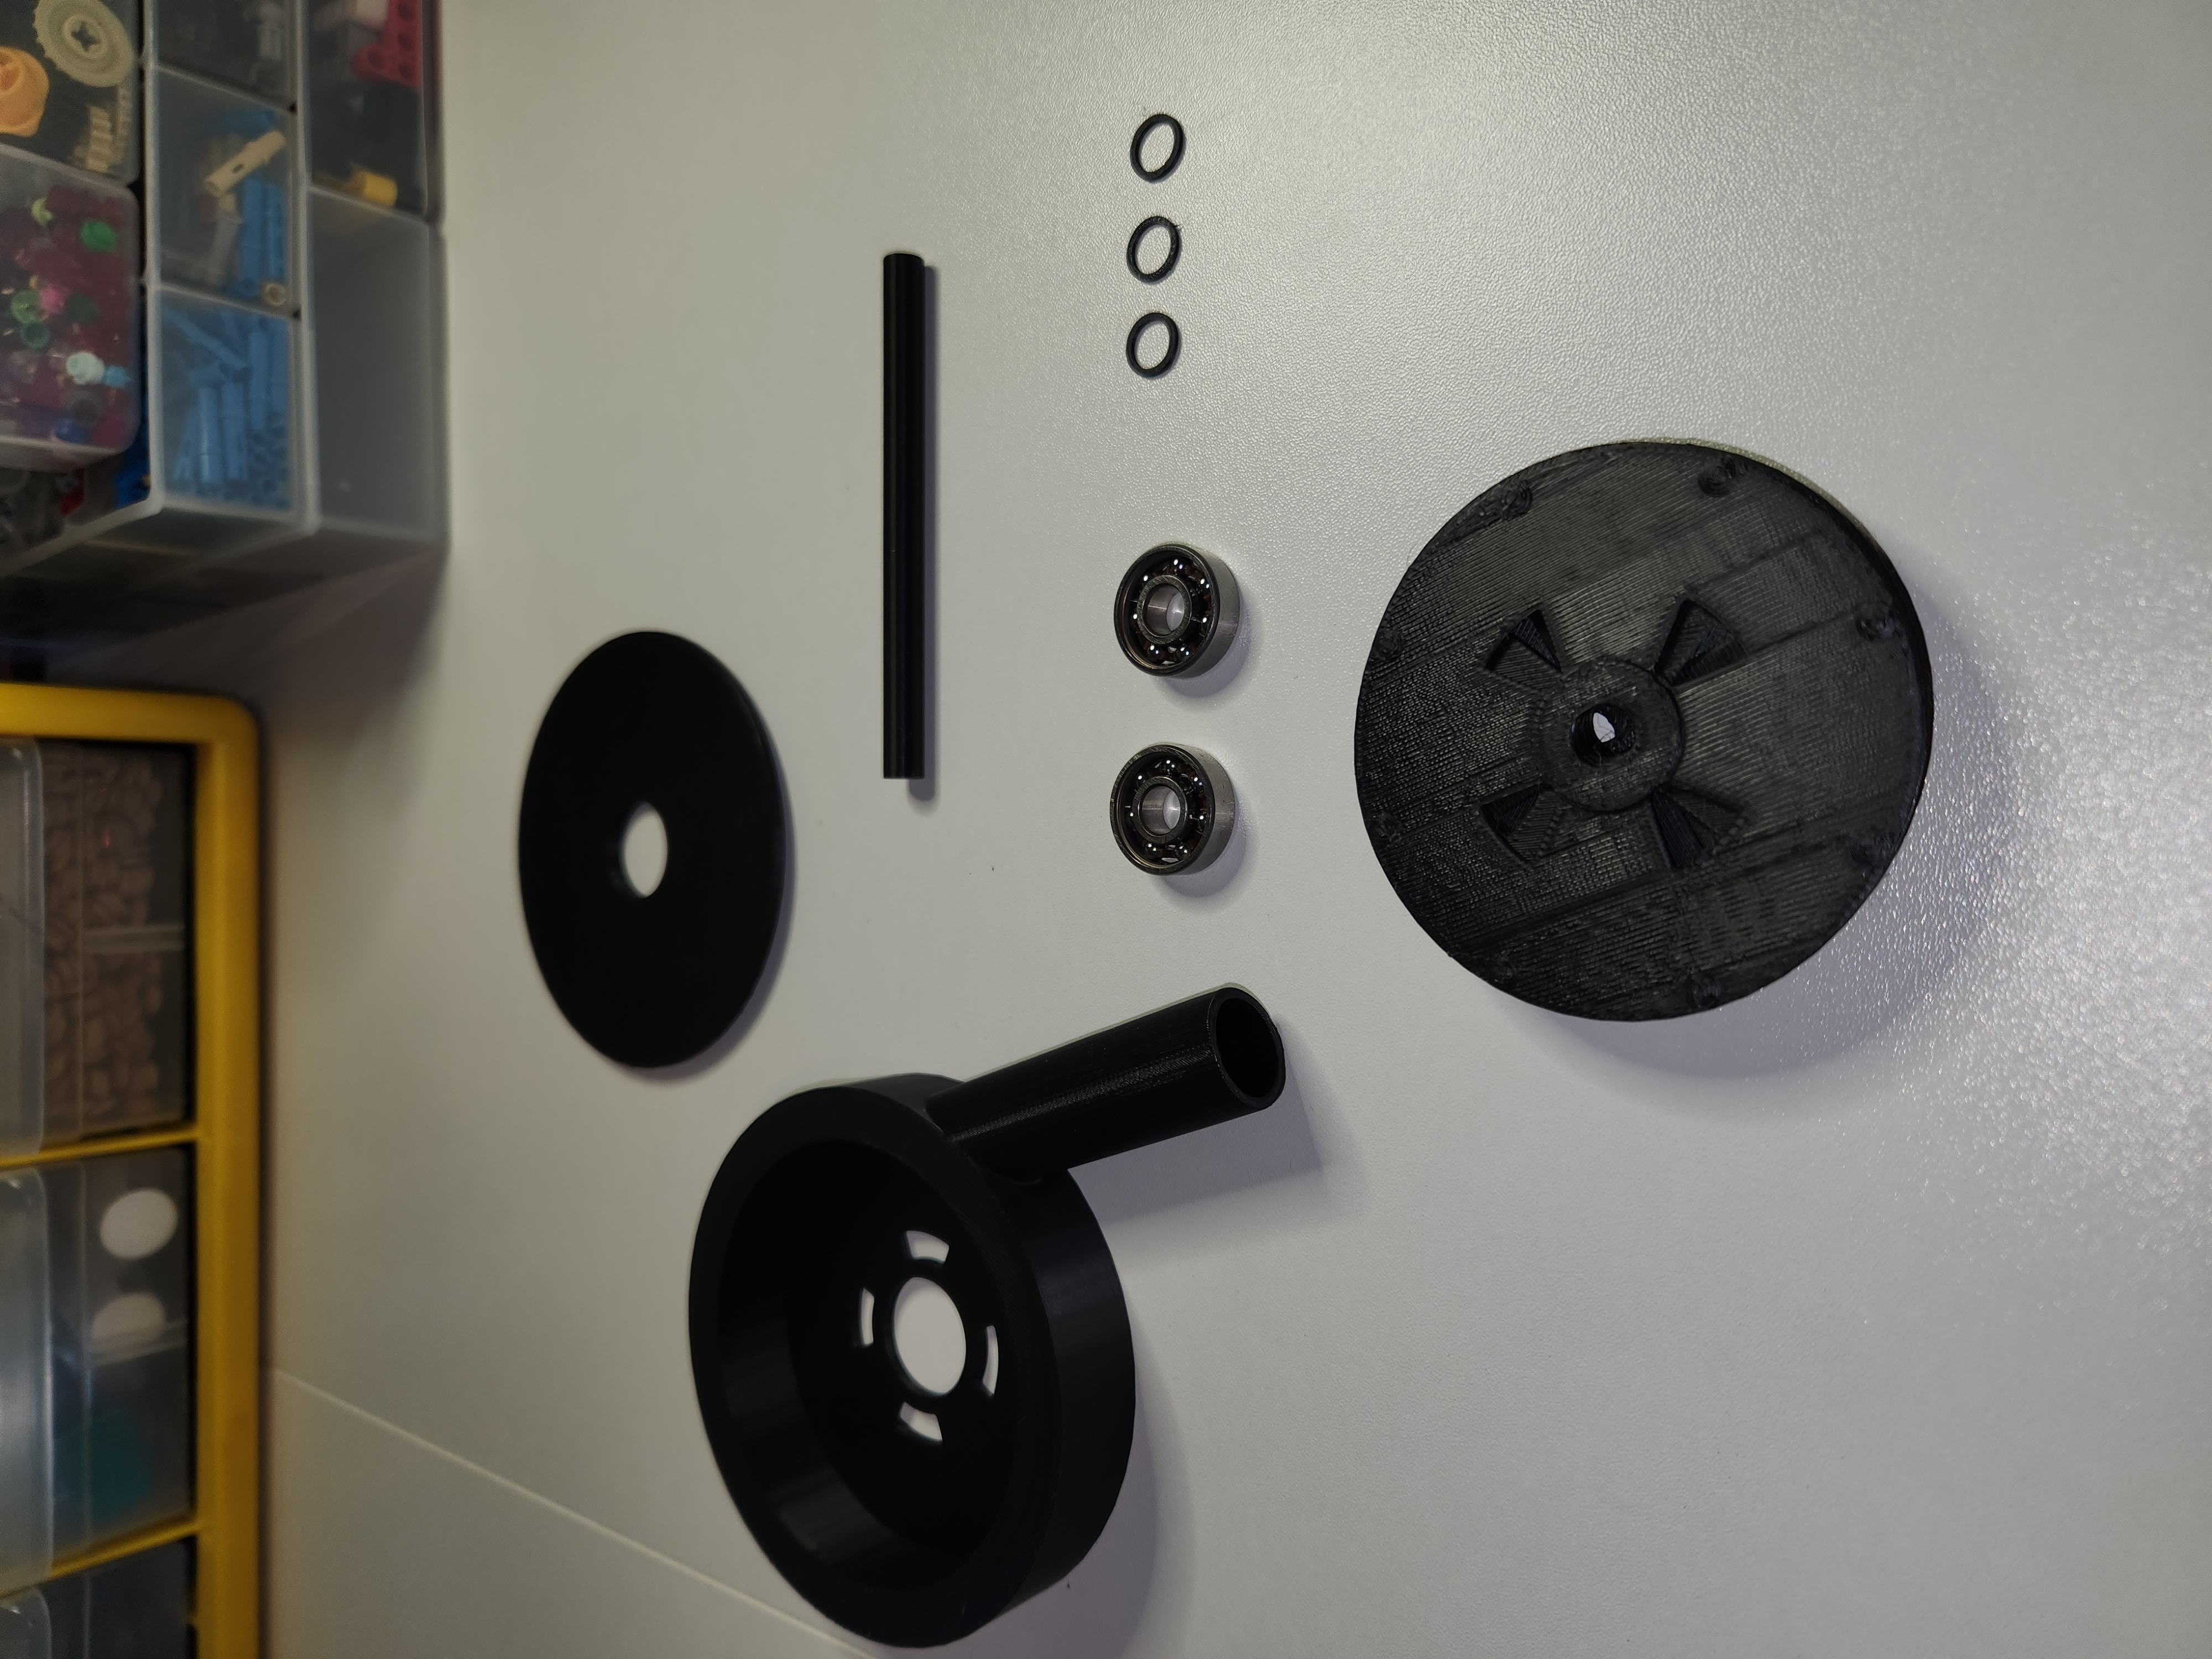
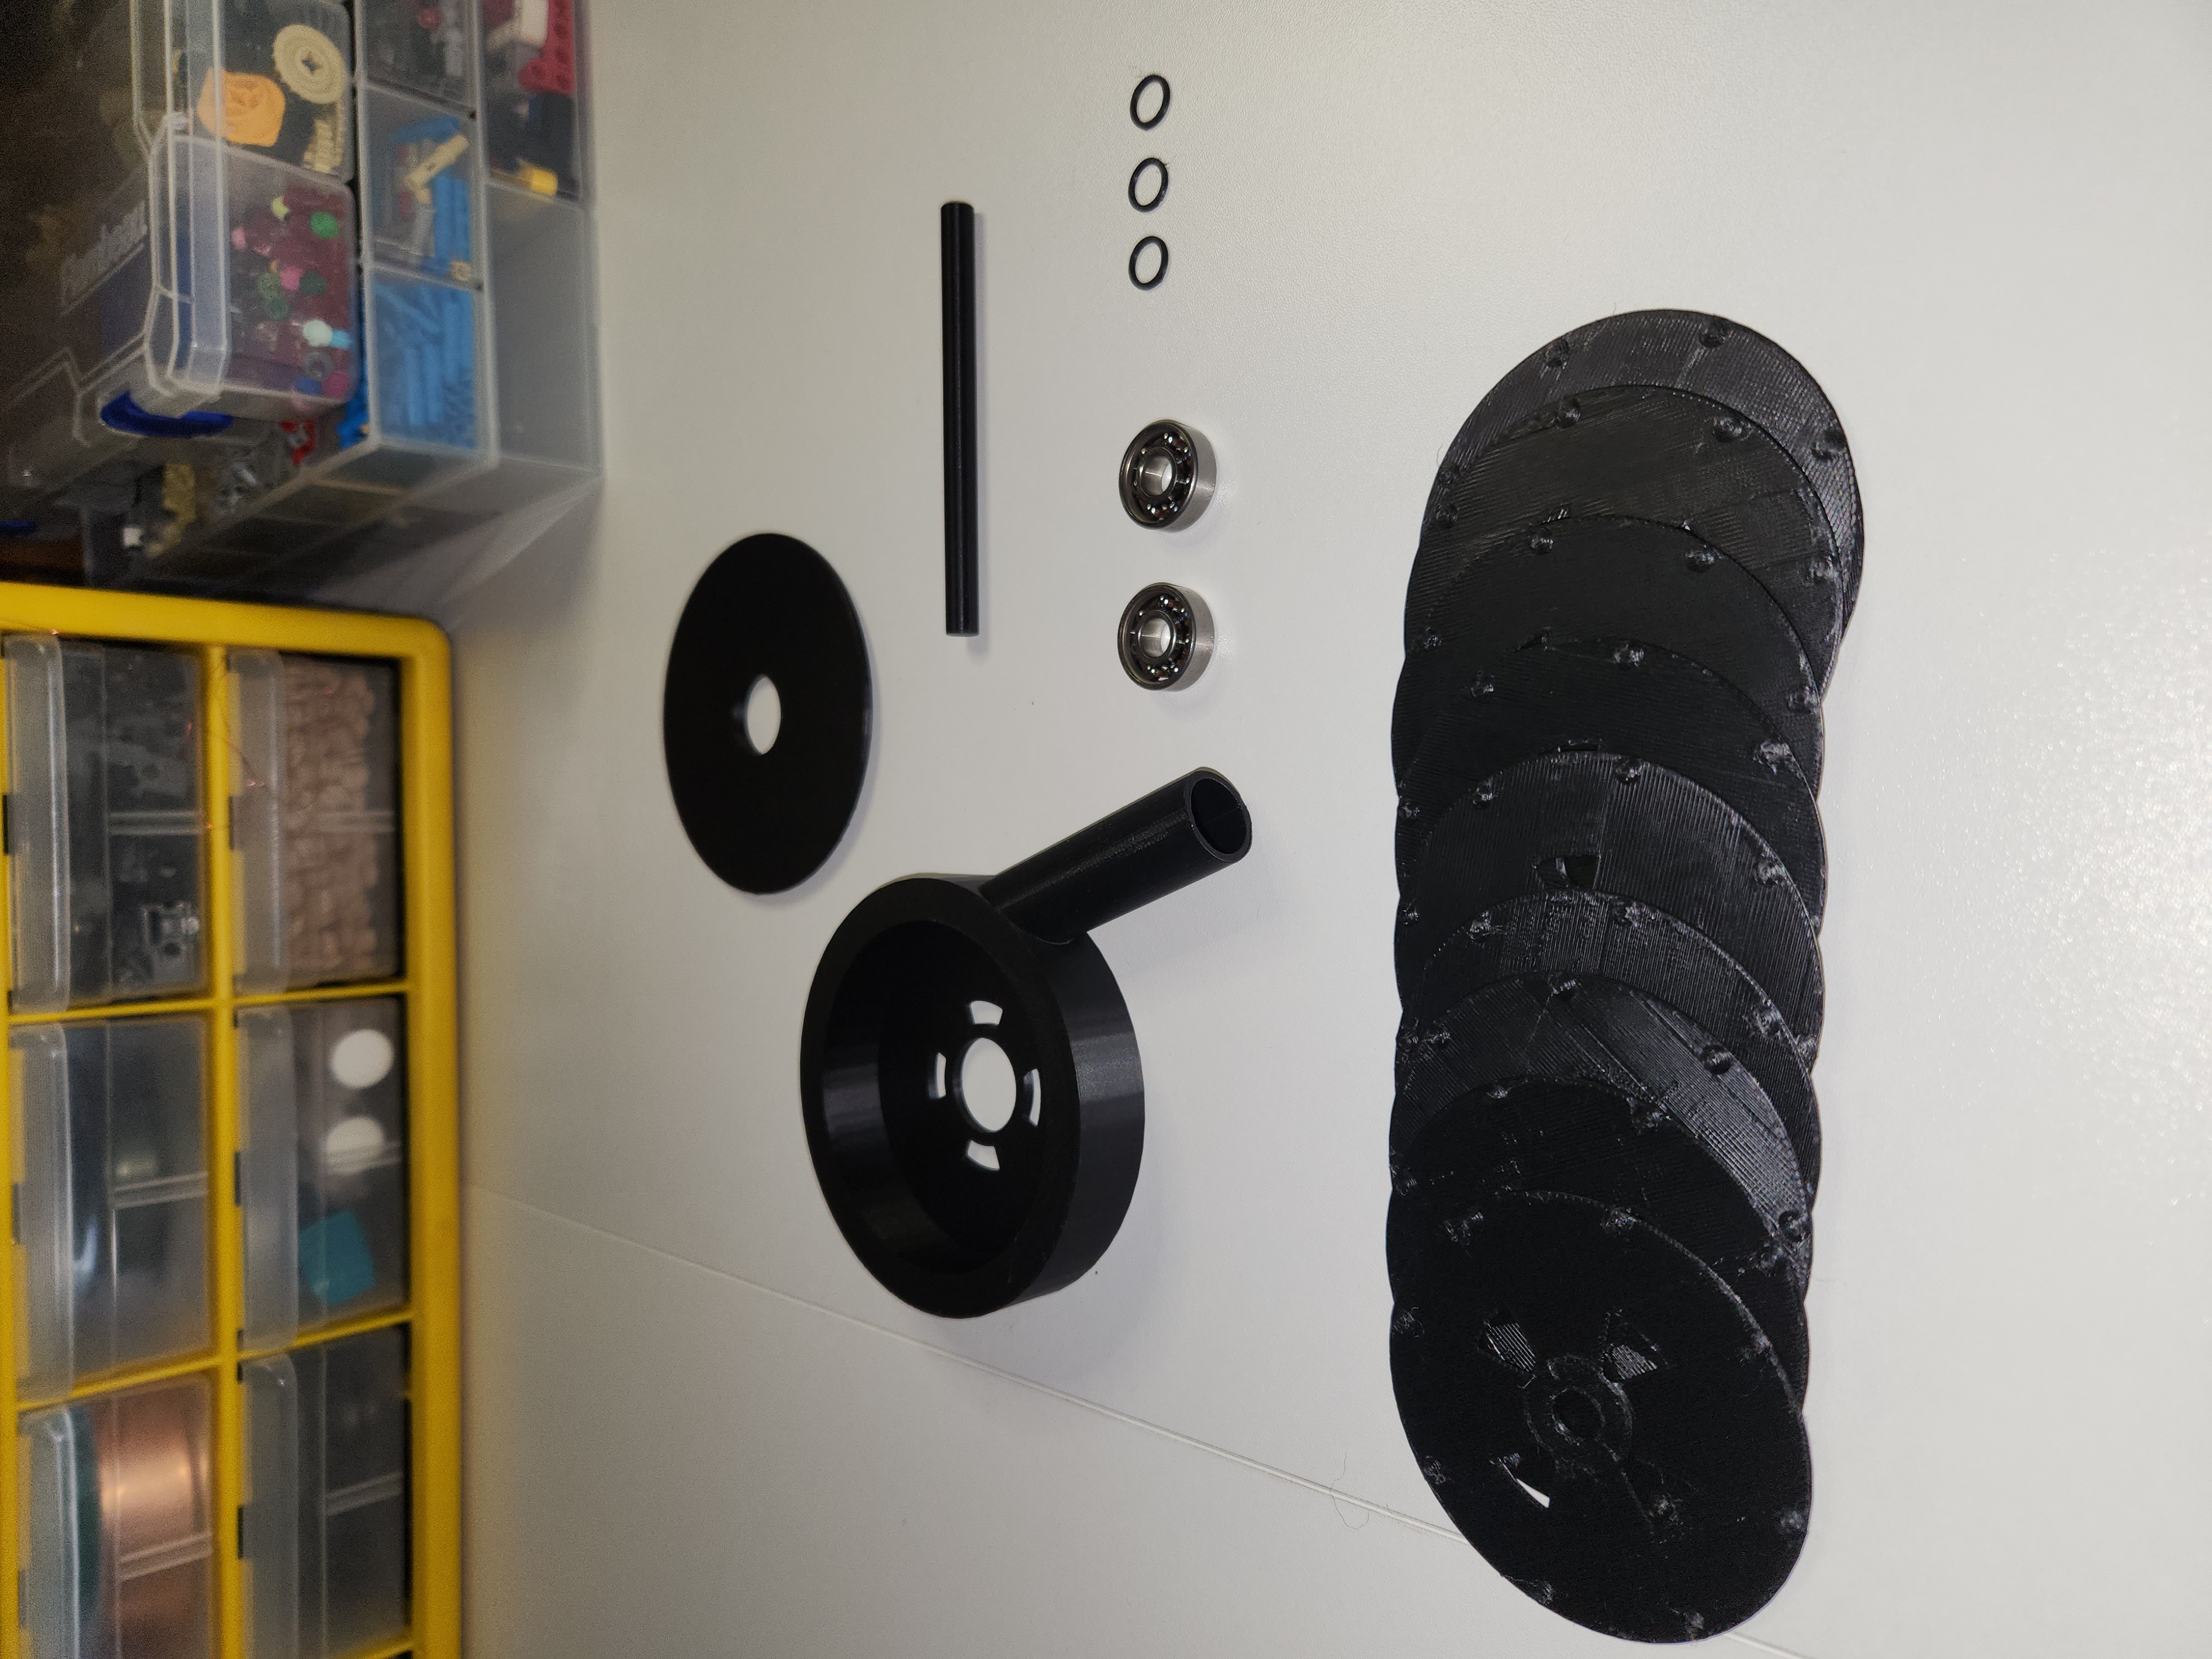
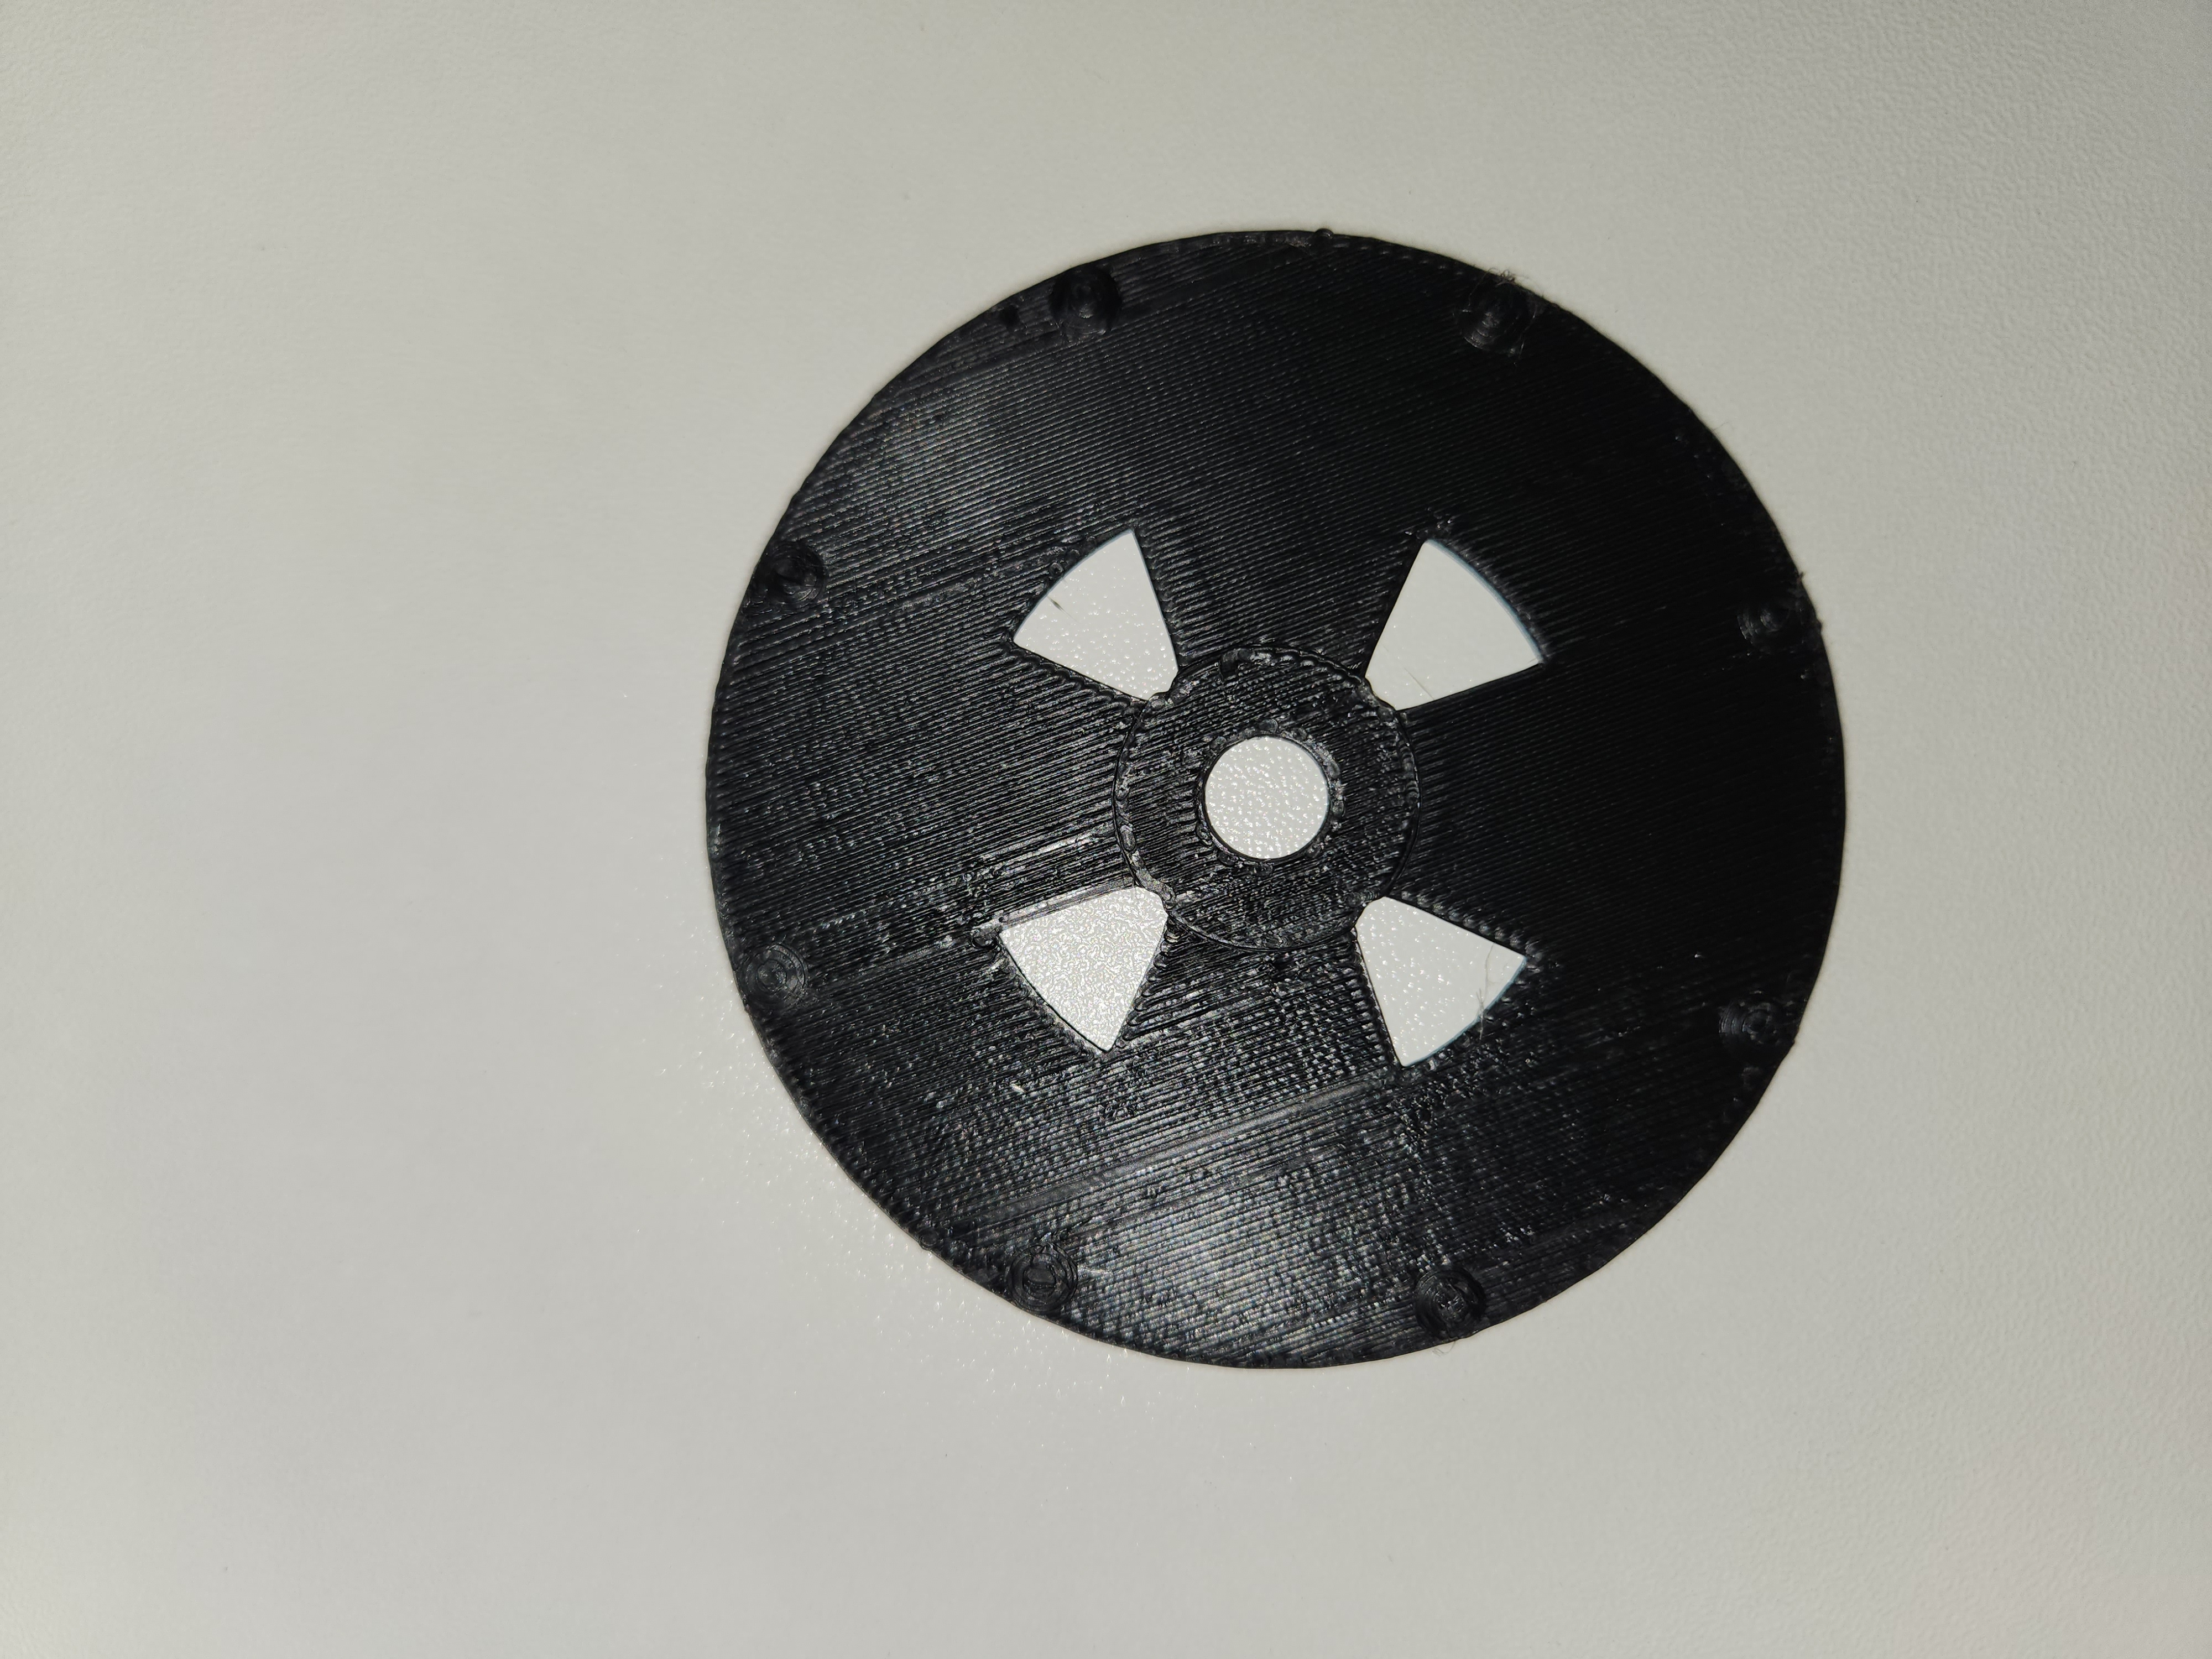
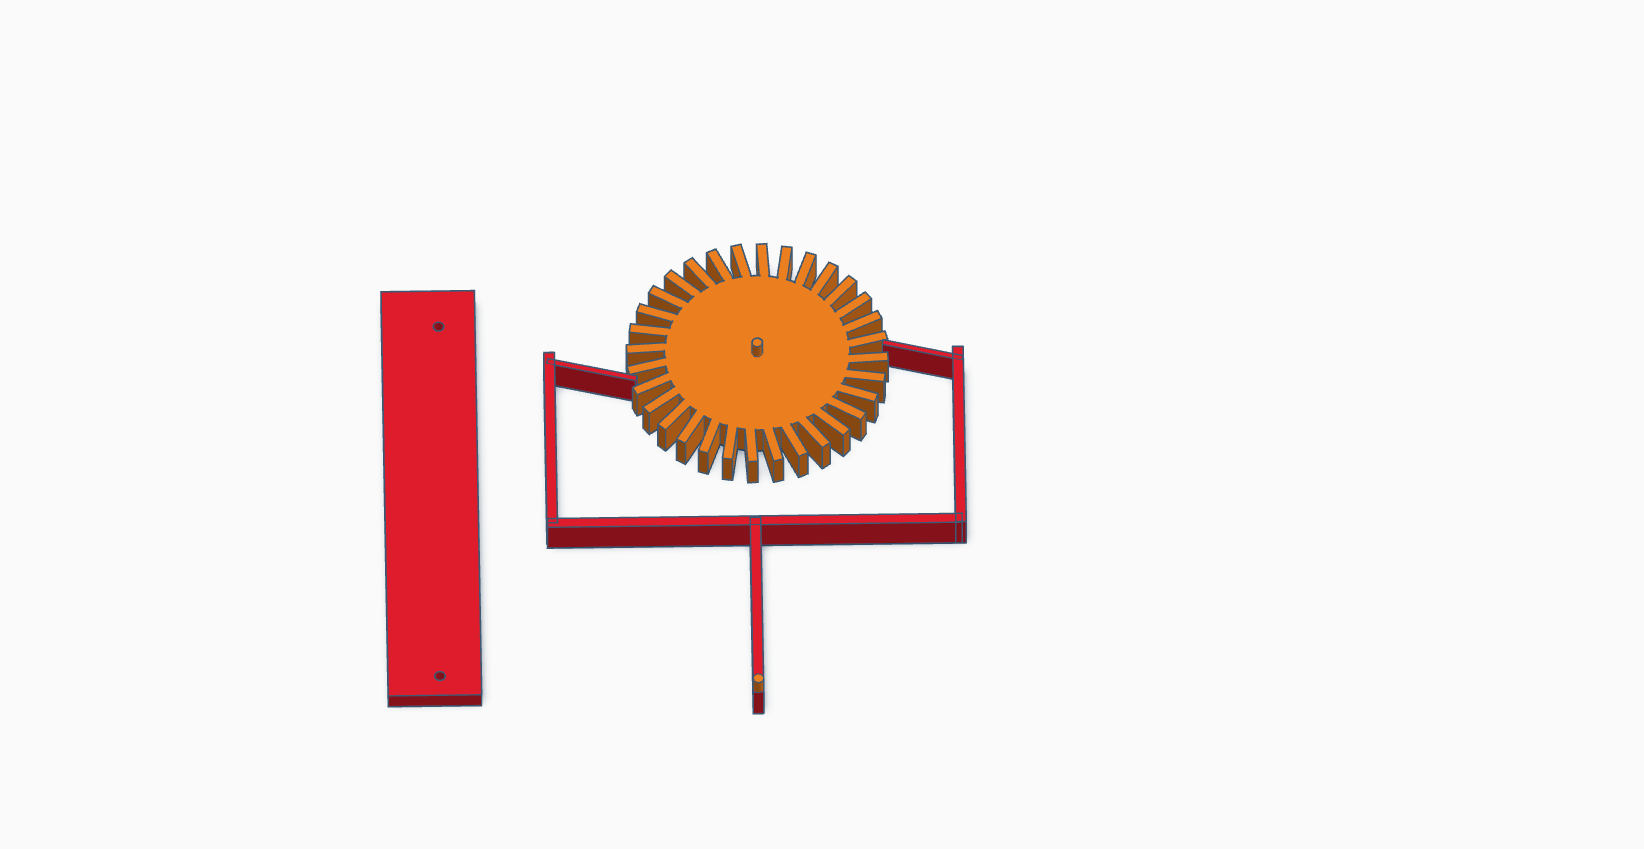
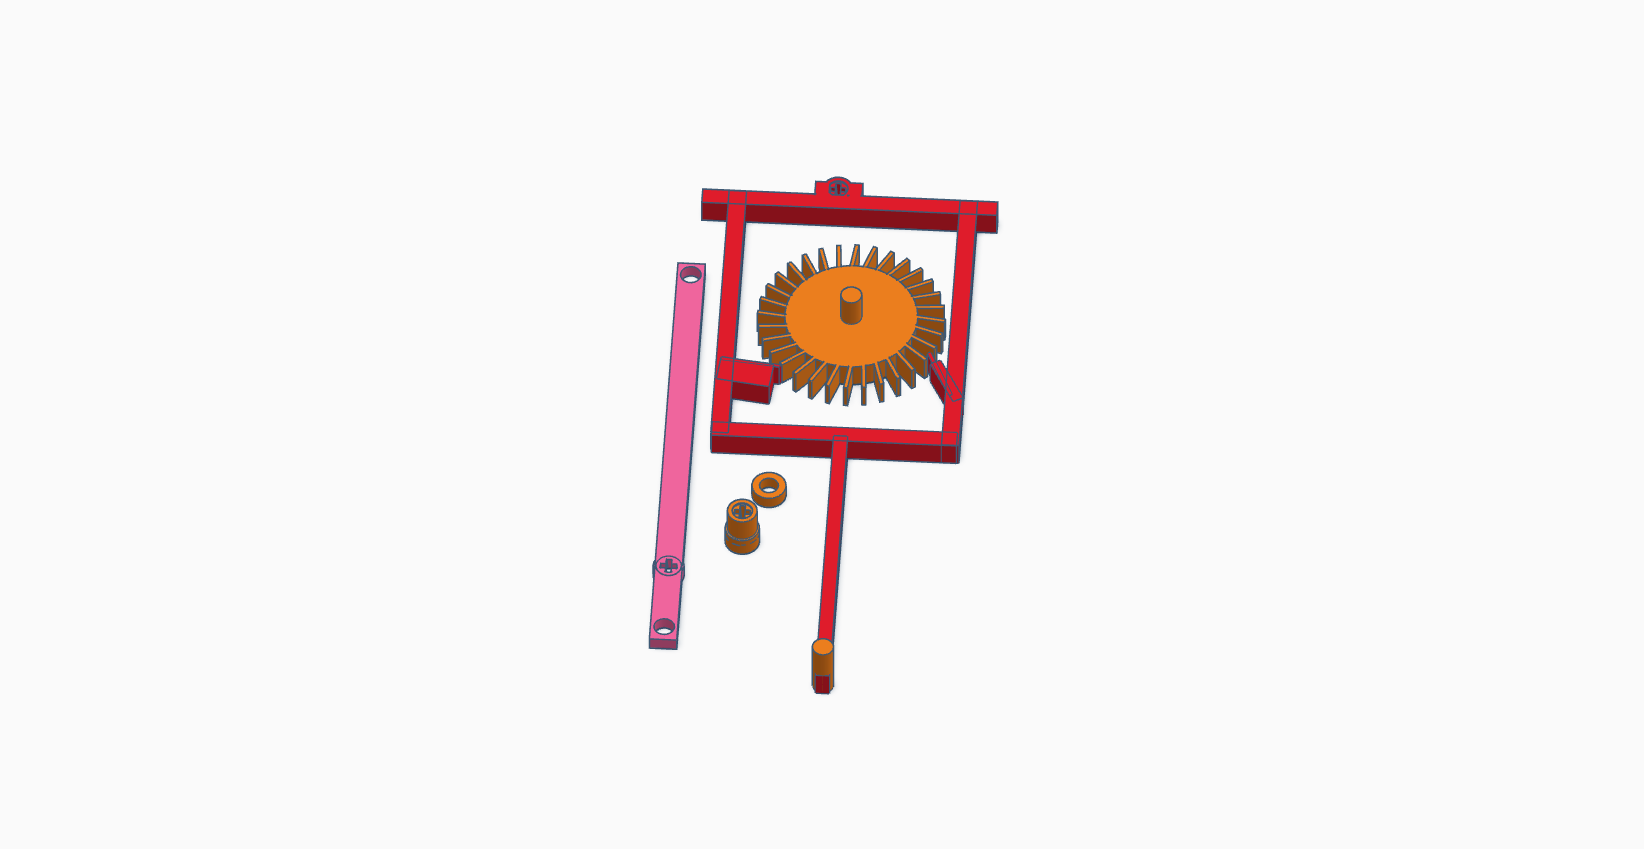
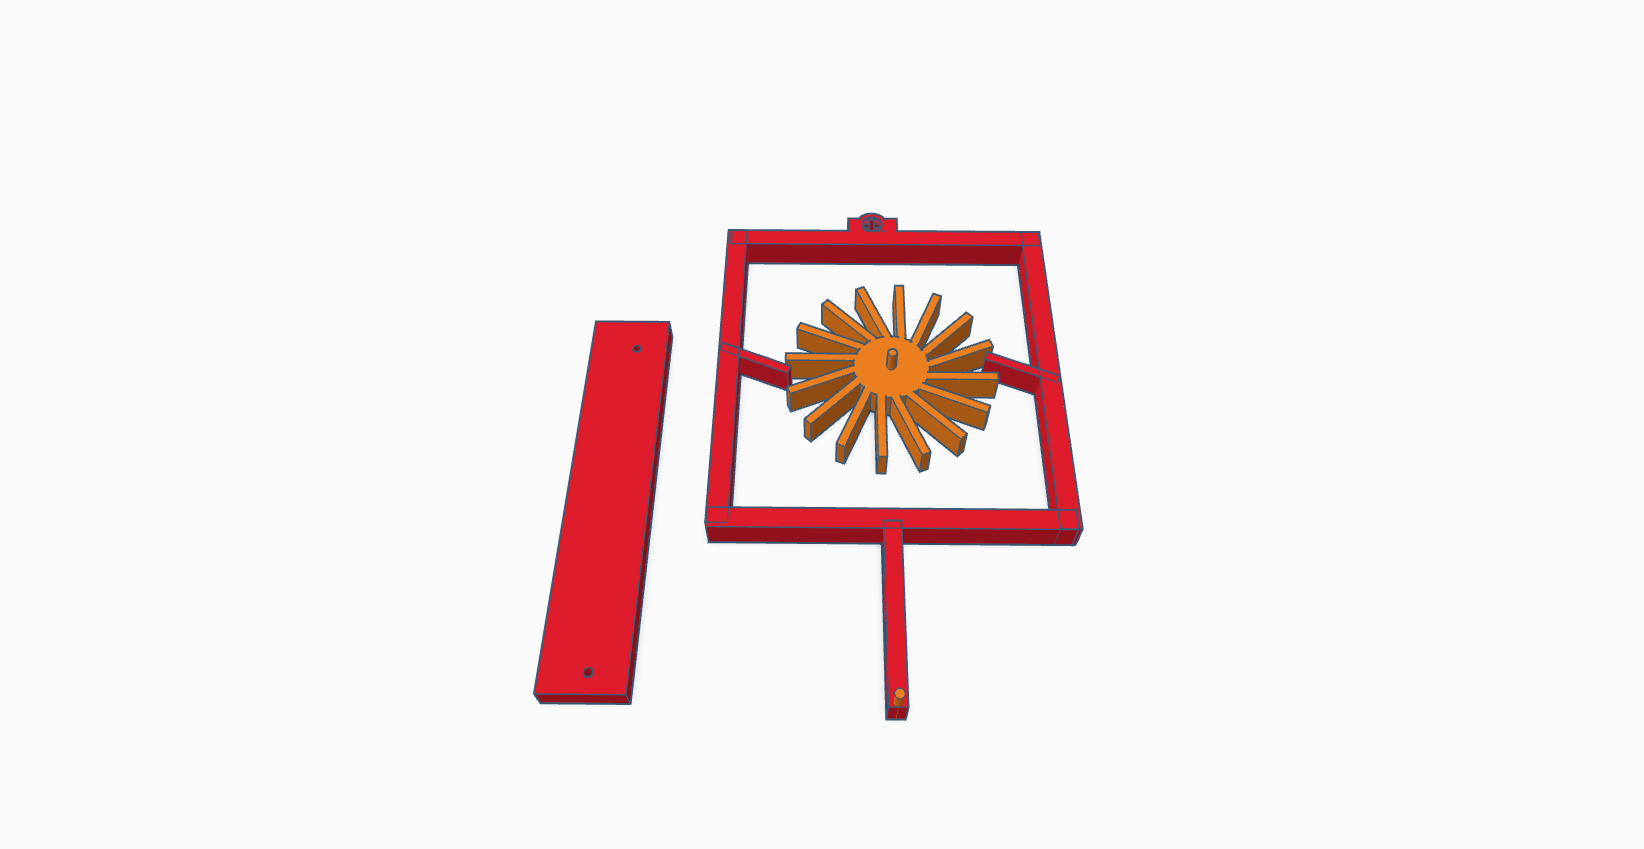
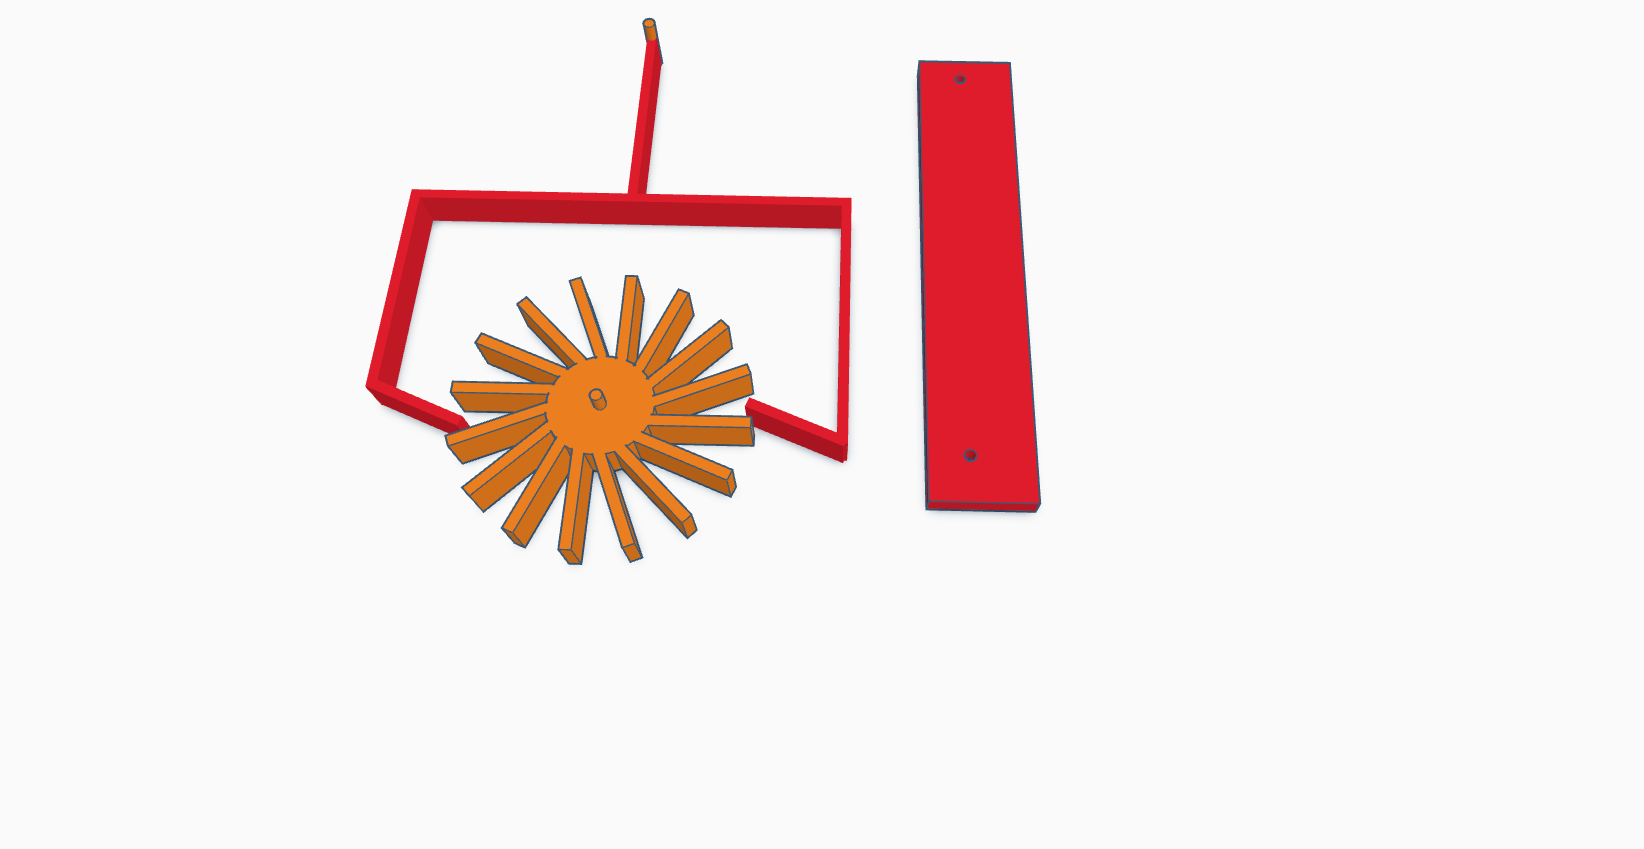
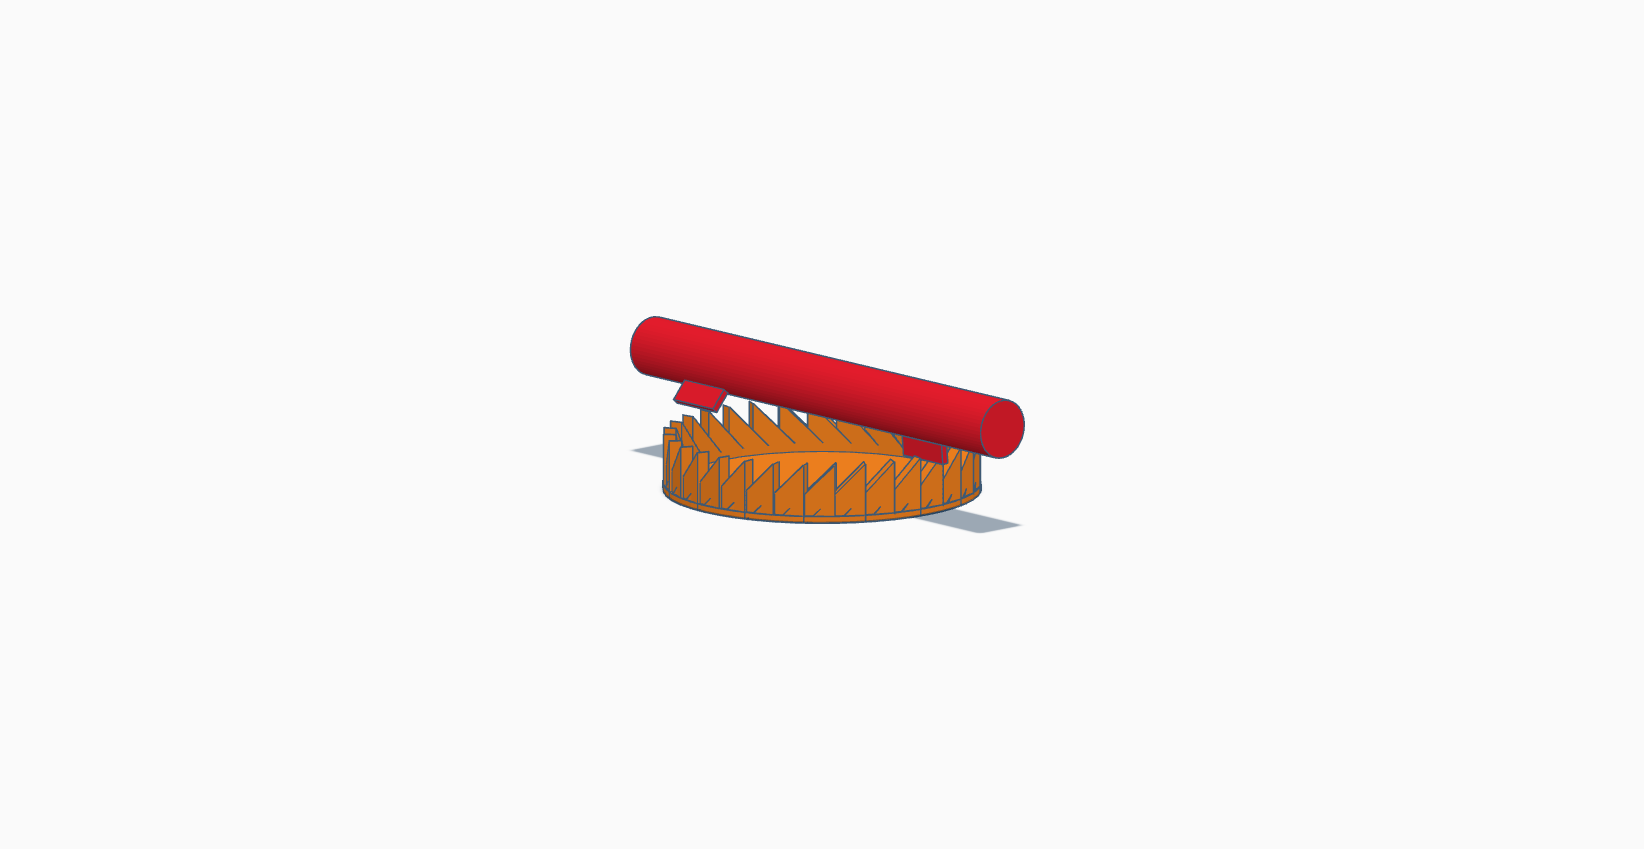
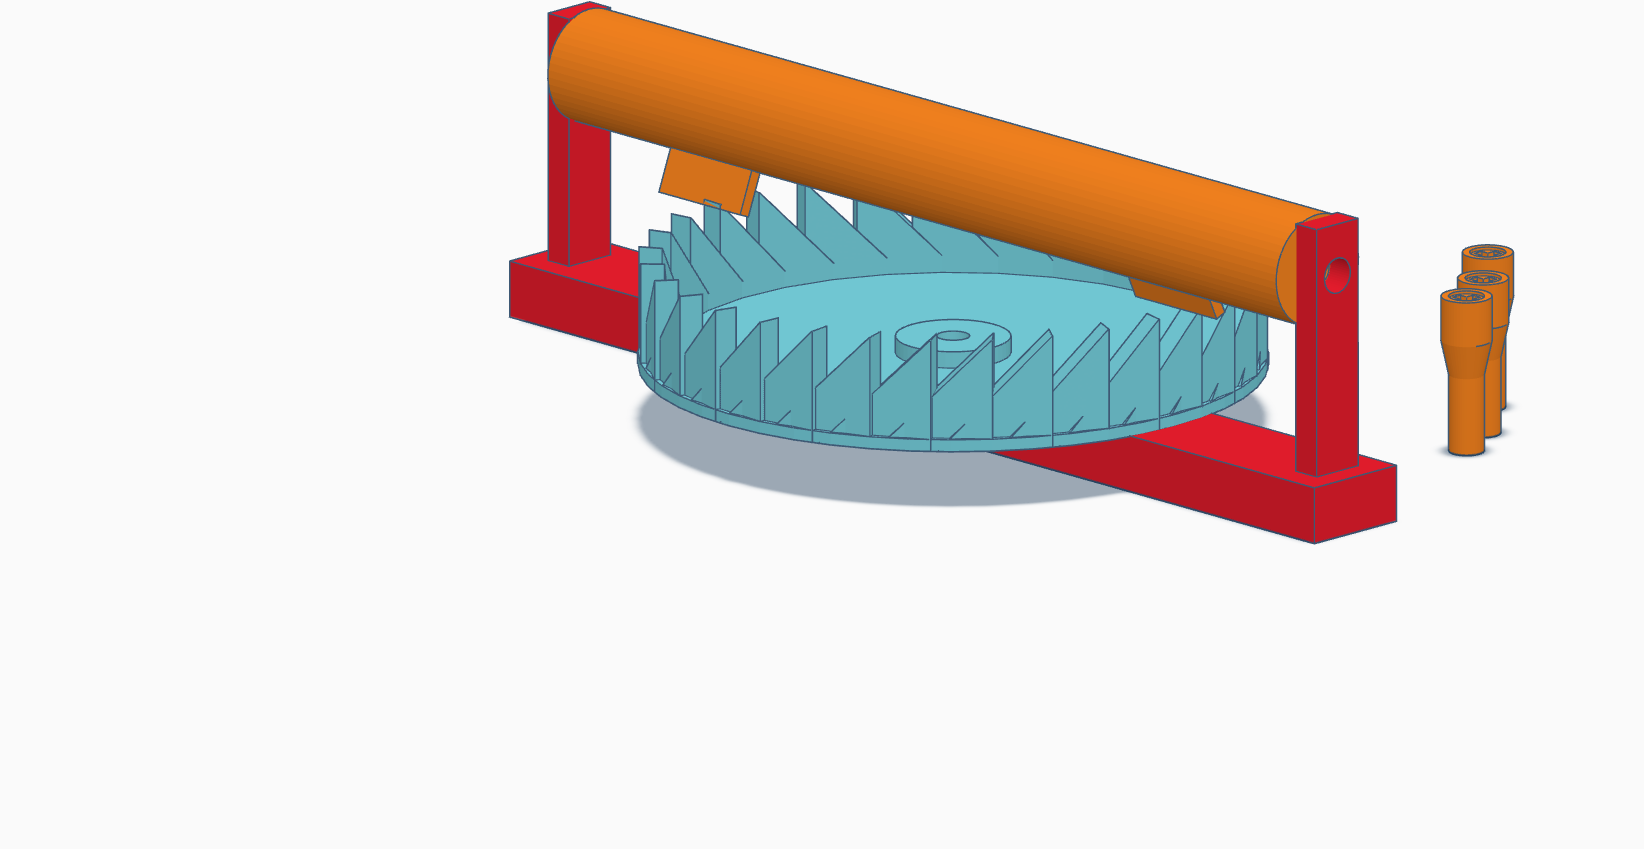
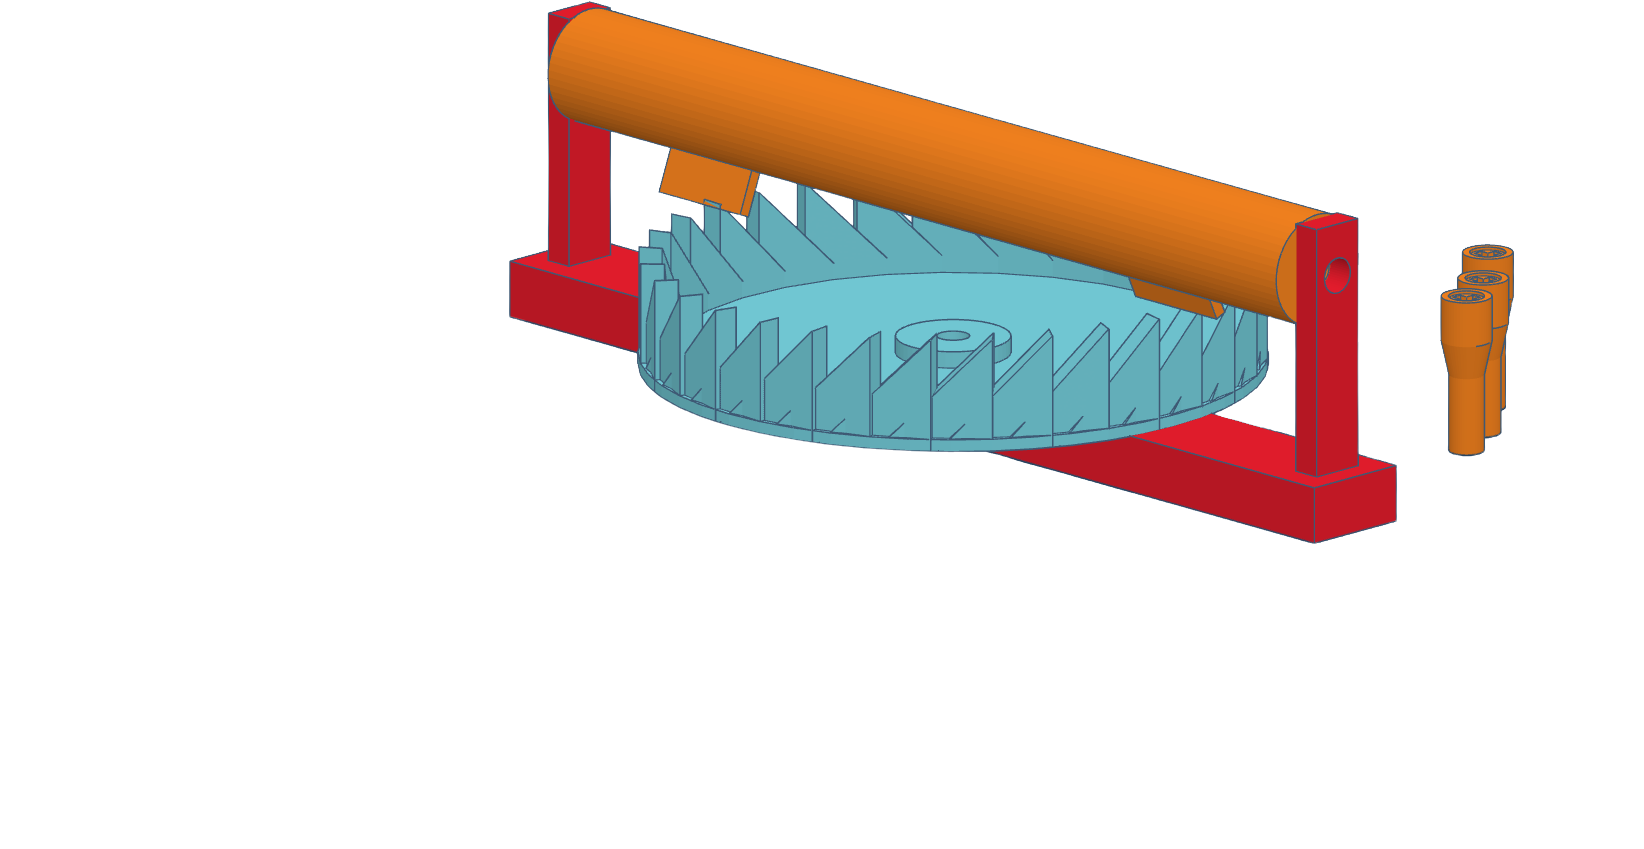
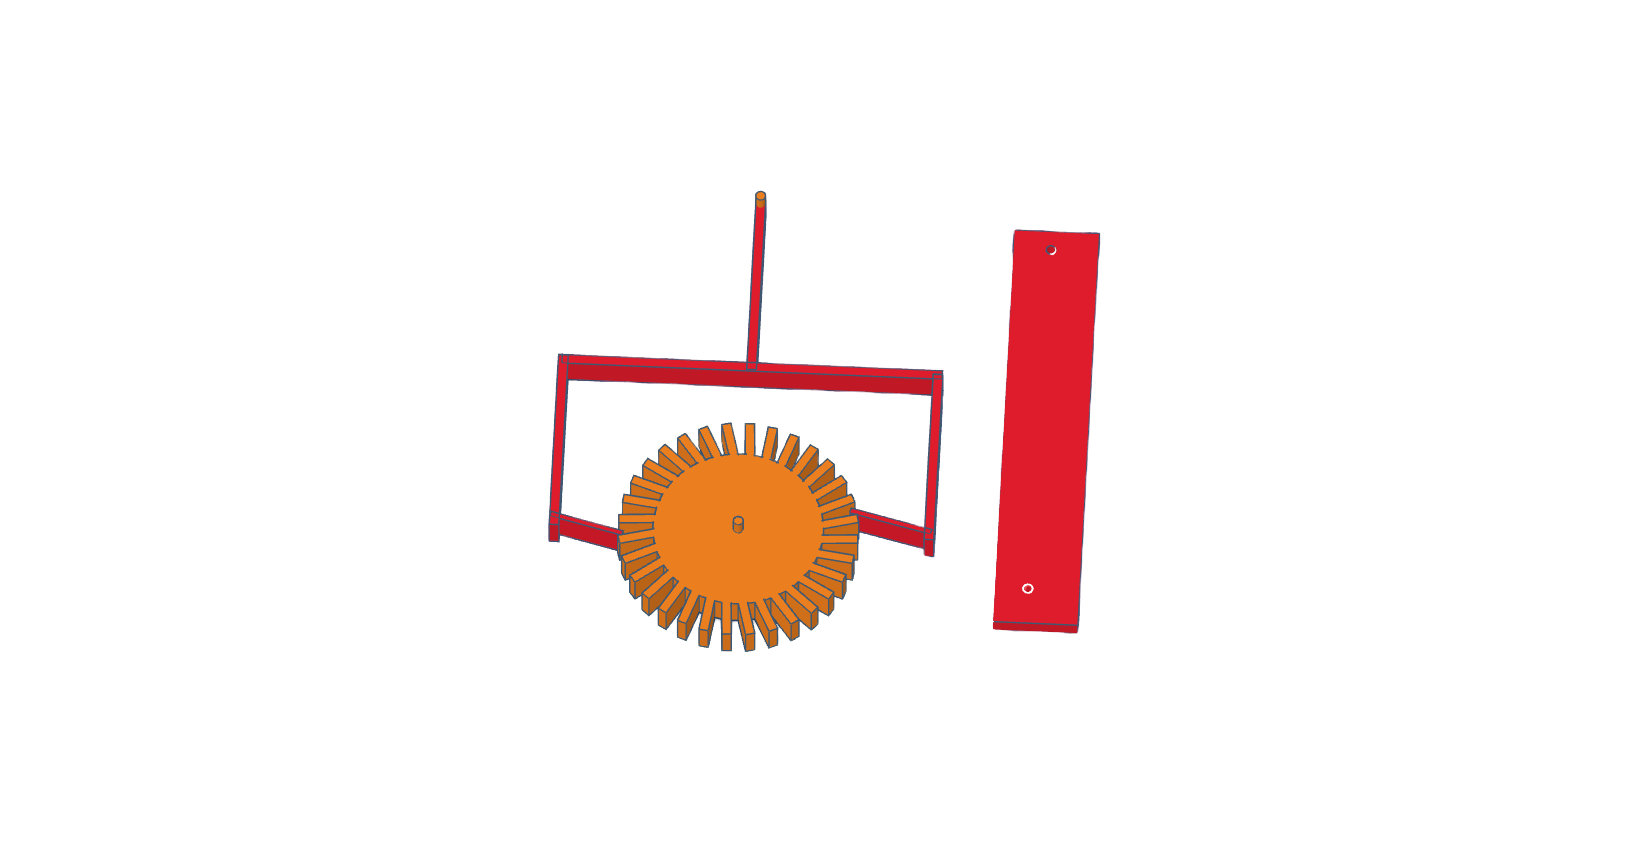
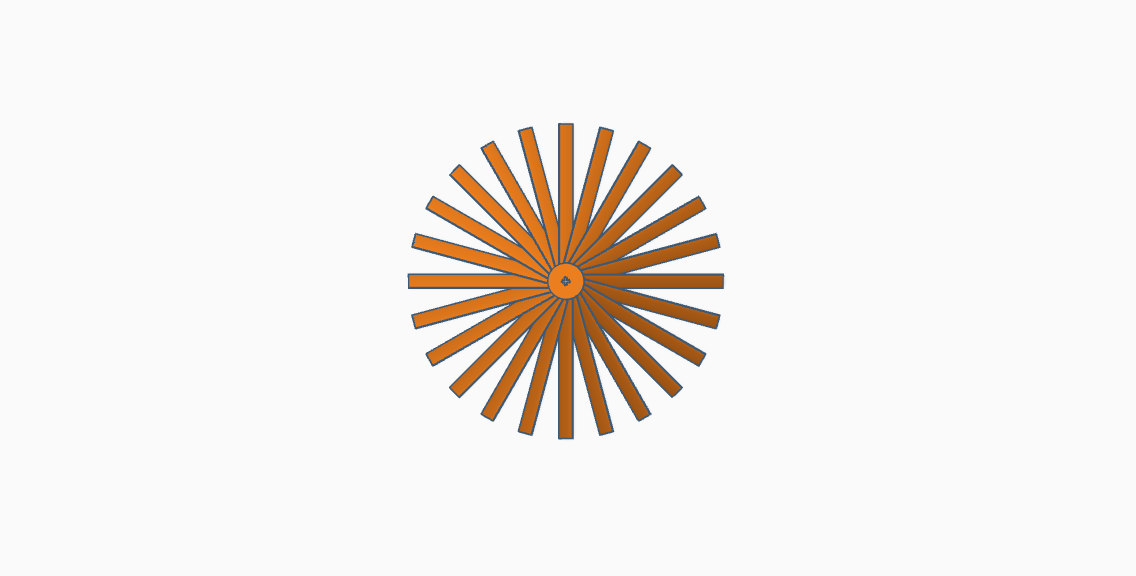
Propeller Attempt 1
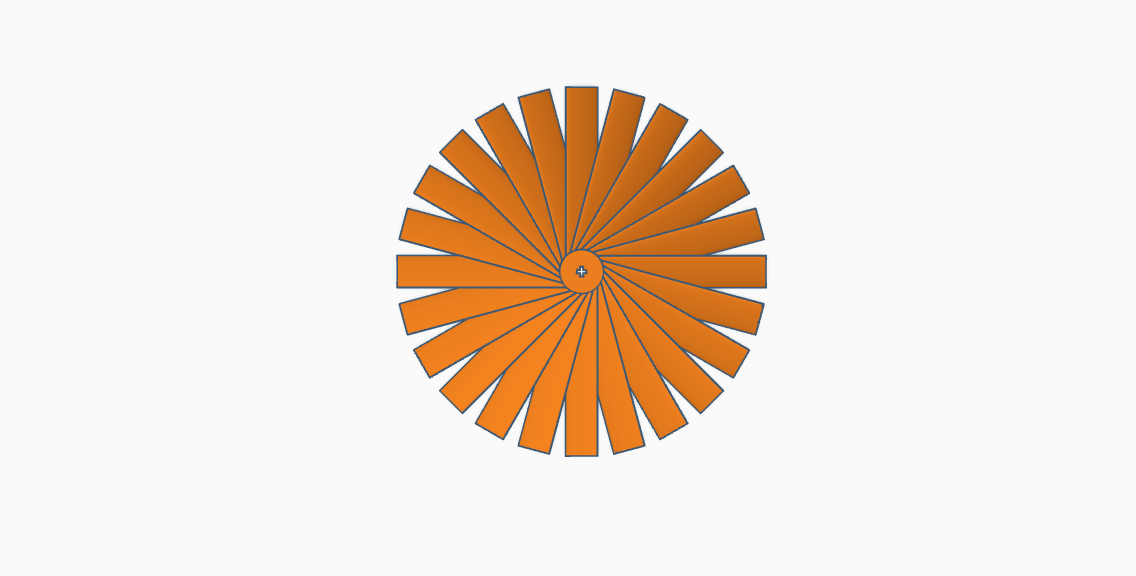
Propeller Attempt 2
Physical Turbine Rotor

Wind-Powered Kinematic Transport Prototype

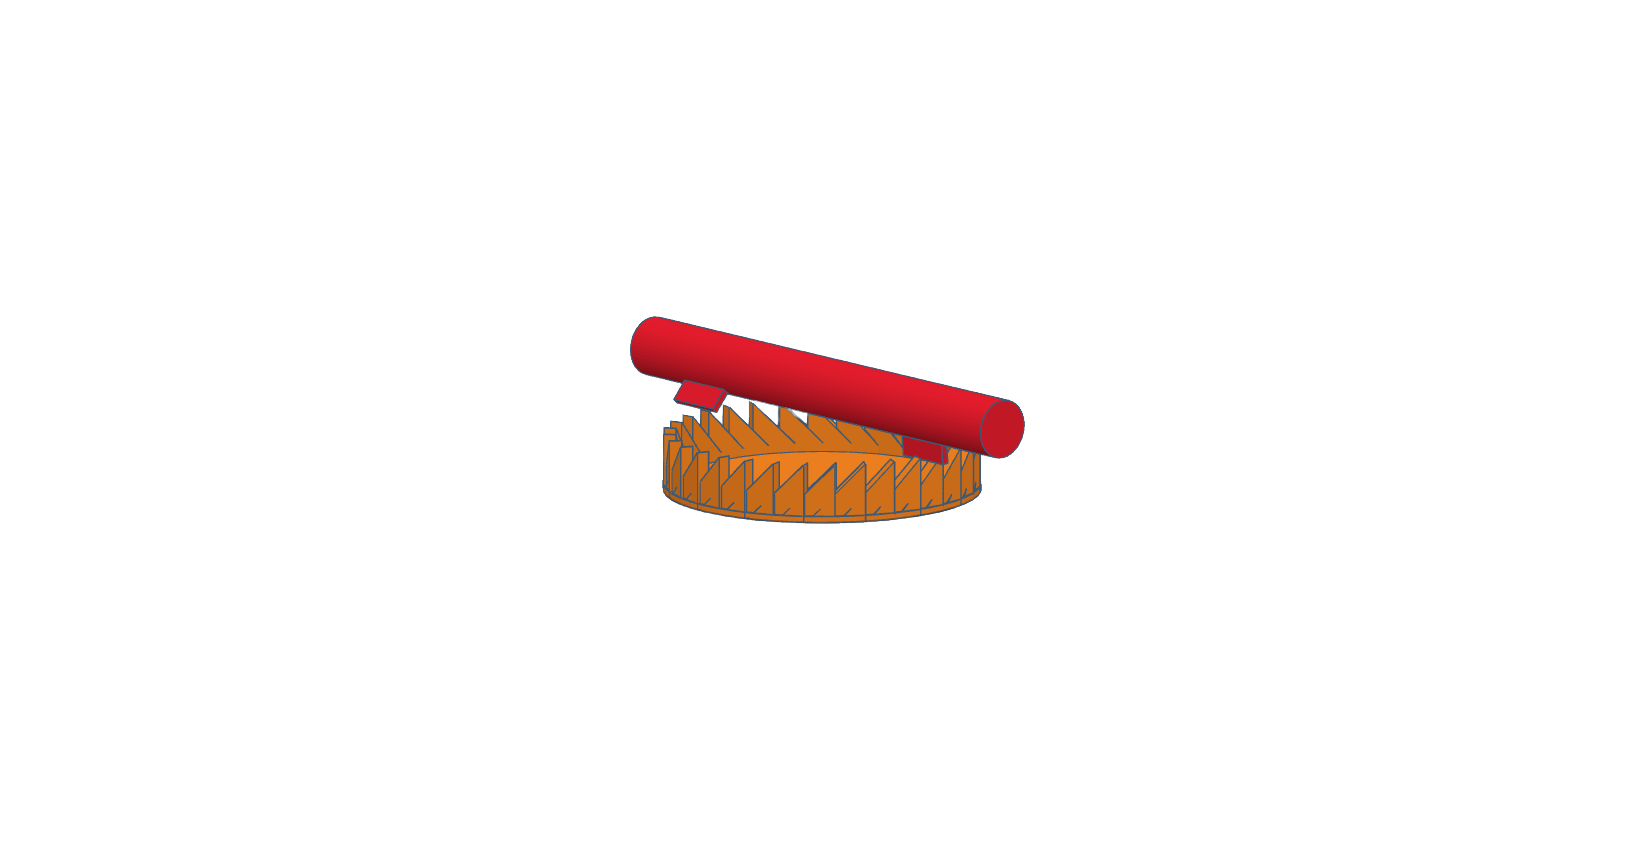
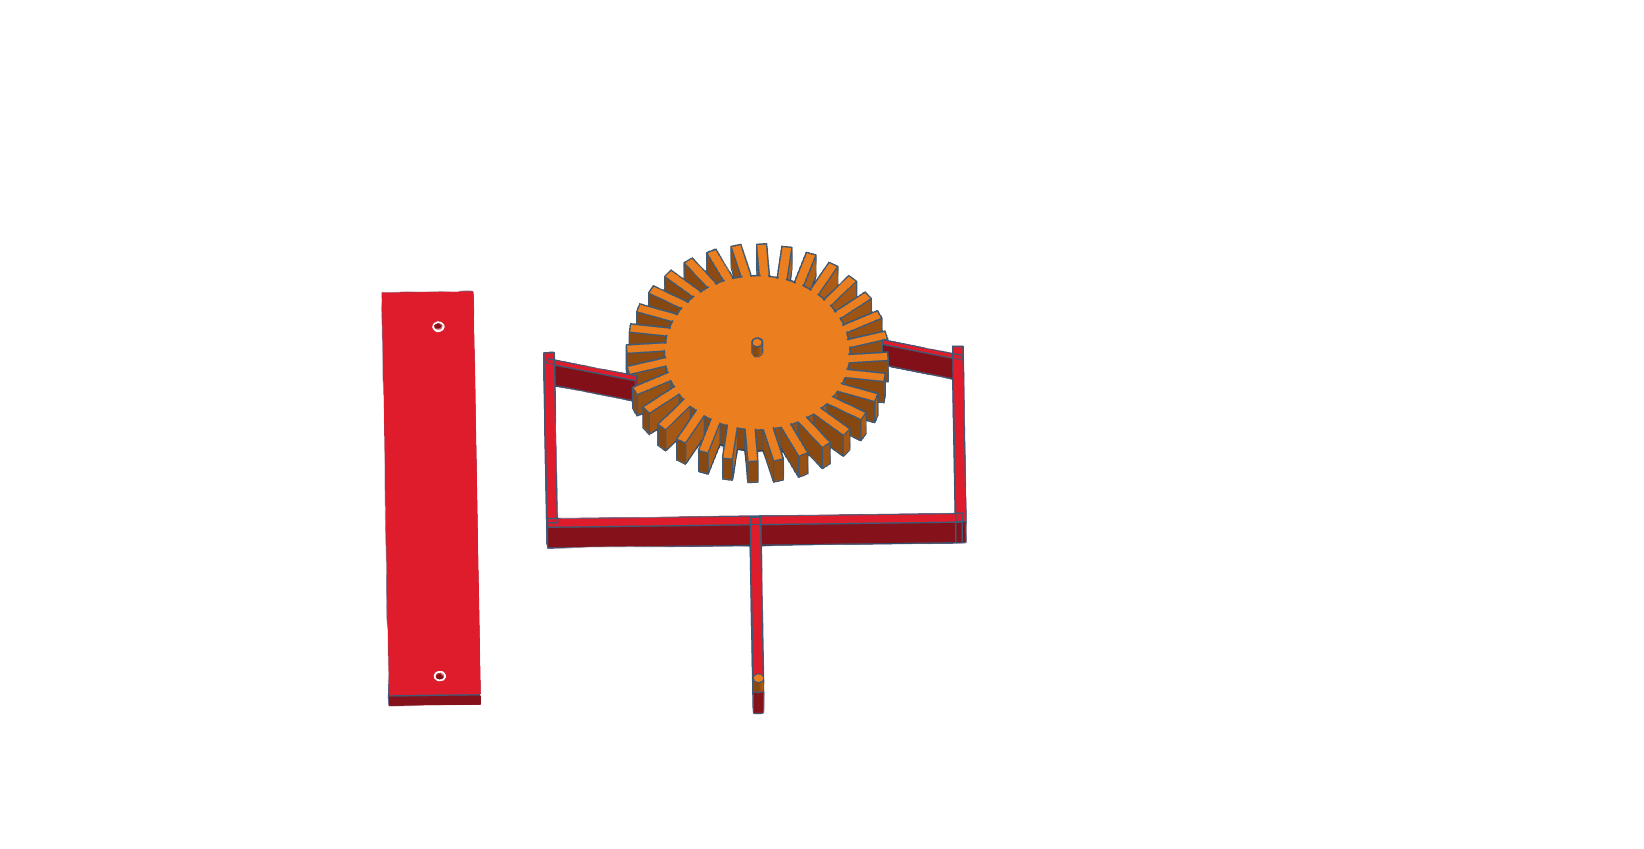
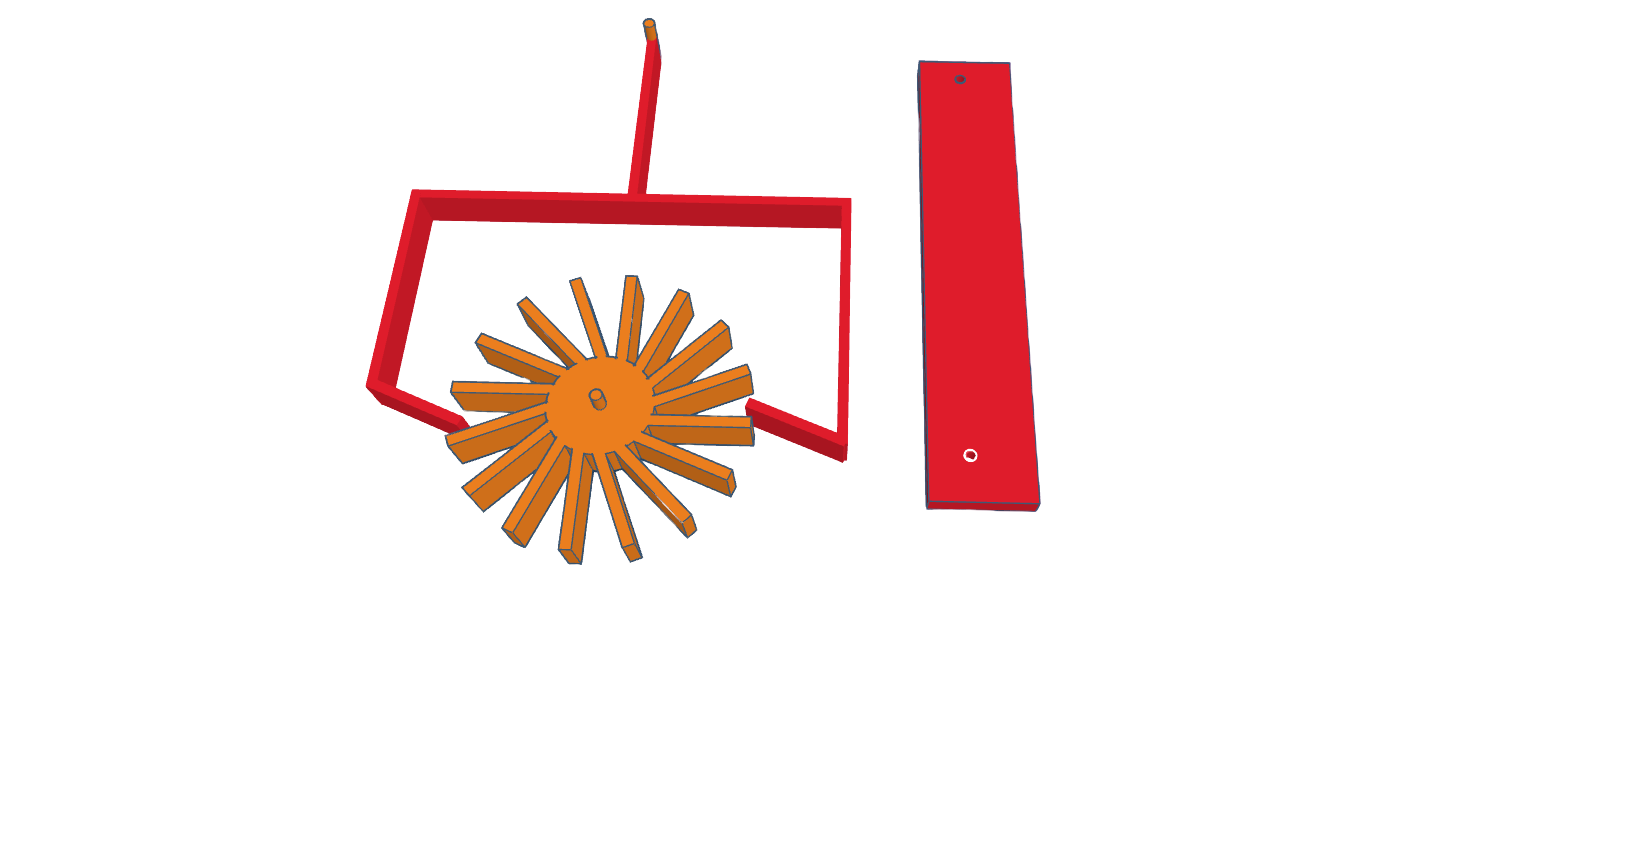
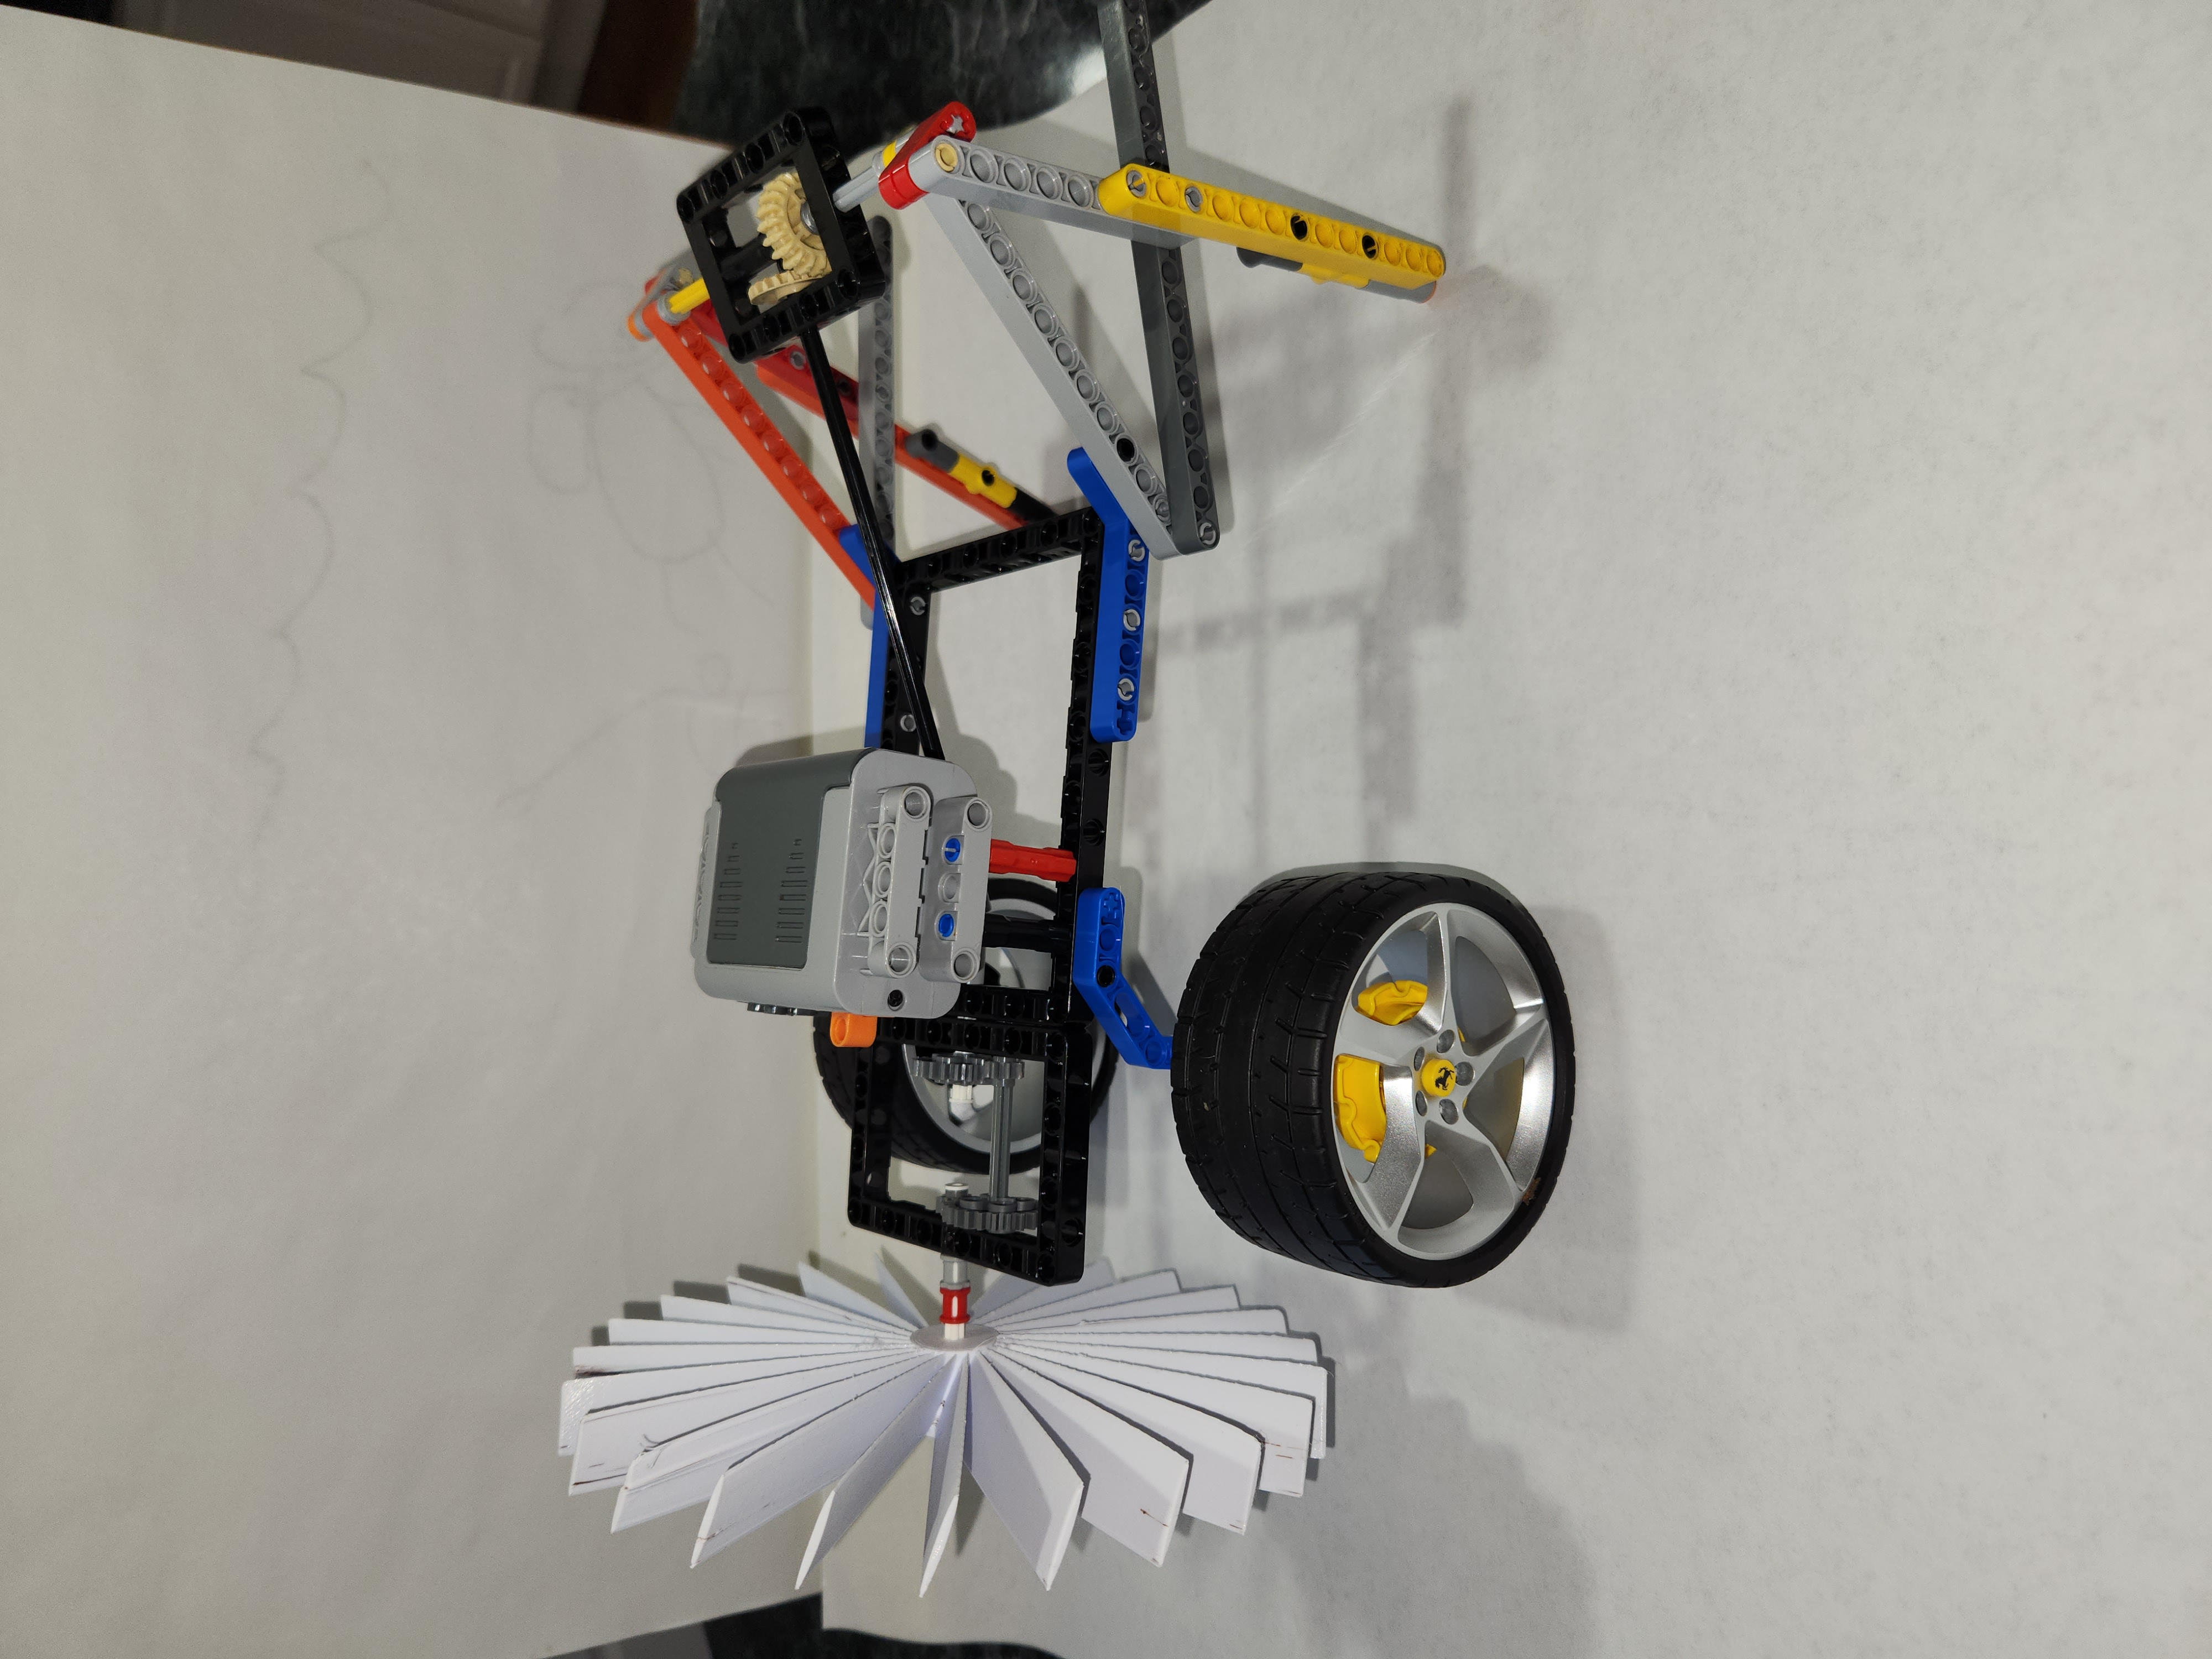
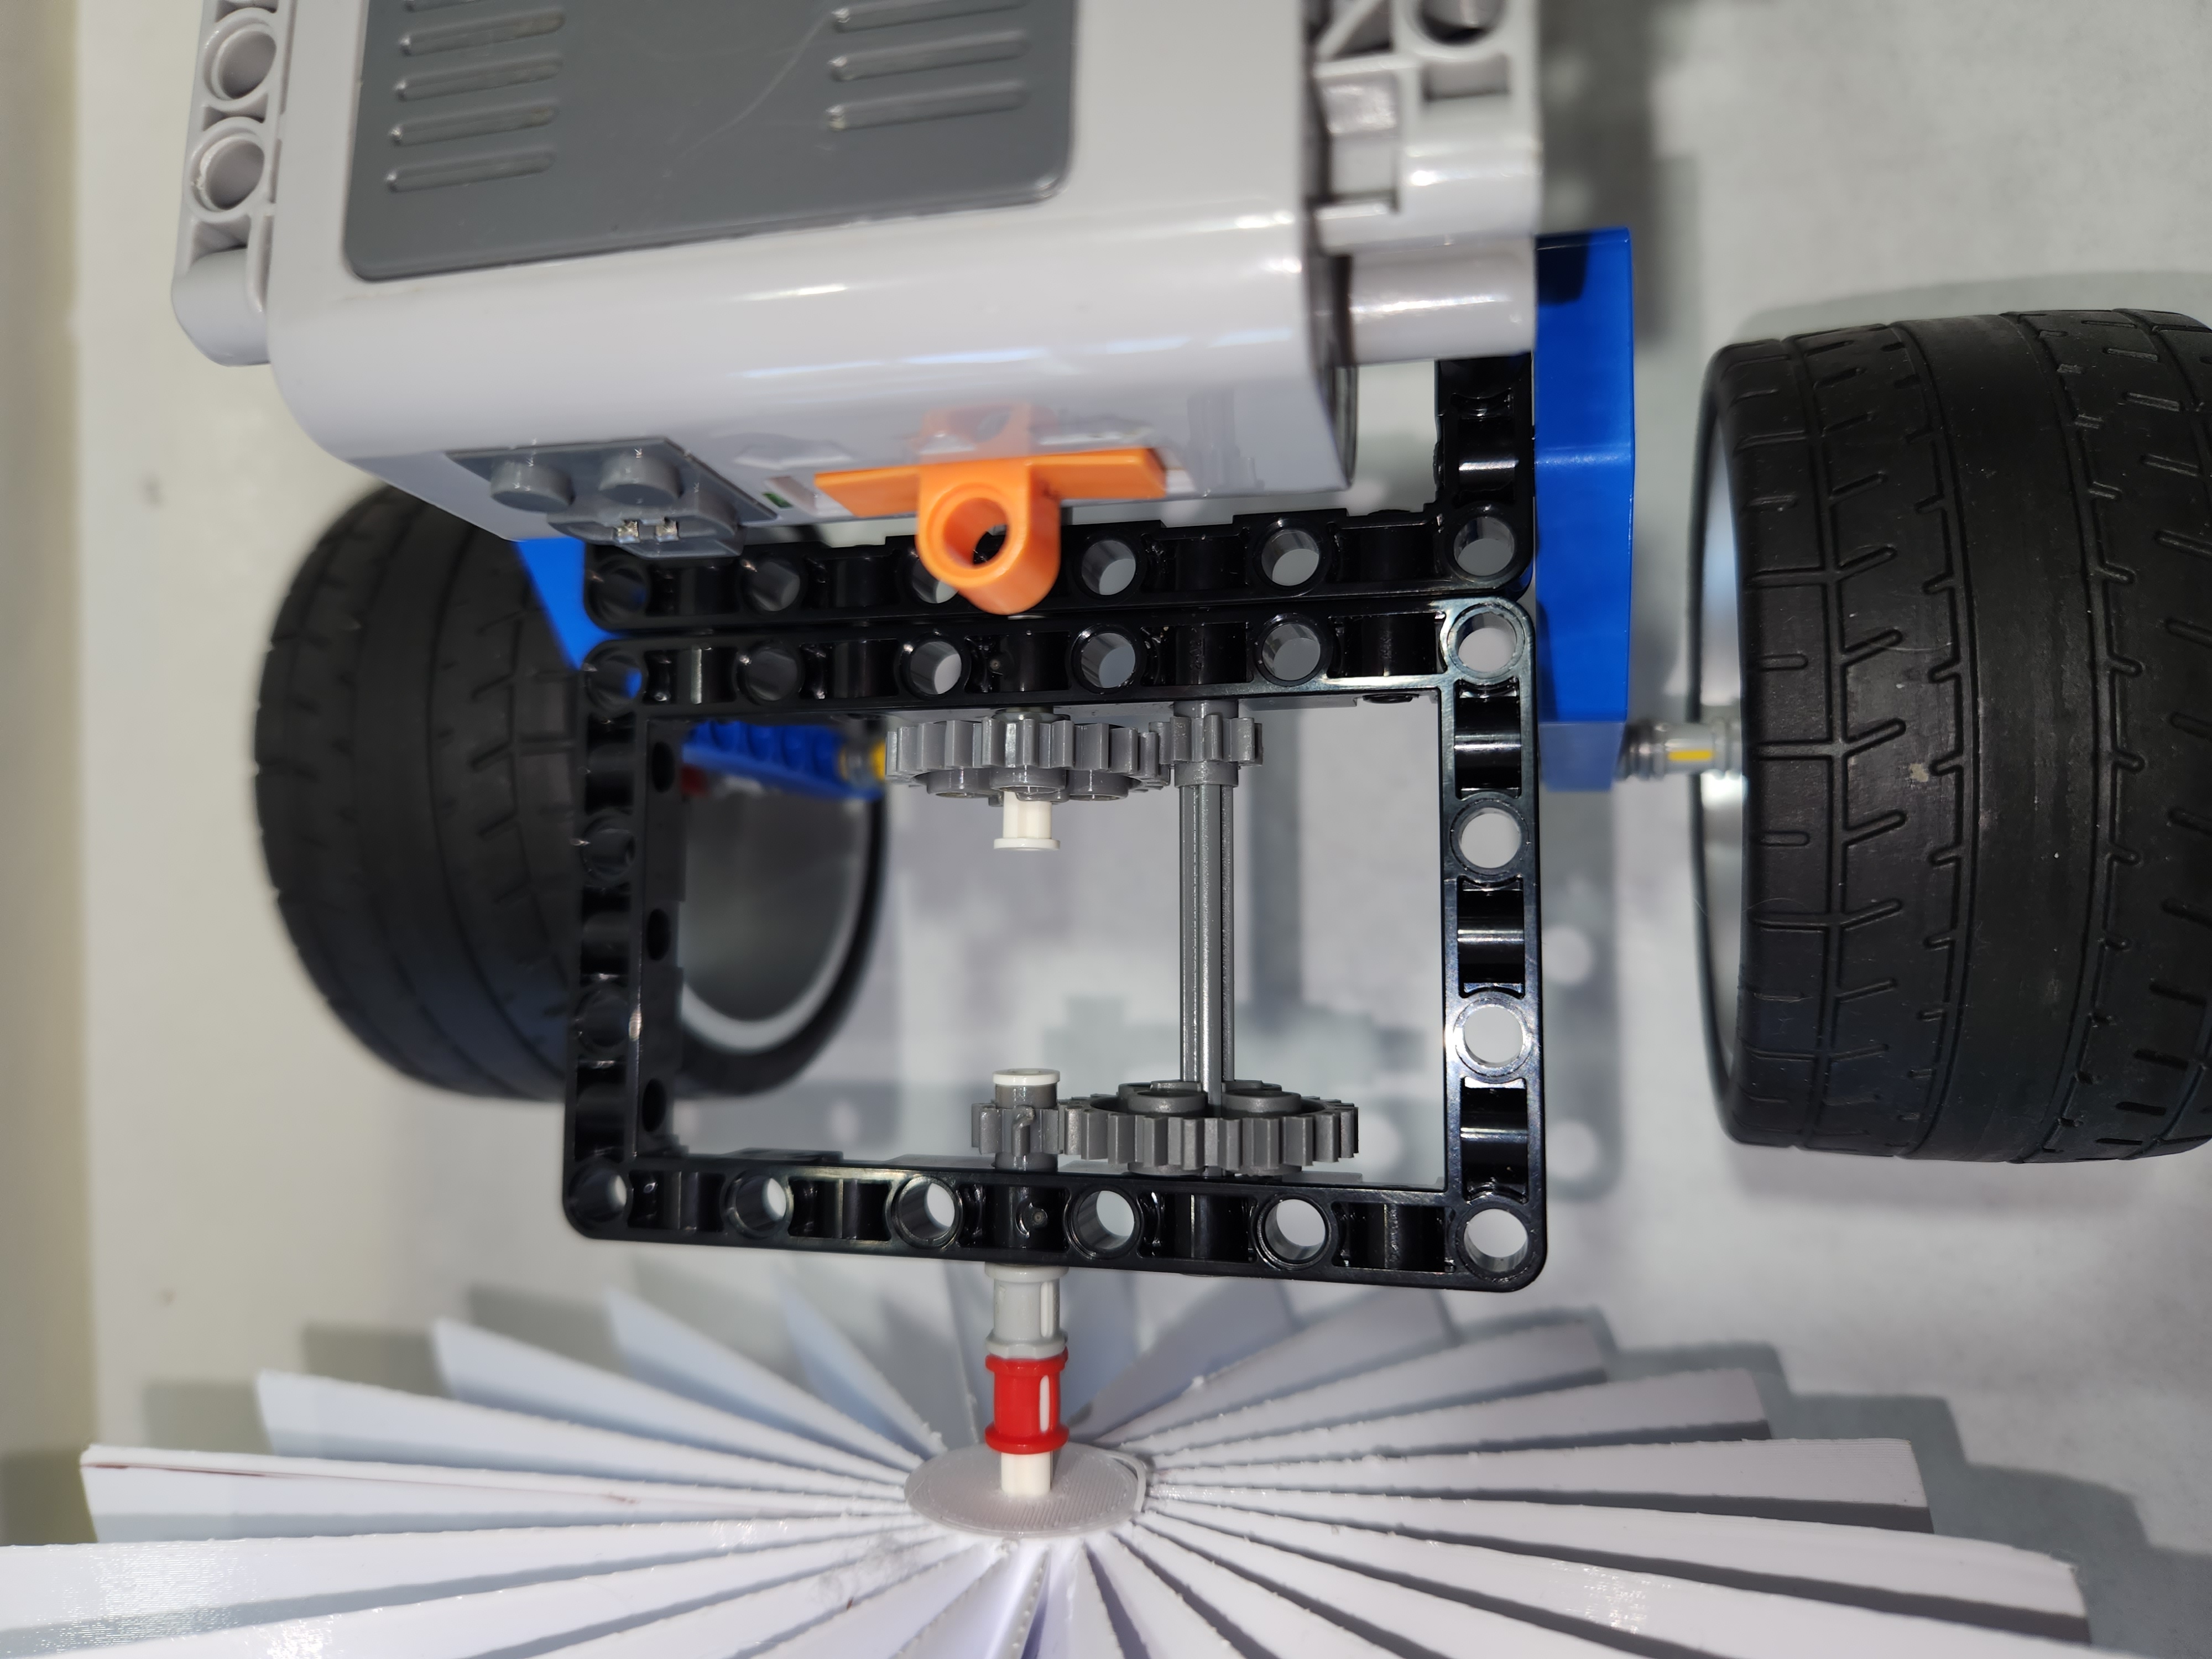
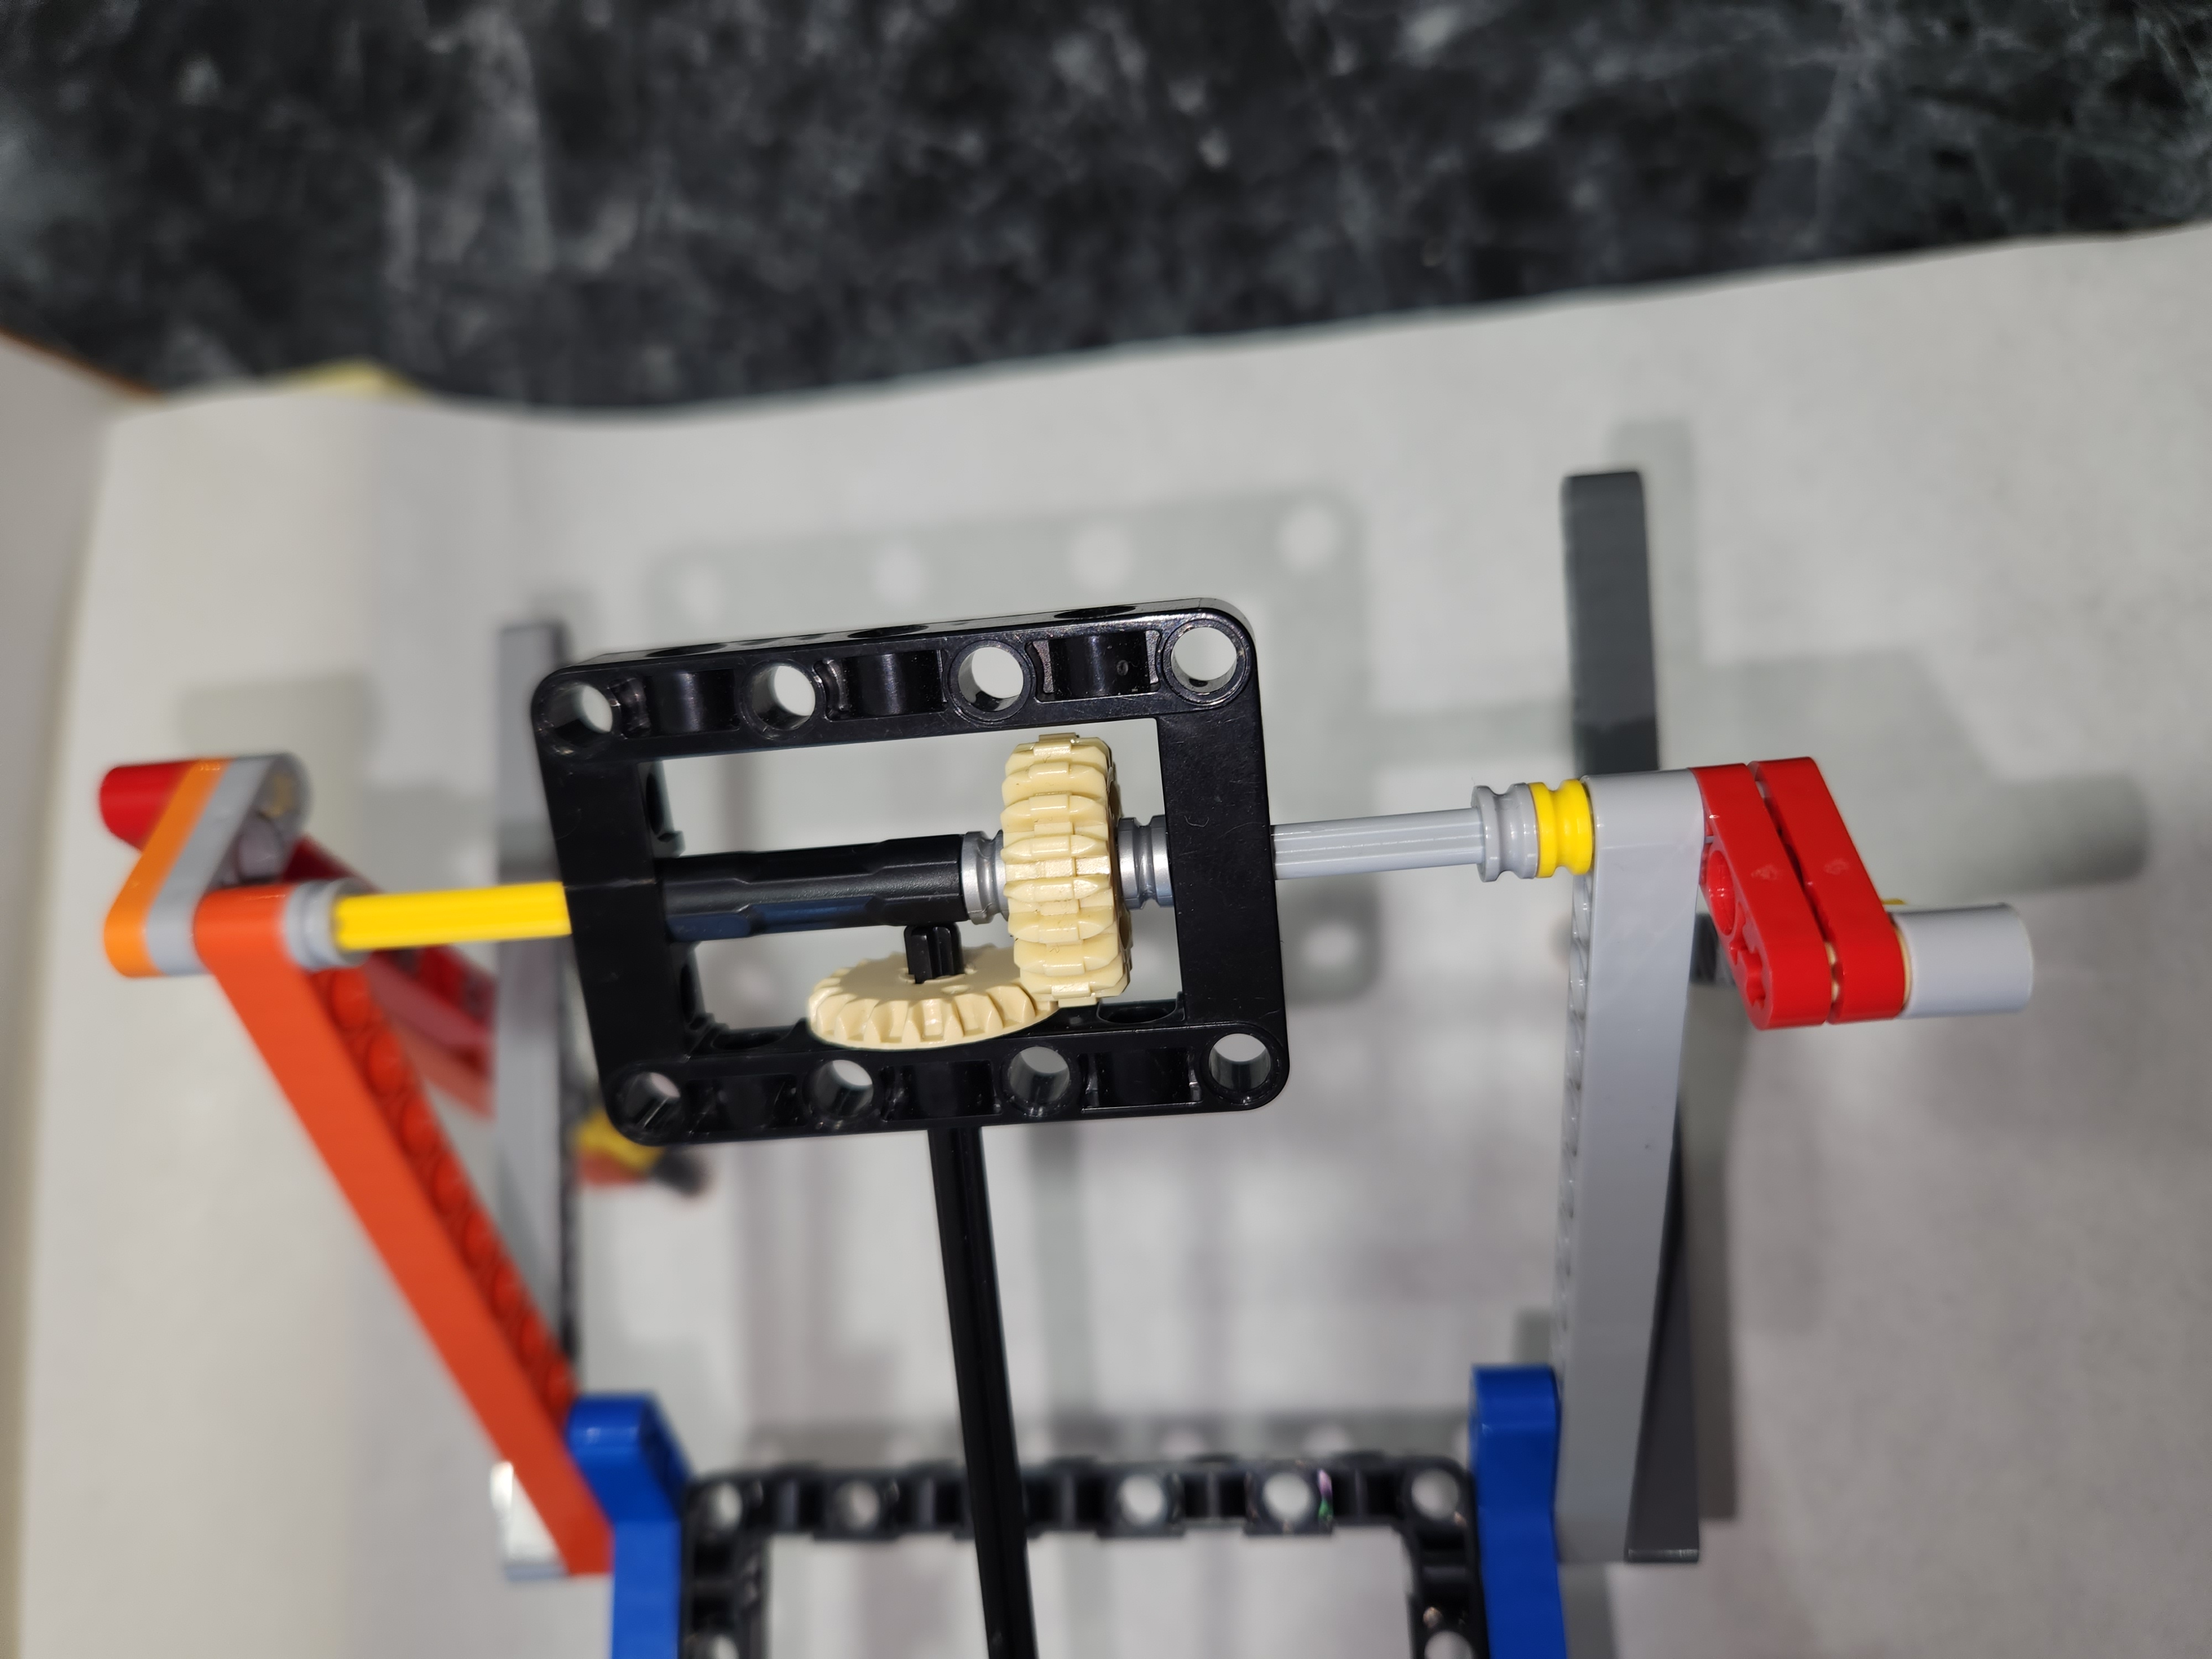
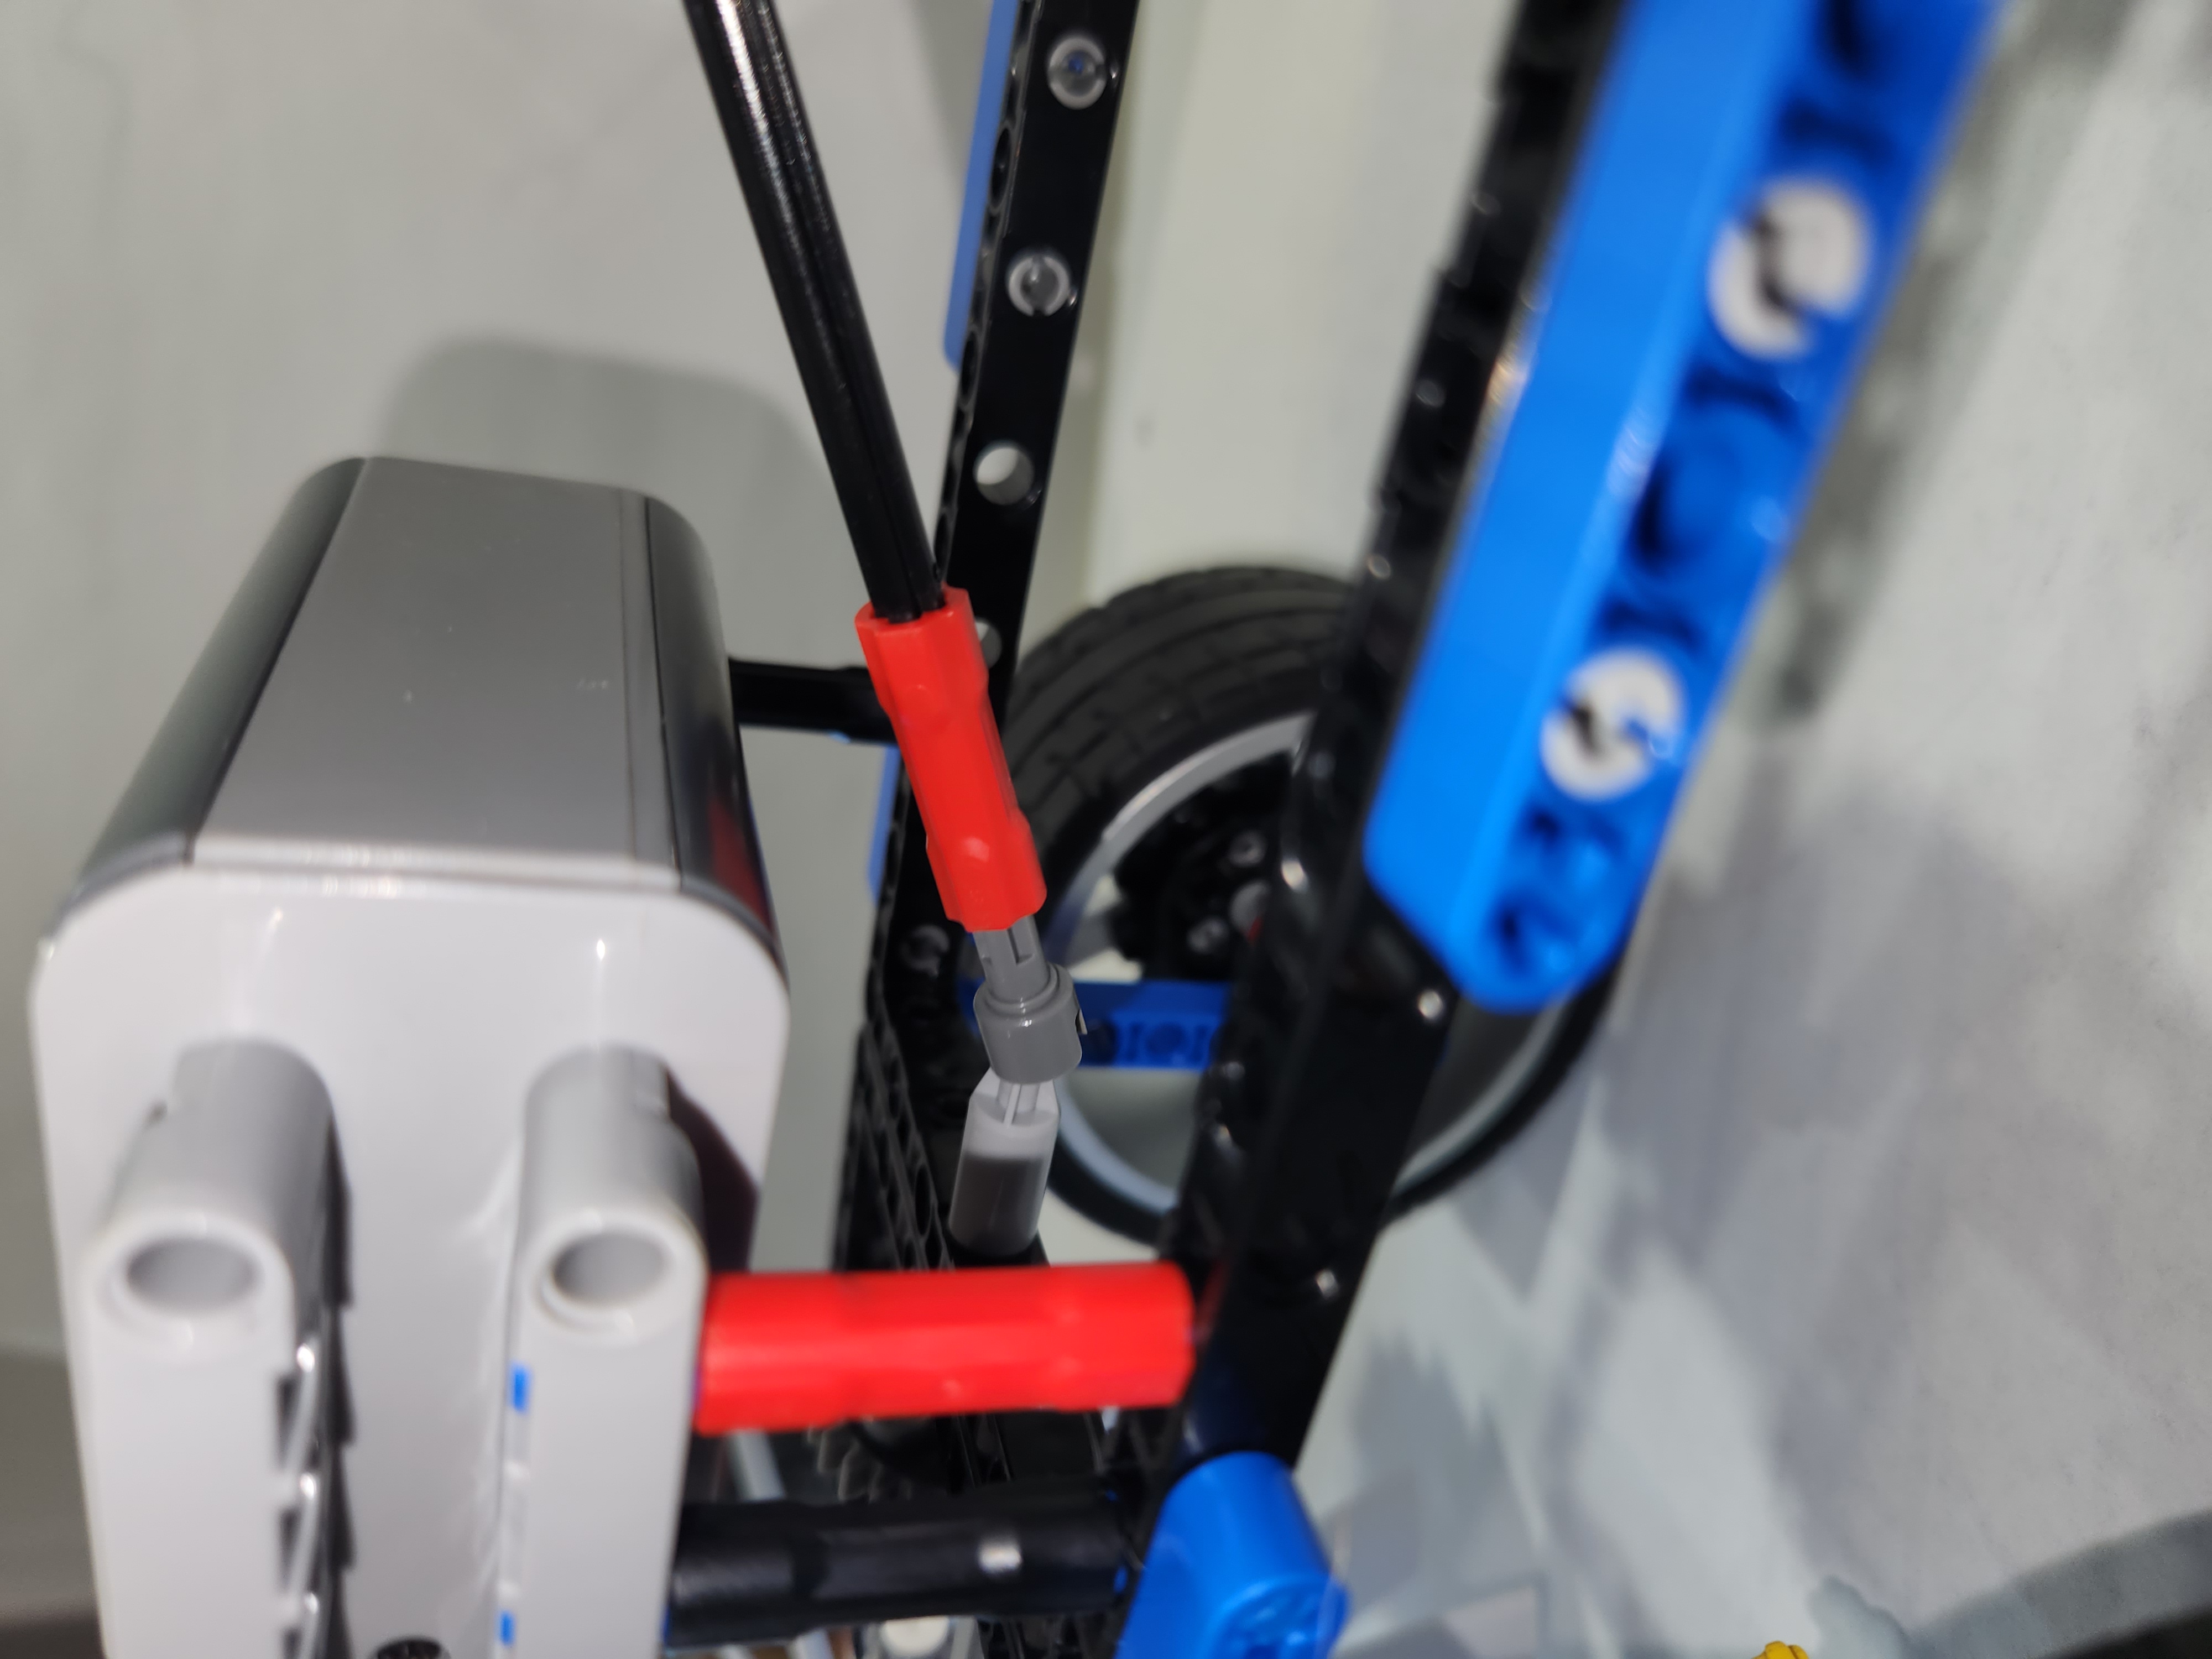
Conceived, modeled, and physically built an autonomous wind-propelled rover capable of crawling directly into headwind airflow. Harnessing wind currents with a custom 3D-printed multi-blade turbine impeller, the rover routes rotational kinetic energy through a multi-stage transmission: a lower spur gear reduction to drive the front wheels, an angled universal joint linkage, and a top 90-degree bevel gearbox driving dual crank arms. Validated on a dedicated test bench against an electric fan airflow, proving sustainable forward mechanical propulsion against aerodynamic resistance.

⚙️ Fluid Dynamics & Impeller Synthesis
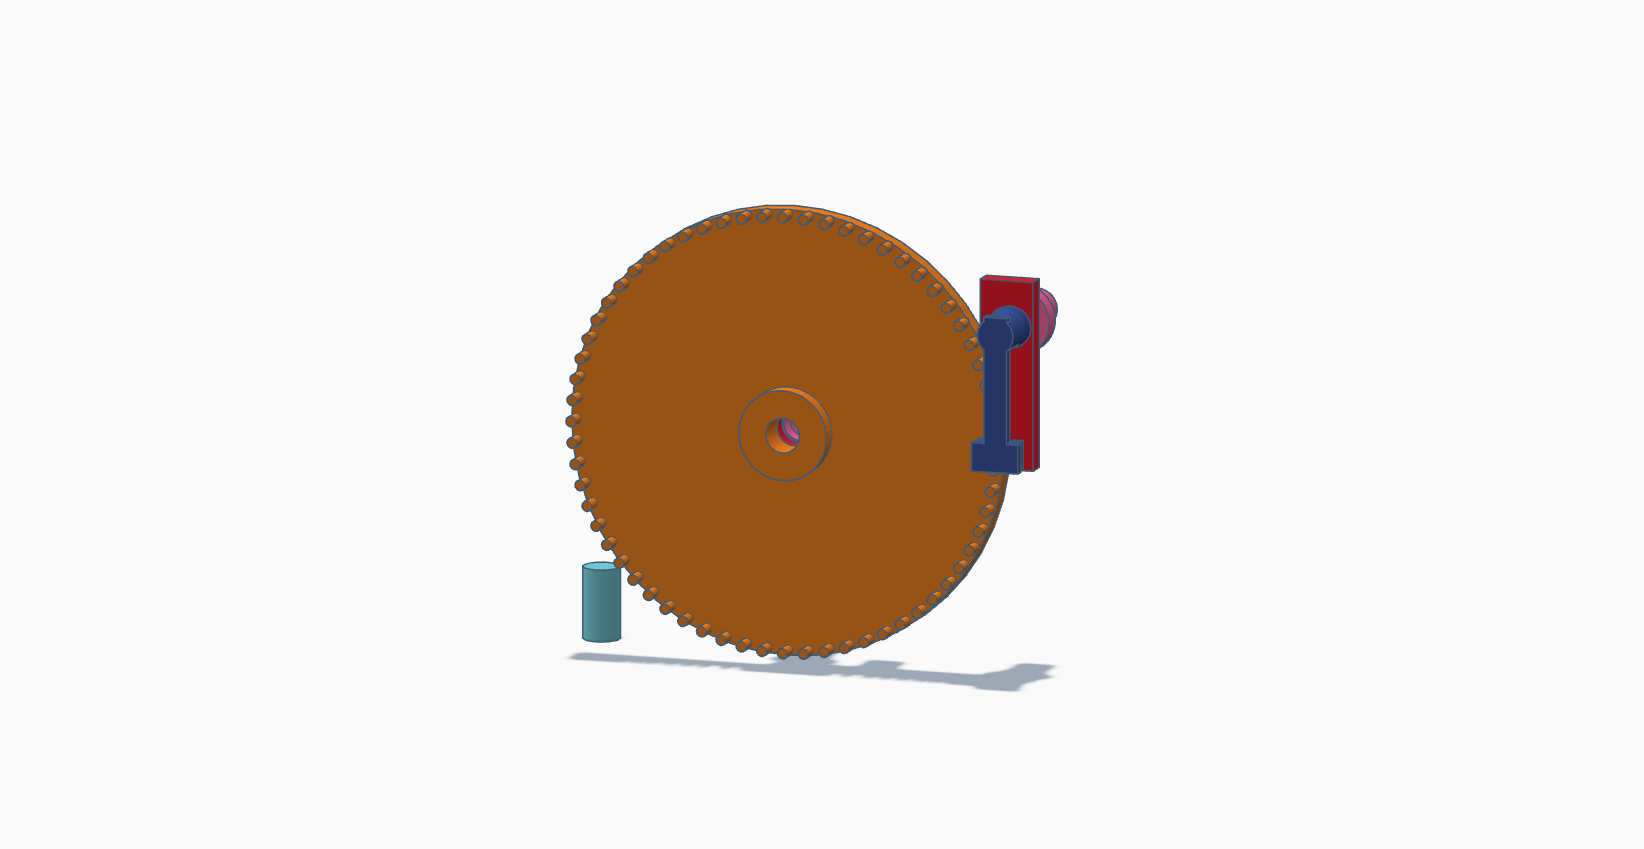
  • Aerodynamic Pitch Optimization: Iterated through multiple 3D-printed blade angles in TinkerCAD, evaluating 0° flat vs. 45° helical pitch to minimize startup stall speed and extract maximum rotational torque.
  • Multi-Blade Rotor Dynamics: High-solidity blade layout captures low-velocity airflow efficiently, generating sufficient starting torque to overcome static chassis inertia and rolling resistance.
🔧 Mechanical Drivetrain & Kinematics
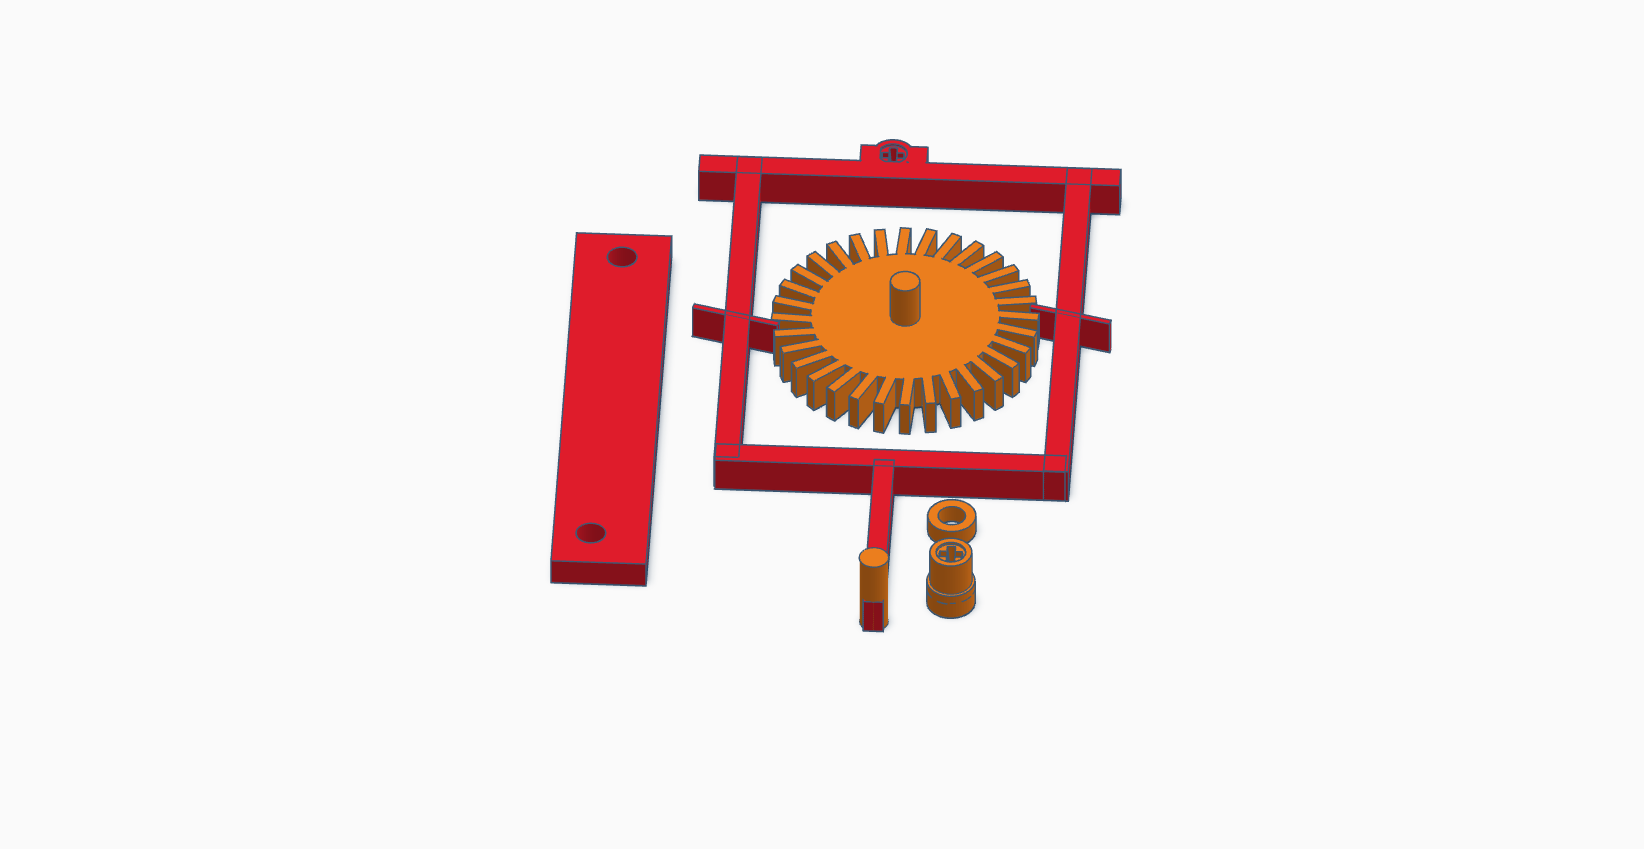
  • Multi-Stage Gear Reduction: Meshed spur gear stage inside a Technic cage steps up mechanical torque from the high-RPM turbine shaft to the front drive axle.
  • 90° Bevel Gearbox & U-Joint: Angled universal joint transfers rotational power up to a top bevel gear stage driving dual counter-phased crank arms.
  • Kinematic Drag Struts: Trailing support struts provide 3-point static stability, preventing aerodynamic pitch-back under high frontal wind drag.
Electromechanical Prototype
Hand-Wound Armature Lorentz Force Neodymium Array Commutator Timing 🎬 Physical Test Video
Brushed DC Motor Prototype
▶

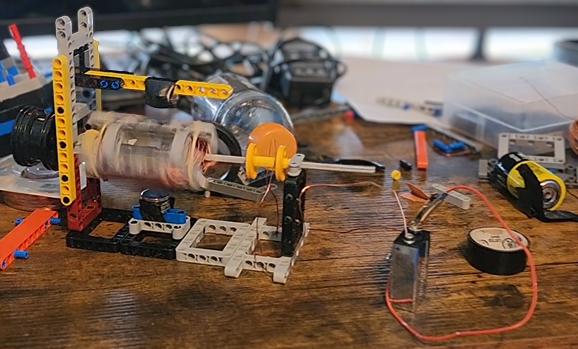
Brushed DC (BDC) Motor Prototype

Designed and assembled a functional brushed DC motor utilizing LEGO Technic for the structural chassis and a hand-wound copper wire armature. The project required micro-positioning of the commutator and brush system to ensure continuous current reversal and consistent torque generation.

⚙️ Electromechanical Highlights
  • Lorentz Force Rotor: Hand-wound magnetic coil armature situated inside a permanent magnetic field.
  • Stability Tower & Contacts: Spring-tensioned copper brush contacts aligned with commutator split rings.
🔧 Challenges & Iterations
  • Flux Density: Swapped initial wiring for high-conductivity enamel magnet wire to increase coil density.
  • Field Calibration: Tested multiple neodymium magnet array configurations to maximize RPM without stalling.
Virtual Automotive CAD
Piston Drivetrain Double Wishbone Suspension Universal Joints
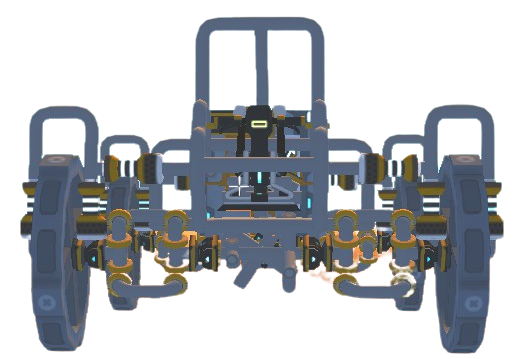
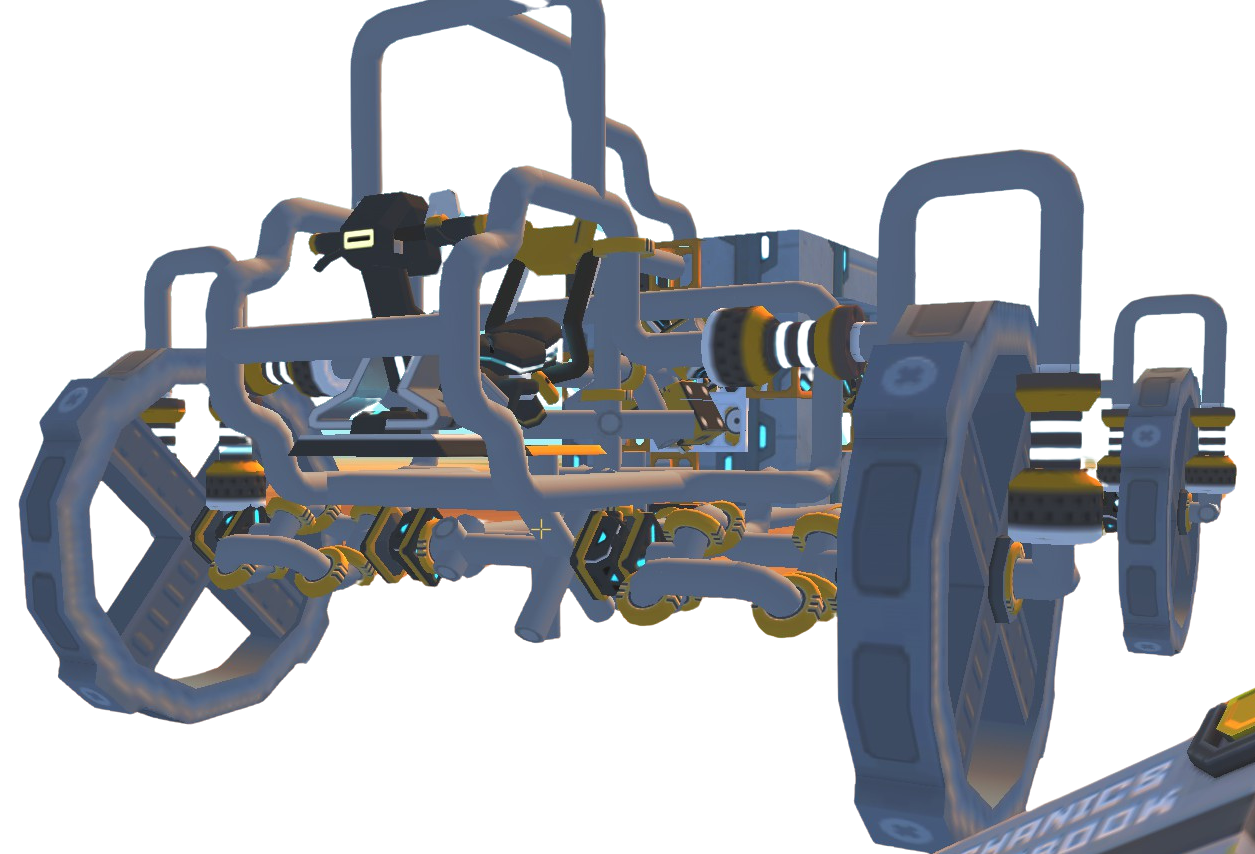
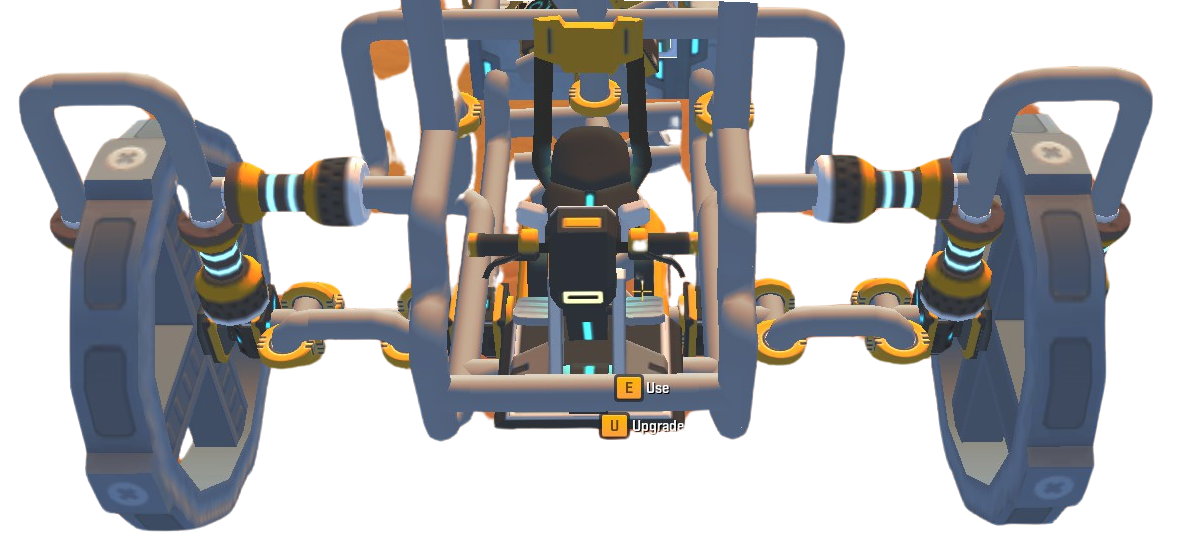
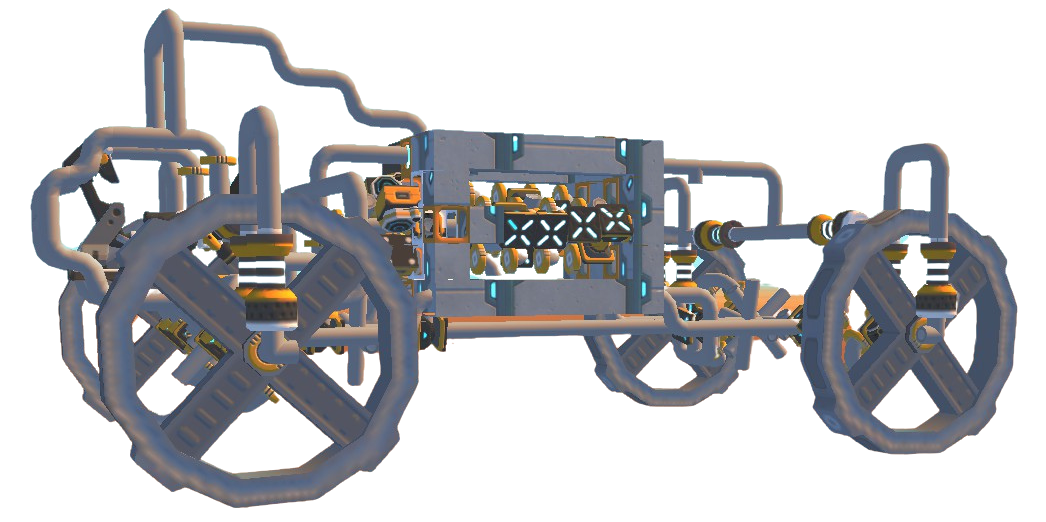
Mechanical Automotive Chassis CAD - Front View

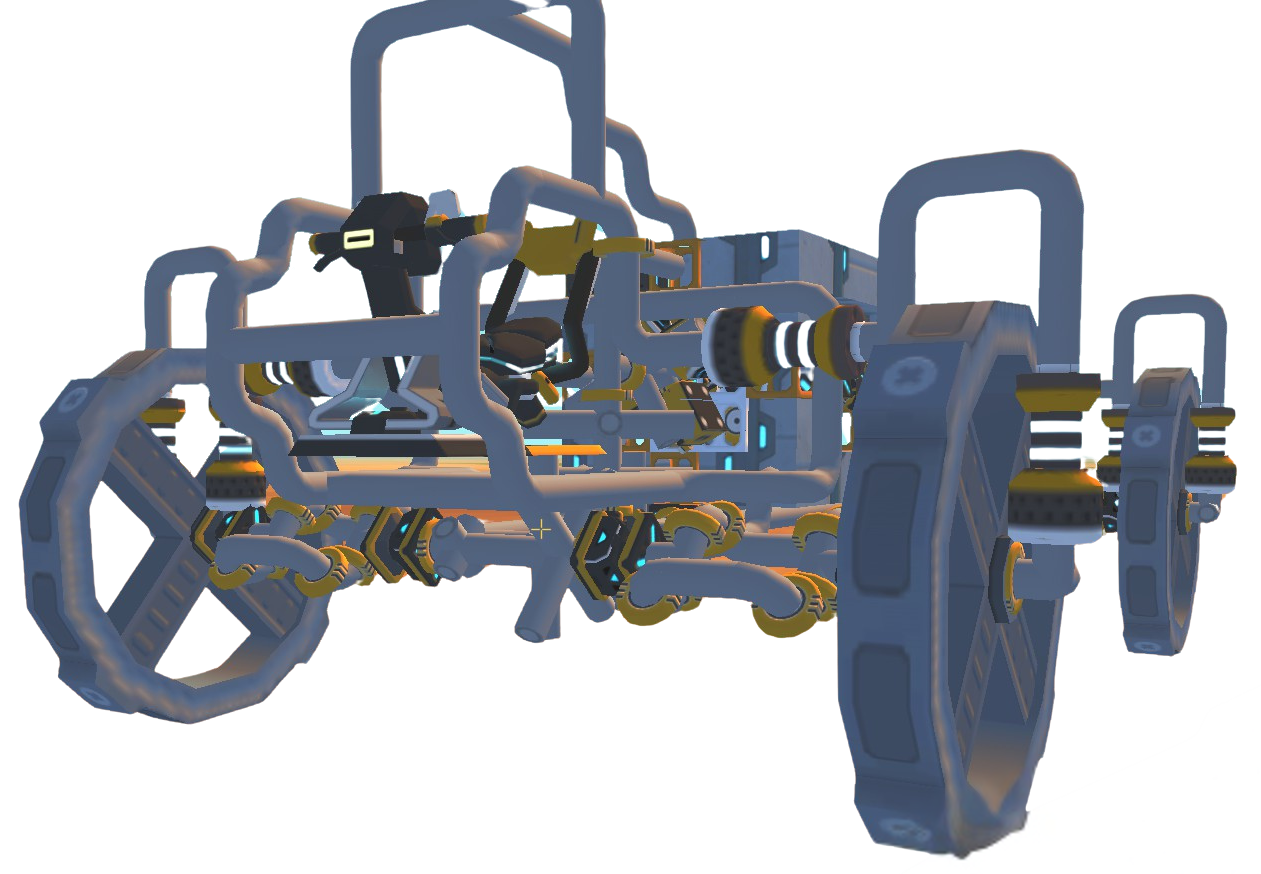
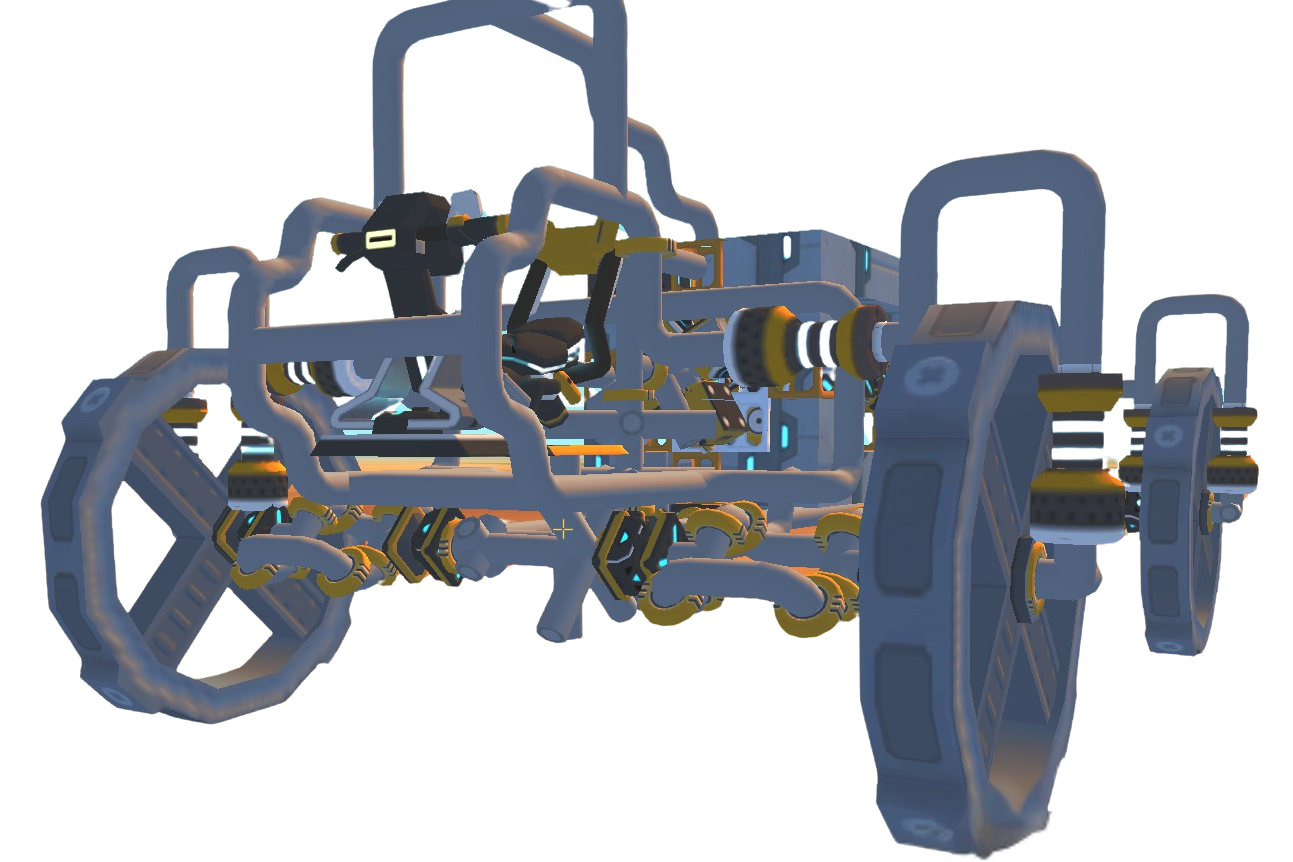
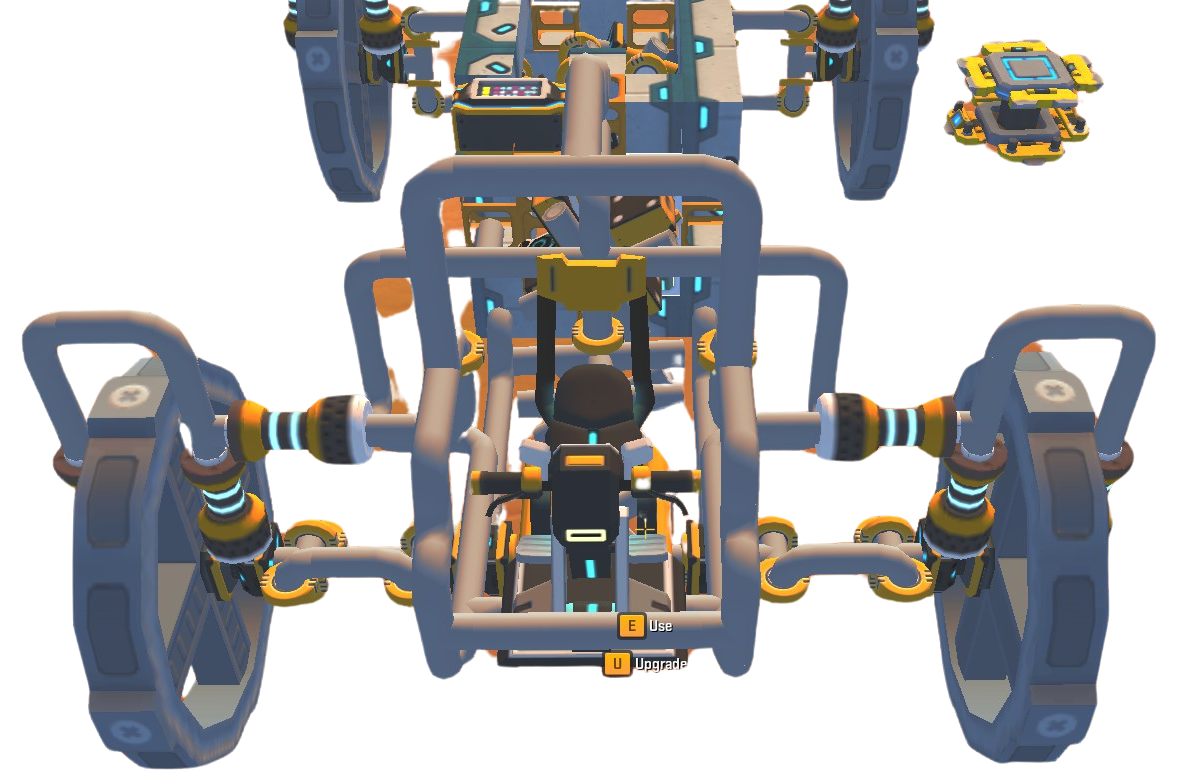
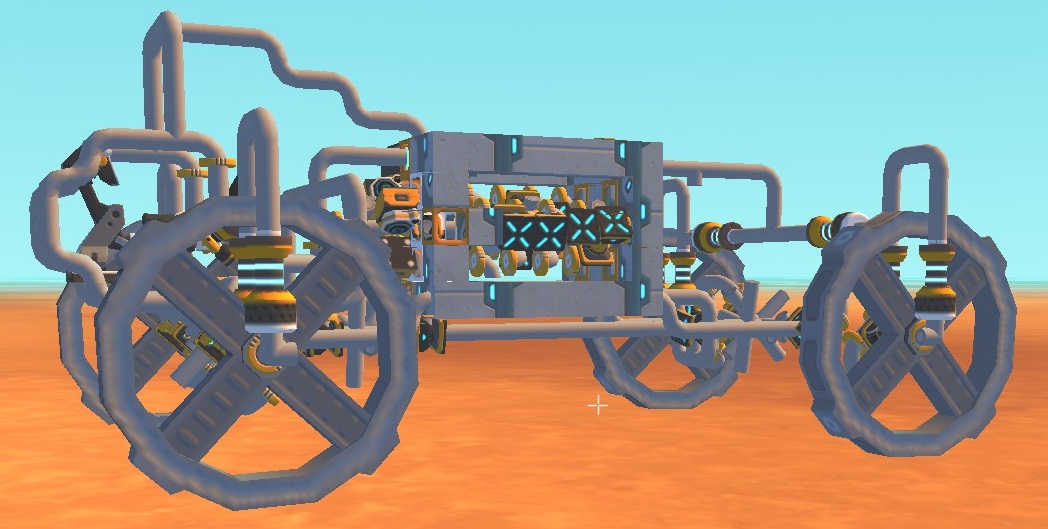
Mechanical Automotive Chassis & Drivetrain

Engineered a complete vehicle chassis integrating a central custom piston engine, independent suspension linkages, and universal joint drive shafts. Designed to test torque transfer during uneven terrain deflection.

⚙️ Sub-System Architecture
  • Universal Joint Transmission: Accommodates angular displacement between the differential and wheel hubs under suspension travel.
  • Independent Damped Suspension: Geometry optimized to minimize body roll and keep tires planted.
🔧 Kinematic Analysis
  • Validated steering knuckle kingpin inclination and Ackerman steering geometry under dynamic wheel turn loads.
Rotational Inertia Prototype
Rotational Inertia Dynamic Symmetry Kinetic Truss Ring Pendulum Drive Hub
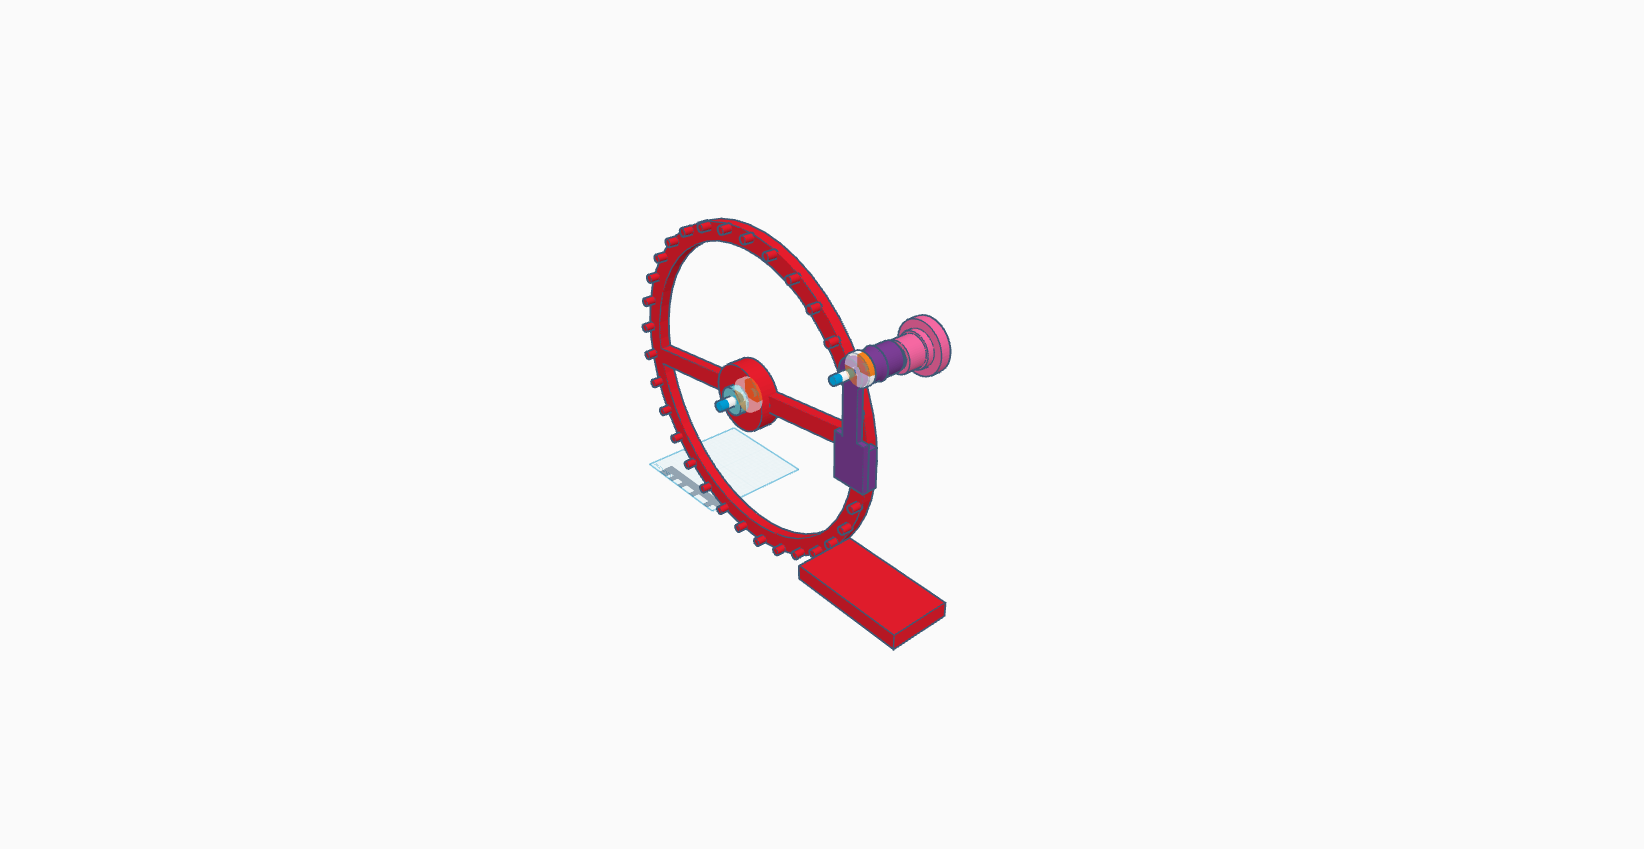
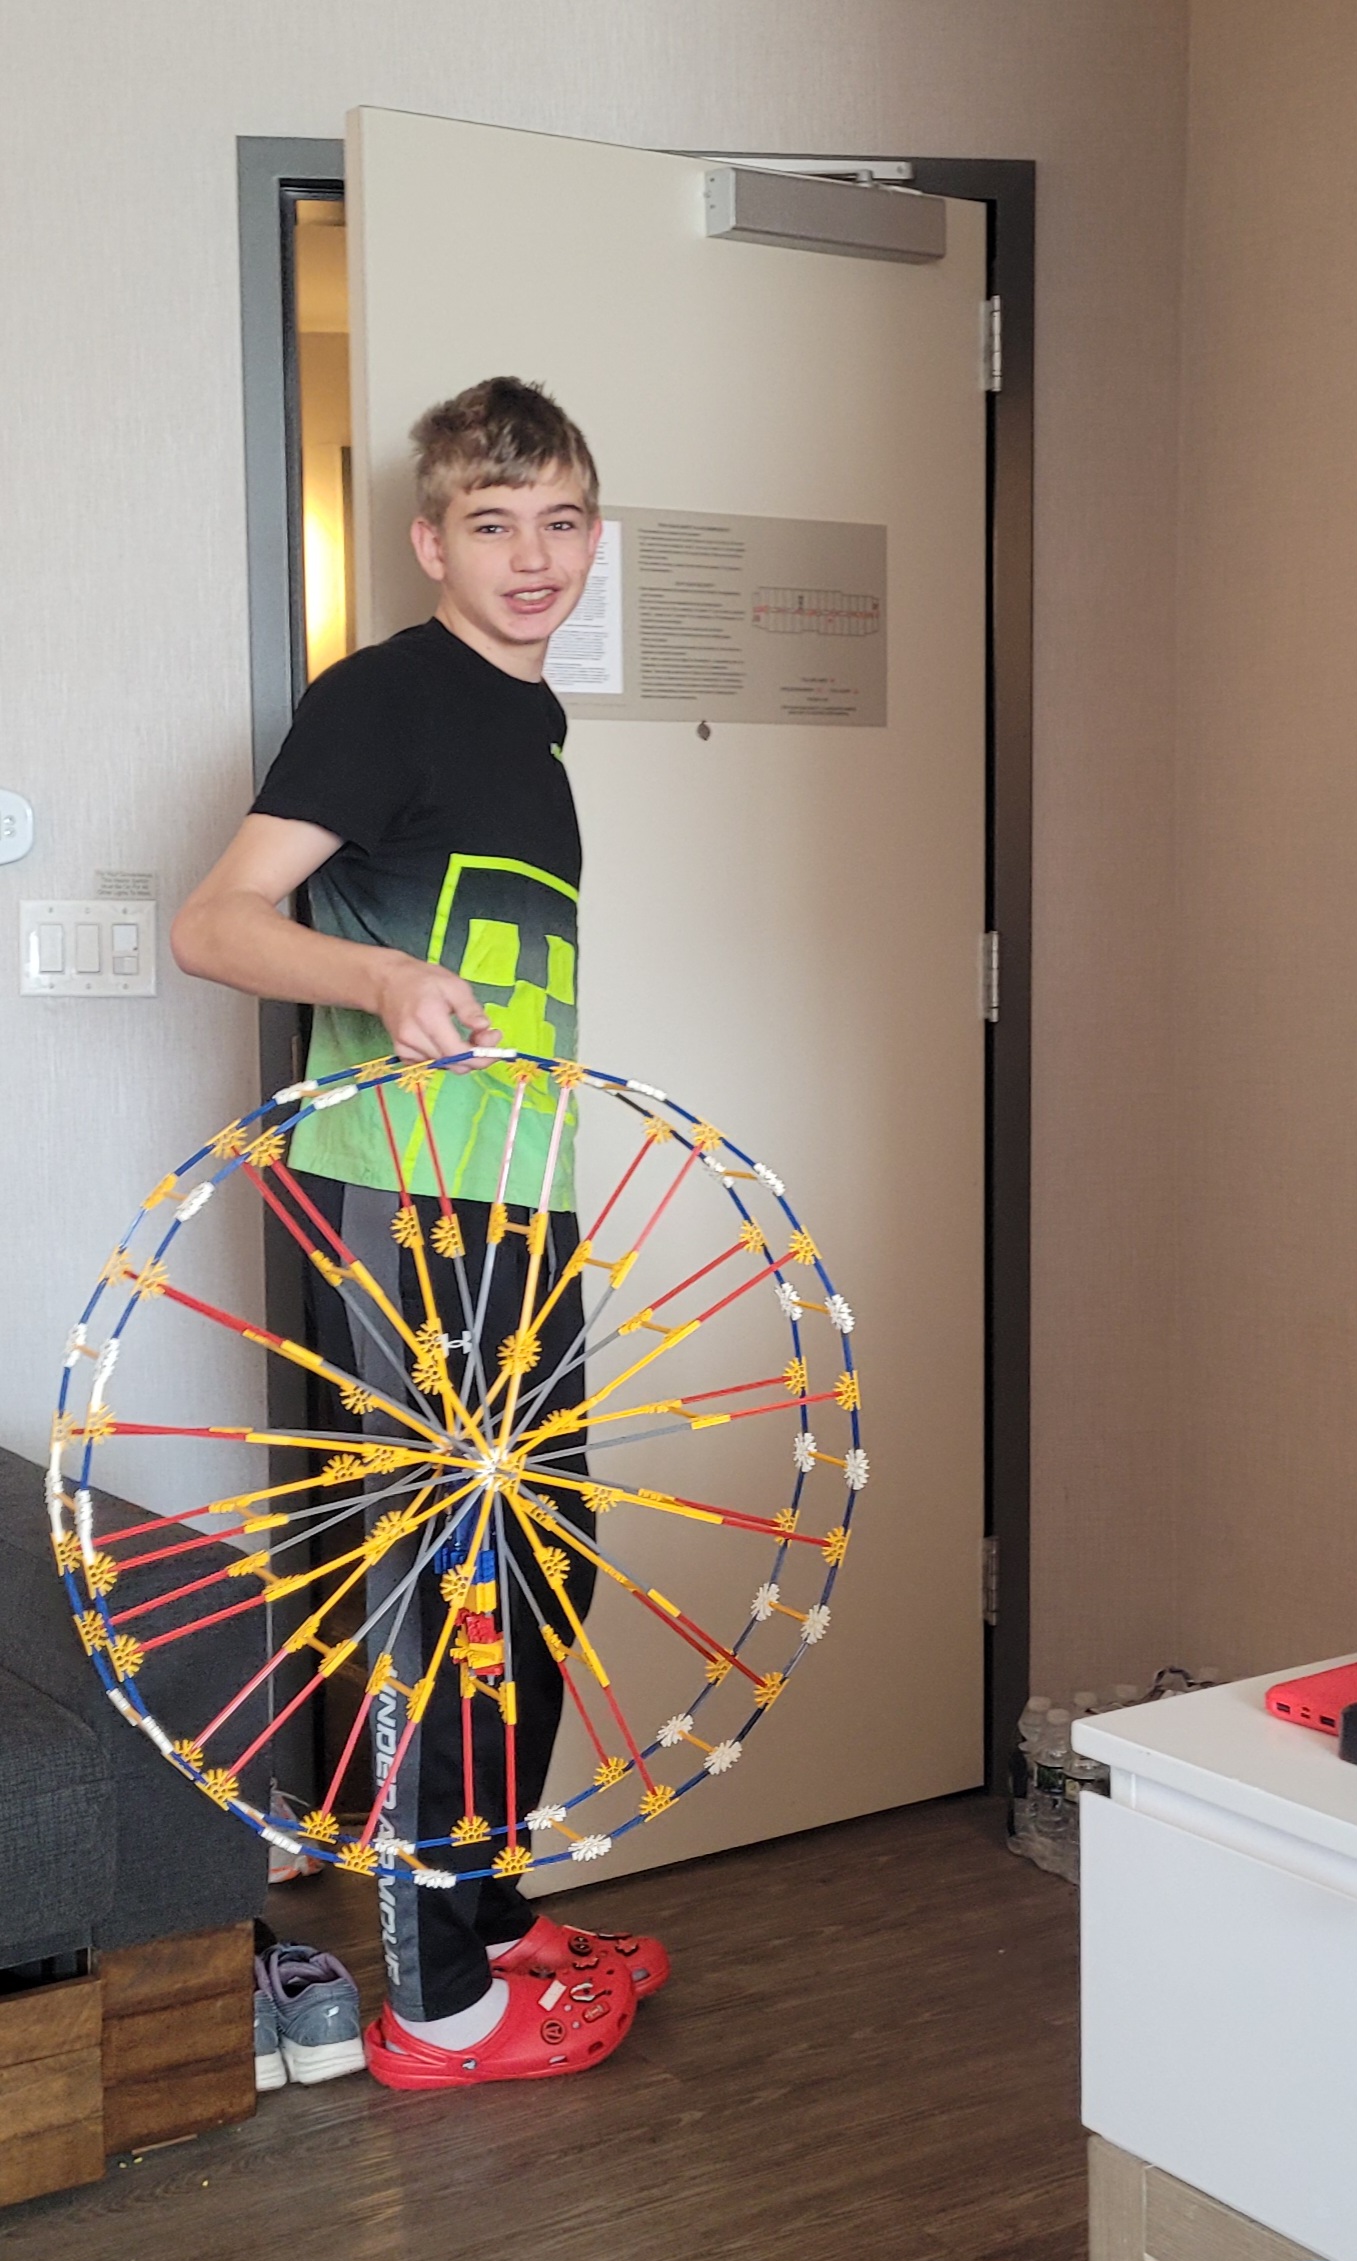
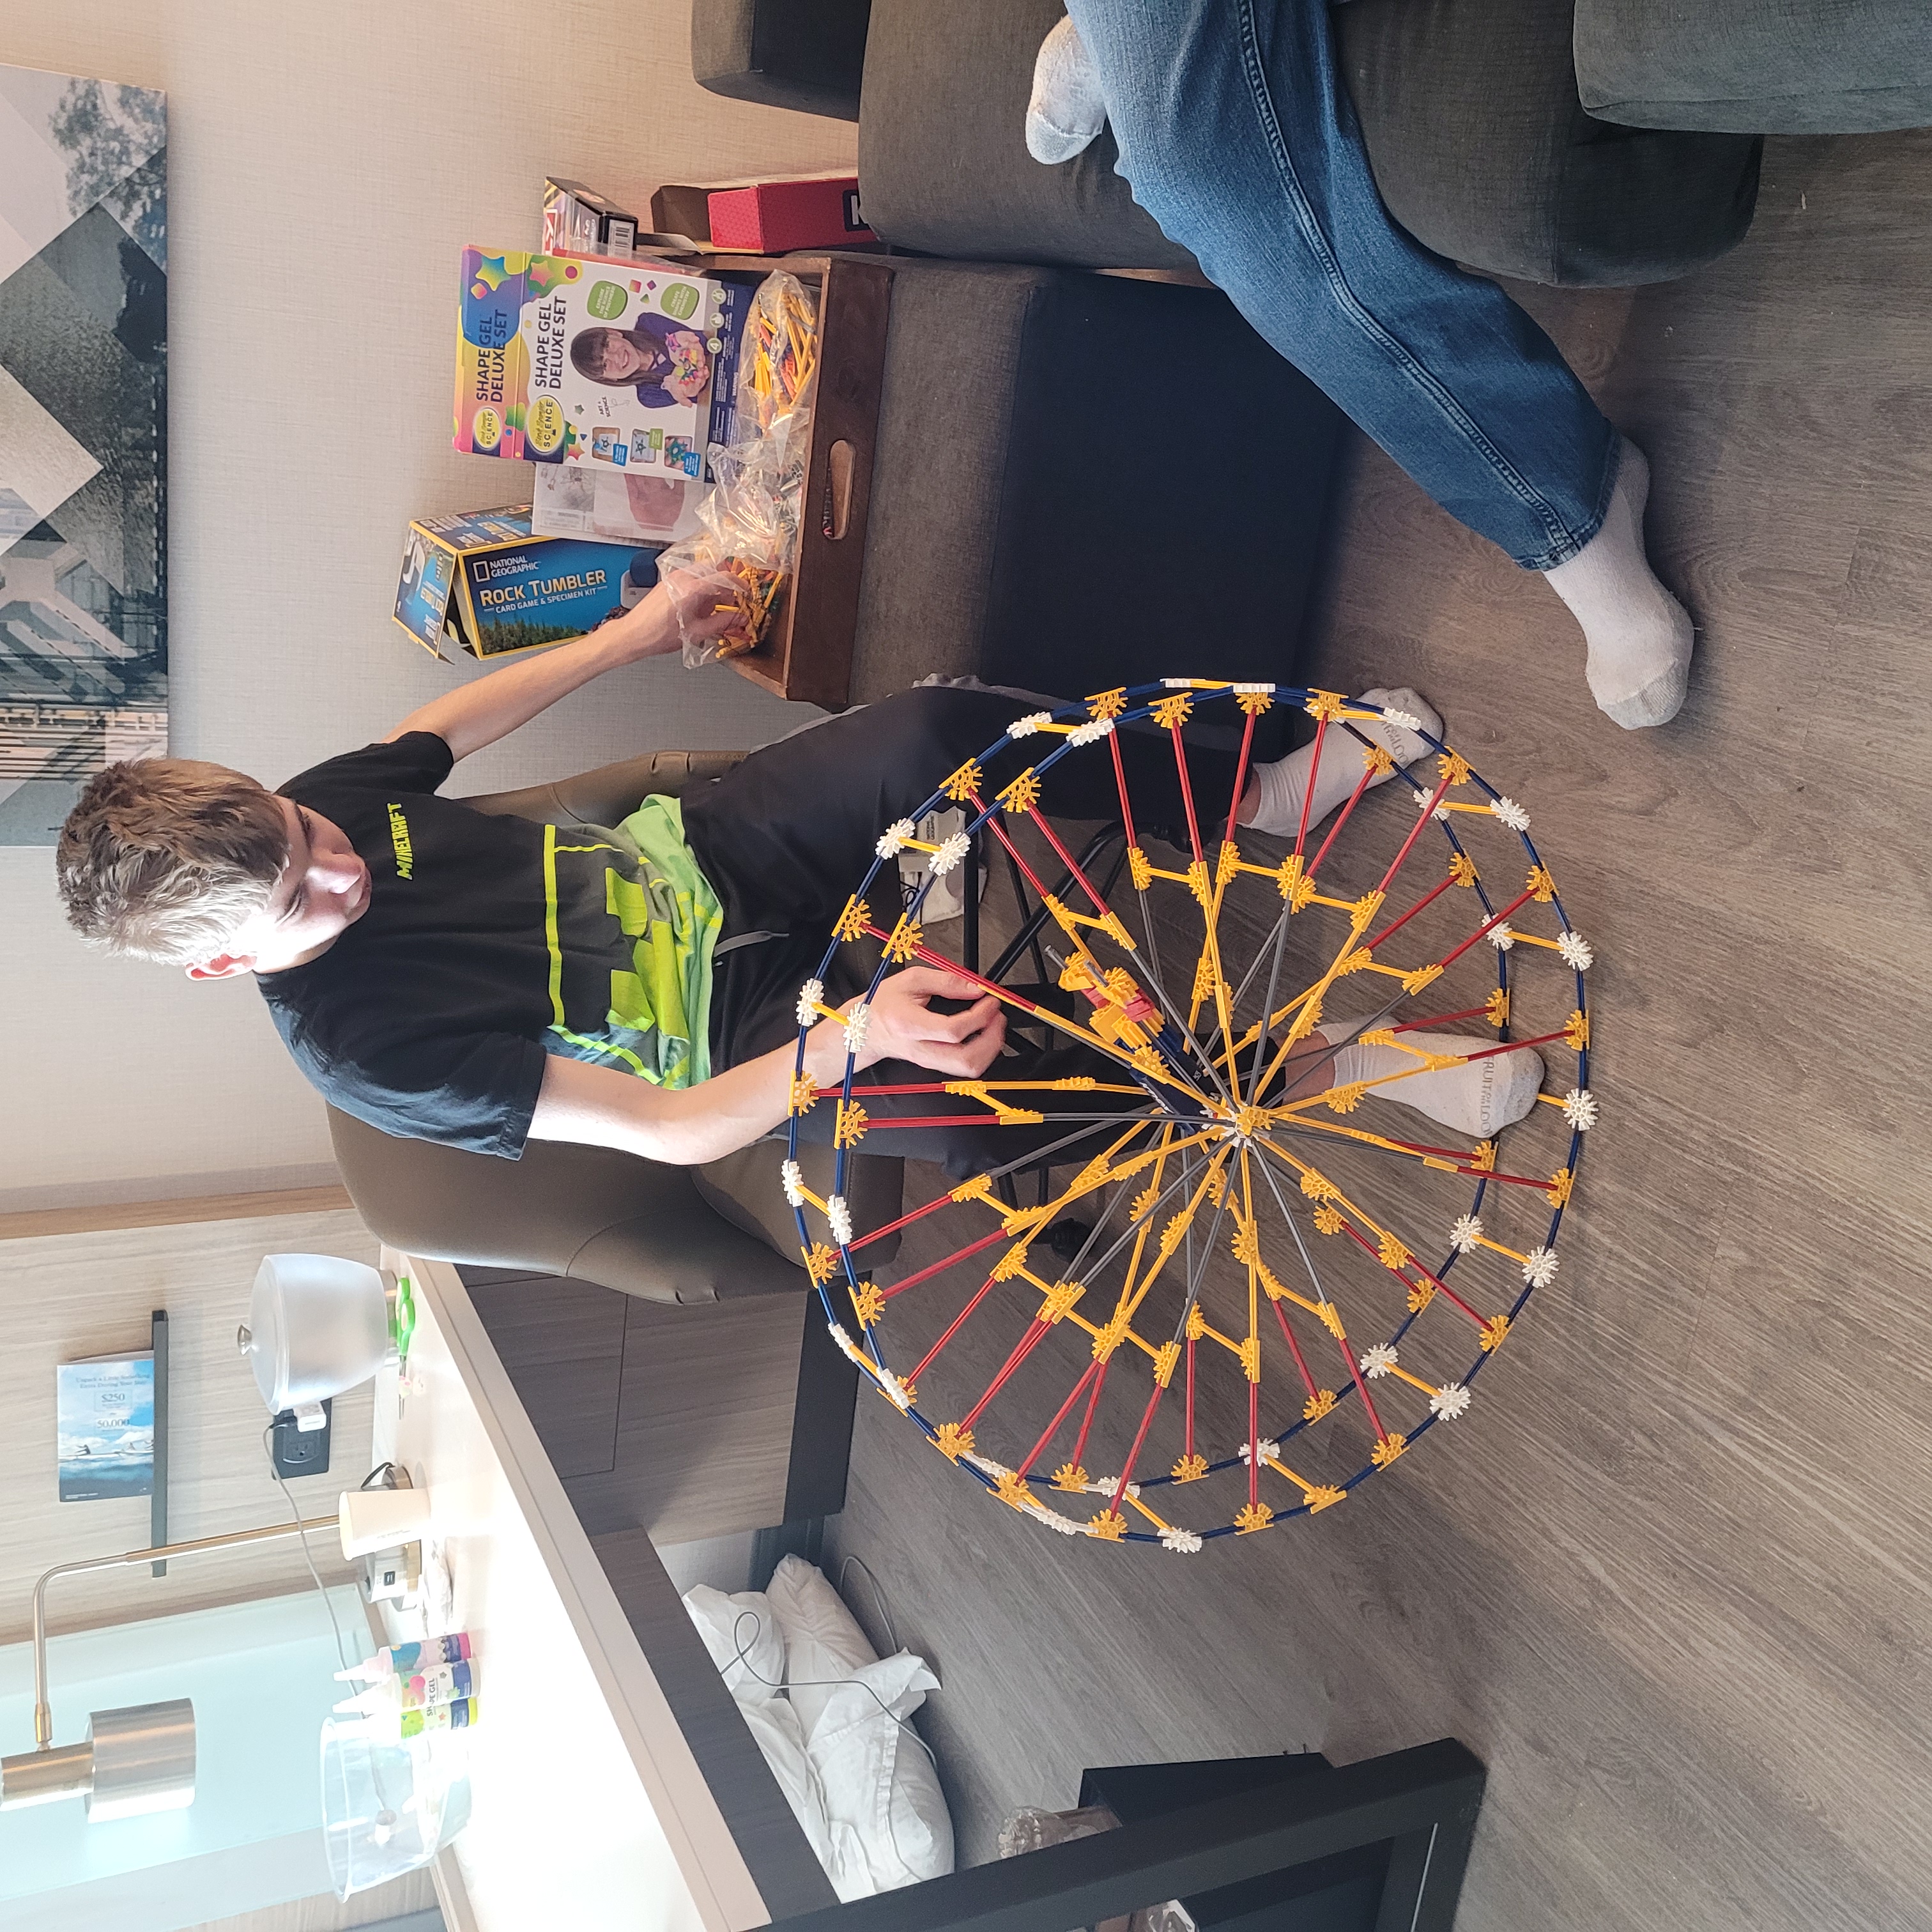
Dynamic Rolling Structure - Full Physical Build
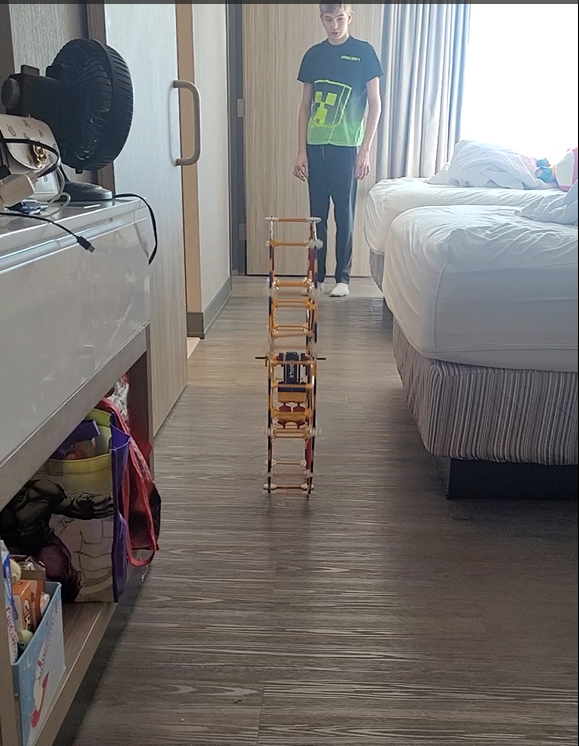
Dynamic Rolling Structure - Hallway Stability Test
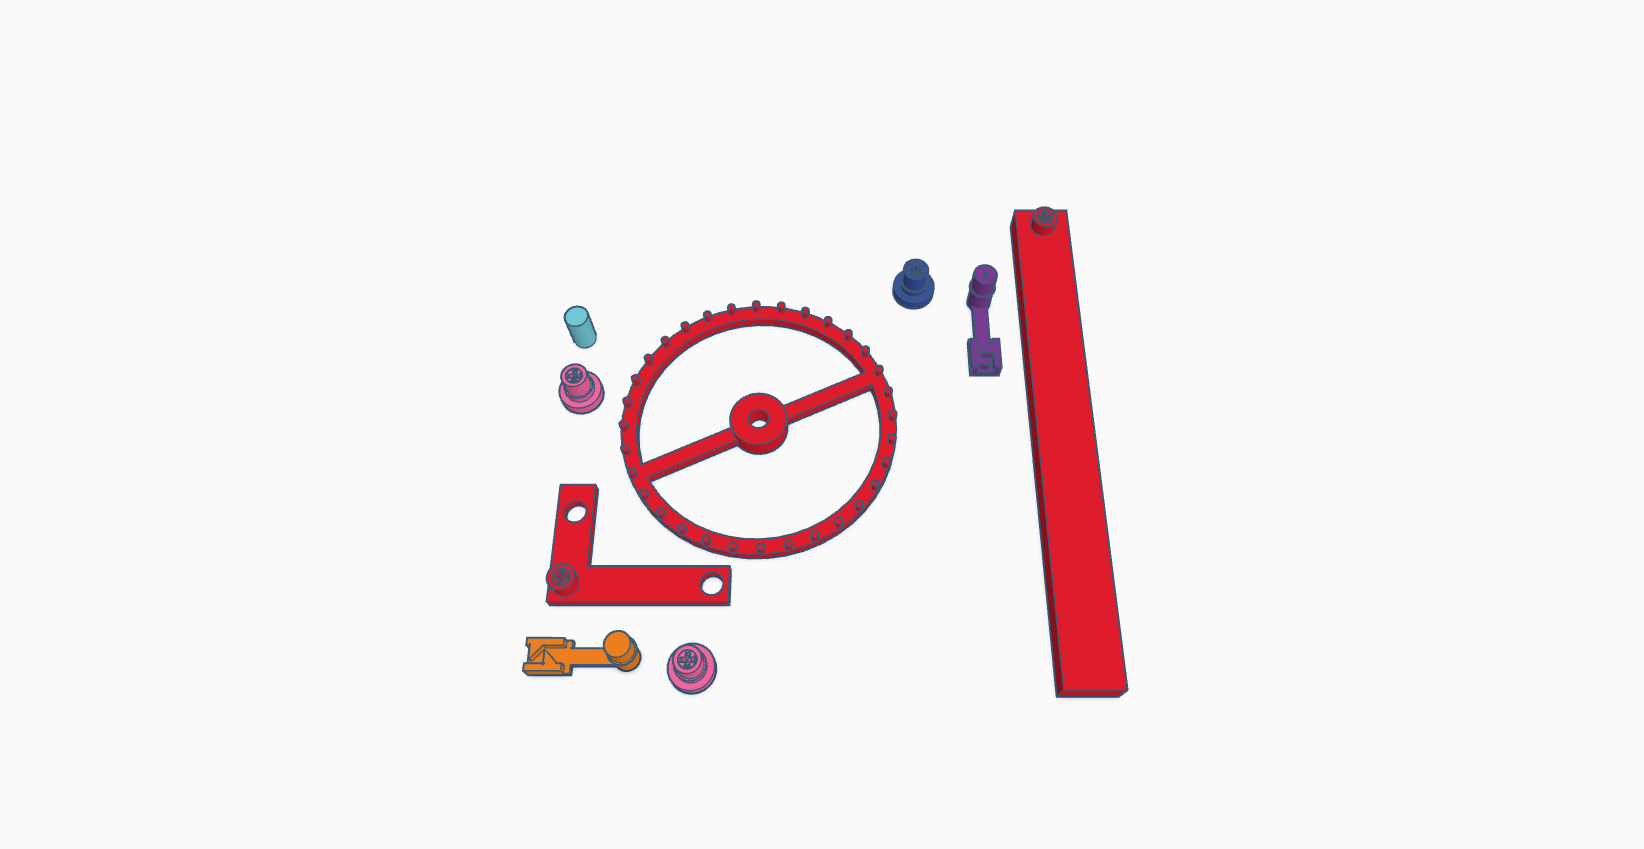
Dynamic Rolling Structure - Radial Truss Assembly
Dynamic Rolling Structure - Internal Motorized Core

Environmental-Stabilizing Dynamic Rolling Structure

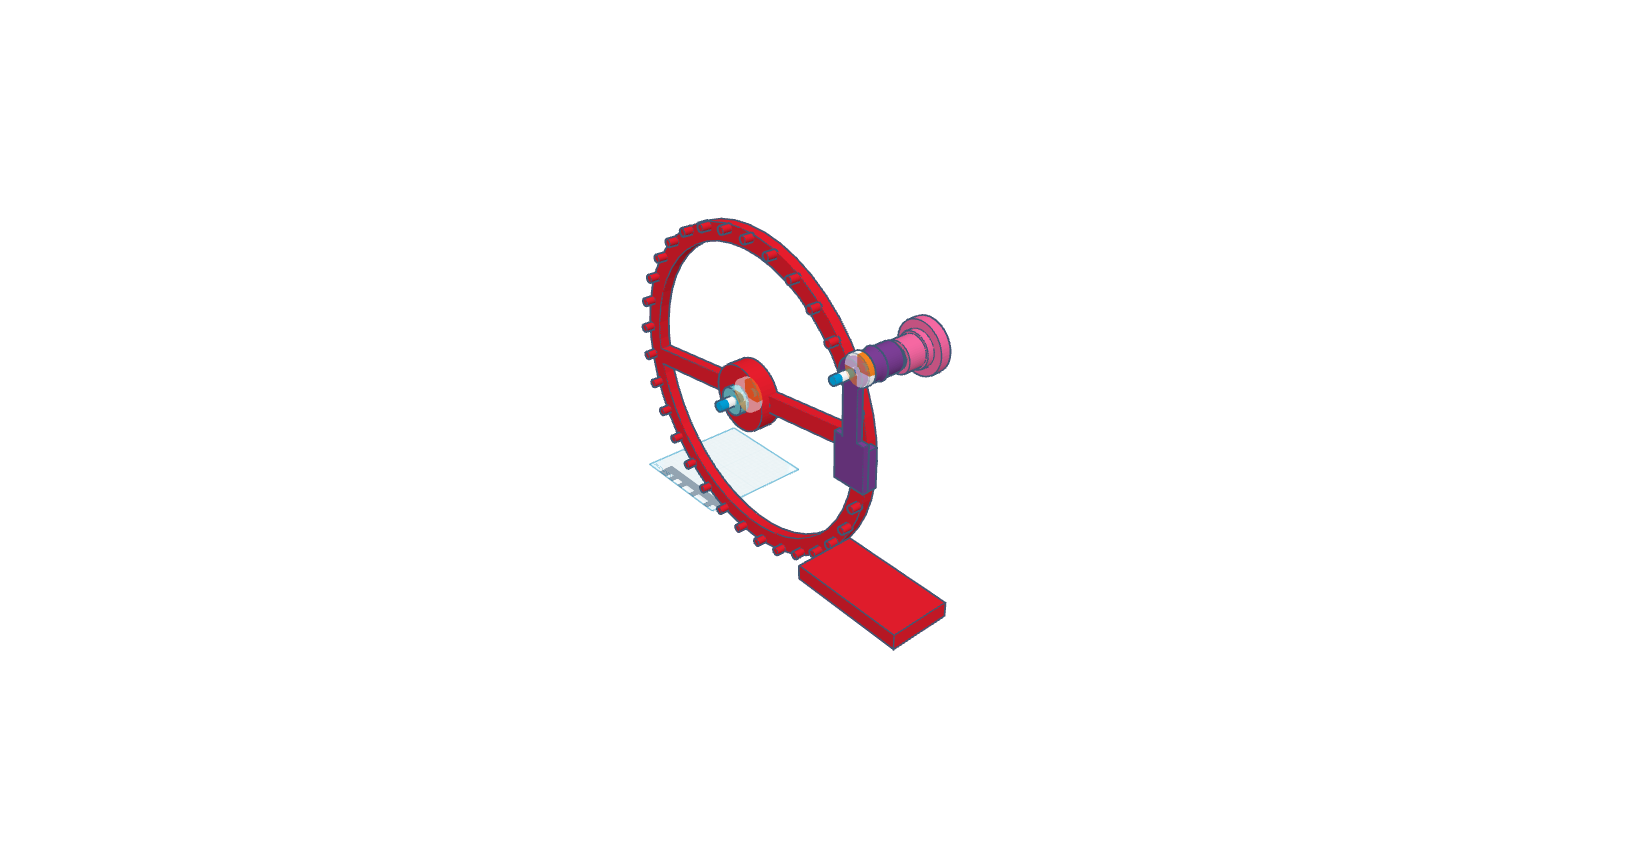
Conceived and engineered a large-scale environmental-stabilizing rolling ring structure. By distributing radial structural truss members symmetrically around a central hub with an internal motorized drive module, the mechanism maintains rotational momentum and self-rights under dynamic perturbation.

⚙️ Structural Dynamics
  • Radial Truss Geometry: Multi-point radial spoke network providing high torsional stiffness against lateral roll forces.
  • Gyroscopic Tendency: Perimeter mass concentration maximizing moment of inertia ($I = m r^2$).
🔧 Internal Drive & Stabilization
  • Suspended Core Module: Integrated an internal motorized pendulum hub suspended within the ring core, lowering the center of gravity and providing active drive thrust.
  • Dynamic Hallway Testing: Physically tested forward roll momentum and angular equilibrium to validate upright self-stabilization.
Fusion 360 CAD
Autodesk Fusion 360 Parametric Solid Modeling Multi-Body Assemblies Observational CAD Studies
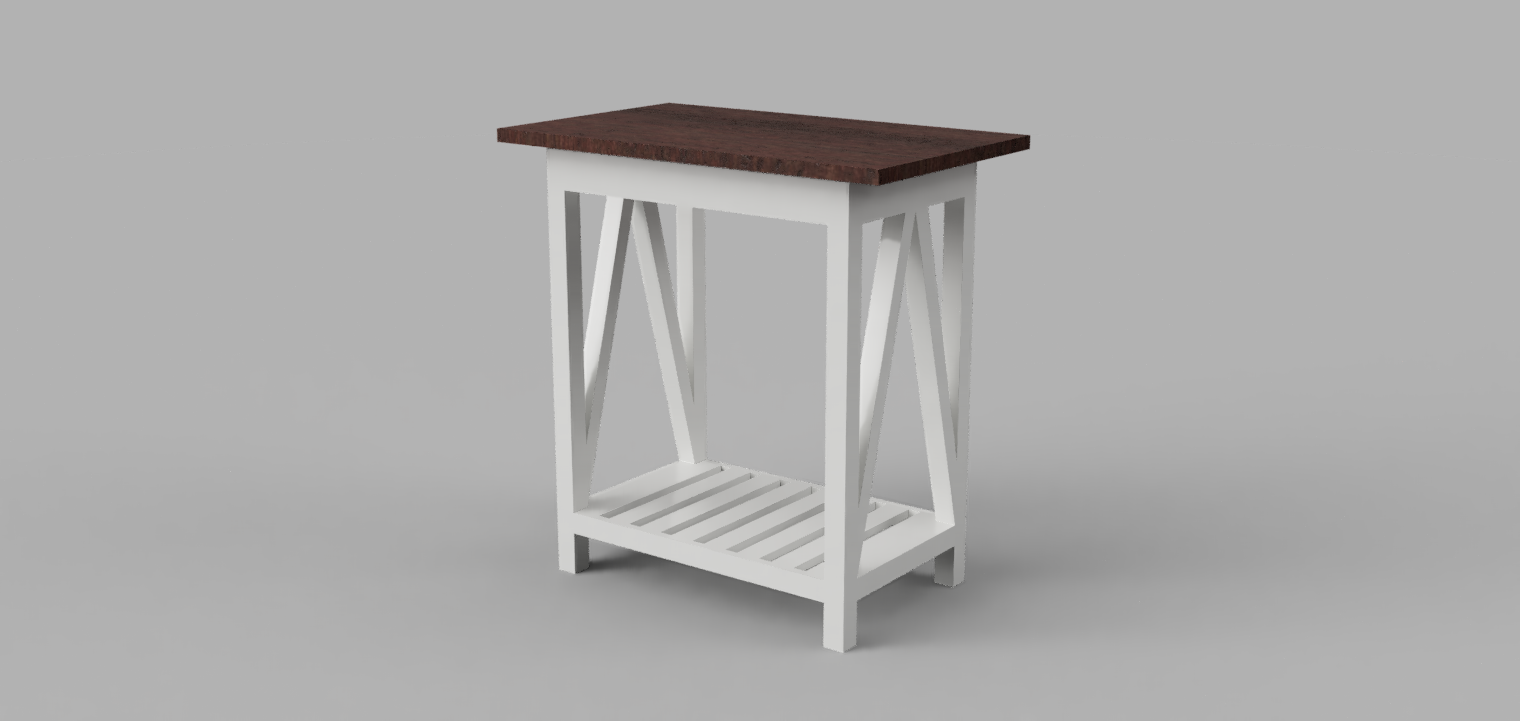
🪵 Console End Table
AUTODESK FUSION 360 STUDIES
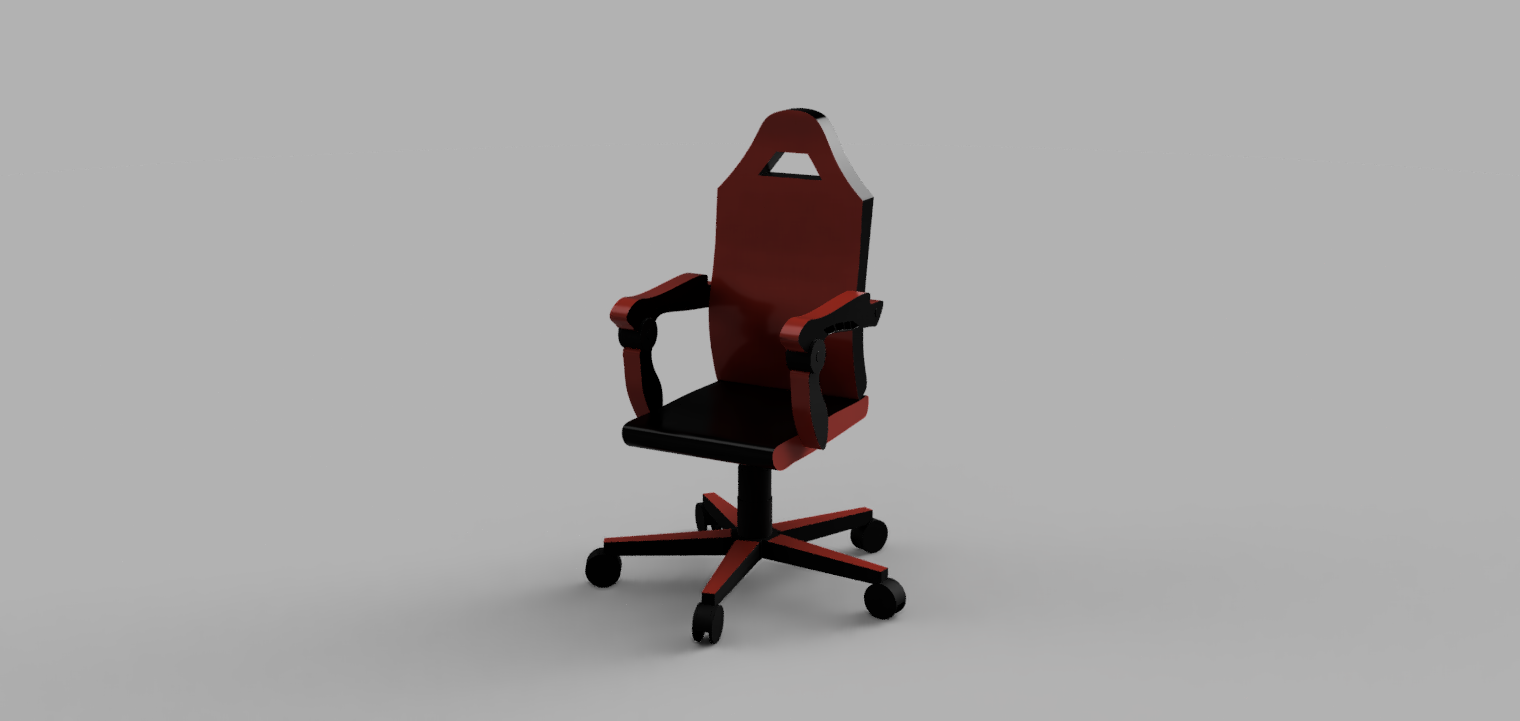
💺 Ergonomic Chair
Console End Table 3D CAD Model - Autodesk Fusion 360 🪵 Console Table
Ergonomic Chair 3D CAD Model - Autodesk Fusion 360 💺 Ergonomic Chair

Fusion 360 Design: Observational CAD Studies

Applied advanced 3D solid modeling in Autodesk Fusion 360 to execute observational CAD reverse-engineering studies of complex everyday objects. Inspired by real-world physical furniture, these digital studies focus strictly on CAD craftsmanship and parametric technique: reconstructing complex physical geometry from visual observation into fully constrained 2D sketches, organic ergonomic contours, and multi-body solid assemblies without relying on external blueprints. Featured models include a multi-component ergonomic chair assembly with contoured lumbar support and 5-point caster base, alongside a craftsman-style console end table featuring angled truss cross-bracing and a lower slatted shelf.

⚙️ Parametric CAD Architecture
  • Fully Constrained Sketching: Recreated observed proportions using parametric 2D profiles with geometric constraints (tangency, symmetry, perpendicularity) for dynamic dimension scalability.
  • Multi-Body Assemblies: Structured complex assemblies into distinct components (swivel star base, gas cylinder, contoured backrest, armrest brackets, table cross-braces, and slatted shelf).
📐 Observational Reverse-Engineering
  • Ergonomic Curvature & Proportion: Modeled compound curves, lumbar fillets, and frame structural ratios purely from visual observation, achieving high dimensional harmony.
  • Material Finish & Rendering: Applied physical appearance materials (wood grain textures, matte and gloss polymers, and metallic finishes) with custom environment lighting in Fusion 360's render workspace.

Engineering Skills & Toolchain

Interdisciplinary capabilities spanning computer-aided design, additive prototyping, electromechanical assembly, digital twin simulations, and kinematic optimization.

📐

CAD & Modeling

Autodesk Fusion 360 TinkerCAD Parametric Modeling Assembly Mates & Joints Tolerance Analysis (0.22mm) Wireframe Modeling Exploded Assembly Views
🖨️

Additive & Fabrication

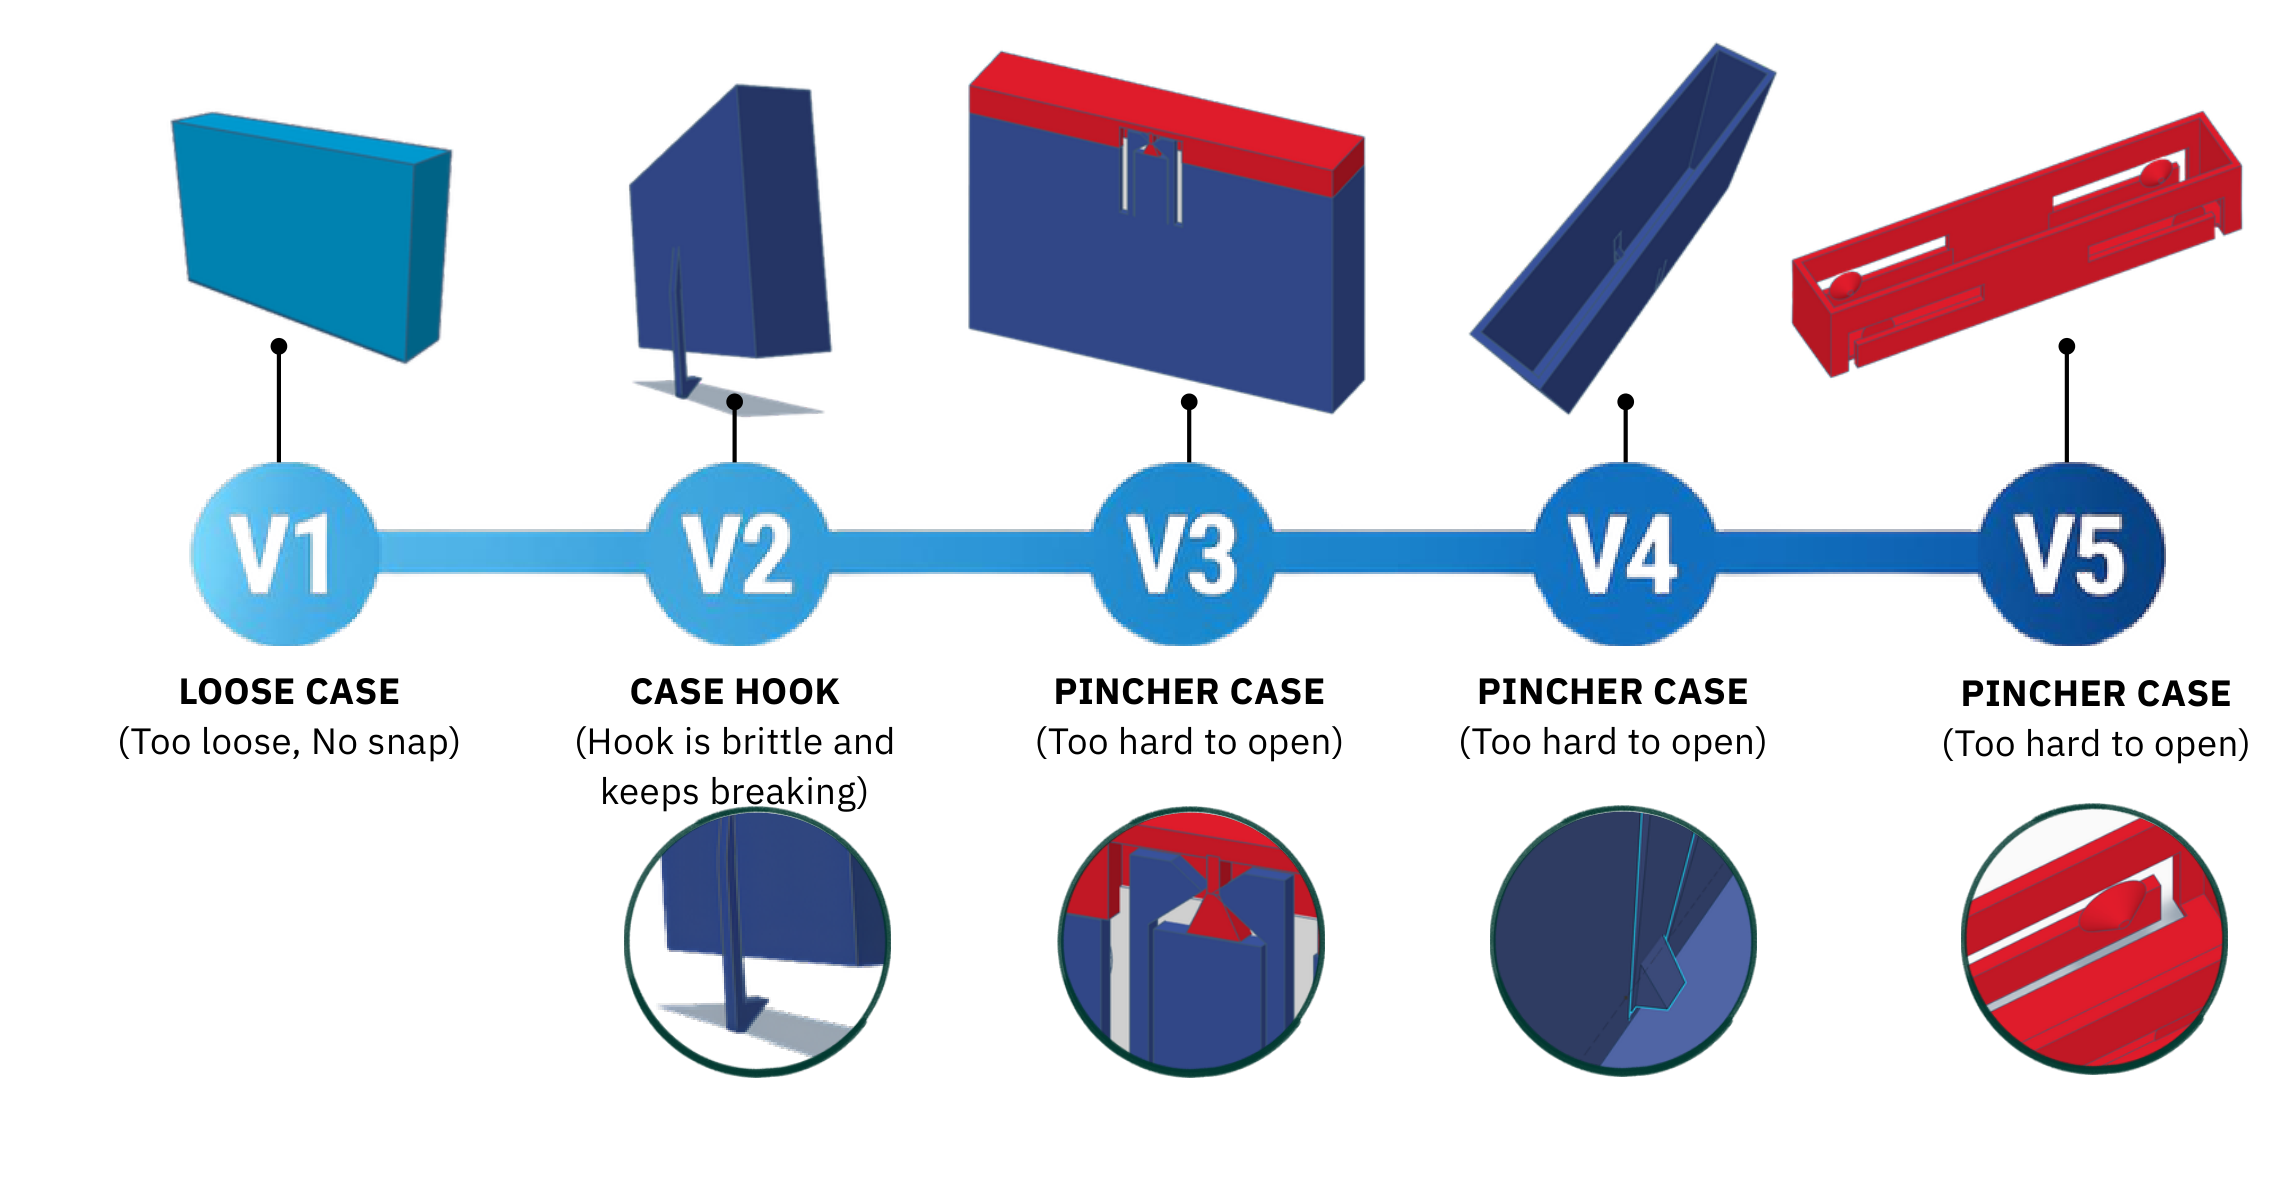
Creality Ender 3 V3 KE FDM Slicing & Cura PLA & Composite Materials Cantilever Snap-Fits Friction-Fit Assemblies Woodworking & Joinery Makerspace Machine Tools
⚙️

Kinematics & Mechatronics

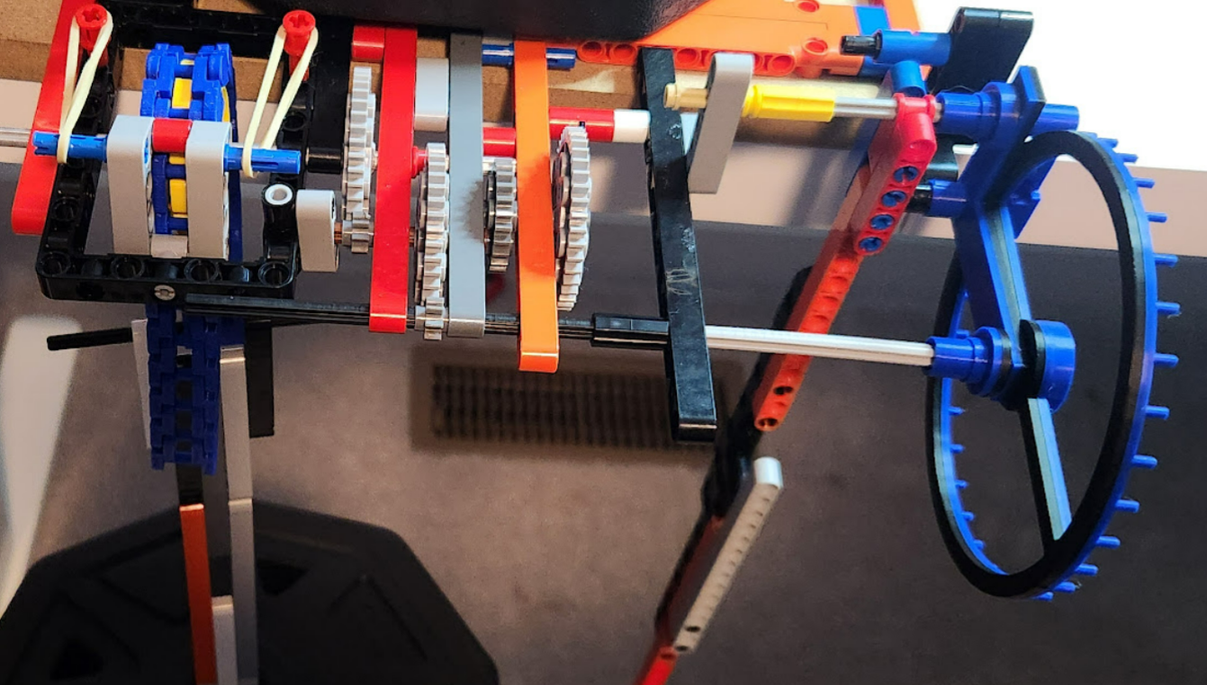
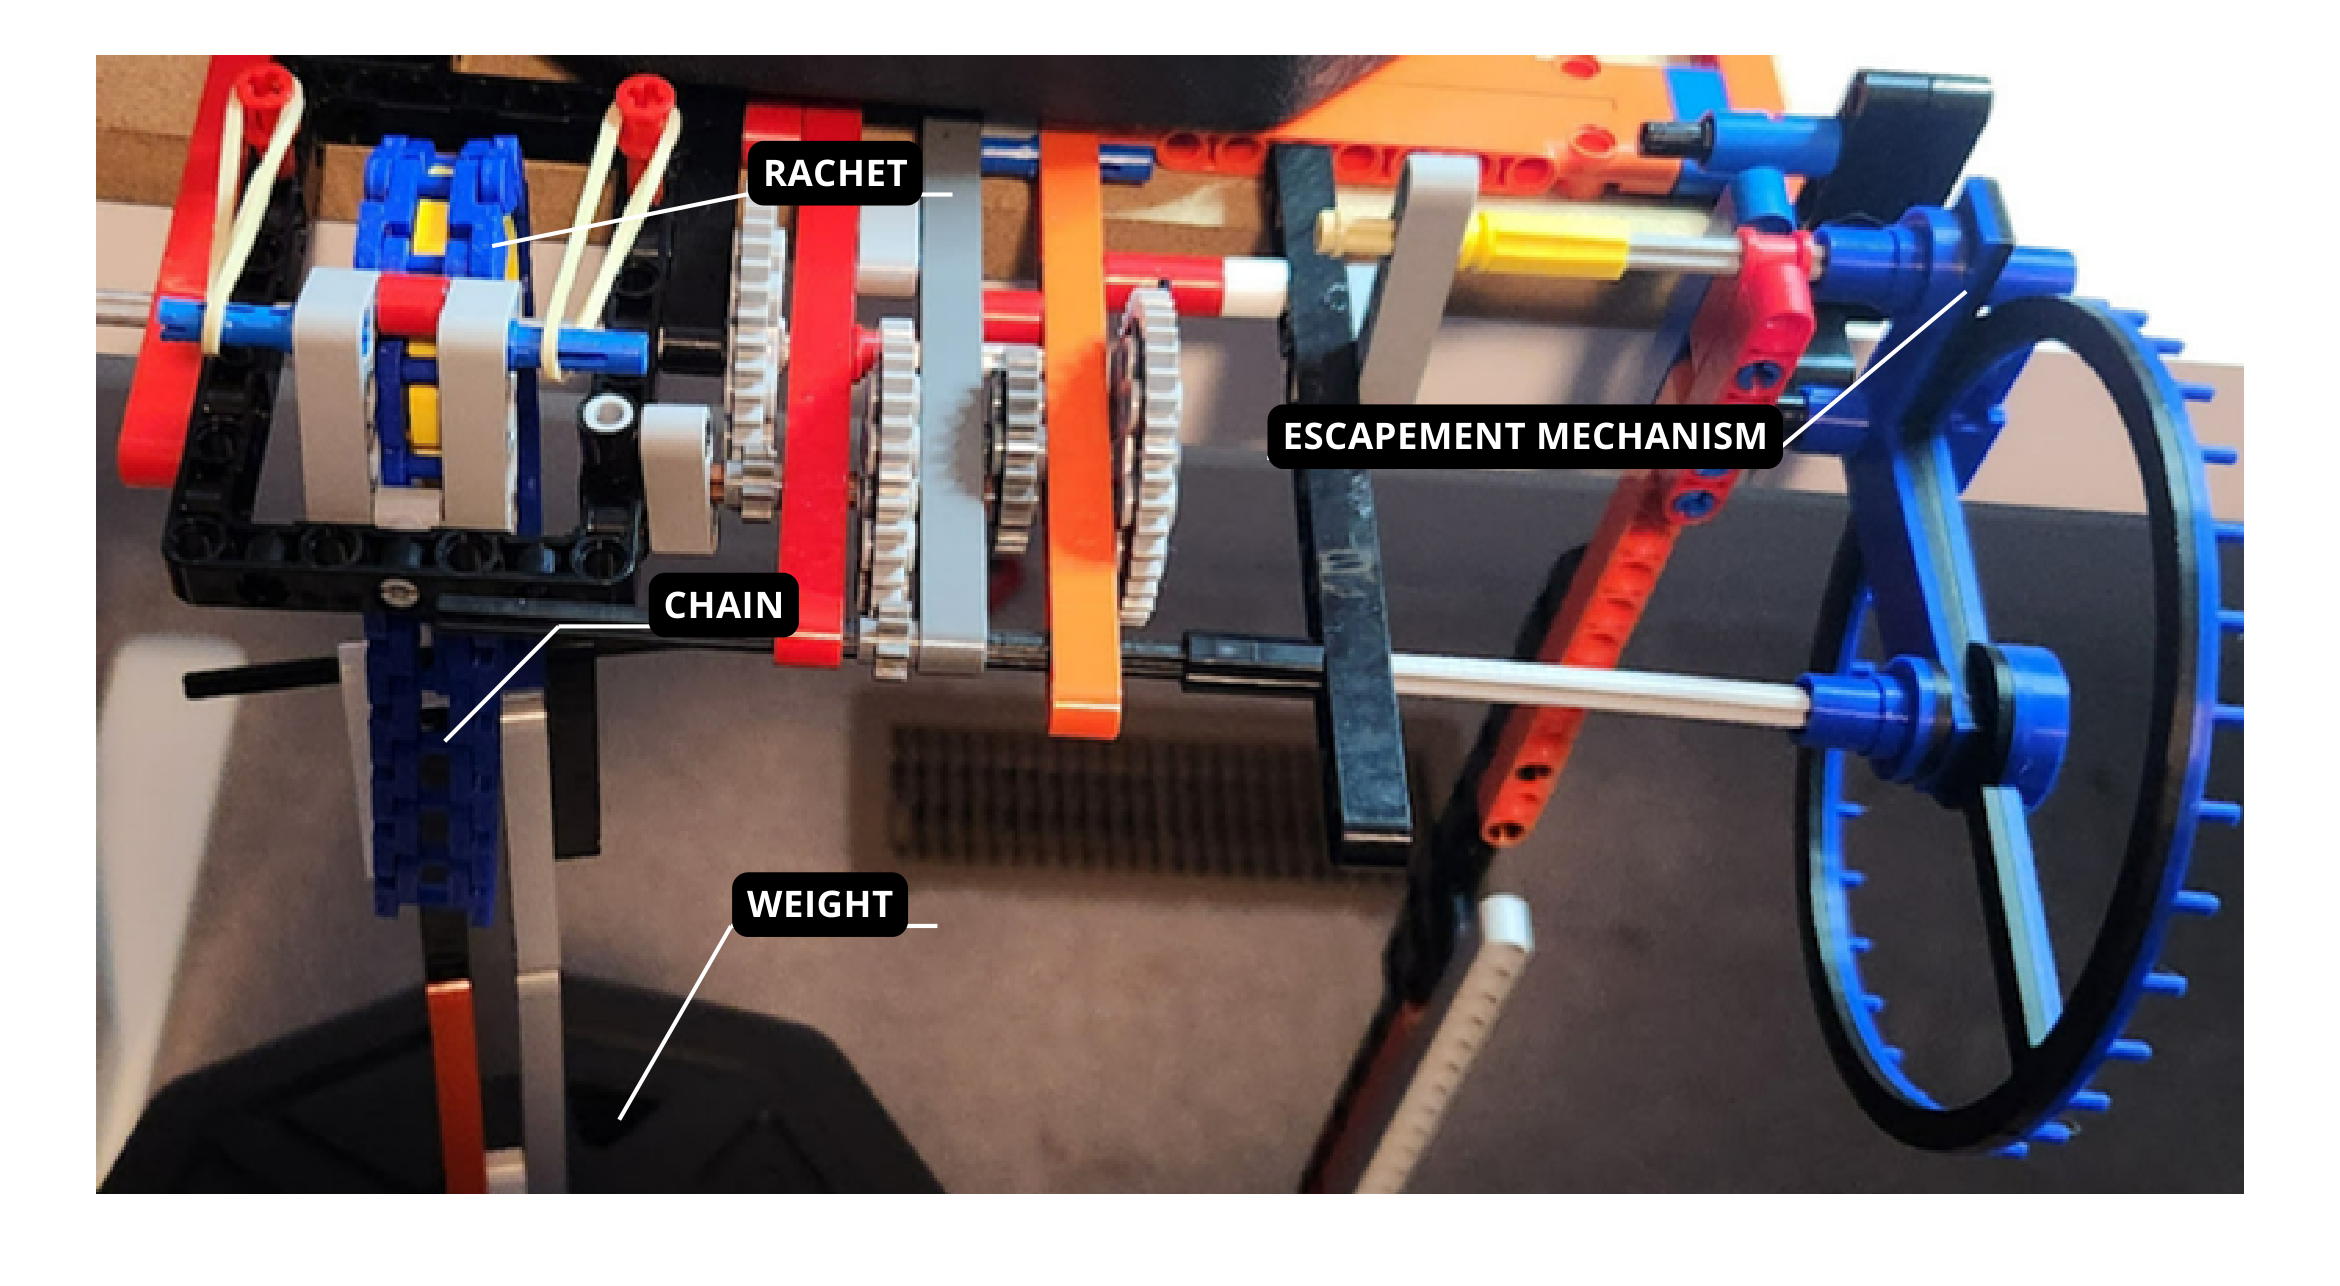
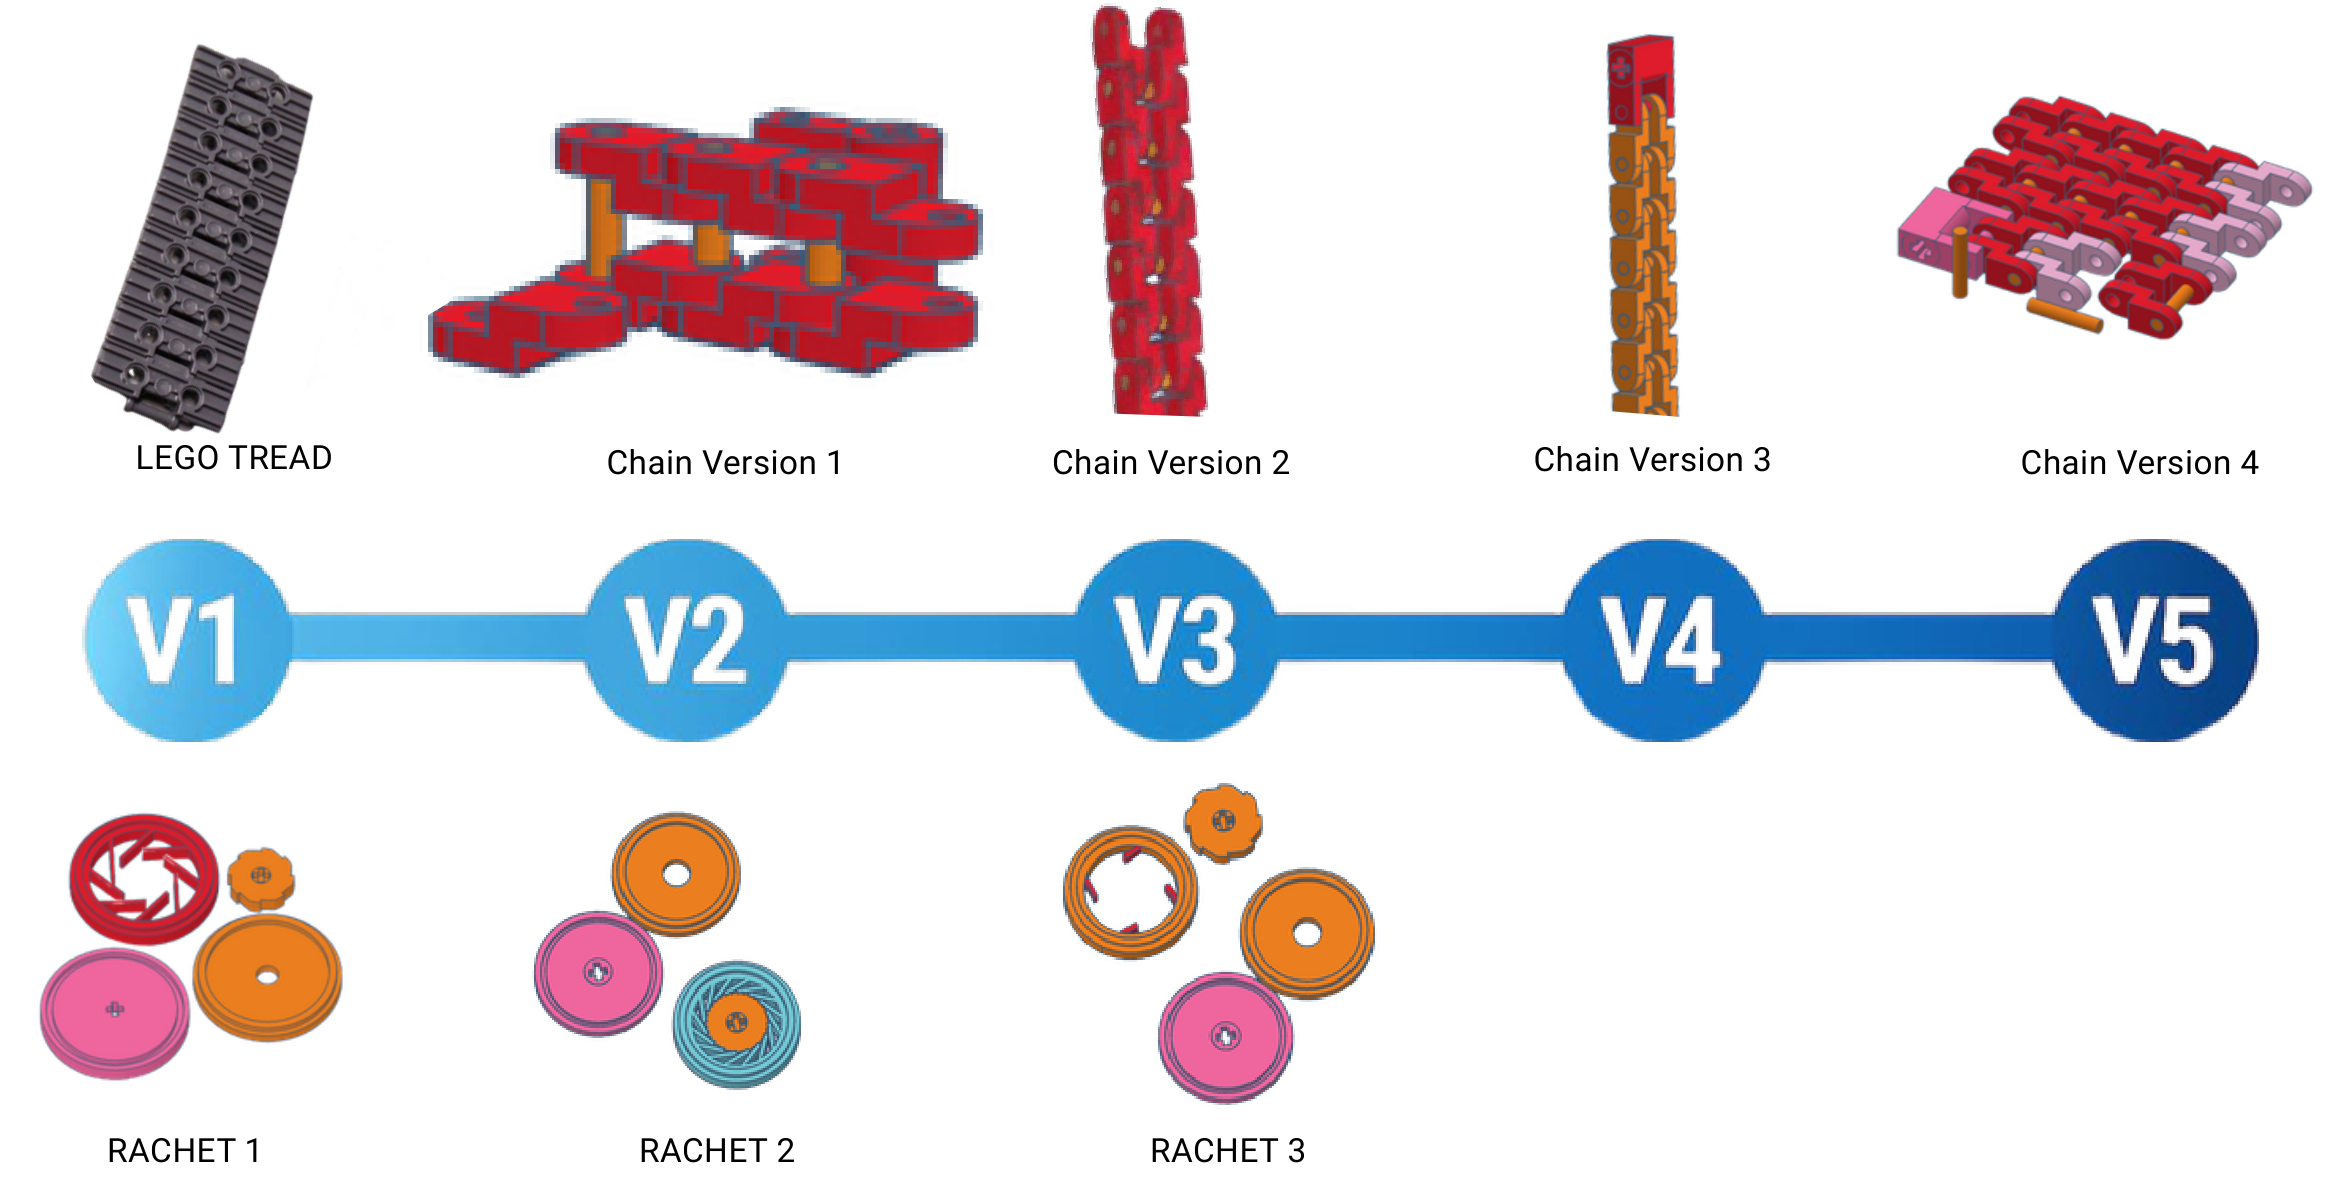
Escapements & Clockwork Ratchet & Pawl Drivetrains Gear Trains & Backlash Brushed DC Motor Design Armature Winding Universal Joint Mechanics Multi-Axis Actuation
🌌

Virtual Simulation

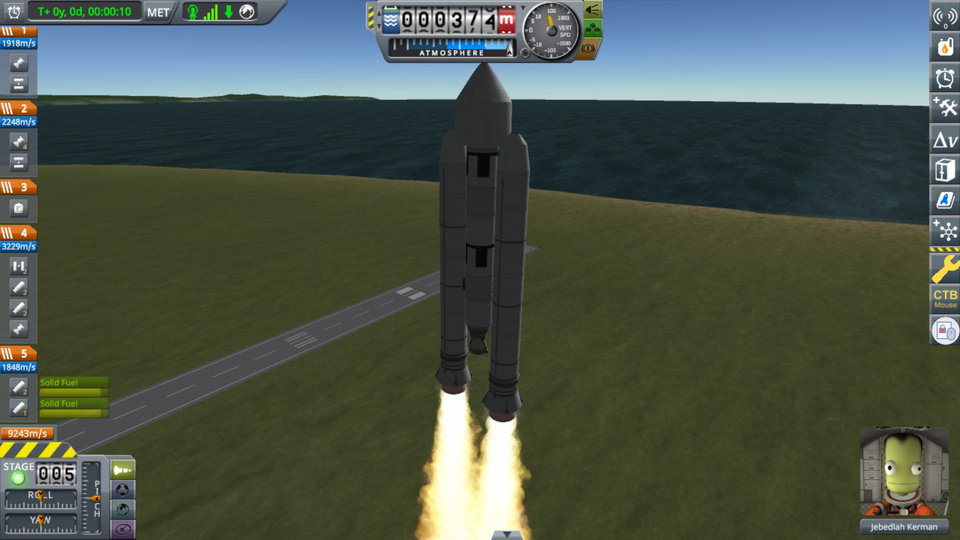
Digital Twin Workflows Kerbal Space Program (KSP) Scrap Mechanic Physics 70+ Piston Engine Designs TWR & ΔV Optimization Orbital Staging Profiles Gravity Turn Mechanics
⚡

Logic & State Control

Boolean Logic (AND, OR, XOR) State Machine Architecture Sequential Micro-Timing Hexapod Dynamic Walking Gait Sensor Feedback Loops Geyser/PaperMC Automation
🔬

Engineering Methods

Failure Point Identification Rapid Iterative Prototyping Requirement Analysis Center of Gravity Tuning Fluid Dynamics (Propeller Pitch) Inertia & Momentum Balance

Let’s Build Something Remarkable

Whether you’re interested in collaborating on mechanical engineering projects, discussing prototype design, or exploring engineering opportunities, feel free to reach out directly.

✉️
Email
aidenhockinberry@gmail.com